Project - Speed Control of a Direct Current (DC) motor
%Design parameters to a model DC motor
J=0.01; % Moment fo inertia of the rotor in kg-m^2
B=0.1; % Motor Viscos friction constant in N-m-s
Km=0.01; % Back EMF constant in V/rad/s
Kt=0.01; % Motor torque constant in N-m/amp
Ra=1.0; % Resistance of the armature circuit in ohms
La=0.5; % Inductance of the armature circuit in hendries
%PID controller Design parameters A & b Matrices
A=[-B/J Kt/J; -Km/La -Ra/La];
b=[0;1/La];
%placement of poles
fn=1;
wn=6.28; %2*pi*fn
zeta=0.9;
%poles of the system
p1=-zeta*wn+wn*sqrt(zeta^2-1);
p2=-zeta*wn-wn*sqrt(zeta^2-1);
P=[p1;p2];
%placement of poles
K=place(A,b,P);
Kp=K(1); %proprtional constant
Kd=K(2); %Derivative constant
Ki=30; % Integral Constant
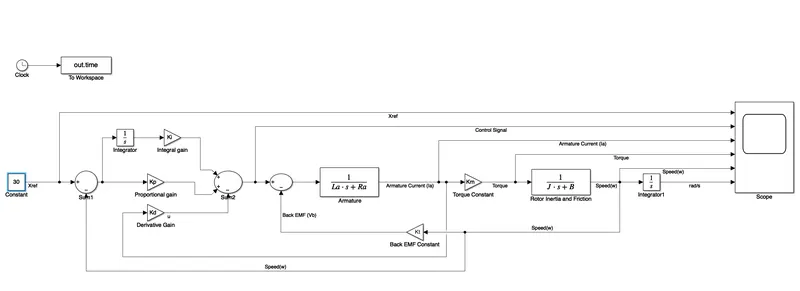
Simulink Model:
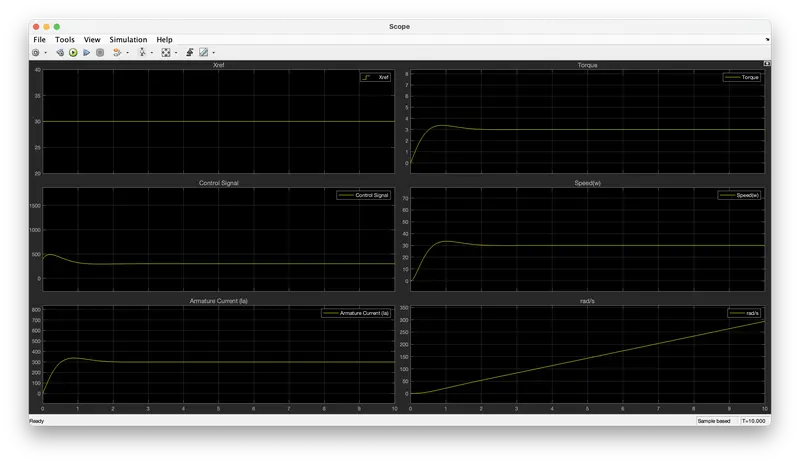
Results:
Conclusion:
%After analysing the system with diffrent values of ki, the desired response is acheived form the system after setting the Ki Value as 30 and zeta as 0.9
After setting the value, the design parameters
Settling time is <3 sec, Overshoot and undershoot is <5%
Steady state error is <1% is acheived