Project - Speed Control of a Direct Current (DC) motor
Project - Speed Control of a Direct Current (DC) motor
In this project, a Simulink model for the DC motor will be first developed per the schematic shown in Figure 1.
Use the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
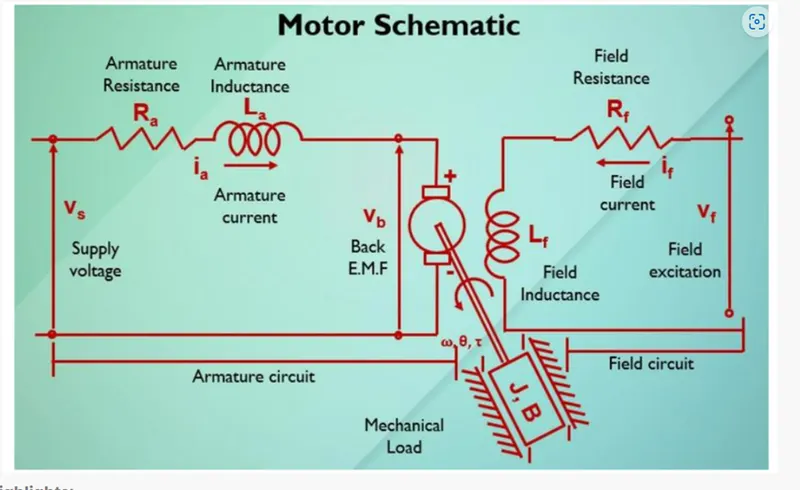
Key Highlights:
- Mathematical modeling from the first principles
- Modeling an Electrical Engineering system
- Simulink based modeling
- Control law design and test
- Stability of a dynamic system
Deliverables:
- Matlab script to define modeling and control design parameters
- Simulink model to simulate and verify the design
Ans:
Modelling of a DC Machine
A DC machine can function as generator and motor.
A DC machine has a rotor with an armature winding providing the electrical circuit.
It also has a stator with field winding serving as a magnet with energized.
While operating in generator mode, a prime mover is coupled to the rotor allowing it to rotate in magnetic field created by the field winding.
This mechanism induces an electromagnetic force (emf) in the conductors on the rotor and contributes to voltage generation.
While operating in motor mode, the electrical energy supplied to the armature winding and the field winding contributes to rotating magnetic field that forces the rotor to rotate, which generates a mechanical torque.
Modelling of a DC Motor
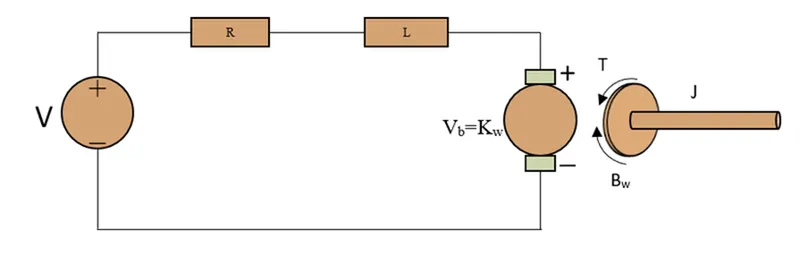
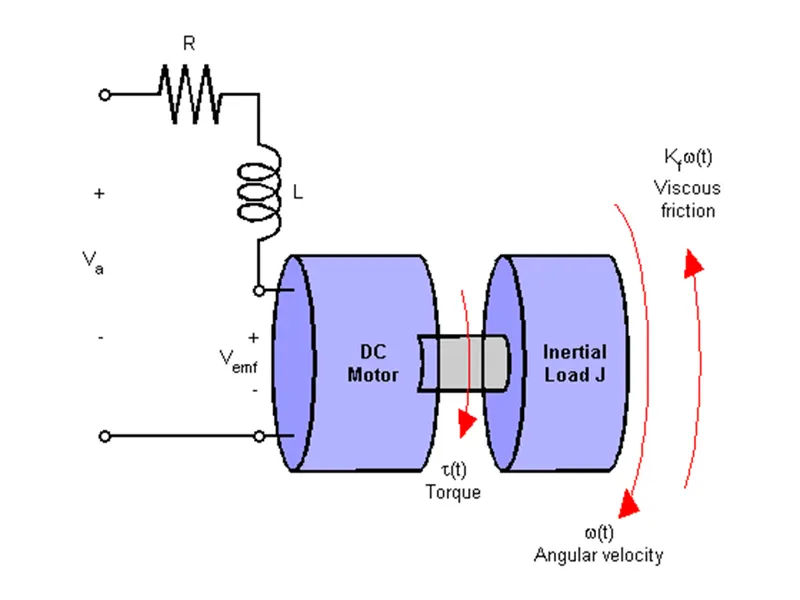
J = Moment of Inertia of Rotor.
B = Damping Coefficient.
R = Armature resistance
L = Armature Inductance
Vb = Back emf constant
KT = Motor Torque Constant
V = Supply Voltage
Motor Torque T = KT * I
Back EMF Vb = Kb * ω = Kb * dθ/dt
Steps to find equation
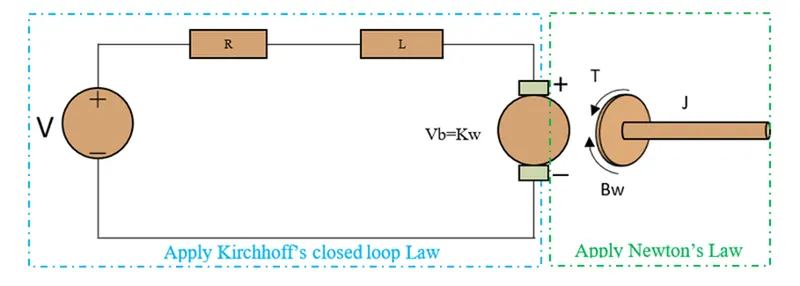
As per Kirchhoff’s Voltage Law
V = IR + L (di/dt) + Vb
L (di/dt) + IR = V - Kb (dθ/dt) ----equ-(a)
As per Newtons Law
J (d2θ/dt2) + B (dθ/dt) = KT * I ----equ-(b)
Converting above equations to S domain (Laplace Transform)
Laplace of equ – (a)
LsI(s) + RI(s) = V(s) - Kbsθ(s) ----equ-(c)
I(s) = V(s) - Kbsθ(s)/Ls + R ---- equ-(d)
Laplace of equ – (b)
Js2 θ(s) + Bs θ(s) = KT * I(s) ---equ-(e)
ωs = s θ(s) = KT * I(s)/Js+B ----equ-(f)
Substitute I(s) value in equ-(e)
Js2 θ(s) + Bs θ(s) = KT * I(s) ---equ-(e)
Js2 θ(s) + Bs θ(s) = KT * (V(s) – Kbsθ(s))/ (Ls + R) ---equ-(g)
s θ(s)[(Js+B) * (Ls+R)] = KTV(s) – KT * Kbsθ(s)
s θ(s)[(Js+B) * (Ls+R)] + KT * Kbsθ(s)= KTV(s)
s θ(s)[(Js+B) * (Ls+R) + (KT * Kb)]= KT V(s)
Transfer function of output angle θ(s) to the input angle V(s) given by
Ga(s) = θ(s)/V(s) = KT / s[(Ls+R) * (Js+B) + (KT * Kb)] ----equ-(h)
Transfer function of output angle ω(s) to the input angle V(s) given by
Ga(s) = (s)/V(s) = KT / [(Ls+R) * (Js+B) + (KT * Kb)] ----equ-(i)
Simulink Modelling of DC Motor
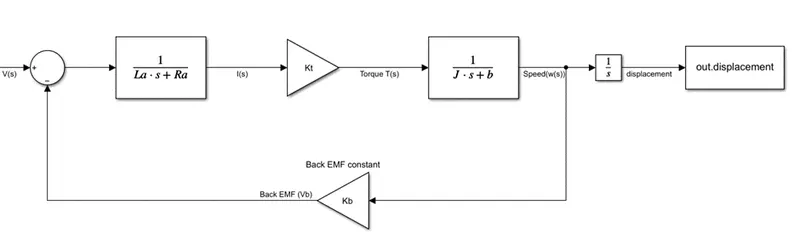
DC Motor Parameters
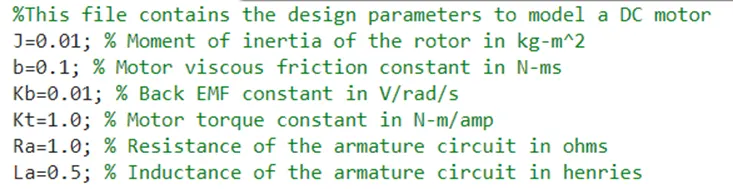
Modelling of a DC Motor with PID controller
State Space equations for the DC Motor
State equations will be derived from equations (a) and (b)
dI/dt = - (R/L) I + (1/L) V – (Kb/L) d/dt
dI/dt = - (R/L) I + (1/L) V – (Kb/L) ω dI/dt
dω/dt= - (B/J) ω + (1/J) KTI
Y(t) = ω = d/dt
A state space representation of the DC motor from above equations
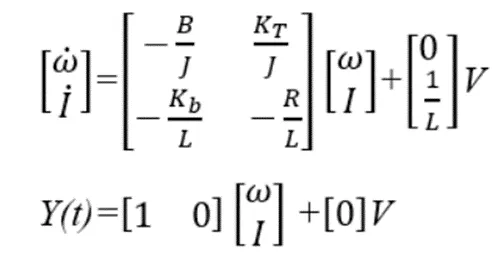
Modelling of DC Motor with PID Controller
What is PID Controller?
A proportional-integral-derivative controller (PID controller or three-term controller) is a control loop mechanism employing feedback that is widely used in industrial control systems and a variety of other applications requiring continuously modulated control. The proportional integral derivative controller produces an output, which is the combination of the outputs of proportional, integral, and derivative controllers. The feedback from the plant whichever is a controllable parameter is given as input to the PID controller and the processed error is minimized to get the desired output if tuning of the parameter is done optimally. The mathematically PID controller can be defined by the following equation where e(t) is the error signal with respect to time, Kp, Ki and KD are PID constants.
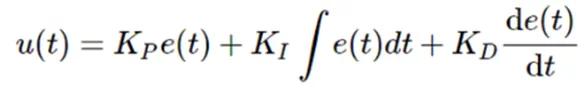
Apply Laplace transform on both sides.
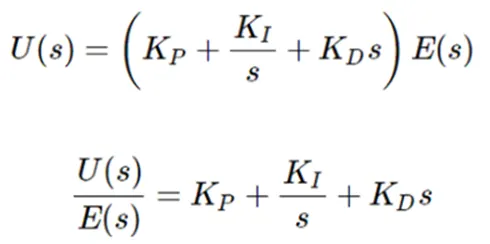
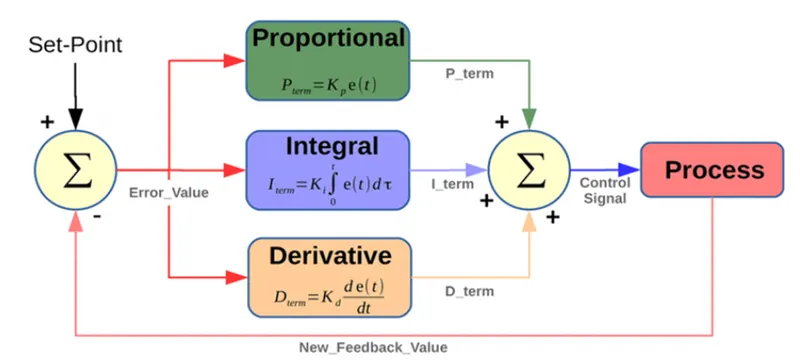
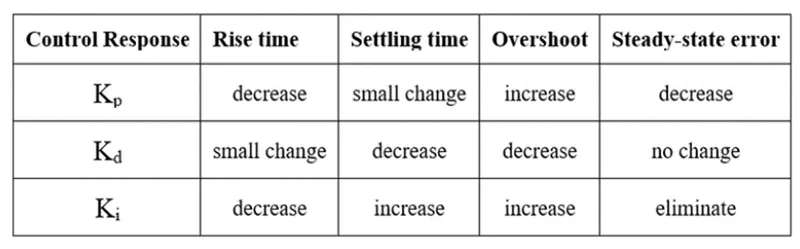
The parameter which is under control must have some properties or free from some properties such as rise time, settling time, overshoot and steady state error. The impact of PID parameters on such properties can be found in the below table.
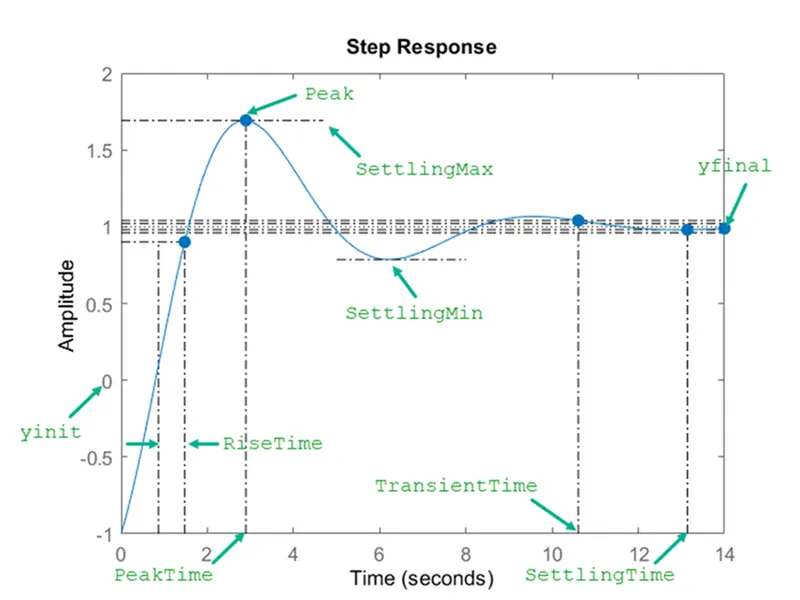
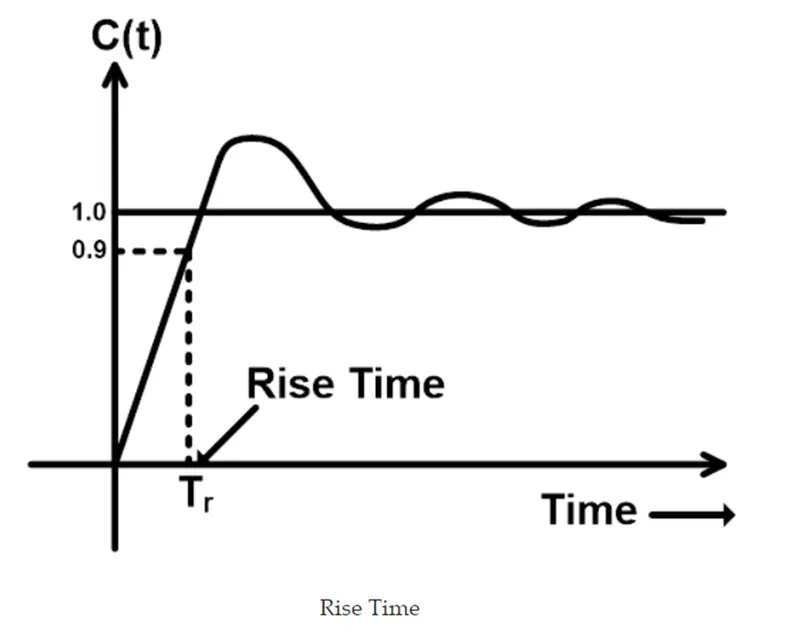
Rise Time
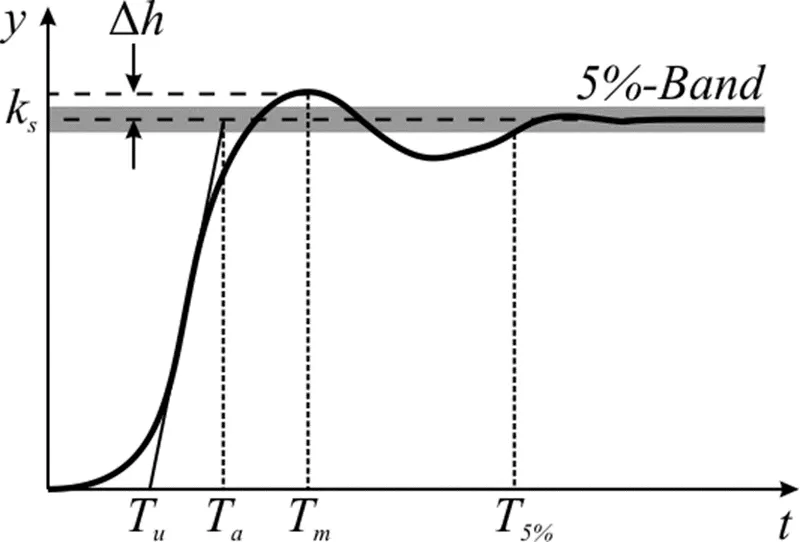
Rise time is defined as the time taken for a signal to cross from a specified low value to a specified high value. In analog and digital electronics, the specified lower value and specified higher value are 10% and 90% of the final or steady-state value. So, the rise time is typically defined as how long it takes for a signal to go from 10% to 90% of its final value.
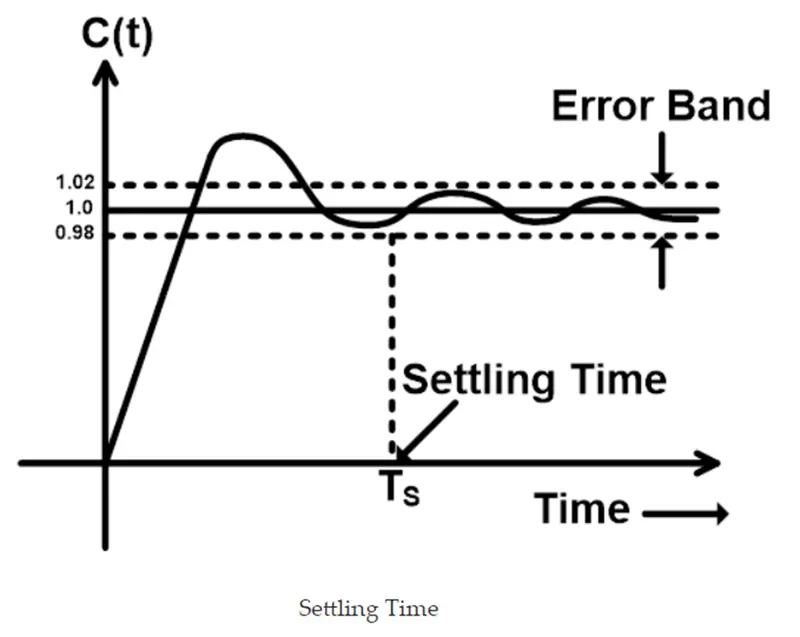
Settling Time
The settling time of a dynamic system is defined as the time required for the output to reach and steady within a given tolerance band. It is denoted as Ts. Settling time comprises propagation delay and time required to reach the region of its final value. It includes the time to recover the overload condition incorporated with slew and steady near to the tolerance band.
The tolerance band is a maximum allowable range in which the output can be settle. Generally, the tolerance bands are 2% or 5%.
Peak Over Shoot
(MP) is defined as the deviation of the response at the peak time from the final value of the response. it is also called the maximum overshoot. We can write it as
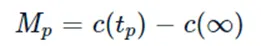
Steady State Error
Steady-state error is defined as the difference between the desired value and the actual value of a system output in the limit as time goes to infinity (i.e., when the response of the control system has reached steady-state).
Steady-state error is a property of the input/output response for a linear system. In general, a good control system will be one that has a low steady-state error.
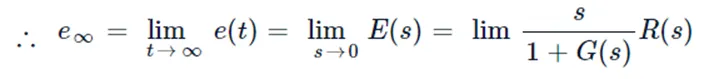
Stability of the System
A system is stable if every bounded input yields a bounded output. We call this statement the bounded-input, bounded-output (BIBO) definition of stability.
The stability of a linear closed loop system can be determined from the locations of the closed loop poles in the s-plane.
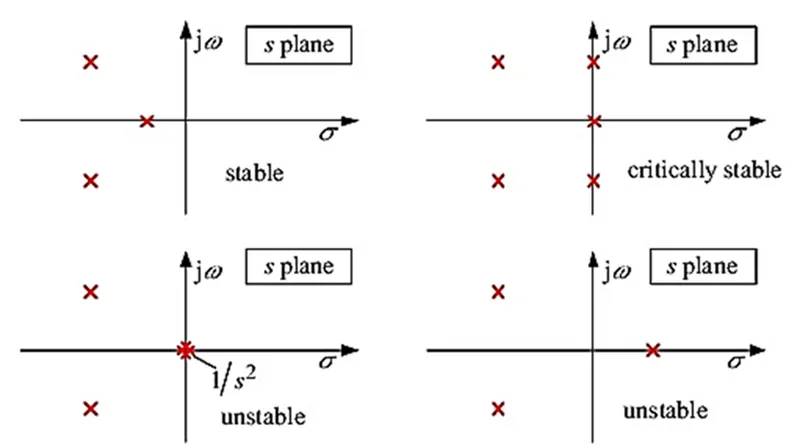
The location of poles of the transfer function decides the stability of the system. Which is shown in the above figure for critically stable, unstable, and stable systems.
For our case, the transfer function is determined from the constants of motor and state space equations,
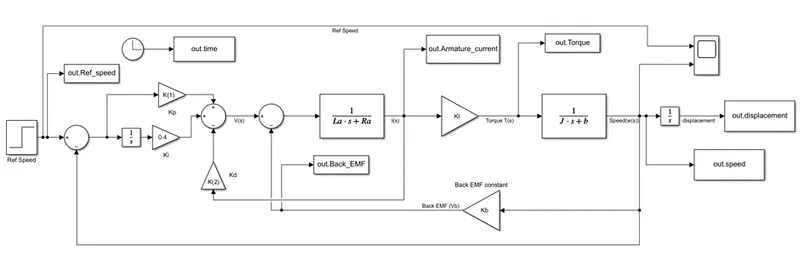
Simulink Modelling of DC Motor with PID Controller
DC Motor with PID Controller Parameters
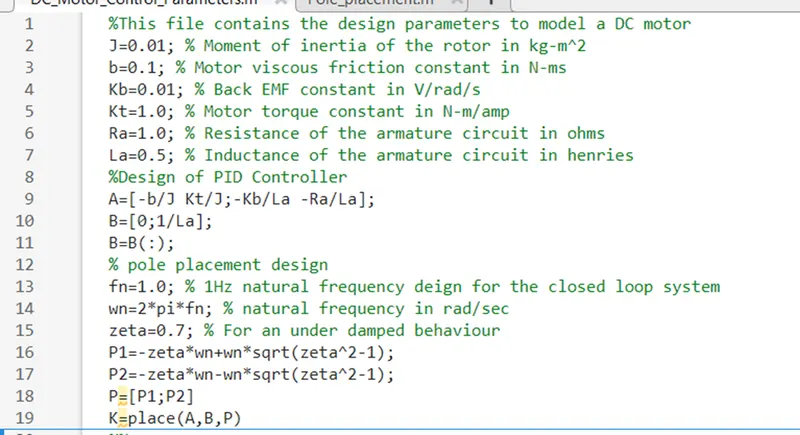
To design a closed loop control scheme for a DC motor the following changes need to be done in the model in the previously created model.
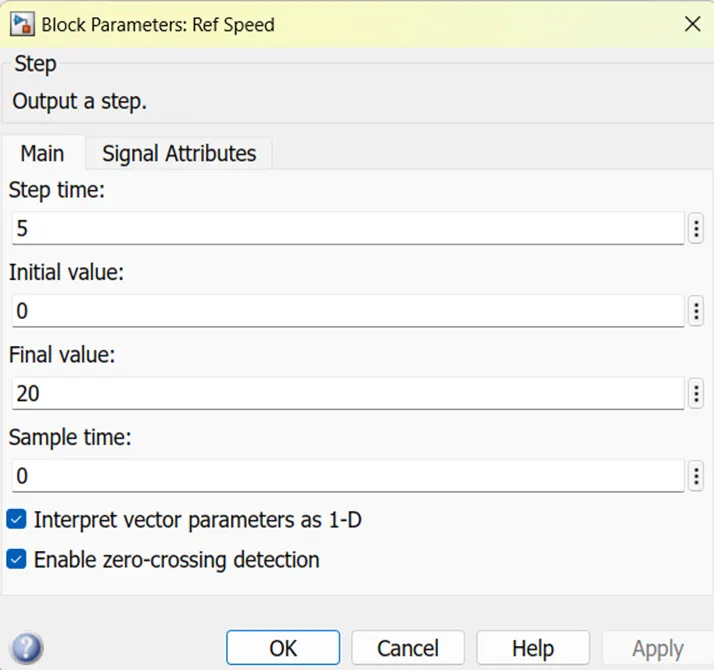
Speed is the controllable parameter, so we will set the reference speed in step block as 10.20, 40 whichever we want.
- Subtract the actual speed from the reference speed to generate the error signal e(t)
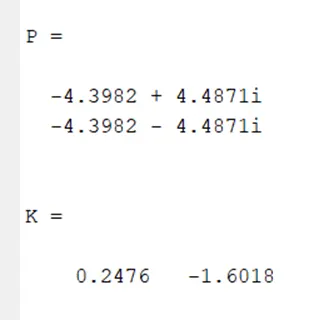
- Add Kp as K(1) and Kd as K(2) parameter determined from place command (K-place(A.B.P)). (use gain block to mention values of Kp, Kd, and Ki)
- The feedback for Kd is provided from the error speed signal.
- Add Ki manually with gain and integrator block and tune different values of Ki and check the impact of it on results.
Values of Kp, Kd & Ki choosen for Controller Design
From the pole placement we got Kp and Kd values and assumed the Ki value as 0.4
Kp = 0.2476
Kd = -1.6018
Ki = 0.4
Control Design Objectives to Meet
Settling time < 2s
Overshoot < 5%
Steady State error < 1%
Result
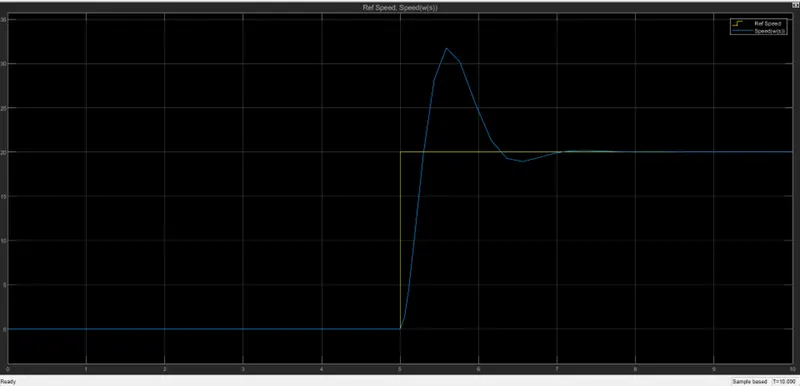
The below response shows the speed of the DC Motor Vs Reference speed. The reference speed given through step function. In this step time considered as t=5sec, initial value taken as 0 and final value is 20.
Observation
From the above graph we can observe that the speed of the motor is following the reference speed of 20rad/sec. by satisfying the control design objectives of settling time (< 2s) Overshoot (< 5%) Steady State error (< 1%) was achieved for the control parameters values of
Kp = 0.2476
Kd = -1.6018
Ki = 0.4
We have to verify how the speed of the motor changing with the change in reference speed.
Case-2:
Changing the initial value of reference speed to 50 and final value to 90 and step time is 5sec.
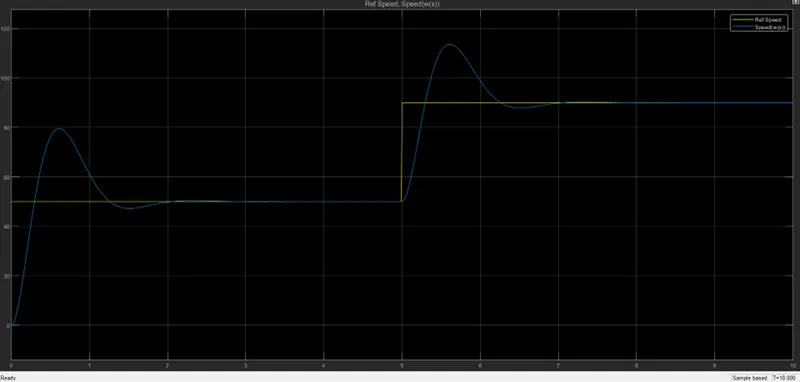
Observation
From the above graph we can observe that the speed of the motor is following the reference speed, initially it is 50rad/sec and changes to 90rad/sec and also it is satisfying the control design objectives of settling time (< 2s) Overshoot (< 5%) Steady State error (< 1%) was achieved for the control parameters values of
Kp = 0.2476
Kd = -1.6018
Ki = 0.4
From this we got to know that the speed of the motor will follow the reference speed for any value of change in reference speed.