Project - Speed Control of a Direct Current (DC) motor
Project-Speed Control of a Direct Current (DC) motor:
Summary:
The Project is based on speed control of a DC Motor By Using PID Controller.
Initially,simulink model of a Dc Motor is constructed, then make it as subsystem called "DC MOTOR".
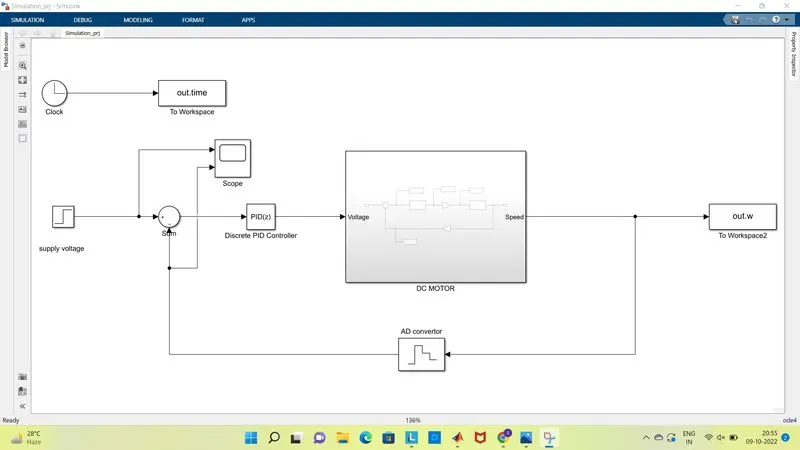
Then,Subsystem Dc motor is connected to the discrete PID controller to maintain the desired speed as it is.
After that Pid controller begin with Kp.Ki,Kd as 1,1.0,0 after tuning accordingly, we can adjust Kp,ki,Kd as
19.09,52.31,1.06,31.80 respectively and futher more tuned to value 167.27,356.90,15.52,124.85. To obtain Control Design Objectives.
Simulink Model: (without PID)
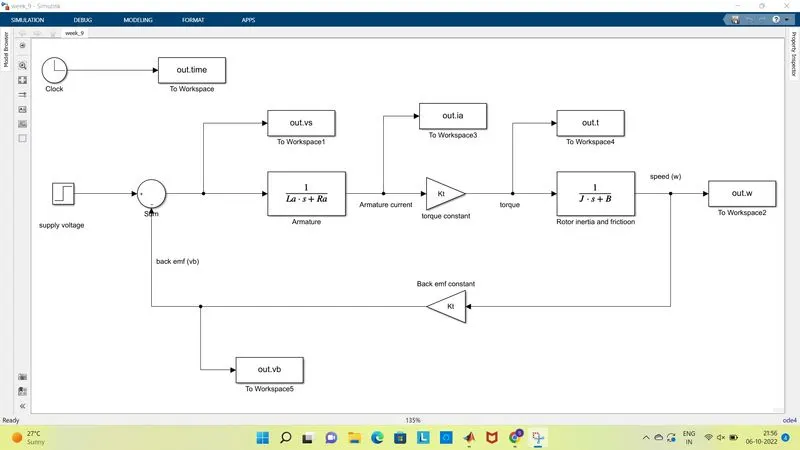
The motor parameter:
Here we consider the following paramters:
% This file contains the design paramters to model a Dc motor
- J = 0.01; % momemt of inertia
- B = 0.1; % motor friction
- Km = 0.01; % back emf
- Kt = 0.01; % Motor torque constant % aramture resistance
- Ra = 1.0;
- La = 0.5; % aramture inductance
Simulation Results :
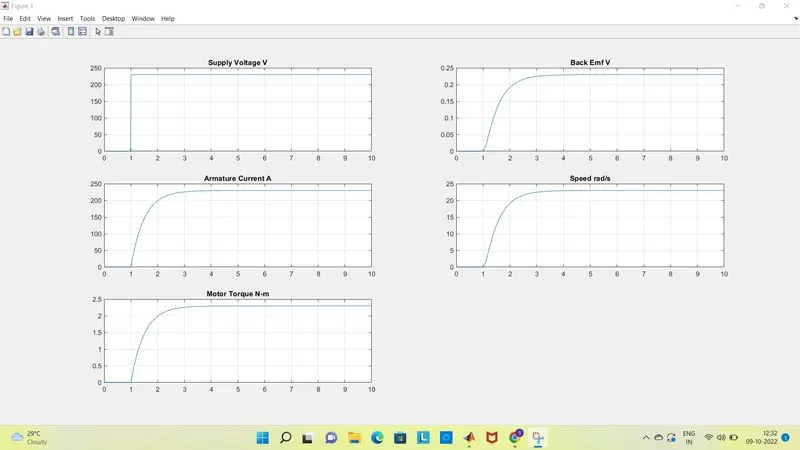
Simulink Model: (without PID):
Resuts (without auto tune):
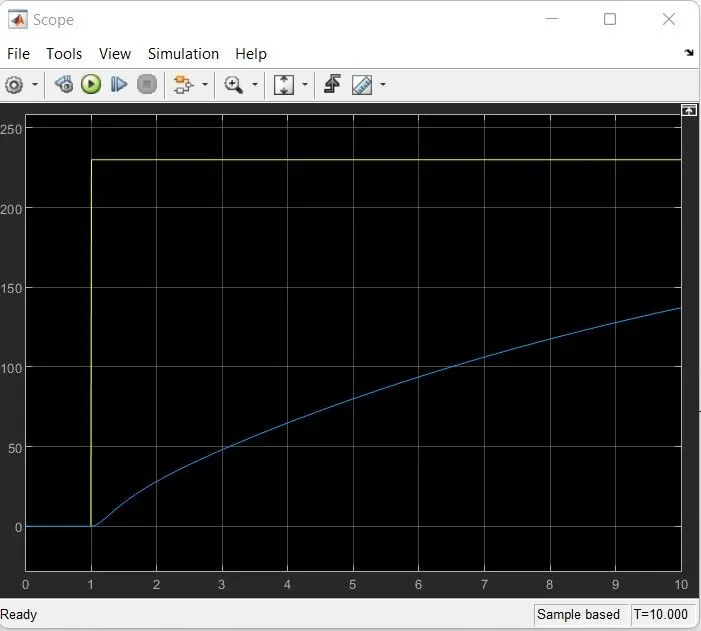
The model was autotune to values
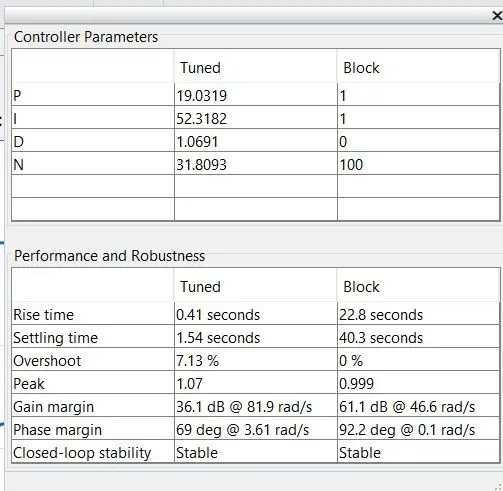
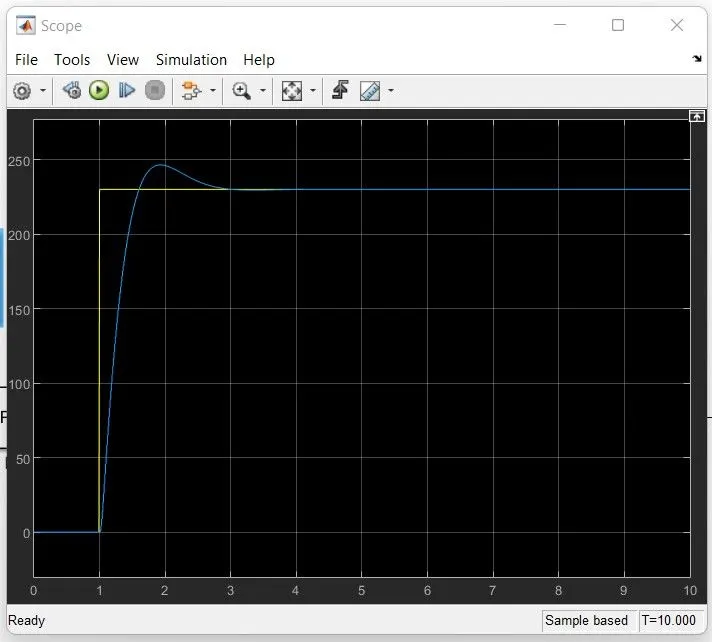
Results :
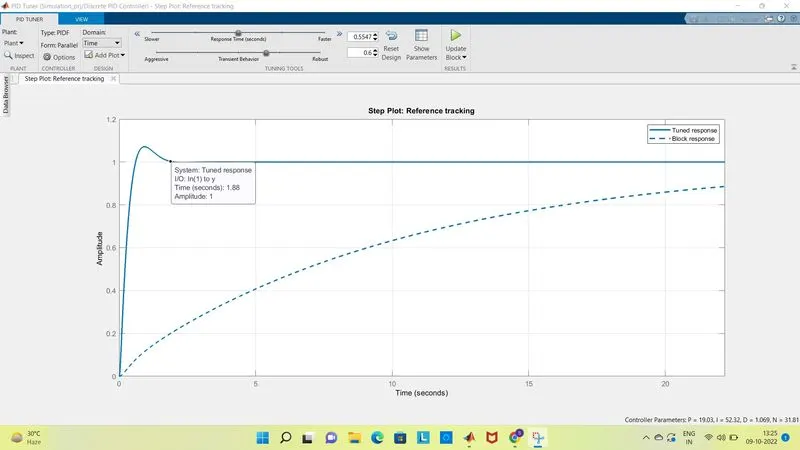
At time 1.88 amplitude 1 is obtained.
Now the model is further tune manually and the values obtained are as below;
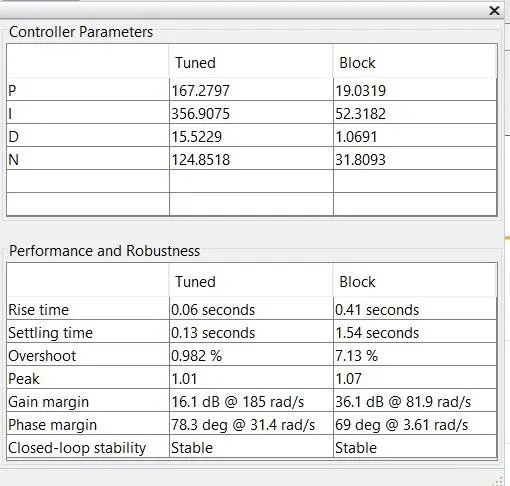
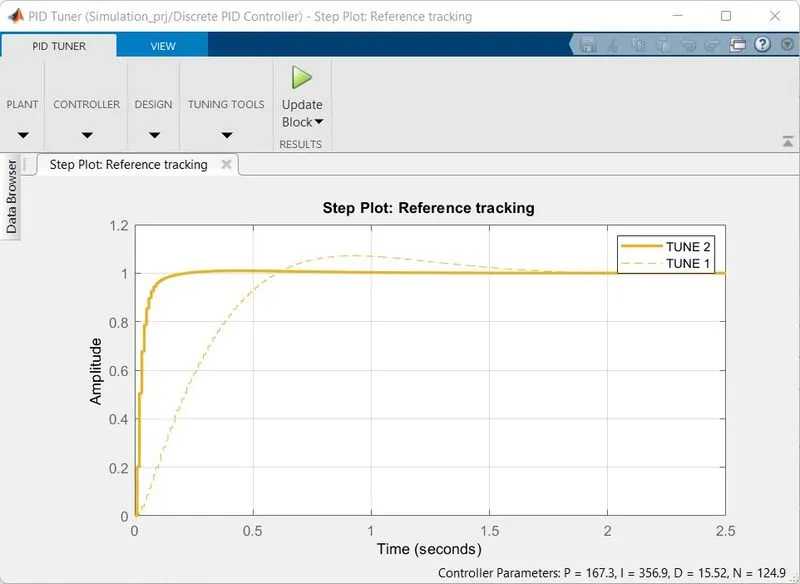
Now we see the ampiltude 1 is obtained much lesser than 1st tunned i.e less than 0.4 sec compared to 1.88 sec
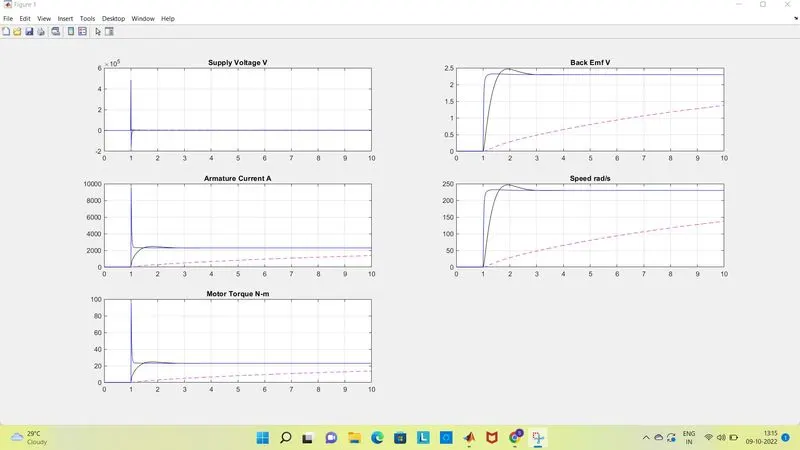
Results (comparision):
Conculsion:
We had successfully added pid in motor simulation model and compiled sucessfuly.The results varied from default pid values to auto tune and manual tune.
Hence the results got more and more better ase we go on tunning it finner.