Project - Speed Control of a Direct Current (DC) motor
Mathematical Modeling of DC motor:
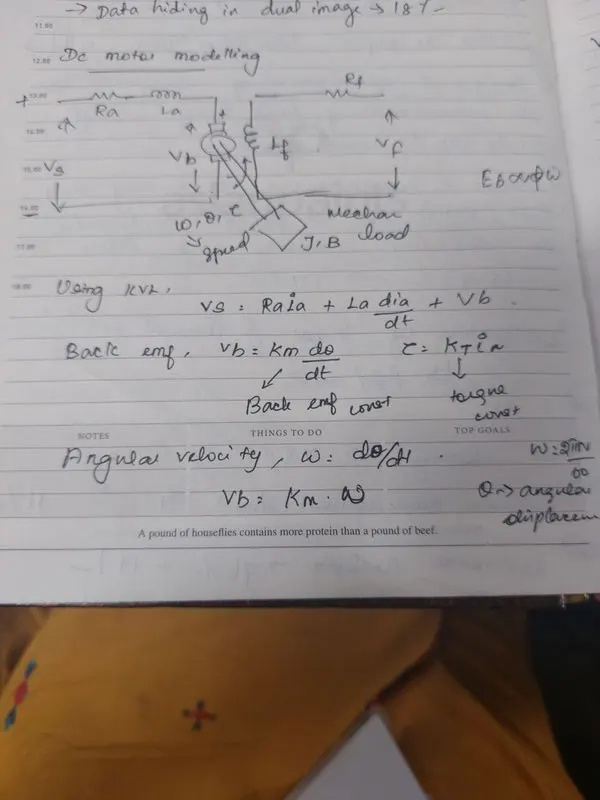
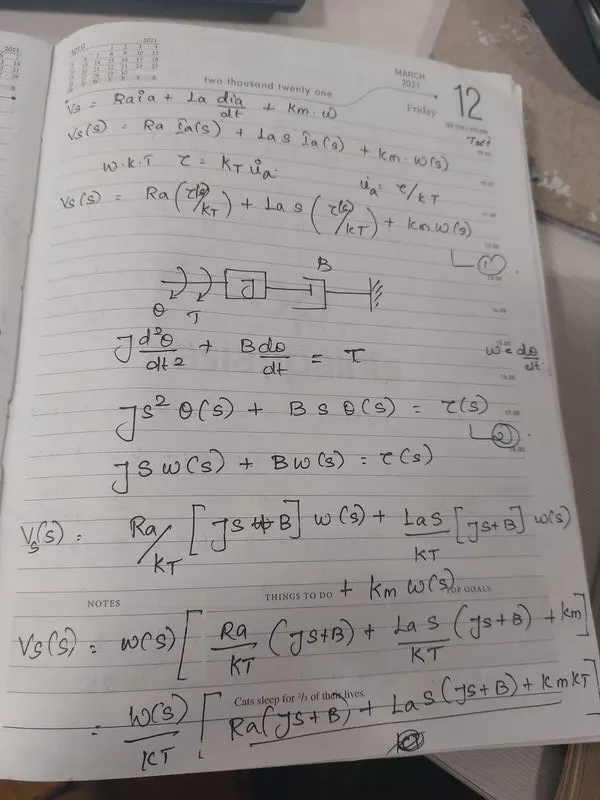
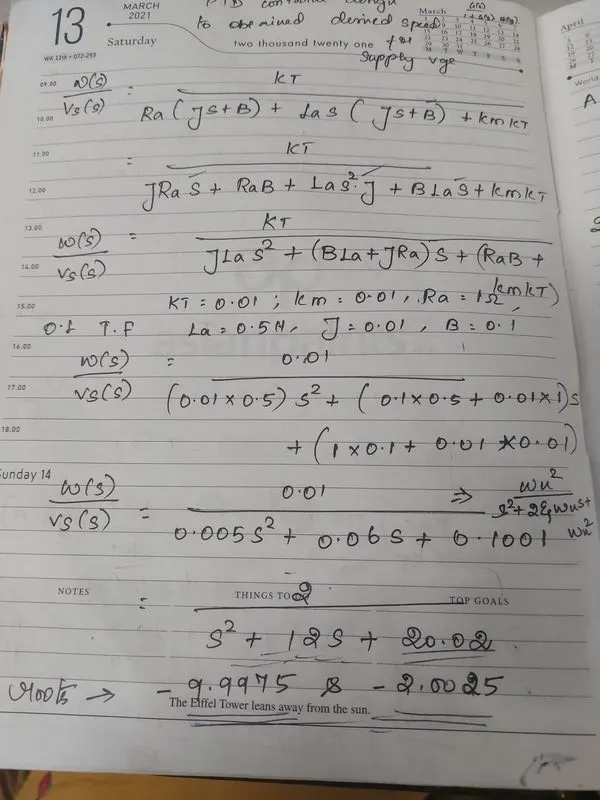
Matlab script to define modeling and control design parameters are given below:
%%DC motor parameters
J=0.01;
B=0.1;
Km=0.01;
Kt=0.01;
Ra=1;
La=0.5;
wn=4.474;
zeta=1.34;
p1=-zeta*wn+wn*sqrt(zeta^2-1)
p2=-zeta*wn-wn*sqrt(zeta^2-1)
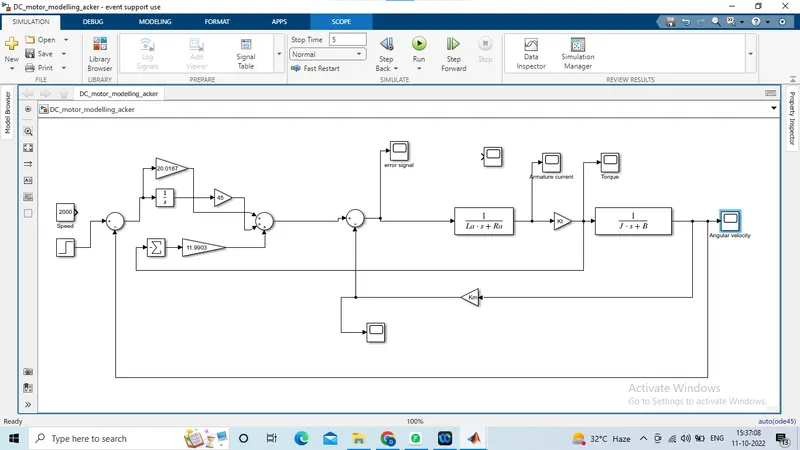
kp=wn^2
kd=2*zeta*wn
p1 =
-2.0045
p2 =
-9.9858
kp =
20.0167
kd =
11.9903
Simulink model to simulate and verify the designed model is presented below:
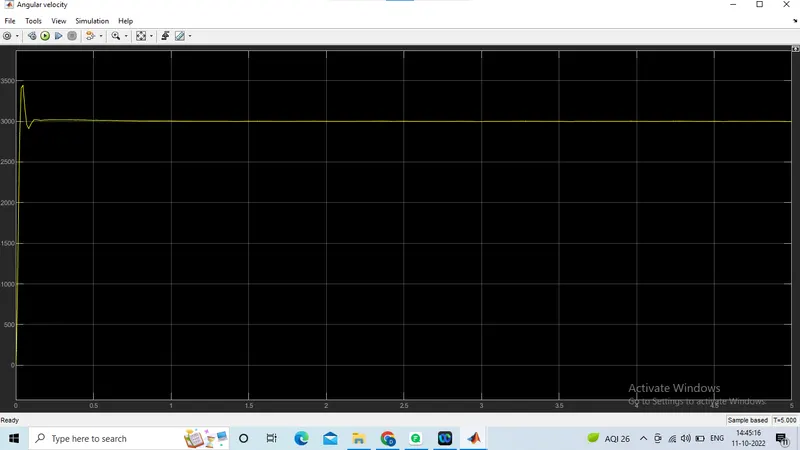
a)Using PID tuner
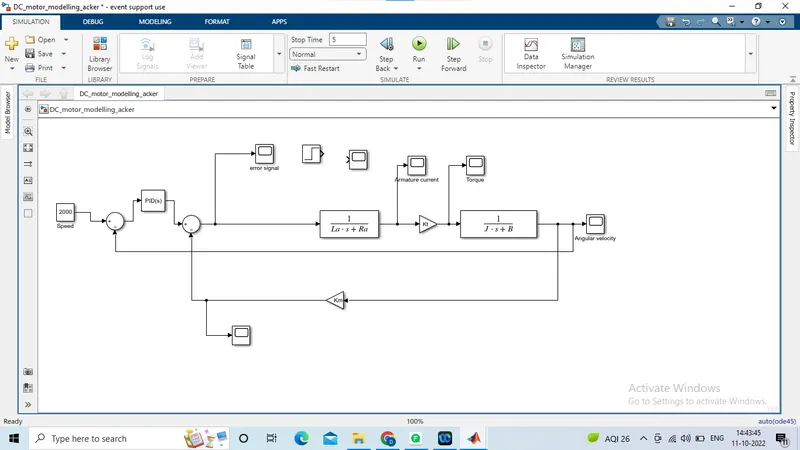
b) with designed control gain values
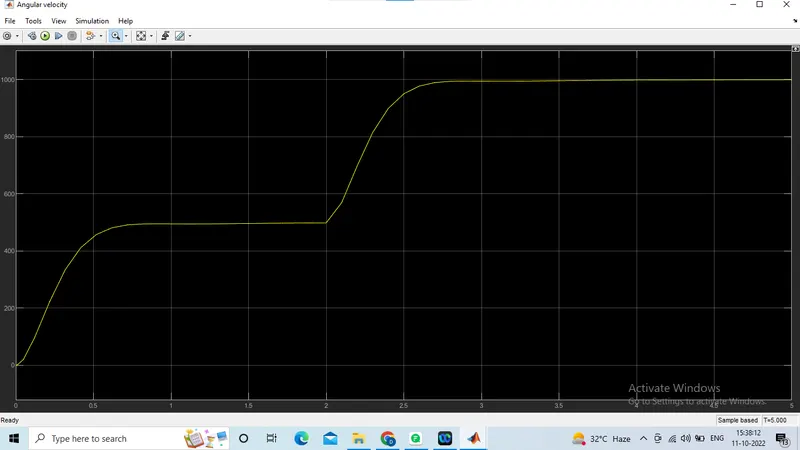
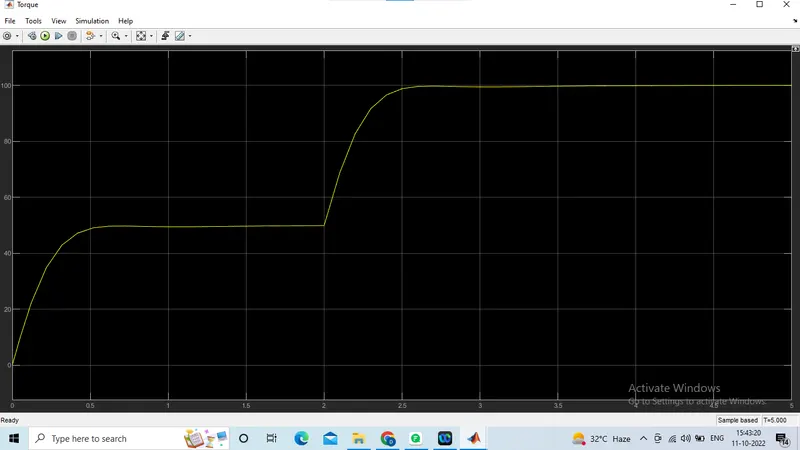
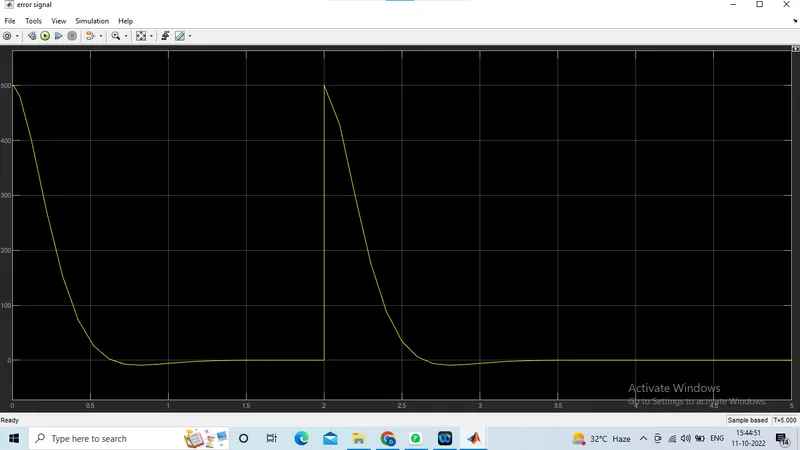
Thus the Proportional, Integral, and Derivative (PID) control gains are designed using pole placement knowledge gained in the training session.
A controller with the PID control gains are developed and tested to maintain the desired speed of the motor.