Project - Position control of mass spring damper system
To design the project of position control of mass speing damper system using matlab simulink model of transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference singnal.
Transfer function of a mass spring damper system and use it in the model. Add PID controller to adjrst the force on mass so that its position follows a reference singnal. The matlab model of the PID control and transfer function pulse waveframe generator.
This example shows a controlled mass spring damper. A controller adjusts the froce on the masss to have its postion track a command signal. The initial velocity for the mass is 10 meter per second. The controller adjusts the force applied by the froce source to track the step changes to the input sigal.
PID controller
In this project, PID controller has bee n designed by using simulink in order to control a mass spring ddamper system which can move any direction. A tranfer function for dc motor was added on the diagram. Response curve of the PID controller were fixed by tunning. The computer interface, different control algoritms can be performed on the system easily; control parameters can be set up online, filter algoithms in various structures can be tried and the reaction of these changeable values to the system can be observed. the effects of controller proportional integral derivative(PID) for developing.
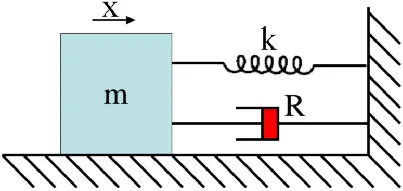
TRANSFER FUNCTION:
The numerator coefficient can be a vector or matrix expression. The denominaotr coefficient must be a vector. The output width equals the numver of rows in the numerator coefficient. You sould specify the coefficients in descending order of powers of s.
'Parameter tunability' controls the runtime tunability level for numerator and denominator coefficients. Auto simulink to choose the most appropriate tunability level. Optimized Tunaility is optimized for performance. Unconstrained.
Tunability is unconstrained across the simulation targets.
Command window commants:
some parameter are give in the input value of spring mass dambering system using the matlab commants
Take m = 3.6,%kg
K=400;N/m
c=100;Ns/m
the all the input value using to write the program and calcultae the value.
MATLAB PROGRAM OF POSITION CONTROL OF SPRING_MASS_DAMPER_SYSTEM;:
clc;
close all;
Program script:
Matlab simulink model of position control of mass sprinmg damper system:
To design a closed loop control scheme for a DC Motor the following changes need to be done in the model in the previously created model.
- speed is the controllable parameter, so we will set the reference speed in the step block as 10,20, 40 whichever you want.
- Substract the actual speed from the refereence speed to genterate the error signal e(t)
- Add Kp as K(1) and Kd as K(2) parameter determined from place command.
- The Feedback for Kd is provided from the output current of the plant/Model. OR we can take feedback.
- Add Ki manually with gain and integrator block and tune different values of Ki and check the impact of it on results.
To Plot output waveform:
CONCLUSION:
To complte the project of position control of mass spring damper system transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position folllows a reference signal to using matlab and simulink wave from plot.