Project - Position control of mass spring damper system
Transfer function:
Given,
mass m = 3.6 kg
Spring constant, k = 400 N/m
Damper coefficient, c = 100 Ns/m
Let, position is denoted as x(t) and faorce acting on mass is F(t)
Therefore,
m d^2x/dt^2 + c dx/dt + kx = F(t)
It can be written in laplace transform as:
m*s^2 X(s) + c*sX(s) + k*X(s) = F(s)
X(s)[m*s^2 + c*s + k] = F(s)
X(s)/F(s) = 1/(m*s^2 + c*s + k)
The above equation represents transfer function of wn^2/(S^2 + 2*zeta*wn*S + wn^2)
Therefore,
wn^2 = k/m = 400/3.6 = 111.1111
wn = 10.5409
Also, 2*zeta*wn = c/m = 0.25
So, zeta = 1.3176 % over damped system
We also know,
A = [0 1; -k/m 0]
By solving, A = [0 1; -111.1111 0]
B = [0; 1/m]
B = [0; 0.2778]
Poles design
p1 = -zeta*wn + wn*sqrt(zeta^2-1) = -4.8451
p2 = -zeta*wn - wn*sqrt(zeta^2-1) = -22.9327
p = [p1; p2]
k = place(A,B,p)
We get,
Kp = -0.0019
Kd = 100
Ki = 1/m = 0.2778
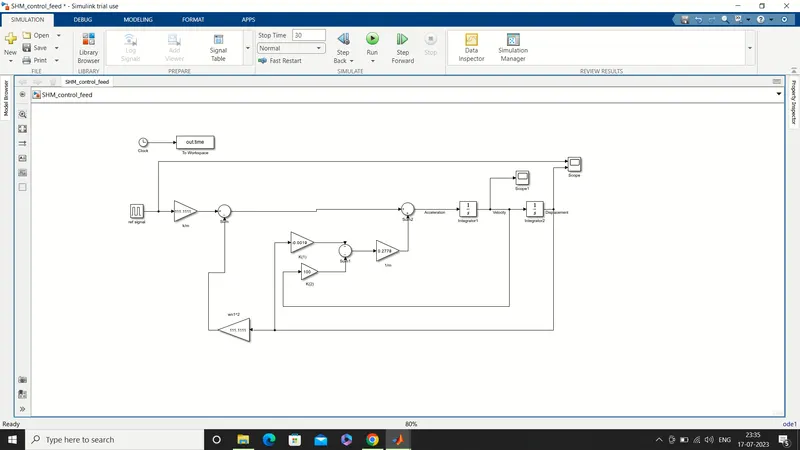
Simulink model
OUTPUT
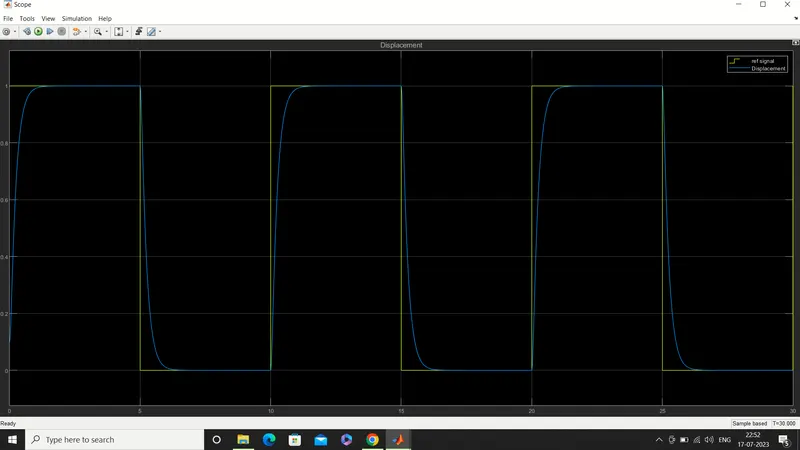
Here, position is tracking the reference signal.