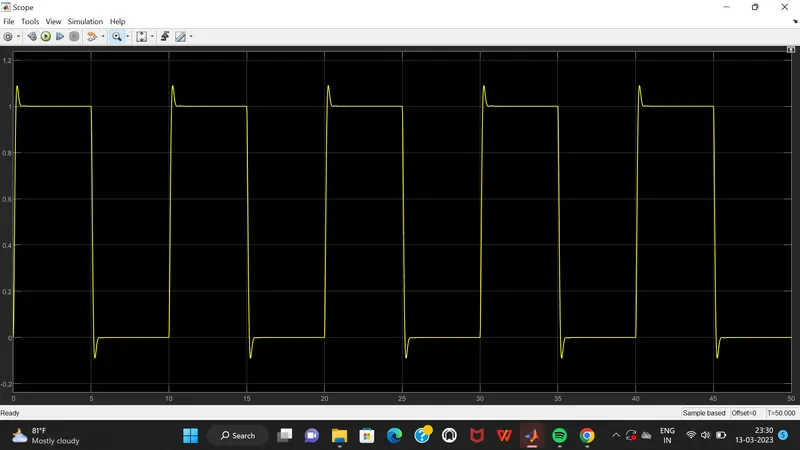
Project - Position control of mass spring damper system
AIM: Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
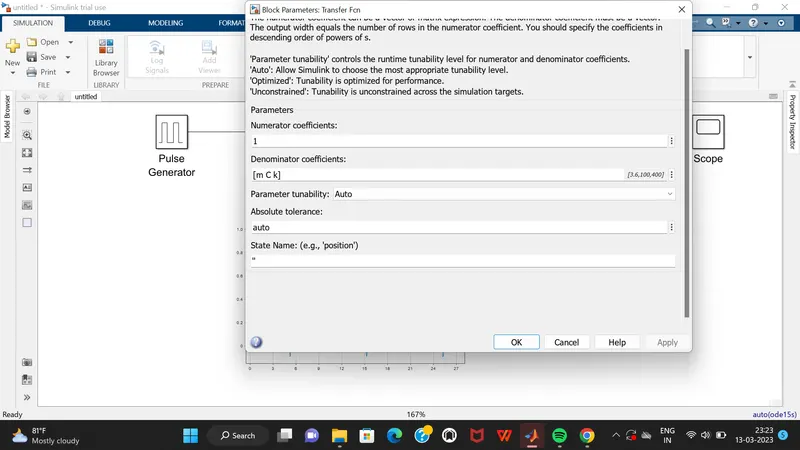
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
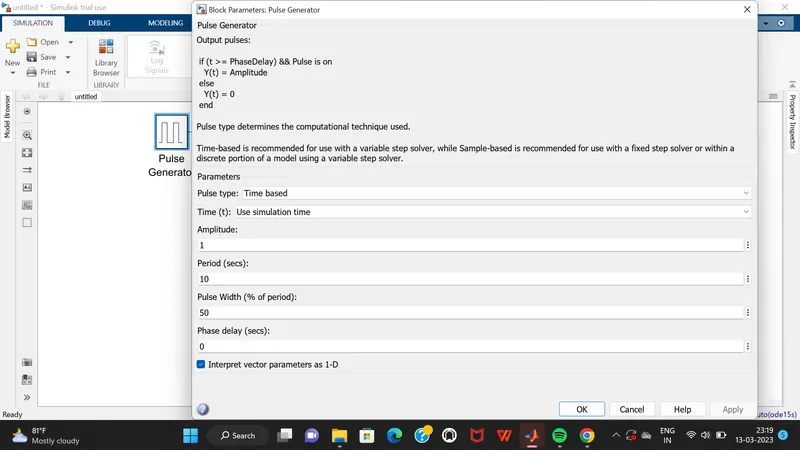
The reference signal is shown in the following figure.
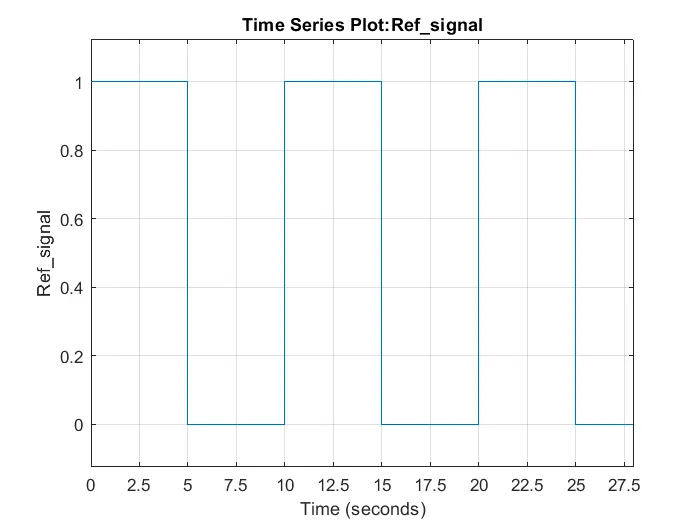
Step 1:
To create a matlab script file in the matlab and to demonstrate the script is given below
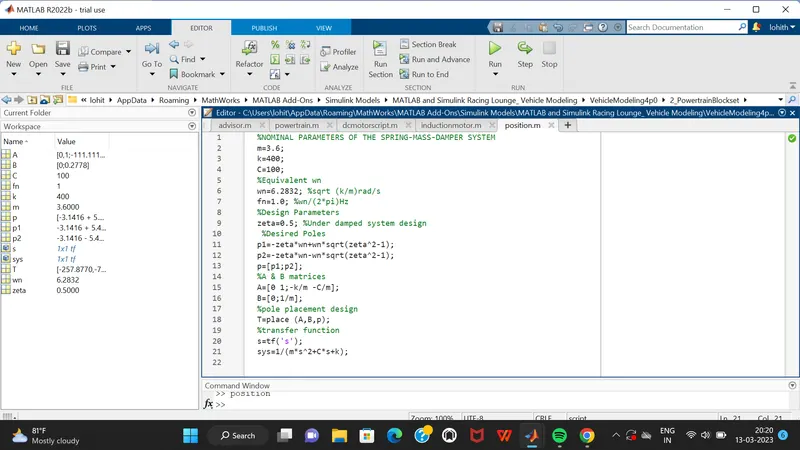
Step 2:
To create a simulink model for the position control of mass spring damper system is given below:
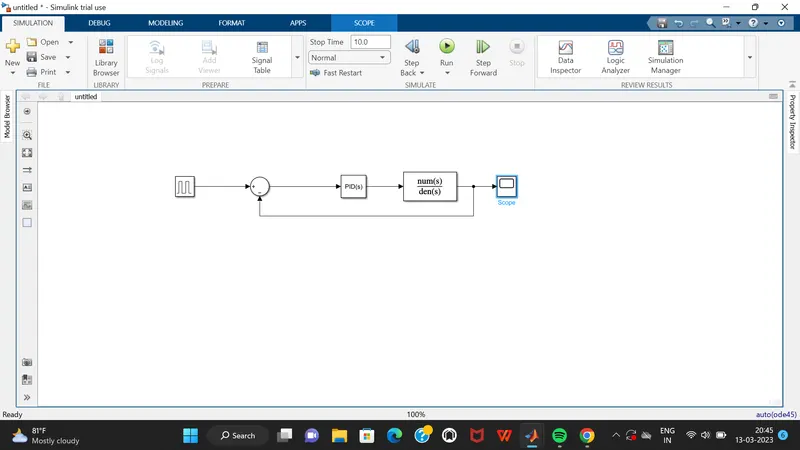
To change reference parameters values in pulse generator is given below:
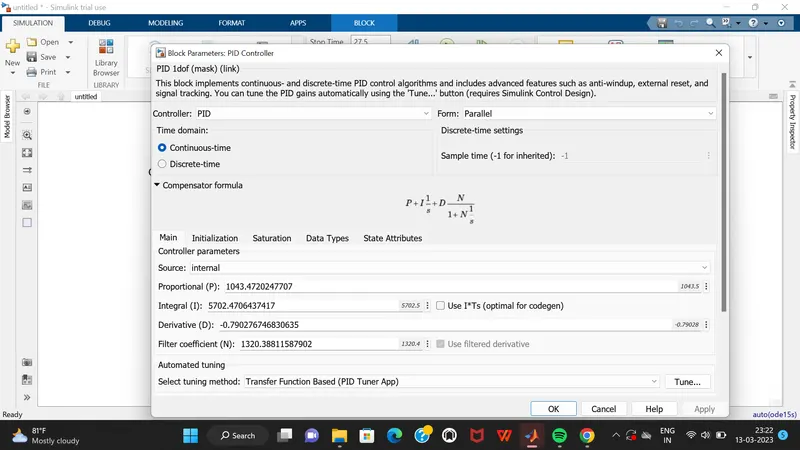
To change the PID controller parameters values is given below:
To change the transfer function parameters values is given below:
The output of position control of mass spring damper system: