Project - Position control of mass spring damper system
REPORT :
we know the transfer function of mass spring damper system
f(t)-cdx/dt-kx(t)=mdx^2/dt^2
Byapplying laplace transform
F(s)-csX(s)-kX(s)=ms^2X(s)
T(s)=1/ ms^2+Cs+k
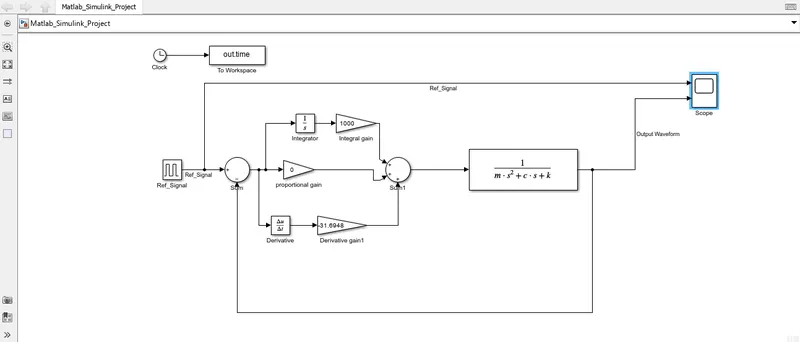
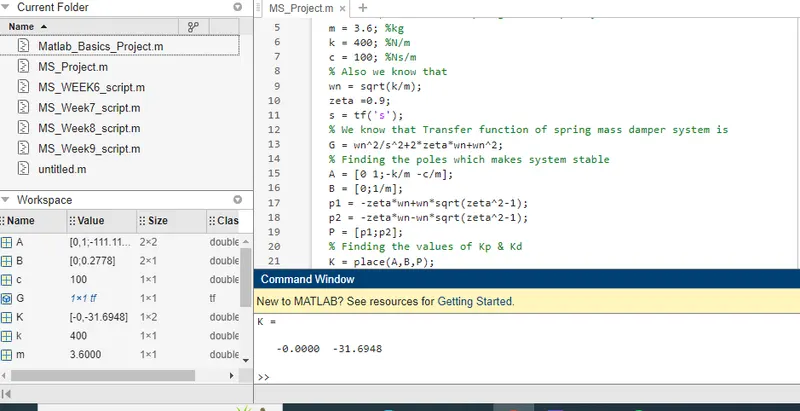
The values of Kp & Kd obtained from the using a 'place' command are 0 and -31.6948 respectively so for obtaining a desired output we observe the output waveform for the diffrenat values of the integral gain i.e. Ki
1. Set Ki = 100
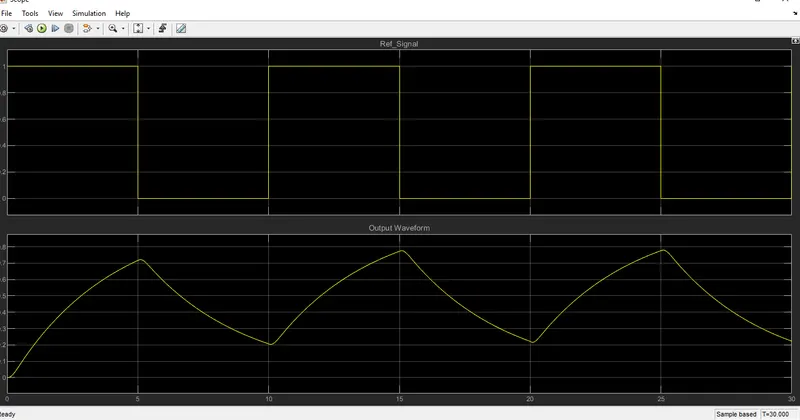
As we see in the above image the output waveform does not folllow the Ref. signal.
2. Set Ki = 500
As we see in the above image the output waveform tries to folllow the Ref. signal as we incresres the value of Ki
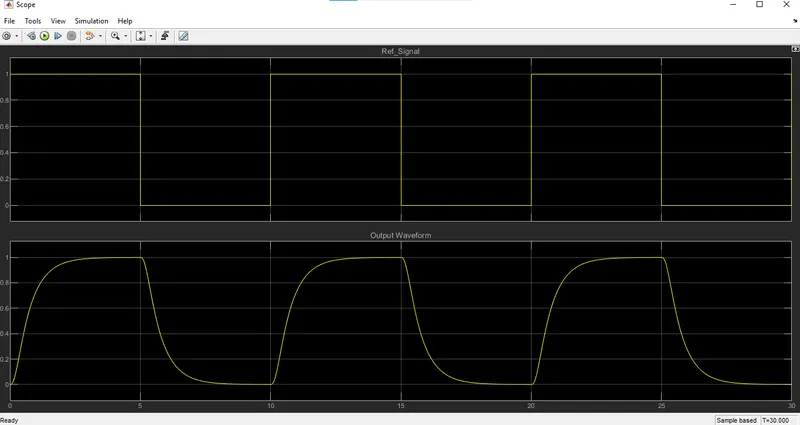
3. Set Ki = 1000
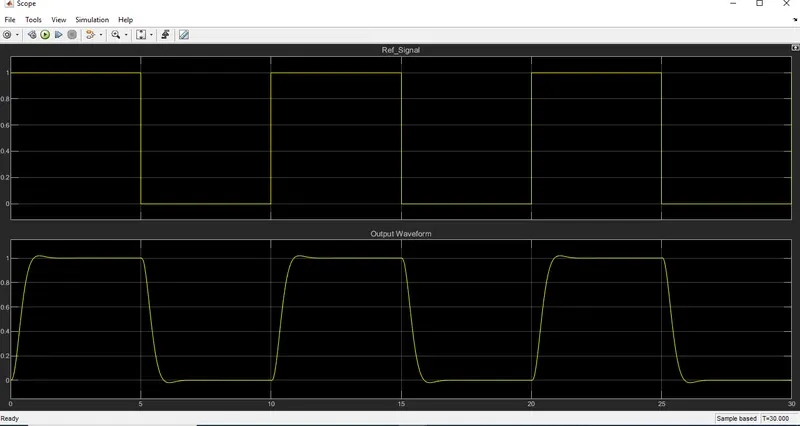
As we see in the above image the output waveform folllows the Ref. signal
CONCLUSION:
Obtained the transfer function of a mass spring damper system with m = 3.6kg k = 400 N/m c = 100 Ns/m using matlab programming and Created a transferfunction model and added PID controller and adjusted the force on mass so its position follows a reference signal when Kp=0 ; Ki=1000 and Kd= -31.6948