Project
Technical Report of Baja AVT
Following are the major compunent use in BAJA AVT Model.
Signal Builder:
Signal Bulider provide input to the model such as throttle, Break..etc
Throttle: The device contrlled the flow of fuel or power to an engine. It use, Valve of requlating the supply of a fluid to an engine, especially the valve controlling the valume of fule delivered to the cylinders of an internal-combustion engine.
Engine Sensor:
Engine sensor is electro mechanical device that moniter verious engine parameter. An engine uses different type of sensor such as Thermocouples, Resistance temp., Detector (RTD) and Hall effect sensor.
Generic Engine:
Generic engine block represent a general internal combution engine. This block is suitable genric engine for spark-ignition and diesel, speed power and speed torque parameterization provided. A throttle physical signal input specifies the normalized engine torque.
CVT (Ccontinuously Varible Transmission):
Is an atomatic that can seamlessly through continus range of gear ratio. this contract with other transmission that provide a limited number of gear ratio in fixed sleps. the flexibility of a CVT with suitable control way allows the engine to operate at a varying speeds. Unlike conventional automatic transmission, continuously varible transmission donot have any gears. Instade a CVT used two cone shaded pulleys. one pulley is connected to the engine, while the other connects to the rest of the transmission. It delivers power to the wheels. Also CVT provide infinit gear ratio.
Vehical Body:
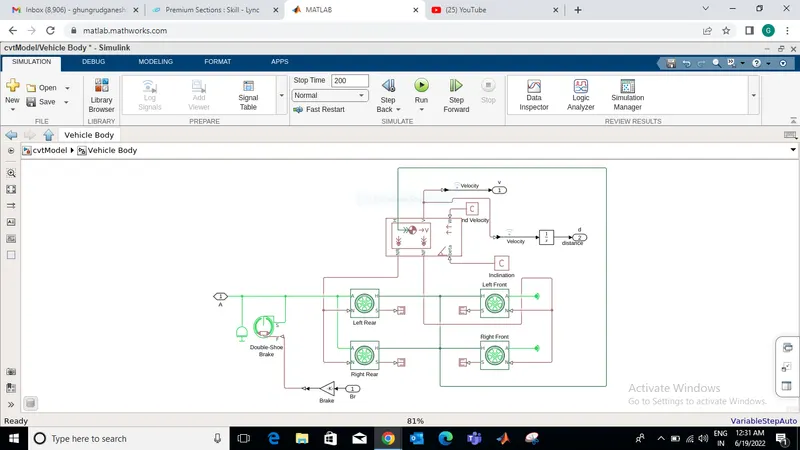
Vehical Body shows all its internal block/component such as wheel, break shoe, break, PS transmitter, etc...
Report:
Case I:
Here in BAJA AVT model made with the help of above mention component. In default model we have provided throttle to system which is 0.5 and break is zero. Aslo we have provide velocity to system.
We have run this system for 200s, after this running time we got some output shown below.
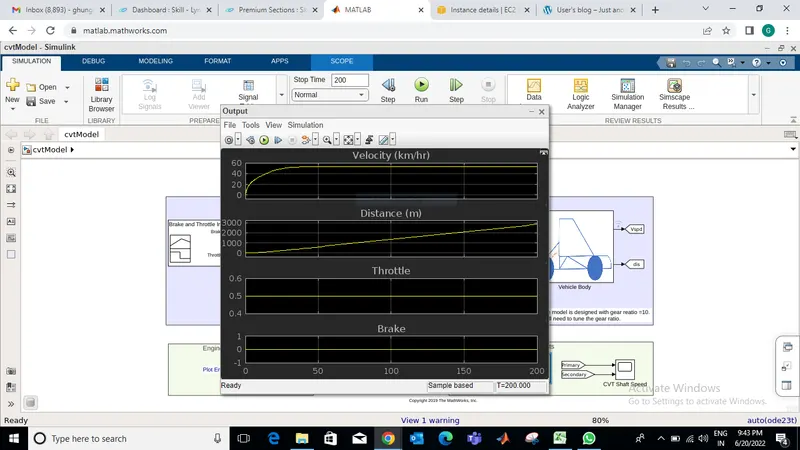
As we can see in above output, we have out in terms of Velocity, Distance coverd, throttle, and break. here in 200 sec the the velocity of system is shown between 55-60 Kmph. The velocity was incresed for specific time and ater that its constant through out the time, the reason behind this we have provided constant throttle to the system, If we have provided more throttle so the system will gain more velocity but for this default case our throttle is same i.e. 0.5. As we can see in next graph the distance covered by out vehicle is continuously in increasing state the totle distance covered is near about 2800m. if we increase our velocity by providing more throttle possible we can cover more distance in same time period. Also for this default system we provided zero break.
for this system we did not use any gear system instead of gear system we have used CVT i.e Continuously Verible Transmission System which provide infinit gear ratio. CVT has two pully primary and secondary. One pully conncted to engine and another one conncetd to wheels. Both pully conncted by belt to run the vehicle. Following is the CVT output in terms of RPM.
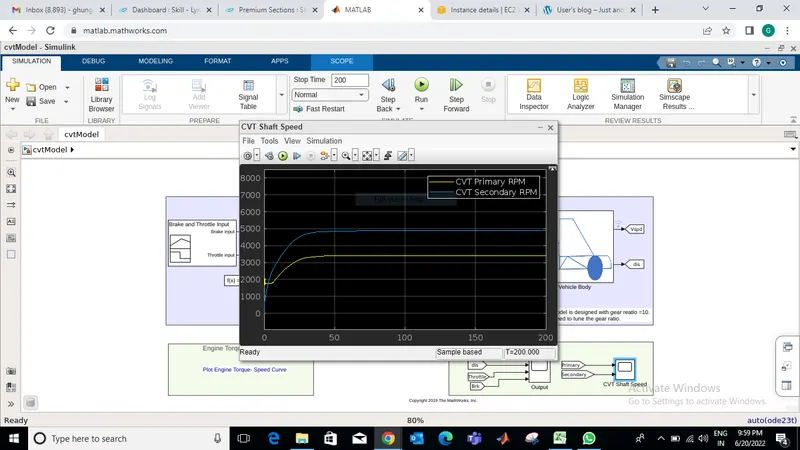
Speed of vehicle some how depend on CVT and its RPM or rotation.
Case II:
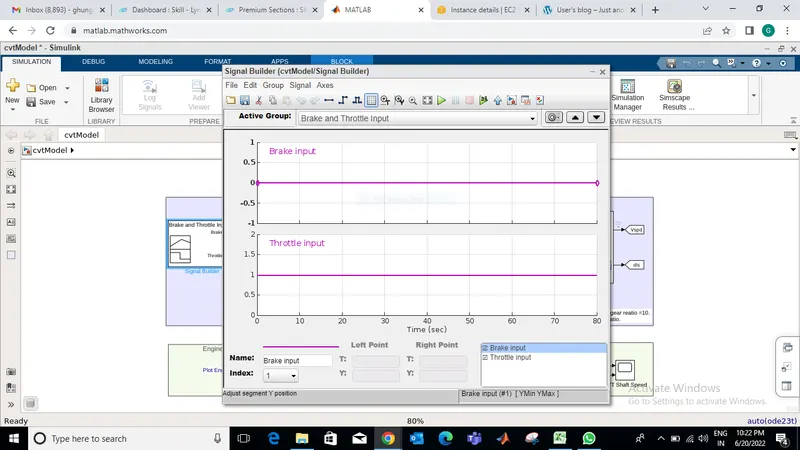
Here in IInd case I have change the throttle to near to 1 instead of 0.5 so we have observe changes in output result such as increase in velocity also in this case we cross more distance in same time. below are the result.
Input:
Output:
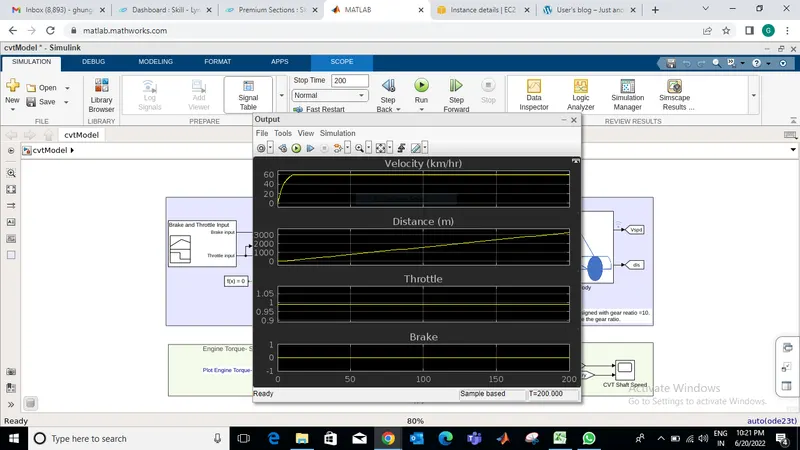
As we can see in above input and outpu img chnages are seen. because of more throttle we gain more output in terms of velocity and distance.
If we provided more throttle we can get in more no. in output.