Project
AIM:
TO study analyse and make a detailed report on BAJA All-Terrain Vehicle (ATV) model using Simulink & compare between its different modes.
OBJECTIVE:
Prepare a technical report explaining the model properties & comments on the results.
THEORY:
All-Terrain Vehicle (ATV)
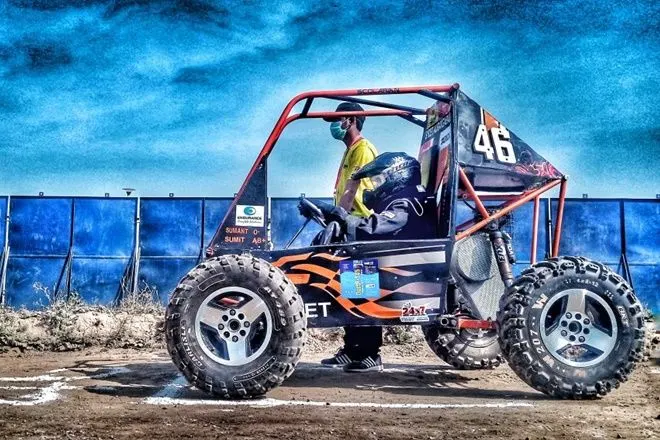
An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad, as defined by the American National Standards Institute (ANSI) is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles. Although it is a street-legal vehicle in some countries, it is not street-legal within most states, territories and provinces of Australia, the United States or Canada.
By the current ANSI definition, ATVs are intended for use by a single operator, although some companies have developed ATVs intended for use by the operator and one passenger. These ATVs are referred to as tandem ATVs.
The rider sits on and operates these vehicles like a motorcycle, but the extra wheels give more stability at slower speeds. Although most are equipped with three or four wheels, six-wheel models exist and existed historically [ for specialized applications]. Multiple-user analogues with side-by-side seating are called utility terrain vehicles (UTVs) or side-by-sides to distinguish the classes of vehicle
BAJA SAE
Baja SAE is an Collegiate Design Series competition run by the Society of Automotive Engineers International (SAE International). Teams of students from universities all over the world design and build small off-roads cars. The cars all have engines of the same specifications.
The goal in Baja SAE racing is to design, build and race off-road vehicles that can withstand the harshest elements of rough terrain. The vehicles used in Baja SAE racing are often similar in appearance to dune buggies. Before 2007, the events were called "Mini Baja."
Simulink ATV model:
Following ATV model without dashboard.
Model image
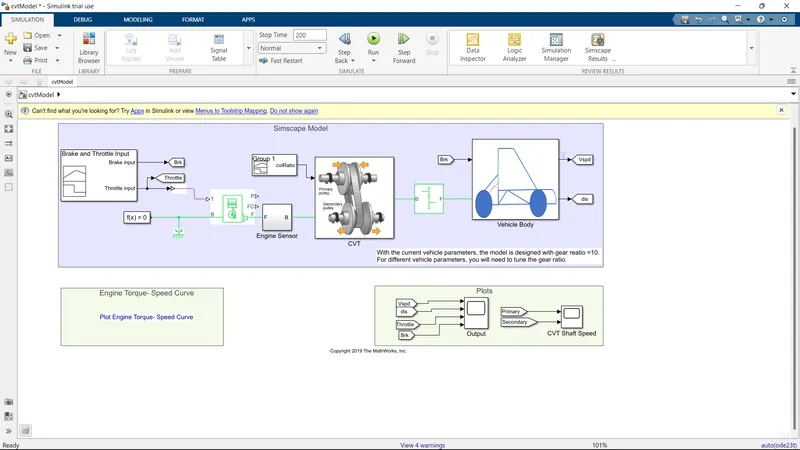
In the above model the following simulation block is used. They are,
- Single builder – The single builder block allows you to create interchangeable groups of piece wise linear signal sources and use them in a model.
- Goto - The Goto block passes its input to its corresponding from block. From & Goto blocks allows you to pass a signal from one block to another without actually connecting them.
- Simulink - PS convertor – it converts the Simulink input signal to a physical signal.
- Generic Engine – It represents a system level model of spark ignition and diesel engines suitable for use at the initial stages of modelling with basic parameters.
- Solver Configuration – It specifies the solver parameters that your model needs before you can begin the simulation.
- Mechanical Rotational Reference – It represents a reference point for all mechanical rotational parts.
- Engine Sensor – It’s a sub-system model consist of the following simulation blocks.
Engine sensor Image:
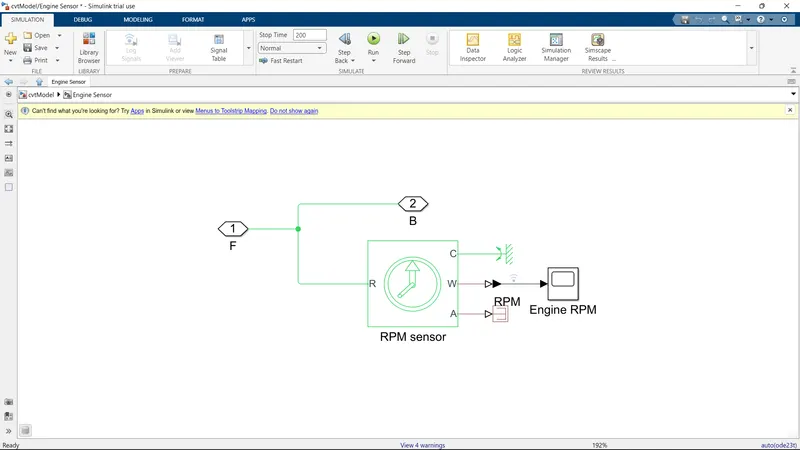
- Ideal Rotational Motion Sensor – The block that converts an across variable measured between two mechanical rotational nodes into a control signal proportional to angular velocity or angle.
- Mechanical Rotational Reference – It represents a reference point for all mechanical rotational parts.
- PS - Simulink convertor – Converts the physical input signals to Simulink signals.
- Scope – Display signals that generated during simulation.
- PS terminator – Use this block to terminate physical signal outputs.
8. CVT – It’s a sub-system model consist of following blocks.
CVT image:
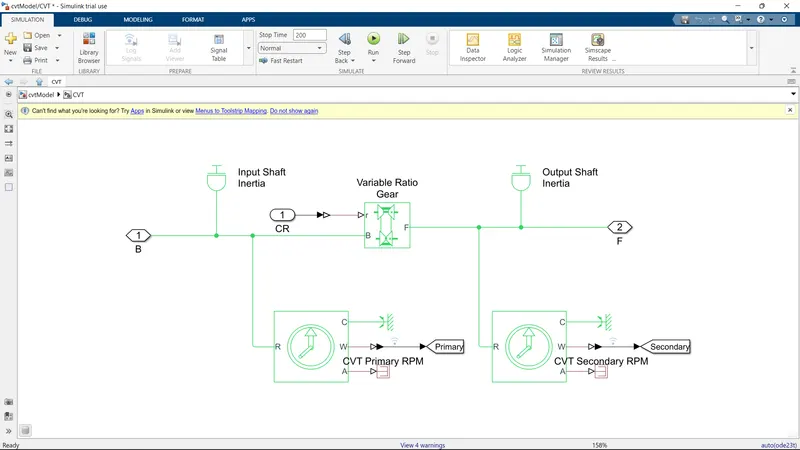
- Inertia – The block represents an ideal mechanical rotational inertia.
- Ideal Rotational Motion Sensor – The block that converts an across variable measured between two mechanical rotational nodes into a control signal proportional to angular velocity or angle.
- Mechanical Rotational Reference – It represents a reference point for all mechanical rotational parts.
- PS - Simulink convertor – Converts the physical input signals to Simulink signals.
- Goto - The Goto block passes its input to its corresponding from block. From & Goto blocks allows you to pass a signal from one block to another without actually connecting them.
- PS terminator – Use this block to terminate physical signal outputs.
- Variable Ratio Transmission – It represents a variable ratio gear box such as implemented by mechanical belt CVT, electric or hydraulic transmission.
9. Simple Gear – It represents a fixed ratio of the gear or gear box.
10. Vehicle Body – It's a sub-system model consists of the following simulation blocks.
Vehicle Body image:
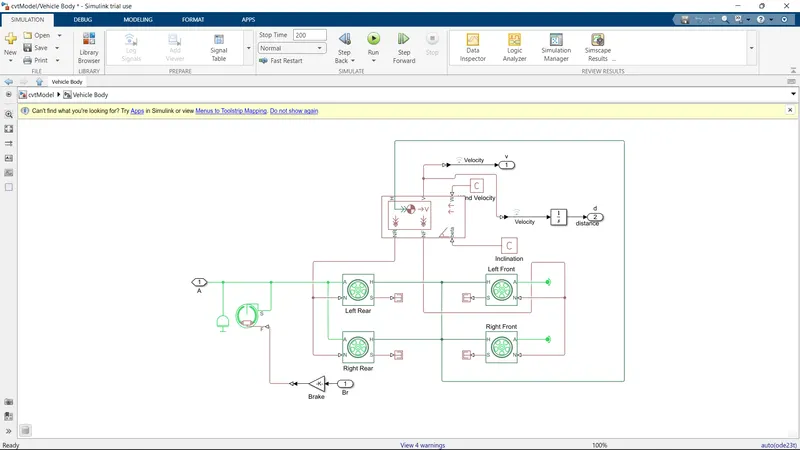
- Inertia – The block represents an ideal mechanical rotational inertia.
- Double Shoe Brake – Represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert friction torque on a shaft connected to the drum.
- Gain – Gain block is use to multiply the given input and give an output value.
- Tyre – It represents the longitudinal behaviour of a highway tire characterized by the tyre magic formula.
- PS terminator – Use this block to terminate physical signal outputs.
- Vehicle Body – It represents a two–axel vehicle body in longitudinal motion. The block accounts for road incline, aerodynamic drag, body mass and weight distribution between axles due to acceleration and road profile.
- PS constant – The block creates a physical signal constant.
- PS - Simulink convertor – Converts the physical input signals to Simulink signals.
- Integrator- The integrator block outputs the value of the integral of its input signal with respect to the time.
11. From – The block accepts a signal from a corresponding Goto block. From & Goto blocks allows you to pass a signal from one block to another without actually connecting them. The data type of the From block is same as Goto block.
12. Scope – Display signals that generated during simulation.
Input for the model
Image of workspace:
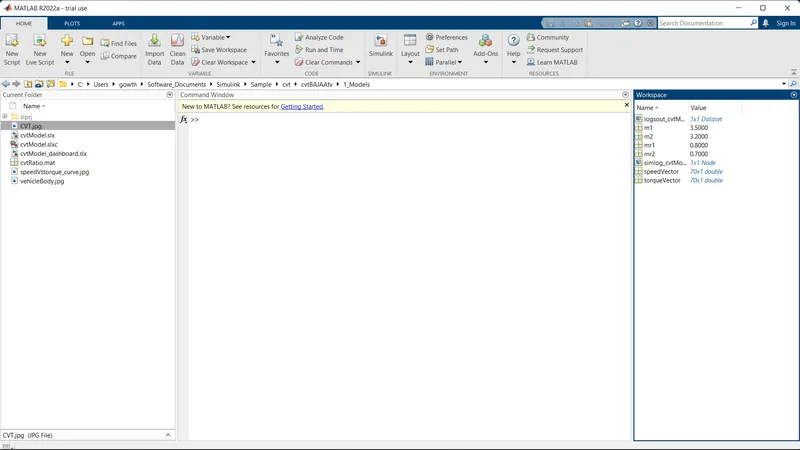
- The following are the variable inputs to the model.
- The variable m1, m2 stands for the mass for the inertial at input shaft and the output shaft at CVT transmission.
- The variable ‘Speed vector’ & ‘Torque vector’ are the engine parameters for the Generic engine. Which provides us the relation between torque and rpm of the engine.
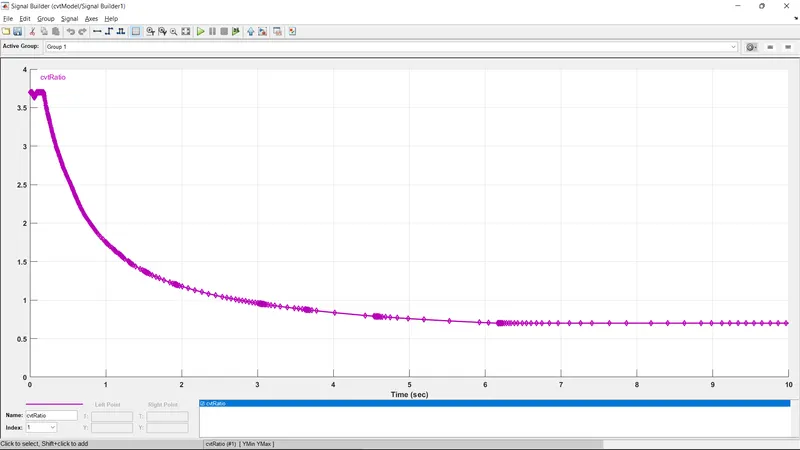
- Using Signal Builder block we have the given Throttle & Brake as input and also the CVT ratio is changed with time.
Signal Builder image.
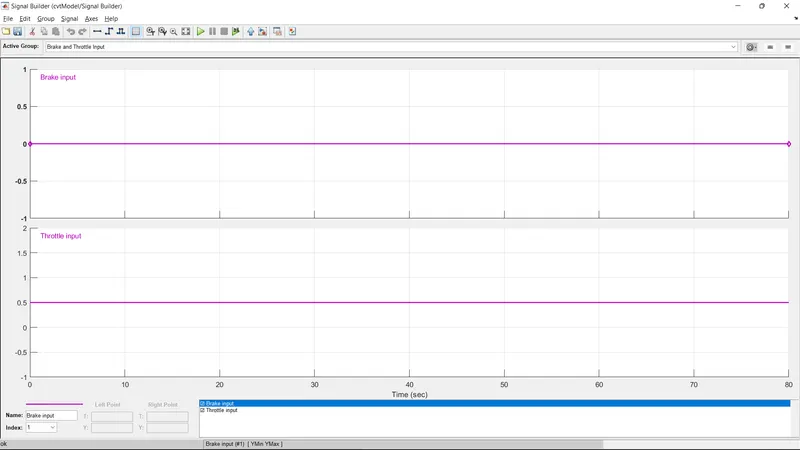
CVT ratio signal builder image
Workflow of the model.
- The initial condition of the engine block is already set according to the engine parameters we have and then according to the throttle input engine changes its parameters of speed, torque and others. For this model, the engine parameters are provided by using the variables ‘Speed vector’ & ‘Torque vector’.
- After getting the throttle input, it provides the rpm, torque and various factors depending upon the engine parameters.
- The output from the Generic engine is the pass through the engine sensor block where it records the rpm of the engine during the period of simulation and then it moves towards the CVT transmission.
- In CVT block, it takes the two inputs one from the engine and another from the signal builder block which provides the CVT ratio.
- There are two ideal rotational sensor blocks & two inertia blocks each for input and output shafts respectively, and then there is the variable ratio gear box which changes its gear ratio during the period of simulation according to the given CVT ratio.
- After the signal from the CVT block it passed through the simple gear block which we can say acts as a differential gear box before passing to the vehicle body.
- In the vehicle body block, it requires two inputs one from the engine which we get through the simple gear block and another is the brake input.
- Since our model is designed based on two-wheel drive vehicle, The signal from the engine is provided to both the rear wheels.
- Since there will be rotational inertia of the shafts so it is then connected to the engine input signal before it reaches the tire.
- The other input brake is provided to the double shoe brake block, but before it reaches there it passes through the gain block which we can say acts as an intensifier for the break input (multiples the input force) in this gain factor is 1000.
- As brakes are indirectly connected to the input power of wheels, hence the output from the double shoe brake block is connected to the engine input signal before it reaches the tire.
- Here there is another vehicle body block inside the block which accounts for road incline, aerodynamic drag, body mass and weight distribution between axles due to acceleration and road profile. This helps the vehicle dynamics data provided to the block it distributes the normal forces on the tire accordingly.
- One more output data we get from the vehicle body block that is velocity.
- As the velocity signal passing through the integrator block, it provides the distance covered by the vehicle.
- We have the results of the simulation in three scope data in which one has engine rpm, another has the rpm of the primary and secondary shafts of CVT transmission and the other has velocity, distance, throttle & brake values of the vehicle.
RESULTS:
The simulation runtime 200 seconds.
Engine RPM image:
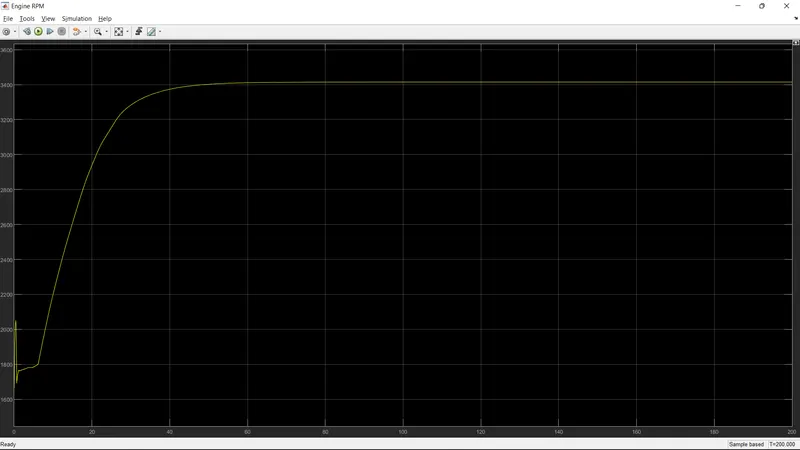
- Initial rpm of engine is defined as the 1750 rpm, then the throttle value becomes a constant input the engine rpm changes accordingly.
- Since the throttle value is constant through the complete simulation after a simulation after a certain duration engine rpm becomes constant.
CVT shaft Image:
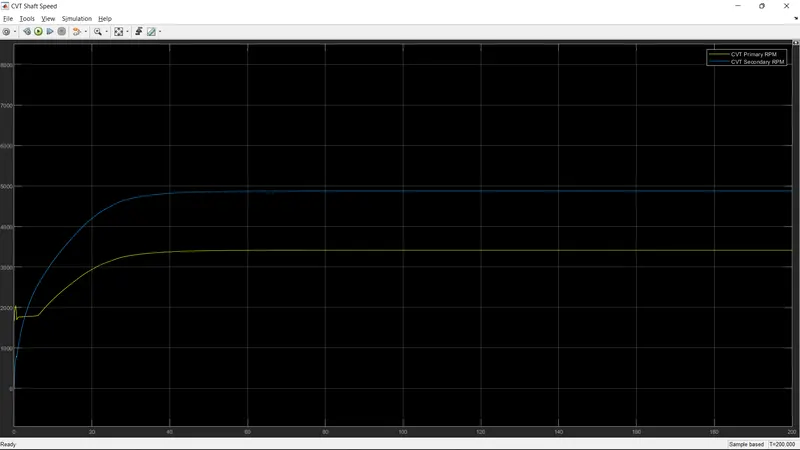
- As the primary shaft is connected to the engine it looks similar to the engine rpm but due to the inertia and other factors the primary shaft rpm will not be the same as the engine rpm and have some losses.
- Hence primary shaft will not be same as the engine but will have similar rpm with considering some losses.
- According to the CVT ratio the secondary shaft speed is achieved.
OUTPUT:
Output image:
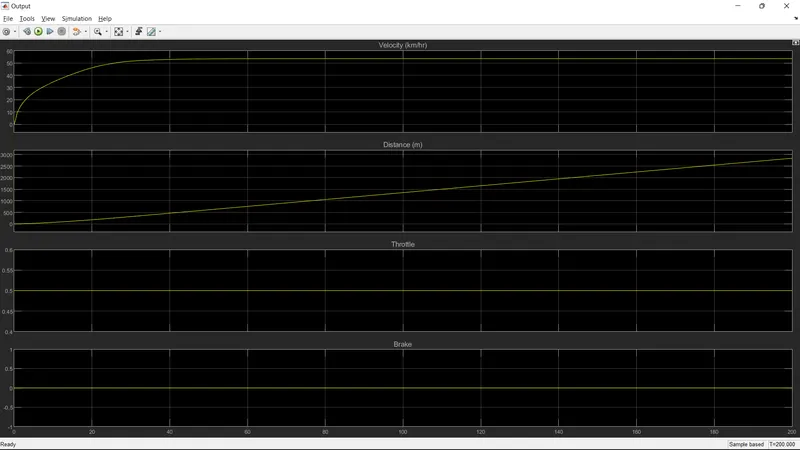
- We can verify that the throttle value & brake value are constant during the complete simulation.
- Initially, the velocity of the vehicle is increased at a great rate and then a certain point when the engine reaches its constant rpm, the vehicle velocity becomes constant.
- We know that integration of the velocity gives us the distance travelled by the vehicle.
- Hence during the initial simulation time, the distance travelled looks like a parabolic curve and then as velocity becomes constant the distance travelled becomes a straight line.
BAJA ATV Model (with dashboard)
This model is same as the earlier model only the difference is we can change the throttle and brake value during the simulation is running and then we can observe its results.
Model image:
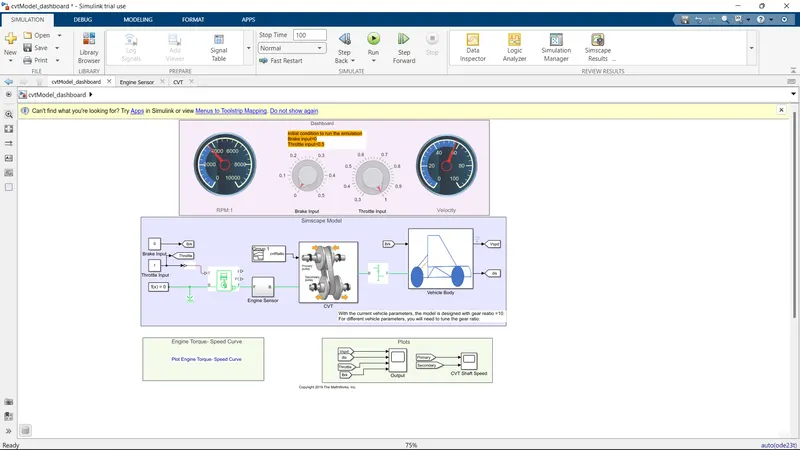
In the above model the following blocks are added to the previous model (BAJA ATV model without dashboard).
- Circular Gauge – Display an input value on a customized gauge.
- Knob – Set a value to tune parameters or variable.
- Constant – Specified constant value can get as output.
Remaining all blocks are same and they are all explained in the previous model (BAJA ATV model without dashboard)
Input for the model
Image of workspace:
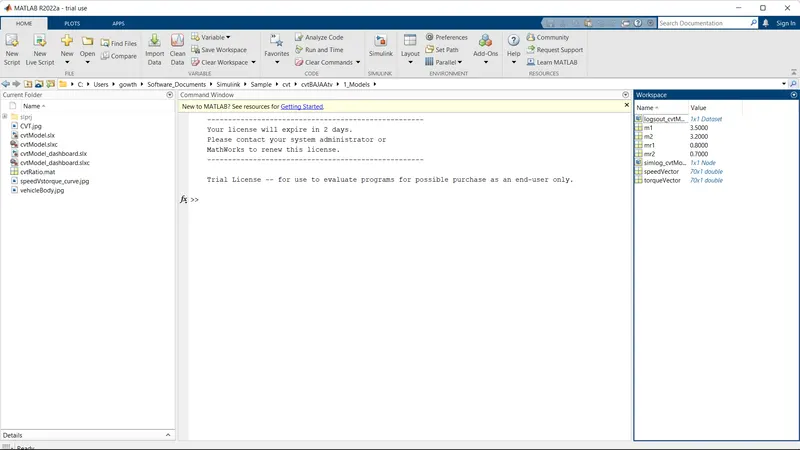
- The following are the variable inputs to the model.
- The variable m1, m2 stands for the mass for the inertial at input shaft and the output shaft at CVT transmission.
- The variable ‘Speed vector’ & ‘Torque vector’ are the engine parameters for the Generic engine. Which provides us the relation between torque and rpm of the engine.
- Using the knob, we are going to provide the throttle & break input while the simulation is running and its limits are provided on the knob.
- Using the signal builder block we have given the CVT ratio which varies with time.
CVT ratio signal builder image
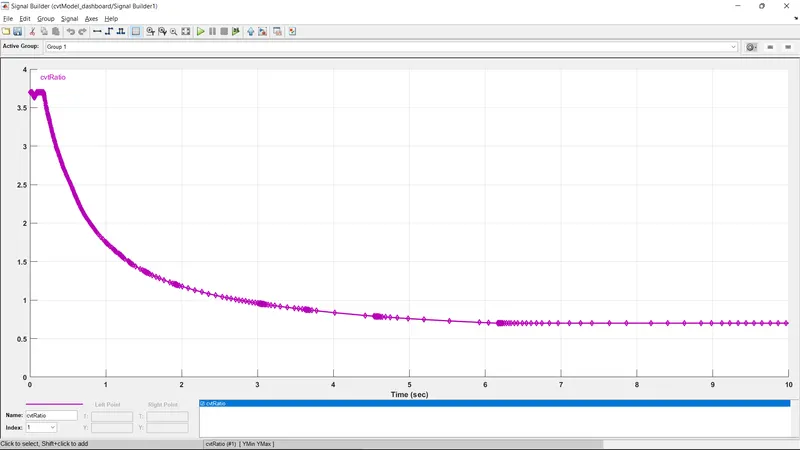
Workflow of the model.
The workflow is same as the previous model, the only change is the throttle and brake inputs.
- The throttle and brake input are provided by the user using the user interface knob block which allow the user to change the throttle and brake inputs while the simulation is running. Remaining all are same.
RESULTS:
- Case 1 – Brake = 0 & Throttle = 0.5 (100 seconds)
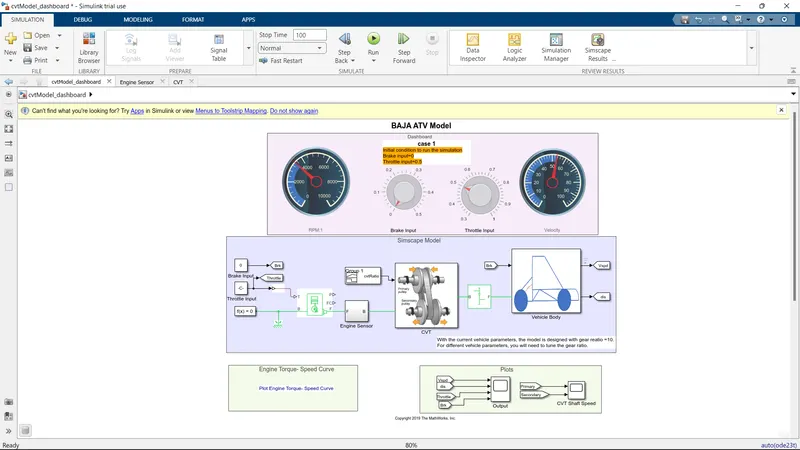
Simulation video:
Click here to see the simulation video of ATV model with brake 0 & throttle 0.5
Engine rpm plot:
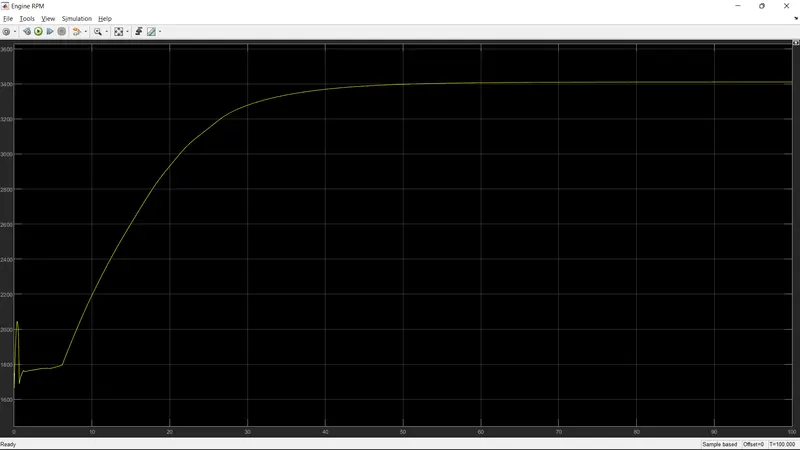
- Initial rpm of engine is defined as the 1750 rpm, then the throttle value becomes a constant input the engine rpm changes accordingly.
- Since the throttle value is constant through the complete simulation after a simulation after a certain duration engine rpm becomes constant.
CVT shaft Image:
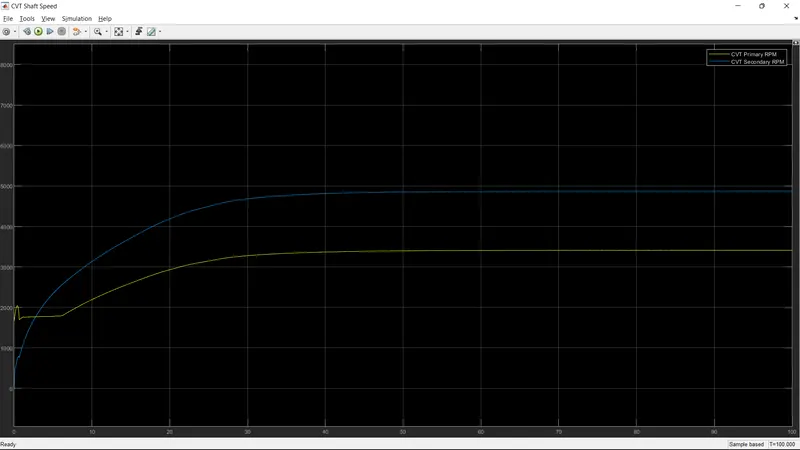
- As the primary shaft is connected to the engine it looks similar to the engine rpm but due to the inertia and other factors the primary shaft rpm will not be the same as the engine rpm and have some losses.
- Hence primary shaft will not be same as the engine but will have similar rpm with considering some losses.
- According to the CVT ratio the secondary shaft speed is achieved.
OUTPUT:
Output image:
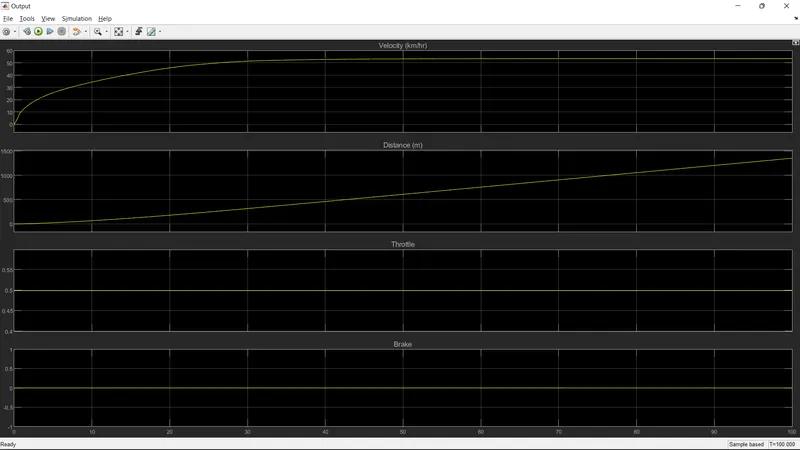
- We can verify that the throttle value & brake value are constant during the complete simulation.
- Initially, the velocity of the vehicle is increased at a great rate and then a certain point when the engine reaches its constant rpm, the vehicle velocity becomes constant.
- We know that integration of the velocity gives us the distance travelled by the vehicle.
- Hence during the initial simulation time, the distance travelled looks like a parabolic curve and then as velocity becomes constant the distance travelled becomes a straight line.
2. Case 2 – Brake = varying & Throttle = 0.5 (100 seconds)
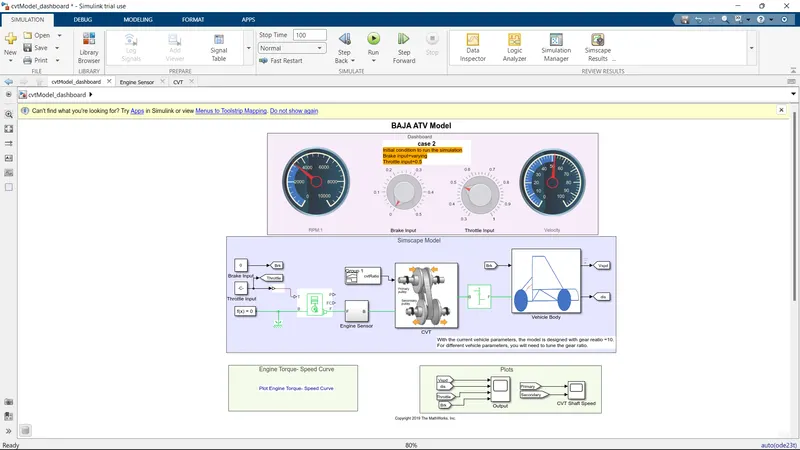
Simulation video:
Click here to see the simulation video of ATV model with brake varying & throttle 0.5
Engine rpm plot:
- The initial rpm of the engine is defined as 1750 rpm, and throttle value is constant.
- From the video we can observe that until the first 30 seconds of simulation the throttle value is constant and no brake is applied, so accordingly the engine rpm is controlled by the throttle input.
- Then as we start applying the brake gradually, the engine rpm starts to decline slowly.
- But brake below 0.1 makes the engine rpm increase slowly than decreasing it.
- Depending upon the brake value, the engine rpm declines faster for high brake value and vice versa.
CVT shaft Image:
- As the primary shaft is connected to the engine it looks similar to the engine rpm but due to the inertia and other factors the primary shaft rpm will not be the same as the engine rpm and it will have some losses.
- Hence primary shaft will not be same as the engine but will have similar rpm with considering some losses.
- According to the CVT ratio the secondary shaft speed is achieved.
OUTPUT:
- We can verify that the throttle is constant throughout the complete simulation.
- The brake line shows us how much brake is applied and also the duration of brake applied.
- Here we can easily observe the effect of applied brake value on the velocity of the vehicle, as the brake value increases velocity starts to decreases.
- But if we observe clearly when we apply brake at below 0.12 or 0.1 value velocity is still increasing but at a slower rate and above those values, we can see velocity starts decreasing at a rate depending upon the value of applied brake.
- According to the power supplied by the engine, we can observe that velocity is also affected by brake as same as the engine is affected. And the velocity graph also looks similar to the engine rpm graph only just got multiplied due to CVT and simple gear and also got affected due to other vehicle dynamic losses.
- We know integration of the velocity gives us the distance travel by vehicle. Hence during the initial simulation time, the distance travelled looks like a parabolic curve and then as velocity becomes constant the distance travelled becomes a straight line.
3. Case 3 – Brake = 0 & Throttle = Varying (200 seconds)
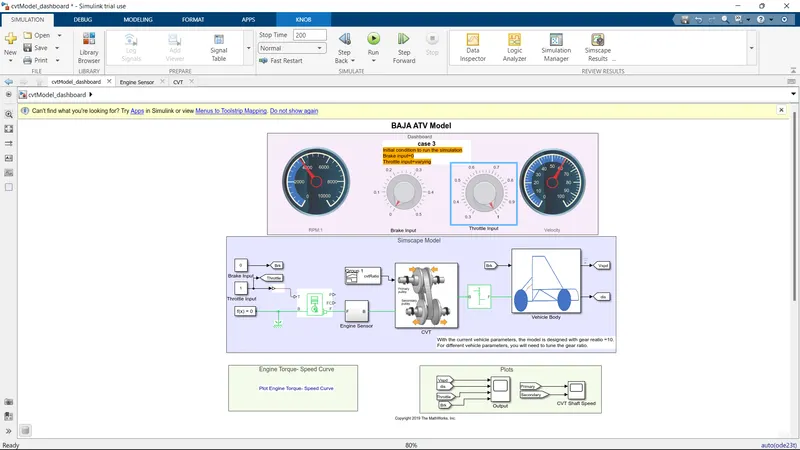
Simulation video:
Click here to see the simulation video of ATV model with brake 0 & throttle varying
- As we observe in the video, we can see that when we did set the throttle values like 0.8, 0.6, 0.5,0.4 the engine and the vehicle stop quickly within the initial 25 seconds of simulation.
- As in the parameters of the engine block, the initial rpm of the engine is 1750 rpm as defined and we can’t reach the initial rpm at the start by keeping the throttle value below 0.45
- So, the throttle value 0.45 and we can observe that the engine is running properly and then the speed of the engine starts to increase to the great range resulting in the increment of the vehicle speed.
Engine rpm plot:
- The initial rpm of the engine is defined as 1750 rpm, and throttle value is constant.
- Initially, the throttle is constant (1) for some time until the rpm of the vehicle starts to become constant.
- Then we change the throttle value, the engine rpm moves increases and decreases.
- When we increasing the throttle, the rpm of the engine increases and vice versa.
- In the plot we can see that increasing the throttle the rpm increases rapidly (with steep slope). While decreasing the throttle the rpm of the engine decreases gradually (curve line).
CVT shaft Image:
- As the primary shaft is connected to the engine it looks similar to the engine rpm but due to the inertia and other factors the primary shaft rpm will not be the same as the engine rpm and it will have some losses.
- Hence primary shaft will not be same as the engine but will have similar rpm with considering some losses.
- According to the CVT ratio the secondary shaft speed is achieved.
OUTPUT:
- We can verify that the throttle is constant throughout the complete simulation.
- The throttle line shows us how much throttle is applied and also the duration of the applied throttle.
- Here we can easily observe the effect of applied throttle value on the velocity of the vehicle, as the throttle value increases velocity starts to increase rapidly but when the applied throttle value decreases the velocity vehicle decreases slowly.
- According to the power supplied to the engine, we can observe that velocity is also affected by throttle as same as the engine is affected, And the velocity also looks similar to the engine rpm
- The distance travelled looks parabolic curve and then as velocity becomes constant the distance travelled becomes a straight line.
CONCLUSION:
- The model helps us to verify the performance of the vehicle under the constructed brake system and throttle system.
- We also observe the performance of breaking and the throttle system.