Project
Aim : To study and analyze the baja ATV model using simulink.
Objective : To prepare technical report of ATV with and without Lookup table.
Theory :
- All-Terrain Vehicle : An ATV is also known as light utility vehicle(luv) or quad.It is designed as a motorized off-highway vehicle designed to travel on four low-pressure or non- pneumatic tires having a seat designed to be straddled by the rider and handlebars for steering control.It is basically designed to travel on all types including rough ground.
- Generic Engine : It is an IC engine,either petrol or diesel,where RPM and torque are set.
- Simple Gear : It is used to control the speed of the vehicle depending on gear ratio.
- Vehicle Body : It is used as the kerb weight of the vehice.
- Double brake shoes : It is an frictional brake with two pivoted rigid shoes symmeterically installed inside and outside a drum and operated by one actuator.The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum.
- Tires : It is connected as two on either sides of the both the axle. Stimulation blocks functions :
- Signal builder : to input the throttle and braking
- Generic engine : to input torque and rpm
- Interia : to represent stable interia
- Ideal Rotational Motion Sensor : output rpm values
- Variable Gear Ratio : to vary speed of engine with gear ratio
- Simple Gear : to control the speed with gear ratio
- Double Brake Shoe : braking
- Vehicle Body : weight of the vehicle
- Converters and Reference used as required and gauges created as dashboard Inputs :
- Mass of the vehicle : 350kgs
- Gear Ratio : 11
- Throttle : 0.6
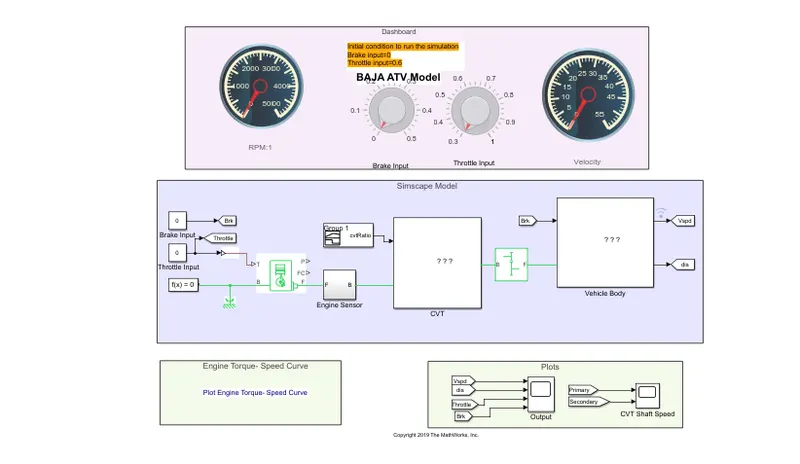
- Braking : 0.1 Model without dashboard in initial condition :
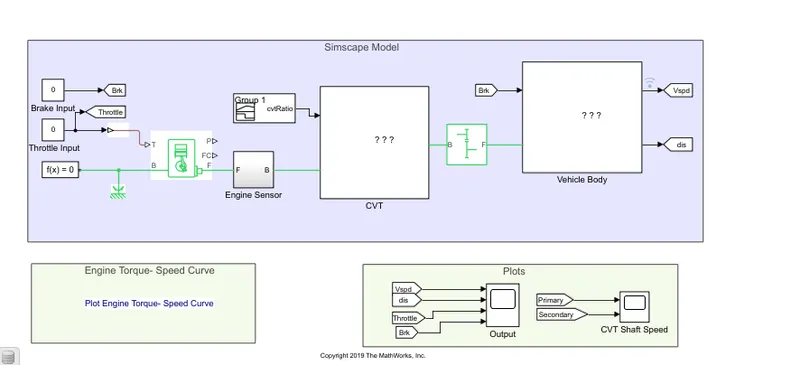 Created Sub sytem model of Engine Sensor , CVT , Vehicle Body :
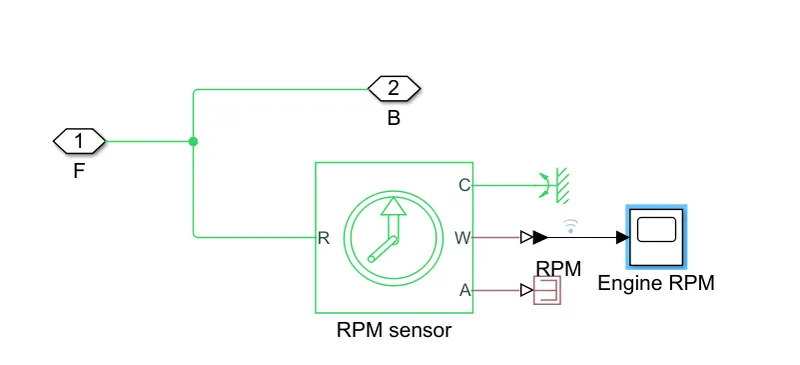
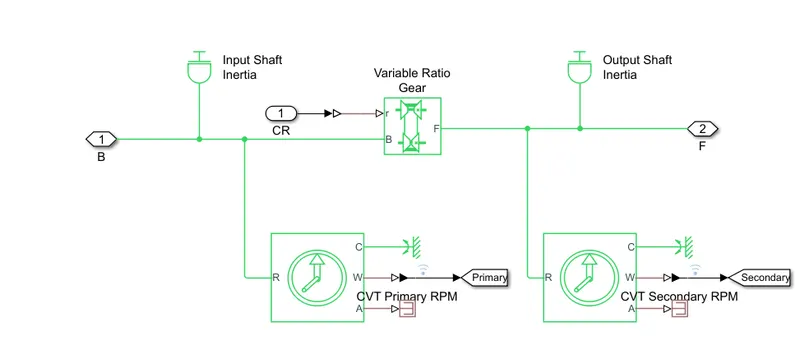
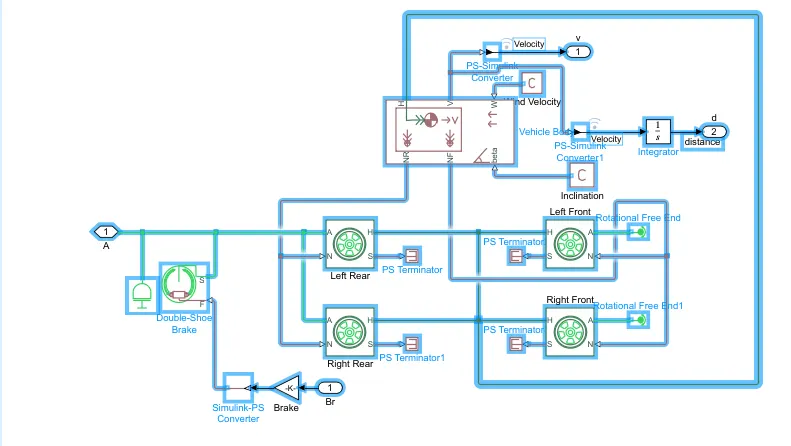
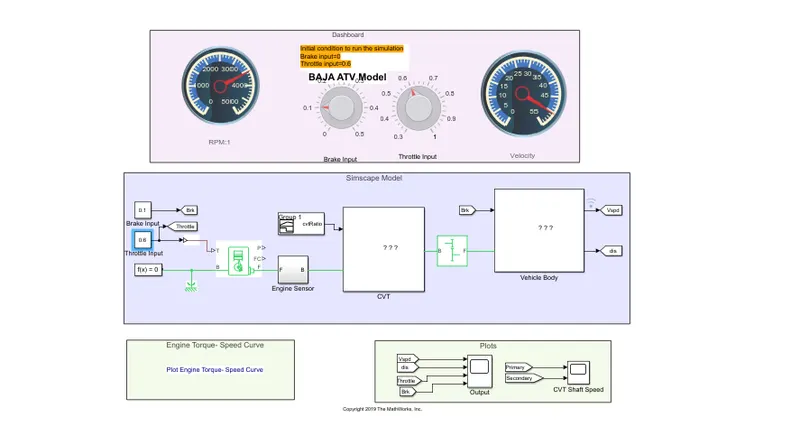
- Model with dashboard
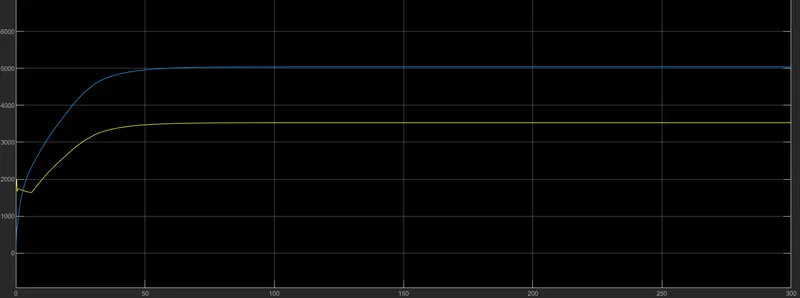
- Output : After the parameters are user entered as per given above we can observe the velocity is 55 and rpm is 3500
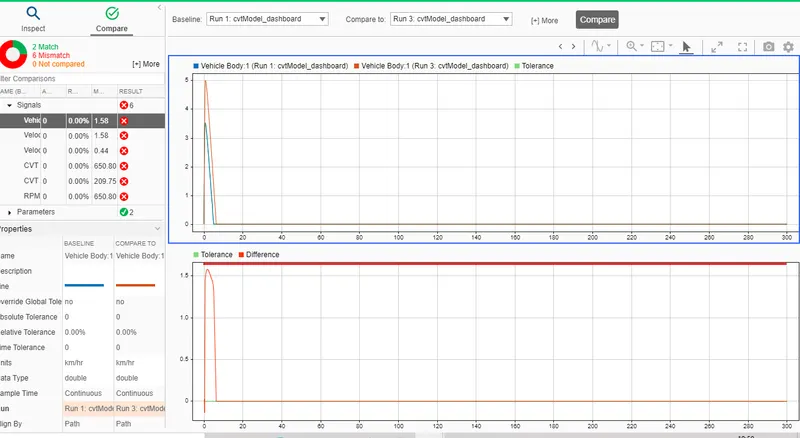
- comparing with the help of data inspector for mass of 350kgs and 450kgs
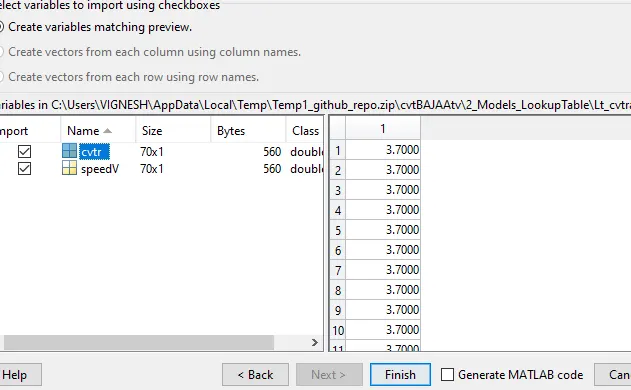
- values of cvtr and speed
-
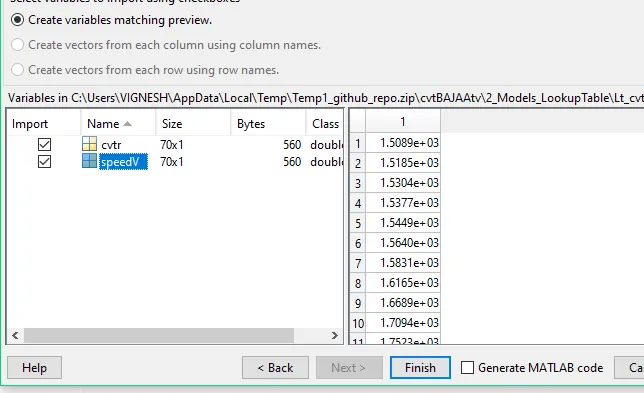
- rpm of primary and secondary pulley
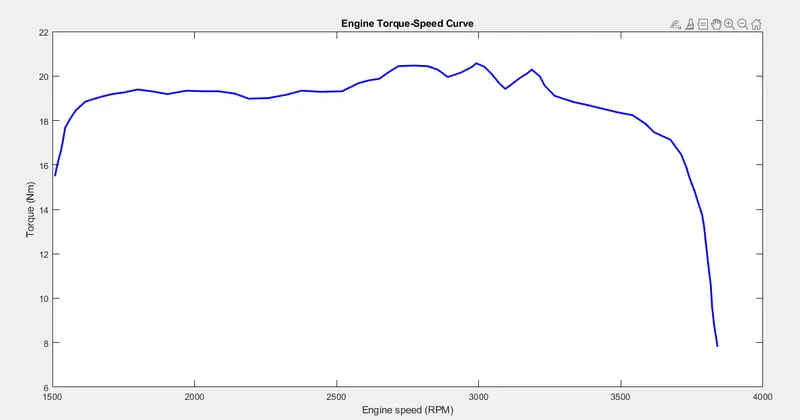
- lookup model
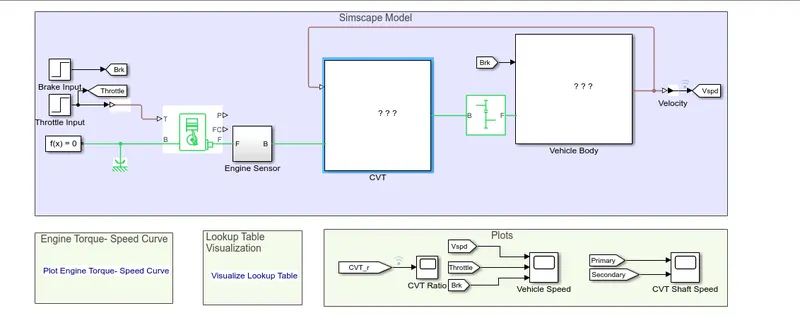
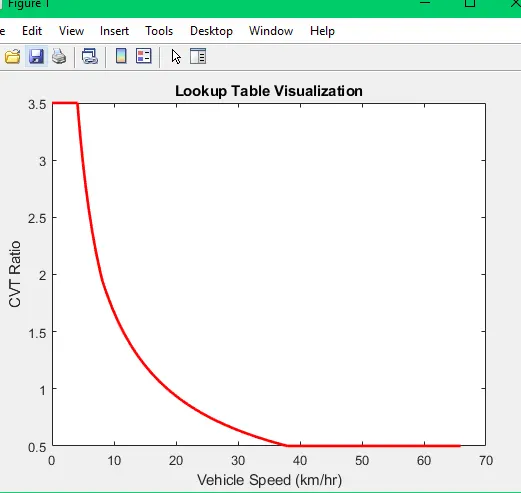
Conclusion : From the above observations we can see that we throttle increases velocity increases when braking is applied the velocity is decreased.