Project 5
Nature and Form
- Nature is a very complex place where we can see countless number of designs.
- We have to just observe the nature around us to find solution for our design needs.
- Nature is evolved over millions of years,So the design is the most optimized.
- So whenever we need to design observe the nature and the answer is their.
- This method of taking inspiration from nature for our design purposes is known as Biomimicry.
- Some designs the nature incorporates are very complex and we have to simplify them so that it will be humanly possible.
Some examples were we took inspiration from nature are given below
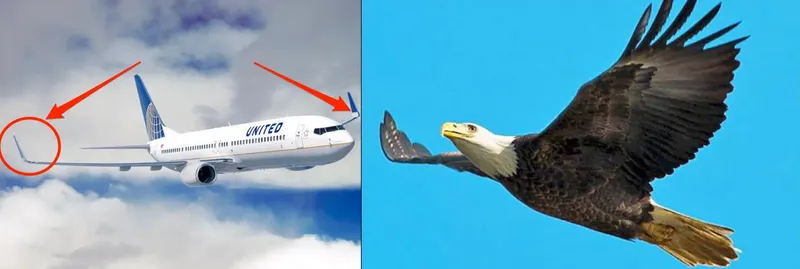
Airplane Winglets inspired from birds.
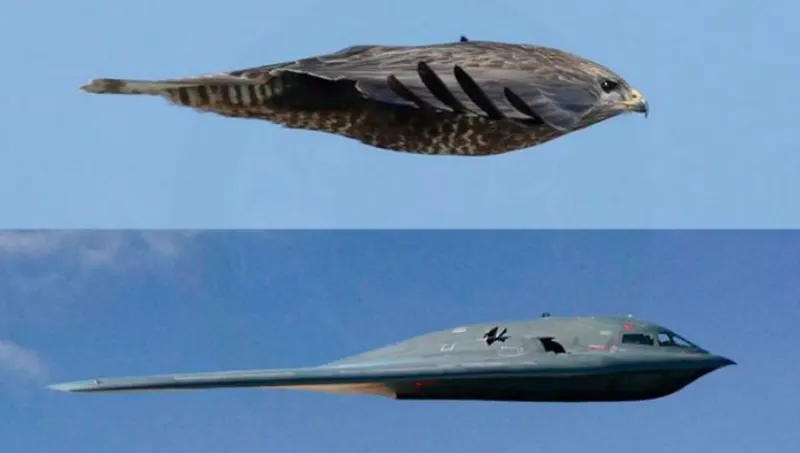
Airplane body inspired from bird body under flight
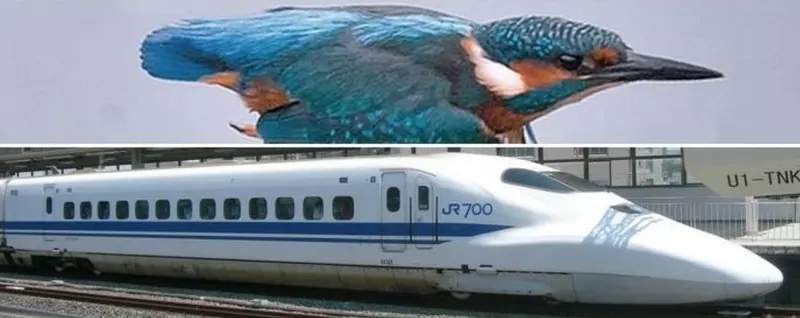
Bullet train inspired from Kingfisher bird.
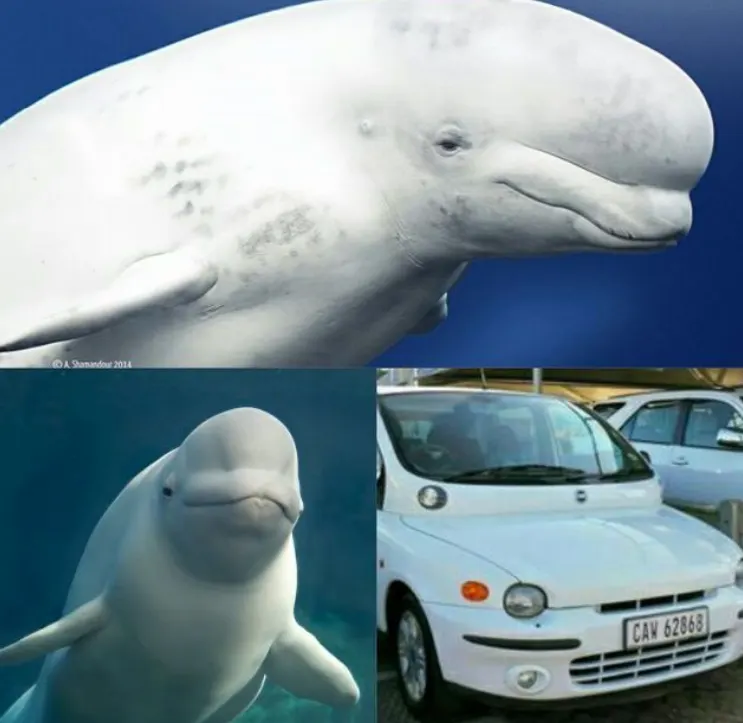
Cars inspired from Animals
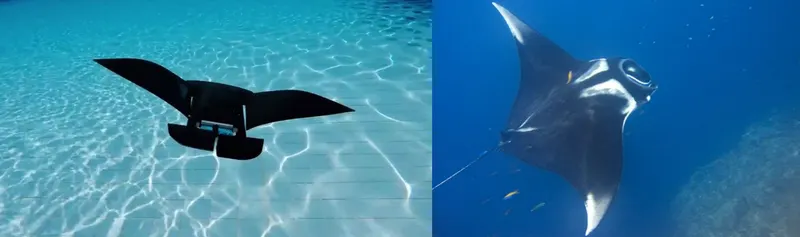
Manta ray robot inspired from living Manta ray
Problem
● Create a Flexible robotic arm for a kitchen robot
● The robotic arm should be flexible.
● The robotic arm should have good motion.
● Easy to manufacture.
● Less weight.
Solution
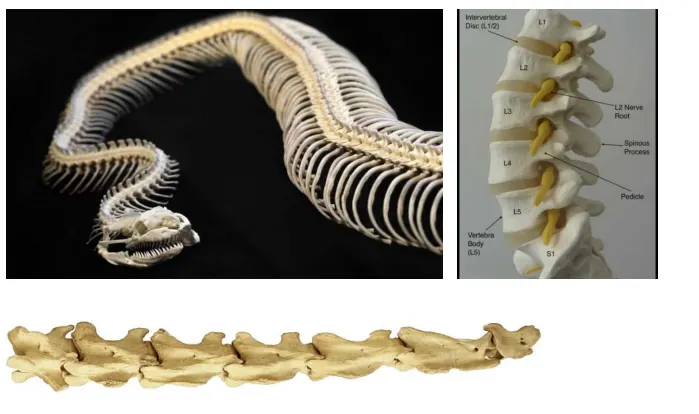
● We can take inspiration from different animals like snake,Giraffe neck,Human vertebrae
etc.
● Some images of the animals are given below
Properties of the above animal parts
● All the above parts of these animal is actually their vertebrae.
● But both of those three works slightly differently.
● The human vertebrae has the least articulation of all three and the bones just rolls on
top of each other with a viscous membrane in between.
● In the giraffe vertebrae the bones slide on each other around a complementary
surfaces.
● The snake vertebrae has the most articulation and has ball joints between adjacent
bones.
● So ,in our case we need good articulation.So we can take the design of the snake
vertebrae.
● The ideation is shown in the next slides.
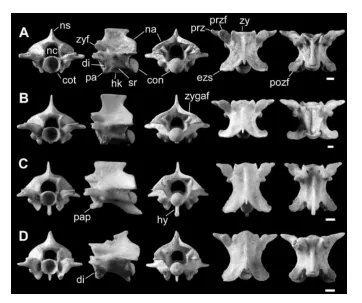
● The above image shows the vertebrae
components in different views.
● We can clearly see the ball and socket joints
● We will be taking this as our inspiration for the
robot
Inspiration and Design
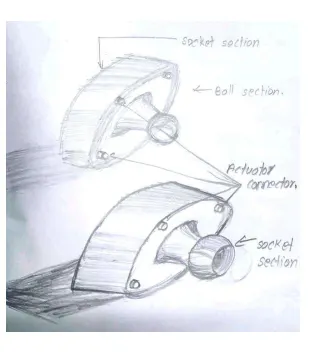
The image on the top is the design with the
ball and socket joint sections
The are end to end connected with ball and
sockets mating together to create the whole
robot.
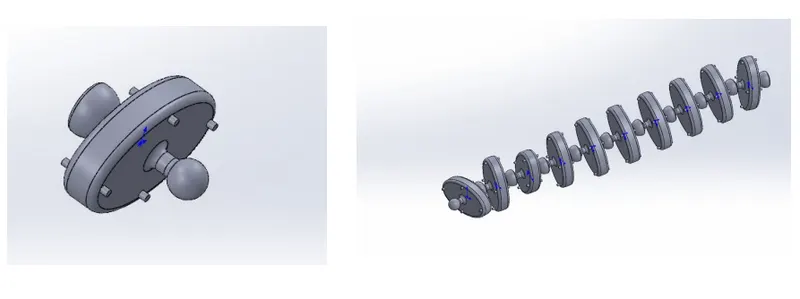
Ball and socket body Ball and socket body interlinked to from the
robot