Project
AIM:
To prepare a technical report of "system-level simulation of an all-terrain vehicle" and explaining the model properties & comments on the results
OBJECTIVE:
- Analyze the cvt model for the given link
- Aware of all the blocks used in the model
- Test run the model and analyze the scope
- Provide a proper technical report as per the model
SYSTEM-LEVEL SIMULATION OF AN ALL TERRAIN VEHICLE
1. ALL TERRAIN VEHICLES:
An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad. is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles. Although it is a street-legal vehicle in some countries, it is not street-legal within most states, territories, and provinces of Australia, the United States or Canada
By the current ANSI definition, ATVs are intended for use by a single operator, although some companies have developed ATVs intended for use by the operator and one passenger. These ATVs are referred to as tandem ATVs
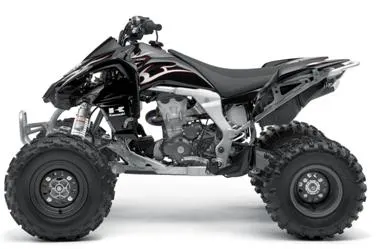
Royal Enfield built and sold the first powered quadracycle in 1893. It had many bicycle components, including handle bars. The Royal Enfield resembles a modern ATV-style quad bike but was designed as a form of horseless carriage for road use
2. CONTINUOUSLY VARIABLE TRANSMISSION (CVT):
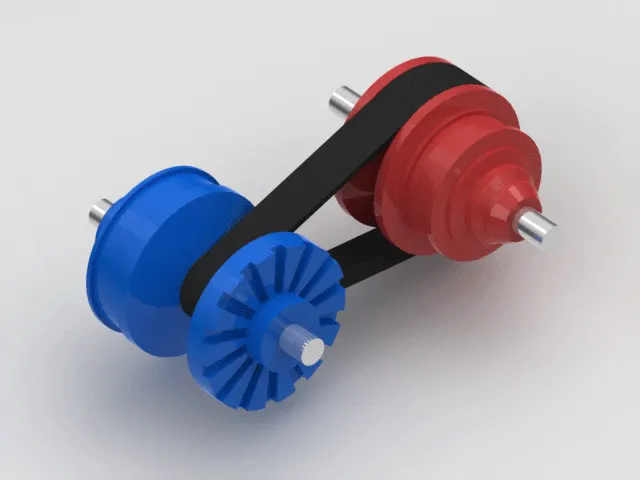
A continuously variable transmission (CVT) is an automatic transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds
CVTs are used in automobiles, tractors, motor scooters, snowmobiles, and earthmoving equipment.The most common type of CVT uses two pulleys connected by a belt or chain, however, several other designs have also been used at times
MODEL:
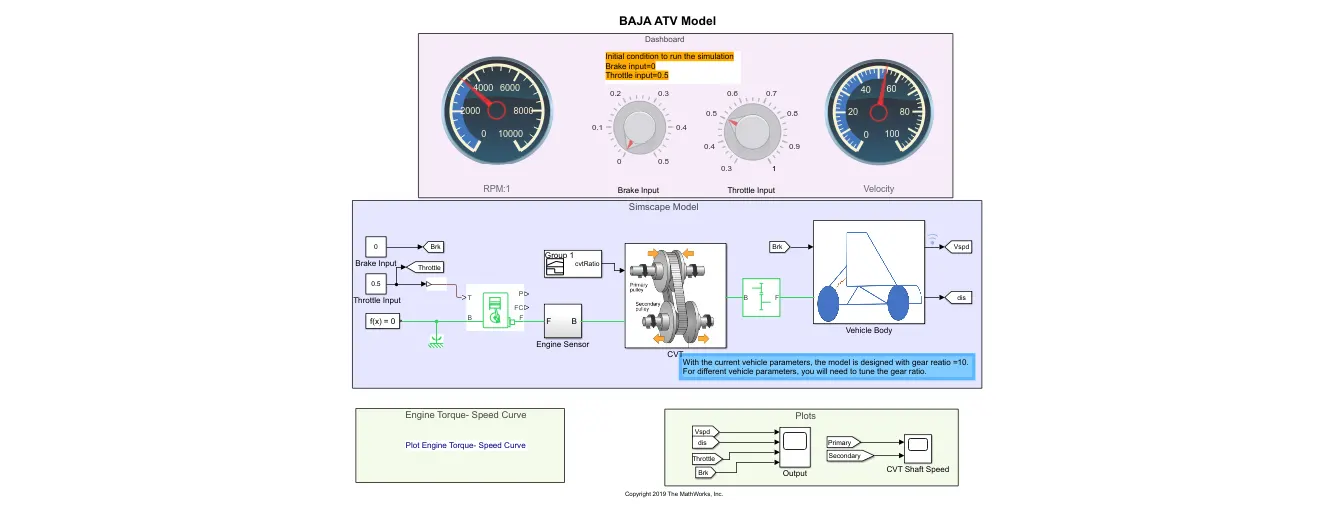
Fig: 1 - CVT of a Terrain Vehicle
EXPLANATION:
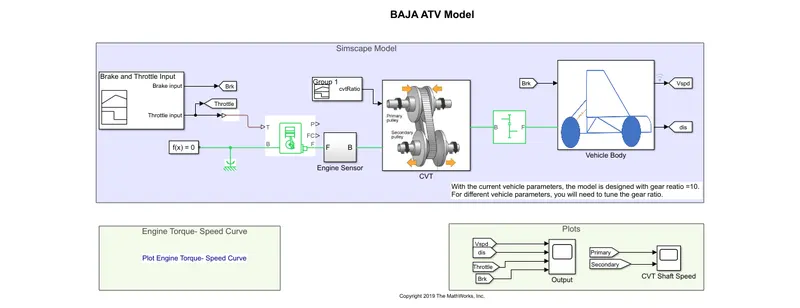
- In this BAJA ATV Model, essentially both of simulink and simscape blocks has used in it. These blocks came up with the reference calculations of previous models in BAJA ATV
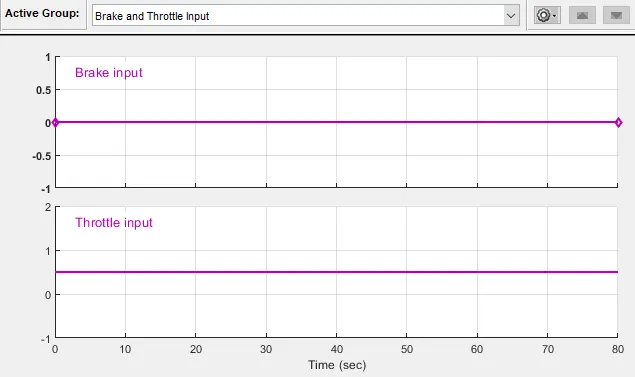
- Here we going analyze these technical blocks which are used to design this continuously variable transmission (CVT). From the beginning, the signal builder block has used to send the inputs of 'brake' and 'throttle' are 0 and 0.5 by the time of 80 seconds
- Simple concept is we going analyze the amount of output(RPM) by giving the amount of input(Throttle), that's why we gives the brake input as 0
- Now the throttle input of simulink signal has have to convert into physical signal, we going to connect the simulink - PS convertor with the output of signal builder
- And it sends to generic engine block as input, this block has Represents a system-level model of spark-ignition and diesel engines suitable for use at initial stages of modeling when only the basic parameters are available. Optional idle speed and red line controllers are included
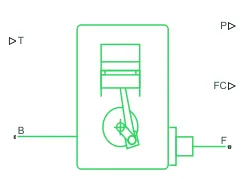
- Here T is the input, B is connected with mechanical rotational reference block to connect the mechanical rotational ports that are rigidly affixed to the frame (ground), F is the output of the engine and remaining are the free ends. The solver configuration block has connected with that
- The output of F is connected with the sub-system which is an engine sensor for monitoring the engine speed. Here RPM sensor block has used in it
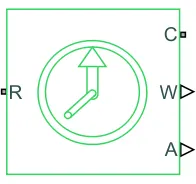
- Here R is the input of this sensor, C is the free end, A is the PS terminator block to terminate physical signal outputs and W is the output of the sensor, it's converts from physical to simulink signal by PS - simulink convertor then it's connect with scope block
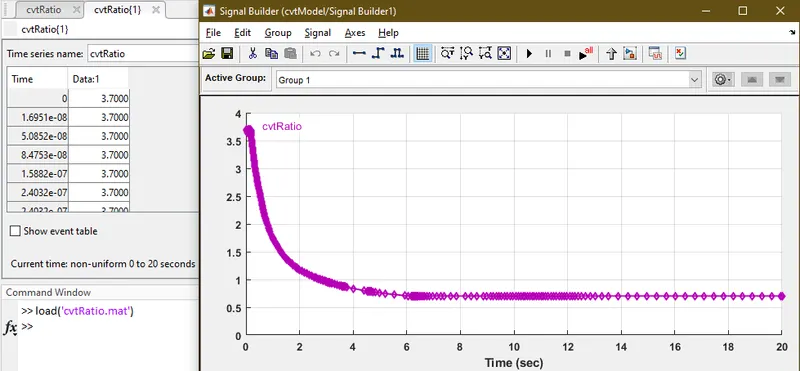
- Then the output of the sub-system B has passed to the another sub-system of CVT block as respectively. For this CVT block, the input has passed to the signal builder by the reference data file of cvtRatio has given which is loaded by the matlab code
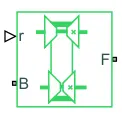
- In the CVT sub-system, the variable ratio transmission block has receives it's input. It has Represents a variable ratio gearbox such as implemented by mechanical belt CVT. The physical signal input r defines the ratio of input to output angular shaft velocities
- Connections B (base) and F (follower) are mechanical rotational conserving ports. On both sides of rotational conversing parts are connected with the inertia shaft as respectively
- The input and output of inertia has given, it represents an ideal mechanical rotational inertia. Commonly in newton's law, an object has applied by the external force to change it's state, if it doesn't change it's state then it is known as inertia. So that inertia is basically came up with the mass and dimension of the object
- For that the inertia block has one or two mechanical rotational conserving ports. The difference is purely graphical, as the ports are rigidly linked. The block positive direction is from its port to the reference point. This means that the inertia torque is positive if the inertia is accelerated in the positive direction
- Then the RPM sensor has connected on the both sides (B & F) in the variable ratio gear, were B side is primary RPM and F side is secondary RPM. The output of both sensors has take out by the goto block, it send signals to From blocks that have the specified tag. If tag visibility is 'scoped', then a Goto Tag Visibility block must be used to define the visibility of the tag. The block icon displays the selected tag name

- On above picture, the output (F) of CVT has connected with the simple gear block which has represents a fixed-ratio gear or gear box. No inertia or compliance is modeled in this block. Output (F) of this block has connected to the sub-system block which is vehicle body construction
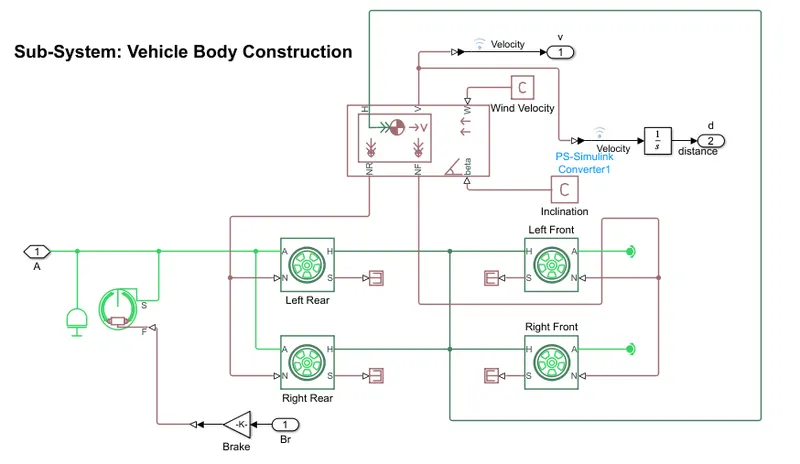
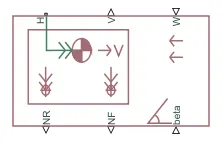
- In this sub-system, there has vehicle body block represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline and weight distribution between axles due to acceleration and road profile. The vehicle have the two number of wheels on each axle
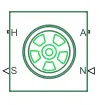
- Now tire block hasgoing to link with the vehicle body block which represents the longitudinal behavior of a highway tire characterized by the tire magic formula
- In vehicle body block, connection W and beta has connected with the PS constant block which has creates a physical signal constant,y = constant. The block output is a physical signal port. Connection NF, and NR are physical signal output ports for vehicle front and rear normal wheel forces, which are connected with the tire block's connection N is a physical signal input port that applies the normal force acting on the tire
- In tire block, connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. It has connected by 4 tire blocks which represents the longitudinal behavior of a highway tire characterized by the tire magic formula
- In vehicle body block, connections V is physical signal output ports for vehicle velocity forces which has converted into simulink signal by using PS-simulink convertor as respectively. And one more connection from V has again converted into simulink signal by PS-simulink convertor which has passed through the integrator block which represents continuous-time integration of the input signal with initial condition 0. This output means as distance travelled bu the vehicle
- Now from the tire, connection A is the mechanical rotational conserving port for the wheel axle. For the front tires, it's going to be connected with the mechanical rotational free end which is used it to allow a node to rotate freely without torque
- For the rear tires, both going to connects with the inertia and double shoe brake block. This double shoe brake block has represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum
- And all the connection S (a physical signal output port that reports the tire slip) in the tire block has connected with PS terminator block which uses this block to terminate physical signal outputs
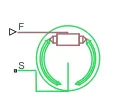
- From this block, connection S is a conserving rotational terminal associated with the drum shaft which is from the rear wheels and connection F is a physical signal port representing the force input to the actuator. The input has got by the brake input with gain block of value 1000. Positive force creates friction torque that resists shaft rotation. Optionally include thermal effects and expose thermal conserving port H by setting Thermal port to Model
- From the all technical block, the outputs of vehicle speed, distance, throttle, brake has conected in a scope and primary, secondary outputs from the CVT sub-system block has connected with another scope as seperately. There is reference plot output has added in this model which is "Engine torque-speed curve"
Fig: 2 - Dashboard of CVT
EXPLANATION:
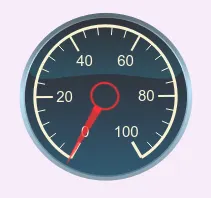
- The above CVT dashboard formation has from the previous kind of model (Fig: 1) has updated with the additional setup included by circular gauges and knobs, which is used to control the inputs and has to monitor sensors as respectively
- Here the 'inputs' of brake and throttle has previously handled by signal builder, but now it has replaced with the two constant blocks which is handled by the knob blocks has placed in the dashboard
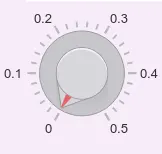
- Then the 'engine sensor' and 'vehicle body sub-system' has monitored by the two circular gauge blocks of 'RPM gauge' and 'Velocity gauge' from the dashboard. Those blocks have set with the certain amount of limits as per the engine performance
- There has an initial condition has given to the vehicle inputs, which is 0 for the brake and 1 for the throttle. So as per the given condition of the inputs, the knobs has to be adjust as manually before the program gets run
- And finally, the above all explanations are detailed about the BAJA ATV model's working function with the simulink blocks usage
GRAPH:
1. Engine Torque-Speed curve [Plotted with the BAJA ATV real-time output data]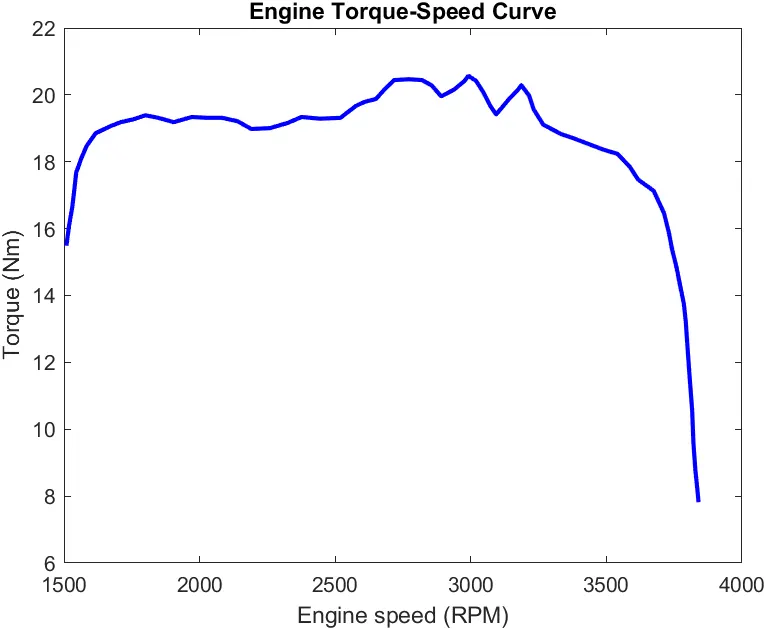
- Based on the real-time overall engine performance of BAJA ATV
2. Plot: Vehicle Speed by Distance as per the Inputs
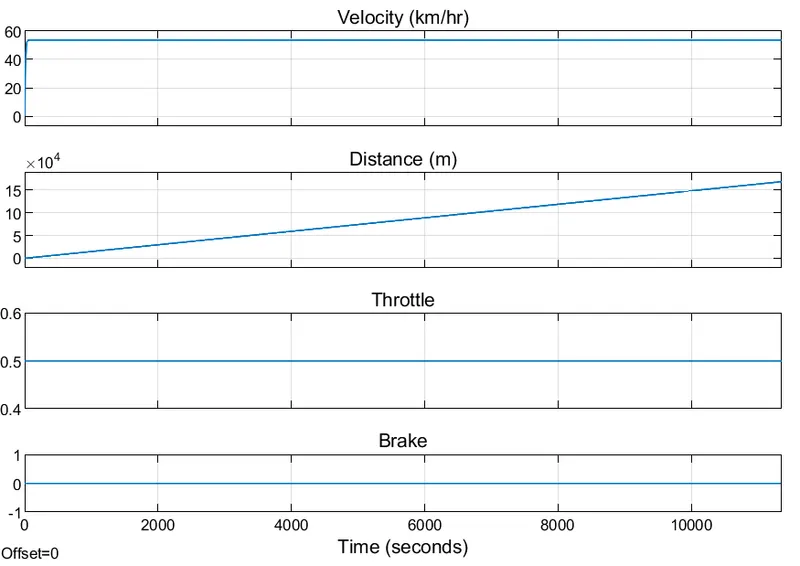
- Here the model designer has not provided the stop time limit and the inputs are also constant, so I have took over the output through the maximum changes in the circular guage: velocity and this CVT has designed with gear ratio as 10
3. Plot: CVT Shaft Speed
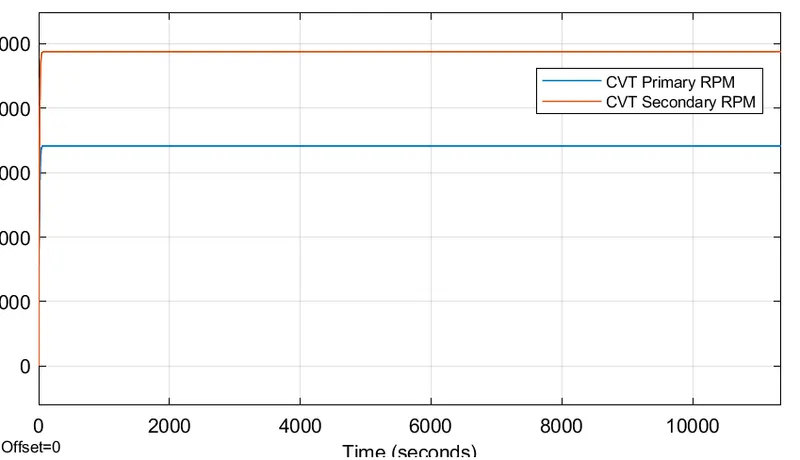
- This output has got from the CVT sub-system block, which shows the constant RPM level in both primary and secondary sensors as per the value levels
CONCLUSION:
- CVT based terrain vehicles working function learned as well
- Complete CVT simulation achieved through the simulink
- Overall blocks and sub-system's uses have understood