Project 2 - Speed Control of a Direct Current (DC) motor
DC Motor Parameters :
Jm=0.01; Moment of Inertia of Rotor
Bm=0.1; Motor Viscous friction constant
Km=0.01; Back EMF constant
Kt=0.01; Motor torque constant
Ra=1.0; Resistance of armature
La=0.5; Inductance of armature
PID Controller Parmeters:
A=[-Bm/Jm Kt/Jm; -Km/La -Ra/La]
B=[0; 1/La]
f=1
wn=2*pi*f
zeta=0.5( Underdamped Case)
p1=-zeta*wn+wn*sqrt(zeta^2-1)
p2=-zeta*wn-wn*sqrt(zeta^2-1)
P=[p1;p2]
K=place(A,B,P)
Gains Obtained,
K1=38.66 (Kp)
K2=-2.65 (Kd)
Assumed Ki= 50
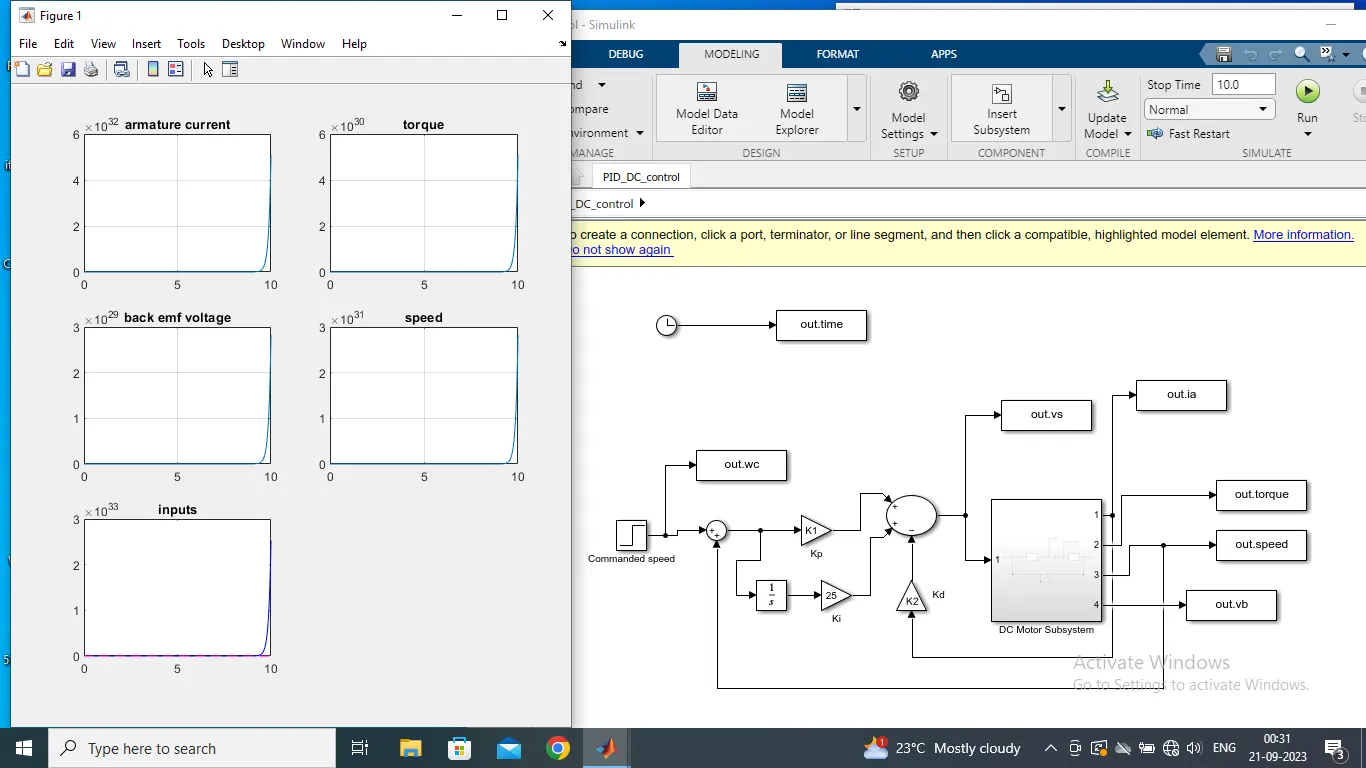
ouput result for stepped command
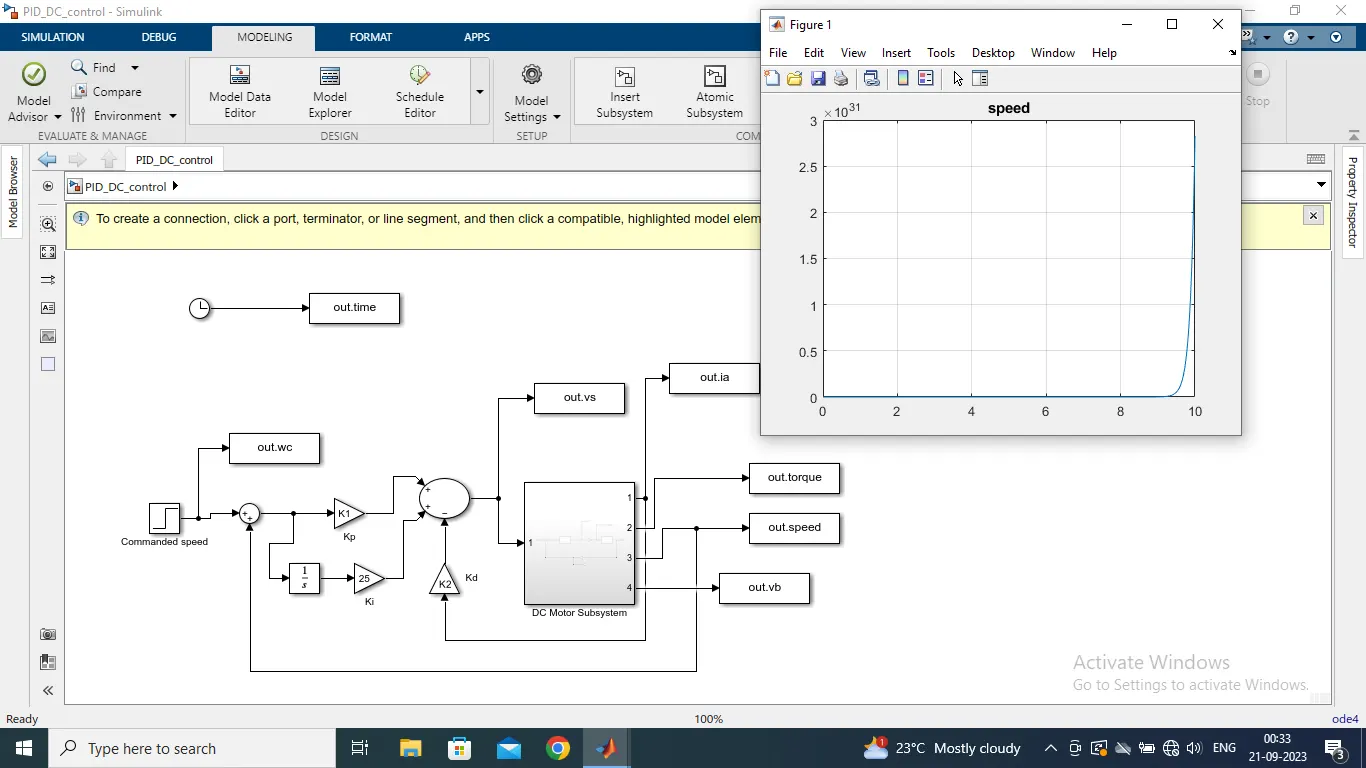
speed controll output
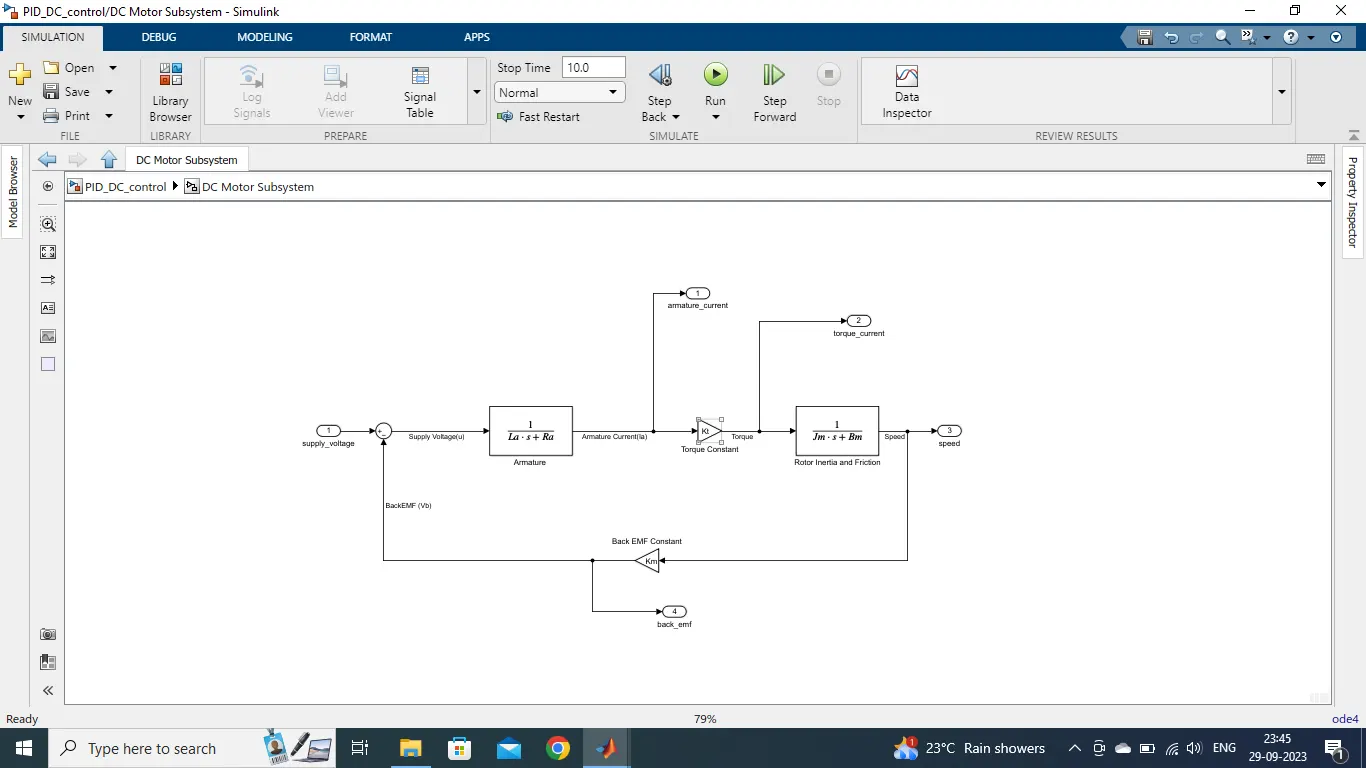
DC motor Design
other outputs and concerned files have been attached below.