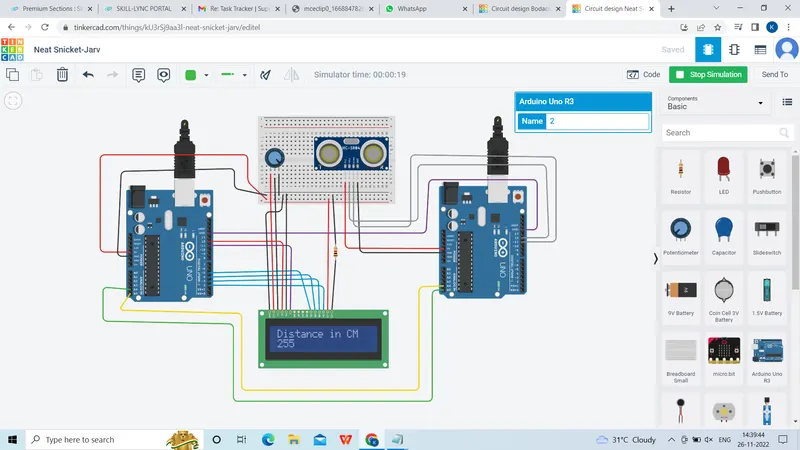
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
Master code:
#include<Wire.h>//i2c communication hedder file
#include <LiquidCrystal.h>//lcd disply headder file
LiquidCrystal lcd(12,11,5,4,3,2);

void setup()
{

lcd.begin(16,2);
lcd.setCursor(0,0);
lcd.print("Ultrasonicsensor");
delay(5000);
lcd.clear();
Wire.begin(); //enable the I2C communication

}

void loop()
{

Wire.requestFrom(1,2); //address of slave and bytes quatity
byte CMReceive = Wire.read();//receive data from slave
lcd.begin(16,2);
lcd.setCursor(0,0);
lcd.print("Distance in CM");
lcd.setCursor(0,1);
lcd.print(CMReceive);
delay(2000);
lcd.clear();
byte INCHReceive = Wire.read();//receive from slave
lcd.begin(16,2);
lcd.setCursor(0,0);
lcd.print("Distance in INCH");
lcd.setCursor(0,1);
lcd.print(INCHReceive);
delay(3000);
lcd.clear();

}
SLave code:
#include<Wire.h>
int CM = 0;
int inch = 0;
int duration = 0; // variable decleration

void setup()
{

pinMode(12, OUTPUT); // pin mode decleration
pinMode(11, INPUT);
Wire.begin(1); //i2c communication begin
Wire.onRequest(requestEvent); // recieve from master

}

void loop()
{
}

void requestEvent() // isr fun
{

digitalWrite(12, LOW);
delayMicroseconds(2);
digitalWrite(12, HIGH);
delayMicroseconds(2);
digitalWrite(12, LOW);
duration = pulseIn(11, HIGH); //ultrosonic wave time travel
CM = 0.01723 * duration;// formula to convert the cm
Wire.write(CM);//write the value in wire
inch = (CM / 2.54); // inch conversion
Wire.write(inch);//write the value in wire

}
OUTPUT: