Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear :
AIM :
Implement the code for controlling the retraction and extensioin of Airplane's Landing gear.
Introduction :
An airplne has three gears for landing:
- Nose Gear
- Left Gear
- Right Gear
The hydraulic pump are used for exerting pressure to the gears to bring it down or pull it up and that pump is electrically driven.
Limit switches: Every leg of the gear has one limit switch.
Squat switch: only nose gear have squat switch to determine whether the airplan is in ground or not.
|
Switch state |
State of Gears |
|
Limit Switch CLOSED |
Gear is UP |
|
Limit Switch OPENED |
Gear is DOWN |
|
Switch State |
State of Airplane |
|
Squat Switch CLOSED |
Airplane is grounded and gears are locked |
|
Squat Switch OPENED |
Airplane is taking off/ landing/ airborne |
A direction valve is controlled by software to allow the hydraulic pressure to either raise or lower the landing gear
|
Status of Direction Valve |
States of landing gear |
|
Direction valve = Down |
(Gear Down) (Parked at bay or Landed) |
|
Direction valve = Up |
Raising Gear (Taking Off) |
|
Control of hydraulic pump for the landing gear part is disabled |
Gear up (Airborne) |
|
Direction valve = down |
Lowering Gear (Landing) |
Input for the direction valve :
|
Pilot's Lever State |
Direction Valve State |
|
Lever UP |
Direction valve = Up |
|
Lever Down |
Direction valve = Down |
|
Pilot's Lever State |
Light Status |
|
Lever Rising Edge |
Red |
|
Lever Falling Edge |
Red |
Every gear has one light. According to the state of the gear, color of the light is changing.
|
Landing Gear State |
Light Status |
|
Gear is up |
OFF |
|
Gear is down |
Green |
|
Gear in transit |
Red |
By incorperating all these constraints we can come to result.
PROGRAMS :
HEADER FILE :
/*
 * States.h
 * Created on: 28-Jan-2023
 *  Author: arjun
 */

#ifndef STATES_H_
#define STATES_H_

/* Declaring all the functions */
void Init_State_Machine();
void Gear_Down();
void Checking_Before_Takeoff();
void Raising_Gear();
void Gear_Up();
void Checking_Before_Landing();
void Lowering_Gear();

typedef enum State
{
	Gear_down, Check_before_takeoff, Raising_gear, Gear_up, Check_before_landing, lowering_gear
}State_Type;

typedef enum Switch
{
	Open, Close
}Switch_Status;

typedef enum Pilot_Lever
{
	Rising, Falling, Up, Down
}Pilot_Lever_Status;

typedef enum Hydraulic_Mechanism
{
	Working, Malfunctioning
}Hydraulic_Mechanism_Status;

/* For changing the states */
static volatile Switch_Status squat_switch;
static volatile Switch_Status limit_switch;
static volatile Pilot_Lever_Status pilot_lever;
static volatile Hydraulic_Mechanism_Status hydraulic_mechanism;

State_Type current_state;

typedef struct
{
	char* current_state_indication;
	char* light_status;
	char* direction_valve_status;
	char* hydraulic_pump_control_status;
	char* gas_pressurized_spring_status[2];
}State_Table;

static State_Table State_Machine[6] = {
		{"Gear Down", "Green", "Down", "Enabled", {0,0}},
		{"Checking Before Take Off", "Green", "Down", "Enabled", {0,0}},
		{"Raising Gear", "Red", "Up", "Enabled", {"Disabled", "Enabled"}},
		{"Gear Up", "Off", "Null", "Disabled", {0,0}},
		{"Checking Before Landing", "Red", "Down", "Enabled", {0,0}},
		{"Lowering Gear", "Green", "Down", "Enabled", {"Disabled", "Enabled"}}
};

#endif /* STATES_H_ */
MAIN C FILE :
/*
 ============================================================================
 Name        : Project2_Aeroplane_landing.c
 Author      :
 Version     :
 Copyright   : Your copyright notice
 Description : Hello World in C, Ansi-style
 ============================================================================
 */

#include "States.h"
#include<stdio.h>

static void (*state_table[])(void) = {Gear_Down, Checking_Before_Takeoff, Raising_Gear, Gear_Up, Checking_Before_Landing, Lowering_Gear};

int main()
{

	Init_State_Machine();

	while(1)
	{
		state_table[current_state]();
	}

}
INIT_STATE_MACHINE FILE :
/*
 * Init_State_Machine.c
 * Created on: 29-Jan-2023
 * Author: arjun
 */

#include "States.h" // User-defined library function

void Init_State_Machine()
{
	// System Initialized
	current_state = Gear_down;
	printf("The state machine is initialized and is in Gear Down state with the Light status: %s\n", State_Machine[current_state].light_status);
}
GEAR_DOWN FILE :
/*
 * Gear_Down.c
 * Created on: 29-Jan-2023
 * Author: arjun
 */

#include<stdio.h>
#include "States.h"

void Gear_Down(void)
{
	current_state = Gear_down;

	printf("\nEnter the Pilot's lever position and the Squat switch status: ");
	fflush(stdout);
	scanf("%d %d", &pilot_lever, &squat_switch);

	if (pilot_lever == Rising && squat_switch == Open)
	{
		current_state = Check_before_takeoff;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
	}

	else
	{
		Gear_Down();
	}
}
CHECKING_BEFORE_TAKEOFF FILE :
/*
 * Checking_Before_Take_Off.c
 * Created on: 29-Jan-2023
 * Author: arjun
 */

#include<stdio.h>
#include "States.h"

void Checking_Before_Takeoff()
{
	current_state = Check_before_takeoff;
	printf("\nEnter the Pilot's lever position, Squat switch status and Hydraulic mechanism status: ");
	fflush(stdout);
	scanf("%d %d %d", &pilot_lever, &squat_switch, &hydraulic_mechanism);
	printf("\nWait for 2 sec\n");

	if (pilot_lever == Falling || squat_switch == Close)
	{
		Gear_Down();
	}

	else if (pilot_lever == Up && squat_switch == Open && hydraulic_mechanism == Working)
	{
		current_state = Raising_gear;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Direction valve: %s\n\n", State_Machine[current_state].direction_valve_status);
	}

	else if (pilot_lever == Up && squat_switch == Open && hydraulic_mechanism == Malfunctioning)
	{
		current_state = Raising_gear;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Direction valve: %s\n\n", State_Machine[current_state].direction_valve_status);
		printf("Gas pressurized spring system status: %s\n", State_Machine[current_state].gas_pressurized_spring_status[hydraulic_mechanism]);
	}
}
RAISING_GEAR FILE :
/*
 * Raising_Gear.c
 * Created on: 29-Jan-2023
 * Author: arjun
 */

#include<stdio.h>
#include "States.h"

void Raising_Gear()
{
	current_state = Raising_gear;
	printf("\nEnter the Pilot's lever position and the Limit switch status: ");
	fflush(stdout);
	scanf("%d %d", &pilot_lever, &limit_switch);
	printf("\nWait for 1 sec\n");

	if (pilot_lever == Falling && limit_switch == Open)
	{
		current_state = Check_before_landing;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Hydraulic control for landing gear status: %s\n", State_Machine[current_state].hydraulic_pump_control_status);
	}

	else if (pilot_lever == Up && limit_switch == Close)
	{
		current_state = Gear_up;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Hydraulic control for landing gear status: %s\n", State_Machine[current_state].hydraulic_pump_control_status);
	}

	else
	{
		Raising_Gear();
	}
}
GEAR_UP FILE :
/*
 * Gear_Up.c
 * Created on: 29-Jan-2023
 * Author: arjun
 */

#include<stdio.h>
#include "States.h"

void Gear_Up()
{
	current_state = Gear_up;
	printf("\nEnter the Pilot's lever position: ");
	fflush(stdout);
	scanf("%d", &pilot_lever);

	if (pilot_lever == Falling)
	{
		current_state = Check_before_landing;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Hydraulic control for landing gear status: %s\n", State_Machine[current_state].hydraulic_pump_control_status);
	}

	else
	{
		Gear_Up();
	}
}
CHECKING_BEFORE_LANDING FILE :
/*
 * Checking_Before_Landing.c
 * Created on: 29-Jan-2023
 * Author: arjun
 */

#include<stdio.h>
#include "States.h"

void Checking_Before_Landing()
{
	current_state = Check_before_landing;
	printf("\nEnter the Pilot's lever position and Hydraulic mechanism status: ");
	fflush(stdout);
	scanf("%d %d", &pilot_lever, &hydraulic_mechanism);

	if (pilot_lever == Down && hydraulic_mechanism == Working)
	{
		current_state = lowering_gear;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Direction valve: %s\n\n", State_Machine[current_state].direction_valve_status);
	}

	else if (pilot_lever == Down && hydraulic_mechanism == Malfunctioning)
	{
		current_state = lowering_gear;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Direction valve: %s\n\n", State_Machine[current_state].direction_valve_status);
		printf("Gas pressurized spring system status: %s\n", State_Machine[current_state].gas_pressurized_spring_status[hydraulic_mechanism]);
	}

	if (pilot_lever == (Up || Rising || Falling))
	{
		Checking_Before_Landing();
	}
}
LOWERING_GEAR FILE :
/*
 * Lowering_Gear.c
 * Created on: 29-Jan-2023
 * Author: arjun
 */

#include<stdio.h>
#include "States.h"

void Lowering_Gear()
{
	current_state = lowering_gear;
	printf("\nEnter the Pilot's lever position and the Limit switch status: ");
	fflush(stdout);
	scanf("%d %d", &pilot_lever, &limit_switch);

	if (pilot_lever == Rising && limit_switch == Close)
	{
		current_state = Check_before_takeoff;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
	}

	if (pilot_lever == Down && limit_switch == Open)
	{
		current_state = Gear_down;
		printf("\nCurrent state: %s\n", State_Machine[current_state].current_state_indication);
		printf("Light status: %s\n", State_Machine[current_state].light_status);
		printf("Hydraulic control for landing gear status: %s\n", State_Machine[current_state].hydraulic_pump_control_status);
	}

	else
	{
		Lowering_Gear();
	}
}
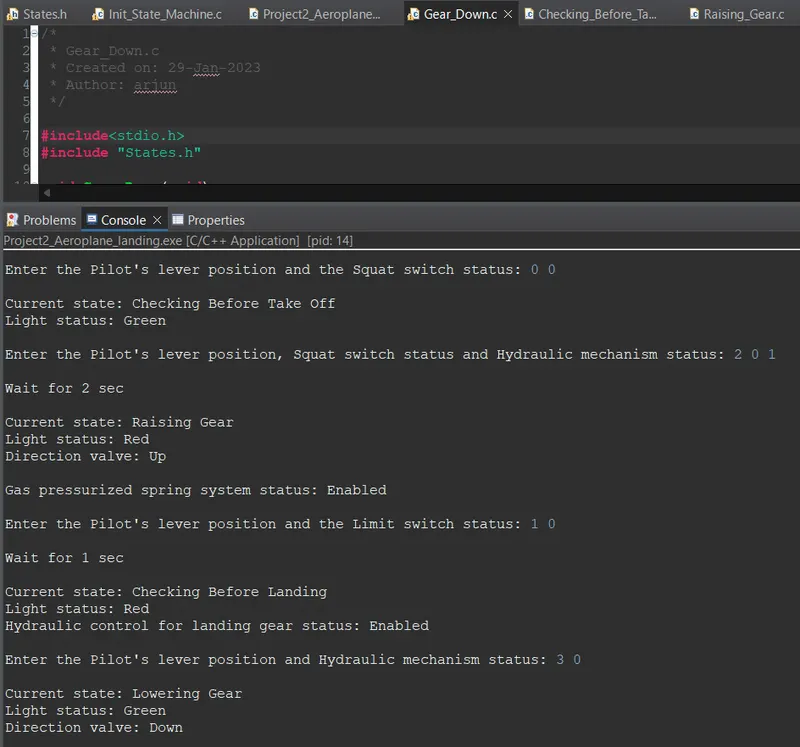
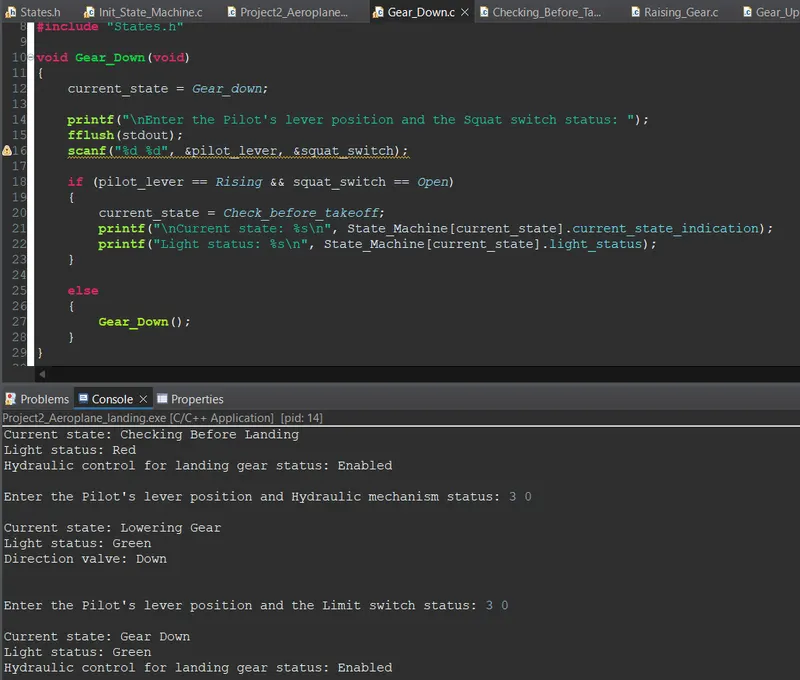
OUTPUT :