Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Project: FINITE STATE MACHINE
Problem Statement:
Implement the Code for controlling the retraction and
extension of Airplane’s landing gear
Proble FSM:
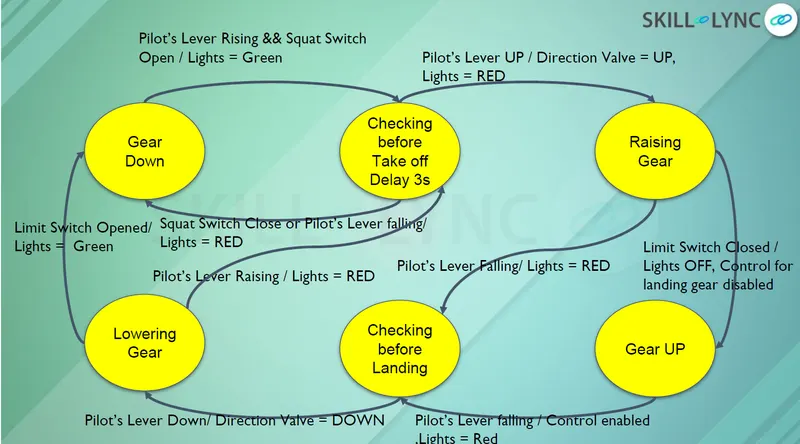
Program:
#include    //Header file
#include


void Gear_Down();                   //Function declaretion
void Checking_before_Take_off();
void Gear_Raising();
void Gear_UP();
void Checking_before_Landing();
void Gear_Lowering();
void Initial_State();
                                     //Function Pointer declaretion
static void(*state_Table[])(void)=
{
    Gear_Down,
    Checking_before_Take_off,
    Gear_Raising,
    Gear_UP,
    Checking_before_Landing,
    Gear_Lowering,
};
                                     //Create enum variable for function state
typedef enum
{                                    //As per enum structure enum position are
    GEAR_DOWN,                       //GEAR_DOWN=0
    CHECKING_BEFORE_TAKE_OFF,        //CHECKING_BEFORE_TAKE_OFF=1,
    GEAR_RAISING,                    //GEAR_RAISING=2,
    GEAR_UP,                         //GEAR_UP=3,
    CHECKING_BEFORE_LANDING,         //CHECKING_BEFORE_LANDING=4,
    GEAR_LOWERING,                   //GEAR_LOWERING=5
}State_Landing;
                                     //Create enum variable for pilot lever position
typedef enum
{                                   //As per enum structure enum position are
    UP,                             //UP=0,
    DOWN,                           //DOWN=1,
    RISING,                         //RISING=2,
    LOWERING,                       //LOWERING=3,
    FALLING,                        //FALLING=4
}Pilot_lever;
                                     //Create enum variable for Limit switch position
typedef enum                         //As per enum structure enum position are
{
    OPEN,                            //OPEN=0,
    CLOSE,                           //CLOSE=1
}Limit_switch;
                                     //Create enum variable for squat switch position
typedef enum
{                                    //As per enum structure enum position are
   OPEN_E,                           //OPEN_E=0,
   CLOSE_E,                          //CLOSE_E=1,
}squat_switch;

typedef enum
{                                    //As per enum structure enum position are
    UP_D,                            //UP_D=0,
    DOWN_D,                          //DOWN_D=1,
}direction_valve;

 State_Landing current_state;         //Name the state landing variable as current_state

 static volatile Pilot_lever Pilot_lever_state;     //Name the Pilot lever enum variable as Pilot_lever_state
 static volatile squat_switch squat_switch_state;   //Name the Squat switch enum variable as squat_switch_state
 static volatile Limit_switch Limit_switch_state;   //Name the Limit switch enum variable as Limit_switch_state
 static volatile direction_valve direction_valve_state;
                                                    //Create structure pointer charecter type array
typedef struct
{
    char* machine_current_state;
    char* State_of_Landing_Gear;
    char* State_of_Airplane;
    char* Light_state;

}state_Table1;
                                                     //Define pointer array eliment asper pointr structure
state_Table1 state_Machine[6]=
{
    {"Gear_Down","RISING","LANDED","GREEN"},
    {"Checking_before_Take_off","UP","TAKEO","RED"},
    {"Gear_Raising","FALLING","TAKEOF","RED"},
    {"Gear_UP","FALLING","FLY","RED"},
    {"Checking_before_Landing","DOWN","LANDING","RED"},
    {"Gear_Lowering","DOWN","LANDING","GREEN"},
};
                                                    //Main function
int main()
{
    Initial_State();                                //Call Initial state for initial condition
    while (1)
    {
        state_Table[current_state]();               //Call state table functions as per logic sequance
    }
}


void Gear_Down(void)                               //Function for Gear Down state
{
    current_state=GEAR_DOWN;
    printf("Enter your Pilot lever and Squat_switch status:\n");
    fflush(stdout);
    scanf("%d %d",&Pilot_lever_state,&squat_switch_state);
    if (Pilot_lever_state==RISING && squat_switch_state==CLOSE_E)
    {
        current_state=CHECKING_BEFORE_TAKE_OFF;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
    else
    {
        Gear_Down();
    }

}

void Checking_before_Take_off(void)              //Function for Take off before checking state
{
    current_state=CHECKING_BEFORE_TAKE_OFF;
    printf("Enter your Pilot lever and Squat_switch status:\n");
    fflush(stdout);
    scanf("%d %d %d",&Pilot_lever_state,&squat_switch_state,&direction_valve_state);
    if (direction_valve_state==UP_D)
    {
        current_state=GEAR_RAISING2
    ;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
     else if (Pilot_lever_state==FALLING || squat_switch_state==CLOSE_E)
    {
        current_state=GEAR_DOWN;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
    else
    {
        Checking_before_Take_off();
    }
}

void Gear_Raising(void)                     //Function for Take Gear Raising state
{
    current_state=GEAR_RAISING;
    printf("Enter your Limit switch status:\n");
    fflush(stdout);
    scanf("%d %d",&Limit_switch_state,&Pilot_lever_state);
    if (Limit_switch_state==CLOSE)
    {
        current_state=GEAR_UP;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
     else if (Pilot_lever_state==FALLING)
    {
        current_state=CHECKING_BEFORE_LANDING;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
    else
    {
        Gear_Raising();
    }

}

void Gear_UP(void)                                      //Function for Gear up state
{
    current_state=GEAR_UP;
    printf("Enter your Pilot lever:GEAR_UP\n");
    fflush(stdout);
    scanf("%d",&Pilot_lever_state);
    if (Pilot_lever_state==FALLING)
    {
        current_state=CHECKING_BEFORE_LANDING;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
    else
    {
        Gear_UP();
    }
}

void Checking_before_Landing(void)                      //Function for Checking Before Landing state
{
    current_state=CHECKING_BEFORE_LANDING;
    printf("Enter your Pilot lever:\n");
    fflush(stdout);
    scanf("%d",&Pilot_lever_state);
    if (Pilot_lever_state==DOWN )
    {
        current_state=GEAR_LOWERING;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
    else
    {
        Checking_before_Landing();
    }
}

void Gear_Lowering(void)                               //Function for Gear lowering state
{
    current_state=GEAR_LOWERING;
    printf("Enter your Pilot lever and Limit switch state:\n");
    fflush(stdout);
    scanf("%d %d",&Pilot_lever_state,&Limit_switch_state);
    if (Pilot_lever_state==RISING)
    {
        current_state=CHECKING_BEFORE_TAKE_OFF;
        printf("current status:%s\n,",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
     else if (Limit_switch_state==OPEN)
    {
        current_state=GEAR_DOWN;
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
    }
    else
    {
        Gear_Lowering();
    }

}

void Initial_State(void)                                  ////Function for initial state state
{
    current_state=GEAR_DOWN;
        printf("Plane at initial condition:\n");
        printf("current status:%s\n",state_Machine[current_state].machine_current_state);
        printf("Lightis: %s\n",state_Machine[current_state].Light_state);
}
List of enum parameter:
Gear State State Position
GEAR_DOWN 0
CHECKING_BEFORE_TAKE_OFF 1
RAISING_GEAR 2
GEAR_UP 3
CHECKING_BEFORE_LANDING 4
LOWERING_GEAR 5
Pilot Lever State Position
UP 0
DOWN 1
RISING 2
LOWERING 3
FALLING 4
Limit Switch State Position
OPEN 0
CLOSE 1
Squat Switch State Position
OPEN_E 0
CLOSE _E 1
Direction valve State Position
UP_D 0
DOWN_D 1
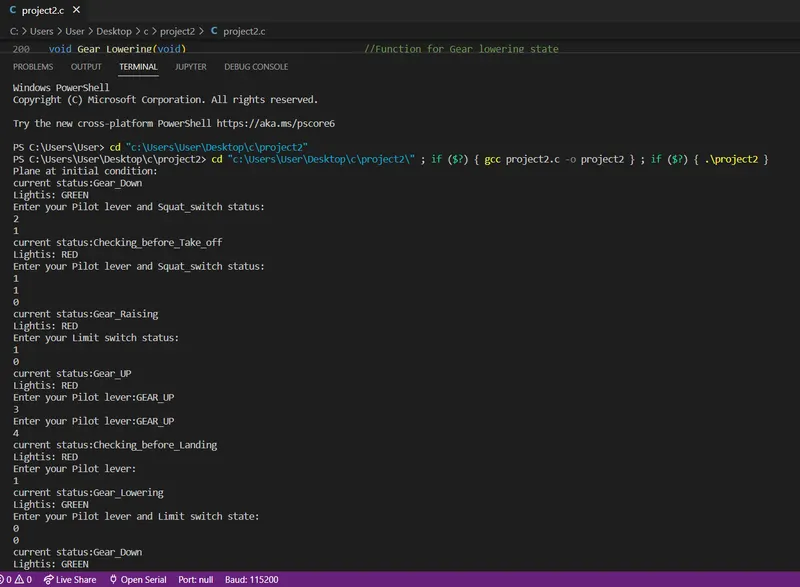
OUTPUT ONE:
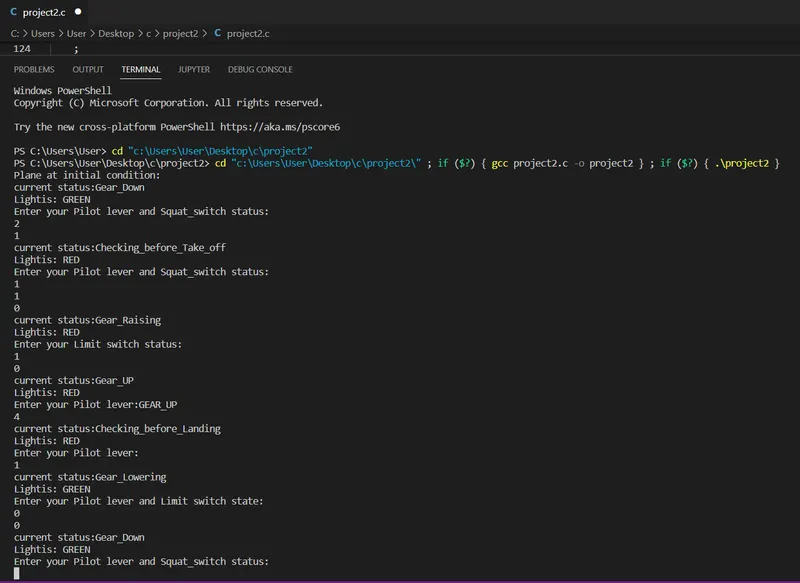
OUTPUT TWO: