Project 2
1)
AIM
DEVELOPMENT OF A FORWARD-BASED FUEL CONSUMPTION OF A HYBRID VEHICLE
OBJECTIVES
- To find the fuel economy of UDDS and HWFET cycle. We will compare it with conventional vehicle.
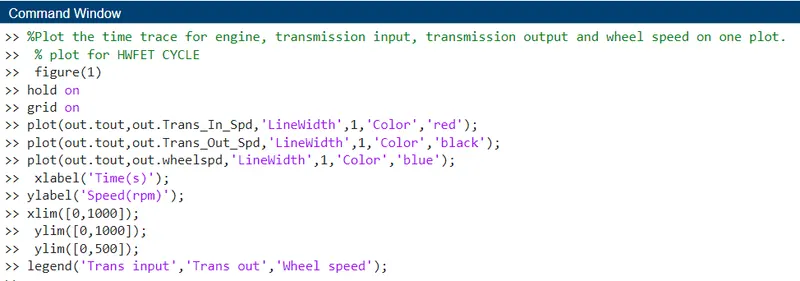
- Plot the time trace for engine, transmission input, transmission output and wheel speed on one plot
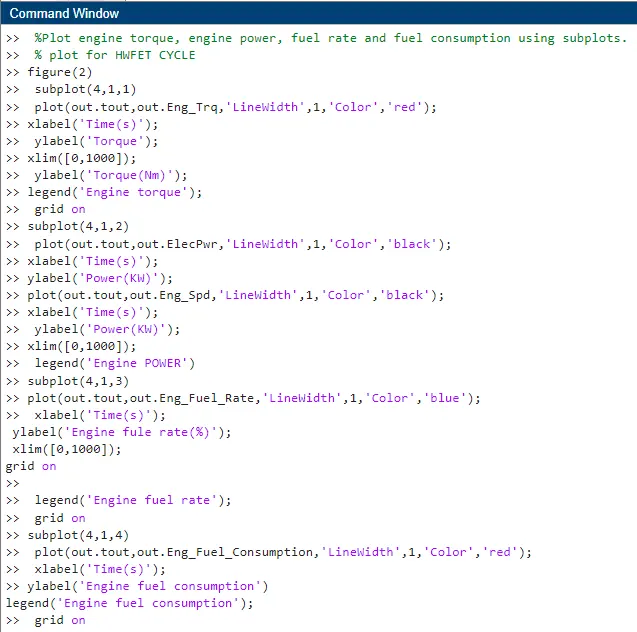
- With the help of subplots plot engine torque, engine power, fuel rate and fuel consumption.
- with the help of subplots Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance.
- With the help of subplots Plot motor speed, torque, motor input power.
- Plot the engine operating points on the engine fuel map.
- Using subplots plot pack voltage, current and SOC.
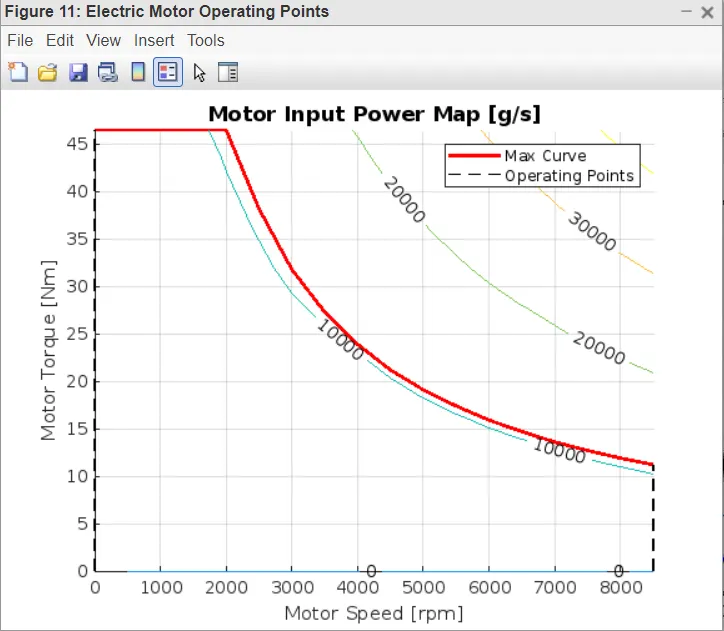
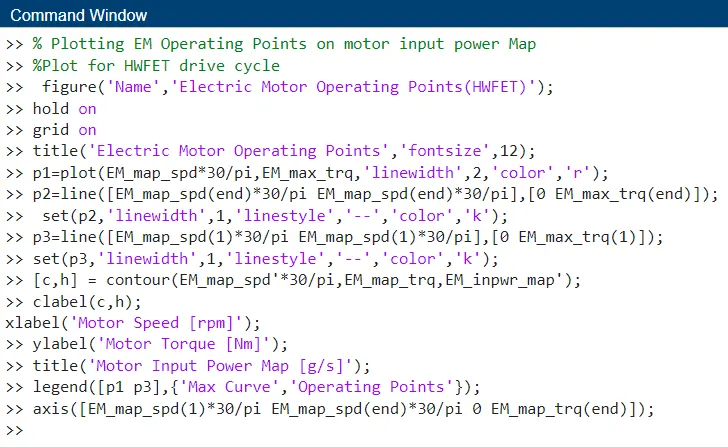
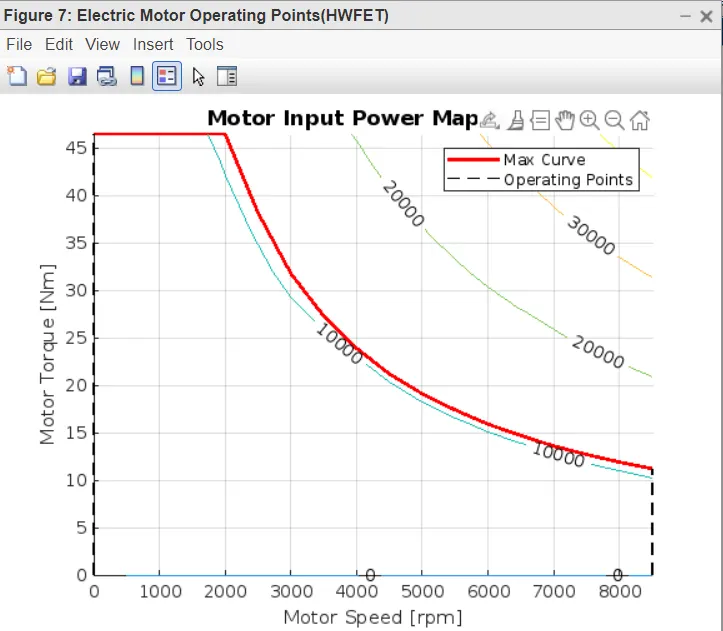
- Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves.
- We will generate the plots for UDDS and HWFET cycle.
THEORY
P1 Mild Hybrid Electric Vehicle
Honda chose the P1 architecture for their first-generation Integrated Motor Assist (IMA) technology because it allows the electric motor to be connected directly to the crankshaft. The electric motor serves as a generator, an engine starter, a motor (to help the engine), and a generator during vehicle braking. The fact that the electric motor can deliver more torque than the BiSG because there is no belt restriction is one of the solution's main benefits (due to slip). The torque demands on the electric motor, however, can be fairly high because there is no speed to torque relationship between the electric machine and crankshaft.
Two examples of P1 MHEV architectures are:
- Honda Insight Hybrid 2009 (with Integrated Motor Assist technology)
- Mercedes Benz S400 Bluehybrid 2010
For example, the main characteristics of the P1 MHEV.
1] ELectric Machine Performance
Maximum torque up to 34 Nm.
Maximum power: 10KW
Efficiency: Up to 94 Percent.
2] Hybrid Modes
Idle stop and stop
Moving stop and start
Engine load shift
Torque assist
Torque boost
Energy recuperation
Brake generation
3] Advantages
Higher efficiency
The 12V starter can be removed.
4] Disadvantages
The torque is limited by size of the motors.
Energy recuperation affected by engine friction losses
High impact on existing vehicle architecture
Higher overall cost of the electrical components
Air cooling not possible for electric machine
5] Overall characteristics
Toruqe Boosting capacity: High
Electrical energy recuperation: Medium
Driveability improvements: Medium
Electrical Creep/drive: Possible
MODEL DESCRIPTION
It is often referred to as dynamic modelling. In-depth simulations are performed using dynamic models. This model uses force, torque, and power as inputs and vehicle status variables, such as acceleration and velocity, as outputs. Due to physical casualty, models and simulations are more realistic and suitable for control development. To achieve the desired vehicle state, there is a feedback loop. It is primarily used to replicate a vehicle while it is being driven in order to analyse the dynamic behavior of the system, which greatly aids in the creation of controls.
PROCESS
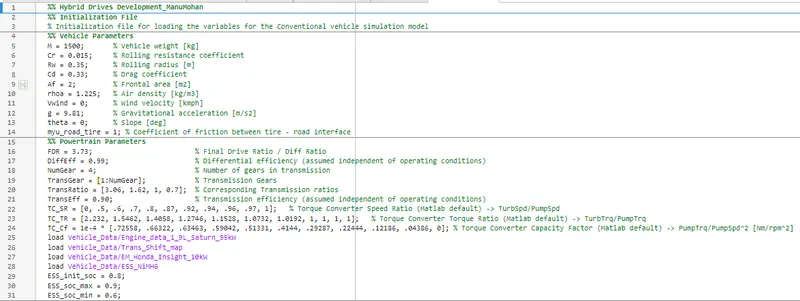
Load the Project2 folder as the Current Folder in Matlab.
Run the “Project2_InitFile.m” Matlab script.
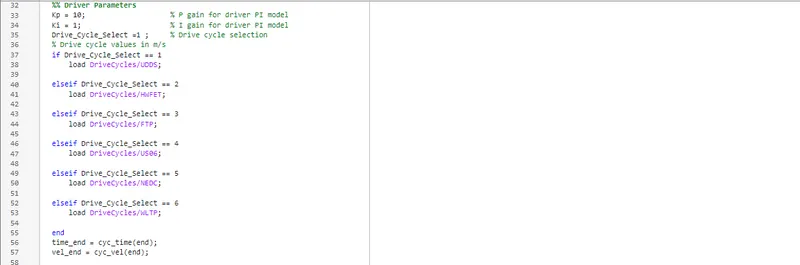
The Drive cycle selection is done here.
After run this coding file open simulink model.
MATLAB CODE
HYBRID VEHICLE BASIC MODEL
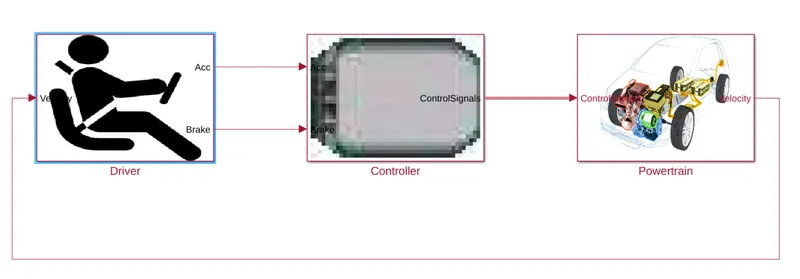
The basic block diagram for conventional vehicle system. The input action is applied by the driver which is controlled by the controller and the control signal is analyzed by the vehicle plant. Feedback system has to control the vehicle speed.
POWER TRAIN
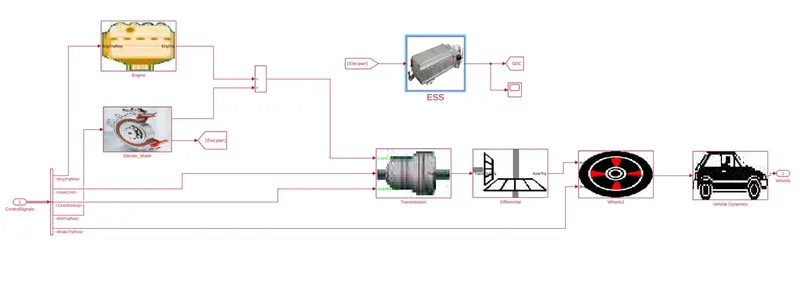
It will pass through all the components that converts power to mechanical work output, includes the engine, transmission, driveshaft, differentials, axles; basically anything from the engine through to the rotating wheels.To model fuel consumption a map based model is employed.It depends on maximum and minimum torque.In these model we take engine torque, gear selector from controller for transmission of gear ratio. We will multiply the ratio with transmission torque, positive, negative torque that gives transmission input speed.The torque converter in the transmission system will connect engine with the transmission system.
VEHICLE DYNAMICS
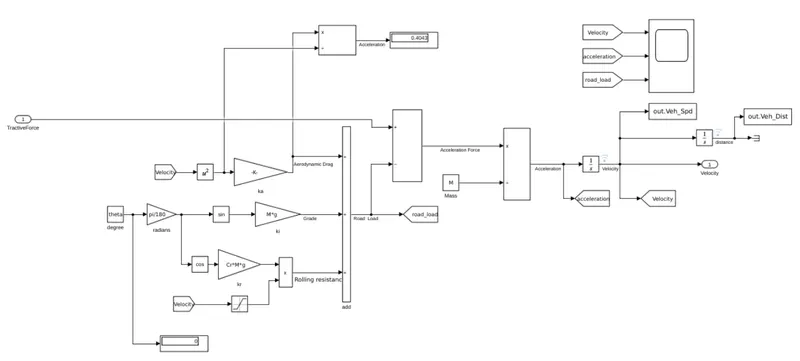
The vehicle dynamics is the movement of the vehicle created by the directing activity, through which the vehicle is able of autonomous movement . It clarifies the movement of the vehicle for a given direct input, and clarifies the mechanics of vehicle movement.
WHEEL
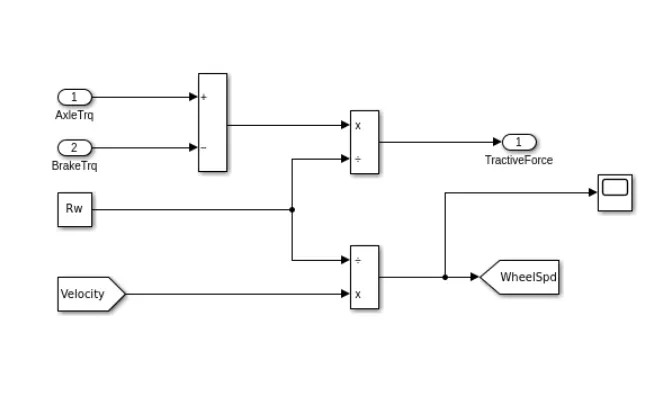
A drive wheel could be a wheel of a engine vehicle that transmits drive, changing torque into tractive constrain from the tires to the street, causing the vehicle to move. The powertrain conveys sufficient torque to the wheel to overcome stationary powers, coming about within the vehicle moving advances or in reverse.
DIFFERENTIAL
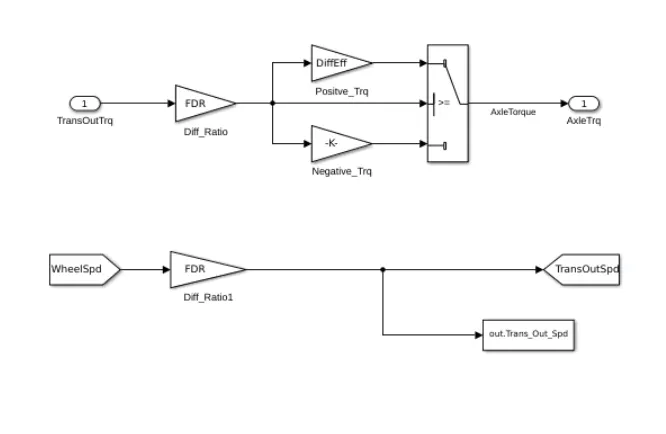
The differential may be a framework of gears that permits different drive wheels (the wheels to which control is conveyed from the motor) on the same hub to turn at distinctive speeds, such as when the car is turning. The output is taken from the transmission. This is then multiplied by differential ratio and to multiply the axle torque.The magnitude of axial torque is less than the transmission torque.In the model depicted below the transmission torque is taken from the differential and brake torque from the controller. The tractive force is obtainedfrom brake torque when it is subtracted and multiplied with rolling radius.The wheel speed is velocity.
TRANSMISSION
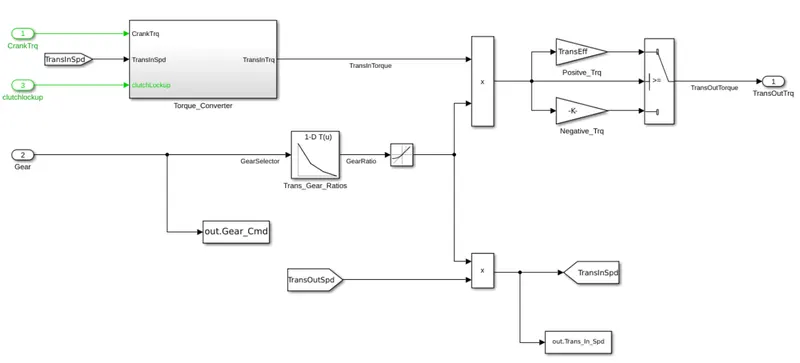
The transmission is for changing over both speed and energy into control that at that point gets the whole car moving and its primary point is to form the motor as effective as possible by lessening the sum of fuel utilization while getting the finest sum of control.
TORQUE CONVERTER
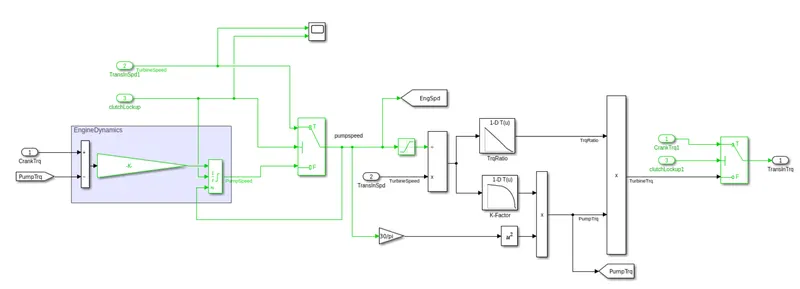
A torque converter could be a sort of liquid coupling that exchanges turning control from a prime mover, like an inner combustion motor, to a pivoting driven stack. In a vehicle with an programmed transmission, the torque converter interfaces the control source to the sink.
ENGINE
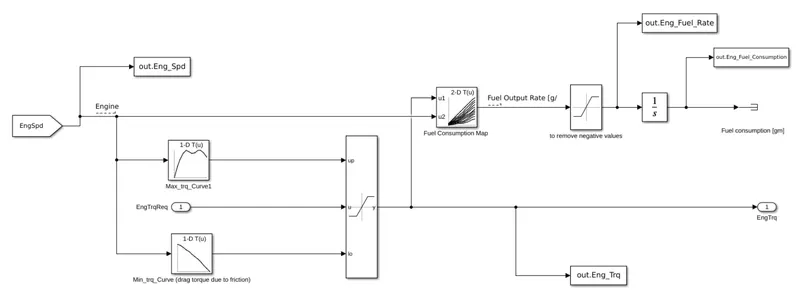
Particularly, an internal-combustion engine could be a warm motor in that it changes over vitality from the warm of burning gasoline into mechanical work, or torque. That torque is connected to the wheels to create the car move.
ELECTRIC MOTOR
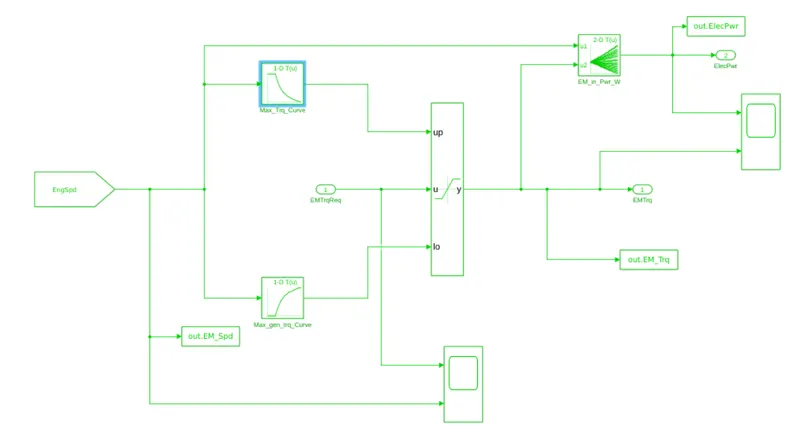
An electric motor is an electrical machine that converts electrical energy into mechanical energy. Most electric motors work through the interaction between the motor's magnetic field and the electric current in the wire winding to create force in the form of torque applied to the motor shaft.
CRANK HUB
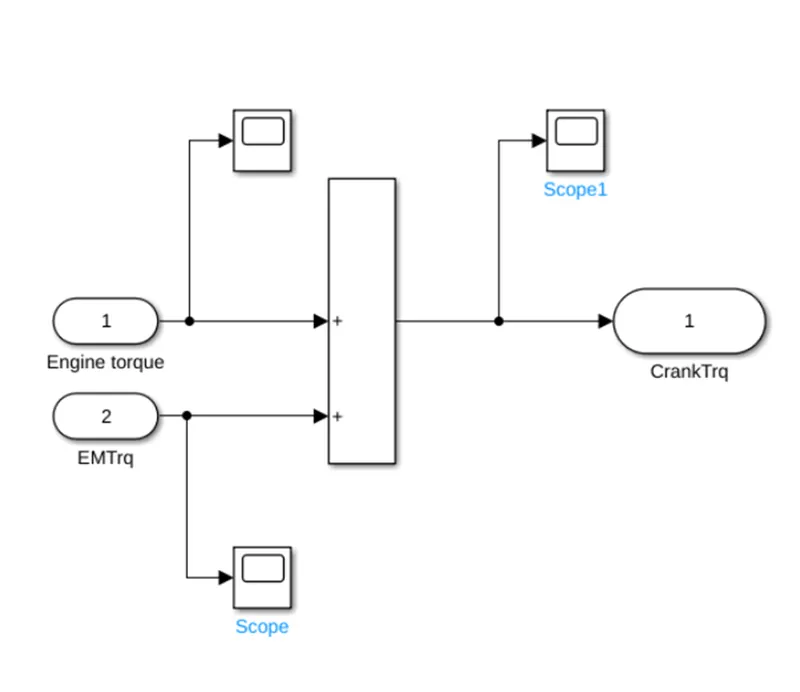
The Stock Crank Hub design allows the pinion to rotate independently of the cranks, causing the user to re-time the engine to a minimum, and in the worst case scenario, piston-to-valve contact will damage the engine and require a complete engine overhaul.
ENERGY STORAGE SYSTEM(ESS)
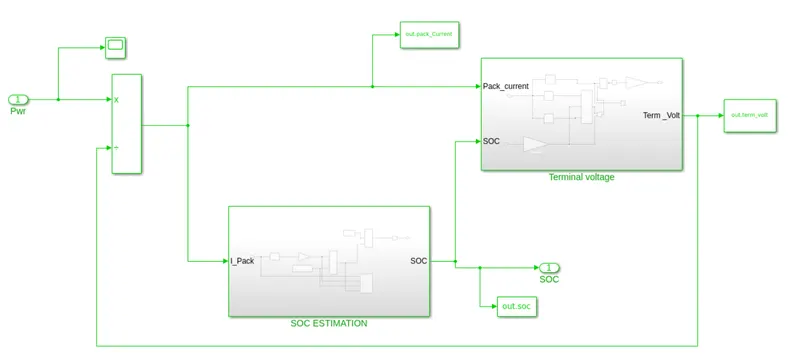
We provide input as power, which is multiplied and converted to output as pack current. After that, the terminal voltage is given as input and is then met as the output of the soc estimation meet output SOC.
SOC ESTIMATION
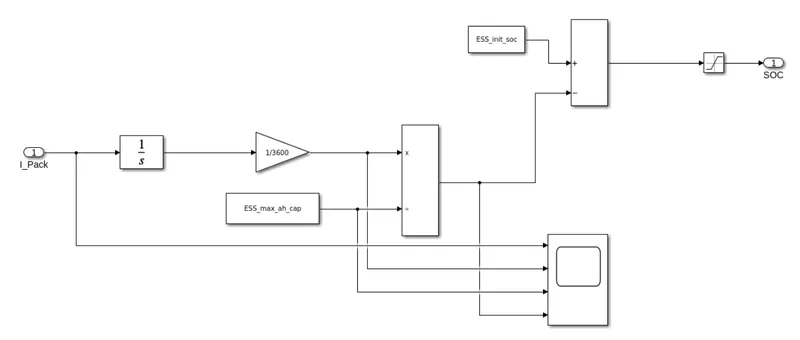
A battery's SOC, i.e. its remaining capacity, can be determined using a discharge test under controlled conditions. The voltage method converts the battery voltage reading to an equivalent SOC value using the known discharge curve (voltage vs. SOC) of the battery.
TERMINAL VOLTAGE
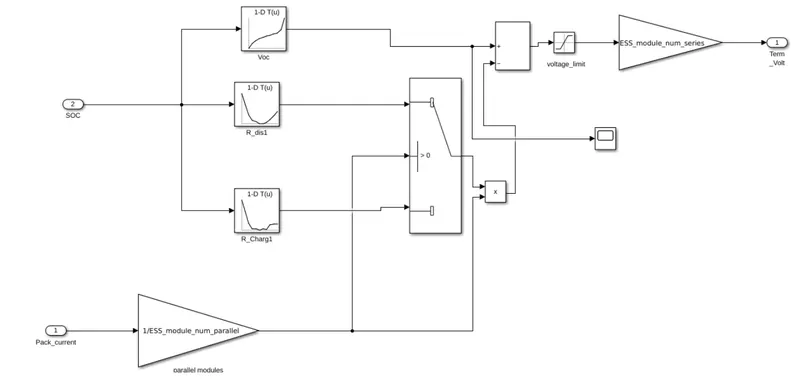
The first table variable in this use input SOC is interpolated as the state of charge and the open voltage circuit. It is coupled to a 1D lookup table. Resistance discharge and state of charge were interpolated as variables in the second table, and resistance charge and state of charge were interpolated as variables in the third table. The switch block is then given control over the three-shold. then they provide maximum and minimum voltage restrictions. meet terminal voltage after that.
CONTROLLER
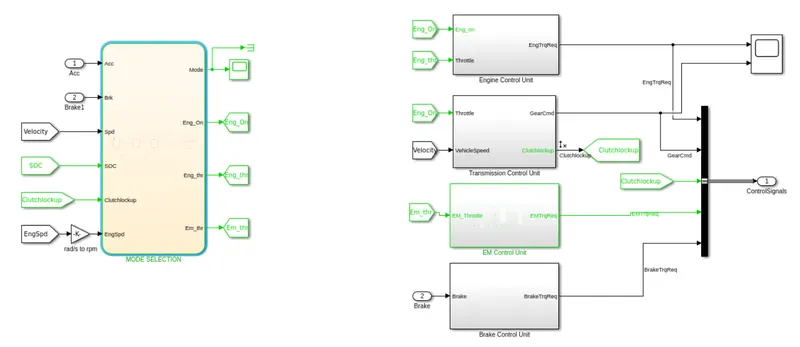
Controller model includes engine control unit, Transmission control unit and brake control unit.
MODE SELECTION
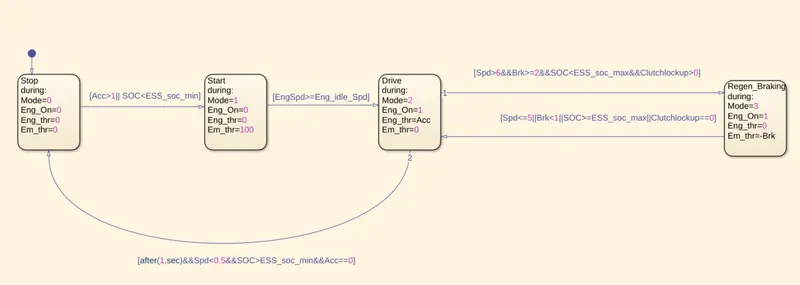
In this we created four conditions like stop, start, drive and regenerative braking. The start block represents a stop condition. In which the engine is turned off. Engine and throttle conditions are zero. Then the second block represents the initial condition. In mode 1, the electric motor throttle is only used to provide the required torque and power to the vehicle. the engine is off and the engine throttle position is zero.State 1 and State 2 are connected by links, i.e. it goes from State 1 to State 2 when acceleration is less than one or SOC is less than minimum SOC.State 3 Represents mode 2 ii.e. the engine is on and the engine throttle is also positive from the driver, but the electric motor throttle is zero. It changes from state 2 to state 3 when the engine speed is greater than or equal to the engine idle speed.state 4 represents regenerative braking, which is model 3 In this state, the engine is on, but the engine throttle has no input from the driver, while the electric motor receives negative power due to braking.The inputs are given to chart is Acceleration, barke, engine speed, vehicle speed, SOC, and clutch lockup.The output we get from the chart is mode, engine condition, engine throttle condition, and electric motor throttle condition.
ENGINE CONTROL UNIT
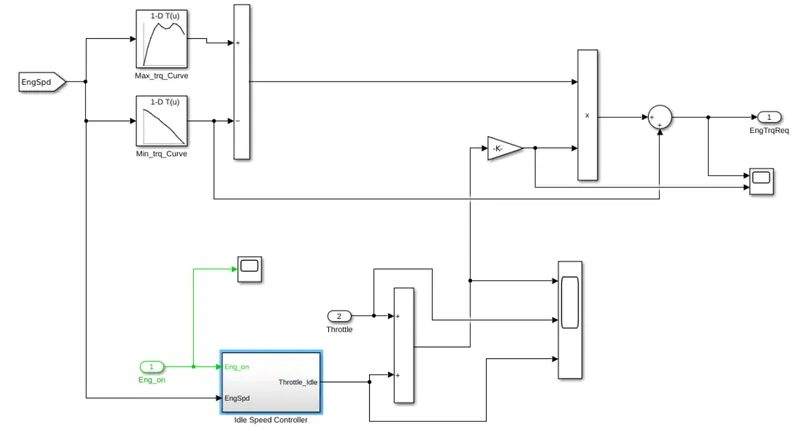
Engine control unit (ECU) is an electronic control unit that guarantees the ideal work of an inside combustion motor. It controls fuel supply and infusion, fuel-to-air proportion, start, sit still speed, and the timing of valve opening and closing.
IDLE SPEED CONTROLLER
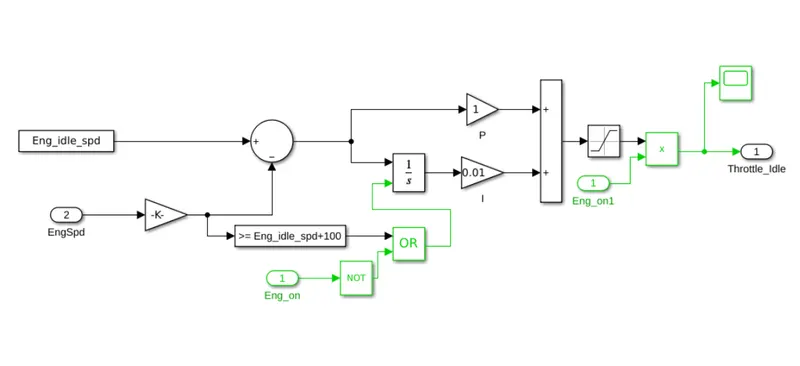
The idle speed control mode is utilized to anticipate motor slow down amid sit still. The objective is to permit the motor to sit still at as moo an RPM as conceivable however keep the motor from running unpleasant and slowing down when power-consuming embellishments, such as air-conditioning compressors and alternators, turn on.
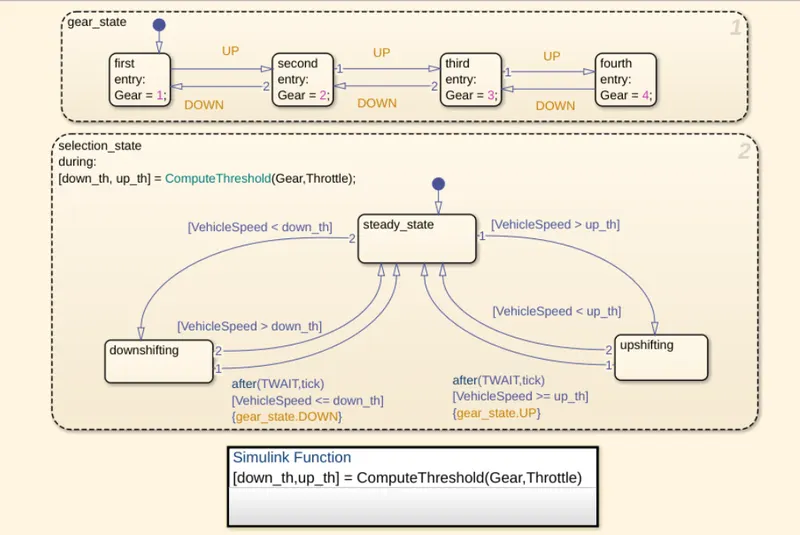
TRANSMISSION CONTROL UNIT
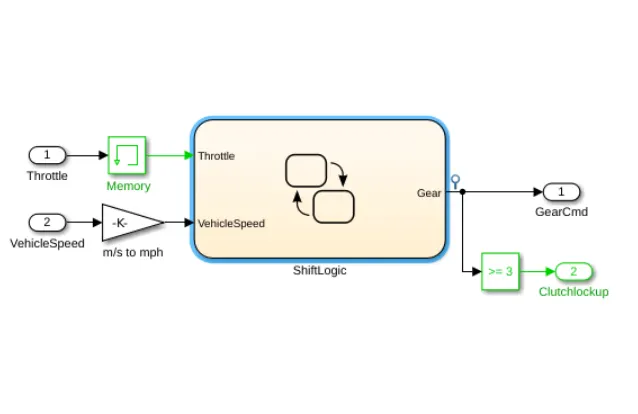
A transmission control module is an electronic component within the transmission that is responsible for interpreting electrical signals from sensors in other parts of the vehicle.
SHIFT LOGIC
ELECTRIC MOTOR CONTROL UNIT
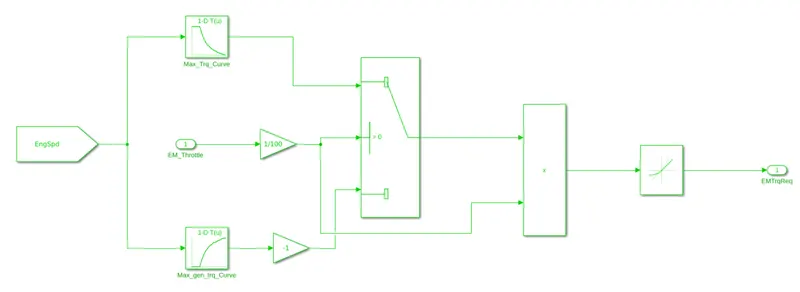
Motor controllers are devices that regulate the operation of an electric motor. In artificial lift applications, motor controllers generally refer to those devices used in conjunction with switchgear or variable frequency drives to control prime mover operation.
BRAKE CONTROL UNIT
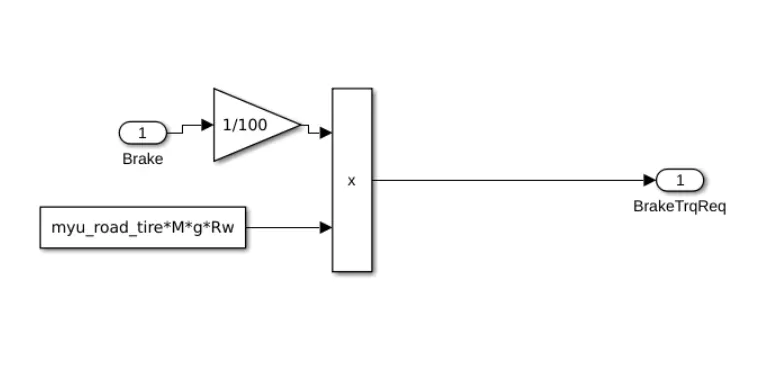
The brake control unit operate independently, but the trailer electric brakes must be connected to the tow vehicle power supply and controlled by a brake control unit or electric brake controller. A brake controller, as the term suggests, is an electronic device that activates and controls the trailer's electric brakes.
DRIVER
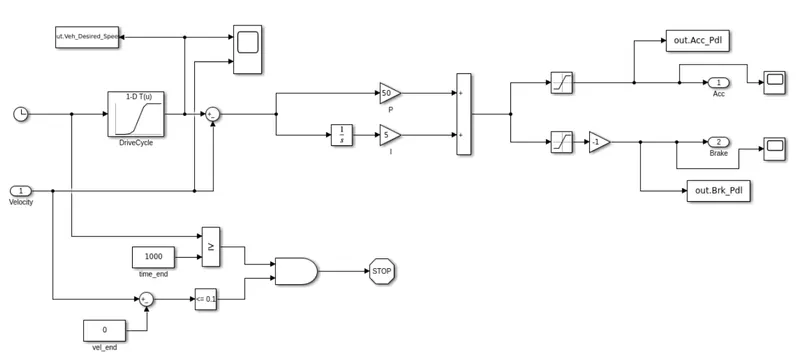
A "Driver" block, a fundamental PI controller, is used to model it. It creates outputs for the accelerator and brake pedals that correspond to the desired and actual vehicle speeds. We use drive cycles for this since they serve as a basis for uniform assessment and the outcomes of fuel consumption and emissions certification for the vehicle. It is based on time and velocity, after which everything is integrated to produce the accelerator and brake pedals.
a)
| Sl.No | Drive cycle | Fuel Economy Number (KMpl) | TYPE OF VEHICLE |
| 1 | UDDS | 15.0773 | HYBRID |
| 2 | UDDS | 14.207 | CONVENTIONAL |
| 3 | HWFET | 17.16 | HYBRID |
| 4 | HWFET | 16.53 | CONVENTIONAL |
- Hybrid system gives higher fuel economy number than conventional system.
- As can be seen, HWFET has higher fuel efficiency than UDDS. This is due to the fact that when driving in cities, there is more traffic, stops are required more frequently, and gasoline consumption is higher at first. Because there is no traffic and the car is moving without excessive braking during HWFET, the fuel economy rating is higher.
- When we can see, project 2's fuel economy figures are a little higher than project 1's because it has an electric motor installed. Because project 2 is a P1 hybrid, the fuel economy may not vary much, but as we add additional architectural features, it will rise dramatically.
b)
UDDS DRIVE CYCLE
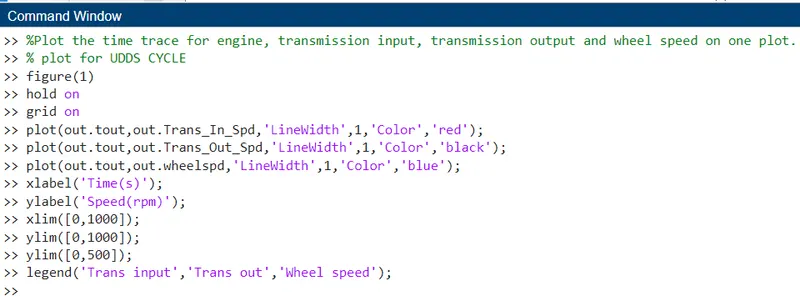
MATLAB CODE
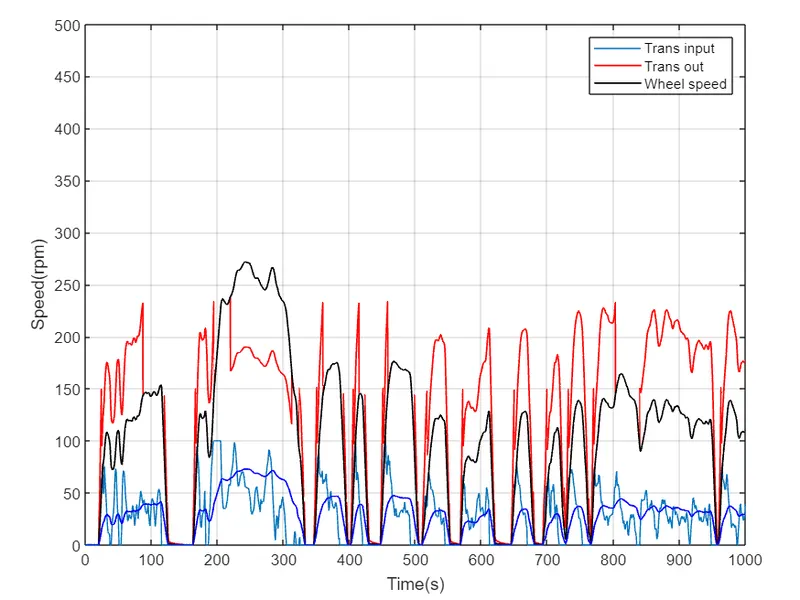
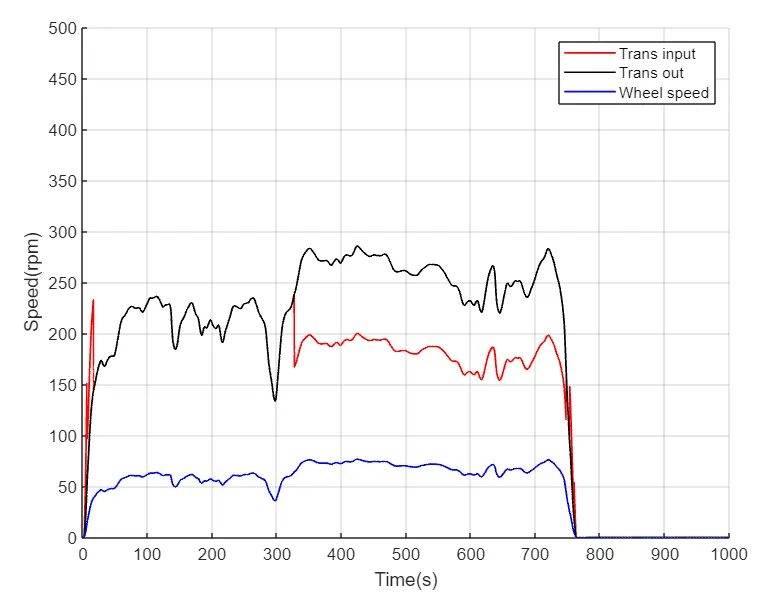
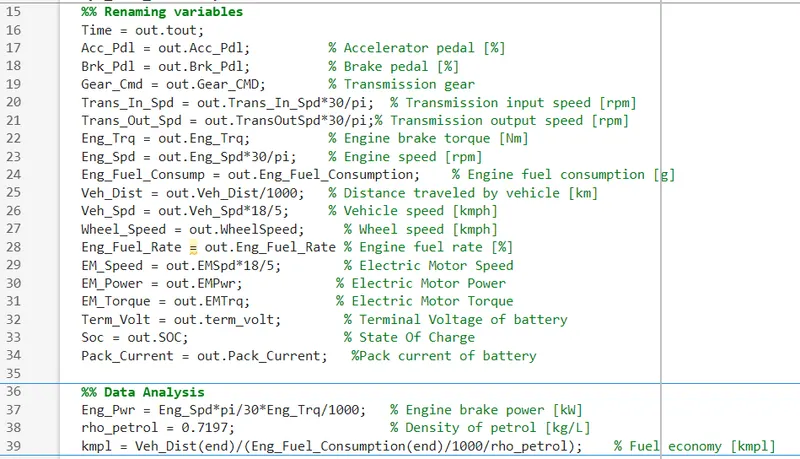
- In this case, we can see that the graph fluctuates more during the UDDS drive cycle than during the HWFET drive cycle. Because HWFET has fewer starts and stops than UDDS, this is the case.
- Compared to HWFET, UDDS requires more braking.
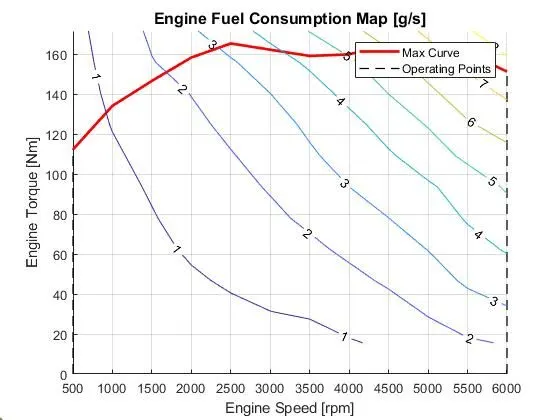
- In the UDDS drive cycle, the engine's maximum speed was close to 4200 RPM, but in the HWFET drive cycle, it was 3000 RPM
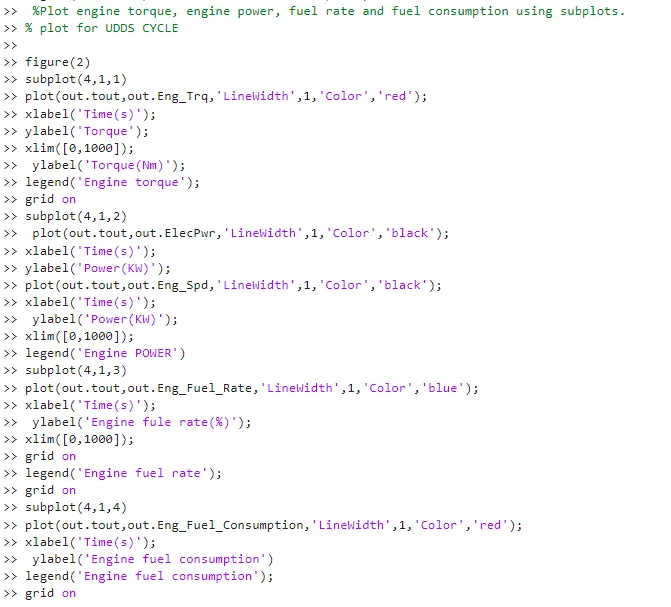
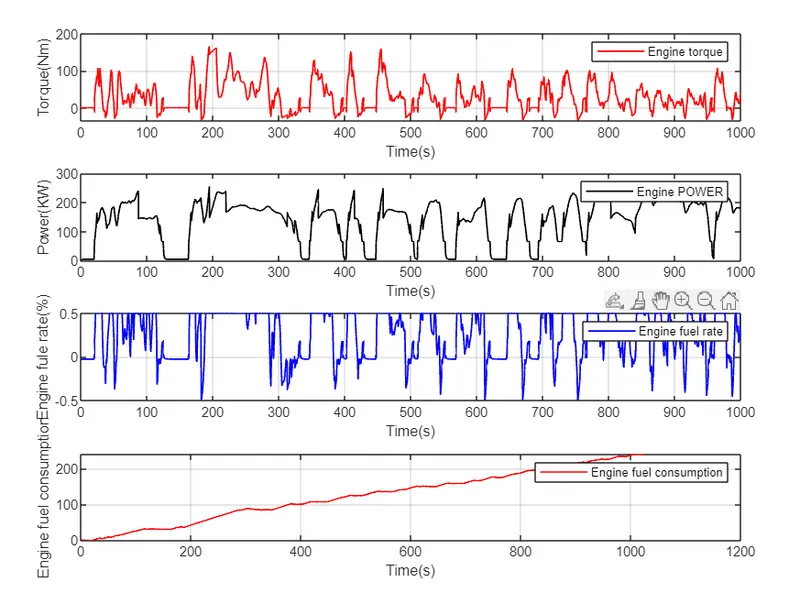
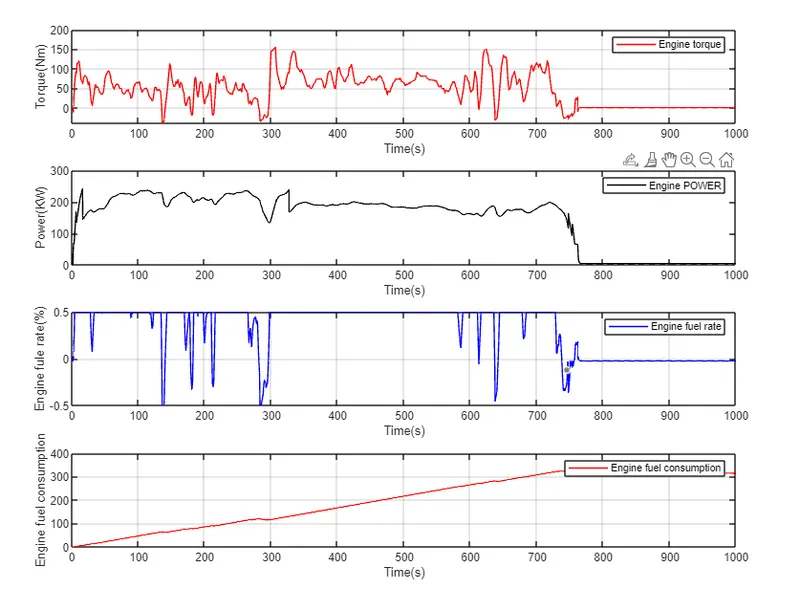
- The car used more electricity in the UDDS driving cycle since it had to make more starts and stops than a HWFET in urban areas.
- Because the vehicle needs more torque when starting from a standstill to overcome static friction, the engine is higher in the UDDS drive cycle than the HWFET drive cycle.
- Compared to the UDDS drive cycle, the HWFET drive cycle has a higher fuel rate since it will be moving continuously and require more fuel.
- Because of the frequent starts and stops that occur during the UDDS cycle and the idle position of the engine, the HWFET has a high fuel efficiency.
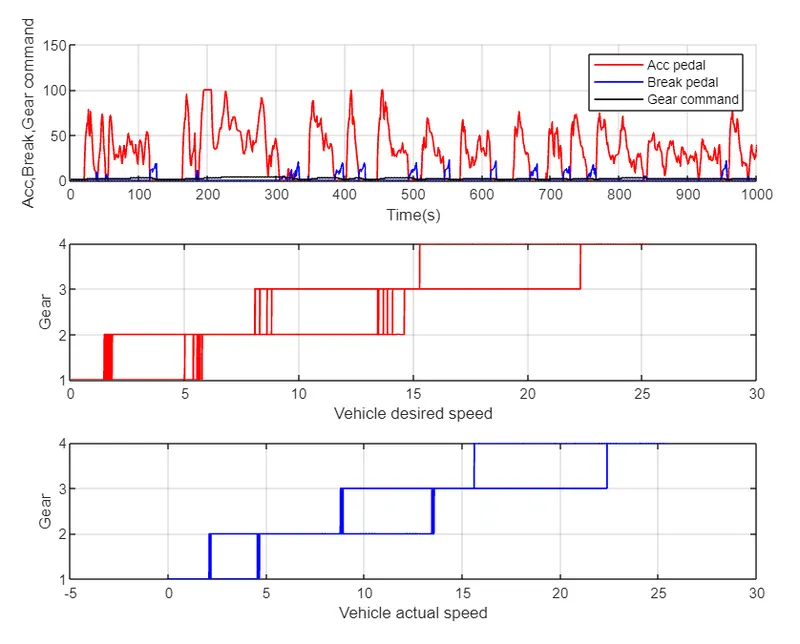
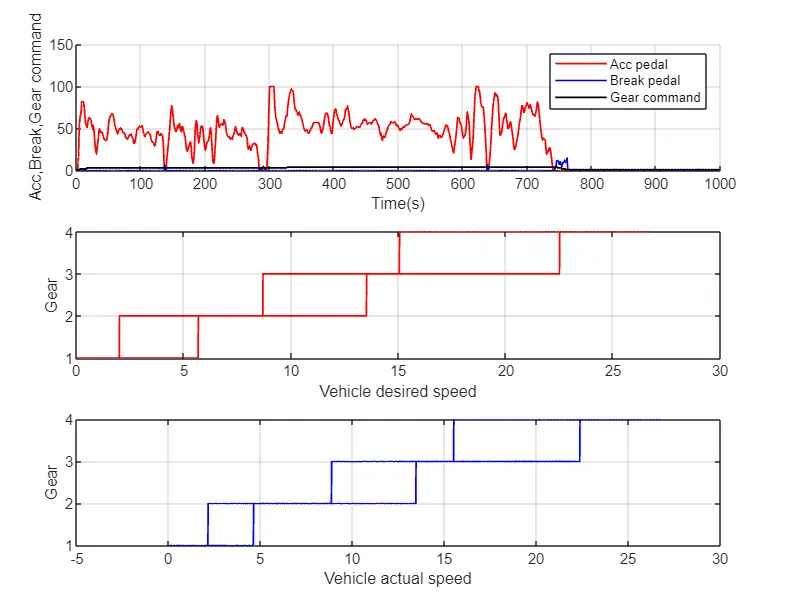
- Due to the frequent starts and pauses, the accelerator and brake pedals in UDDS experience greater variations. However, because there won't be any frequent stops, the brake pedal fluctuations in HWFET are almost close to the zero line.
- The first and second gears are used frequently in UDDS cycles, whereas the third and fourth gears are rarely used because the cycle cannot reach high speeds in such traffic. The car runs primarily in third and fourth gears during the HWFET cycle because it will be travelling quickly.
HWFET DRIVE CYCLE
f)
UDDS DRIVE CYCLE
MATLAB CODE
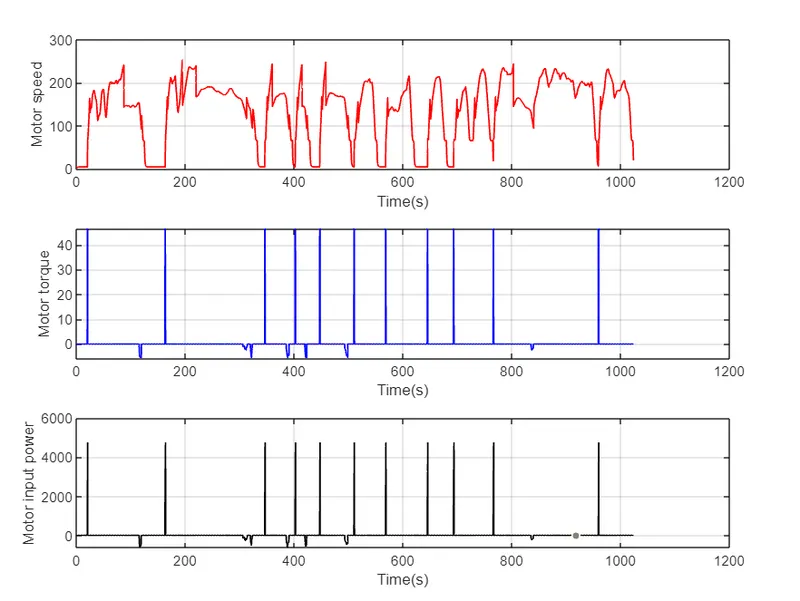
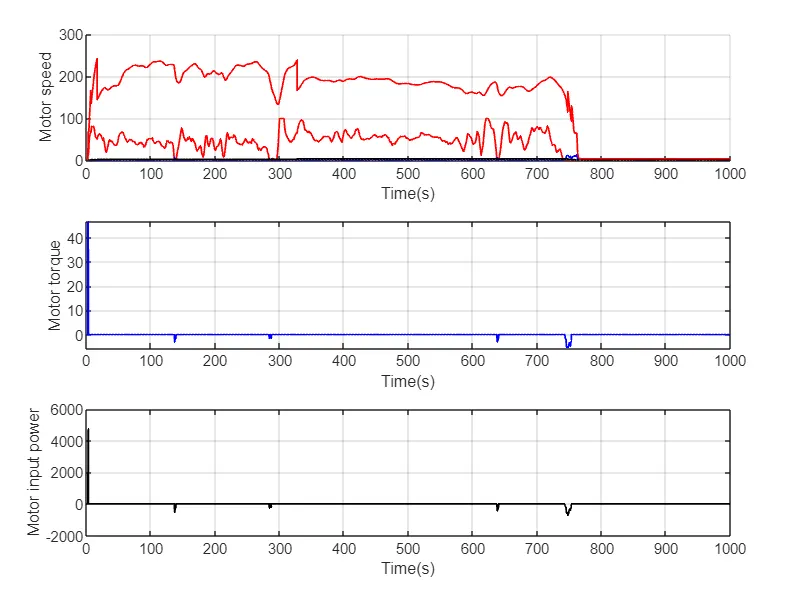
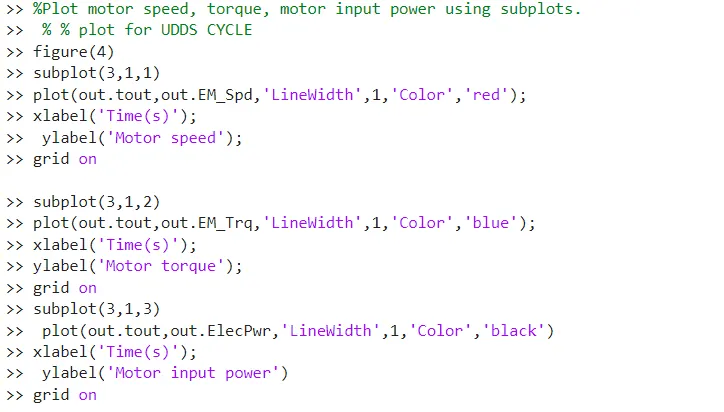
- As the objective of the motor in the P! hybrid is the starting of crank rotation, the variations will be greater in the UDDS cycle compared to the HWFET cycle because UDDS has more starts and stops as a result of traffic.
- Both cycles would have higher fluctuations if the motor's goal were to provide traction.
- We can see that the motor power and torque in the HWFET start out very high and quickly drop to nearly nothing, but in the UDDS, there are continuous variations. This is due to the frequent braking in the UDDS.
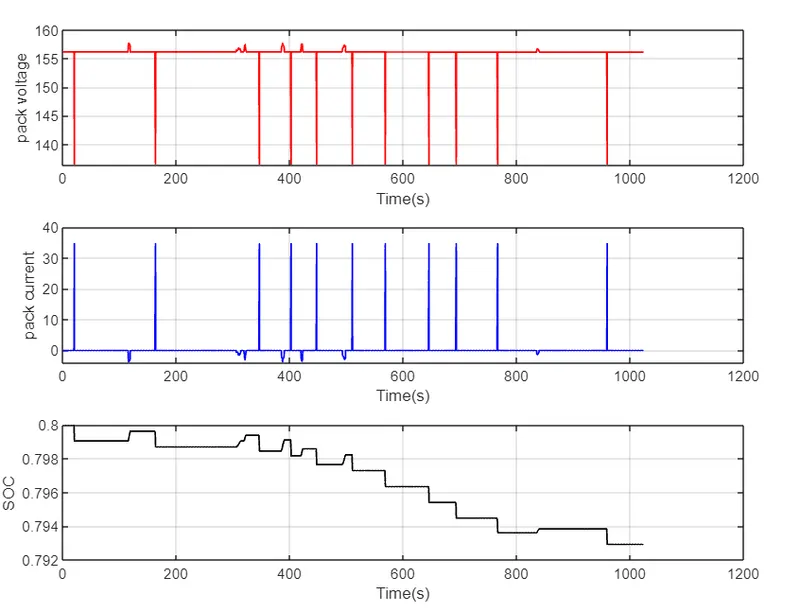
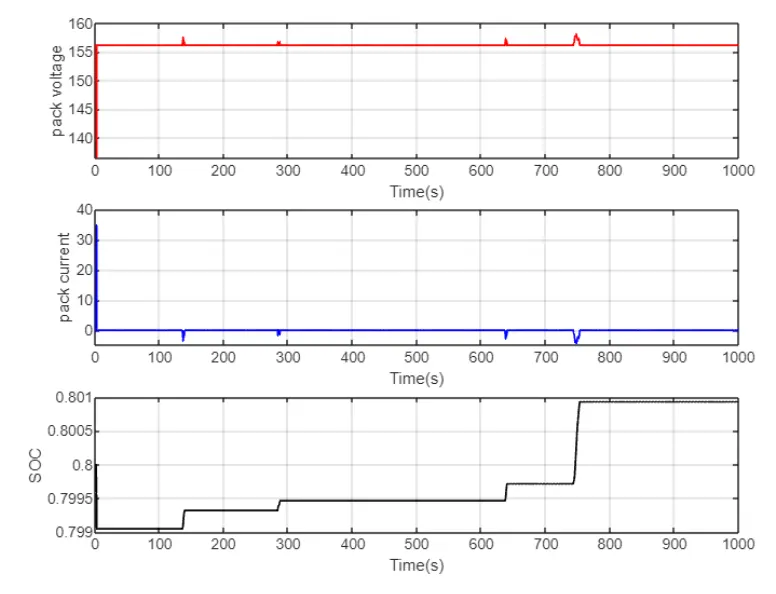
- Due to the many starts and stops throughout the drive and the battery's need to supply energy each time the car is started from the idle position, the pack voltage and current will fluctuate more in UDDS than in HWFET cycle.
- SOC declined with time in the UDDS cycle but increased over time in the HWFET cycle. It is because in UDDS, we frequently start and stop the car, and the battery must supply the energy every time the car is starting from the idle position, and as a result, the SOC decreases. However, in the HWFET cycle, the vehicle will be moving continuously without frequently stopping, and the alternator will be used to use some engine power to transfer to the battery through the motor, causing the SOC to increase
CONCLUSION
The various performance of characteristics and operating points of UDDS drive cycle and HWFET drive cycle are analysed and the following graphs are plotted
- Time trace for engine, Transmission input, Transmission output and wheelspeed with respect to time.
- Engine torque, Engine power, Fuel rate and Fuel consumption with respect to time.
- Accelerator and brake pedal, gear command and vehicle desired, actual speed, vehicle distance with respect to time.
- Engine operating points on the engine fuel map with respect to time.
- Motor speed, Torque, Motor input power with respect to time.
- Pack voltage, Current and State of charging with respect to time.
- The motor operating points on the motor input power map with respect to time.
- Also it comparing with HWFET drive cycle and their numbers also compared