Project-1: Modelling an electric Car with Li-ion battery
Project-1(Modelling of Electric car using Li-ion battery)
OBJECTIVE:
To create a model of electric Car with Li-ion battery and run the model with FTP75 drive cycles.
TO OBSERVE:
- Temperature rise in controller from initial temperature during each drive cycles.
- Temperature rise in DC motor from initial temperature during each drive cycles.
- Battery SOC(state of charge) at each drive cycles.
- Distance covered by each drive cycles.
- Voltage,Current variations on Li-ion battery.
MODEL:
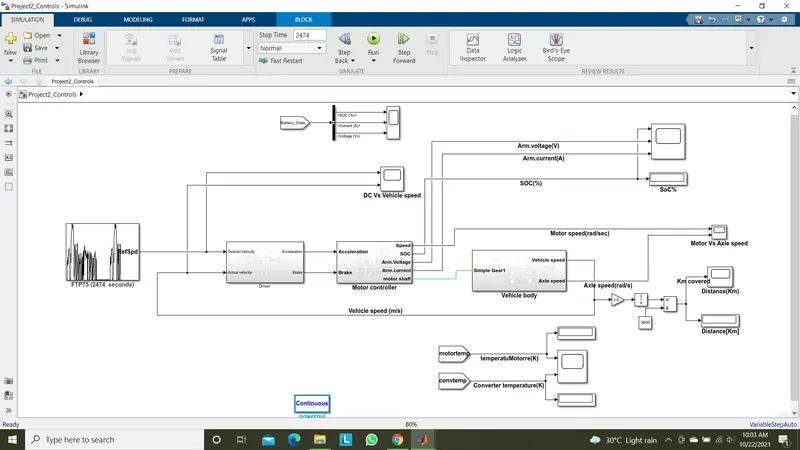
OPERATIONS:
Drive cycles:
Here in our model we have choosen FTP75 drive cycle.
Below shown the FTP75 drive cycle plot and their block paramrters,
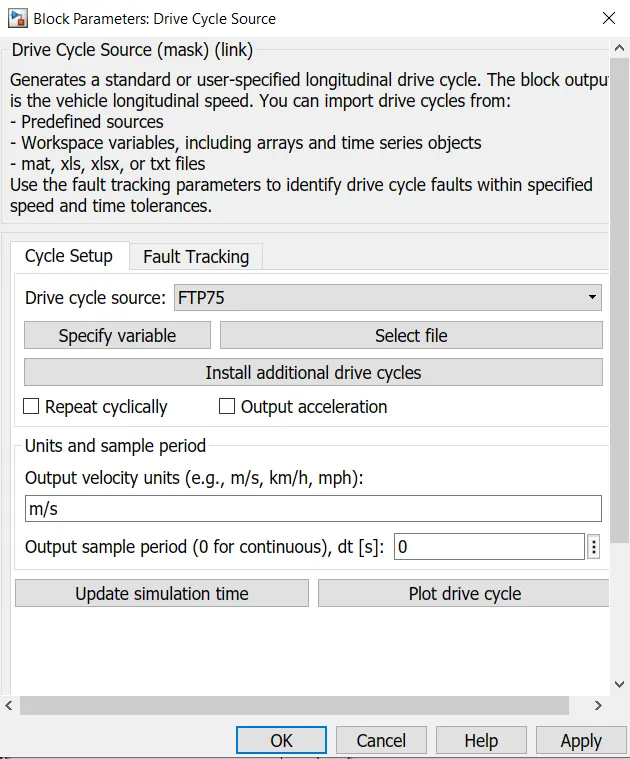
The output velocity is in m/s as mentioned above and its plot can be viewed by clicking 'plot drive cycle' tab.
We can also select our owm drive cycle datas from 'select file' option an choose out excel file data or .mat files time vs speed datas.
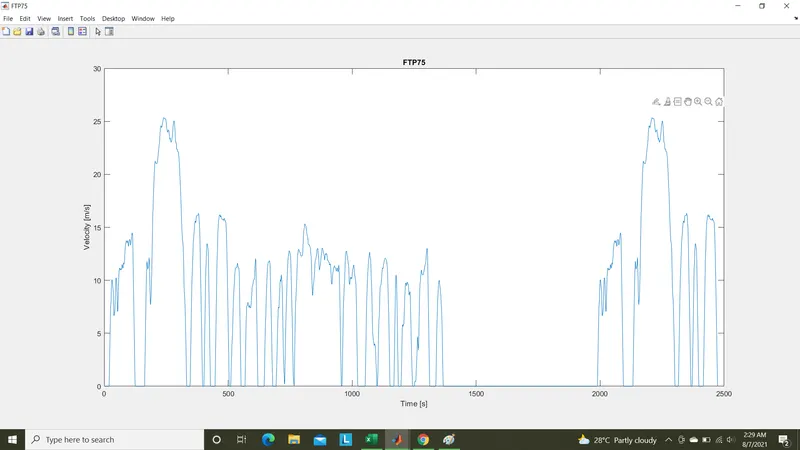
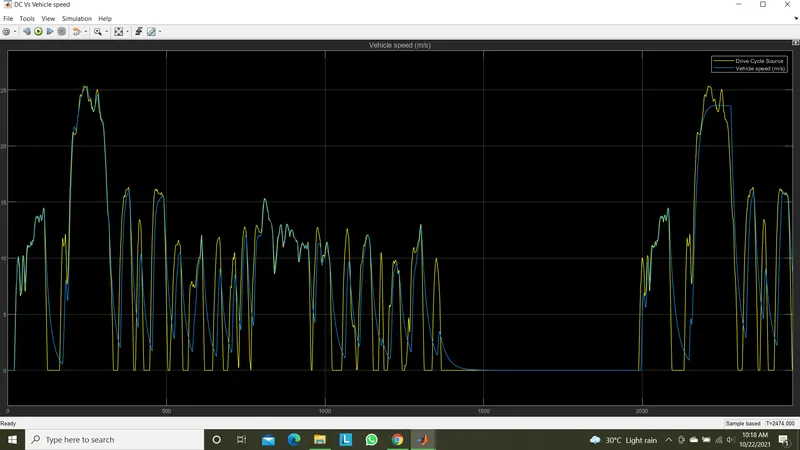
These referance drive cycles are given as referance speed input with respect to time to the PID controlled driver block.
Driver block:
Here created the PID controller controlled driver block to get acceleration and brake commands.
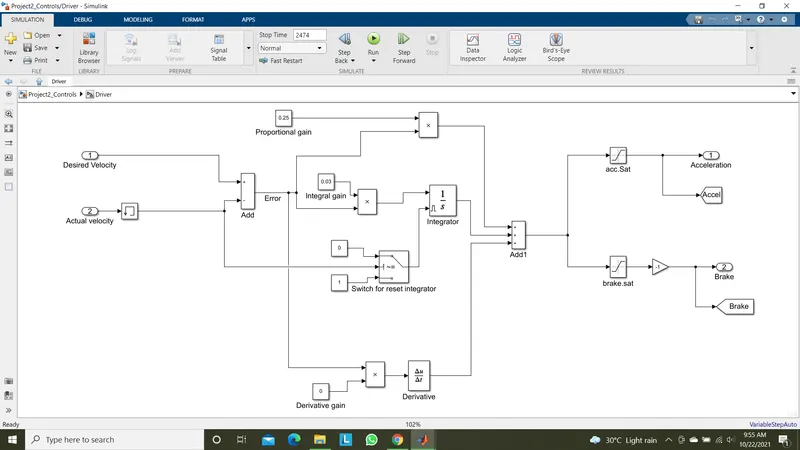
In this block the inputs are Desired velocity from drive cycle source and Actual velocity as feedback from vehicle dynamics subsystem.
The outputs of this subsystem are acceleration and brake commands.
Initially the Desired velocity is subtracted from actual vehicle velocity and it creats a error(difference) in velocity output.
This error output is feeded as proportional,integral,derivative outputs and added to get final acceleration/brake command outputs.
The error is multiplied with a proportion gain value to perform proportional operation output.
The error is multiplied with an intrgral gain value and given to an integrator block to perform integral operation output.
A switch to reset the integrator is created as when the velocity of vehicle comes to 0 the integrator gets reseted(Switch o/p as 1 for reset) to perform its operation again from initial stage.
This action helps to correct the integral error values,preventing from integral wind up condition.
Again error is multiplied with a derivative gain and given to a derivative block to perform derivative operation output.
These actions are considered as a PID controlling of vehicle velocity.
All three outputs from Proportional(P),Integral(I)and Derivative(D) are added with a ADD block to get final acceleration/brake command outputs.
A saturation block of range 0 to 1 given for acceleration command and saturation of 0 to -1, multiplied with -1 given for brake command to consider brake command also in positive values.
While acceleration is in progress,brake is in off state and viseversa. Both acceleration and brake will not occure in same time.
Motor Controller:
Here shown the overall motor controller parts of this subsystem.
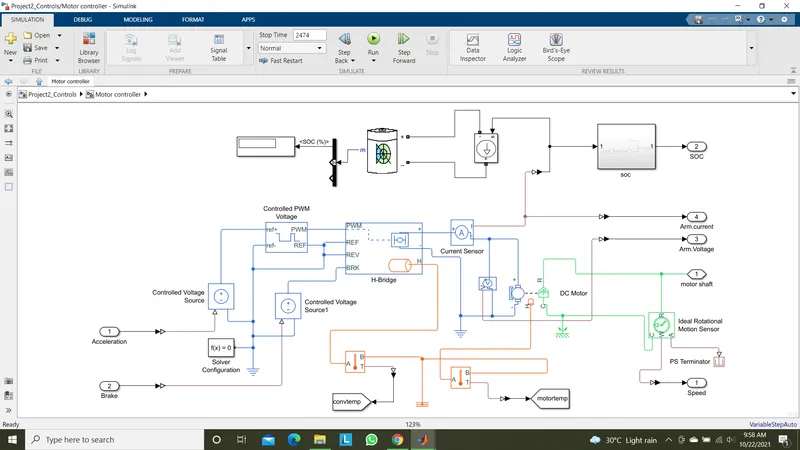
In this subsystem the major blocks presented were,
- Controlled voltage source.
- Controlled PWM voltage.
- H-bridge(Converter).
- Current sensor.
- Voltage sensor.
- DC Motor.
- Thermal sensor.
- Ideal rotation motion sensor.
- Li-ion Battery.
- Controlled current source.
- SOC unit.
- Energy consumption unit.
The operation of this subsystem explained as below,
- The Acceleration and deceleration commands are given to controlled voltage source for producing voltage accordingly to the commands for PWM generation unit.
- The controlled PWM voltage block produce the PWM pulses for H-Bridge(DC-DC converter) switches as controlled PWM signals.
- These PWM Pulses makes ON/OFF accordingly to make the motor input voltage as controlled voltage from battery source.
- The speed of the motor changes correspond to the referance drive cycle speeds by the power converter switches present in H-bridge circuit.
- The Voltange can be controlled by variations in their duty cycle in PWM signals.
- Finally the shaft of motor is given to the axle of vehicle body through a coupled gear with certain gear ratio.
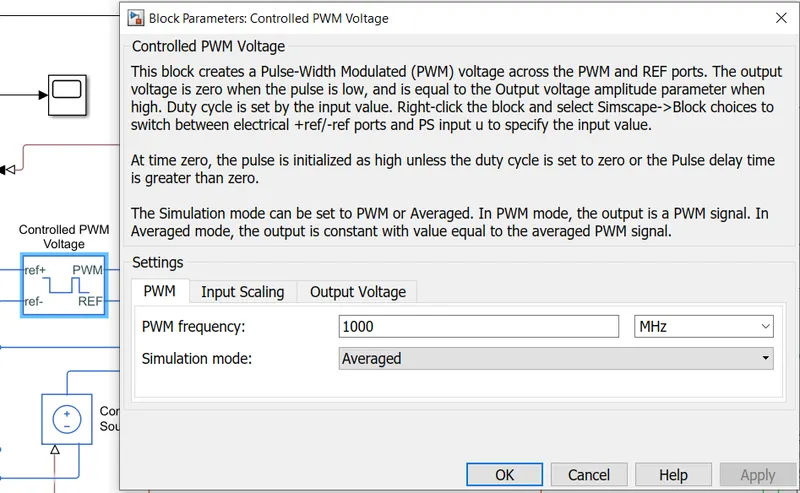
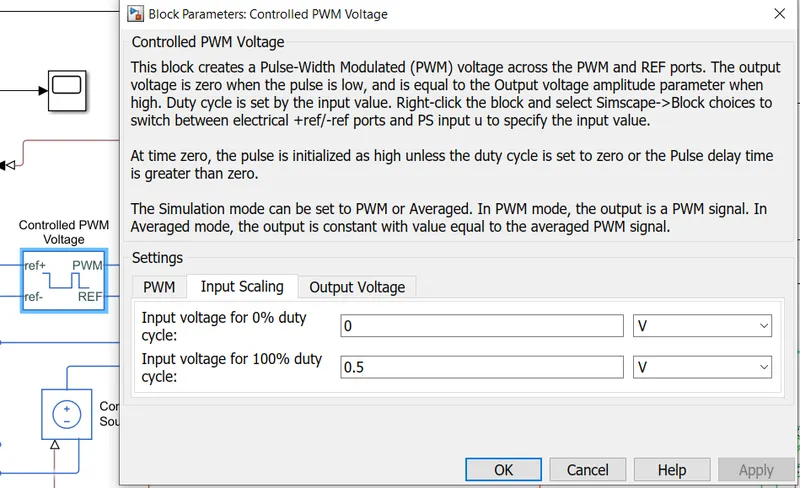
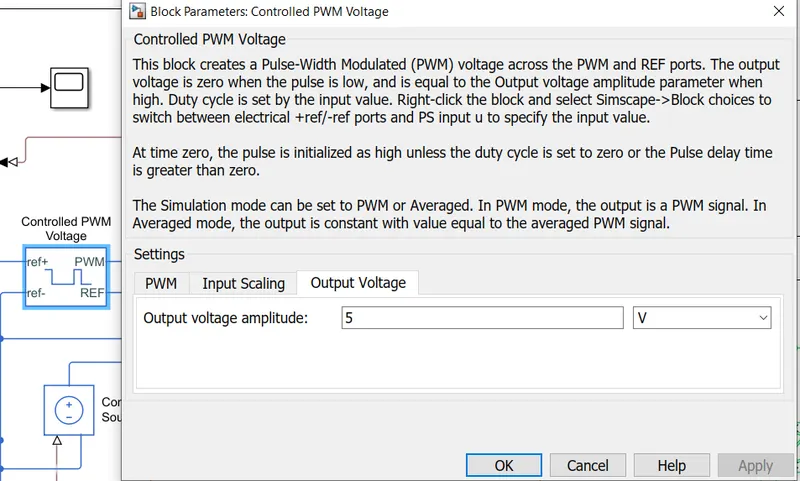
Controlled PWM voltage:
The configured values are shown below,
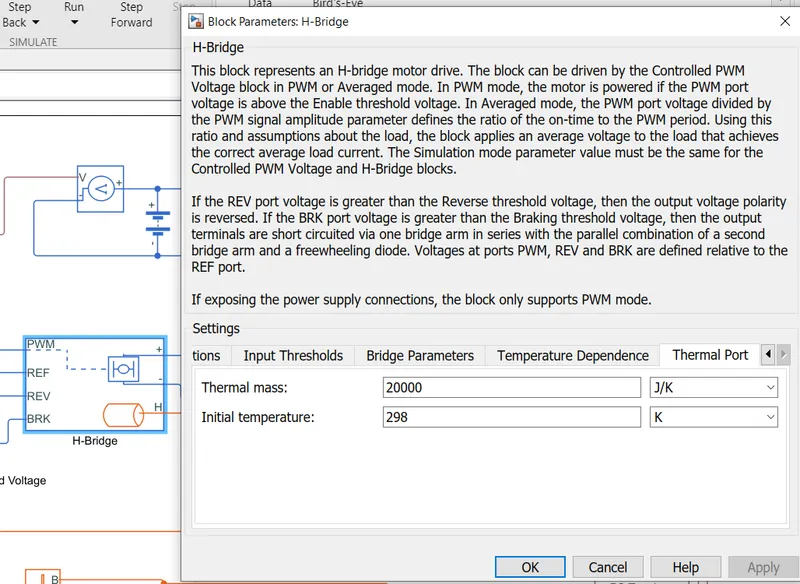
H-bridge:
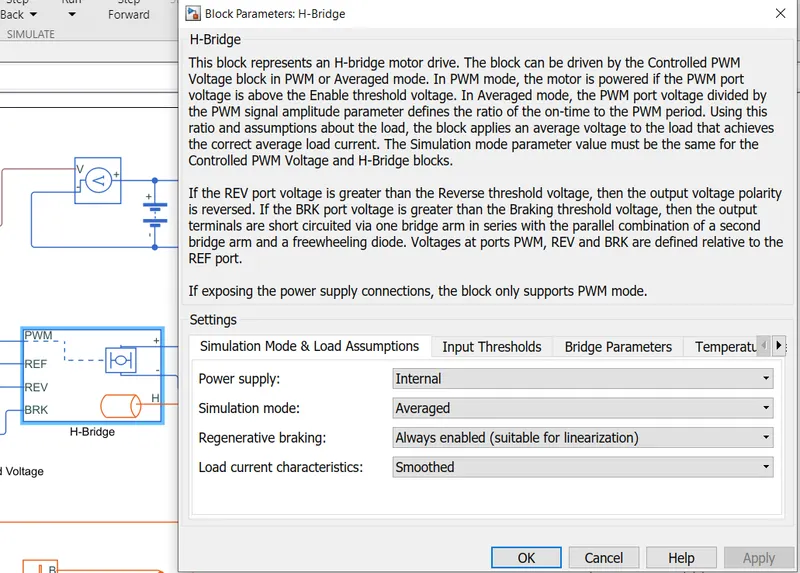
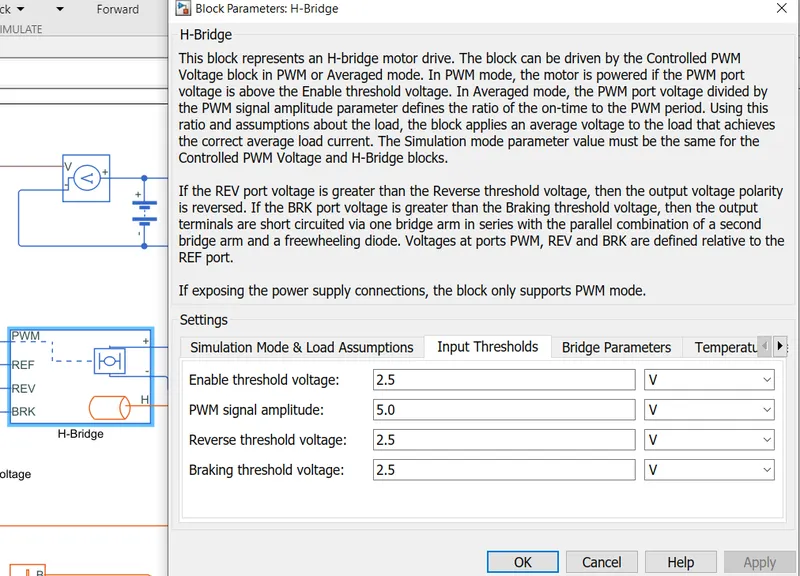
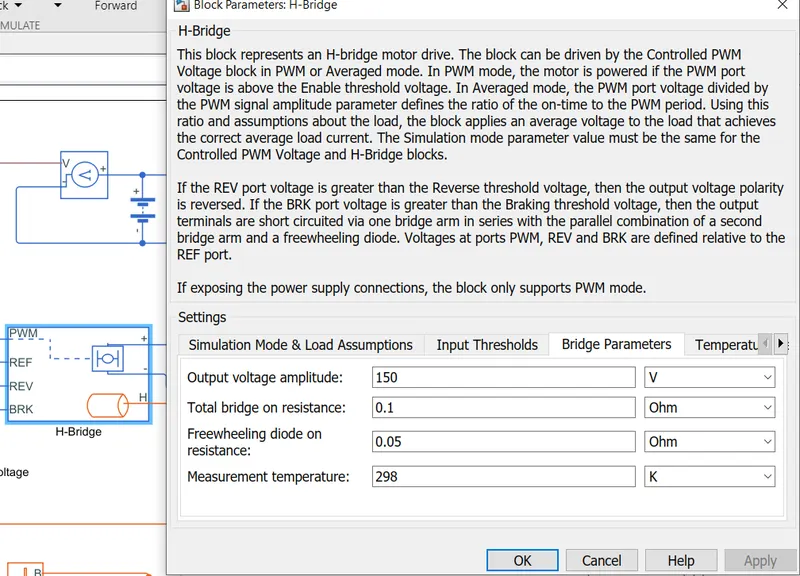
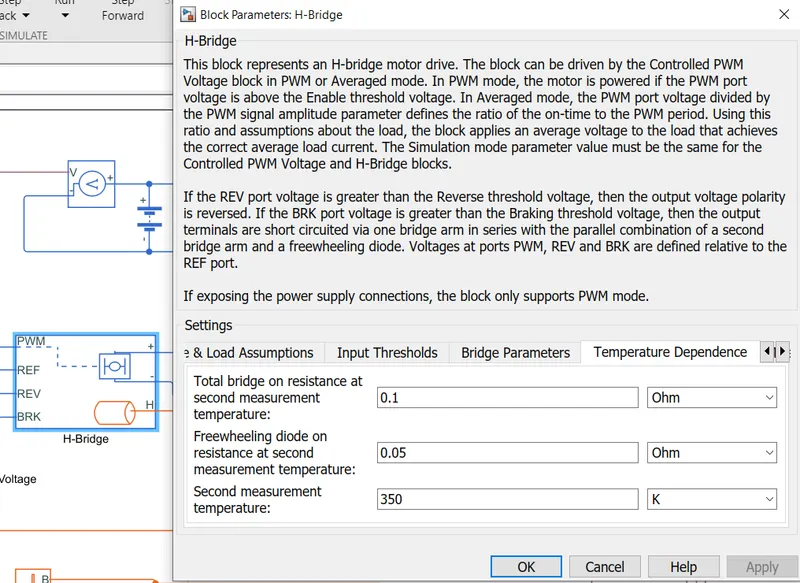
This block is power electronic converter of DC motor.The battery rated voltage 400V reduced to 150V and given as input to DC motor.
Thermal port is adden in this block to measure the temperature produced on converter. From this port we can maesure the rice in temperature in converter
by, Temperature rise =(Initial temperature 298K(25 deg celcius) - Noted temperature at end of drive cycle)
The configuration parameters for H-bridge are given below,
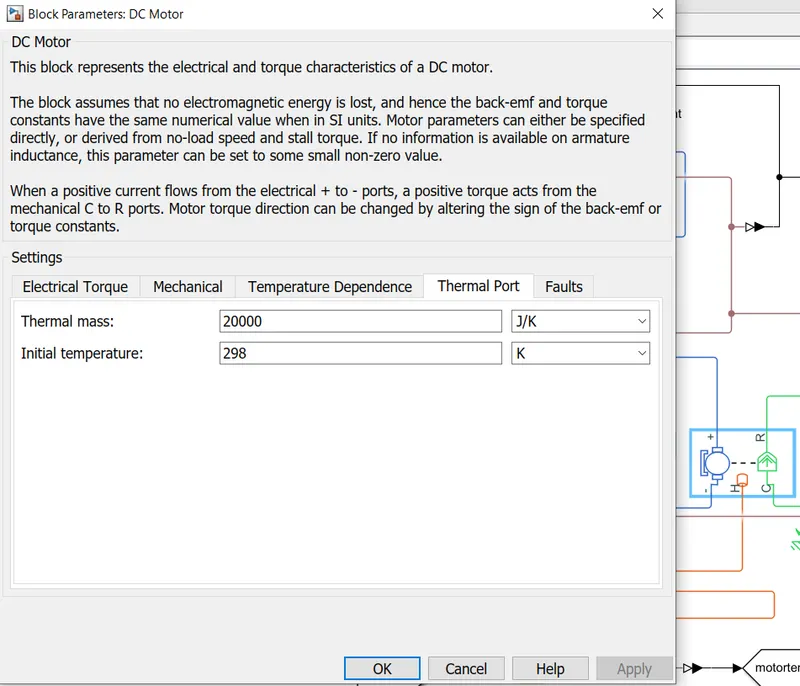
DC Motor:
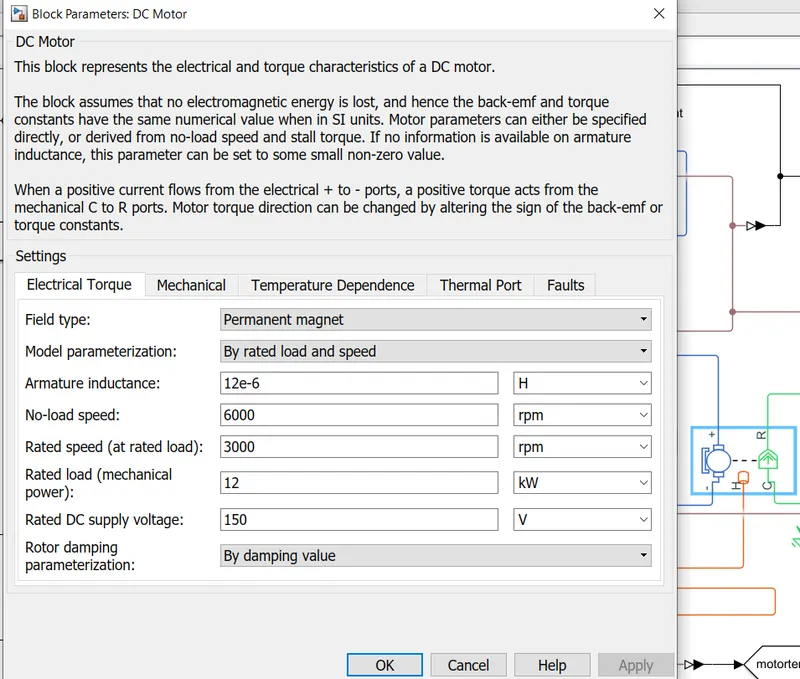
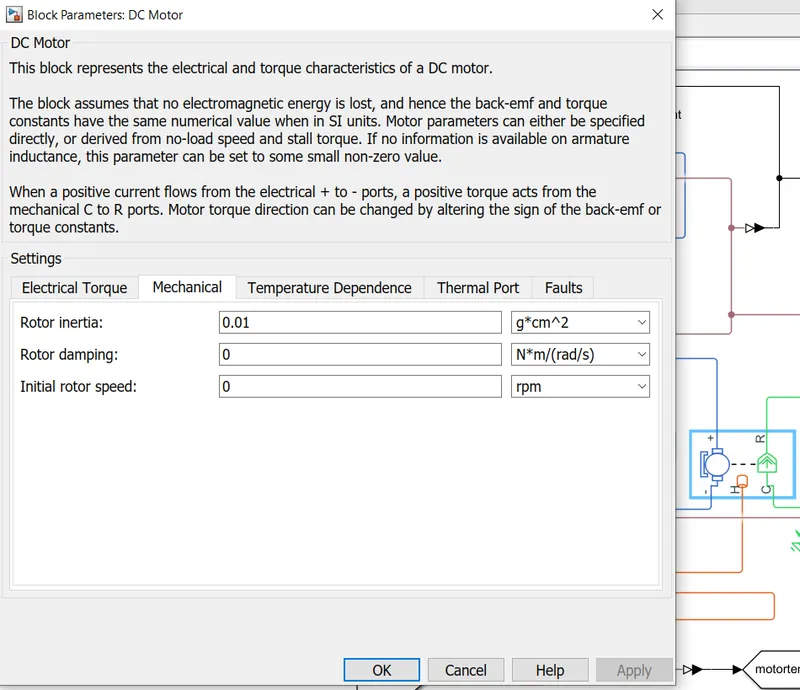
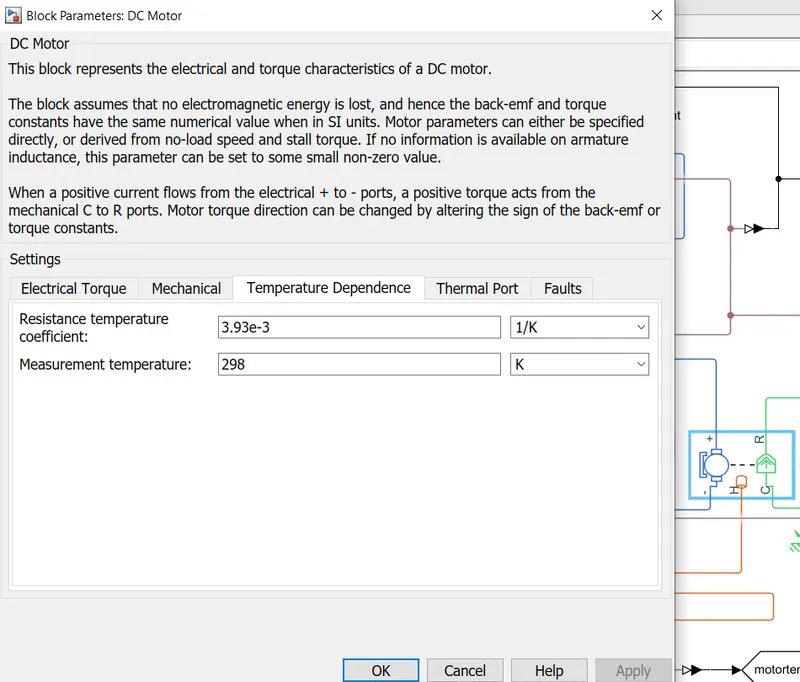
The configured parameters are,
Here we had taken 12KW rated load motor with no load speed as 6000 rpm and rated speed as 3000 rpm.Rated DC supply as 150 V.
Here also thermal out port is added to measure temperature rise of motor.
Battery:
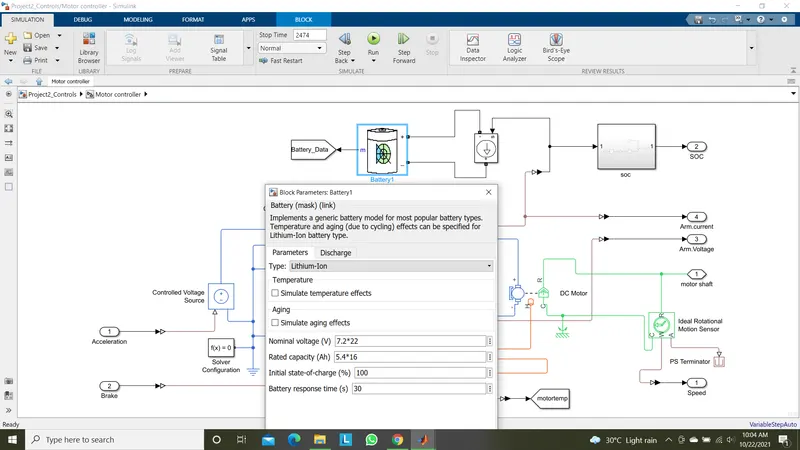
Here Li-ion battery is additionally added to see the charging and discharging current , voltage changes and SOC of Li-ion battery.
The voltage to DC motor is supplied directly from converter circuit as voltage source is given as internal in H-Bridge block parameter.
Here battery nominal valtage is set as 7.2*22(cells) to get around 160 V.
The battery rated capacity is set as 5.4*16(cells) for around 86 Ah level of battey as suitable of moter driving.
SOC % :
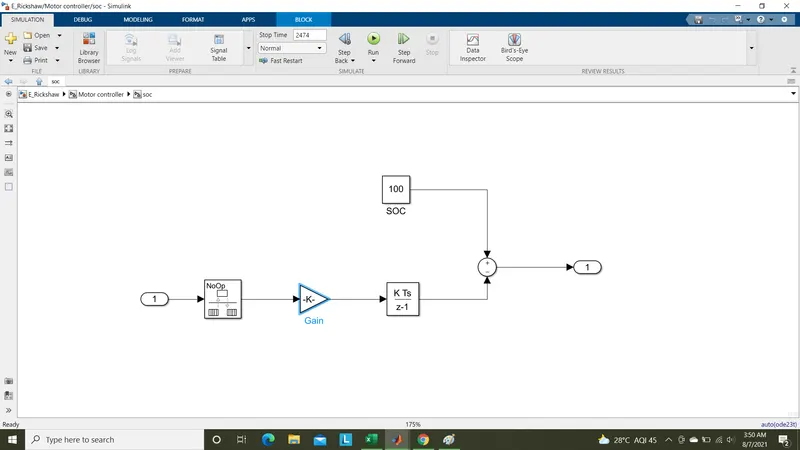
The SOC of battey can be calculated by taking 100% as initial refeerance state.
Then the variation in current senced at armature of DC motor is given to a rate transition for converting the current value to a per unit
of 100 ,multiplied with gain of inverted 1 Ah value, then converted to state of charge value at every sec compared with 100%.
The resultant charge is plotted accordingly at every sec.
Temperature senceing:
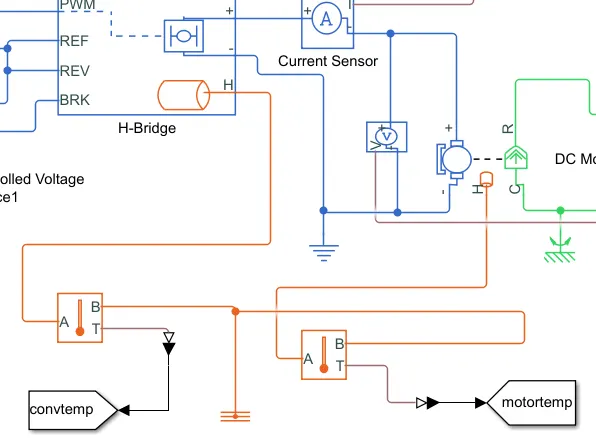
The temperature out ports are enabled in converter and motor blocks.
The outports are connected to Thermal sensor to sence the temperature of converter and motor at every second.
The connections are shown as,
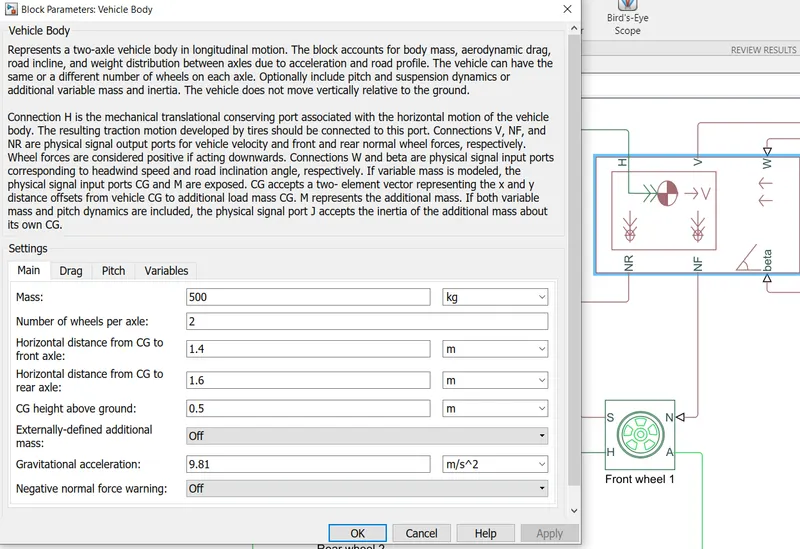
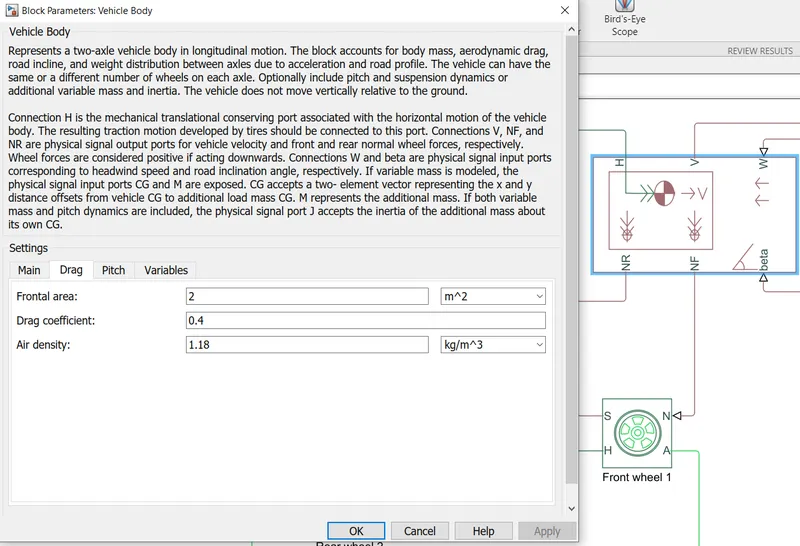
Vehicle body:
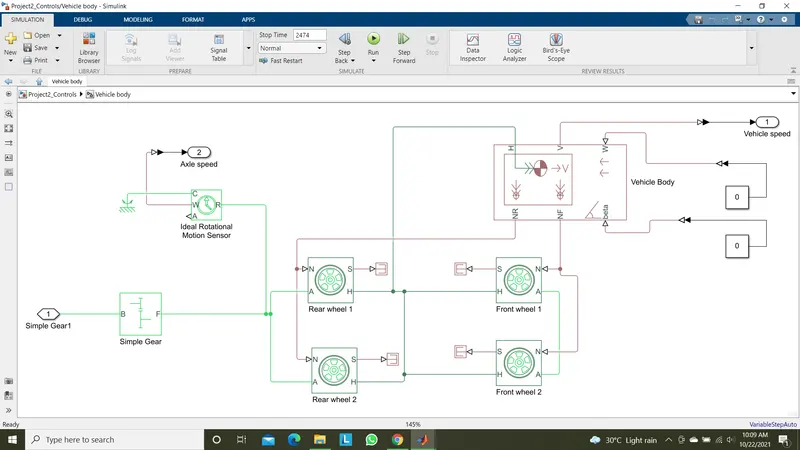
Here a simple gear of gear ration 5 is connected between the motor shaft and rear wheel axle.
The vehicle body configured as,
RESULTS:
After configured all the parameters run the model for three drive cycles connected as referance.
FTP75 Drive cycle:
Set stop time as 2474 secs and click run.
The results are,
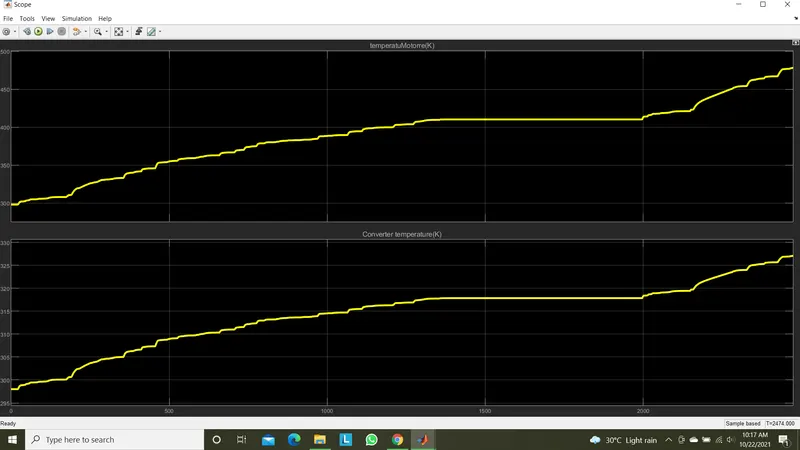
Temperature rise in controller from initial temperature during drive cycle=28.95 deg C.
as final temp of converter is 327.1K(53.95 C)
=>( 53.95 - 25) =28.95deg C
Temperature rise in DC motor from initial temperature during drive cycle=180.05 deg C.
as final temp of motor is 478.2K(205.05 C)
=>( 205.05 - 25) =180.05 deg C
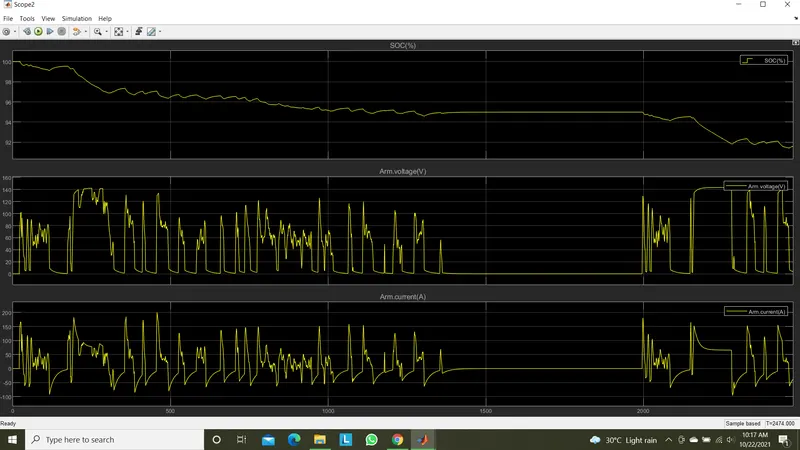
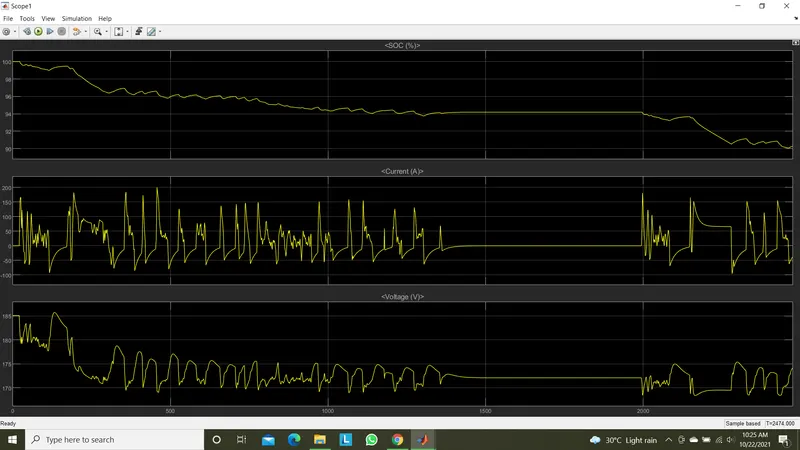
Battery SOC(state of charge) at end of drive cycle=91.59%( Approx. 10% reduced in this drive cycle)
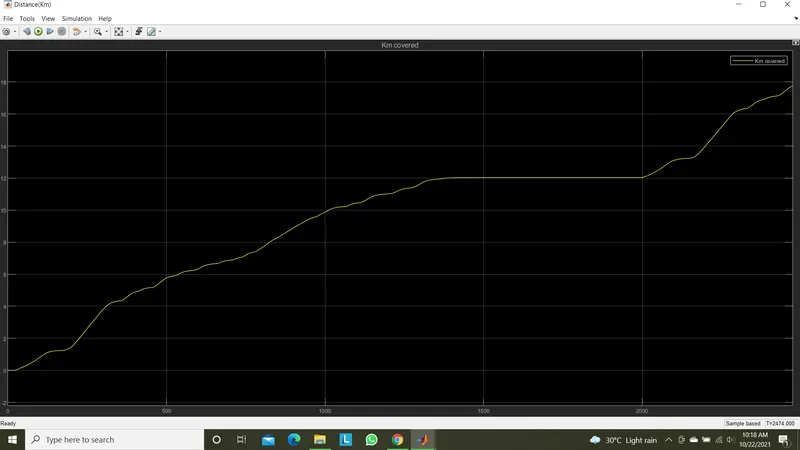
Distance covered by at end of drive cycle= 17.75 Km.
Armature voltage,Armature current scope and SOC(calculated from SOC block) of battery results:
Li-ion battery Datas:
Temperature rise:
Distance covered:
Referance speed Vs Vehicle speed control:
Note: Model file attached with this submission.
Thank you
Submitted by,
Praveen Kumar L V,