Project-1: Modelling an electric Car with Li-ion battery
Objective Of the Project :
Create a MATLAB model of electric car which uses lithium ion battery and suitable motor. Choose suitable blocks from Simscape or Powertrain block set. Implement the vehicle speed control using PI controller and generate brake and accelerator commands. Avoid using readymade driver block for speed control.
The Vehicle is a set of sub-systems.These sub-systems are designed to achieve their individual objectives for an example the Motor controller will produce the voltages according to the switching pattern & this pattern will be generated by the throttle control of the vehicle.So in order to design a Electric vehicle we have to design each & individual system by considering physical parameters of our car.
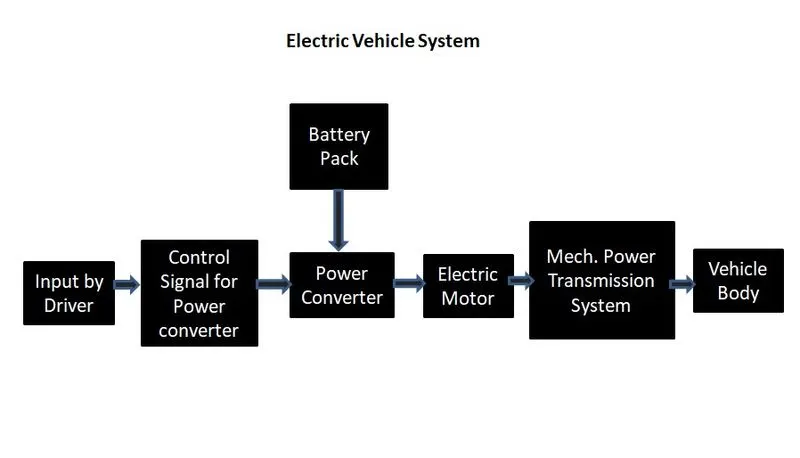
I have divided the entire vehicle in different sub-system as mentioned above I will explain individual system step by step.
1) Vehivle Body & Mechanical Power transmission system :
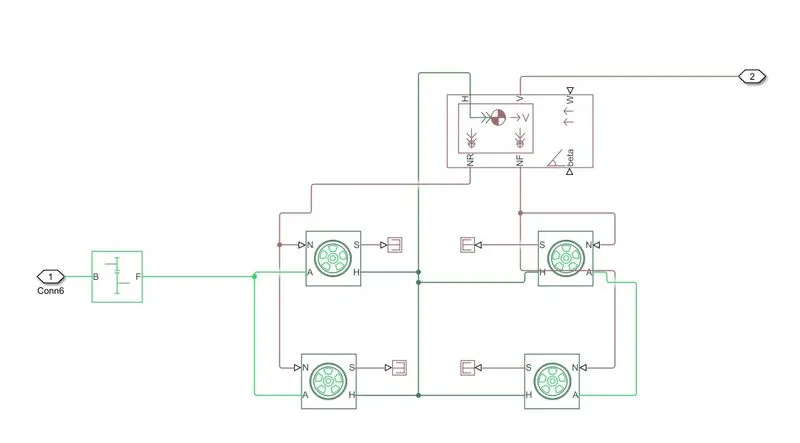
It is the most fundamental part of the system because all the forces that would be calculated to select th motor power based on it.The Wind drag force,Inclination angle of road (Grade),Wheel rotation,Friction loss, Gear & other mechanical parameters of the system can be configured in this perticular system.
Tire block :
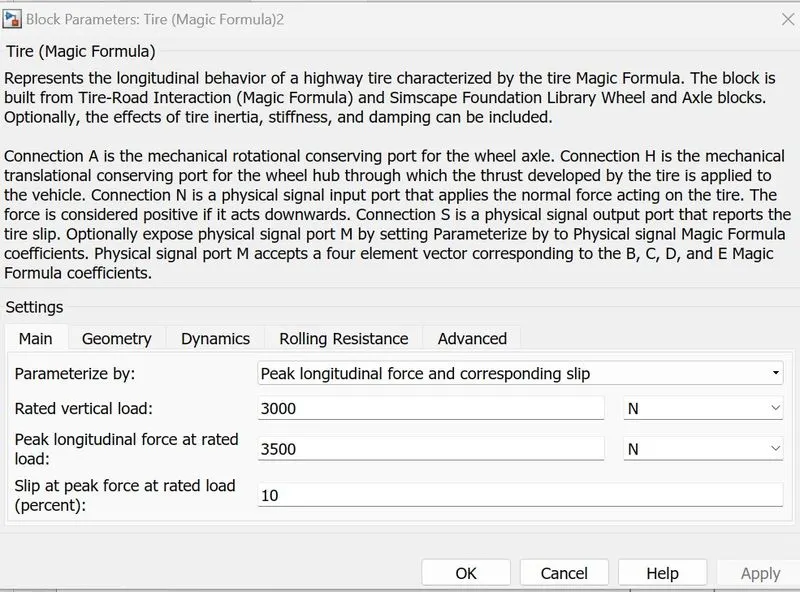
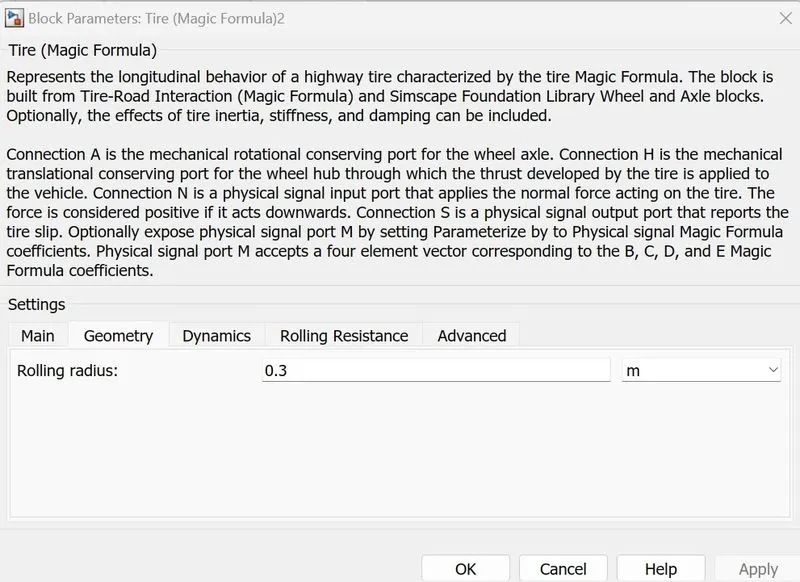
Tire block is a block which represents the vehicle tire.The mechanical data of the tire are as per shown above.
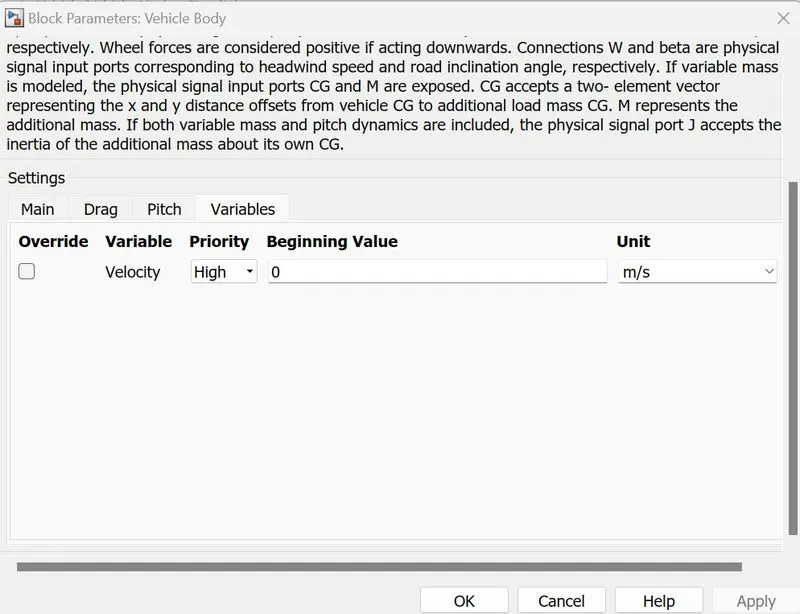
Vehicle Body :
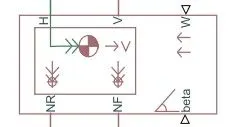
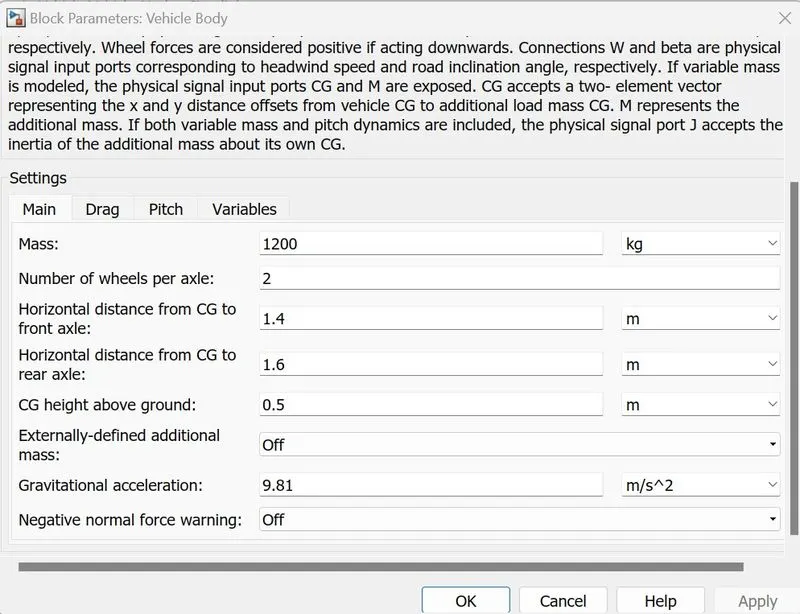
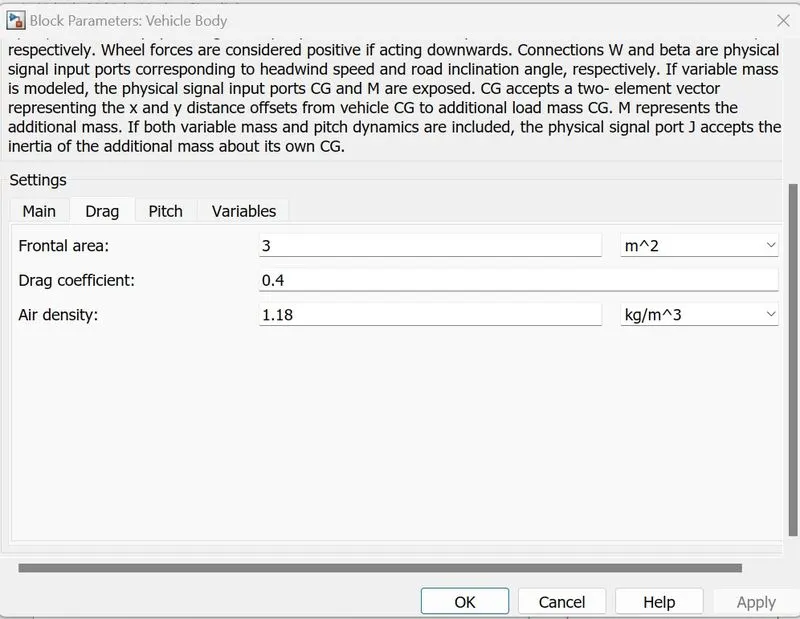
This block will facilitate us to realise the vehicle select the physical parameters of the vehicle as vehicle weight,wheel of the vehicle per axle,Distance between two axles of the car body,Car's hight from the ground,Air drag coefficient,Gravitational Acceleration & other variables. We can configure vehicle body as we wanted by just changing this values.
We have to provide following inputs to this block:
1)Normal force on front wheel (NF)
2)Normal force on rear wheel (NR)
3)Windage force on vehicle body
4)Hub (through all the wheels are connected)
5)Inclination angle of the road with reference (Grade)
Output of the Block:
Vehicle Velocity in ( Desired Unit)
Simple Gear:
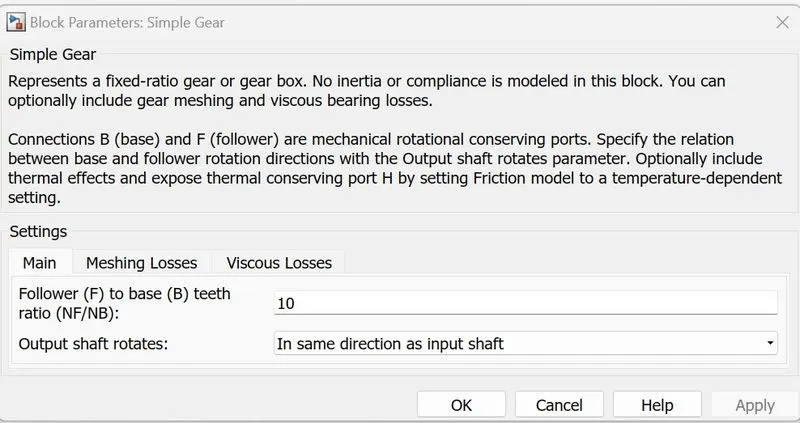
This Part of the mechanical system will convert the Motor output rotational foece into desired rpm needed by the vehicle.It will also help to achieve the trade off between Speed & Torque of the vehicle.
Electrical Power System :
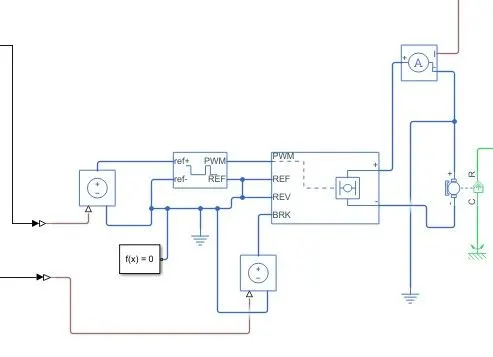
Electrical Suystem is a powering system which will give rotational mechanical output to the vehicle.It includes the power converter which will produce the voltage from which we could able to control the vehicle as we want.Also the power converter will convert back the mechanical power into electrical power feeding back to the system during the brakig operation.
DC Motor:
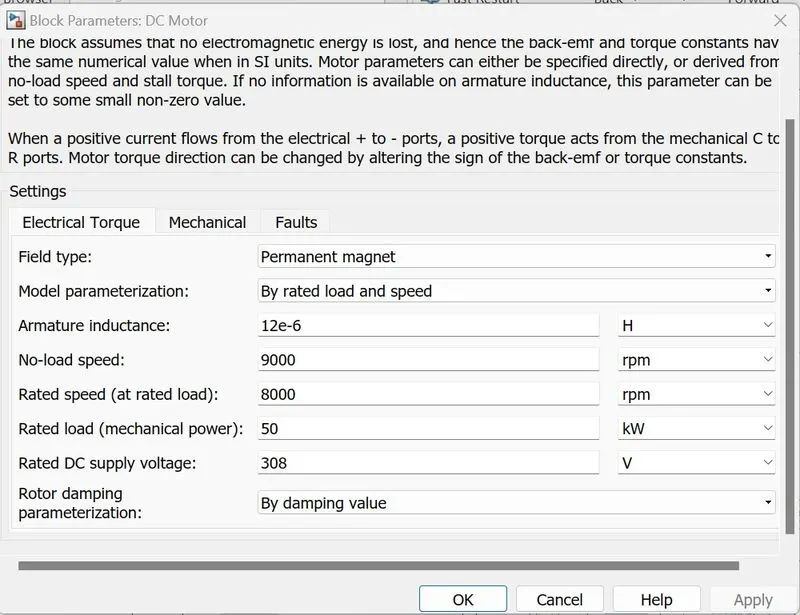
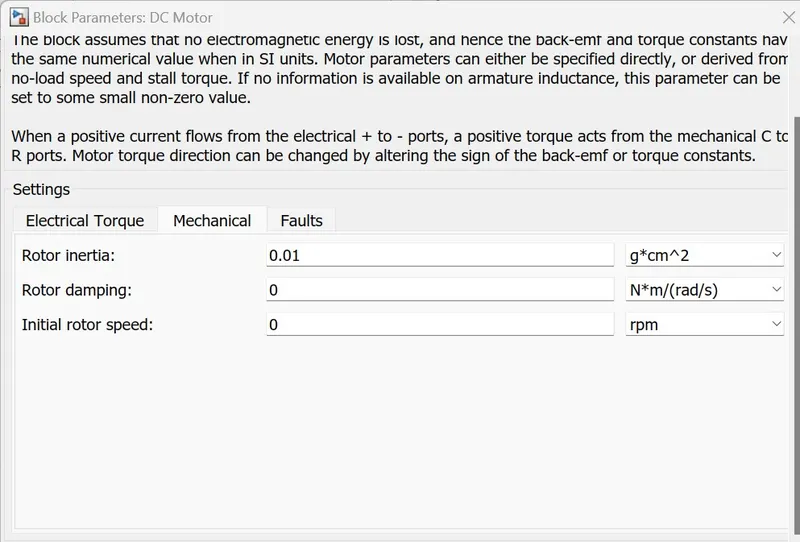
It is a DC motor with permanent magnet for the Field Induction.The Motor characteristics as as per shown below. The output of the motor will be given to the input to the mechanical gear and it will generate the rpm accordingly for the wheels.
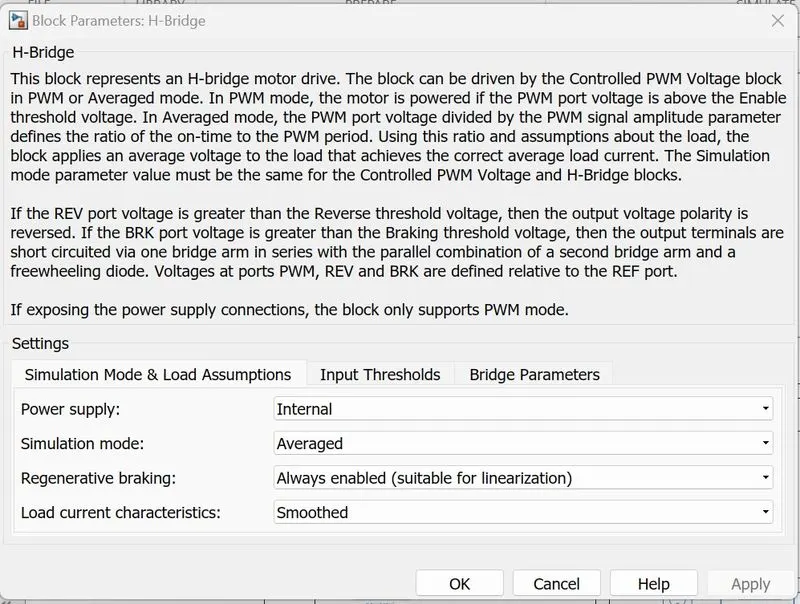
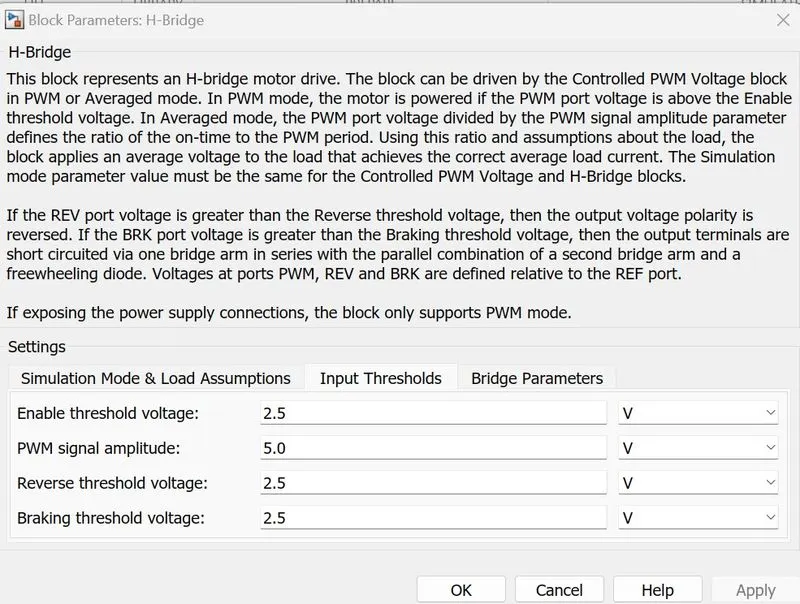
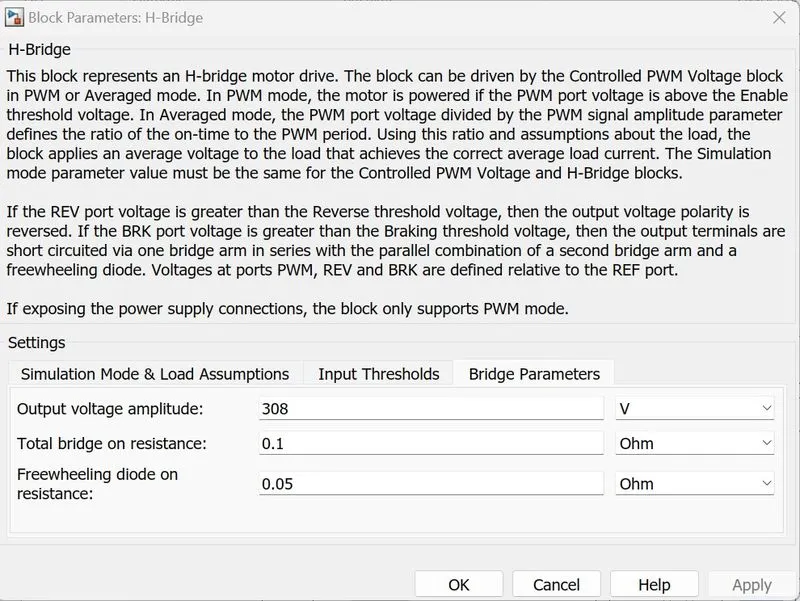
H Bridge Converter:
It is a power converter which is responsible to produce the desired output viltage for respective speed reference given by the driver.It also converts the mechanical power into electrical power during braking.
The parameters for the bridge inveter is shown as per below.
PWM controlled Voltage :
This is the block which will generate the switching sequence for the switches located in the H bridge converter.The output of this block is regulated DC Voltae.It has also provision of braking voltage generation signal input.
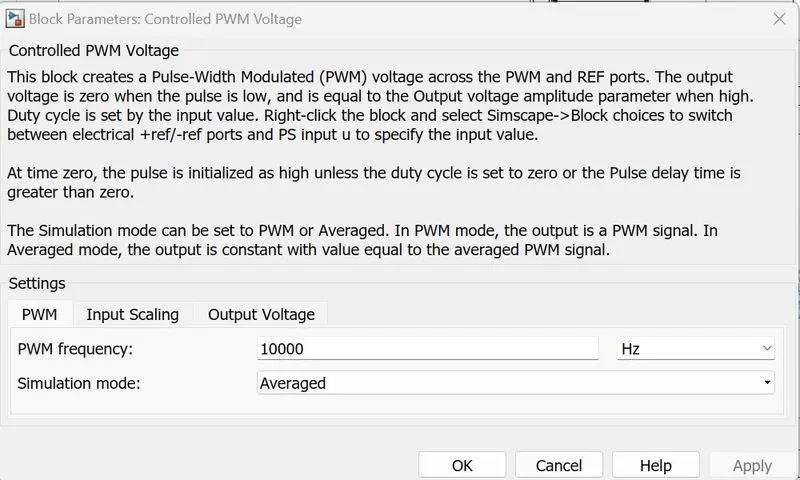
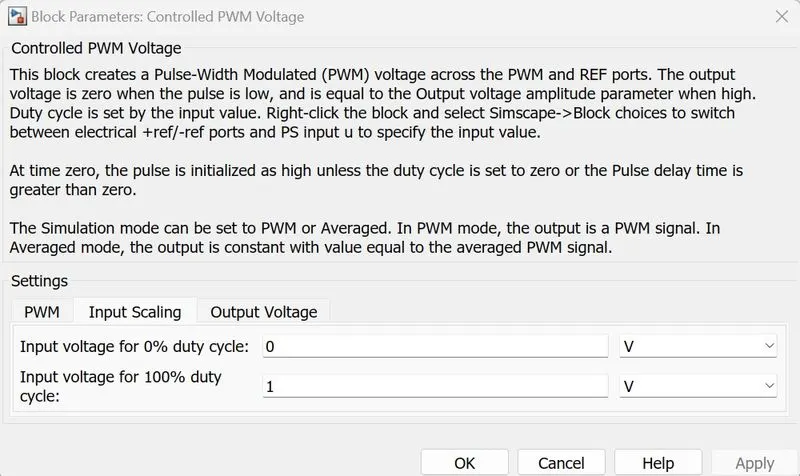
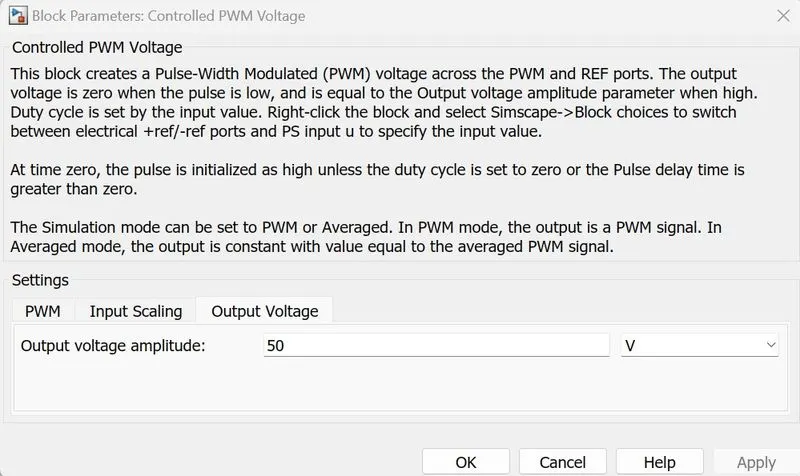
This controlled voltage source is used for the input of PWM voltage generator. The controlled signal given by the PID output will given ti this block & it will generate the commands for the controlled voltage source.
This block has been used for the acceleration command & braking too.
Solver block will help us to run the simulation smoothly & without generating any error.
Electrical referance is used to detact the referance voltage for each block used in electrical system.
Current Sensor:
It will detact the DC motor output current & accordinlgy give signal to battery system to discharge.
Battery System:
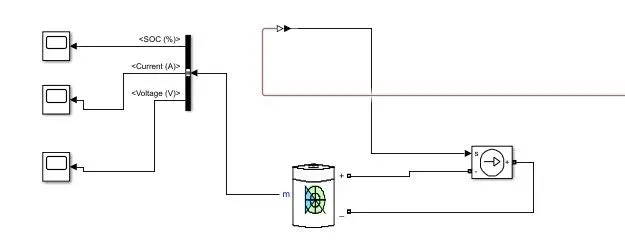
it is the main powering source of the electric vehicle. The vehiclw will get the electric power from the rechargable battery mounted on the vehicle body.it will contain the following blocks.
Battery :
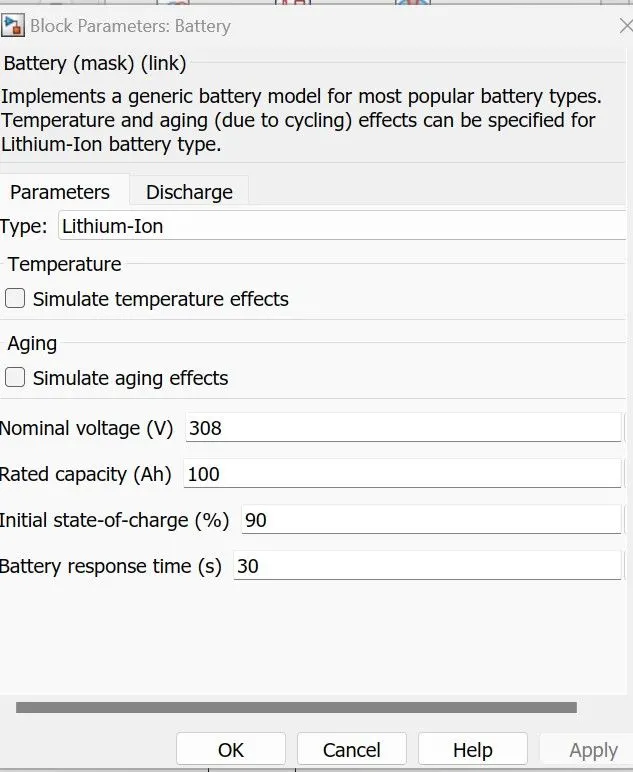
Its parameters are choosen which are feasible for our EV system.
This will give input to discharge the battery as the controller needs power.
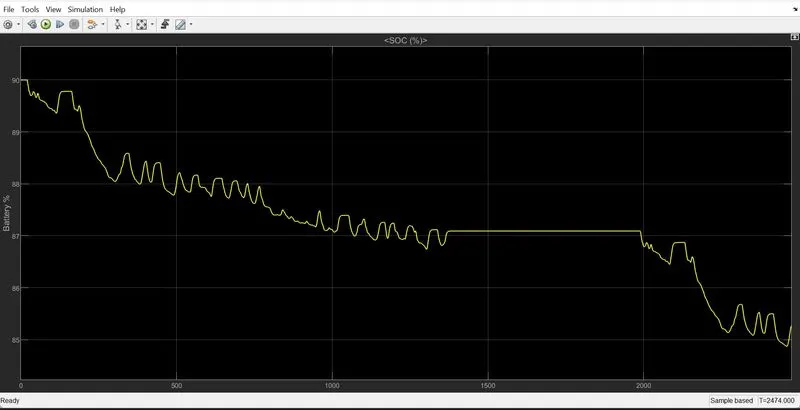
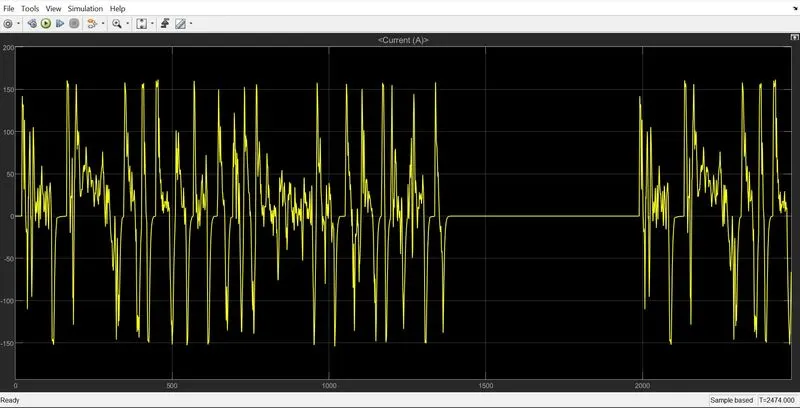
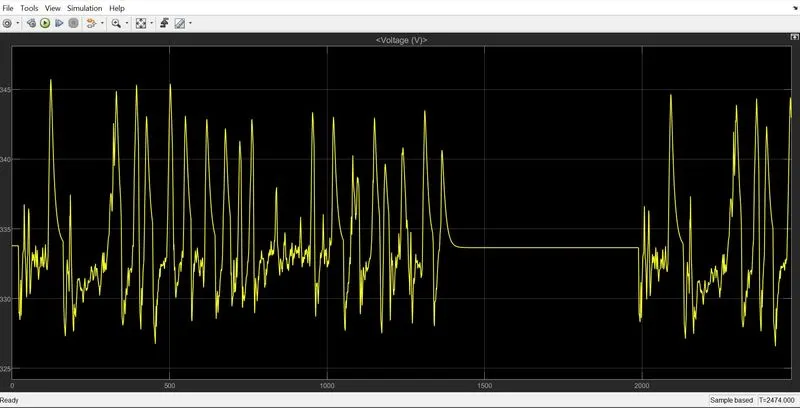
The battery system also has SOC,Voltage & current output port. These are real time output data of the system.It could be also used in calculating the power consumption of the system. As our vehicle is propelling forward the SOC will be decrasing gradually.
PID Control System :
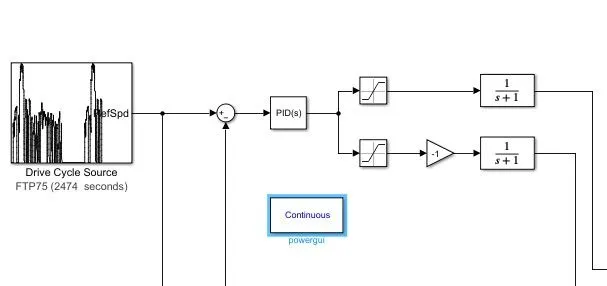
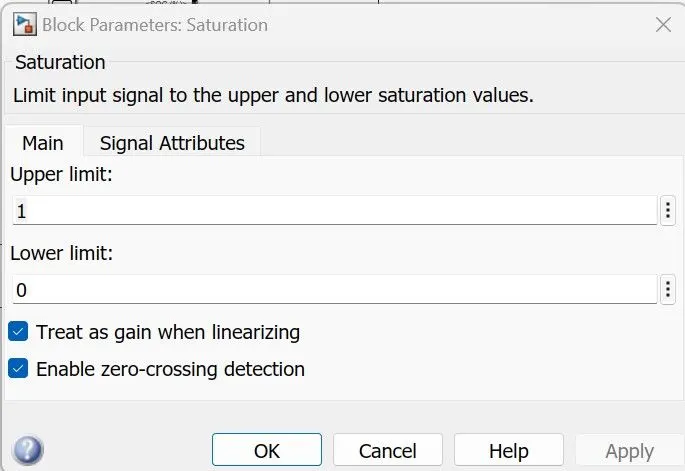
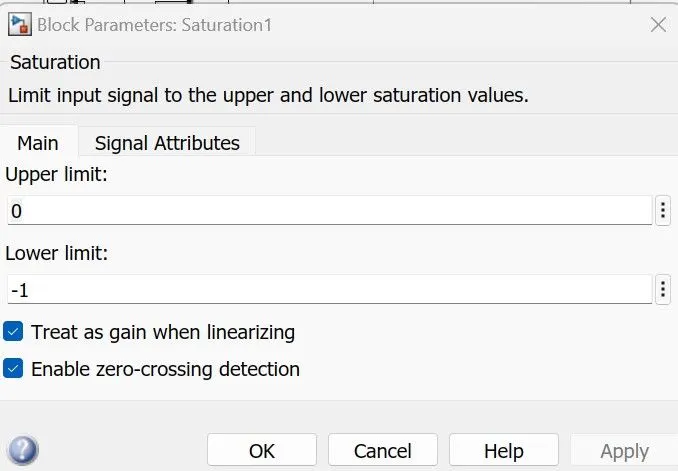
The control system is the heart of the Electric vehicle because all the command will be processed here & based on the error signal the controller input will be prooduced by this system.it includes PID controller , Drive cycle, Saturation block,PowerGui block.Here the output of the vehicle body will be given back to the PID controller to generate the error signal.The drive cycle will give input as a meter/second & the error signal will be generated according to their difference.The saturation block will bound the acceleration & braking inputs in limit for the control signal input.
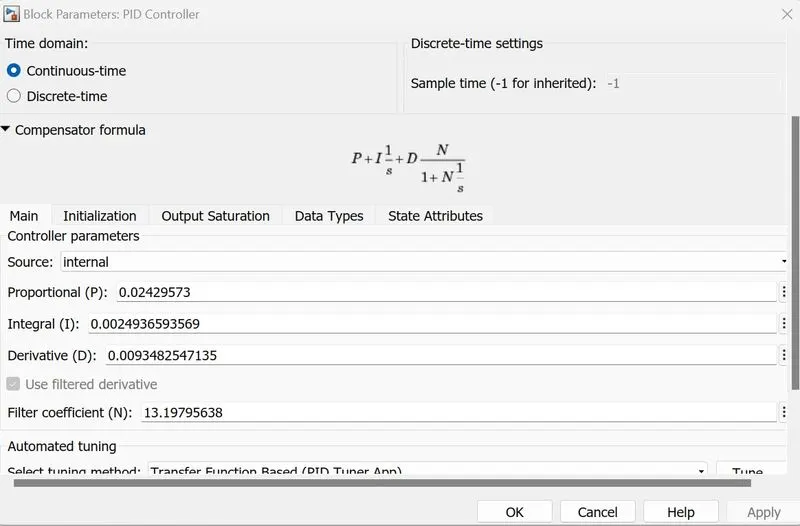
The transfer function represents the plant as a mathematical model.The PID controller's Kp ,Kd & Ki constants will make the output more accurate.
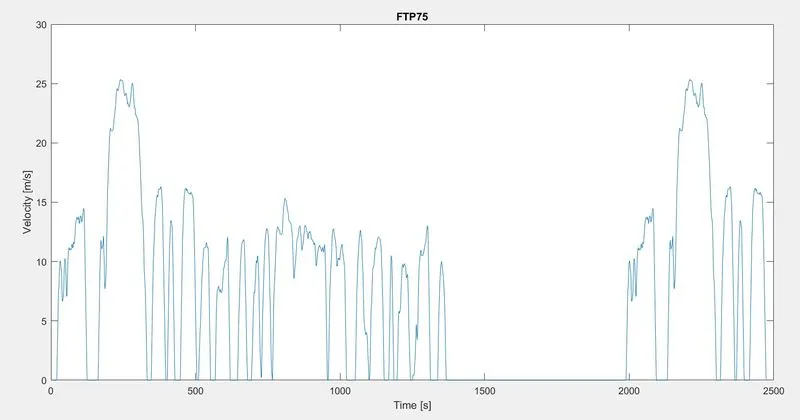
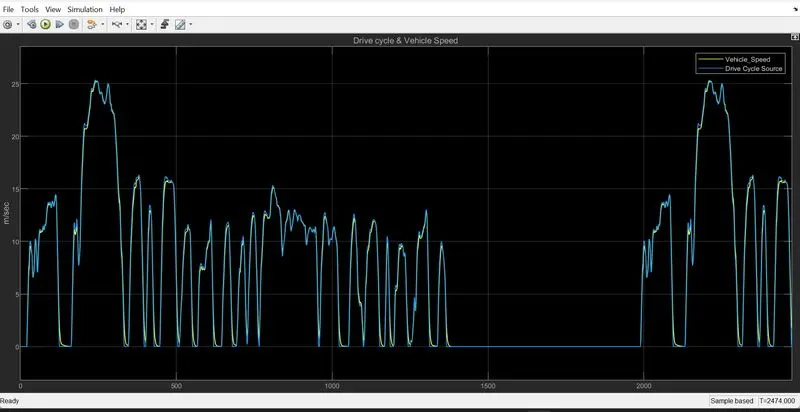
FTP75 Drive cycle for ( 2474 seconds ):
It is predifined vehicle acceleration & deceleration data to testify different vehicles.
Saturation Block:
Acceleration Saturation block
Deceleration Saturation block :
PID Block :
Result for FTP75 Drive cycle:
Battery SOC:
Battery Current:
Battery Voltage :
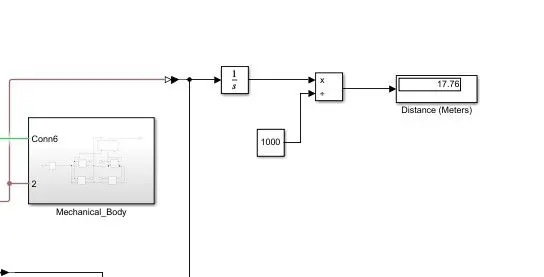
The output of the vehicle body is in meter/second so, if we integrate it once than we will get the total distance travelled by the vehicle & that would be in meters. By dividing it by 1000 we will get it in kilometers.
Conclusion:
With the help of MATLAB & Simulink block we can able to simulate the Battery Electric Car. We can also do more or less modification in the design parameters & can get the output data.One has to identify the precise control system transfer function & the Kp , Kd & Ki gains too.This model has also helped us to understand the Battery Electric vehicle working at system level & component level.