Project-1: Modelling an electric Car with Li-ion battery
PROJECT 1:
MODELLING AN ELECTRIC CAR WITH LI-ION BATTERY AND PID CONTROLLER:
SIMULINK MODEL:
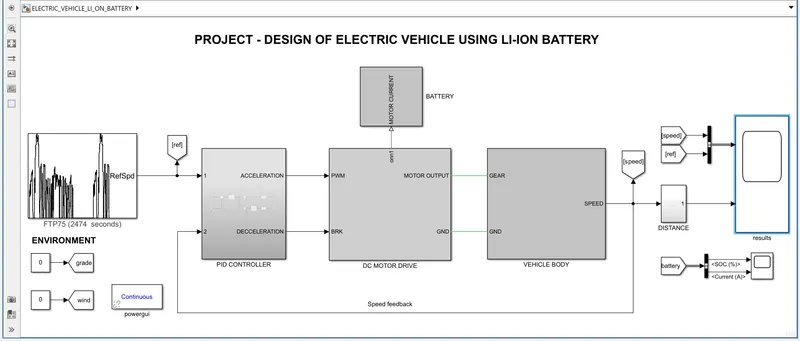
- The model of electric vehicle
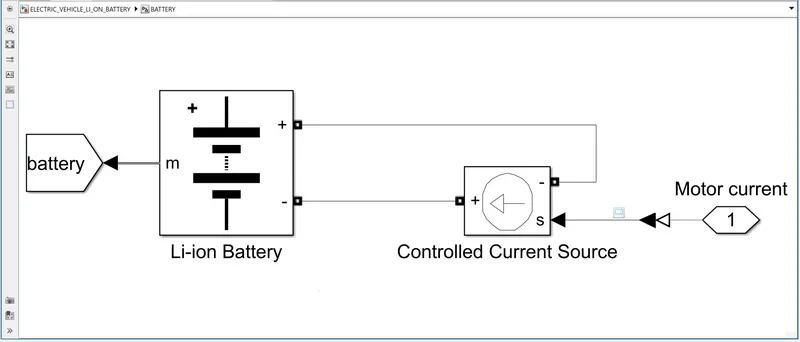
- The Li-ion battery block
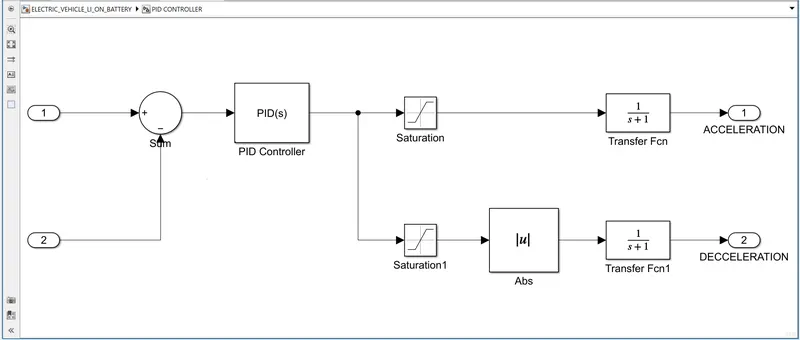
- PID controller block
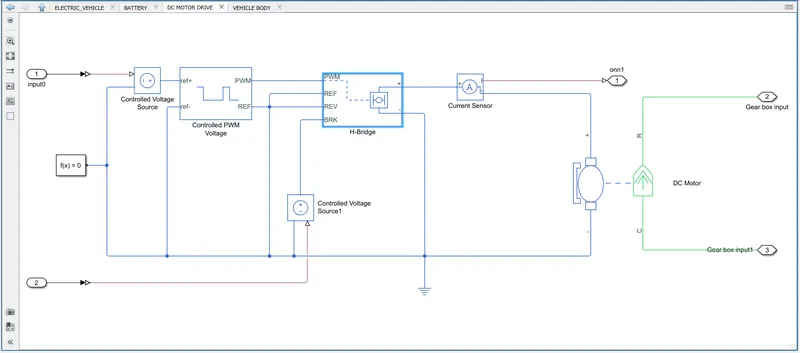
- The DC motor drive block
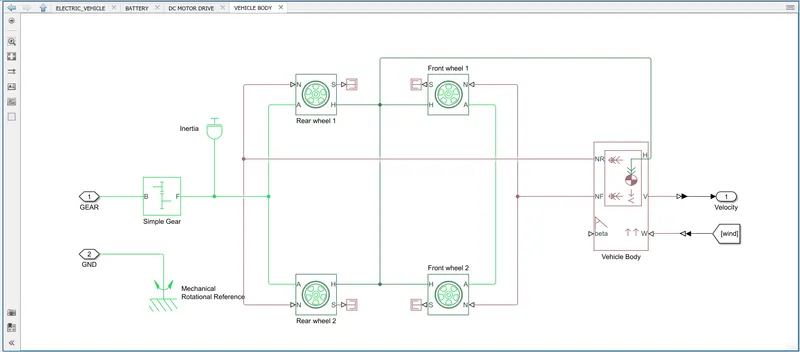
- The vehicle body block
REPORT:
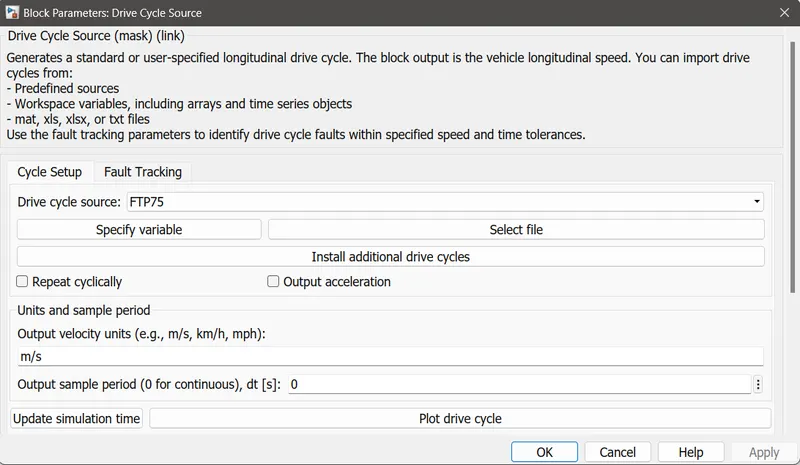
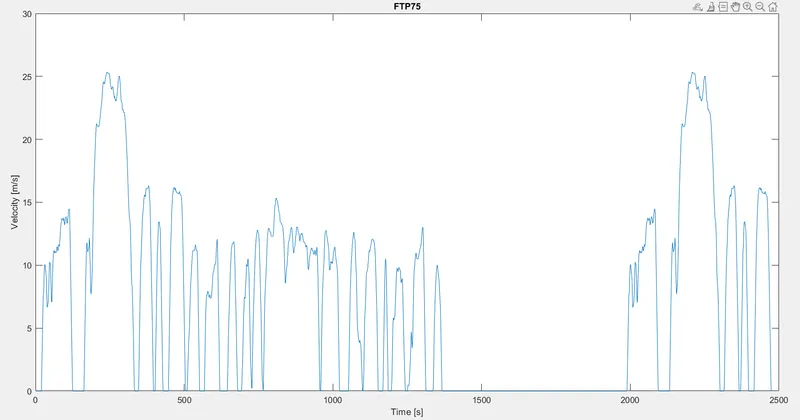
- The FTP75 drive cycle choosen from the Drive cycle source block
- The reference speed is connected is sum where it subtracted by speed of the vehicle togenerate error signal
- This error signal is connected to PID controller block
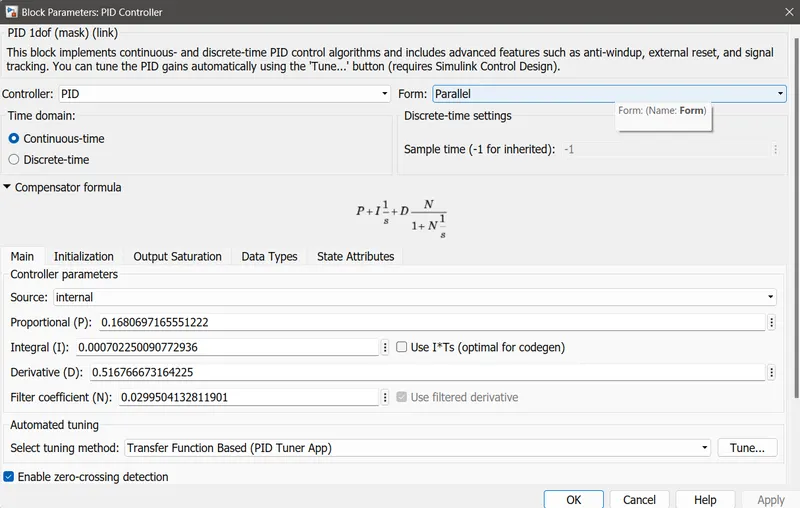
- The PID gain values obtained by PID tuner tool by linearisation method as follows
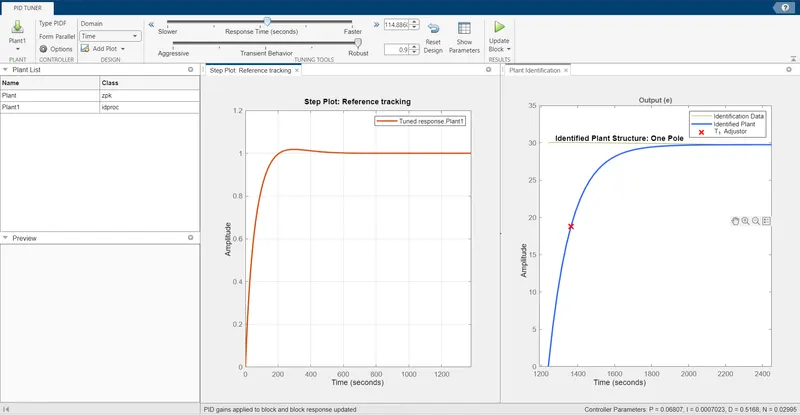
- The gain values obtained by adjusting the step response of plant
- For acceleration command,The PID controller output given to saturation block
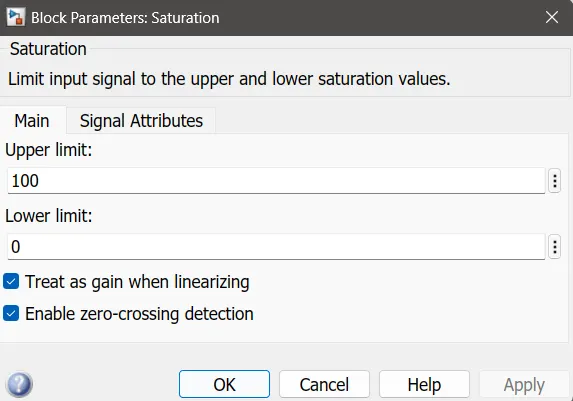
- An then connected to tranfer function block used to suppress the algebraic loop errors
- The final output given to PWM input through controlled voltage source
- For decceleration command.PID output given to saturation block
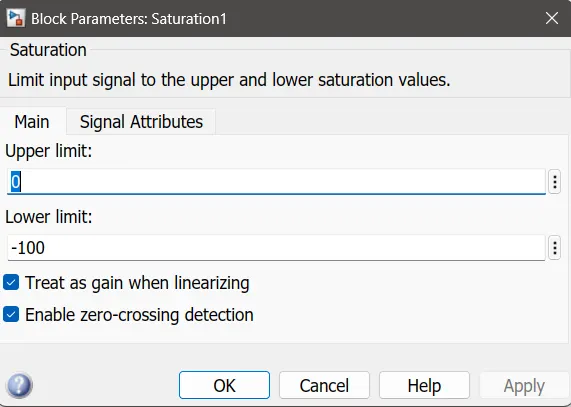
- An absolute block used to make the signal postitve and given to transfer function block
- The decceleration command given to the BRK port of H-bridge converter
- The motor drive block contains PWM controller,H-bridge converter and DCmotor
- The PWM controller parameters choosen as folllows
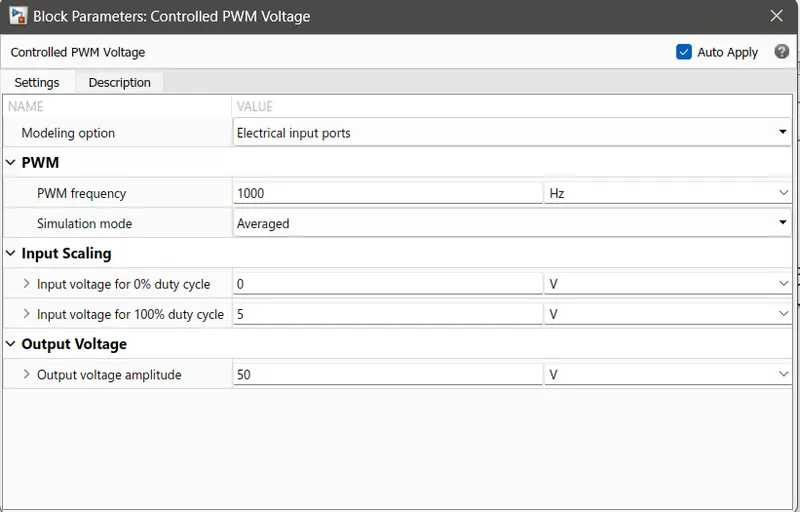
- The acceleration command from the driver block is connected to the ref+ port of PWM controller through a controlled voltage source
- The ref- port connected to the electrical reference
- The output voltage of PWM controller set to 50v in order to achieve the required output
- Thi output signal given to the input of H-bridge converter
- The H-bridge converter from simscape library used and parameters choosen a follows
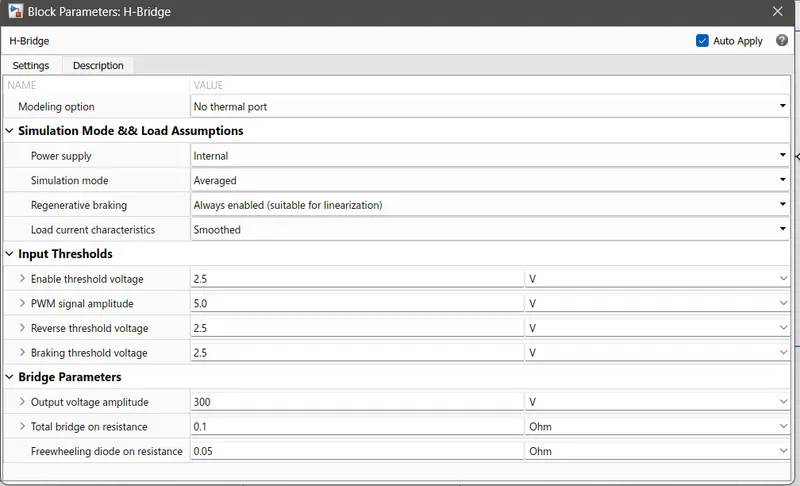
- The output voltage set to 300v according to the motor voltage
- The PWM input port receives the output voltage of PWM controller
- The REF port connected to the REF port of PWM controller and grounded
- The REV port connected to the electrical reference
- The BRK port get the input decceleration command from the driver block through a controlled voltage source which act as regeneratve braking
- The output of the H-bridge converter is connected to the DC motor through a current sensor
- The output from the current sensor is given to the battery block
- The DC motor model from simscape library used and parameters choosen as follows
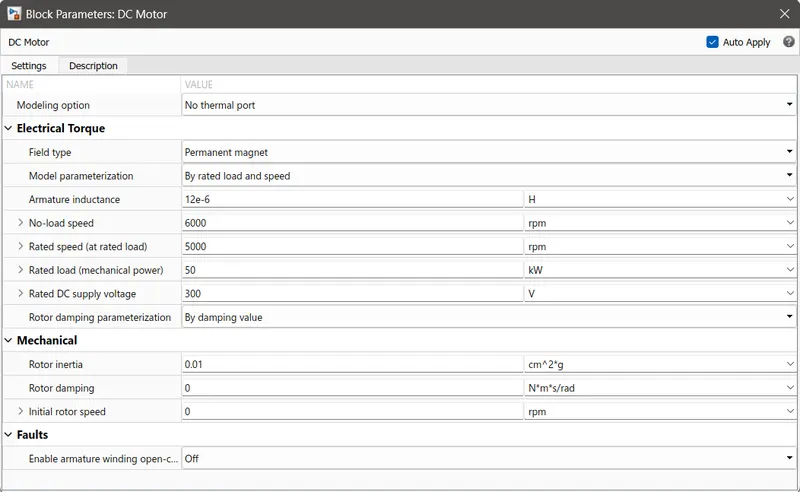
- Permanent magnet field DC motor type selected
- The rated load set to 50kw and rated voltage set to 300v
- The mechanical output of the DC motor connected through Rear wheel axle through a gear model
- And also it grounded using mechanical rotational reference block
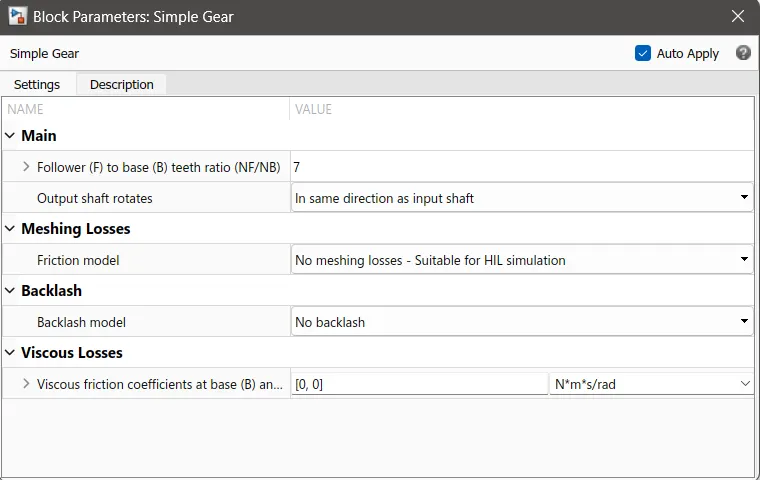
- The simple gear block parameterss choosen as follows
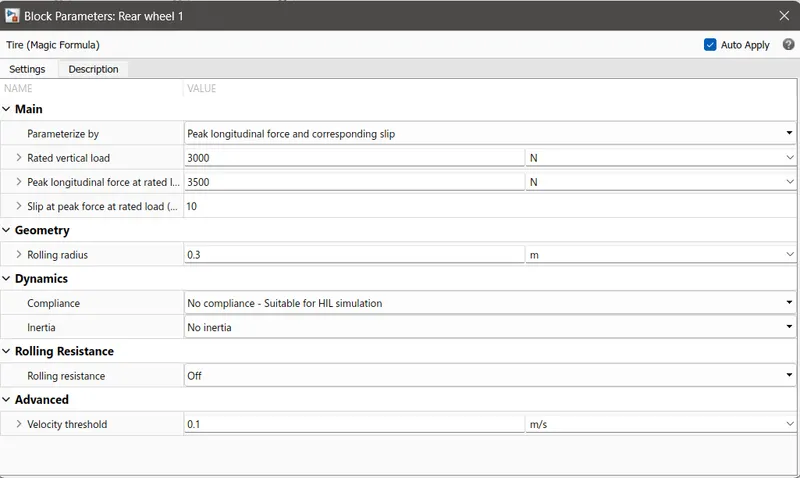
- The wheel blocks parameters choosen as follows
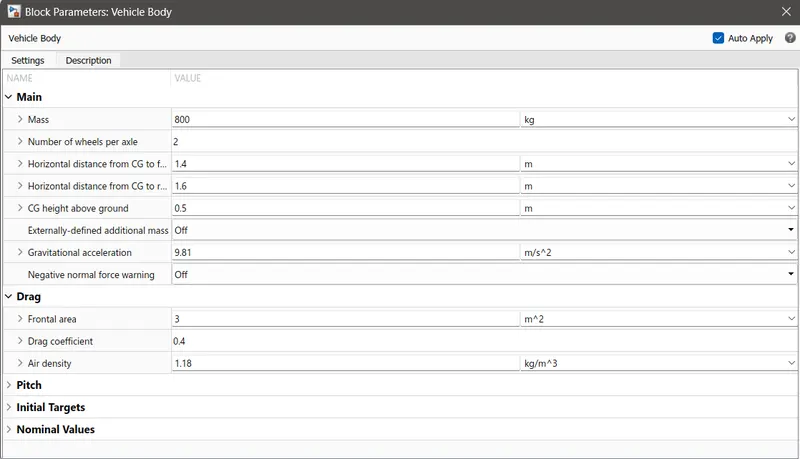
- The vehicle body block parameters choosen as follows
- The vehicle body hub port connected to the hub port of all rear and front wheels
- Rear wheel axle port and N port which is force signal connected and same done for front wheels as well
- The force to rear wheel applied by the NR port of vehicle body
- The force to front wheel applied by NF port ofvehicle body
- The wind velocity port is connected through constant block through goto &from block
- The output is velocity converted from physical signal to simulink signal using PS-Simulink converter
- The output velocity feeded back to the driver block
- The battery used in this model is LI-ION battery ,the battery parameters choosen according to the motor
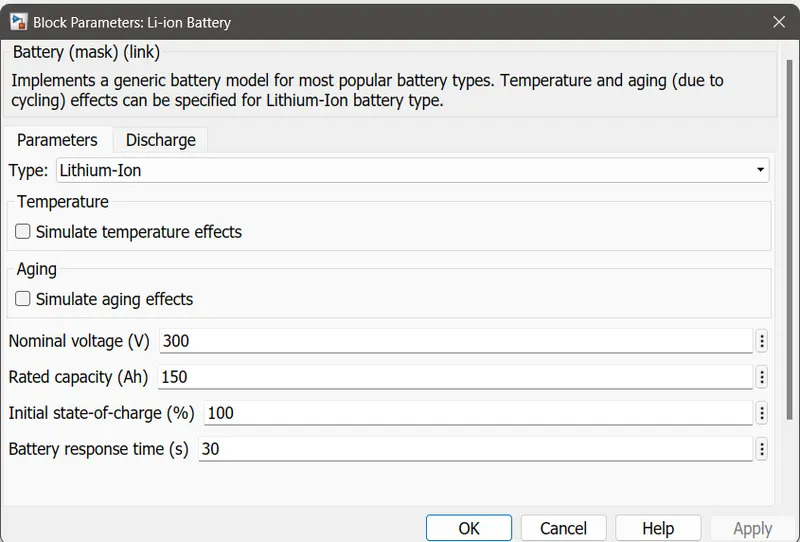
- The motor current is connected to the battery through controlled current source
- The state of charge and battery current is plotted in a scope
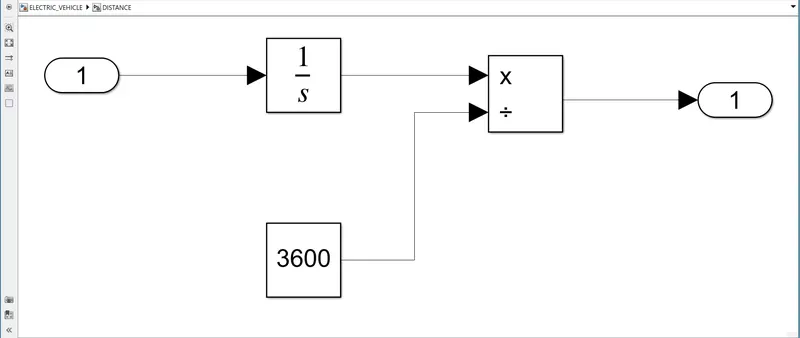
- The distance travelled by the electric vehicle calculated as
- All the ouputs SOC of battery ,reference speed ,actual speed and distance connected to the scope block
- The model simulated for 2474 seconds same time as of the FTP75 drive cycle
- The output results plotted
RESULT:
- The FTP75 driving cycle used as reference iss hown below
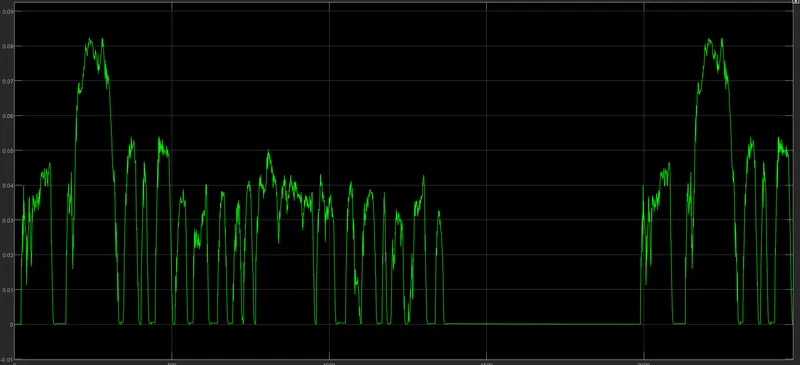
- The acceleration command from the PID controller is shown below
- The decceleration command from the PID controller is shown below
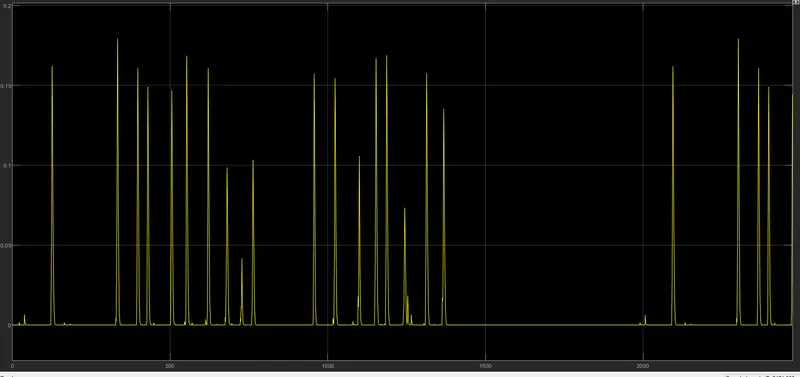
- The speed of the vehicle with repect to the reference speed is shown below
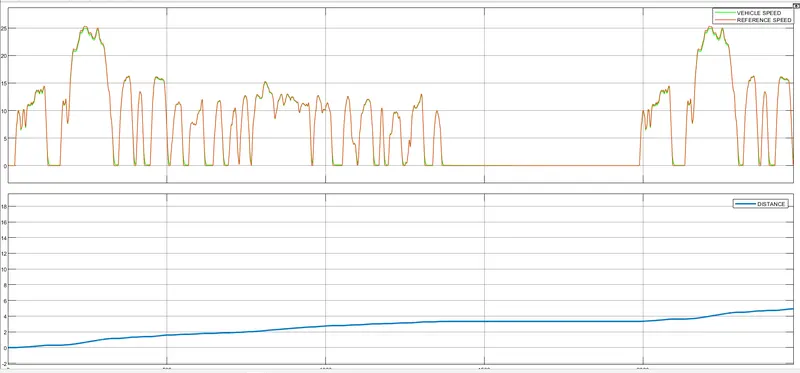
- Graph 1:It represents the actual speed of the vehicle and the reference speed
- It observed that the actual speed of the vehicle is following the reference speed
- But due to inertia of the vehicle ,the decceleration takes more time compared to reference
- A better result can be obatined by fine tuning the controller
- Graph 2:It represents the distance travelled by the vehicle for the given drive cycle
- It observed that vehicle travelled almost 5km for the given drive cycle
- The battery current and state of charge is shown below
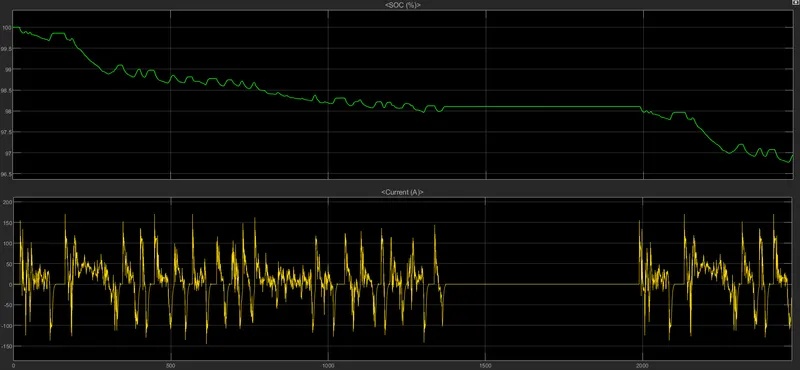
- Graph 1: It represents the State of charge of the battery of electric vehicle for the given drive cycle
- Its oberved that almost 97% of charge remains in the battery after completing the drive cycle
- Graph 2: The current polarity changes as per the acceleration and decceleration commands
CONCLUSION:
- Designed model of an electric car which uses the lithium-ion battery
- The PID controller designed for the model and generated accelearation and decceleration command
- The model simulated for a defined drive cycle and analysed the vehicle performance