Project-1: Modelling an electric Car with Li-ion battery
Title = Modelling an electric car with Li-ion battery.
Objectives=
Create a MATLAB model of electric car which uses lithium ion battery and suitable motor. Choose suitable blocks from Simscape or Powertrain block set. Implement the vehicle speed control using PI controller and generate brake and accelerator commands. Avoid using readymade driver block for speed control.
Prepare a report about your model including following:
Objectives, System level configurations, Model parameters, Results, Conclusion.
(Note- The simulink model file should be compulsorily attached)
Answer=
- the electric car is a vehicle which is partially or fully propelled by an electric motor, using an energy stored in rechargeable batteries.
- the electric cars were invented practically in the 1880s but it was popular late in the 19th century and early 20th century.
-at that time, the innovation and advanced growth of the internal combustion engines (ICE) and mass production of cheaper gasoline vehicles has led to decline for the use of electric vehicles.
-as per user choice, there are various types of electric cars changed, developed and innovated time to time.
- as of now, the world is very much familiar with the terms BEV,HEV,PHEV and FCEV.
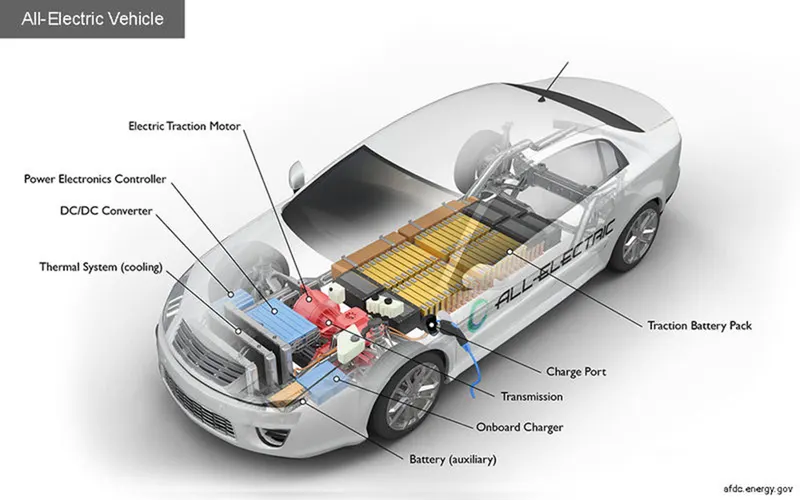
In general, electric car working=
- if we press the pedal of the car then controller takes action and regulates the electrical energy from the batteries and inverters as per requirement.
- when the controller setting has been done then the inverter sends a certain amount of electrical energy to the motor (as per the depth of pressure on the pedal).
-then the electric motor converts electrical energy into mechanical energy and motor rotor rotates the transmission therefore the wheels of the vehicle rotated which results the car moves.
types of electric vehicle =
1) Battery electric vehicle (BEV)
2) Hybrid electric vehicle (HEV)
3) Plug-in hybrid electric vehicle (PHEV)
4) Fuel cell electric vehicle (FCEV)
1) Battery electric vehicle (BEV) =
- it is entirely runs on a battery and electric drive train.
- in these types of electric car/vehicle we do not use ICE, so energy is stored in a large battery pack through charged by plugging into electricity grid.
- the energy stored in the battery used to power the one or more electric motors to run the electric car.
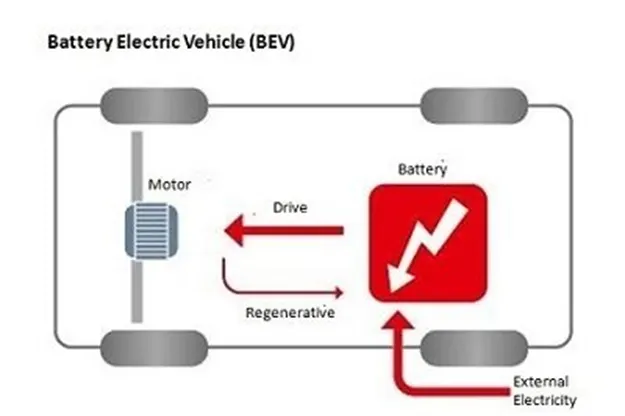
- the main components used in BEV are electric motor, inverter, battery, control module and drive train.
-inverter converts power from DC battery to AC for the electric motor.
- when the accelerator pedal sends a signal to the controller then adjusts the vehicle speed by changing the frequency of the AC power from the inverter to the motor.
-then rotated rotor turns the wheels through transmission.
-when the brakes are pressed as per requirement then the electric car is decelerating, the motor become goes to alternator mode and produces power which is sent back to the battery.
-the example of this type of vehicle is Volkswagen e-Golf, Tesla model 3, BMW i3, chevy spark, Nissan LEAF, Ford Focus Electric, Hyundai Ioniq, Karma Revera etc.
2) Hybrid electric vehicle (HEV)
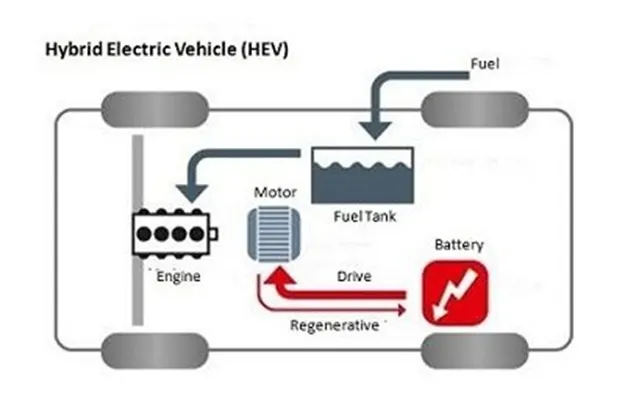
- it is also called as standard hybrid or parallel hybrid electric vehicle.
-in this vehicle, we use both an ICE and an electric motor.
- in these types of electric cars, for internal combustion engine getting energy from fuel and for the electric motor getting electricity from batteries.
-both gasoline engine and electric motor works simultaneously to rotate the transmission of the vehicle, which drives the wheels.
-the main difference between HEV as compared with BEV and PHEV is the batteries in HEV can be charged by the ICE or motion of the wheel or a combination of both.
-in this car, there is no charging port therefore the battery cannot be recharged from outside of the system.
-the components of HEV are engine, electric motor, battery pack with controller and inverter, fuel tank, control module.
-it has a fuel tank that supplies gas to the engine like a regular car and also it has a set of batteries that run the electric motor. Both the engine and electric motor can turn the transmission at the same time to move the vehicle.
-the examples of this vehicle are Honda civic hybrid, toyots prius hybrid, honda civic hybrid, toyota camry hybrid.
3) Plug-in hybrid electric vehicle (PHEV)=
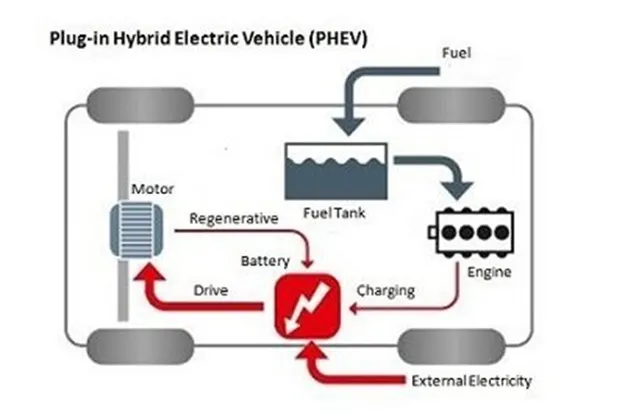
-it is a type of hybrid that both an ICE and a motor, also called as series hybrid electric vehicle. For this type of electric cars there is a choice of fuels.
-this type of electric vehicle is powered by a conventional fuel (gasoline) or an alternative fuel (bio-diesel) and also a rechargeable battery pack.
-the battery of the vehicle can be charged up with electricity by plugging into an electrical outlet or electric vehicle charging stations (EVCS).
-this vehicle typically run at least two modes-
- all electric mode-in this, battery provide the energy to the motor to move the vehicle and also for other accessories.
- Hybrid mode- in this, both electricity and gasoline are employed.
- the component of PHEV is electric motor, engine, inverter, battery, fuel tank, control module, battery charger (if onboard model).
- it is typically start up in all electric mode and operate on electricity until there is a battery pack depleted.
- there is some model-shift to hybrid mode occurs when they reach highway cruising speed, generally above 60-70 miles per hour.
-whenever the battery is empty, the engine takes over that is engine start and the vehicle can be operates as a conventional, non-plug-in hybrid.
- in addition to plugging into an outside electric power source, PHEV batteries can be charged by an combustion engine or regenerative braking.
- at the time of braking, the electric motor acts as a generator and this generating energy is used to charge the battery.
-in this, the electric motor is a supplement the engines power as a results smaller engine can be used, increasing the cars fuel efficiency without compromising performance.
-the examples of PHEV are Porsche cayenna SE-hybrid, Chevy vott, Chrysler pacifica, Ford c-max energi, Ford fusion energi, Mercedes C350e, Mercedes S550e etc.
4) Fuel cell electric vehicle (FCEV)=
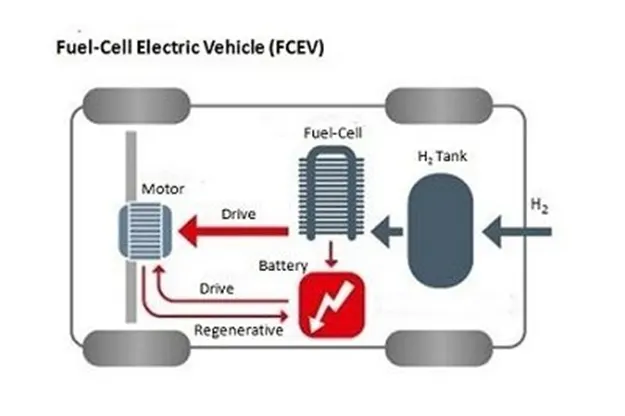
- it is also known as fuel cell vehicles (FCVs) or zero emission vehicle, are the types of electric cars that employ fuel cell technology to generate the electricity required to run the vehicle.
-in this type of vehicles, the chemical energy of the fuel is converted directly to electric energy.
- the components of FCEV are electric motor, fuel cell stack, hydrogen storage tank, battery with converter and controller.
- the fuel cell electric car working principle is different compared to that of a plug-in electric car.
-the Fuel cell generates the electricity required to run this vehicle on the vehicle itself.
-the examples of FCEV are Toyota Mirai, Hyundai Tuscon FCev, River simple rasa, Honda clarity fuel cell, Huyndai Nexa.
ELECTRIC CAR COMPONENTS-
-Electric car or vehicle component and function depend on the car type.
-Here we discuss various common main electric vehicle/car components or parts or elements and their function such as traction batteries, inverters (DC-DC converters), traction motors, on-board chargers and controllers.
-the different electric cars (vehicles) components and functions are as follows-
a) Traction battery pack-
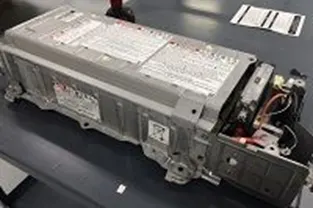
-the main function of the battery in the electric vehicle is to store electrical energy in the form of direct-current electricity (DC).
-the controller sends a signal to the battery, then the battery will flow the DC electrical energy to the inverter to then be used to drive the motor.
- the type of battery used is a rechargeable battery and which is arranged in such a way that of traction battery pack.
- currently there are different types of electric car batteries used but the most widely used battery is lithium-ion batteries.
b) power inverters-
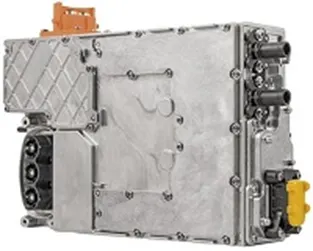
-the direct current (DC) of the battery is converted in to an alternating current (AC) with the help of inverter and this alternating current is used in the electric motor.
-during regenerative braking, the inverter on an electric car has a function to change the AC current to DC current and then it is used to recharge the battery.
- this type of inverter used in some electric car models is the bi-directional inverter category.
c) Controller=
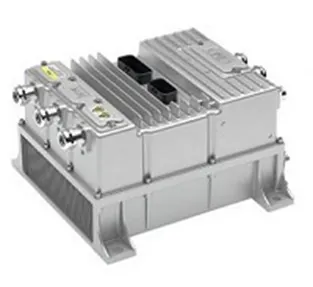
-the function of the controller is as a regulator of electrical energy from batteries and inverters that will be distributed to electric motors.
-the input of the controller is the car pedal which is set by the driver.
-the setting of the pedal determines the frequency variation or voltage variation that will enter the motor and at the same time determines the cars speed.
-in general, this unit is used to control the flow of electrical energy delivered by the traction battery, also controlling the speed of the electric traction motor and the torque produced. The working of electric car is mainly depended on this component.
d) Electric traction motor-
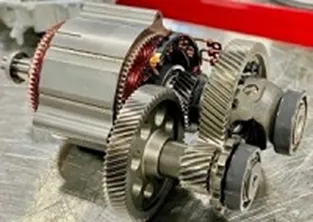
-The controller provides electrical power from the traction battery; the electric traction motors turn the transmission and then moves the wheels.
- In some hybrid electric cars, we can use a type of generator -motor that performs both the operation like propulsion and regeneration.
-In general, the type of electric motor used is the BLDC (brushless DC) motor.
E) Charger-
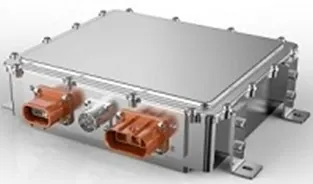
-this is a battery charging device.
-the chargers get electricity from outside sources, such as the utility grid or solar power plants.
-chargers converts AC electricity into DC electricity and stored in the battery.
-there are 2 types of electric car chargers:
- On-board charger: this type of charger is located and installed in the car.
- Off- board charger: this charger is not installed or not located in the car.
F) transmission-
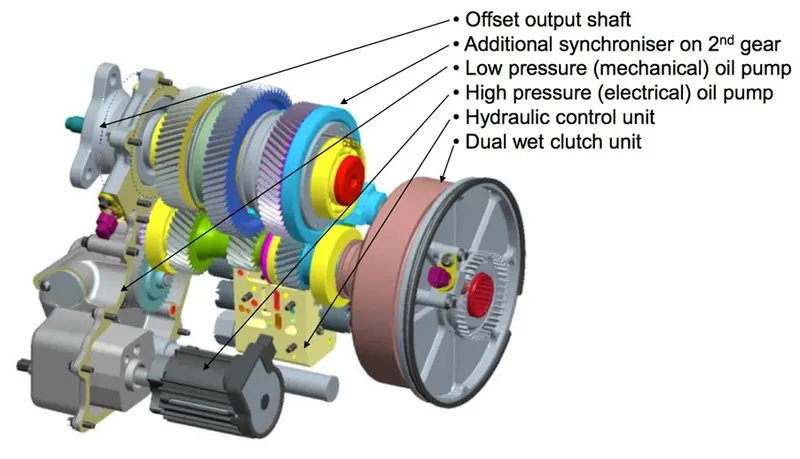
it transfers mechanical power from the electric traction motor to drive the wheels.
g) DC-DC converter=
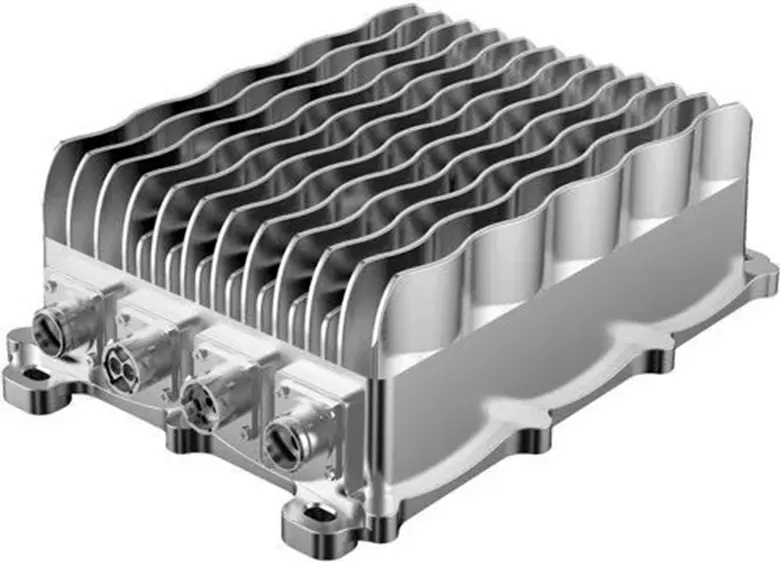
- the main function of this device is to converts higher-voltage DC power from the traction battery pack to the lower-voltage DC power required to run the vehicle or to run other accessories and to recharge the auxiliary battery.
h) Thermal system=
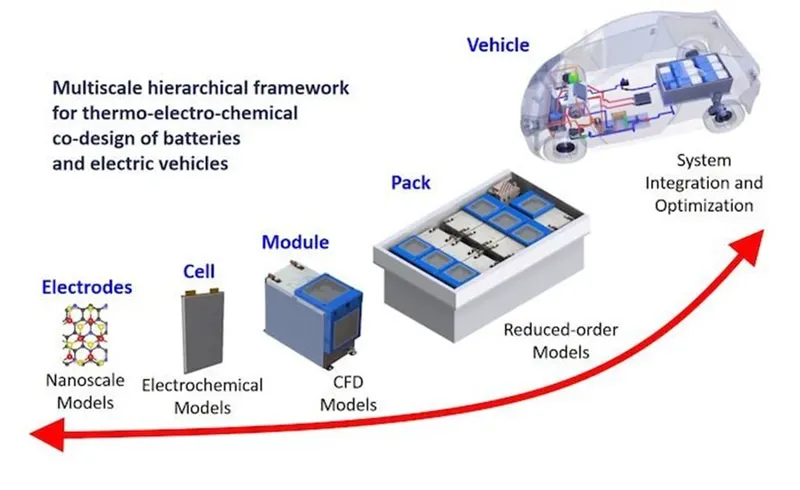
- this system maintains a proper operating temperature range of the engine, electric motor, power electronic devices and all other components.
i) Charge port-
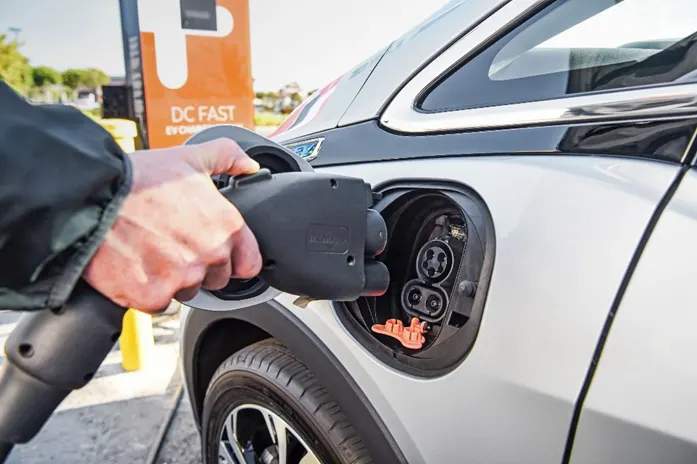
the charge port allows the vehicle to connect an external power supply in order to charge the traction battery pack.
MODELLING OF EV
objectives-
- electric vehicle with fever components.
- to make a most simple and low run time vehicle model using individual component models.
- to checkout performance parameters speed, SOC, current etc with various drive cycles.
- to play with motor power, vehicle body (rolling resistance, air drag, weight)inputs.
- to know MATLAB models and their configuration to match with actual vehicle.
Block diagram=
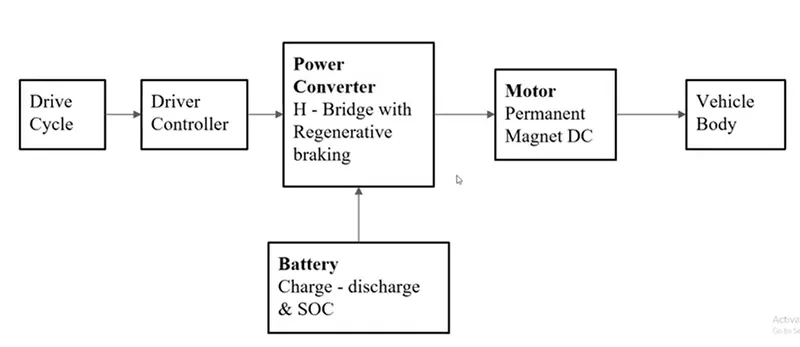
-this block diagram is a schematic general arrangement of the principal parts of an electric car and it is reference to our MATLAB model of an electric car.
-In this shows there are 6 main parts of this arrangement. the electric vehicle has vehicle body, DC motor, power converter, driver controller, drive cycle and battery.
-in this, the drive cycle is used to input the data into the driver controller. The driver controller controls the acceleration and deceleration of the vehicle.
-Power converter which is a H-bridge with regenerative braking, here we use H-bridge to drive the DC motor.
-as per our model we are using a battery and dc motor. battery cannot be directly connected to motor because if we connect then rated voltage is given to motor and motor speed is also rated, so we cannot increase or decrease motor speed variation as per our requirement of vehicle.
-the motor block and battery block are connected to the power converter block so power converter plays a vital role in the controlling and converting the electrical energy.
-the battery block indicates the charge and discharging condition and % SOC (state of charge) variations with respect to the drive cycle.
-motor blocks indicate we are using which type of motor and its positioning, here we are using the permanent magnet DC motor.
-finally, the vehicle body block indicates the mechanical structure of an electric car like wheels and their connections. Then the motor rotational energy rotates the wheel through transmission gear system.
Simulink model
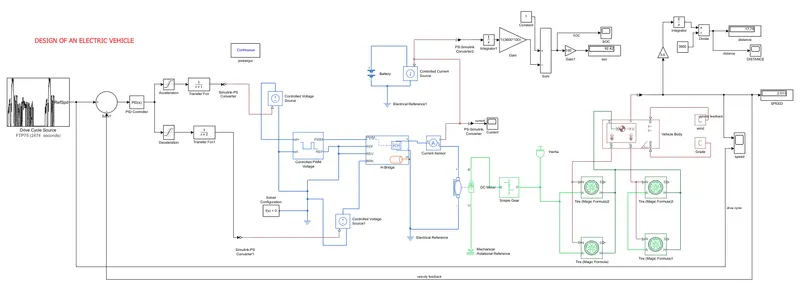
now we will discuss each block used in this Simulink model-
1)Drive Control
In order to control the vehicle, we need another system that decides how the vehicle will operate. This means that data needs to be input in to this model as commands for how we desire the vehicle to operate. In addition, we need blocks that control how the vehicle will operate as a response to its instantaneous state. This system is explained belowdrive cycle source-
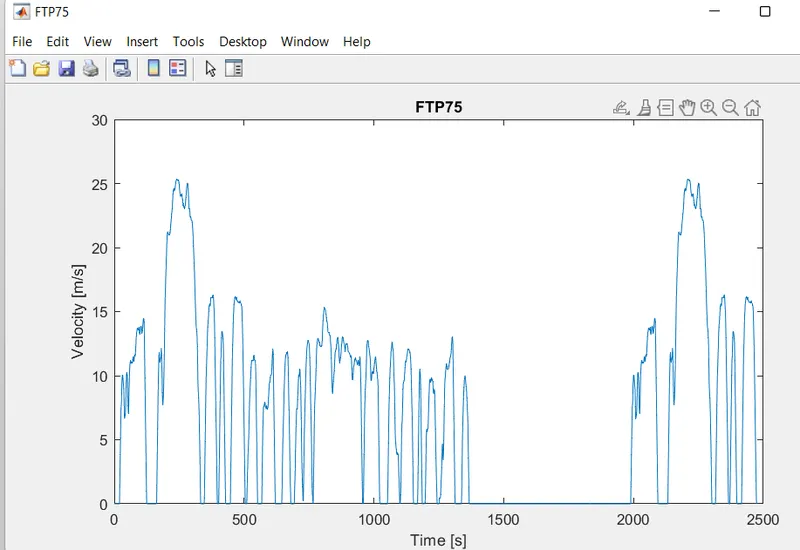
A drive cycle is a data set that contains velocity and time data for the purpose of modelling the motion of a vehicle. The drive cycle will be a plot of the velocity against the time and it is made to resemble typical driving conditions that a consumer may experience themselves in. For instance, they can model highway driving situations, driving in urban areas or driving with full power etc. Drive cycles are used by automotive companies for various testing procedures such as mileage, pollution tests, and acceleration and top speed tests. There are various different drive cycles that are industry standard e.g., Urban Dynamometer Driving Schedule (UDDS), FTP 75.
In my EV model, a drive cycle is used as the reference velocity data for the longitudinal driver block to send acceleration or deceleration commands according to the drive cycle. There are 3 ways of implementing a drive cycle. One method is to create or own drive cycle with a spreadsheet of velocity data in one column and time data in another column. Another method is to use a signal builder block and create signals that represent the velocities at which the vehicle should travel and the durations for which those velocities are to be maintained. The last method is to use the industry standard drive cycles which are in - built in to the SIMULINK library.
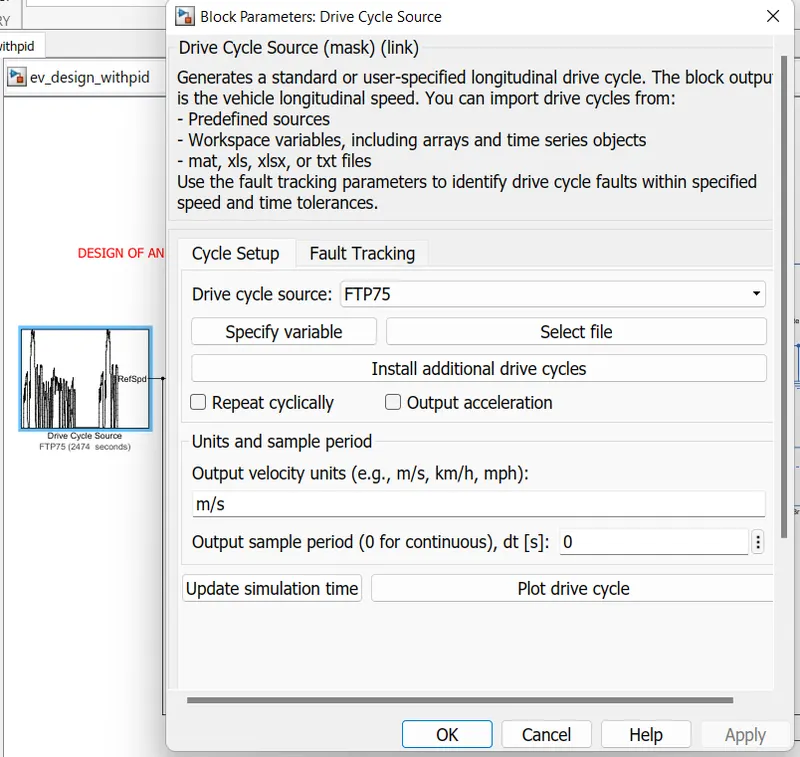
-this block helps in inputting the drive cycle data, whether it is built in or custom made by the user. for the operation of the cycle,Here we used FTP75 drive cycle. the test duration would be 2474 seconds.
the block parameters for this drive cycle source
drive cycle plot is as-
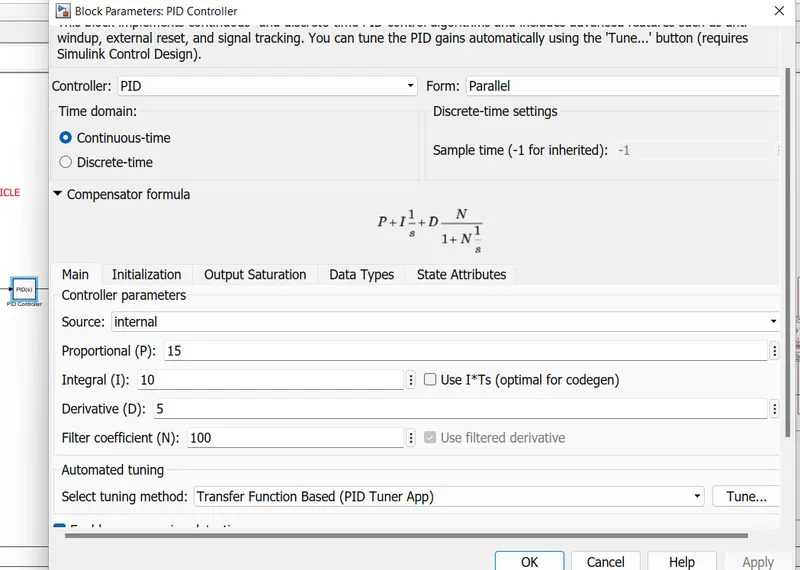
2) PID BLOCK=
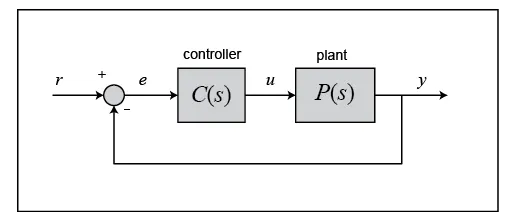
The output of a PID controller, which is equal to the control input to the plant, is calculated in the time domain from the feedback error as follows:
u(t) = Kp *e(t) + Ki*∫e(t) dt + Kd*de/dt.
First, let's take a look at how the PID controller works in a closed-loop system using the schematic shown above. The variable (e) represents the tracking error, the difference between the desired output (r) and the actual output (y). This error signal (e) is fed to the PID controller, and the controller computes both the derivative and the integral of this error signal with respect to time.
The control signal (u) to the plant is equal to the proportional gain (Kp) times the magnitude of the error plus the integral gain (Ki) times the integral of the error plus the derivative gain (Kd) times the derivative of the error.
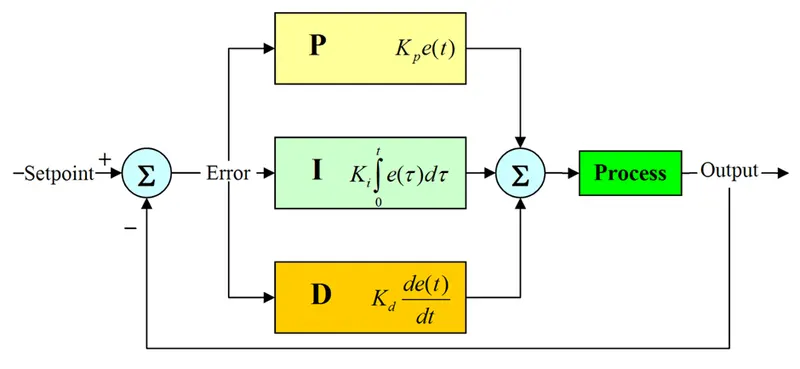
- This control signal (e) is fed to the plant and the new output (y) is obtained. The new output (y) is then fed back and compared to the reference to find the new error signal (e). The controller takes this new error signal and computes an update of the control input. This process continues while the controller is in effect.
General Observation for PID gain:
|
Gain |
Rise time |
Overshoot |
Settling time |
Steady-state error |
|
Kp |
Decrease |
Increase |
Small change |
Decrease |
|
Ki |
Decrease |
Increase |
Increase |
Eliminate |
|
Kd |
Small change |
Decrease |
Decrease |
Small change |
the block parameters for this PID block is
3) Saturation block
- The Saturation block produces an output signal that is the value of the input signal bounded to the upper and lower saturation values. The upper and lower limits are specified by the parameters Upper Limit and Lower Limit in the Command Block.
-This block helps to limit the output signal from pid controller and separate deceleration and acceleration values.
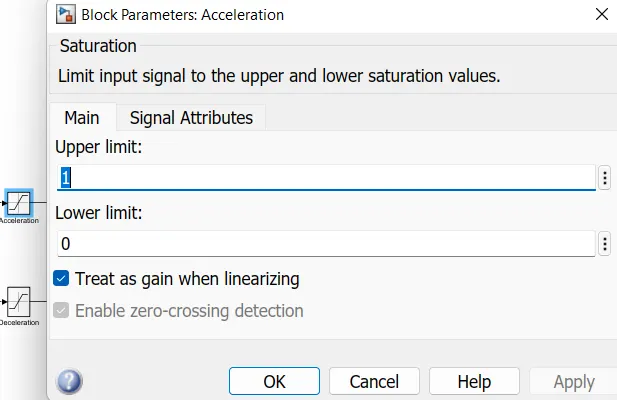
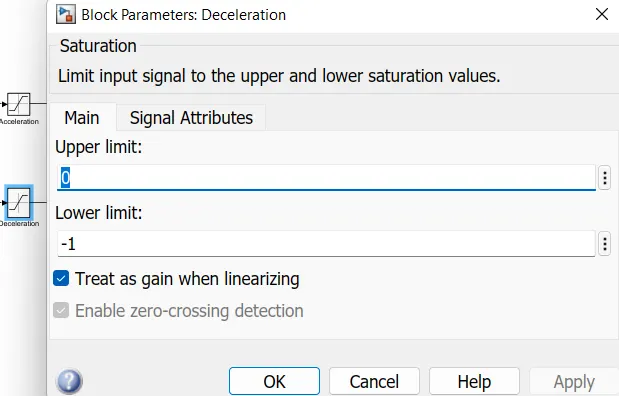
- The output from these blocks is sent to a transfer function then these are provided to motor controller block.
4) Transfer function
- A transfer function is defined as the ratio of the Laplace transform of the output of a system to the input of a system. The transfer function block is shown below:
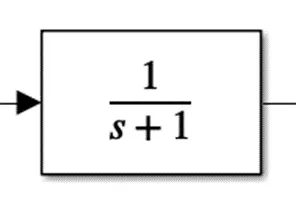
-Double-clicking the block opens the block parameters as shown below:
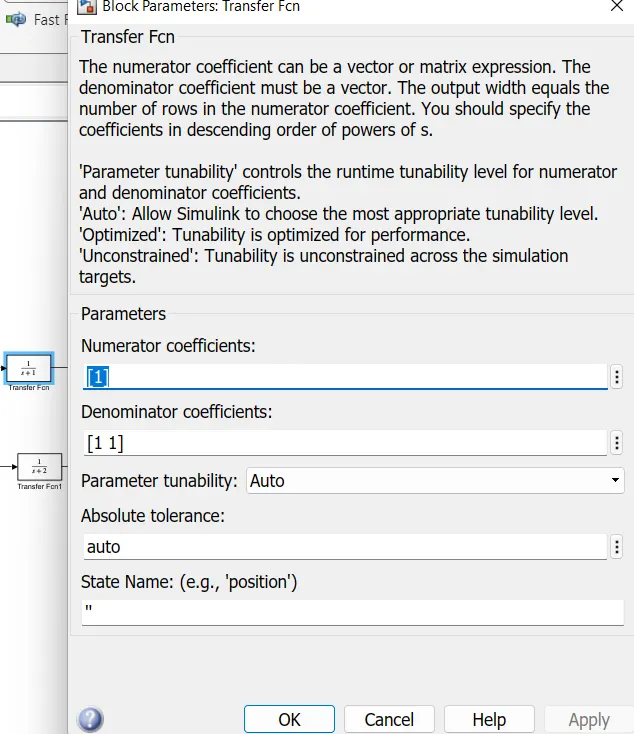
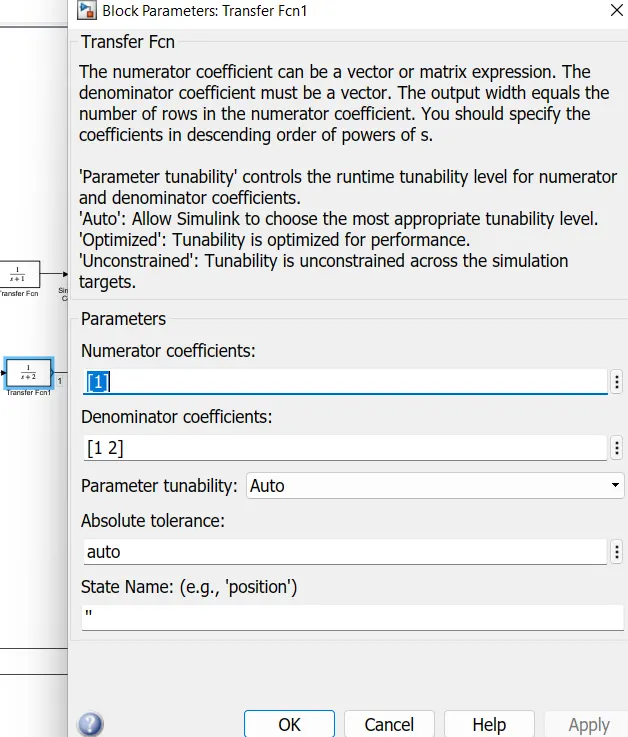
-From the block parameters, we can modify the transfer function by changing the numerator and denominator coefficients. I have used the default coefficients.
-For the deceleration command, I have used another transfer function block with a slightly different transfer function. This is shown in the image below:
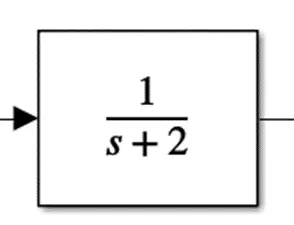
- The transfer function block was modified by changing the coefficient of the denominator as shown in the image below:
5) controlled PWM voltage block -
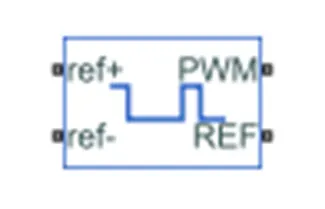
- this block is used to create the pulse width modulated (PWM) voltage.
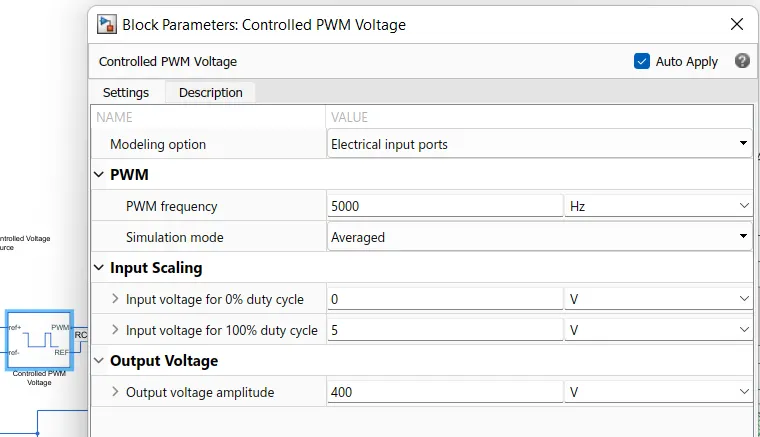
- Electrical input ports- this block calculates the duty cycle which is based on the reference voltage across its ref+ and ref- ports. This modelling variant is the default.
-the value of the output voltage amplitude parameter determines amplitude of the output voltage.
ref + = reference positive connected with the acceleration commands from the driver model
ref- = reference negative connected with the deceleration commands from the driver model
PWM = PWM connected directly to the H-block.
REF = REF connected directly to the H-block
- the parameters of this block are as
6) H- bridge =
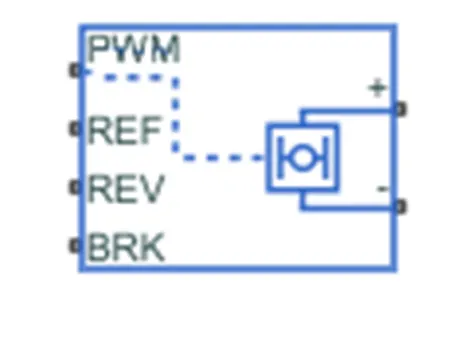
-this block is used to change the polarity of the voltage applied across the DC motor so as to run the motor in forward and reverse direction as per the input command.
-this block is driven by controlled PWM voltage block in PWM or averaged mode.
- in PWM mode, the motor is powered if the PWM port voltage is above the enable threshold voltage, in averaged mode, the PWM port voltage divided by the PWM signal amplitude parameters defines the ratio of the on-time to PWM period.
- using the ratio assumptions about the load, the block applies an average voltage to the load that achieves the correct average load current.
- the simulation mode parameter must be same for the controlled PWM voltage and H-bridge blocks.
-REF- controlling with reference
-REV -controlling with reverse
-BRK- controlling the brake and regenerative action
+ =controlled output to the positive terminal of the motor
- = controlled output to the negative terminal of the motor
-the block parameters of H-bridge are as
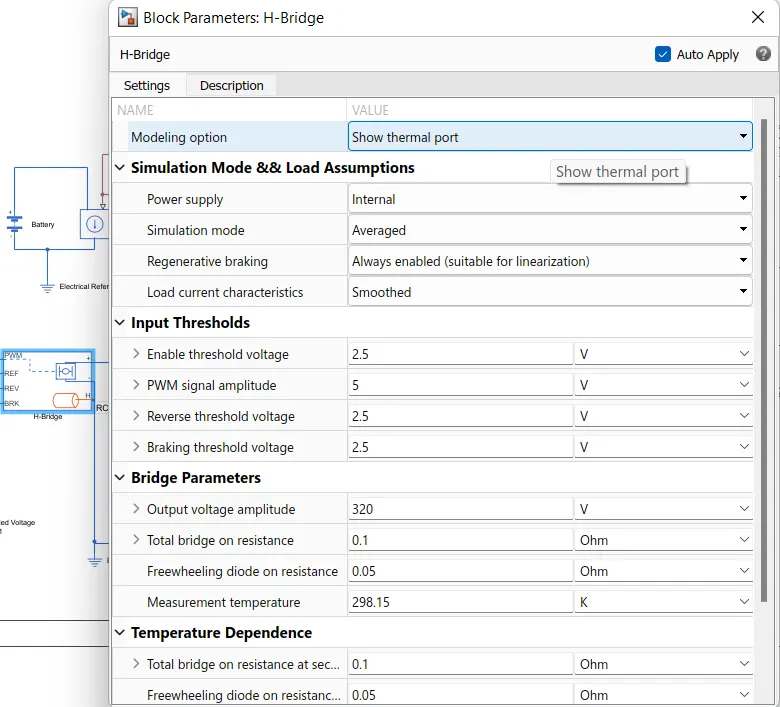
- we have selected the internal type power supply and enabled the regenerative braking for flow power back to battery while braking and deceleration to make EV efficient.
the following values are considered for H-bridge-
- output voltage amplitude-320 V
- enable threshold voltage-2.5 V
- PWM signal amplitude- 5 V
- reverse threshold voltage-2.5 V
- braking threshold voltage- 2.5 V
7) DC motor-
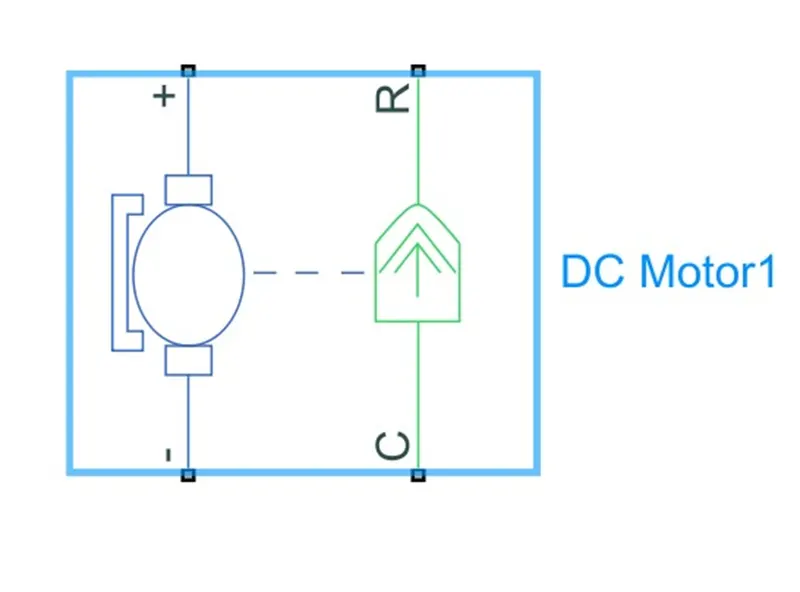
- For the EV model, the DC motor block is selected because DC motors are easy to model and have very few parameters to run for a particular application.
-The left side of the motor represents the electrical part of the motor, whereas the right side represents the mechanical part.
- using the power from the battery pack this motor drives the vehicle wheels.
- some vehicles use the motor generators to perform both the drive and regeneration functions.
-this is the DC motor (Brushed type) terminals are connected as -
+ = electrical signal to the motor positive terminals
- = electrical signal to the motor negative terminals
C = connected to casing of the motor connected with the mechanical rotational reference block.
R = rotor shaft of dc motor is connected to simple gear, which vary torque and speed.
- the parameters of dc motor are
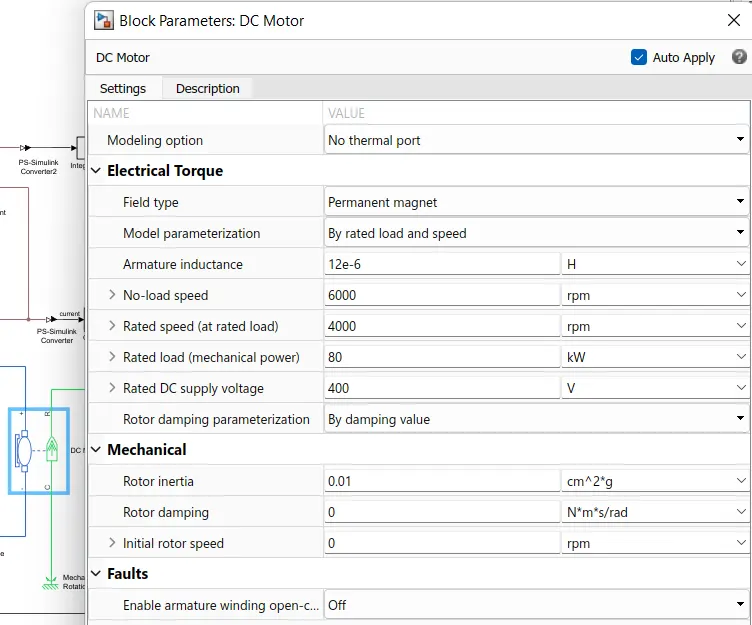
the parameters values are as follows-
- rotor inertia -0.01
- field type - permanent magnet
- no-load speed-6000 rpm
- rated speed (at rated load)-4000 rpm
- rated load- 80 Kw
- rated DC supply- 400 V
8) gear box-
-A gearbox is a mechanical device that is used to increase the output torque or change the speed (RPM) of the motor. The motor shaft is connected to one end of the gearbox and through the internal configuration of the gears of the gearbox, it provides an output torque and a specific speed determined by the gear ratio.
-The most basic definition of a gearbox is that it is a mechanical unit or component consisting of a gear train or set of gears embedded in a housing. In fact, the name itself defines it as a box containing gears. In the most basic sense, a gearbox works like a gear system. Change torque and speed between a drive, such as a motor, and a load.
-Gears in gearboxes can be one of several types, from bevel and helical gears to worm gears and planetary gears. The gear is mounted on a shaft supported by roller bearings and rotates around it. A gearbox is a mechanical method of transferring energy from one device to another, which is used to increase torque while decreasing speed.
-Gearboxes are used in many applications, including machine tools, industrial equipment, conveyor belts, and almost any power transmission application with rotary motion that requires a change in torque and speed.
- the gear box block represents an ideal ,nonplanetary ,fixed gear ratio gear box.
- the gear ratio is determined as the ratio of the input shaft angular velocity to that of the output shaft.
- the parameters of gear box block as-
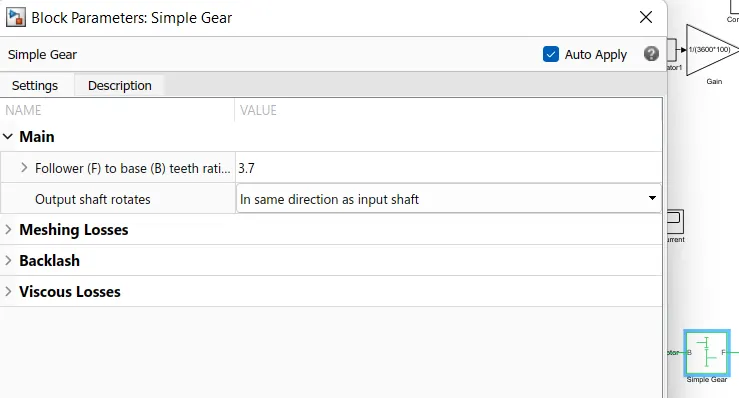
9) tire/wheels=
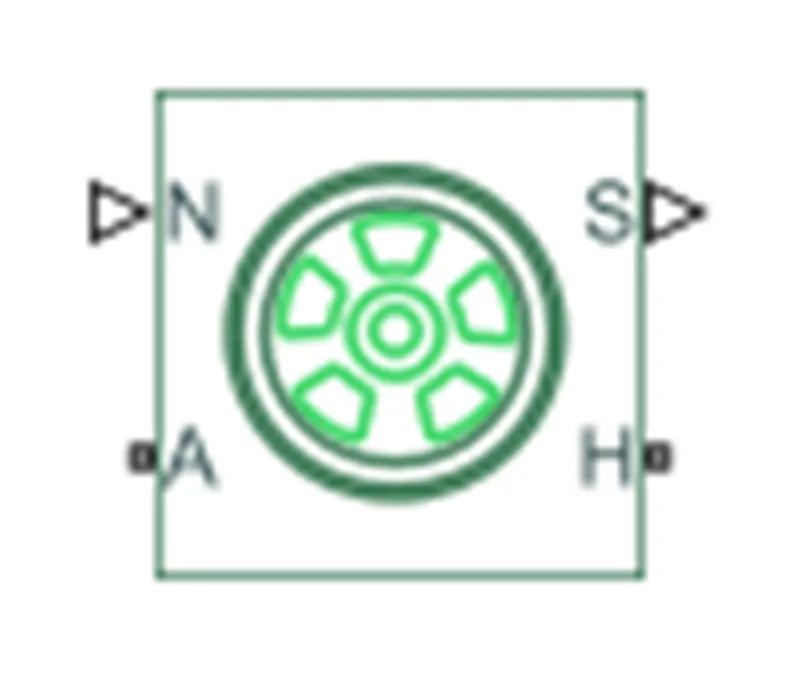
- this block represents the longitudinal behaviour of a highway tire characterized by the tire magic formula.
- connection A is the mechanical rotational conserving port for the wheel axle.
- connection H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle.
- connection N is the physical signal input port that applies the normal force acting on the tire.
- connection S is a physical signal output port that reports the tire slip.
- the parameters for tire block are
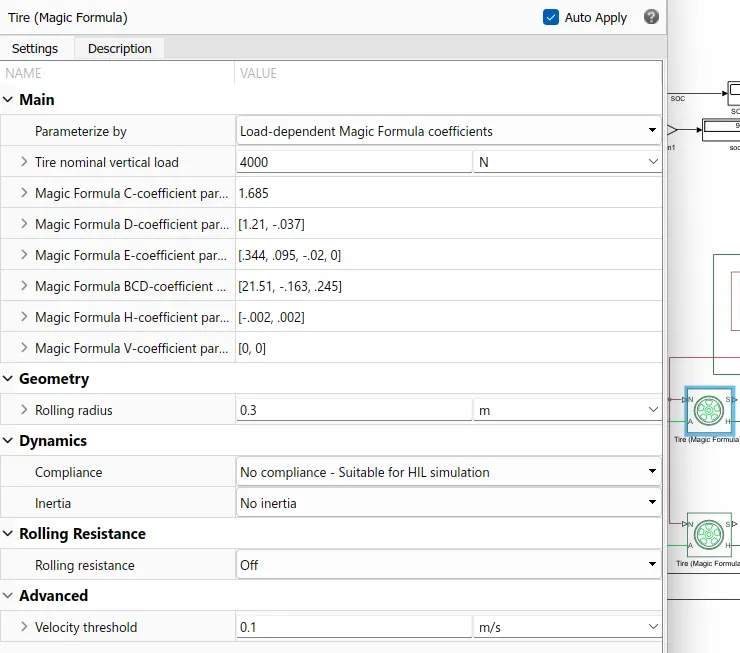
10) Vehicle body-
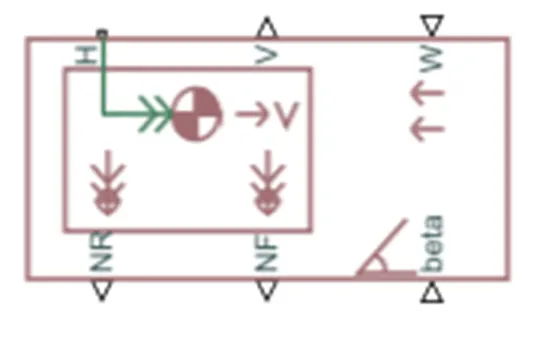
- the vehicle body block represents a two-axle vehicle body in longitudinal motion.
- the vehicle has the same or different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. Each vehicle wheels are of same size and structure.
-this block accounts for body mass, aerodynamic drag, road incline and weight distribution between axles due to acceleration and road profile.
- optionally include pitch and suspension dynamics, the vehicle does not move vertically relative to the ground.
-this block has an option to include an externally defined mass and an externally defined inertia.
-the mass, inertia and centre of gravity of the vehicle body can vary over the course of simulation in response to system changes.
- angle terminal (beta)= the angle is the slope in the road condition at which the car is running.
- wind= it is specified as per the condition where the vehicle has to be driven.
- Velocity = the speed of the EV car.
- H = it is a conserving port associated with the horizontal motion of the vehicle body. tire traction motion is connected to this port.
- NF= the front wheel connection
- NR= the rear wheel connection.
-the parameters of vehicle body block are
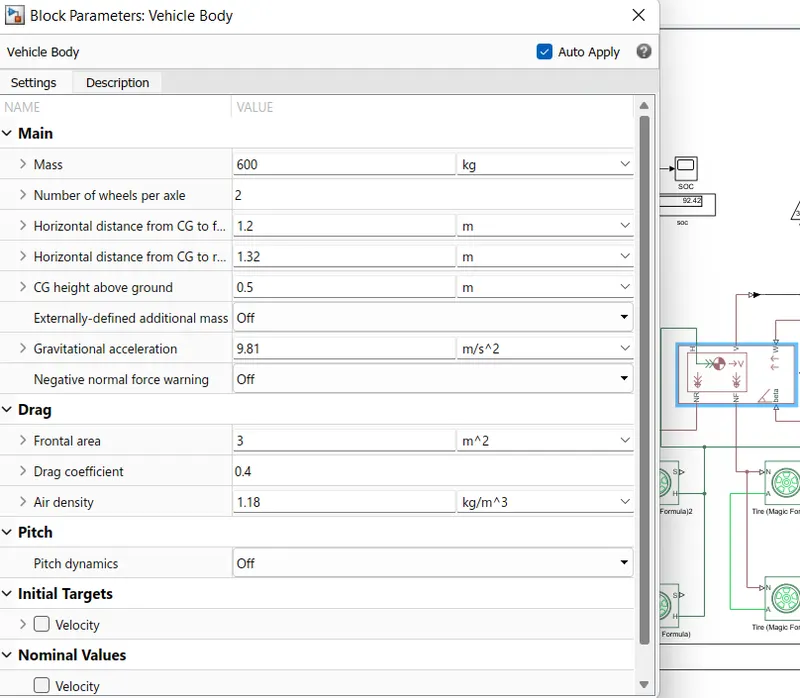
we considered following parameters-
frontal area= 3 m^2
drag coefficient=0.4
air density= 1.18 kg/m^3
mass= 600 kg
11) battery model=
- the battery is connected as the source to the model so that the power could be generated and the same power is transmitted accordingly to all the operating sources and load demand of driver. The terminal connection is
+ = the positive terminal of the operating sources
- = the negative terminal of the operating sources
- the battery block implements a generic dynamic model that represents most popular types of rechargeable batteries like lithium-ion type battery.
- the complete battery soc block is-
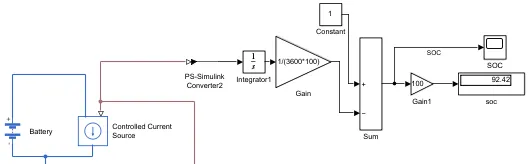
-it includes the controlled current sources to draw controlled current from battery to load, the electrical reference, PS-Simulink converters, the scope and SOC estimate.
- SOC estimation:
-for this we use a simple method called coulomb counting.
- coulomb counting is a technique used to track the state of charge of a battery pack.
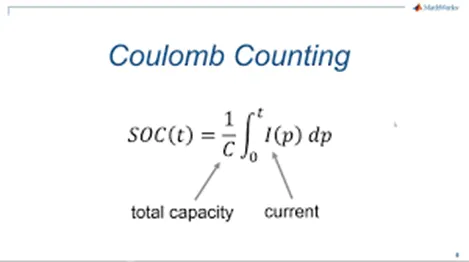
- it works by integrating the active current flowing in ampere over time to derive the total sum of energy entering or leaving the battery pack. This produces a capacity that is measured in amp-hours.
-the SOC estimate block is connected with battery through controlled current source block from which integrator block counts all time period +, - values of current. The gain considered at (1/100*3600) Ah capacity of battery, then the sum block subtracts the SOC from initial set constant block. This gives us the battery SOC estimate.
-the parameters of battery block are-
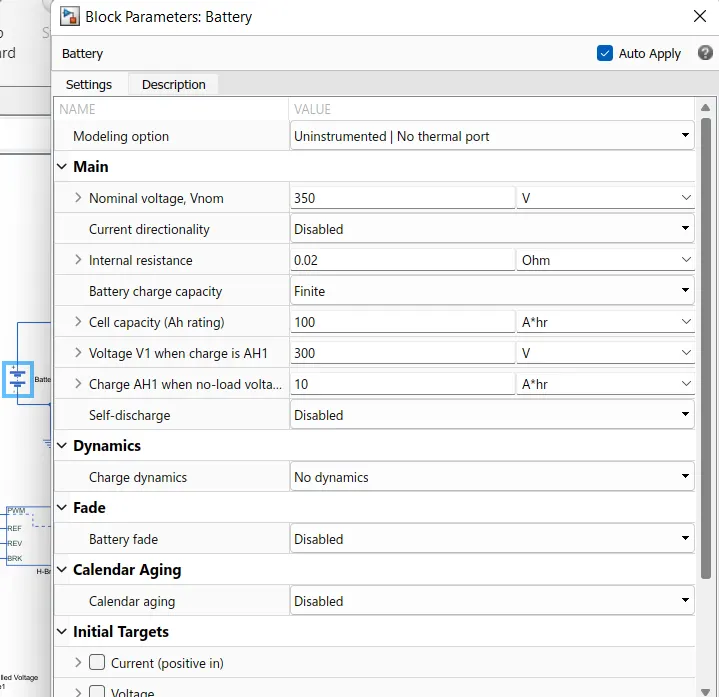
we consider the following parameter values for this battery
- nominal voltage= 350 V
- rated capacity= 100 A*hr
- initial state of charge=100 %
12) controlled voltage source
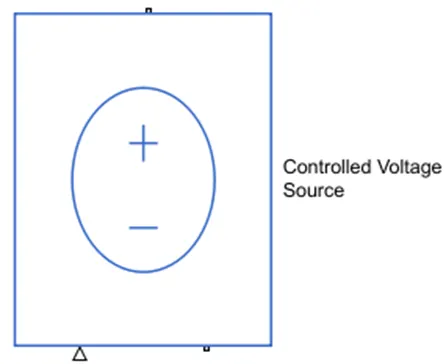
it is located in the Simulink library at electrical sources.
it is used to control the voltage which is connected to the positive reference of the controlled PWM voltage in the form of a signal by the PID controller model acceleration command and another controlled voltage source 2 is used to connect to the H-bridge BRK terminal. the negative sides of both the sources are connected to the electrical reference as shown above.
13) controlled current source=
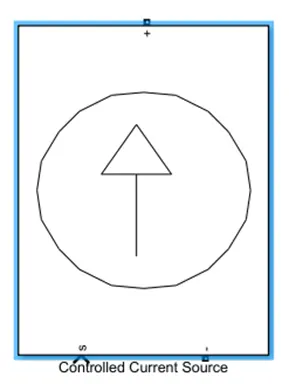
- it is located in Simulink library at simscape /electrical /specialized power systems / fundamental blocks / electrical sources.
- this block converts the Simulink input signal into an equivalent current source. The generated current is driven by the input signal of the block which is shown as symbol of 's’. the arrow in block shows positive current direction. This current source may be used for the both AC and DC current controls. Without giving any signal or values to the control as input it will not work. Here the controlled current source +Ve and -ve terminals are connected to the battery +ve and -ve terminals respectively as shown in model. The input signal 's' is connected to the power control unit current sensor signal I which is the physical signal.
14) solver configuration
- it is placed in the power control unit for the mathematical values in the model solver settings at the simulation time.
15) current sensor-
-it is located in the Simulink library at electrical sensors.
-this is used to measure the current flowing through the H-bridge. The positive and negative terminals of the current sensor are connected to the DC motor and H-bridge block respectively and the signal is connected to the controlled current source in the battery as a physical input signal from the H-bridge circuit.
16) electrical reference
-it is located in the Simulink library at electrical elements.
-it is used to connect all the terminal of the negative signals and the reference values as the ground.
17) mechanical rotational reference
it is representing as a mechanical ground reference point that is as a frame part which is used to connect rotational parts to the ground.
18) Inertia
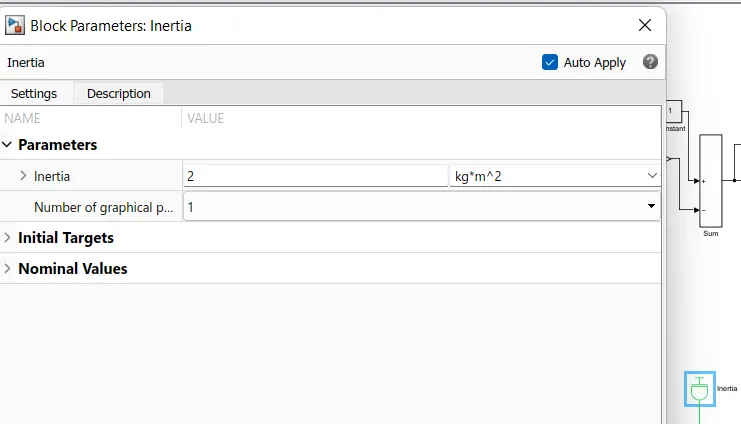
it is used to represent the ideal mechanical rotational inertia which is the reference port to give the positive inertia torque with the terminal used to connect to the reference one.
19)display
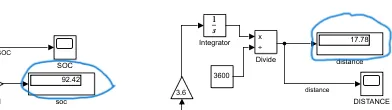
-it is located in the library Simulink at Simulink / sinks.
-it is used to display the value that connected to this block in the form of physical form.
20) scope=
it is also located at different places as,
simulink/commonly used blocks
simulink/ sinks
HDL coder / commonly used blocks
HDL coder / sink
it is used to display the signals generated during simulation.
21) Powergui
-it is present at simscape / electrical / specialized power systems / fundamental blocks.
-it is used with simulation of power systems and power electronics.
- it is used for the analysis and measurement of parameters like voltage, current, active power, reactive power.it gives the steady state values of the system.
22) PS-Simulink converter:
- it is located in the Simulink library at utilities.
- it is used to connect the line from physical signal to Simulink which act as a converter.
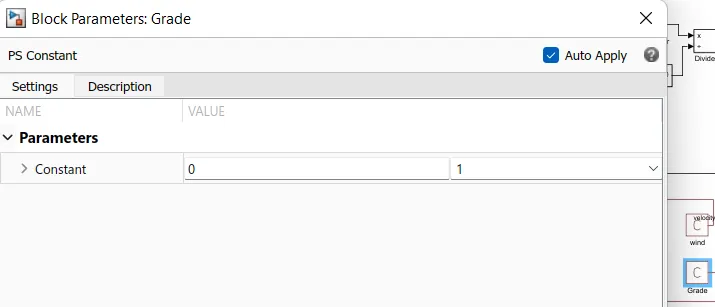
23) PS constant=
- this block generates a physical signal of a constant value.it has only one output port which is a physical signal.
- we specified the value and unit of the signal as the constant parameter.in our model we are using 2 PS constant blocks which are connected across the W and beta ports of the vehicle.
25) Sum block=
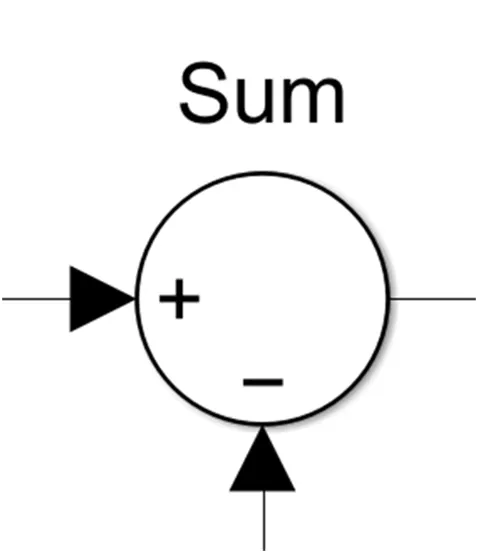
- This block subtracts feedback velocity from reference velocity.
- This output is given to PID controller.
26) Simulink to PS converter=

- It converts the simulink input signal to a physical signal
Results=
To get the results of this model we have to keep the stop time to 2474 sec or above because of the given drive cycle source with FTP (2474 seconds).
so, now I am running the model by selecting the stop time as 2474 second by clicking the run button at the top of the window
So,we can see the following observation which is shown in the figure.
Vehicle speed scope=
this plot can be observed from the scope which is connected across the drive cycle source and feedback velocity which is coming from the transmission subsystem and the longitudinal driver block.
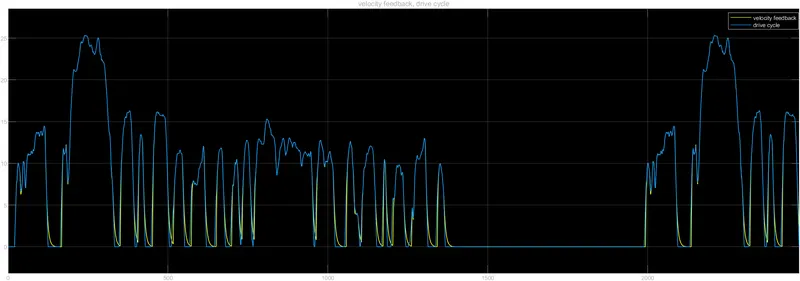
- from this response we can see, there are two signals. The blue signals shown is the drive cycle data and the yellow signal represents the vehicle body speed.
-the PID control block successfully maintains the drive cycle data, processes it and controls the vehicle speed according to the reference speed.
-if we observe them, we can say that they are looking similar but not exactly. Because when we driving the car there will be speed variation according to the time, sudden stops and some other factors also affect such as type of road and rolling resistance etc.
-so there will be same movements like high speed, low speed but due to the factor effected in the real time there will be a variation from the original drive cycle.
SOC Scope =
the below graph has been observed form the scope block which is connected to the battery.
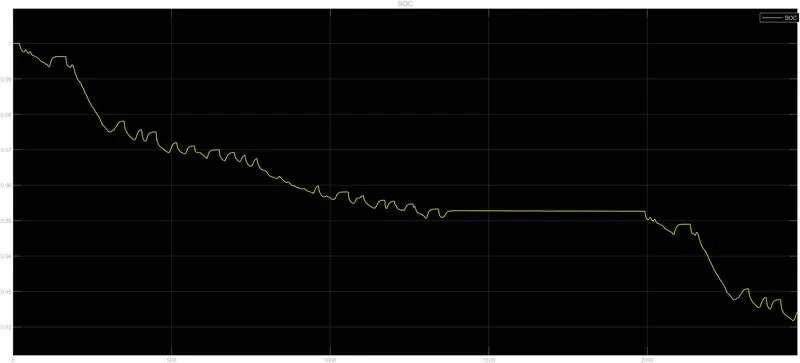
-the SOC graph shows the state of battery varies over the drive cycle time.
-initially the battery SOC is 100 %
- as the the simulation starts then there will be a fall of SOC.
- the charge of the battery gets decreased from 100 % to 92.42 %
- the spikes in battery SOC graph shows regeneration during the deceleration of the vehicle as battery starts recharging and motor acts as generator.
-again, if we observe from that graph that in between 1400-2000 sec it is almost constant to zero speed which means that either the car is in neutral gear or it is in downhill road, so in that period the battery gets charged.
Distance covered=
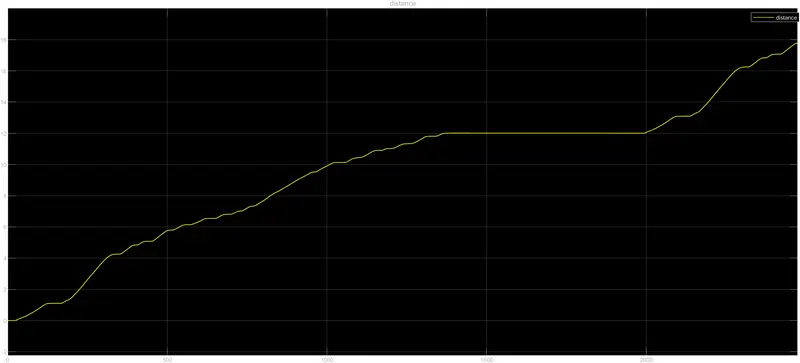
-vehicle speed obtained in m/s so we can convert this to km/hr by using gain block 3.6.
-we convert velocity speed to distance that is km/hr to only km by using integrator block, constant block of 3600, divide block.
-from this graph and display block,we have seen that the total distance covered during the period of 2474 seconds is 17.78 km.

Current scope=
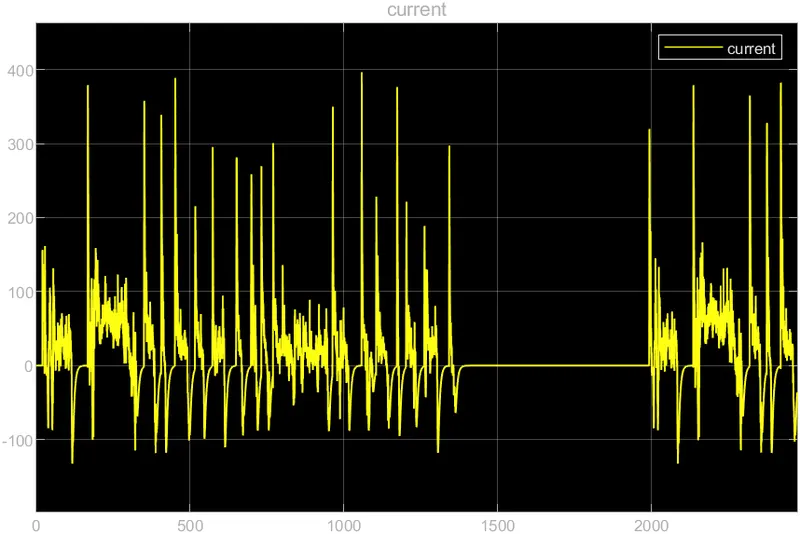
-the above graph shows the current variations of the motor according to drive cycle.
-the current sensor is connected between the H-bridge and DC motor senses the current changes and they are plotted through the scope block, so this current variation is observed from the changes in DC motor conditions.
-we can see that current increases according to acceleration and decreases according to the deceleration.
-when the vehicle is maintaining a constant acceleration or deceleration then the current is also maintaining its range according to it.
-at peak value the maximum current is approximately 395 A, at neutral condition that is at 0 velocity the current value is also settled at nearby zero value and during deceleration of the car the current value is also going to decrease in negative values.
the link for this model is-
https://drive.google.com/file/d/1RQcFCQrVE7dAUC3paduvXnMVMxZKKaLD/view?usp=share_link
CONCLUSION=
- the above electric vehicle/car model has been created by using the DC motor and battery with all the necessary components by using Simulink and the model is simulated with all the proper procedure.
- The main objective of the project was to design the power controller unit, the designed PCU is working properly with fast response and under stable condition. The PID controller was tuned for maximum fast response with stability as a constrain.
- the simulation can be carried out by deciding the overall specification that the vehicle should achieve, in this manner all components can be chosen and then the actual model could be manufactured.
- this simulation gives the vehicle speed output, current flowing through the battery and the state of charge as well as the distance travelled within the simulation running time.
- the total distance covered during the period of 2474 seconds is 17.78 km.
- the SOC of the battery is discharged efficiently up to 92.42% from full charge.
- this model has been attached above as a slx file.