Project 1 (Mini Project on Vehicle Direction Detection
Aim: To develop the Simulink Model for Vehicle Direction Indicator.
Objective:
1) Create the simulink model for Requirement 1 subsystem to generate the Vehicle turn status.
2) create the simulink model for Requirement 2 subsystem to Vehicle direction Indicator.
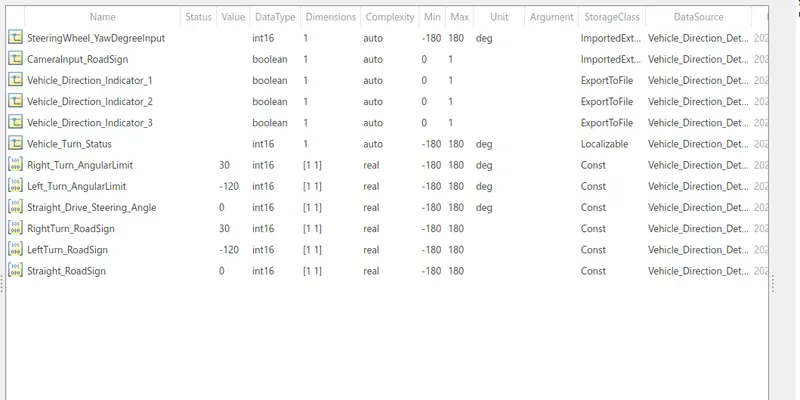
3) Create SLDD and link to model.
4)Generate the Model Advisory Report.
Answer -
In the ADAS, this Vehicle direction indication is one of the most important feature for the driver to understand the direction of road sign and to clarify the its driving direction is going correct or not.
Simulink Model:
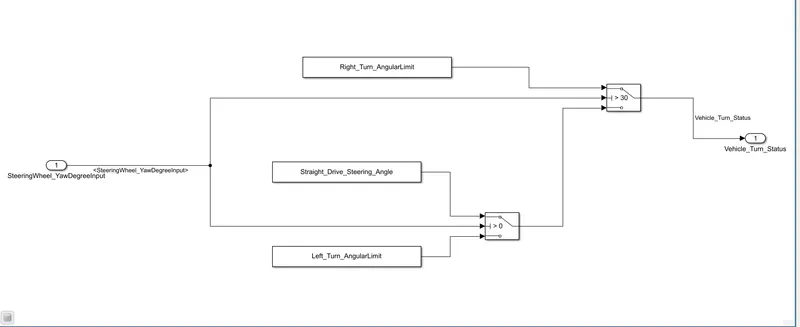
1) Requirement 1
Steps to create first requirement 1 simulink model
Step 1: Yaw rate signal from the vehicle create the In1.
Step 2: create the three constant block for left_Turn_angular_limit, right_Turn_anguler_limit and straight_turn_anguler_limit.
Step3: Create two switch block to compaire the Yaw Rate signal with above three constant blocks.
Step 4:apply the condition setting to switch block and create Out block forVehicle_Turn_Status.
Simulink Model for Requirement 1:
Explanation -
We apply the condition for switch 1 that if Input angle is greater than 30 then it gives the True value as as right turnangulaer limit. If the Input angle from Yaw rate is between the 0 & 30 then, switch produce Straight drive steering angle and if the Input Yaw rate angle is less than 0 then it give the output LeftTurn_Angular_Limit. This output is then take out by the Out1 named as Vehicle Turn Status.
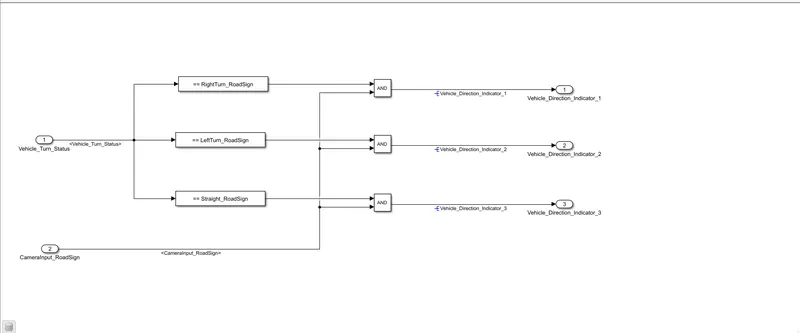
Requirement 2
Steps to create first requirement 2 simulink model
Step 1: Take the Vehicle Turn Status Input of Requirement 2.
Step 2: Create three Relational blocks( Compare to constant) to compare this Vehicle Turn Status to product logical 1 and 0 output.
Step 3: create another In signal block to take the Camera Input as named CameraInput_RoadSign.
Step 4 : create the three relation equal to block to compare the Camera Input with the Compare to constant blocks.
Step 5: finally the result is taken out by Out port as Vehicle Direction Indication.
Simulink Model for Requirement 2:
Explanation -
This input we have compare with the compare to constant blocks which is the RightTurn_RoadSide, LeftTurn_RoadSign and Straight_RoadSign. Create three blocks of relational equal too block to compare with the Camera Input to produce the Vehicle Direction Indication. after the successfully create the model we make the SLDD and linked it with the model and run it.
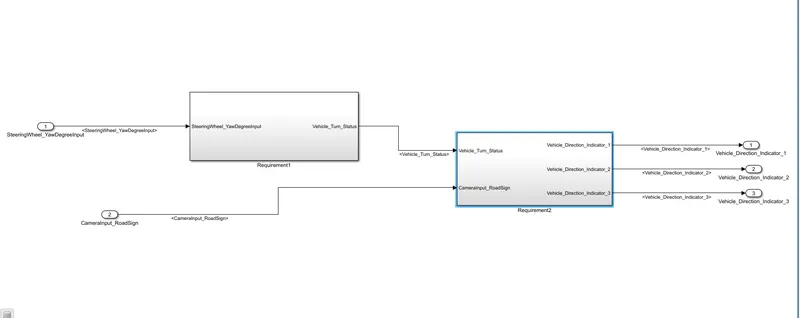
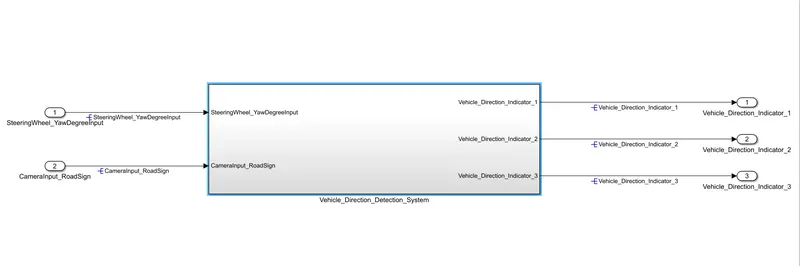
Main Simulink Model
Blocks Used
1)Inport
2)Constant
3)Compare to Constant
4)Switch
5)Equal to
6)Subsystem
7)Outport
SLDD File
Results
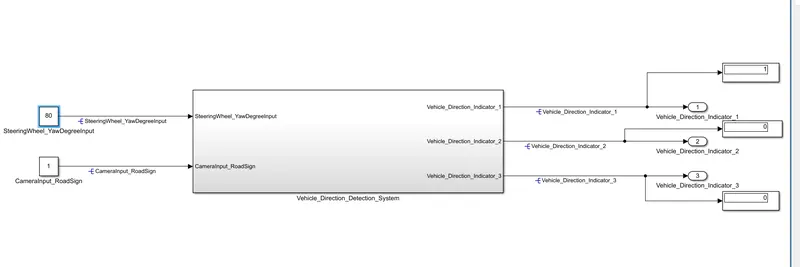
when we apply the Yaw Rate greater the 30, then the system produce the output that Right turn Indication
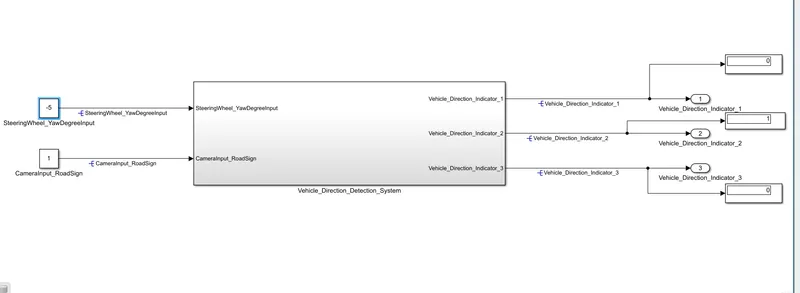
When the Input Yaw Rate signal is less than the 0 then, the Vehicle Indicator Produce Left turn Indication.
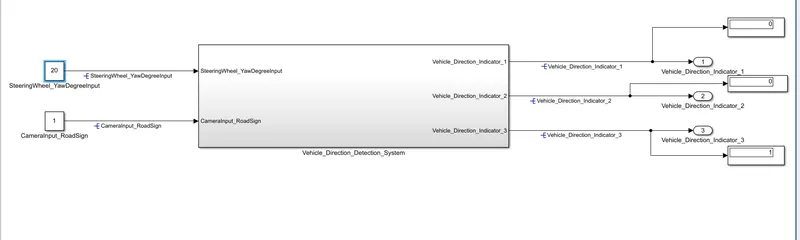
When the Yaw Rate Input is between the 0 to 30 then Vehicle Direction Indicator produce the Straight indication
Conclusion :
we successfully Created the Simulink Model for the Vehicle Direction Indicator to Guide the Driver about the Vehicle direction