Project 1 (Mini Project on Vehicle Direction Detection
Aim:
To create the vehicle direction Detection Model using the given requirements.
Objective:
- Development of MATLAB Simulink model as per requirement.
- Tag the requirements to the Simulink model; tagging requirements 1 & requirement 2 to their corresponding subsystems is fine.
- MBD-compliant changes, Data Dictionary creation & code generation is added advantage, and that is not the scope of this project.
- If choosing code generation, the Storage class for Input signals: ImportedExtern; the Storage class for Output signal: Export to File; the Storage class for local signals: localizable; the Storage class for calibration signals: Const.
- Choose sample time for all signals as 0.01s
Simulink Model:
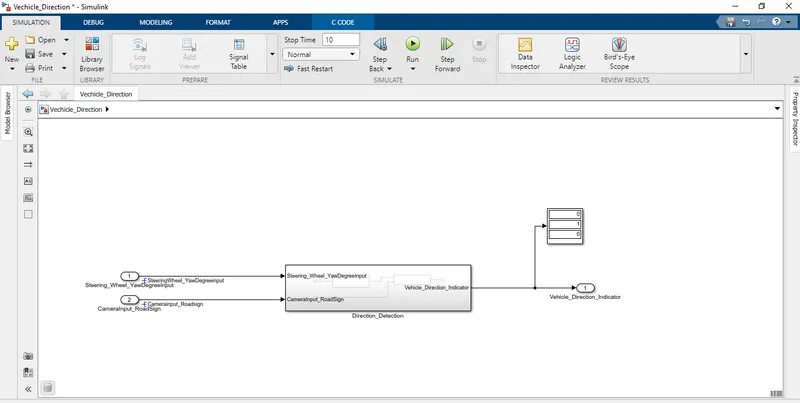
The inputs are Steering_Wheel_YawdegreeInput and Camera_RoadSign
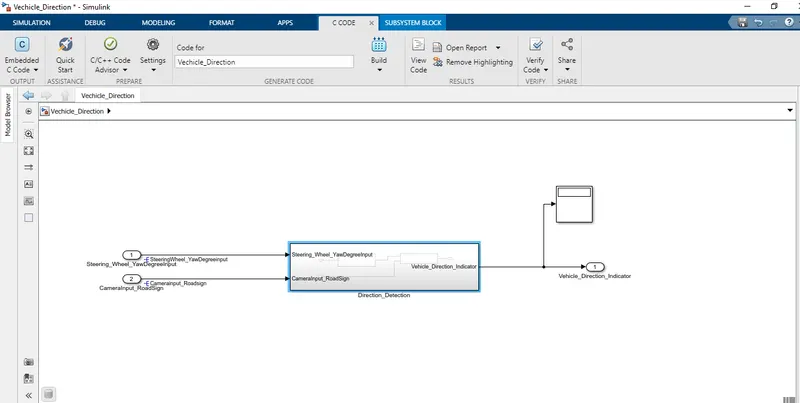
Vehicle Direction subsystem:
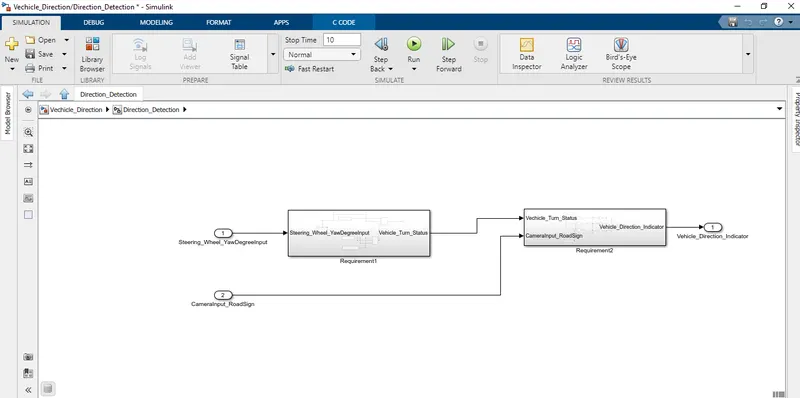
Requirement 1:
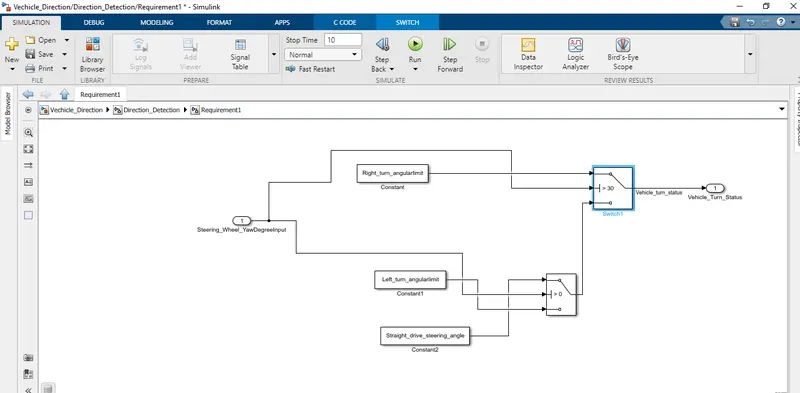
In requirement 1 Subsystem Steering_wheel_YawdegreeInput is input and it is for a left turn, right turn, and straight drive. This input signal is compared to angular values and one for a left, right, or straight drive.
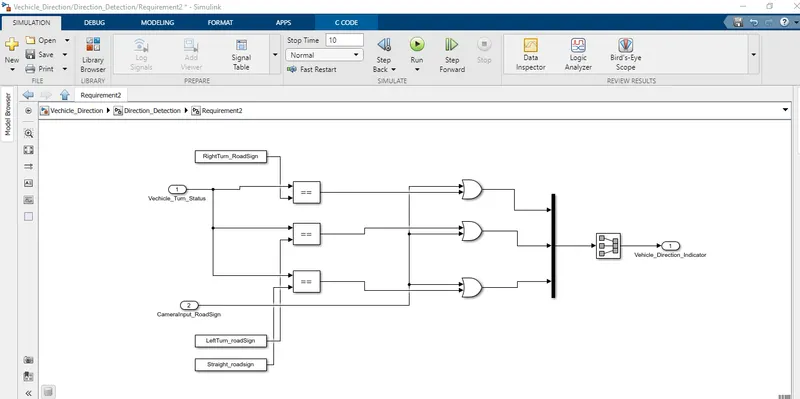
Requirement 2:
Vehicle turn Status is taken as input and is compared against the left turn, right turn, and straight road sign. The value obtained is compared with the camera signal and gives output.
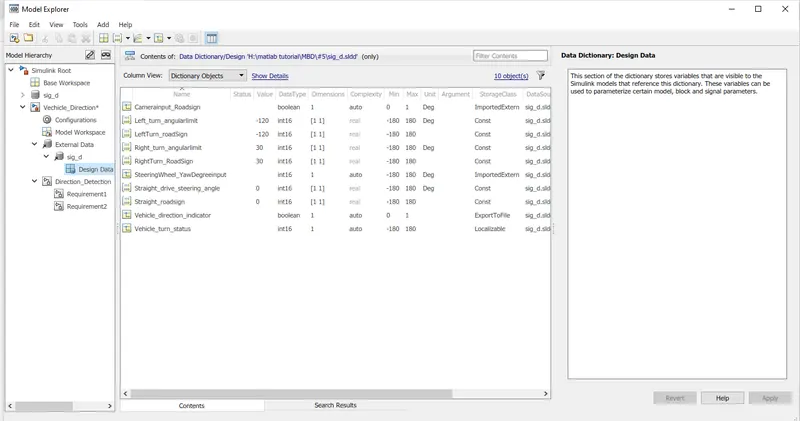
Simulink Data Dictionary File:
SLDD file contains input signal and calibration values.
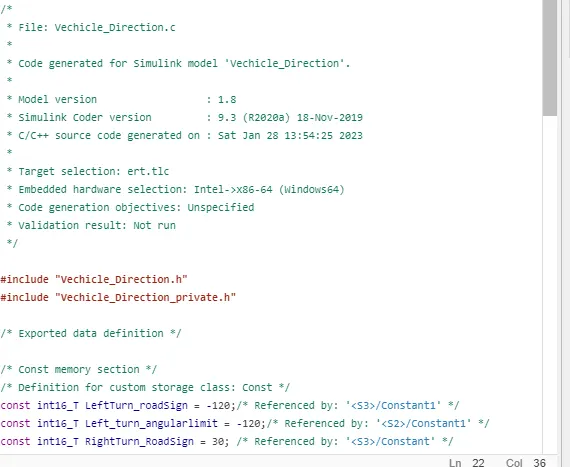
Generate code:
Using Build code we generate code.
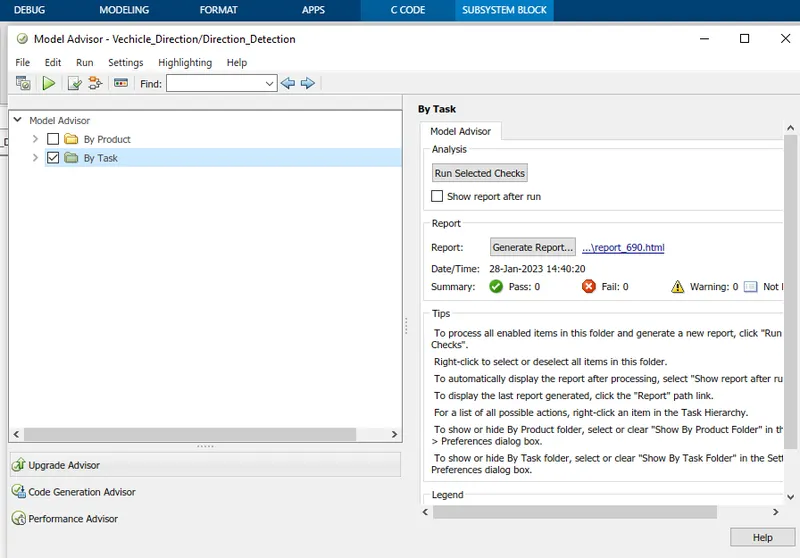
Model Advisor:
By using Model advisor we can see commonly modeled errors.
Result:
The vehicle direction detection is modeled as per requirement and all signals and parameters are defined simulink data dictionary. Updated model to check errors and static model advisor to see any errors.
when the vehicle turn left side.