Project 1 (Mini Project on Vehicle Direction Detection
Aim Of The Project:
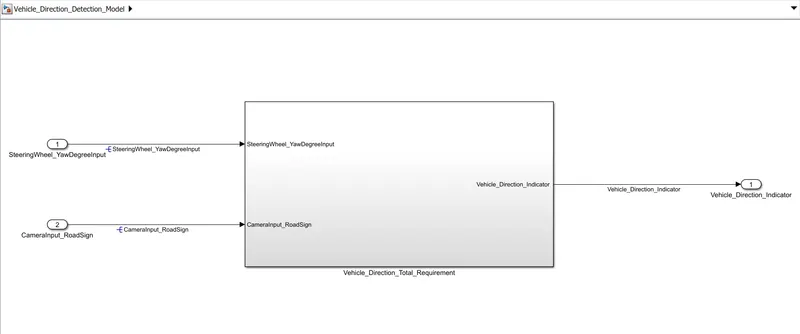
Identifying the direction of the vehicle based on the camera input.
Objective of the Project:
- Development of MATLAB Simulink model as per requirement.
- Tag the requirements to the simulink model; tagging requirement 1 & requirement 2 to their corresponding subsystems is fine.
- MBD compliant changes, Data Dictionary creation & code generation is added advantage, and that is not scope of this project.
Requirement - 1:
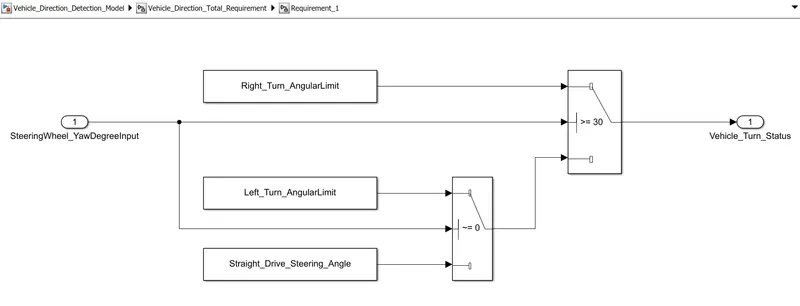
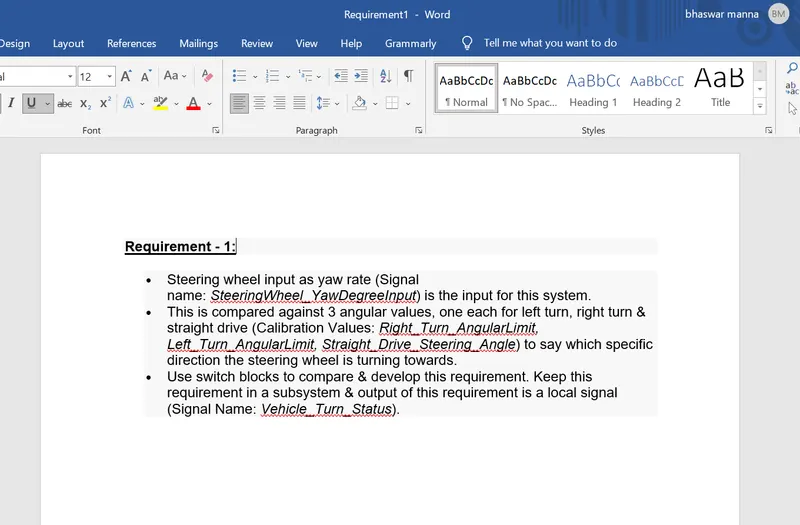
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
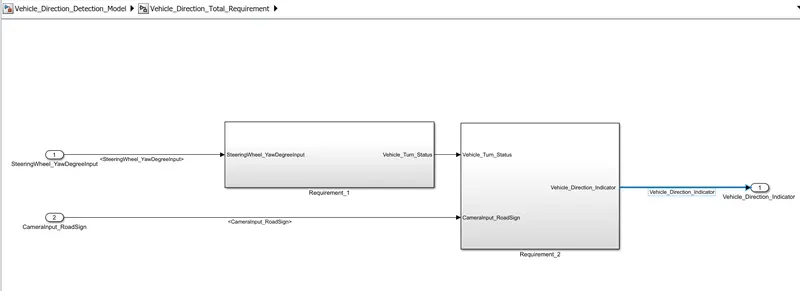
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
Requirement – 2:
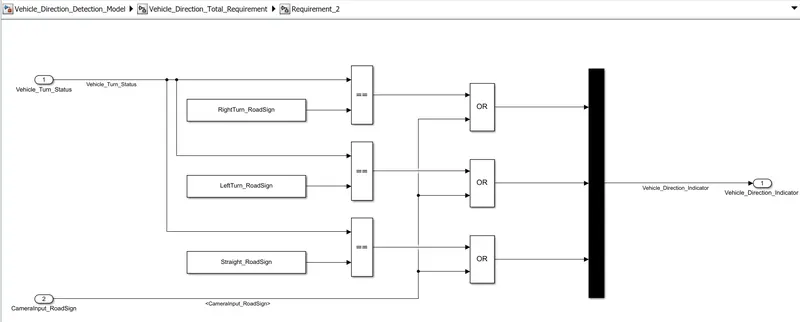
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator).
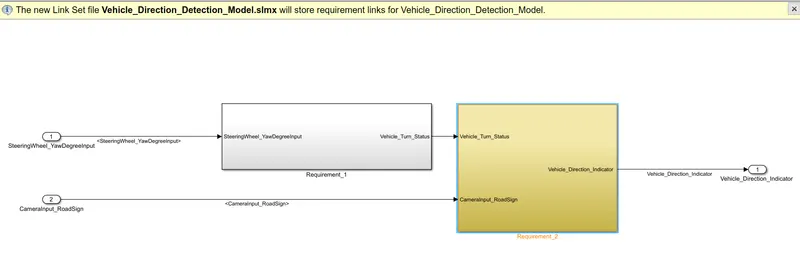
Main Model for the Project and all the levels of Subsytems for both the requirements-->
Requirement-1-->
Requirement-2-->
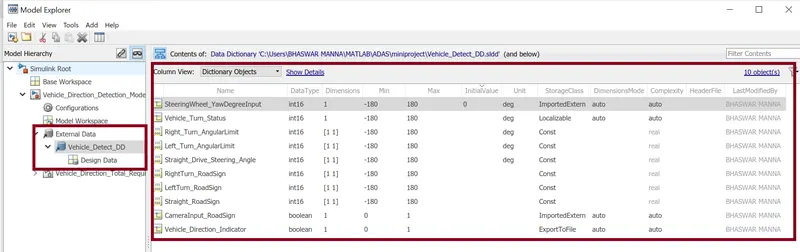
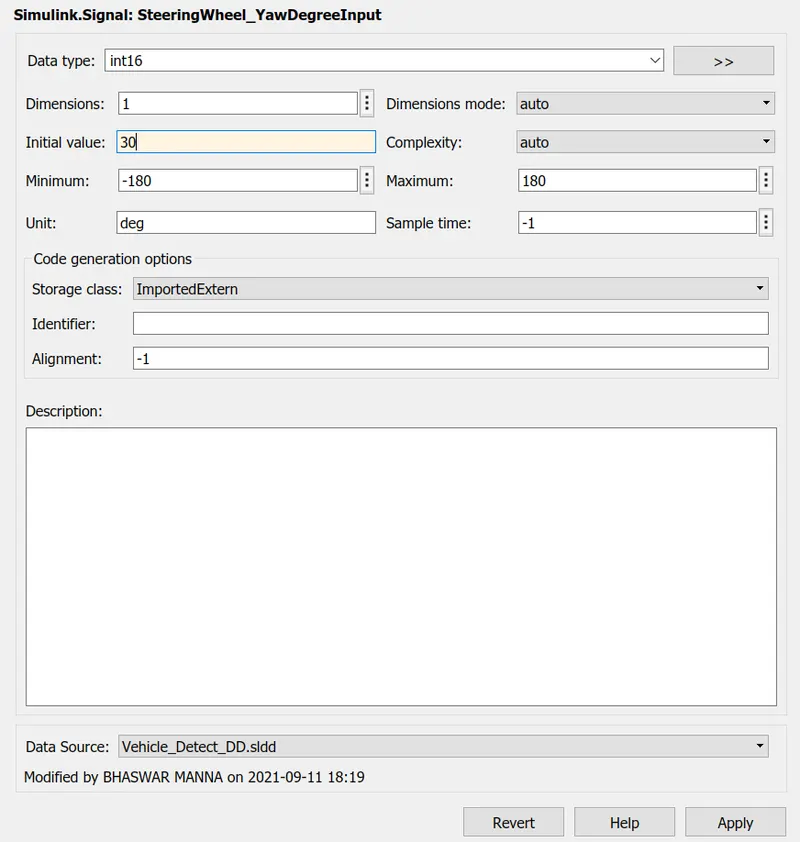
Data Storerd in SLDD file, created for the project-->
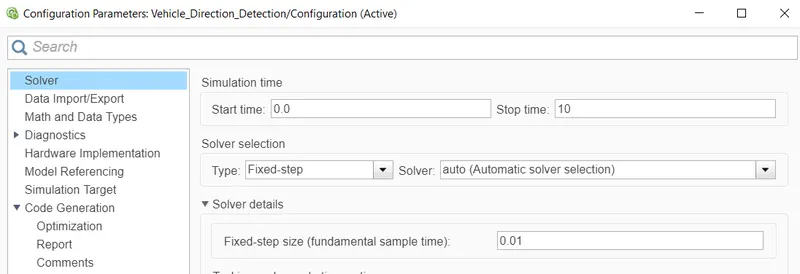
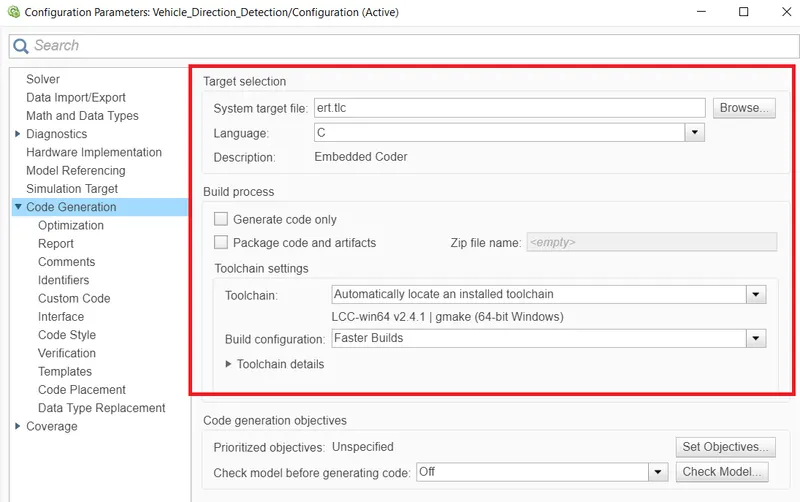
Configuration Settings for MBD compliance -->
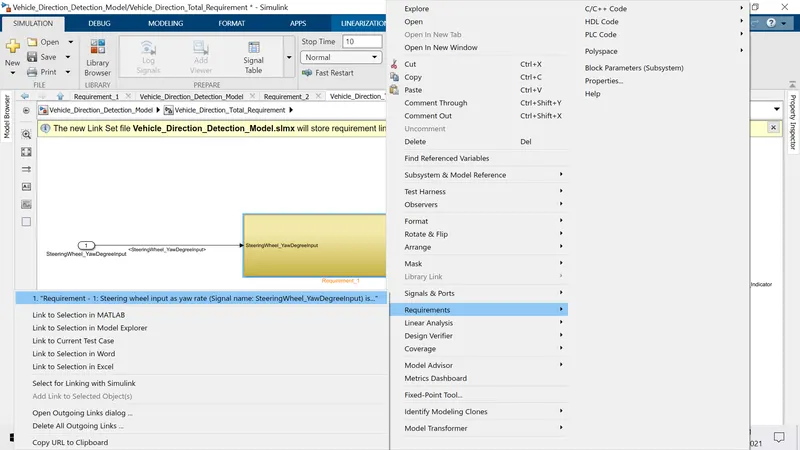
Now, Tagging the requirements are done Both the tagging is done like the same.
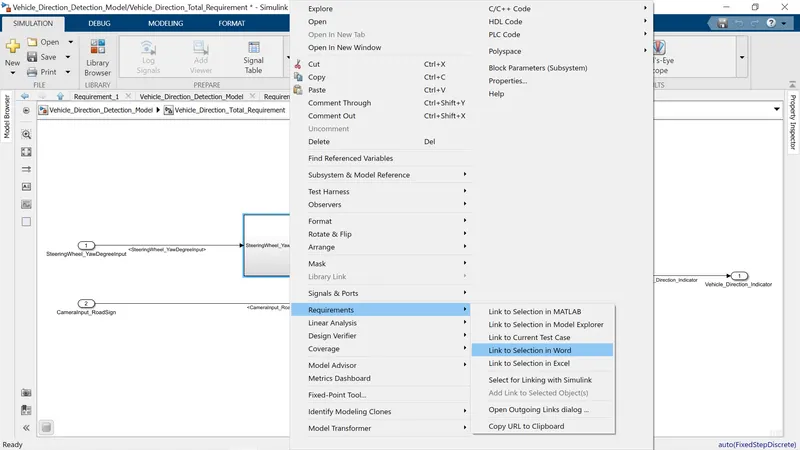
For the Requirement 2 it is also done.
Simulation process and Results:
For Right Turn, we give initial value of 30 deg-->
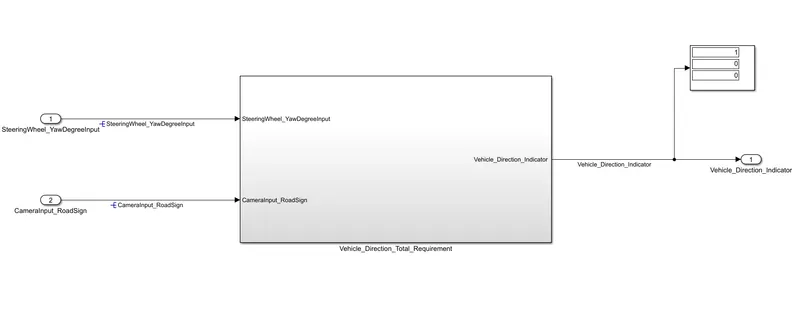
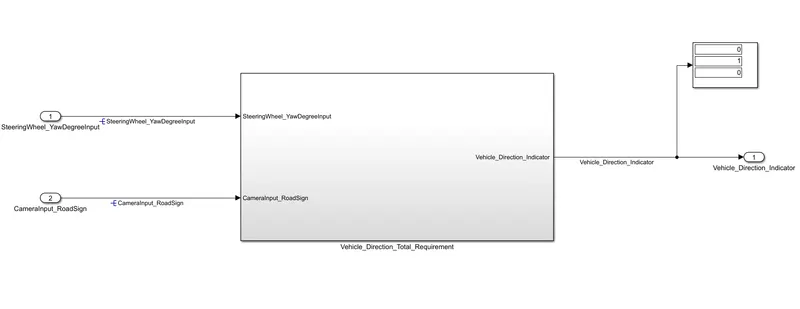
Similarly, for Left Turn and Straight Driving the results are:
Left Turn(-120 deg)-->
Straight Drive(0 deg)-->
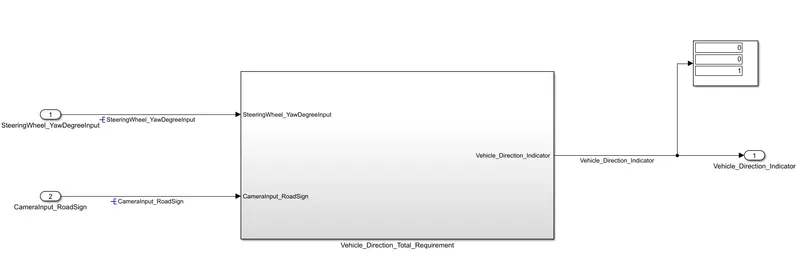
So, All the 3 different outputs are coming fine.
**P.S.- Due to deadlines, the added advantages for the same are not done because it is said that it is nit necessary. Model Advisor Report and the Code generation is not done for the mini-project(it is not the scope of the same).