Project 1 (Mini Project on Vehicle Direction Detection
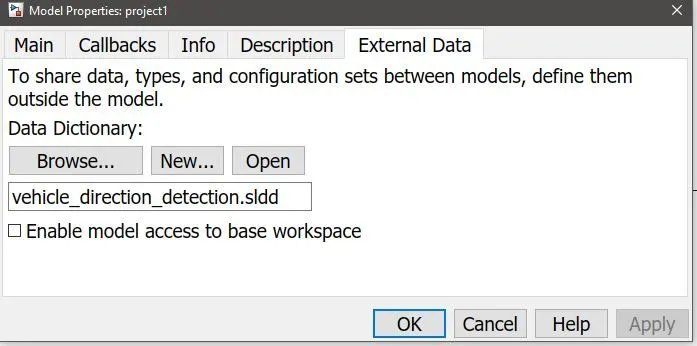
step 1: sldd file has to be inserted
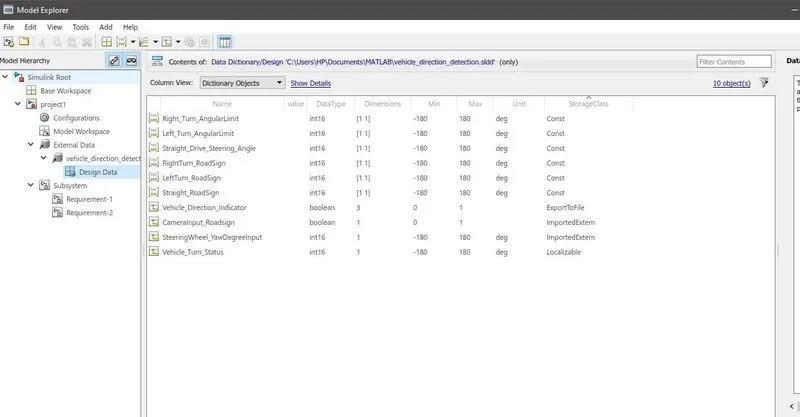
step 2: signals and parameters are to be added
step 3: block modeling is being done:
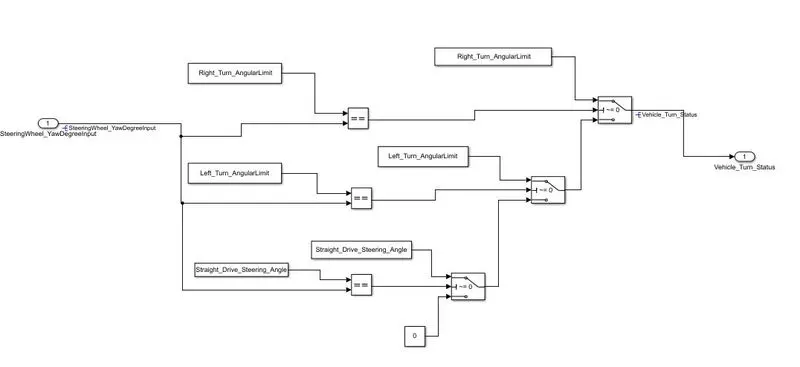
Requirement-1 subsystem:
- Steering wheel input as SteeringWheel_YawDegreeInput
- This is compared against 3 angular values, one each for left turn, right turn & straight drive: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle to say which specific direction the steering wheel is turning towards.
- switch blocks are used to compare & develop this requirement. output of the system is Vehicle_Turn_Status.
Requirement-2 subsystem:
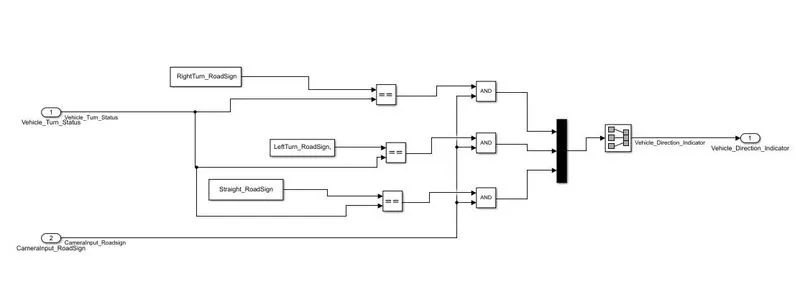
- Inputs to this requirement are Vehicle_Turn_Status & a CameraInput_RoadSign, which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign, if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal Vehicle_Direction_Indicator.
subsystem has been created using the 2 requirement blocks:
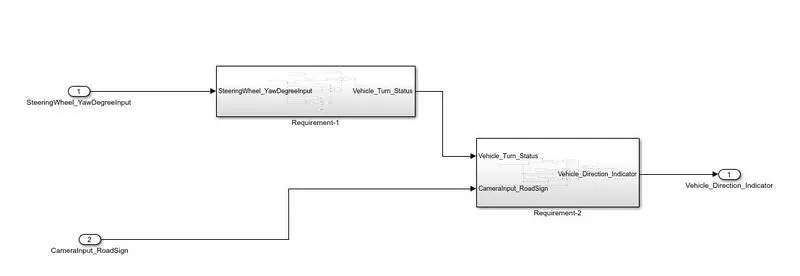
Simulink model:
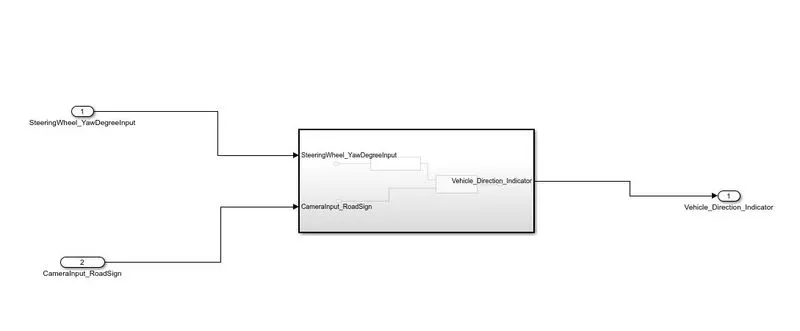
step 4: right click on requirement 1 model : go to requirements- link to selection in word. do the same with requirement 2 block.
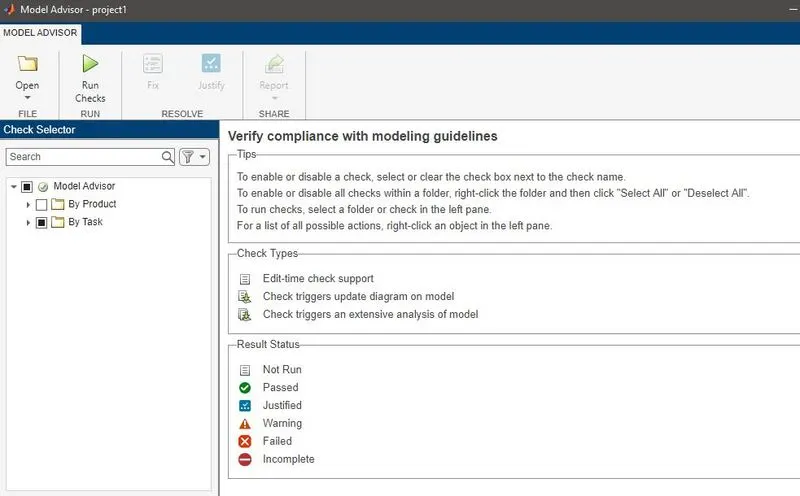
step 5: check for model advisor report if any error is there or not.
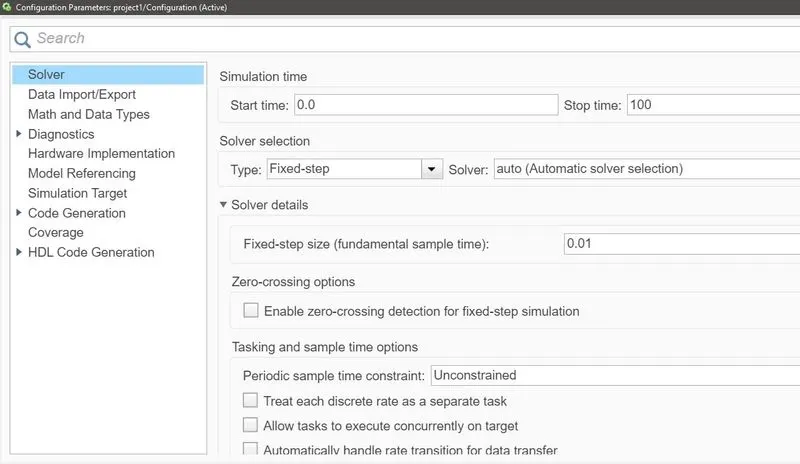
step 6: check solver with 0.01 step size and code generation.
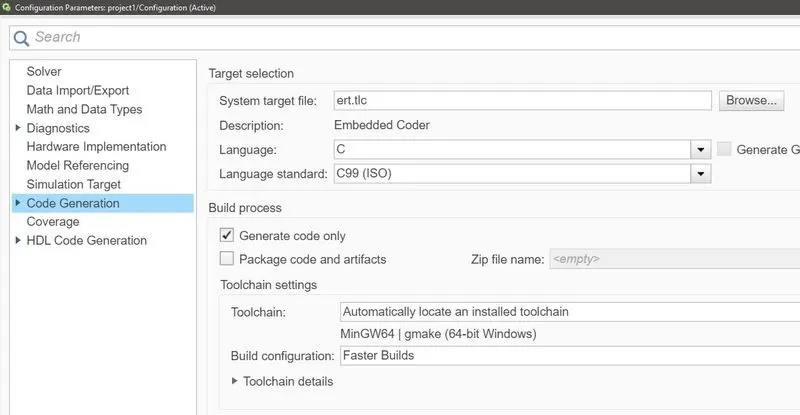
7. click on generate code
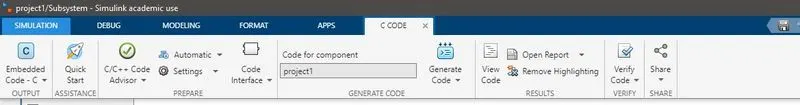
code:
/*
* Academic License - for use in teaching, academic research, and meeting
* course requirements at degree granting institutions only. Not for
* government, commercial, or other organizational use.
*
* File: project1.c
*
* Code generated for Simulink model 'project1'.
*
* Model version : 1.2
* Simulink Coder version : 9.7 (R2022a) 13-Nov-2021
* C/C++ source code generated on : Mon Sep 26 12:02:42 2022
*
* Target selection: ert.tlc
* Embedded hardware selection: Intel->x86-64 (Windows64)
* Code generation objectives: Unspecified
* Validation result: Not run
*/
#include "project1.h"
#include "rtwtypes.h"
#include "project1_private.h"
/* Exported data definition */
/* Const memory section */
/* Definition for custom storage class: Const */
const int16_T LeftTurn_RoadSign = -120;/* Referenced by: '/Constant1' */
const int16_T Left_Turn_AngularLimit = -120;/* Referenced by:
* '/Constant1'
* '/Constant4'
*/
const int16_T RightTurn_RoadSign = 30; /* Referenced by: '/Constant' */
const int16_T Right_Turn_AngularLimit = 30;/* Referenced by:
* '/Constant'
* '/Constant3'
*/
const int16_T Straight_Drive_Steering_Angle = 0;/* Referenced by:
* '/Constant2'
* '/Constant5'
*/
const int16_T Straight_RoadSign = 0; /* Referenced by: '/Constant2' */
/* External inputs (root inport signals with default storage) */
ExtU_project1_T project1_U;
/* External outputs (root outports fed by signals with default storage) */
ExtY_project1_T project1_Y;
/* Real-time model */
static RT_MODEL_project1_T project1_M_;
RT_MODEL_project1_T *const project1_M = &project1_M_;
/* Model step function */
void project1_step(void)
{
/* local block i/o variables */
int16_T Vehicle_Turn_Status;
/* Outputs for Atomic SubSystem: '/Subsystem' */
/* Switch: '/Switch' incorporates:
* Constant: '/Constant'
* Constant: '/Constant1'
* Constant: '/Constant2'
* Inport: '/SteeringWheel_YawDegreeInput'
* RelationalOperator: '/Relational Operator'
* RelationalOperator: '/Relational Operator1'
* RelationalOperator: '/Relational Operator2'
* Switch: '/Switch1'
* Switch: '/Switch2'
*/
if (Right_Turn_AngularLimit == SteeringWheel_YawDegreeInput) {
/* Switch: '/Switch' incorporates:
* Constant: '/Constant3'
*/
Vehicle_Turn_Status = Right_Turn_AngularLimit;
} else if (Left_Turn_AngularLimit == SteeringWheel_YawDegreeInput) {
/* Switch: '/Switch1' incorporates:
* Constant: '/Constant4'
* Switch: '/Switch'
*/
Vehicle_Turn_Status = Left_Turn_AngularLimit;
} else if (Straight_Drive_Steering_Angle == SteeringWheel_YawDegreeInput) {
/* Switch: '/Switch2' incorporates:
* Constant: '/Constant5'
* Switch: '/Switch'
* Switch: '/Switch1'
*/
Vehicle_Turn_Status = Straight_Drive_Steering_Angle;
} else {
/* Switch: '/Switch' incorporates:
* Constant: '/Constant6'
* Switch: '/Switch1'
* Switch: '/Switch2'
*/
Vehicle_Turn_Status = 0;
}
/* End of Switch: '/Switch' */
/* Outport: '/Vehicle_Direction_Indicator' incorporates:
* Constant: '/Constant'
* Constant: '/Constant1'
* Constant: '/Constant2'
* Inport: '/CameraInput_RoadSign'
* Logic: '/Logical Operator'
* Logic: '/Logical Operator1'
* Logic: '/Logical Operator2'
* RelationalOperator: '/Relational Operator'
* RelationalOperator: '/Relational Operator1'
* RelationalOperator: '/Relational Operator2'
*/
project1_Y.Vehicle_Direction_Indicator[0] = ((RightTurn_RoadSign ==
Vehicle_Turn_Status) && project1_U.CameraInput_RoadSign);
project1_Y.Vehicle_Direction_Indicator[1] = ((LeftTurn_RoadSign ==
Vehicle_Turn_Status) && project1_U.CameraInput_RoadSign);
project1_Y.Vehicle_Direction_Indicator[2] = ((Straight_RoadSign ==
Vehicle_Turn_Status) && project1_U.CameraInput_RoadSign);
/* End of Outputs for SubSystem: '/Subsystem' */
}
/* Model initialize function */
void project1_initialize(void)
{
/* (no initialization code required) */
}
/* Model terminate function */
void project1_terminate(void)
{
/* (no terminate code required) */
}
/*
* File trailer for generated code.
*
* [EOF]
*/