Project 1 (Mini Project on Vehicle Direction Detection
Aim of the project :
Identifying the direction of the vehicle is one of the important & diverse features in Autonomous driving & Advanced Driver Assistance Features. This particular sub-feature of identifying the direction of vehicle is basically identifying the direction the vehicle is taking based on the camera input.
Camera reads the road signs & stores into its memory with unique values for left turn, right turn & straight drive. Depending on the direction it is taking, final indication is given to the driver – as an indication if he is driving in the recommended direction or not.
Description :
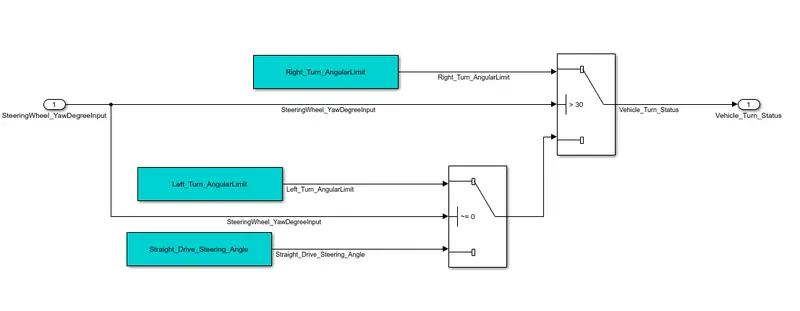
we have one input that is connected to the system that is "SteeringWheel_YawDegreeInput " signal according to the input we have to decide which side the vehicle turn like Left _turn , Riht_Turn ,Straight_Drive .
we have to compare SteeringWheel_YawDegreeInput with the Left _turn , Riht_Turn ,Straight_Drive tO get our desired output the signal name "Vehicle _Turn _Status".
Here we have to compare with switch block to get corresponding output .
These Vehicle_Turn_Status output signal is input as requirment -2.
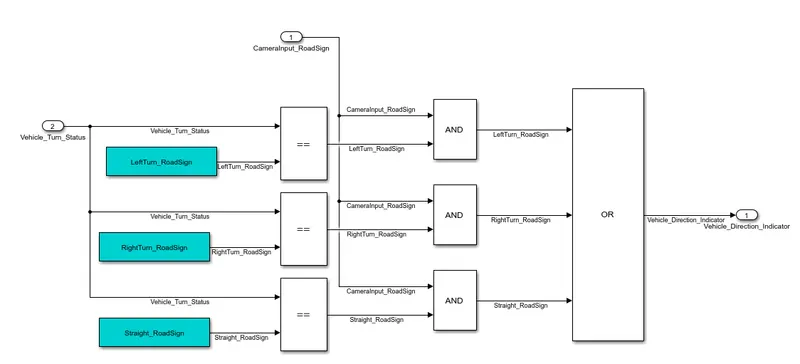
Based on vehicle_turn_Status and camera_Input with these 2 inputs ,the it will decide to which side turn required.
The camera_Input is connected to the system ,according to the carema view ,we have to decided which side turn with this vehicle is turn .
here we have to give the three camera signs ,based on these we have to compare final output is get the signal name is Vehicle_Direction_Indicator.
Simulink Model :
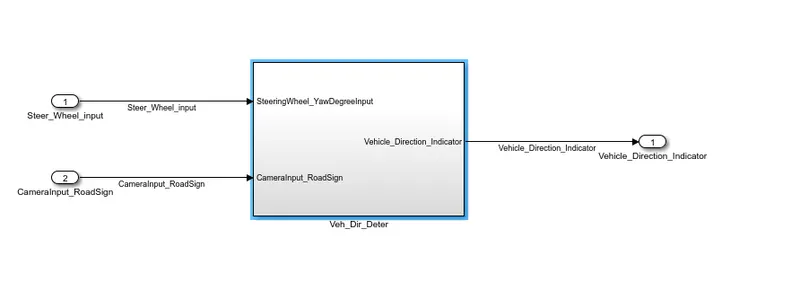
Here we developing a model for vehicle Direction Determination .
Here the we have two inputs for the system .
one out put is Vehicle_Direction_Indicator.
Requirment_1 :
Here we using the subsystem .in these we have Three turns which direction is need based on the data requirments we haev to compare these signals .
Requirments -2 :
Here we have 2 inpts one is Vehicle_Turn_Status ,Camerainput_RoadSign,with this we have to compare with 3 roadsign values acoording to data we have to turn the required output ,the signal name is Vehicle_Direction_Indicator.
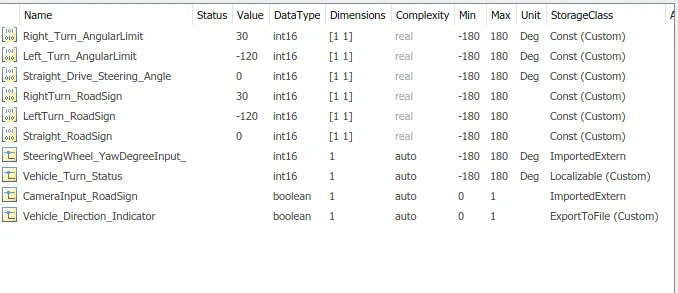
Slld file :IN thesw we write the data .
Results:
Here we compare the three signals with the SteeringWheel_YawDegreeInput .
when we compare ,it checks equal to 30 then it will say to Right_Turn.
when we compare ,it checks less than the -120 then it will say to Left_Turn .
when we compare ,it checks less than the 0 then it will say to Straight_Drive .