Project 1 - Controlling a DC motor using PWM and monitoring its Running status
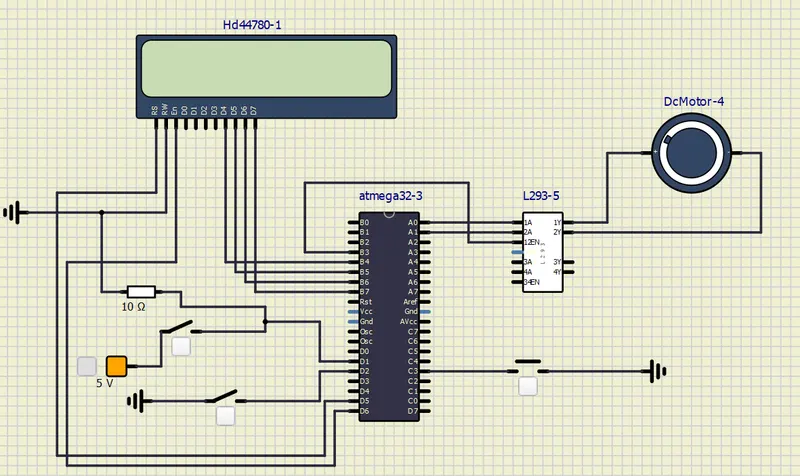
Implement a system on the simulator for controlling a DC motor using L293 motor driver, monitor its status and print the running status of motor on the LCD Display.
Component used in simulIDE: Display, DC motor, L293 motor drive, Switch, ATmega32, fixed volt,Ground.
Goals:
- Implement a system on simulator for Controlling the DC motor using L293 motor driver.
- Displaying the running status of DC motor on the LCD display.
Circuit diagram:
CODE:
/*
* PROJECT1.c
*
* Created: 5/2/2022 12:35:37 PM
* Author : nickd
*/
#include
#define F_CPU 16000000ul // CPU frequency //
#include "avr/interrupt.h" // external interrupt pin //
#include
#define sw_dir (PIND&(1<<1))
#define sw_spd (PIND&(1<<2))
#define pw (PINC&(1<<3))
#define lcd_port PORTB
#define RS_high PORTD|=(1<<5)
#define RS_low PORTD&=~(1<<5)
#define EN_high PORTD|=(1<<6)
#define EN_low PORTD&=~(1<<6)
unsigned char i;
void lcd_cmd(char cmd)
{
lcd_port=(cmd&0xf0);
RS_low;
EN_low;
_delay_ms(1);
EN_high;
lcd_port=((cmd<<4)&(0xf0));
RS_low;
EN_low;
_delay_ms(1);
EN_high;
}
void lcd_data(char data)
{
lcd_port=(data &0xf0);
RS_high;
EN_low;
_delay_ms(1);
EN_high;
lcd_port=((data<<4)&(0xf0));
RS_high;
EN_low;
_delay_ms(1);
EN_high;
}
void lcd_init()
{
lcd_cmd(0x02);_delay_ms(5);
lcd_cmd(0x01);_delay_ms(5);
lcd_cmd(0x0C);_delay_ms(5);
lcd_cmd(0x06);_delay_ms(5);
lcd_cmd(0x80);_delay_ms(5);
lcd_cmd(0x28);_delay_ms(5);
}
void cursorpos( char x, char y)
{
if ((x<1||x>2)||(y>16||y<1))
{
x=1;
y=1;
}
if (x==1)
{
lcd_cmd(0x7f+y);
}
else
{
lcd_cmd(0xBF+y);
}
}
void lcd_out(char x, char y, char *str)
{
cursorpos(x,y);
while ( *str)
{
lcd_data( *str);
str++;
}
}
int main ()
{
DDRB=0xFF;
DDRA|=((1<<0)|(1<<1));
DDRD&=~(1<<1);
DDRD&=~(1<<2);
DDRD |=(1<<5);
DDRD |=(1<<6);
DDRC&=~(1<<3);
PORTD|=(1<<2);
PORTC|=(1<<3);
i=64;
//duty cycle //
TCCR0=0x61;
GICR=(1<
sei ();
lcd_init();
while (1)
{
while(pw==0)
{
if (sw_dir==0)
{
PORTA=0b00000001;
lcd_out(1,1,"Motor is running");
lcd_out(2,3,"clockwise");
}
else
{
PORTA=0b00000010;
lcd_out(1,1,"motor is running");
lcd_out(2,3,"anticlockwise");
}
OCR0=i;
}
PORTA=0X00;
lcd_out(1,1,"motor is off ");
lcd_out(2,3,"caution ");
}
}
ISR(INT0_vect) // interrupt service routine //
{
i=i+20;
}
OUTPUT:
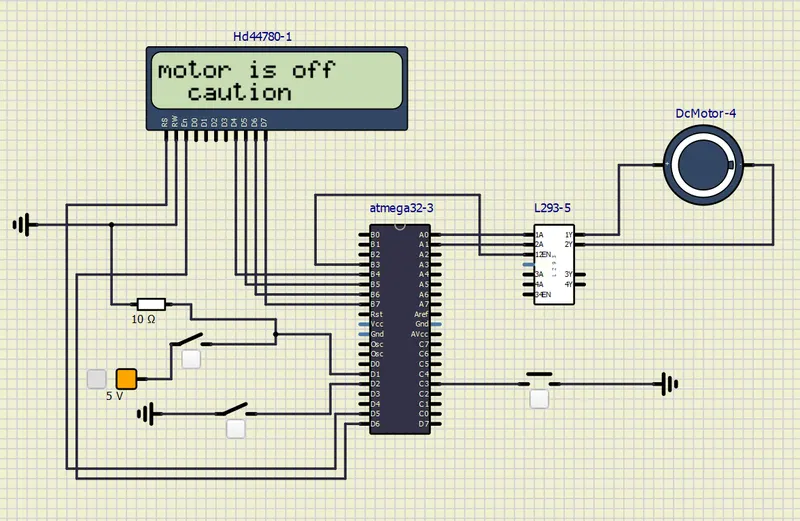
Motor is off condition:
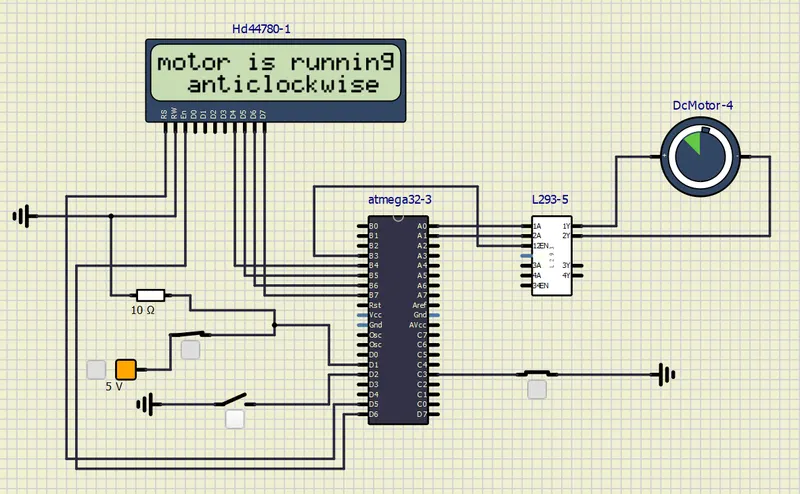
Motor is anticlockwise:
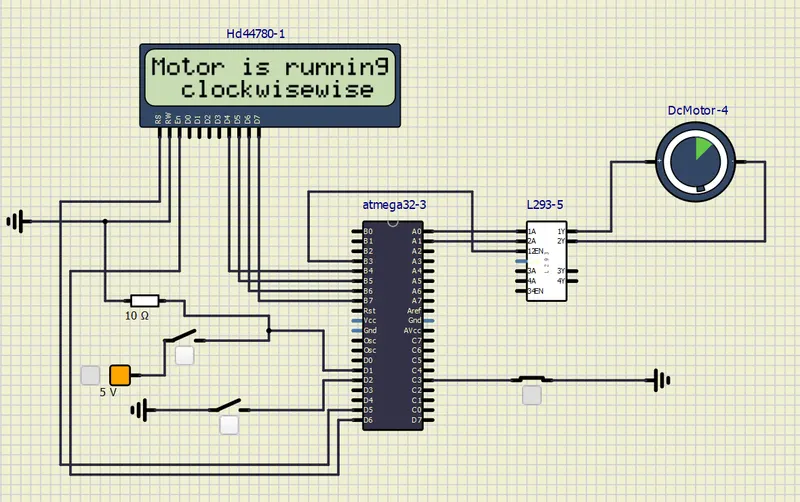
Motor is clockwise :