Project 1
Title: Deals with the development of a forward energy-based fuel consumption model of a conventional vehicle.
Aim:
- Build Simulink model using blocks and complete the vehicle model.
- Writing scripts in MATLAB to load all the variables required for running the Simulink model.
- Tabulate the fuel economy numbers (kmpl) for UDDS and HWFET cycle.
- Plot the time trace for engine, transmission output and wheel speed.
- Plot engine torque, engine power, fuel rate and fuel consumption using subplots.
- Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance using subplots.
- Plot the engine operating points on the engine fuel map.
- Generate the plots for both drive cycles.
- Study of Conventional vehicle Simulink model and creates graphs.
Conventional Vehicle:
Conventional vehicles use an internal combustion engine fueled by gasoline or diesel to power the wheels. In this, the heat engine uses the principles of heat released through the combustion of a fuel with an oxidizer in a combustion chamber to create expanding gases that push against a piston creating forces and torque output.
This vehicle converts chemical energy stored in the fuel into heat which is used to produce useful work. Typically use fossil fuels like petroleum (petrol and diesel).
The most popular type of engine is used in this system is the 4-stroke reciprocating engine. The engine in-cylinder process can be represented by ideal thermodynamics cycles such as the Otto cycle, Diesel cycle. Otto cycle is an ideal cycle process for a spark-ignited SI engine and the Diesel cycle is the ideal cycle that describes the cycle process for a compression ignited CI engine.
Energy and Performance of Vehicle:
This system's true power demand on the wheel needs to be instantly supplied by the powertrain. In other words, the power coming from the powertrain dictates the power demand on the wheels as per performance viz, acceleration, speed etc is determined by it.
In this vehicle, the powertrain is consists of an engine connected to the wheels through a transmission therefore the power comes from the engine through the transmission.
Conventional Powertrain Efficiency:
The engine generates power by converting chemical energy stored into mechanical energy by the process of combustion. This process of energy conversion also has efficiency and the energy input is in the form of fuel consumption.
Instantaneous fuel consumption is given as
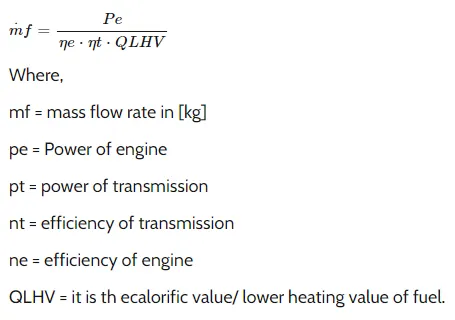
This system of IC engine if true power at the wheels is zero the engine is idling and still consumes some fe=uel to overcome the engine drag loss and keep it spinning this is the idling fuel consumption and know as an idling process. The above-mentioned formula is applicable only when the wheel power is strictly power. When the wheel power is negative either the engine is disengaged and idling or the engine is engaged and providing some engine braking due to the engine drag losses.
The engine is consuming fuel when it is idling but even for engine might be consuming some fuel.
The fuel consumption not only depends on the power requirement at the wheels but also is required to generate power to run the various engine and vehicle accessory loads.
System Dynamics:
It deals with the modelling of the multi-domain system through the use of a unified approach based on an ordinary differential and algebraic equation describing the static and dynamic effects.
Each system has two generalised variables-
- Efforts: It is a generalised force variable. Ex- torque, force, voltage, heating value.
- Flow: It is the generalised flow/velocity variable. Ex- velocity, current, mass flow rate.
- Power: it is the product of the effort and flow variable. It is interchangeable between energy domains.
Energy-based Models- Element models:
To model the internal physical properties of the element and the losses there are basically two kinds of approaches.
- Map-based models: Elements are modelled using maps that characterized the relationship between the input and output, output and losses etc.
- Analytical Models: Elements are models using physical equations that represent the internal dynamics. These are the two extremes most models are a combination of the two with some dynamics models analytically and for some using maps.
In this model we use Forward Model:
It is also known as dynamic simulation. Dynamics models are used for detailed simulations. In this model force/torque/power is the input and the vehicle state variable velocity and acceleration are outputs. The models and simulation are more realistic due to physical casualty hence appropriate for control development. There is a feedback loop to meet the desired vehicle state. It is mainly used to simulate a vehicle on a driving cycle to analyse the dynamic behaviour of the system helps significantly in control development.
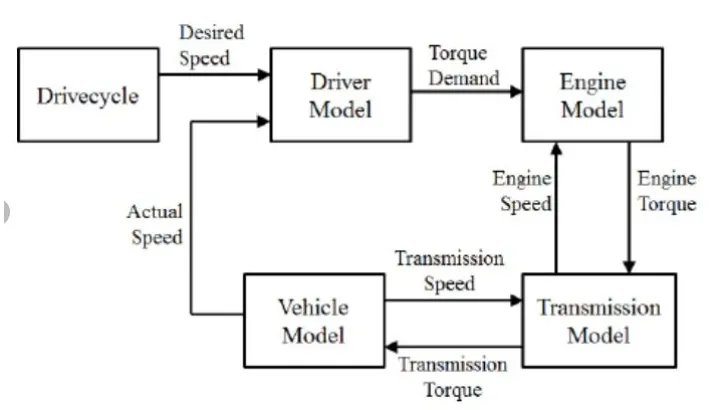
MATLAB Scripts:
Used to load all the variables required for running the Simulink Model and for post-processing. The drive cycle selection is also done here. before running the Simulink vehicle model, run this initialization script.
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model
% By - Harshavardhana G

% Description:

%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model

%% Vehicle Parameters
M = 1500;       % Vehicle weight [kg]
Cr = 0.015;     % Rolling resistance coefficient
Rw = 0.35;      % Rolling radius [m]
Cd = 0.33;      % Drag coefficient
Af = 2;         % Frontal area [m2]
rhoa = 1.225;   % Air density [kg/m3]
Vwind = 0;      % Wind velocity [kmph]
g = 9.81;       % Gravitational acceleration [m/s2]
theta = 0;      % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface

%% Powertrain Parameters
FDR = 3.73;                         % Final Drive Ratio / Diff Ratio
DiffEff = 0.99;                     % Differential efficiency (assumed independent of operating conditions)

NumGear = 4;                        % Number of gears in transmission
TransGear = [1:NumGear];            % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7];  % Corresponding Transmission ratios
TransEff = 0.90;                    % Transmission efficiency (assumed independent of operating conditions)

TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1];   % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1];   % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]

load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map

%% Driver Parameters
Kp = 10;                    % P gain for driver PI model
Ki = 1;                     % I gain for driver PI model
Drive_Cycle_Select = 1;     % Drive cycle selection

% Drive cycle values in m/s

if Drive_Cycle_Select == 1
    load DriveCycles/UDDS;

elseif Drive_Cycle_Select == 2
    load DriveCycles/HWFET;

elseif Drive_Cycle_Select == 3
    load DriveCycles/FTP;

elseif Drive_Cycle_Select == 4
    load DriveCycles/US06;

elseif Drive_Cycle_Select == 5
    load DriveCycles/NEDC;

elseif Drive_Cycle_Select == 6
    load DriveCycles/WLTP;

end

time_end = cyc_time(end);
vel_end = cyc_vel(end);
Now,
let's see the Simulink model of a conventional vehicle,
In this project, a typical midsize car with a 1.9L engine and a 4-speed automatic transmission is considered. Data is taken from the ADVISOR database developed by NRE#L, USA. transmission shift map and controller is taken from Matlab/Simulink example database.
The model developed has the capability to simulate the vehicle on different drive cycles like UDDS, HWFET, FTP, NEDC, etc.
"Project1_InitFile.m" is a Matlab script used to load all the variables required for running the Simulink model and for post-processing. The drive cycle selection is also done here. Before running the Simulink vehicle model, run this initialization script.
Driver Model:
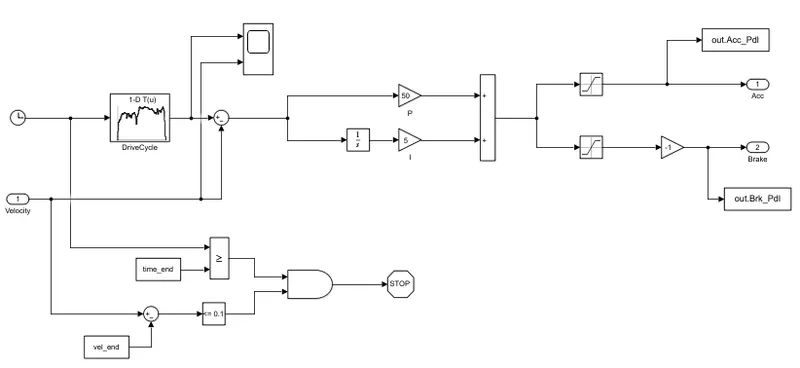
It is modelled using a 'Driver' block, which is a basic PI controller that generates accelerator and brake pedal outputs to match the desired and actual vehicle speeds. In this we use drive cycles from the based on these results of fuel consumption and emissions the vehicle gets certified and it also forms a basis pf uniform assessment. It is based on time, velocity then it all integrates and creates an output acceleration pedal and a brake pedal.
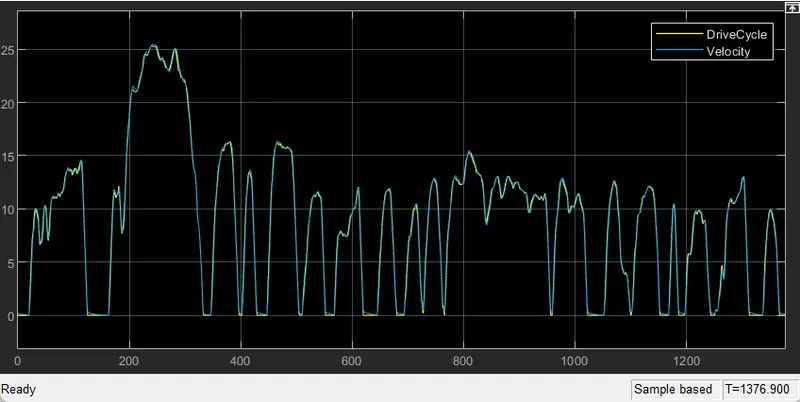
Graph created from Scope in Driver Model:
Control Model:
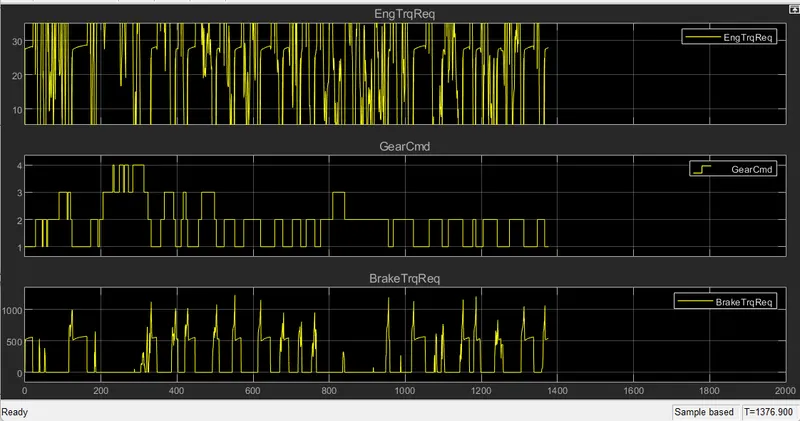
The 'Controller' block is the brains of the vehicle, representing the electronic controls units. It is based on the driver inputs, it generates desired engine torque, desired transmission gear and desired brake torque. These inputs are fed to the 'Powertrain' block which represents the drivetrain of the vehicle.
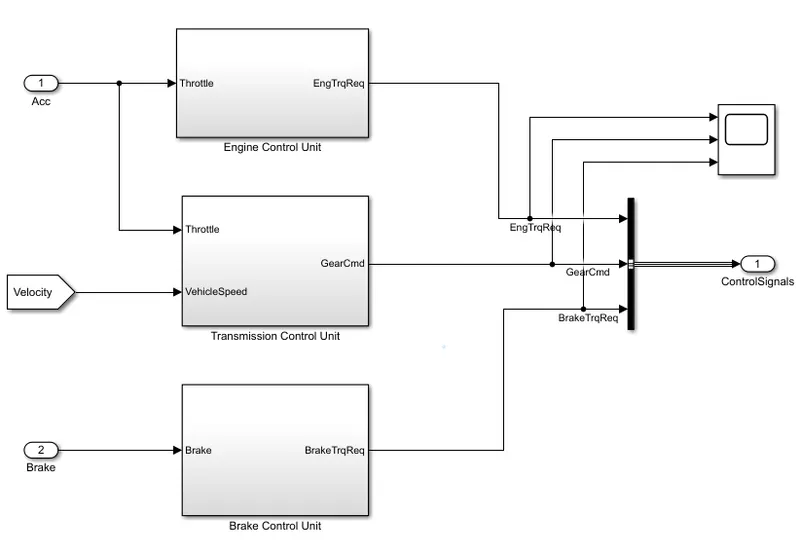
1. Engine Control Unit:
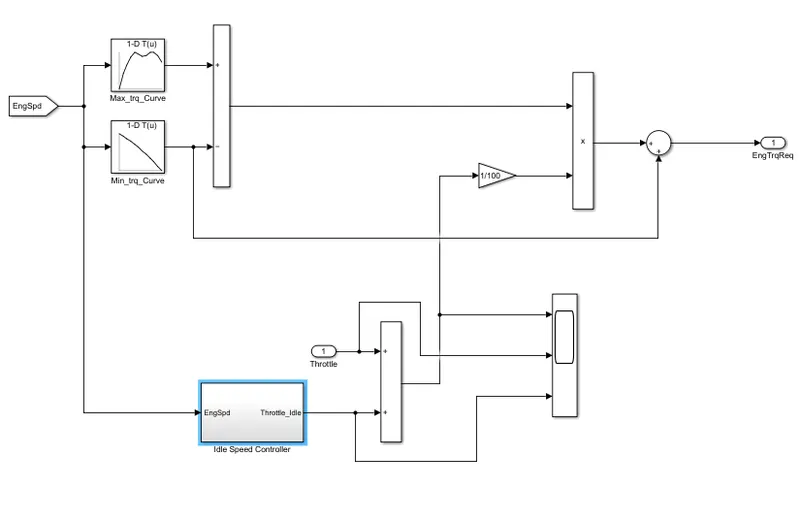
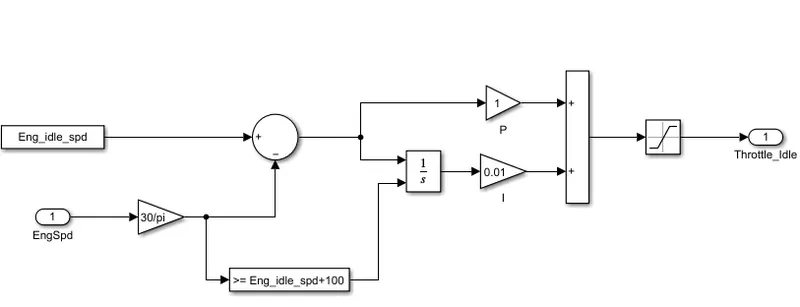
In this control model, we use an engine control unit that gives input Engine speed by creating a lookup table. In that table, we have given input Maximum torque and map speed then also created 2nd lookup table is that give input ct torque and map speed then it subtracts and multiplied. The engine speed also gives to ideal control speed to integrate from this we meet the output of engine required torque.
1(a) Idle Speed Controller:
2. Transmission Control Unit:
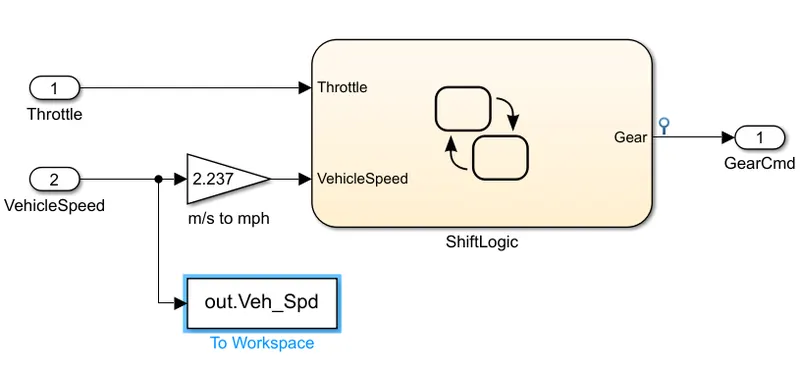
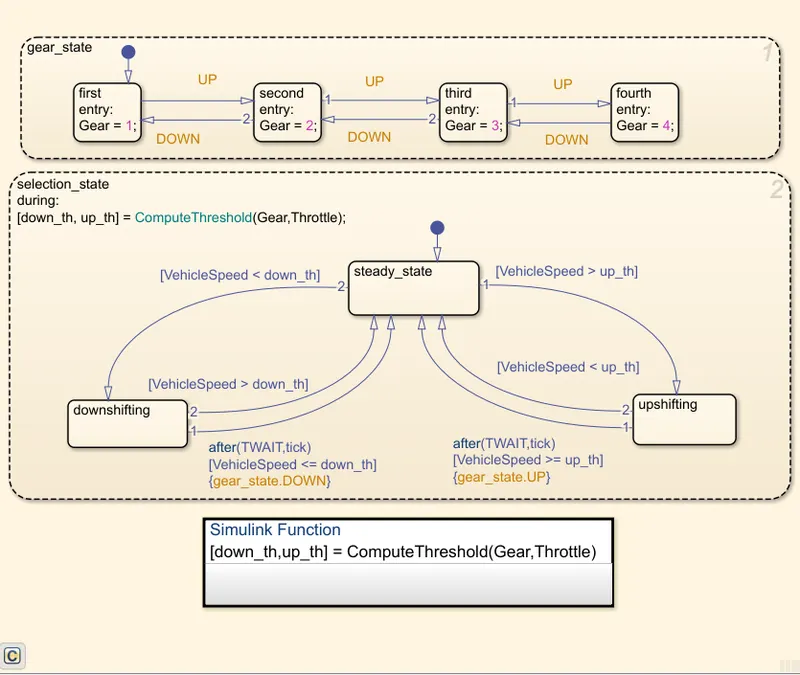
In this unit, we create a steady flow variable state of controlling of gears of the vehicle as in ascending and descending order with respect to time, speed, distance and give input to this steady-state is vehicle speed in m/s to mph.
2(B) Shift Logic:
3. Break Control Unit:
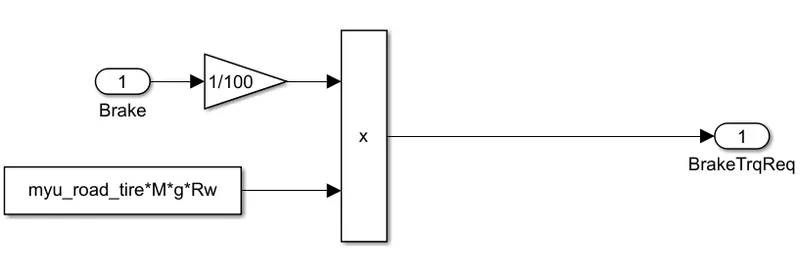
In this, calculate brake torque and then all three control signals output is given to powertrain.
Graph created from Spcope in Control Model:
3. Powertrain:
The Powertrain encompasses every component that converts the engine's power into movement. This includes the engine, transmission, the driveshaft, differentials, axles; basically anything from the engine through to the rotating wheels.
1) Engine:
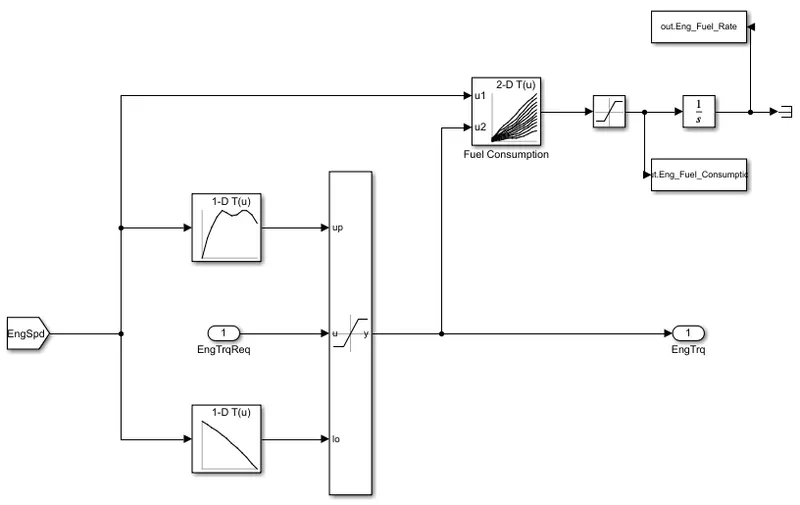
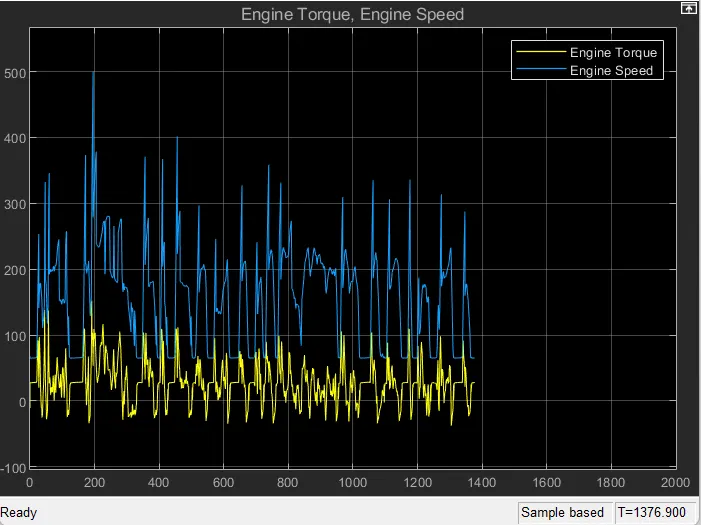
In this model, we used the map-based model to model, the fuel consumption of the engine. it is based on maximum torque and minimum torque from the controller. And then, it saturates torque and gives output and the speed map gives fuel consumption that takes the speed and torque then the output goes into saturated then it is integrated
Graph created from the scope in Engine Model - Engine Torque and Engine Speed
2) Transmission:
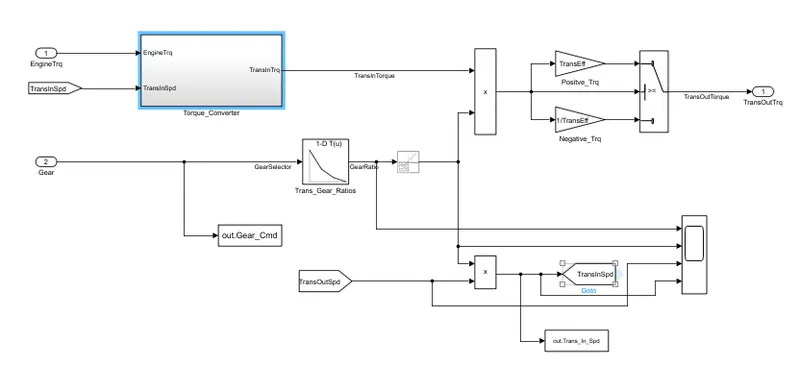
In these models, we engine torque, gear selector from the controller for transmission of gear ratio. The ratio is multiplied by transmission input torque and then the transmission efficiency positive torque and negative torque gives transmission input speed. In this case, the torque converter connects the engine to the transmission it is part of the transmission. It is basically engine dynamics and that is decoupled.
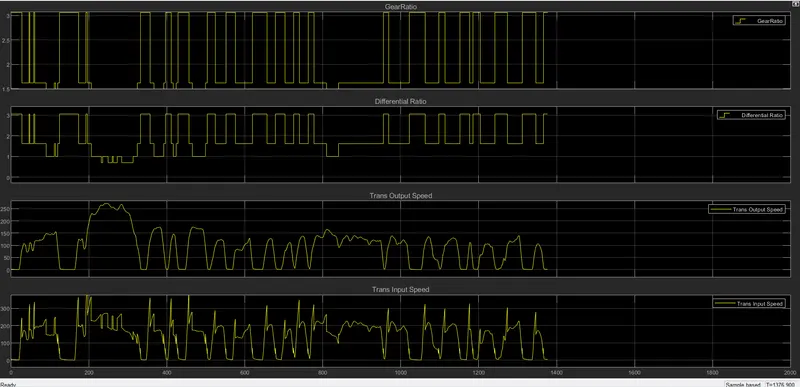
Graph created from Scope of Transmission Model:
1. Transmission 2. Gear ratio 3. Differential Ratio
3) Differential:
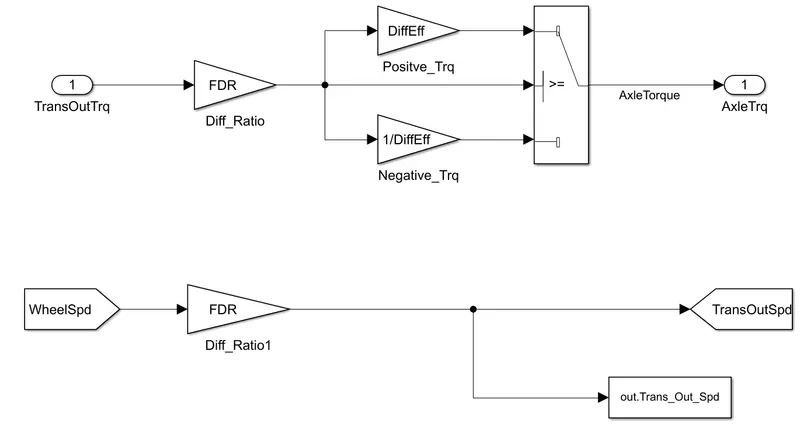
In this taking input is the transmission output then it's going to differential ratio multiplied the output and output torque then meet axel torque. The axel torque is lower than the transmission torque and differential ratio.
4) Wheels:
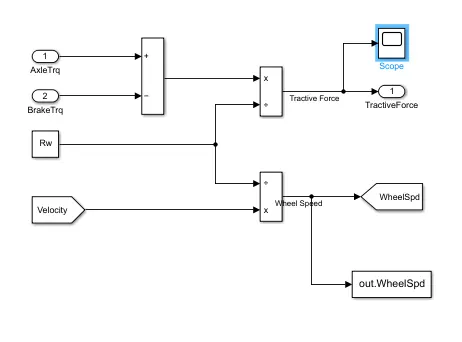
In this model, we take the axle torque from the differential and brake torque from the controller. It is subtracted and multiplied by rolling radius and velocity we meet the tractive force from the axle and brake torque and the wheel speed is met using velocity.
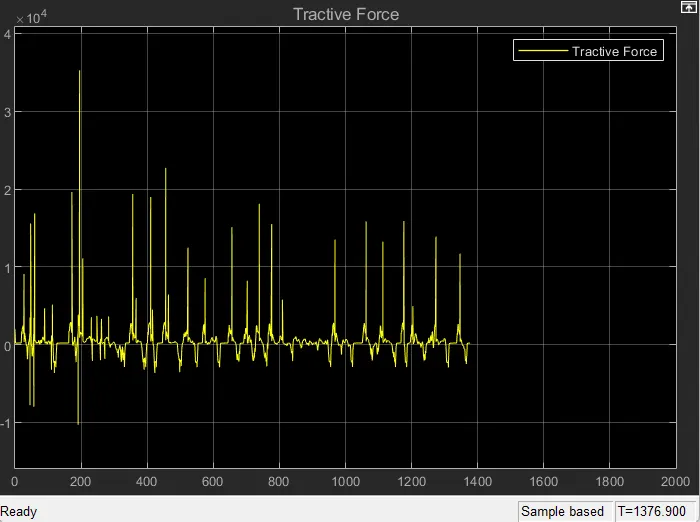
Graph created from Scope of Wheel Model: Tractive Force
5) Vehicle Dynamics:
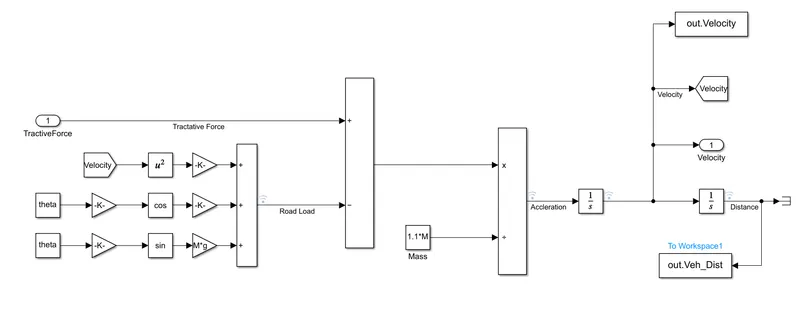
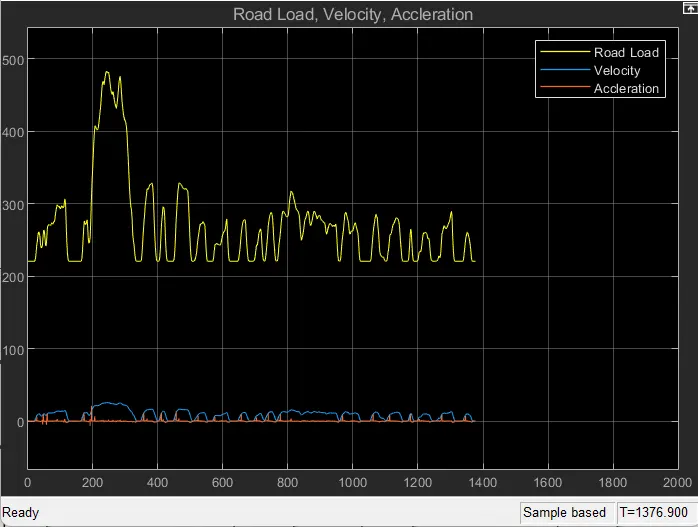
This takes tractive force and road load. it is dictated vehicle sped based on tractive force and road load.
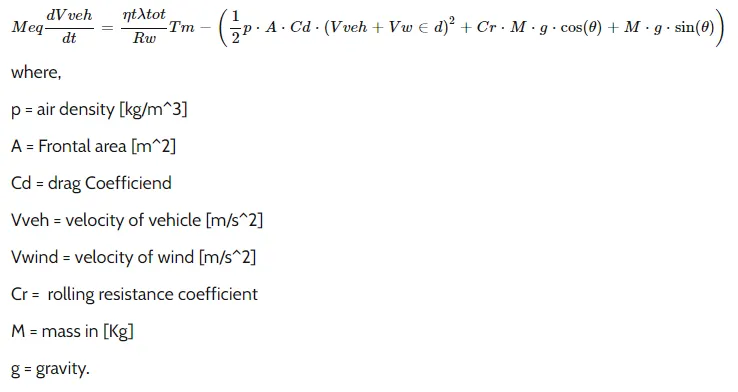
The dynamics equation for calculating road load is
Then we calculate and integrate then we meet the acceleration of the vehicle and velocity of the vehicle it means vehicle distance and vehicle speed.
Graph created from Scope of Vehicle Dynamics Model: Road Load, Velocity and Acceleration
Now, we compute the Fuel economy numbers using UDDS and HWFET cycle:
1. UDDS Drive Cycle
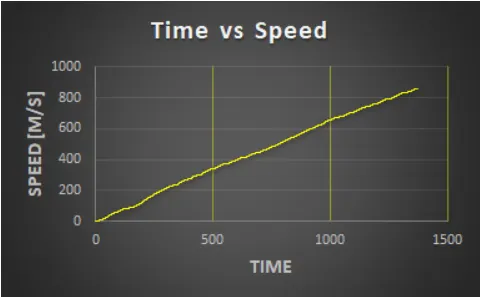
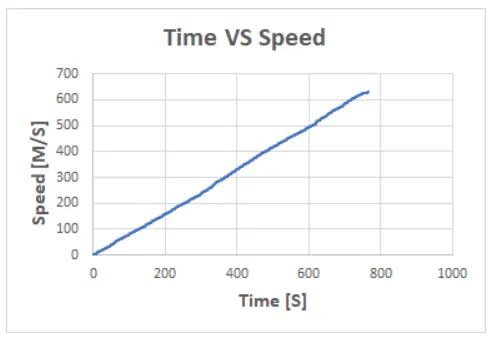
a. Time Vs Speed: In this, the speed is increasing continuously.
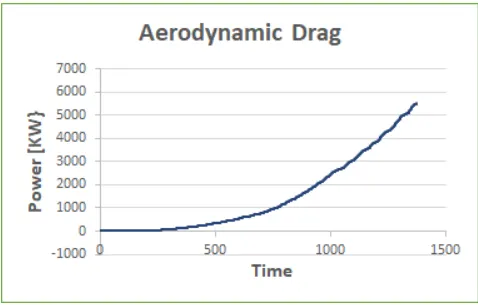
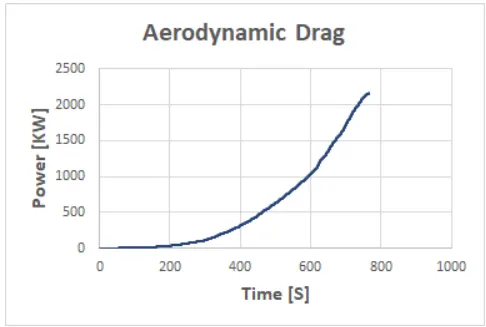
b. Aerodynamic Drag: Drag increase when the power increase.
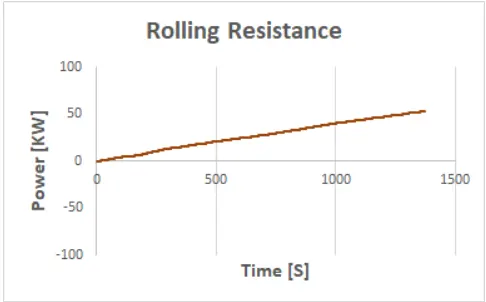
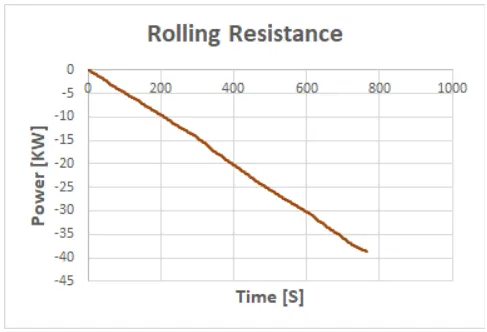
c. Rolling resistance: It also increases when power is increased wrt time.
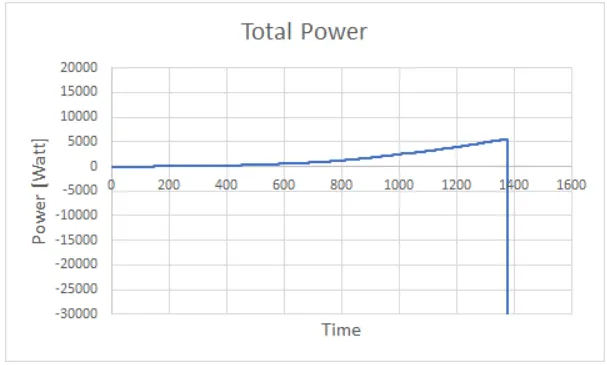
d. Total Power = aerodynamics drag + rolling resistance + inertial resistance
Conclusion:
Total Power is increase slowly as increasing rolling resistance, aerodynamic drag and inertial resistance.
2. HWFET Drive Cycle:
a. Time vs Speed: Speed is continuously increasing wrt time.
b. Aerodynamic Drag: Drag increase when the power increase.
c. Rolling Resistance: Resistance decreases wrt time.
d. Total Power = Aerodynamic Drag + Rolling Resistance + Inertial Resistance
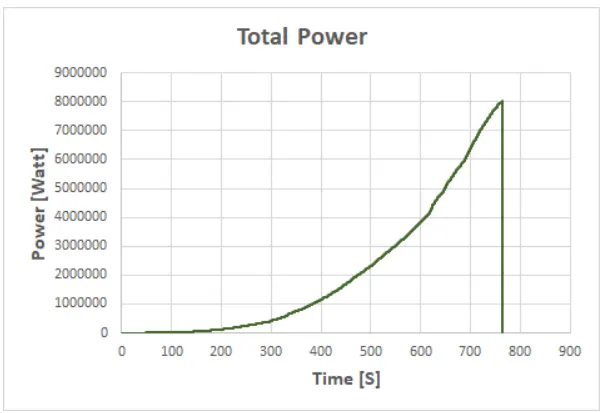
Conclusion:
As comparing both cycles we used to UDDS drive cycle. Its best to asses of fuel consumption and pollutants emission of vehicles in a normalised way.
Now for creating Plots we use MATLAB closing will give down:
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model
% By - Harshavardhana G

% Description:
% The following file is to use with the Initialization file and Simulink
% results for post-processing of the data.
% The file is incomplete has some examples of how the data is imported
% into a readable format, data analysis and plotting examples.
% Based on the project task, use commands in a similar format as given
% below, to analyse the data and generate required plots.
% You can change variable names if desired

%% Post-Processing File
%  File for post-processing the Conventional vehicle simulation model data

%% Renaming variables
Time = out.tout;
Acc_Pdl = out.Acc_Pdl;     %     % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl;     %     % Brake pedal [%]
Gear_Cmd = out.Gear_Cmd;    %    % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi; %  % Transmission input speed [rpm]
Trans_Out_Spd = out.Trans_Out_Spd*30/pi; %   % Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq;       %   % Engine brake torque [Nm]
Eng_Spd = out.Eng_Spd*30/pi;  %  % Engine speed [rpm]
Eng_Fuel_Consump = out.Eng_Fuel_Consumption;    % Engine fuel consumption [g]
Veh_Dist = out.Veh_Dist/1000;  % % Distance traveled by vehicle [km]
Veh_Spd = out.Veh_Spd*18/5;  %   % Vehicle speed [kmph]
Wheel_Spd = out.WheelSpd;  % % Wheel Speed [kmph]
Velocity = out.Velocity; %  % Velocity in [m/s]
Eng_Fuel_Rate = out.Eng_Fuel_Rate; % Engine Fuel Rate

%% Data Analysis
Eng_Pwr = Eng_Spd*pi/30*Eng_Trq/1000;   % Engine brake power [kW]
rho_petrol = 0.7197;                    % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol);    % Fuel economy [kmpl]

Wheel_spd = Wheel_Spd.Data(:,1);
%% Plotting vehicle characteristics Trans Input & Output Speed and Wheel Speed wrt Time
figure ('Name','Trans Input & Output Speed and Wheel Speed wrt Time')
hold on
grid on
plot (Time, Trans_In_Spd, 'linewidth', 1, 'color', 'black');
plot (Time, Trans_Out_Spd, 'linewidth', 1, 'color', 'red');
plot (Time,Wheel_spd, 'linewidth', 1, 'color', 'blue');
ylabel('Speed [rpm]');
xlabel('Time [sec]');
xlim([0, Time(end)]);
ylim([0, 5000]);
legend('Trans Input','trans Output','Wheel Speed');
title('Trans Input & Output Speed and Wheel Speed wrt Time');
%% plotting vehicle characteristics time trace to Engine speed, Engine Torque, Engine power, and Engine Fuel Rate, Engine Fuel Consumption
% Data Conversion from Double Timeseries

Eng_spd = Eng_Spd.Data(:,1); % Engine Speed
Eng_trq = Eng_Trq.Data(:,1); % Engine Torque
Eng_pwr = Eng_Pwr.Data(:,1); % Engine Power
Eng_fuel_consumption = Eng_Fuel_Consump.Data(:,1); % Engine Fuel Consumption
Eng_fuel_rate = Eng_Fuel_Rate.Data(:,1); % Engine Fuel Rate
Veh_dist = Veh_Dist.Data(:,1); % Vehicle Distance
Veh_spd = Veh_Spd.Data(:,1); % Vehicle Speed

% Plotting Engine speed, Engine Torque and Engine power
figure ('Name','Engine speed, Engine Torque and Engine power')
subplot(3,1,1)
plot(Time,Eng_spd,'linewidth',1,'color','yellow');
xlabel('Time [sec]');
ylabel('Speed [kmph]');
legend('Engine Speed');
title('Speed wrt Time');
grid on
subplot(3,1,2)
plot(Time,Eng_trq,'linewidth',1,'color','black');
xlabel('Time [sec]');
ylabel('Torque [Nm]');
legend('Engine Torque');
title('Torque wrt Time');
grid on
subplot(3,1,3)
plot(Time,Eng_pwr,'linewidth',1,'color','blue');
xlabel('Time [sec]');
ylabel('Power [kW]');
legend('Engine Power');
title('Power wrt Time');
grid on

% Plotting Engine Fuel Rate and Engine Fuel Consumption
figure('Name','Engine Fuel Rate and Engine Fuel Consumption')
subplot(2,1,1)
plot(Time,Eng_fuel_rate,'linewidth',1,'color','green');
xlabel('Time [sec]');
ylabel('Fuel Rate [%]');
legend('Engine Fuel Rate');
title('Fuel Rate wrt Time');
grid on
subplot(2,1,2)
plot(Time,Eng_fuel_consumption,'linewidth',1,'color','red');
xlabel('Time [sec]');
ylabel('Fuel Consumption');
legend('Engine Fuel Consumption');
title('Fuel Consumption wrt Time');
grid on

%% Plotting Fuel Economy Vs Engine Fuel Consumption
figure('Name','Engine Fuel Economy vs Engine Fuel Consumption')
plot(Eng_fuel_rate, Eng_fuel_consumption,'linewidth',1,'color','black');
ylabel('Fuel Consumption');
xlabel('Fuel Rate [%]');
legend('Fuel Economy vs Fuel Consumption');
title('Engine Fuel Economy vs Engine Fuel Consumption');
grid on
%% Plotting vehicle characteristics of Acc. & Brake Pedal, Trans Input & Output Speed and Gear Command wrt Time
figure ('Name','Acc. & Brake Pedal, Trans Input & Output Speed and Gear Command wrt Time')
subplot(3,1,1)
hold on
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlim([0, Time(end)]);
legend('Accel','Brake');
title('Acceleration & Brake Pedal wrt Time');
grid on
subplot(3,1,2)
hold on
plot(Time, Trans_In_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Trans_Out_Spd, 'linewidth', 1, 'Color', 'red');
ylabel('Speed [rpm]')
xlim([0, Time(end)]);
ylim([0, 6000]);
legend('Trans Input','Trans Output');
title('Trans Input and Output Speed wrt Time');
grid on
subplot(3,1,3)
plot(Time, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Gear');
title('Gear Command wrt Time');
grid on

%% Plotting gear command vehicle distance with actual speed
figure ('Name','Vehicle distance and Actual speed wrt Gear Command')
subplot(2,1,1)
plot(Veh_spd,Gear_Cmd,'linewidth',1,'color','black');
xlabel('Speed [rpm]')
ylabel('Gear')
title('Gear Command wrt Vehicle Speed')
grid on
subplot(2,1,2)
plot(Veh_dist,Gear_Cmd,'linewidth',1,'color','blue');
xlabel('Distance [km]')
ylabel('Gear')
title('Gear Command wrt Distance')
grid on


%% Plotting engine operating points on engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);

figure('Name','Fuel Consumption Map');
hold on
grid on
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);
UDDS Cycle:
1) Plotting vehicle characteristics time trace transmission IN/OUT and Wheel Speed:
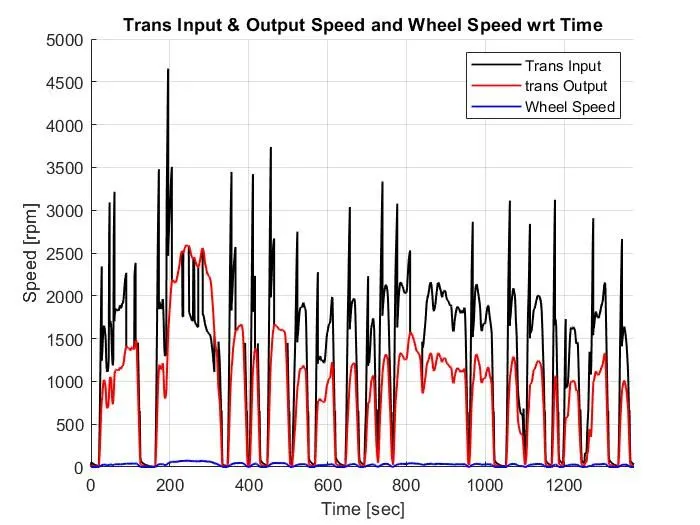
In this graph, transmission input and output will fluctuate up and down with increasing speed and time.
2) Plotting vehicle characteristics time trace to Engine speed, Engine Torque and Engine Power:
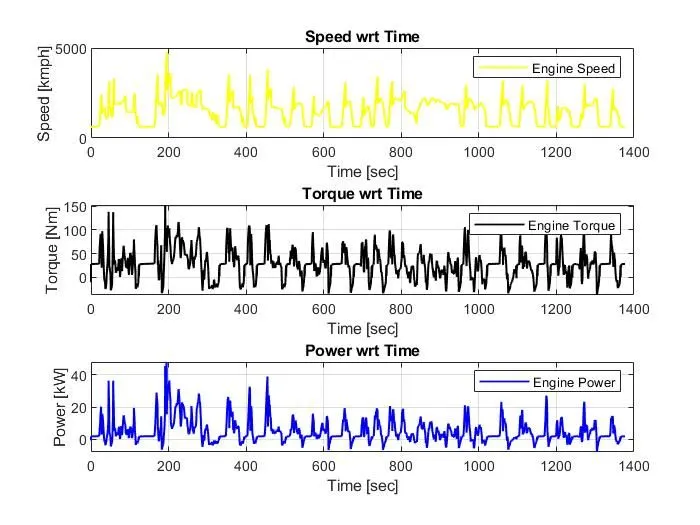
In this engine speed, engine torque and engine power wrt time.
3) Plotting vehicle characteristics time trace to Engine Fuel Consumption and Fuel Rate:
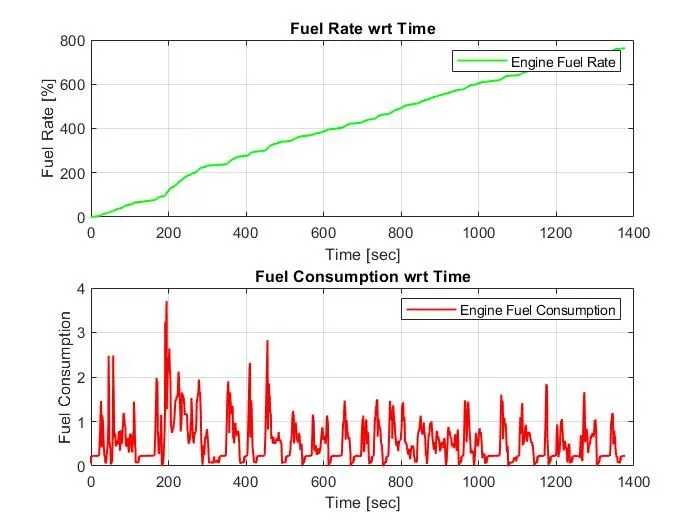
4) Plotting vehicle characteristics for Engine Fuel Economy vs Engine Fuel Consumption.
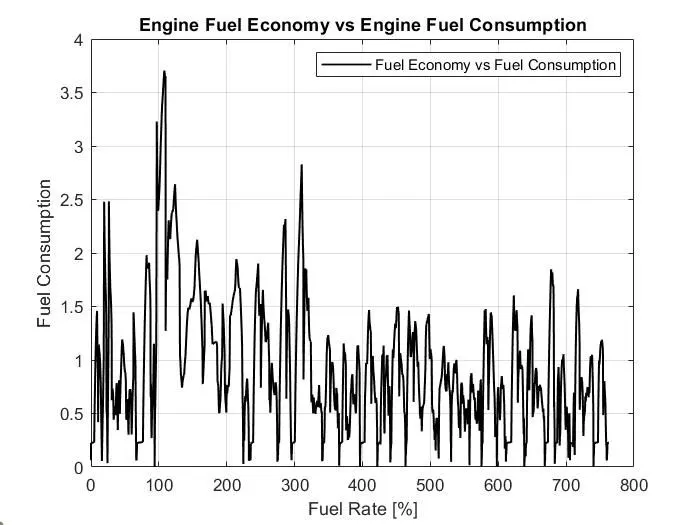
In this, the engine fuel consumption is suddenly increasing as increasing fuel economy but if fuel economy is constant then the fuel consumption is also constant.
5) Plotting vehicle characteristics time trace Acceleration & Brake Pedal, Transmission IN/OUT Speed and Gear Command wrt Time:
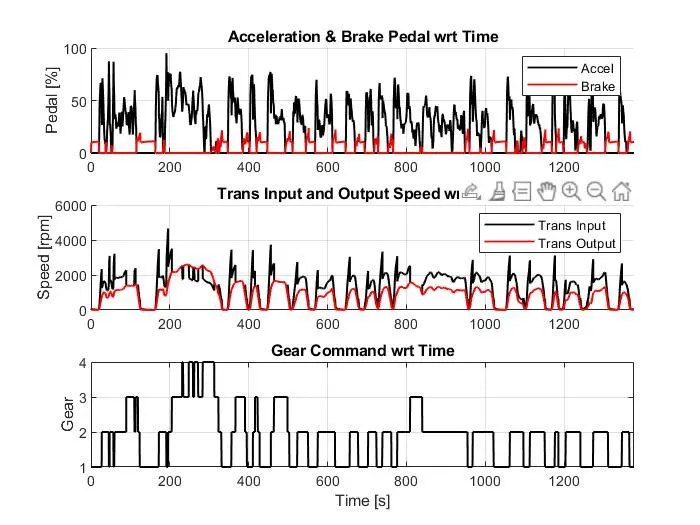
In this, the as comparing brake of the vehicle the acceleration of the vehicle is more so the brake torque is min required and the gear shifting is also required wrt time.
6) Plotting vehicle characteristics Vehicle Speed, Distance wrt Gear Command:
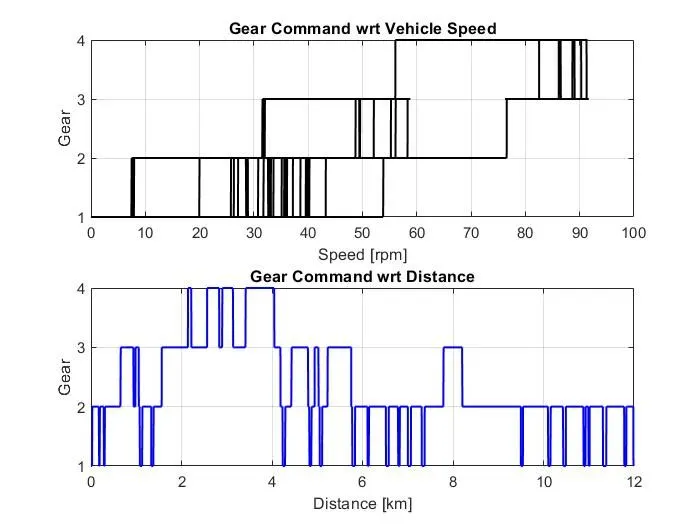
In this the gear shifting is required to increase vehicle speed as shifting order is gear1, then gear2, then gear3 and then gear4.
7. Plotting vehicle characteristics of Engine Operating Points:
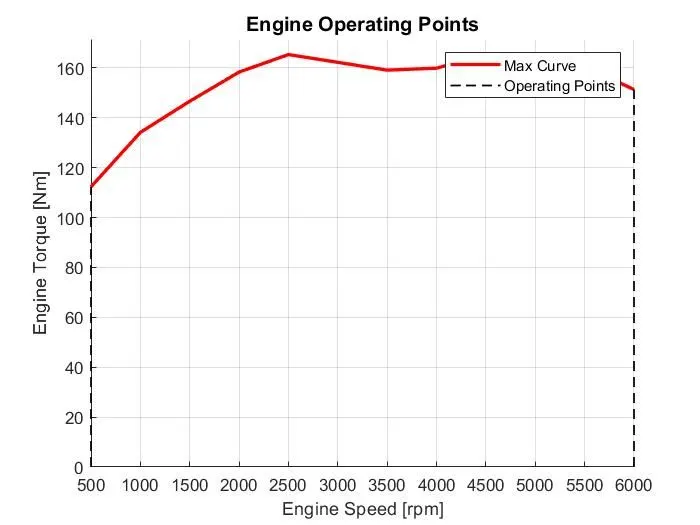
8. Plotting vehicle characteristics for Engine Fuel Consumption Map:
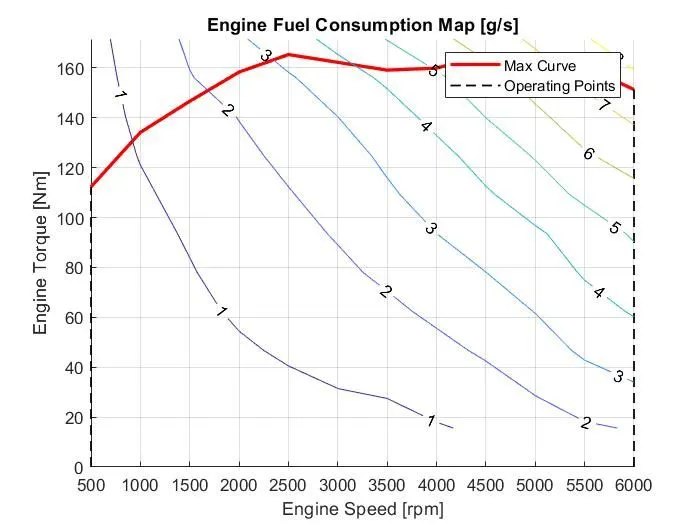
In this the as decrease torque speed is increase.
HWFET Cycle:
1) Plotting vehicle characteristics time trace transmission IN/OUT and Wheel Speed:
In this graph, transmission input and output will fluctuate up and down with increasing speed and time.
2) Plotting vehicle characteristics time trace to Engine speed, Engine Torque and Engine Power:
In this engine speed, engine torque and engine power wrt time.
3) Plotting vehicle characteristics time trace to Engine Fuel Consumption and Fuel Rate:
4) Plotting vehicle characteristics for Engine Fuel Economy vs Engine Fuel Consumption:
In this, the engine fuel consumption is suddenly increasing as increasing fuel economy but if fuel economy is constant then the fuel consumption is also constant.
5) Plotting vehicle characteristics time trace Acceleration & Brake Pedal, Transmission IN/OUT Speed and Gear Command wrt Time:
In this, the as comparing brake of the vehicle the acceleration of the vehicle is more so the brake torque is min required and the gear shifting is also required wrt time.
6) Plotting vehicle characteristics Vehicle Speed, Distance wrt Gear Command:
In this the gear shifting is required to increase vehicle speed as shifting order is gear1, then gear2, then gear3 and then gear4.
7. Plotting vehicle characteristics of Engine Operating Points:
8. Plotting vehicle characteristics for Engine Fuel Consumption Map:
In this the as decrease torque speed is increase.
End...