Project 1
PROJECT:
Develop a double-acting actuator model using Simscape Multibody and Simscape components:
- The Double-Acting Hydraulic Cylinder block in the scissor hoist contains mechanical and hydraulic subsystems.
- The mechanical subsystem models the piston and barrel.
- A Prismatic Joint block provides the translational degree of freedom needed for piston extension and retraction.
- The piston's range of motion is constrained using joint limits.
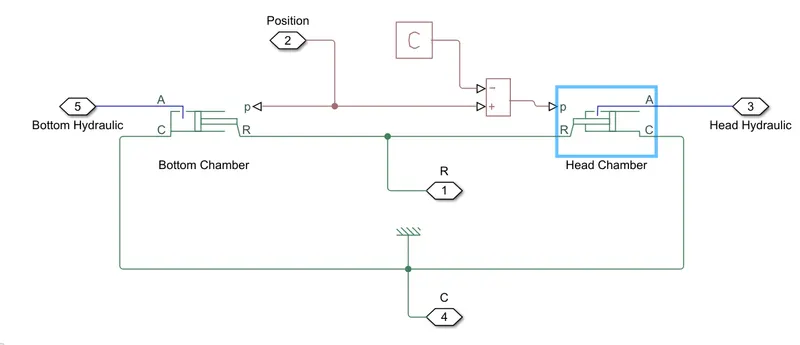
- The hydraulic subsystem contains two Translational Mechanical Converter blocks from the Isothermal Liquid foundation library in Simscape.
- These blocks exchange velocity and force information with the prismatic joint via a Translational Multibody Interface block.
- In addition, both of the converter blocks are configured to accept a physical position signal from the prismatic joint.
- These connections ensure that the state of the hyraulic chambers in the converter blocks are always consistent with the state of the prismatic joint.
MODEL:
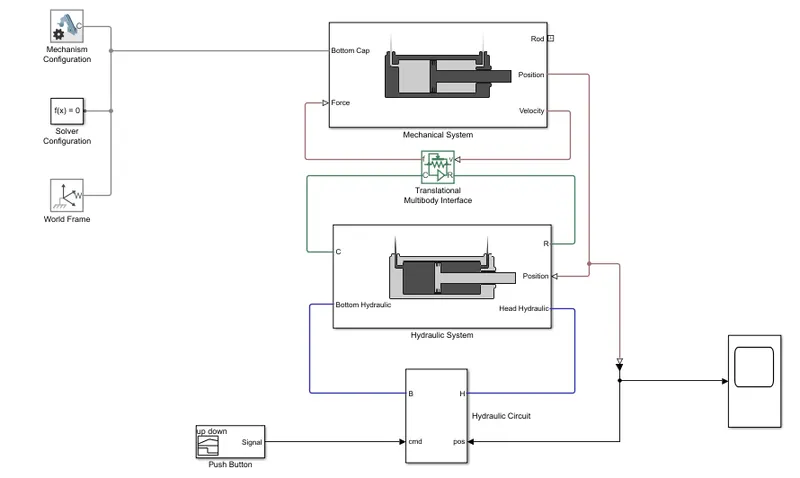
In this model we have main 3 system
- Mechanical system
- Hydraulic system
- Control system
Mechanical system:
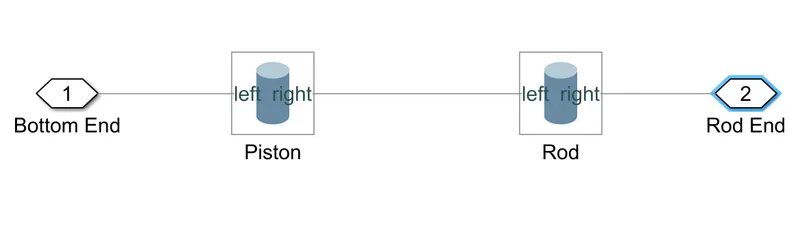
- In this mechanical system we have two assembly one is cylinder and another one is piston.
- this both assembly is connected with prismatic joint.
- A Prismatic Joint block provides the translational degree of freedom needed for piston extension and retraction.
- The piston's range of motion is constrained using joint limits.
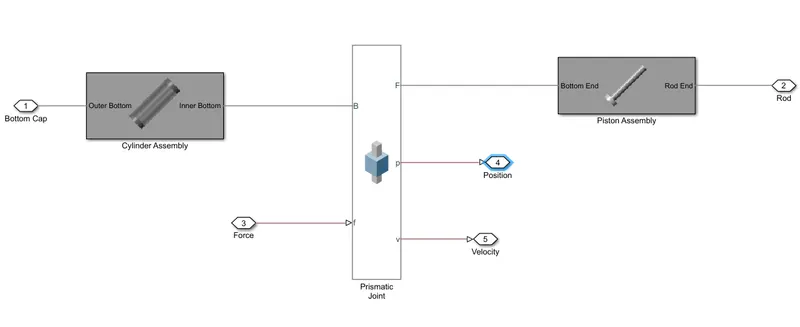
cylinder assembly:
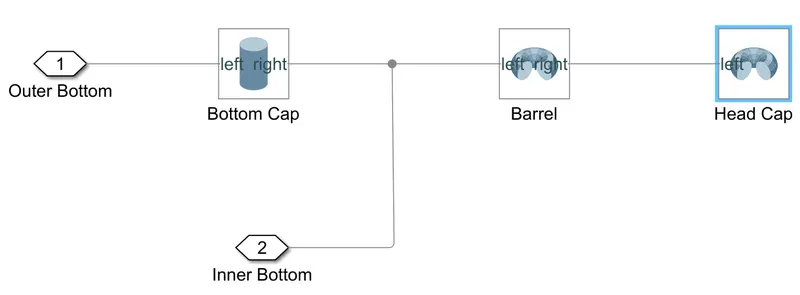
piston assembly:
Hydraulic system:
- The hydraulic subsystem contains two Translational Mechanical Converter blocks from the Isothermal Liquid foundation library in Simscape.
- These blocks exchange velocity and force information with the prismatic joint via a Translational Multibody Interface block.
Control system:
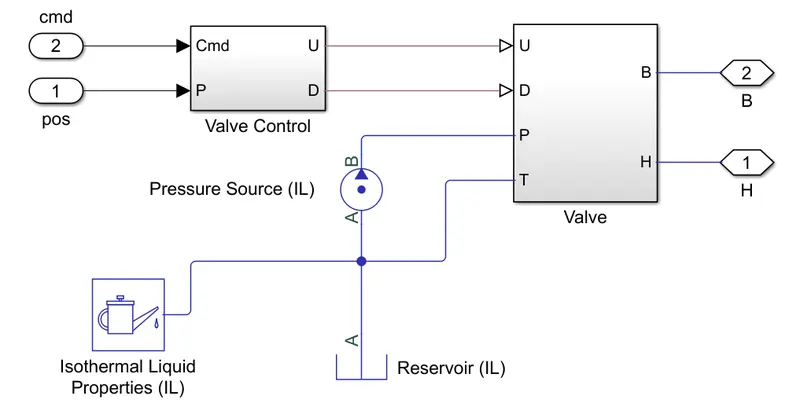
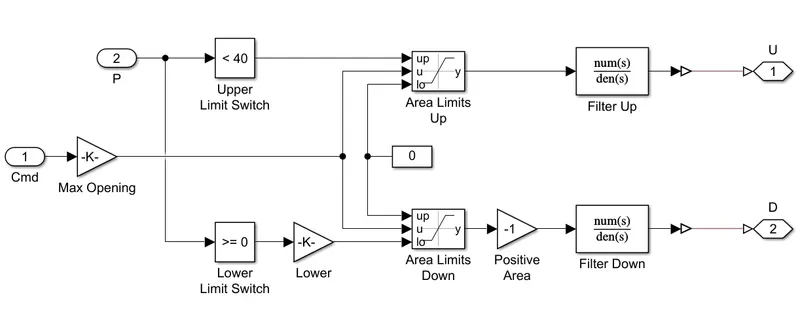
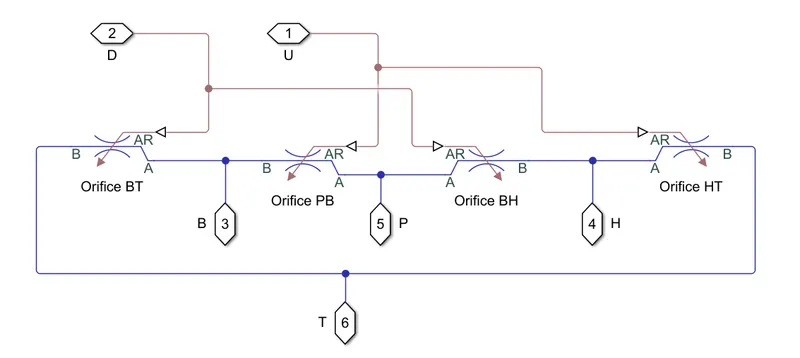
Valve control:
- In this valve control we controling upper and ower limit postion of the piston.
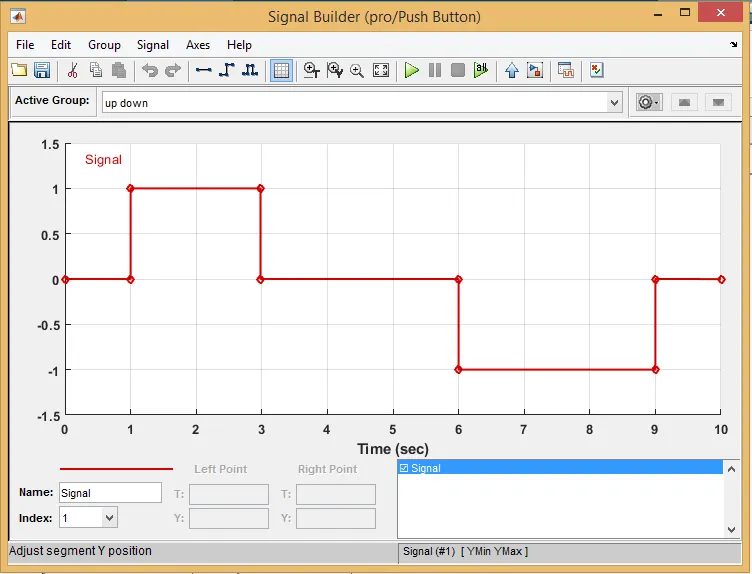
- Its acting as per the input signal
Valve:
Input:
Scope:
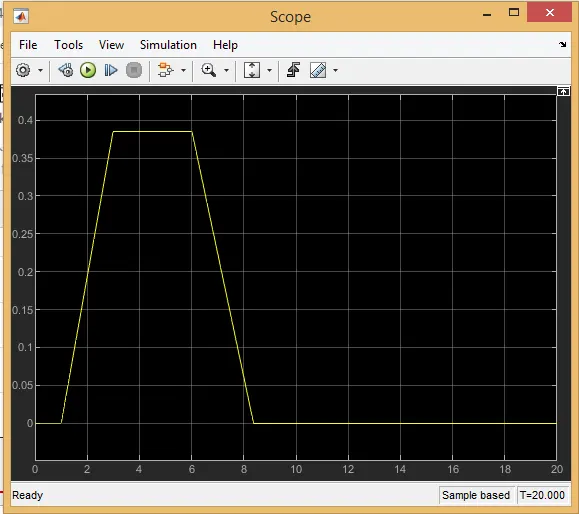
- From this scope in initial position piston is closed at the input signal at zero.
- when the input signal is change from zero the piston move to open from the close position.
Mechanics explorer:
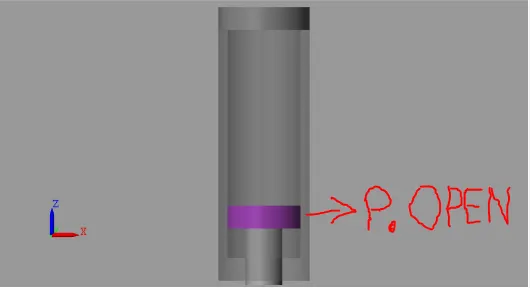
- In the intial condtion piston is close
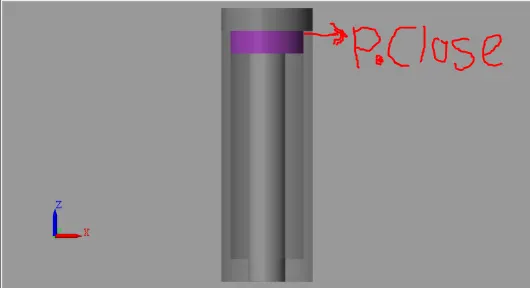
- After input signal move from zero piston move to open from the close postion