Project 1
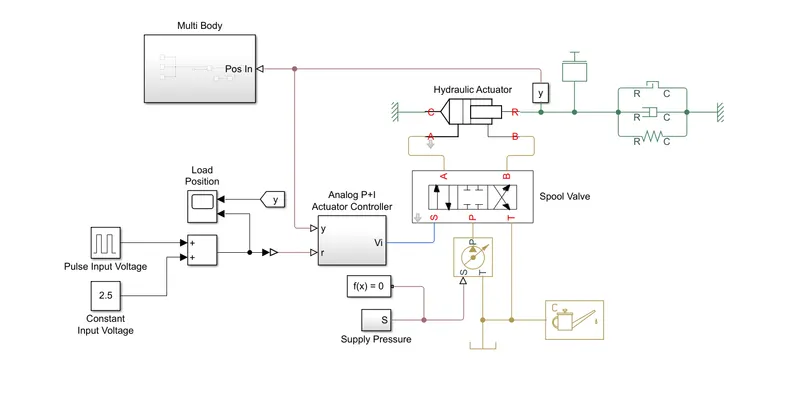
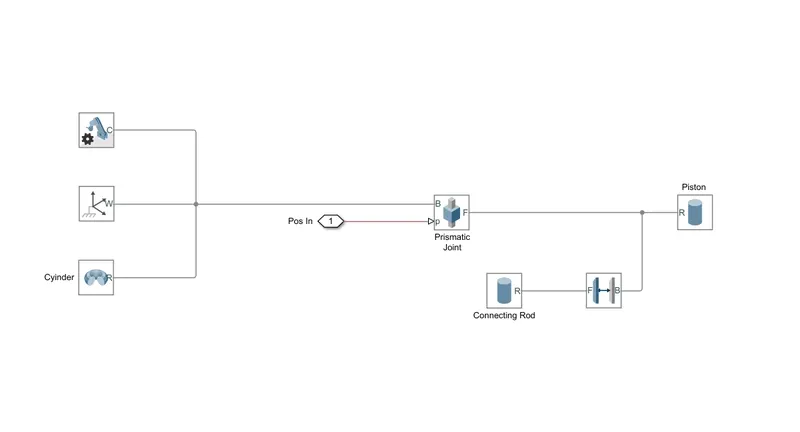
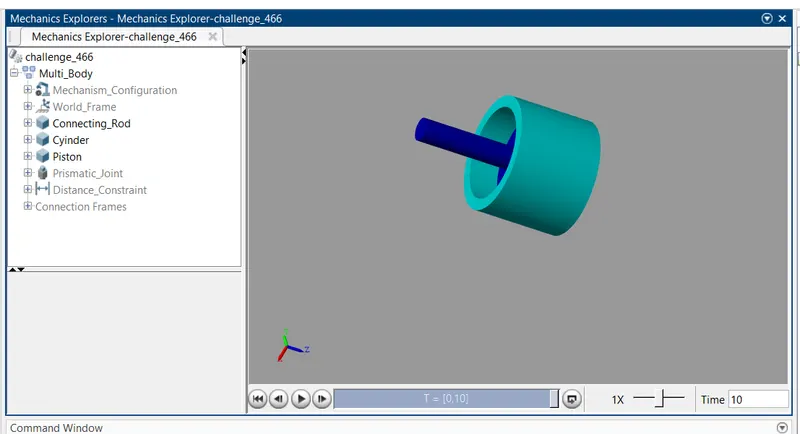
In this model a double acting actuator is modeled using simscape multibody which is hydraulically operated. The hydraulic part of the model is built using simscape. A spool Valve is used to control the direction of the actuator. The input is based on a pulse generator and .The output is verified in the mechanics explorer window
mechanics Explorer
Scope Output
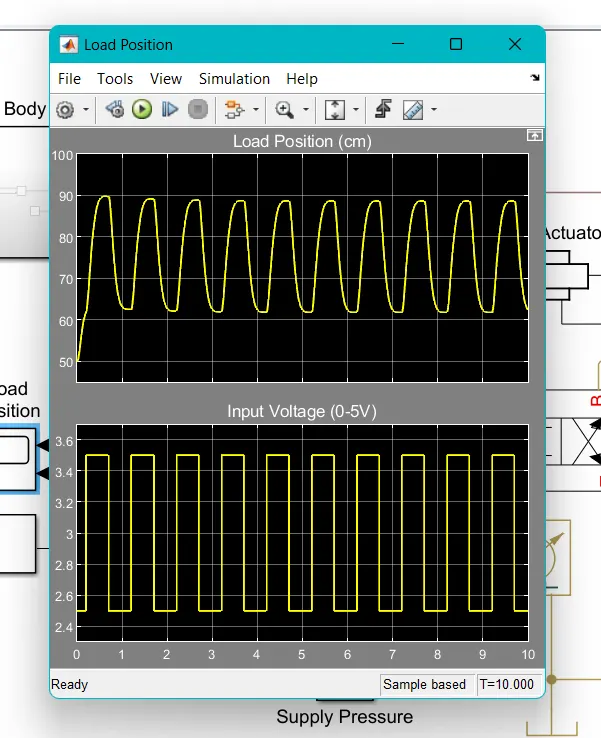
It is observed that the output from the scope and the motion of the piston is observed to be same