Four wheel steering-vehicle Dynamics
AIM:
To study and simulate the 4WS model for steady state.
OBJECTIVES:
- To derive the `delta_f/delta_r` formula for zero side slip.
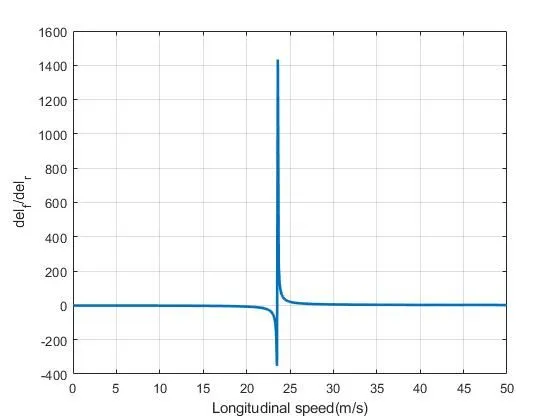
- To plot the ratio against forward speed.
- To infer conclusions from the plot.
Notations used:
m= mass of vehicle
`I_z`= yaw moment of inertia
r= yaw rate
u= longitudinal speed
v= lateral speed
a,b= CG distance from front and rear axle
L= a+b= length of wheel base
`C_{alphaf}`,`C_{alphar}`= front and rear cornering stiffness
`delta_f,delta_r`= front and rear steering angles
Deriving `delta_f/delta_r`ratio for zero side slip:
The state space representation of 4WS vehicle system is given as:
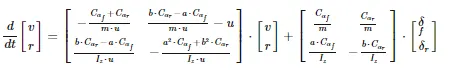
Assuming steady state we get:
`(dv)/dt=0` and `(dr)/dt`
Substituting these we get:
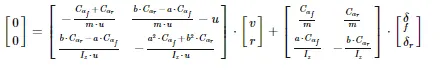
As slip angle `beta=v/u=0`, we get `v=0`
On further simplification we get:
`delta_{f}=frac{a cdot r}{u}+frac{m cdot b cdot u cdot r}{C_{alpha_{f}} cdot L}` and
`delta_{r}=frac{m cdot a cdot u cdot r}{C_{alpha_{r}} cdot L}-frac{b cdot r}{u}`
Ratio of angles is given by:
`frac{delta_{f}}{delta_{r}}=-frac{C_{alpha_{r}}}{C_{alpha_{f}}} cdot frac{(a cdot C_{alpha_{f}} cdot L+m cdot b cdot u^{2})}{(b cdot C_{alpha_{r}} cdot L-m cdot a cdot u^{2}}`
Matlab Code:
% inputs

m=1000;
Iz=1400;        % yaw moment of inertia(kgm^2)
L=2.54;         % wheel base(m)
a=1.14;         % CG distance from kfront axle(m)
C_af=2400*180/pi; % front cornering stiffness(N/rad)
C_ar=2000*280/pi; % rear cornering stiffness(N/rad)
b=L-a;
r=0.5;          % yaw rate

% speed range
u=0:0.1:50;

% steering angle ratio
for i=1:length(u)
    ratio_del(i)=-(C_ar/C_af)*(a*C_af*L+m*b*u(i)^2)/(b*C_ar*L-m*a*u(i)^2);
end

% plot
plot(u,ratio_del,'linewidth',2)
xlabel('Longitudinal speed(m/s)')
ylabel('del_f/del_r')
grid on
Results:
Plot is obtained as shown below and we could see that there is shock wave at 23.5 m/s and 23.6 m/s and these shock waves need to be minimised when vehicle is at low speeds.