Forward Kinematics Of A 2R Robotics Arm
Aim:-To Write A Mat-lab Program On Forward Kinematics Of A 2R Robotics Arm And Creat A Animation File.
Objective:-Our Main Objective Is That How The End Effector Varies With Different Value Of Theta For Both Link So That We Could Get The Required Work Space Of Manuplatar And Make Animation Of 2R Robotic Arm.
Theory:- A Robotic Arm Is Machine Which Is Capable Of Doing Work As Instruction Is Given To It .Robotic Arm Find Lots Of Application In The Manufacturing Industry As Well As Assembly Line. It Consists Of Link Joint End Effector And Control Unit.The End Effector Motion Is Defined By The Movement Of The Subsequent Links.First The Motion Is Given To The Link (L1) And According To That Link(L2) And End Effector Motion Is Obtained.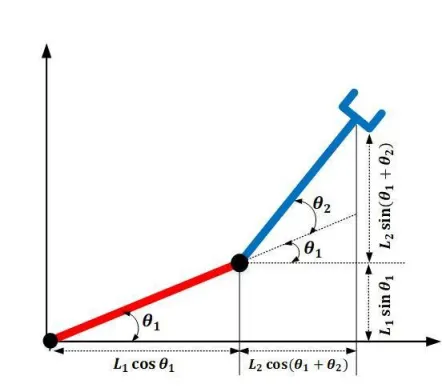
Fig:-Forward Kinematics Of A 2R Robotics Arm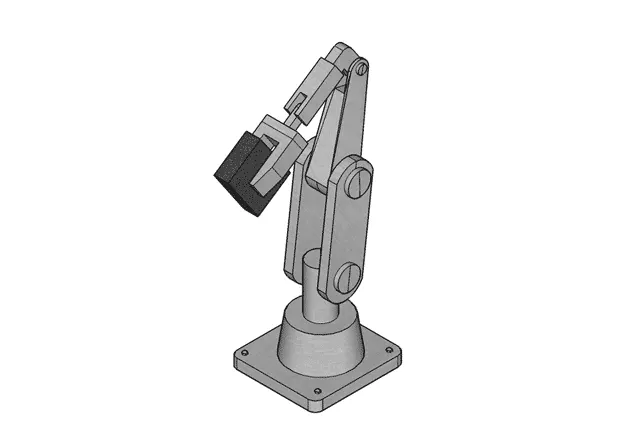
CODE:-
%program for forwad kinemaytics of robotic arm
clear all
close all
clc
%input
l1=1;
l2=0.5;

theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i=1:length(theta1)
    THETA1=theta1(i);
    for j=1:length(theta2)
    THETA2=theta2(j);

    x0=0;
    y0=0;

    x1=l1*cosd(THETA1);
    y1=l1*sind(THETA1);

    x2=x1+l2*cosd(THETA2);
    y2=y1+l2*sind(THETA2);

    %plotting

   plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
   axis([-0.1 2 0 2])
   pause(0.01);
   grid on
   M(ct)=getframe(gcf);
    ct=ct+1;


    end
end

movie(M)
videofile = VideoWriter('forward_kinamatices.avi','uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
OUTPUT:-
IN OUTPUT WE HAVE GET WORKING RANG OF 2R ROBOTIC ARM
OUTPUT VIDEO LINK
ERROR:-
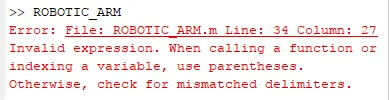
STEPS TAKEN TO SOLVE THIS :- AGIN WATCH THE VIDEO AND PROPERLY WRITE THE COMMAND.
CONCLUSION:-DETRMINE WORK SPACE OF THE ROBOTIC ARM.