Final Project: Electric Rickshaw modelling
In the design of Electric Rickshaw main blocks are Battery, Drive cycle, Controller, DC Motor, Vehicle body & Transmission system. The drive cycle is the input data like how a human drive his actual vehicle here FTP75, WOT & Excel (manually prepared) drive cycles are used to make the designed vehicle to give output how it reacts to the drive cycle. The main objective is to obtain the speed by the driver, to estimate the temperature of motor and controller, to estimate the state of charge, distance travelled by vehicle. There is a SOC block that will estimate the state of charge of the battery, distance is calculated by speed and time parameter for all the tree Drive cycles.
BLOCK DIAGRAM.
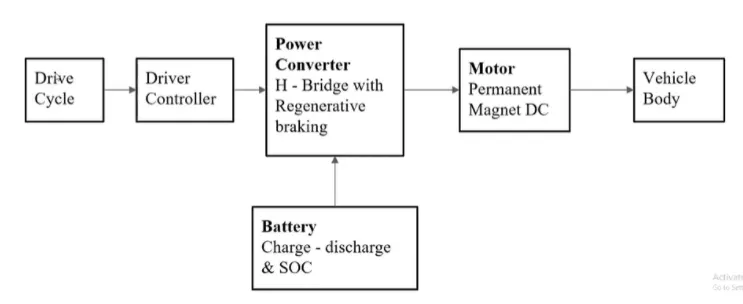
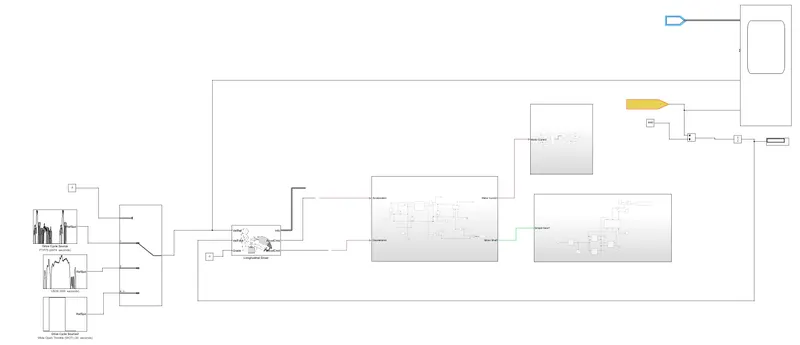
Initially the current flows to the DC motor from the battery through the DC-DC power converter to drive the motor.The required voltage will be controlled in the controller.The controller will follw the given drive cycle reference and run the motor in required RPM. Then Motor power is transmitted to wheels of the vehicle through the gear box and the controller will take the vehicle speed and compare and controlled.
Model Parameters
Drive Cycle:
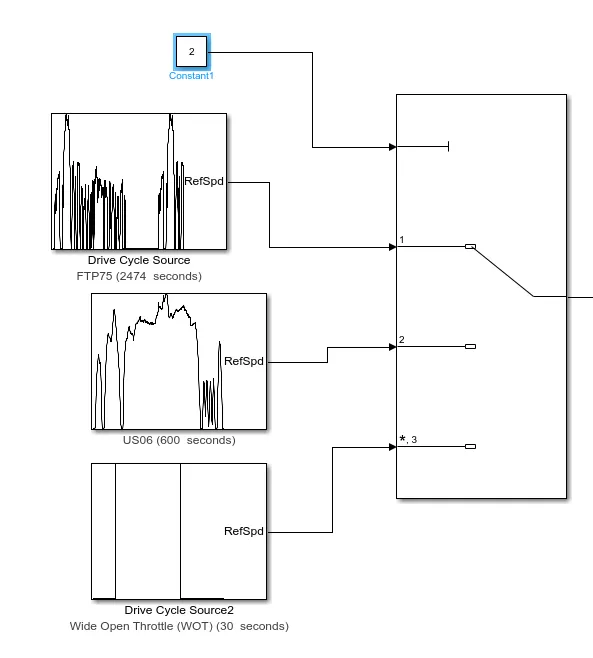
The Drive cycle is assumed as the driver's input of a vehicle it replaced how a driver will drive a vehicle. Here we have used drive cycles which is used to test the vehicle performances.These drive cycle like WOT, FTP75 etc .
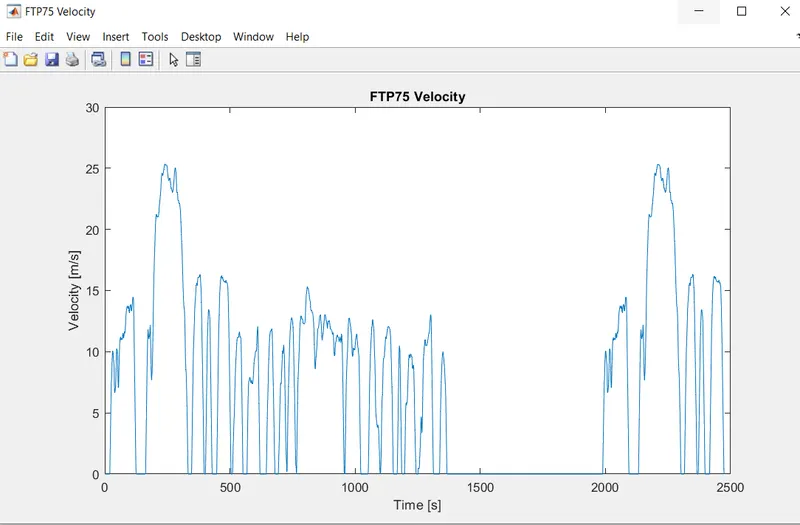
Generates a standard or user defined longitudinal drive cycle. The block output is the vehicle longitunal speed. You can import drive cycle form
Predefined sources
Workspace variable including array and time series objects
mat. xls, xlxx or text files
Ise the fault tracking parametes to identify the drive cycle faults within specified speed and time tolerances.
Driver controller
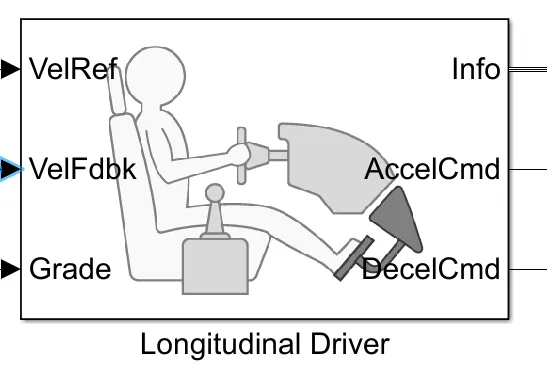
A parametric longitunidal speed tracking controller for generating nomalized acceleration and braking commands based on reference and feedback velocities. use the external actions to input signals that can disable hold or override the closed loop cammands determined by the block. This block uses this priority for the input commands: disable, hold, overide.
Drive cycle is connected to longitudinal driver, it has six ports namely velocity reference, velocity feedback, grade info, acceleration & Deceleration.
VelRef is given by the drive cycle data and VelFdbk is given to the output of the motor. These two will get compare and the acceleration or deceleration output will be given to the motor controller. Accelcmd is given to the PWM generator block and decelcmd is given to regeneratie port of the H- Bridge which uses to generate regenerative braking. Info is used to get any other data from a longitunal driver block. The grade is to give the input of gradeability to the driver block. This block helps to generate regenrate the driver's condition of the vehicle using the drive cycle block.
MOTOR & CONTROLLER
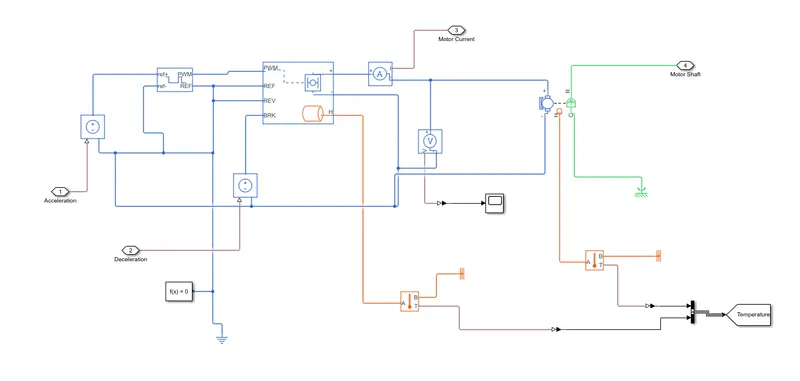
MOTOR TYPE: PMDC Motor
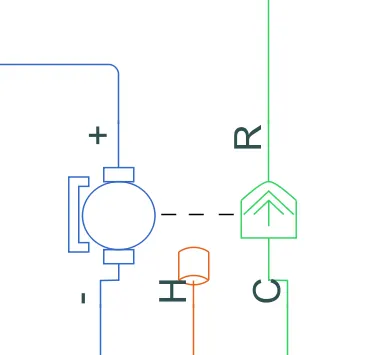
This Block represents the electrical and torque characteristic of a DC motor includes thermal port to sence the temperature of the motor.
The Block assumes that no electromagnetic energy is lost and hence the back - emf and torque constant have the same numerical value when in SI units. Motor parameters can either be specified directly or derived from no load speed and stall torque. If no information is vailable on armature inductance, this parameter can be set to some small non zero value.
When a positive current flow from the eletrical +ve to -ve ports a positive torque acts from the mechanical C to R ports. Motor torque direction can be changed by altering the sign of the back-emf or torque constant.
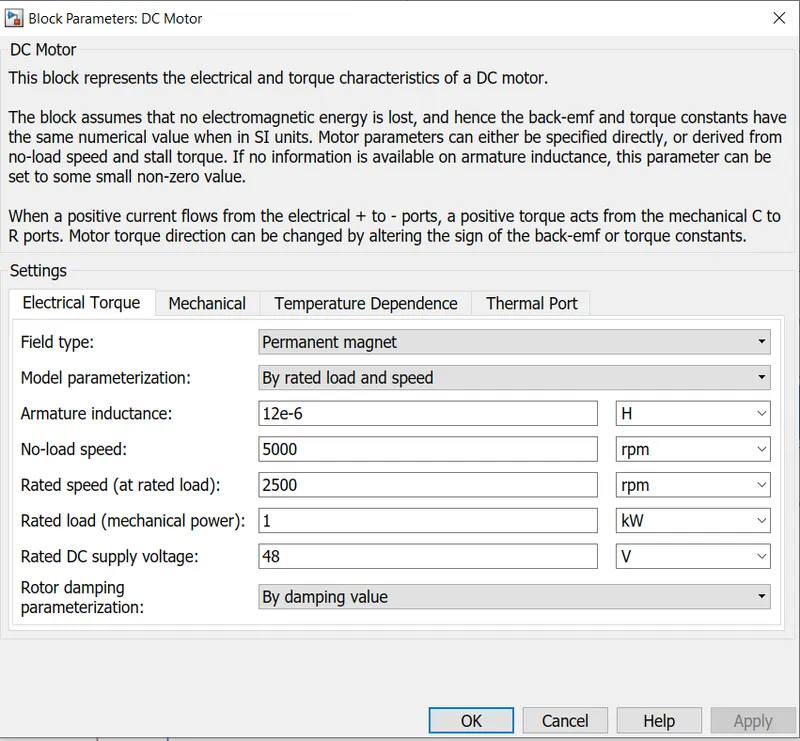
The motor controller will get the input from longitudinal driver.Its task are to control the speed of the motor and drive according to the input of the driver. Majorly motor controlled we designed had two main parts named PWM voltage generator and H- Bridge.
Input1 is getting from the acceleration command of a longitudinal driver and it is given to a controlled voltage source block where it is input to controlled PWM voltage. Controlled PWM voltage will generate the required voltage to operate the DC motor for given driver input.PWM voltage block negative reference and REF are grounded and REF of H bridge respectively.H-Bridge is a motor controller that has IGBT components aligned in the shape of H and will operate only two at a time respectively to the input of the signal from the PWM block. When deceleration occur this h bridge will give an output from the positive and negative terminals of it. These negative & positive terminal are later connected to DC motor and battery. All these component are the simscape electrical components so they need a connection to solver configuration block which helps solve the simulation.
Controlled PWM Voltage source:
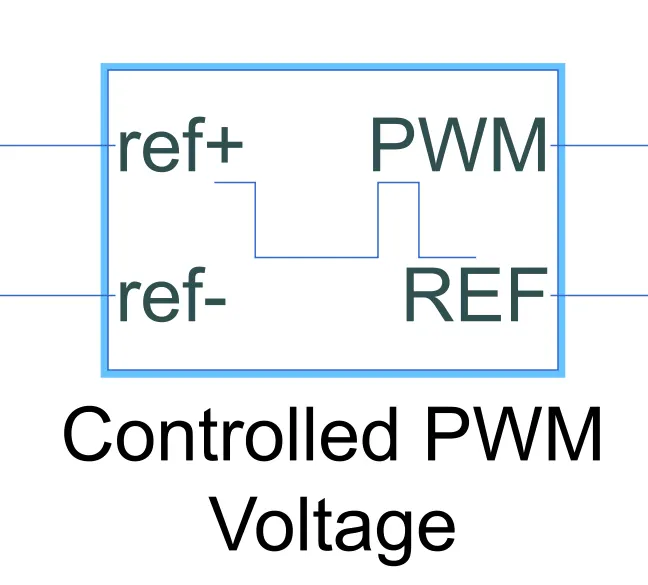
This block create Pulse width modulated(PWM) voltage across PWM and REF ports, The output voltage is zero when the pulse is low and is equal to output voltage amplitude parameter when high. Ducty cycle is set by the input value. Right click the block and select simscape vlock choices to switch between electrical +ref/+ref ports and PS intput u to specify the input value.
At the zero the pulse is initialized as high unless the duty cycle is set to zero or pulse delay time is greater than zero.
The simulation mode can be set to PWM or averaged. In PWM mode the output is a PWM signal. In averaged mode the output is constant with equal to the averaged PWM signal.Select simulation mode as averaged.
Power Converter - H Bridge
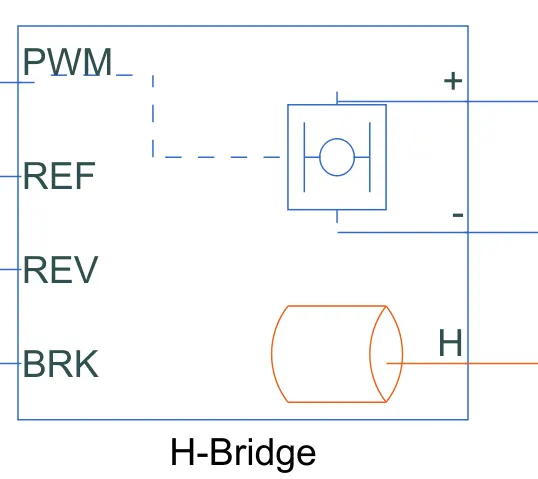
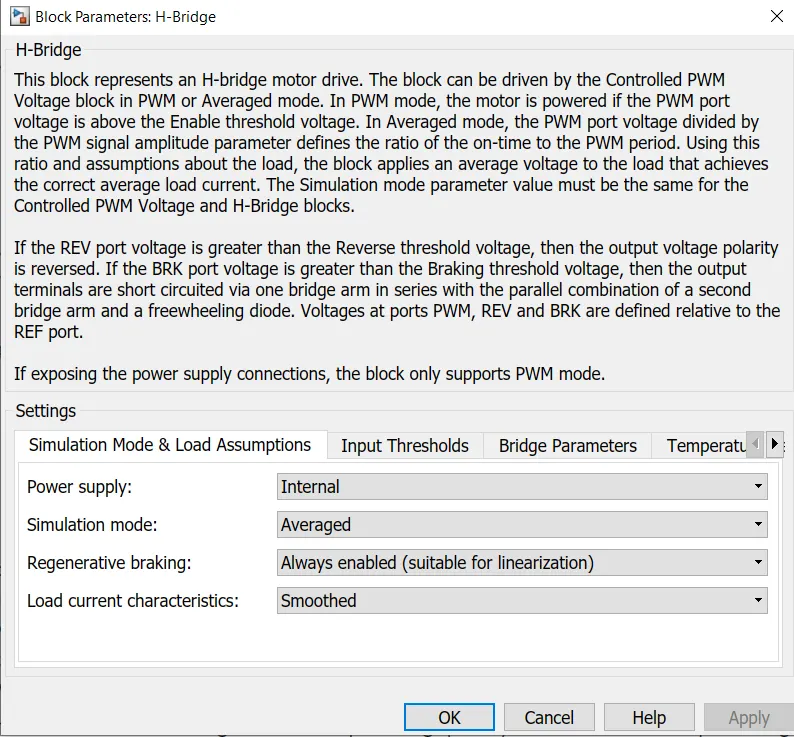
This block represets an H bridge motor drive. The block can be driven by the controlled PWM voltage block in PWM or averaged mode.In PWM mode the motor is powered if the PWM port voltage is above the enable threshhold voltage. In averaged mode the PWM port voltage divided by PWM signal amplitude parameter defines the ratio of the ontime to the PWM period. Using this ratio and assumptions about the load, the block applies an average voltage to load that achieves the correct average load current.The simulation mode parameter value must be the same for the controlled PWM voltage and H bridge blocks.
If the Rev port voltage is greater than the reverse threshold voltage, then the output voltage polarity is reversed. If the BRK port voltage is greater than the braking threshold voltage, then the output terminals are shortcircuited via one bridge arm in series with the parallel combination of a second bridge arm and a freewheeling diode. Voltages at ports PWM, REV and BRK are defined to relative to the REF port.
Temperature Sensor:
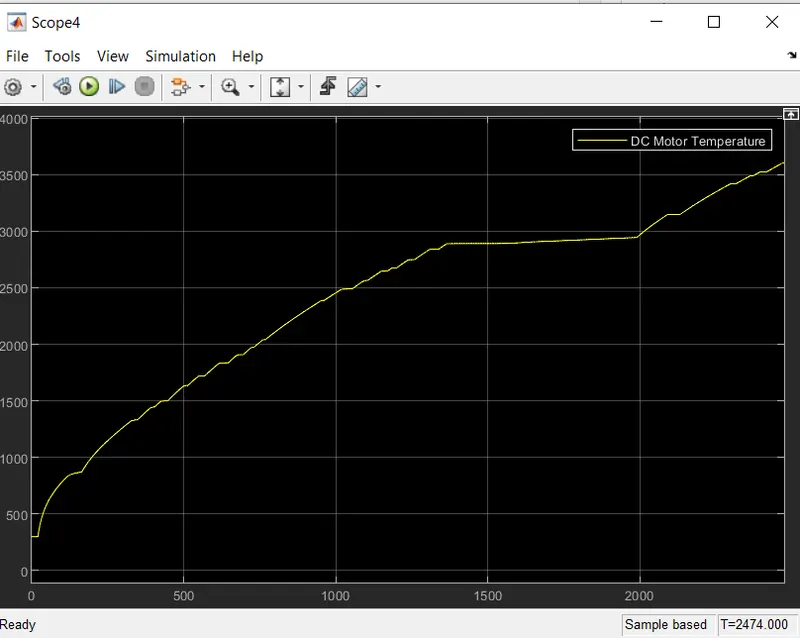
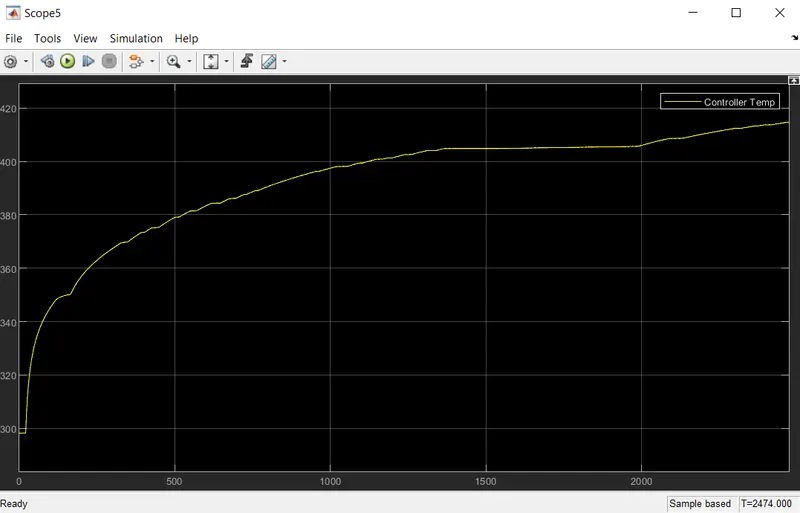
Temperature Sensor is used to measure the temperature of H bridge and motor.
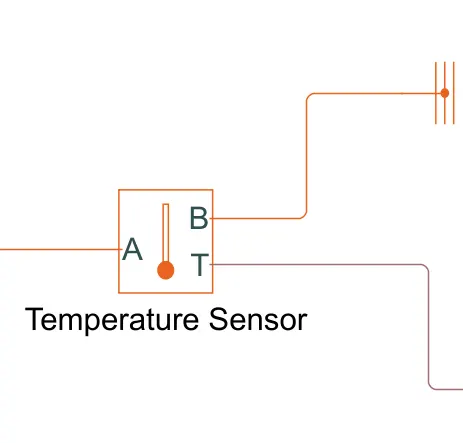
This block measures temperature in a thermal network. There is no heat flow through the sensor. The Physical signal port T reports the temperature difference across the sensor. The measurement is positive when the temperature at port A is greater than the temperature at port B.
Solver Configuration:
Defines solver settings to use for simulation.
References:
-Electrical Reference : Used to ground the all electrical connections
-Mechanical Rotational References: Used to ground all the mechanical rotational Parts.
-Thermal Reference: Used to ground the thermal sensor.
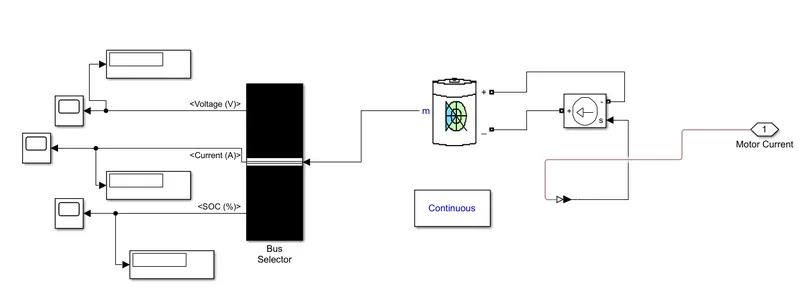
Battery:
Vehicle Body:
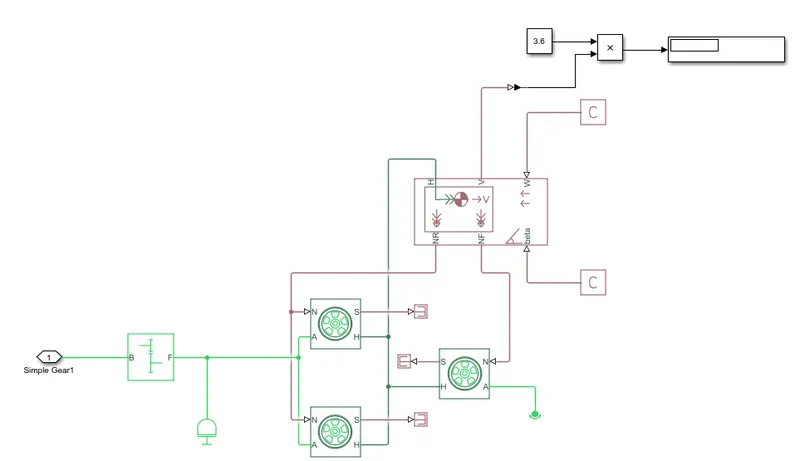
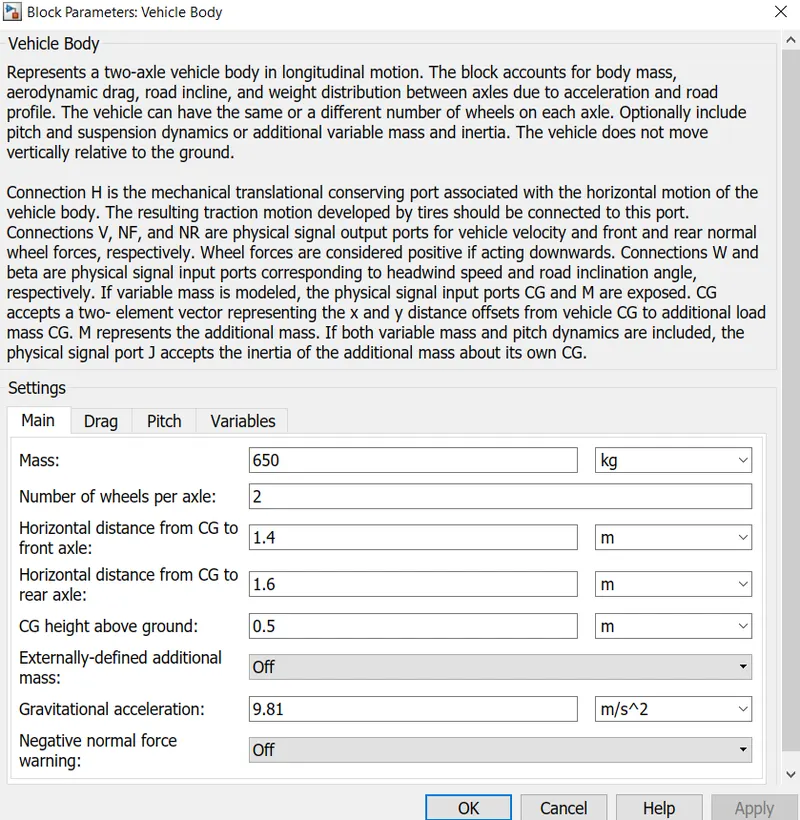
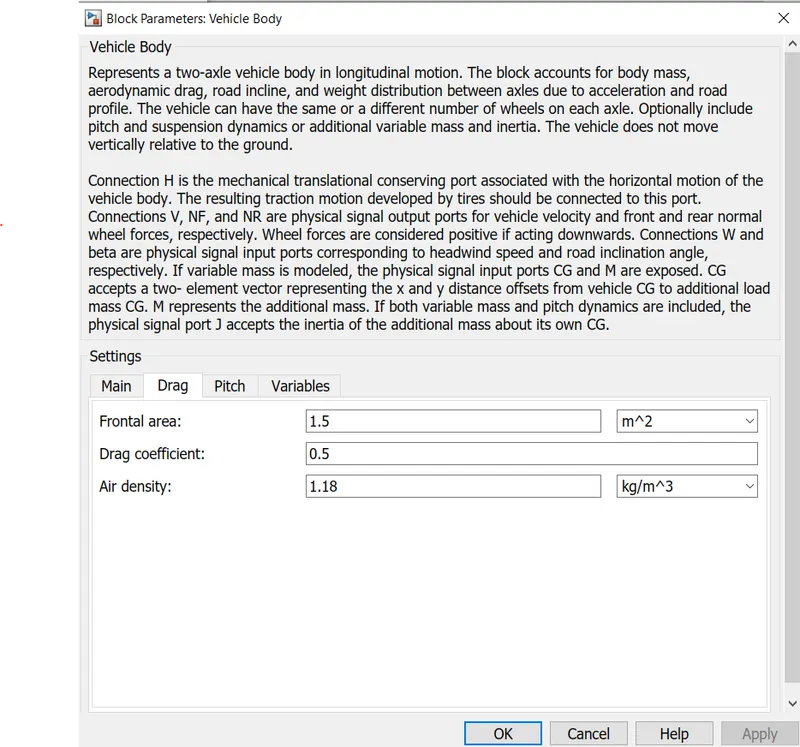
The Vehicle Body subsystem consist of Vehicle Body Block, Tire magic formula block and simple gear block from simscape library. The Tires are connected to a common hub from the vehicle body and axels are connected within the front tire and rear tires. The normal forward force and the normal reverse force are given to the front and rear tires respectively. The wind velocity and the angle of inclination of the vehicle are given. But Here i have not considered angle of inclination. A simple grar block here simulates the transmission system of the vehicle in a simple way.
Vehicle Body Parameters
Results :
For FTP75 DRIVE CYCLE
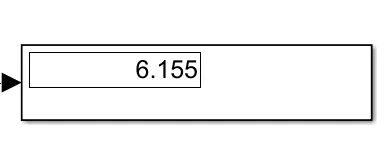
The Distance travelled by running the FTP75 drive cycle is 6.155mph.
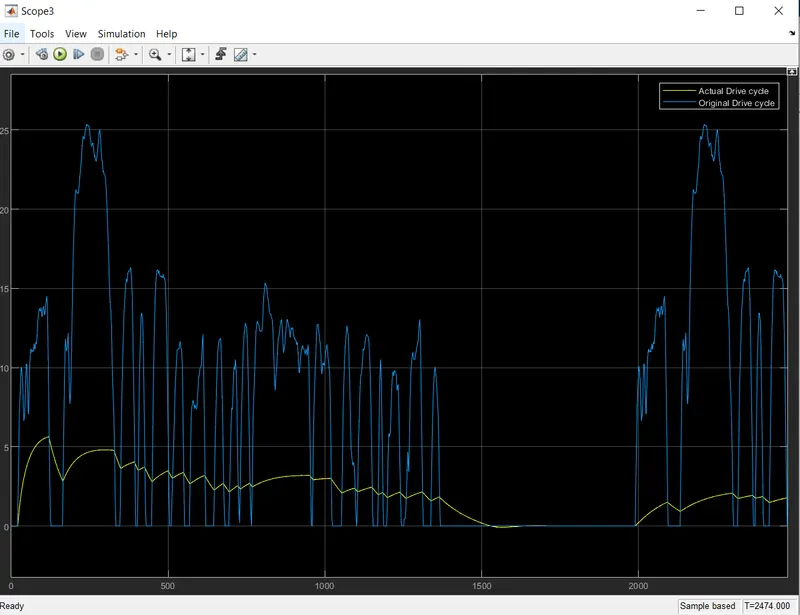
Comaprison between Actual Drive cycle and Original drive cycle.
DC Motor Temperature
Controller Temperature
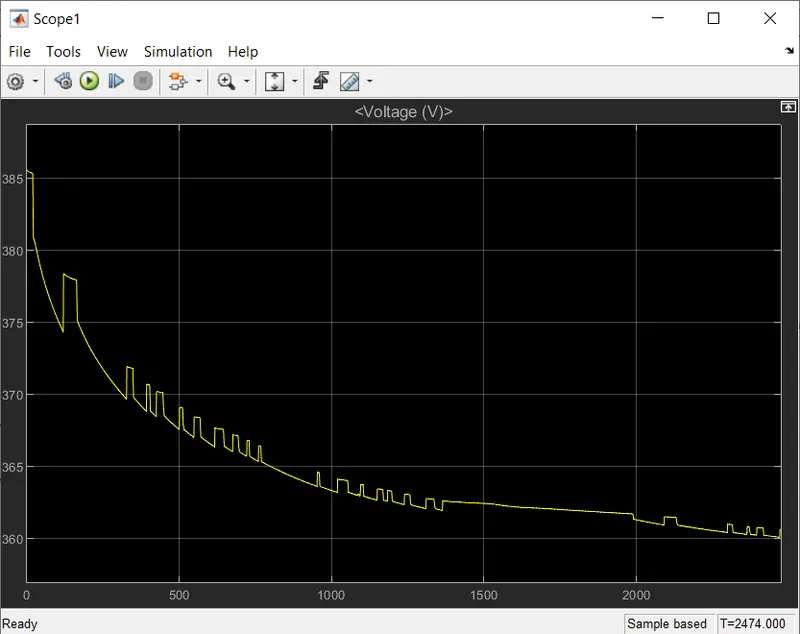
Battery Voltage parameter