Final Project: Electric Rickshaw modelling
Aim:
To Create a detailed MATLAB model of an Electric Rickshaw (three wheel passenger vehicle).
Software used:
MATLAB R2020a (Simulink)
Objectives:
- Rear wheels driven by PM brushed type motor
- Assume efficiency points of motor controller and motor
- Make an excel sheet of all input and assumed data
- Results: For any three standard driving cycles show energy consumption, temperature rise of motor and controller.
A basic layout of the component used in the vehicle itself:
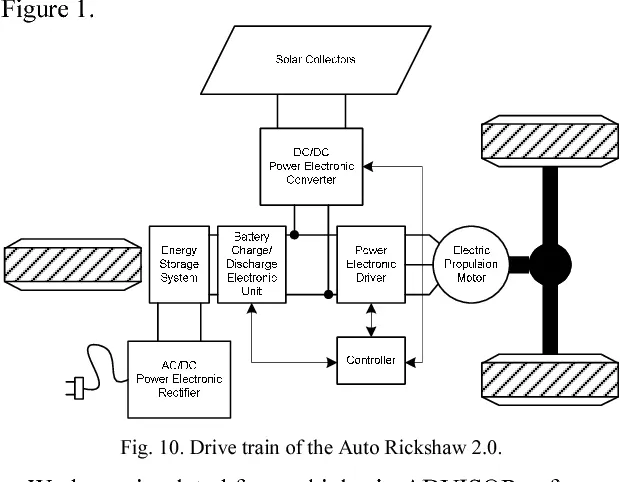
An electric autorickshaw should have the following components to simulate in virtual environment:
1.Drive cycle
2.Battery
3.Driver Configuration
4.Power Controller
5.Motor and Gear system
6.Vehicle Dynamics
An electric rikshaw is combination of above-mentioned subsystems.
MATLAB Model of an Electric Rickshaw:
in the above shown simulink model the blocks that are used are as follows :
- constant block
- ftp75 drive cycle
- wide open throttle
- custom cycle (excel sheet)
- selecter switch
- longitudnal driver block
- motor and controller block (designed)
- custom transmission (system)
- battery managment block (custom made)
- transmission (system)
- from
- to
- display
- scope
- lt block
- division
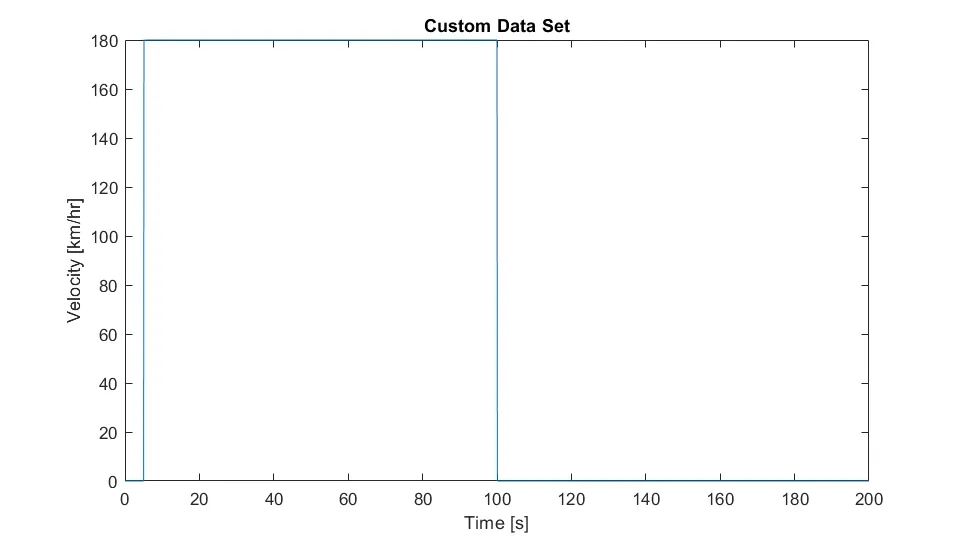
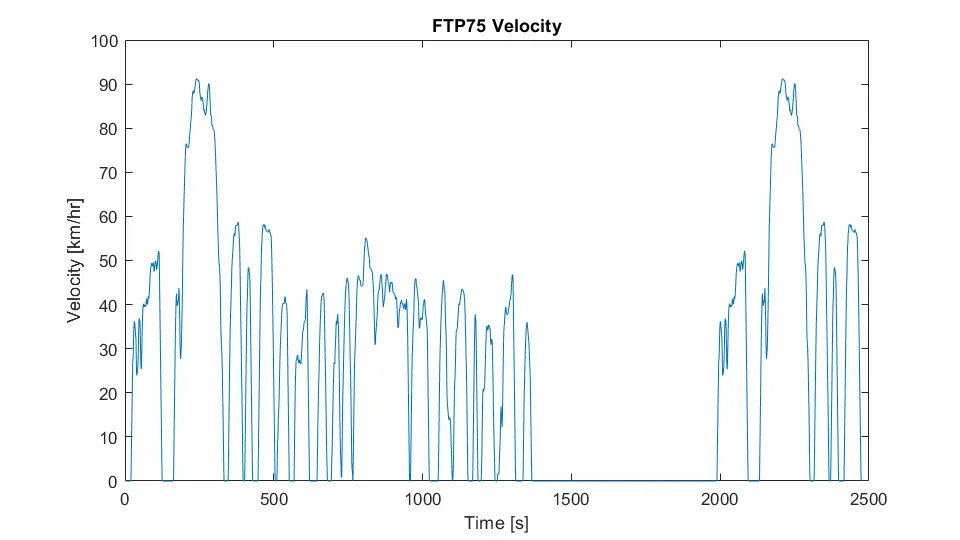
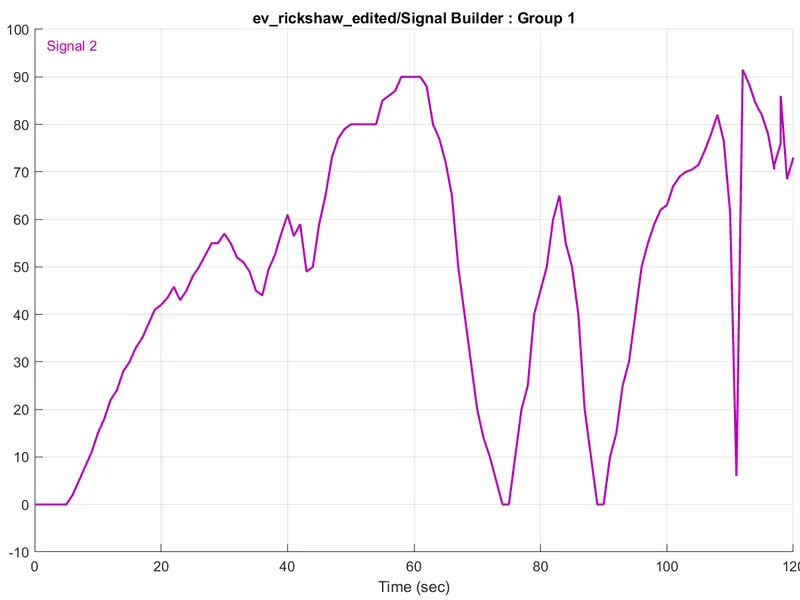
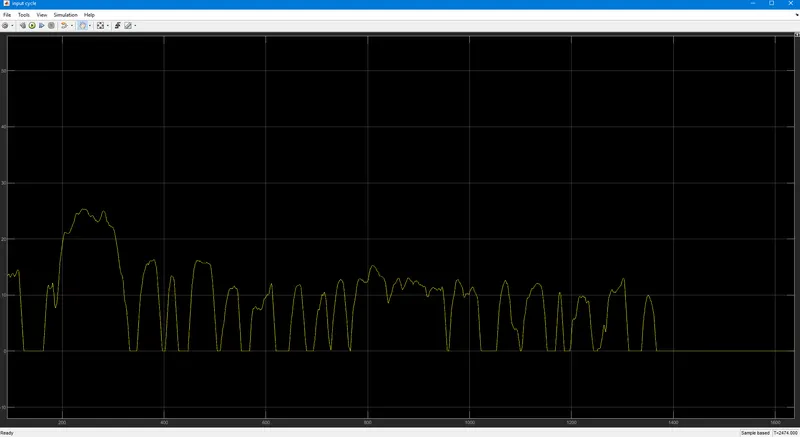
starting with drive cycle : Drive cycle is assumed as the driver's input of a vehicle, it replaced how a driver will drive a vehicle. Here I have used three drive cycles which is used to test the vehicle performances. These drive cycle will have high speed, low speed, braking conditions in it. There are different drive cycles like WOT, FTP75 etc., Here in this model I have used FTP 75, WOT & Manually prepared in excel Drive Cycle source
wide open throttle (wot).
ftp75
signal builder(custom duty cycle)
Driver Controller: default configuration
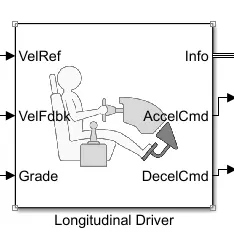
we can find this block already in the simulink library A parametric longitudinal speed tracking controller for generating normalized acceleration and braking commands based on reference and feedback velocities.Use the external actions to input signals that can disable, hold, or override the closed-loop commands determined by the block. The block uses this priority for the input commands: disable, hold, override.
Drive cycle is connected to a longitudinal driver, it has six ports namely velocity reference, velocity feedback, grade, info, Acceleration, Deceleration.
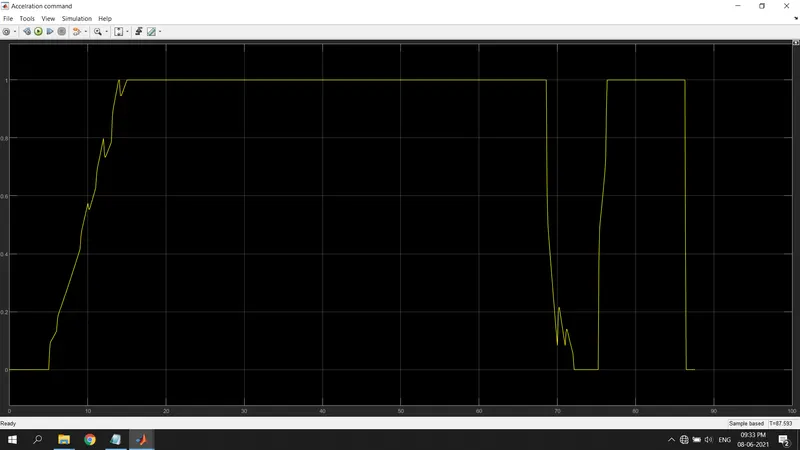
VelRef is given by the drive cycle data and VelFdbk is given by the output of the motor. These two will get compare and the acceleration or deceleration output will be given to the motor controller. Accelcmd is given the PWM generator block and deccelcmd is given to the regenerative port of the h-bridge which uses to generate regenerative braking. Info is used to get any other data from a longitudinal driver block. The grade is to give the input of gradeability to the driver block. This block helps to generate regerate the driver's conditions of the vehicle using the driver cycle block.
motor controller :
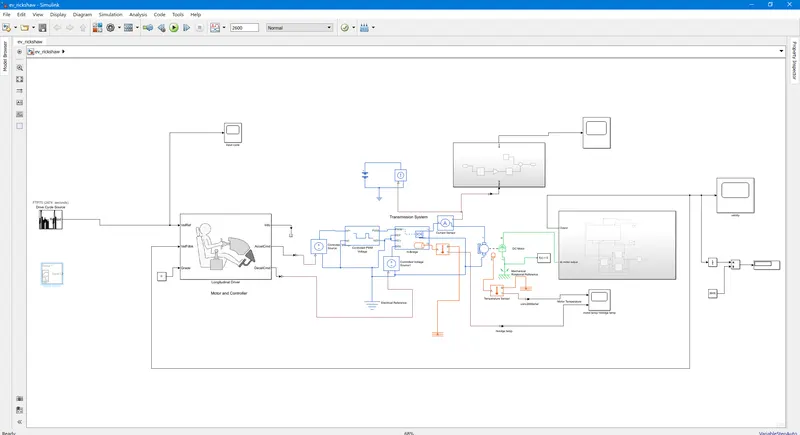
blocks used in motor controller are :
- controlled volage source
- pwm source
- connection ports
- solver blocks
- electrical reference
- h bridge
- temprature sensor
- dc motor
- bus
- from block (for temprature).
Battery:
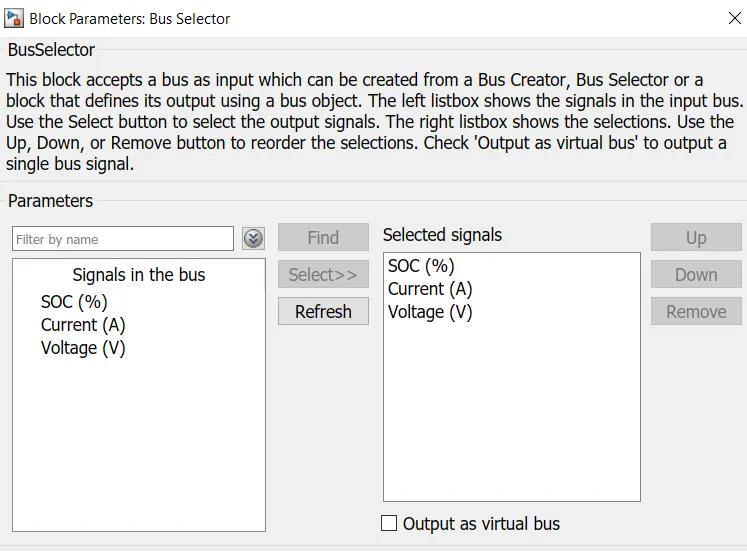
Battery Parameters:
| Battery Type | Lithium ion |
| Nominal Voltage | 48V |
| Rated capacity | 75 Ah |
| Initial SoC% | 100 |
| Internal Resistance | 0.0012 ohm |
The Nominal voltage of battery is 330 V
Initial SoC is of 100%
The battery as a series internal resistance plus a charge-dependent voltage source defined by:
V=Vnom*state of charge/1- β *(1- state of charge)
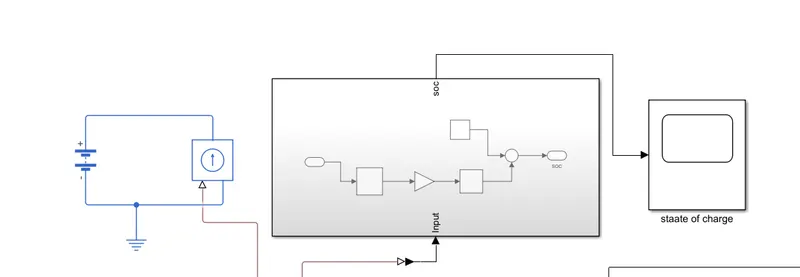
The battery has a positive and negative terminal which is given the voltage-controlled source where the battery consumption is controlled by the motor controller and then it is given to the SOC block.
motor parameter:
power: 8 kw
peak torque : 42 nm
transmission type : direct drive
State of charge (SoC):
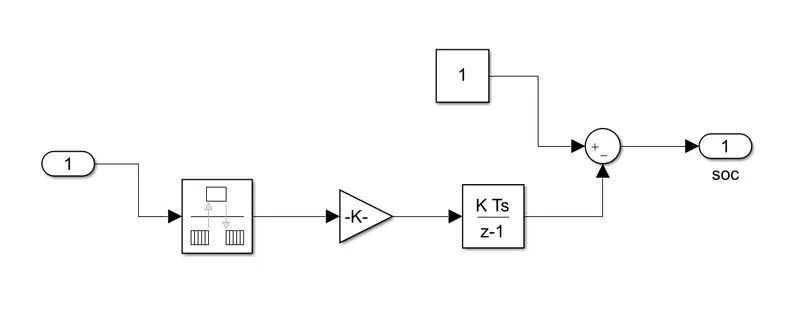
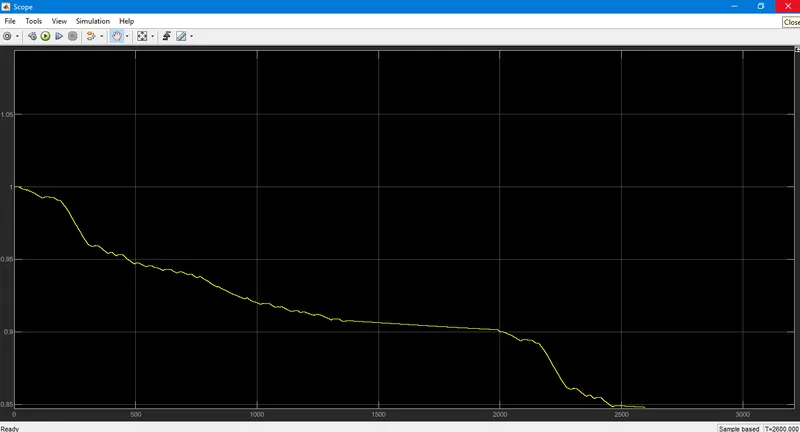
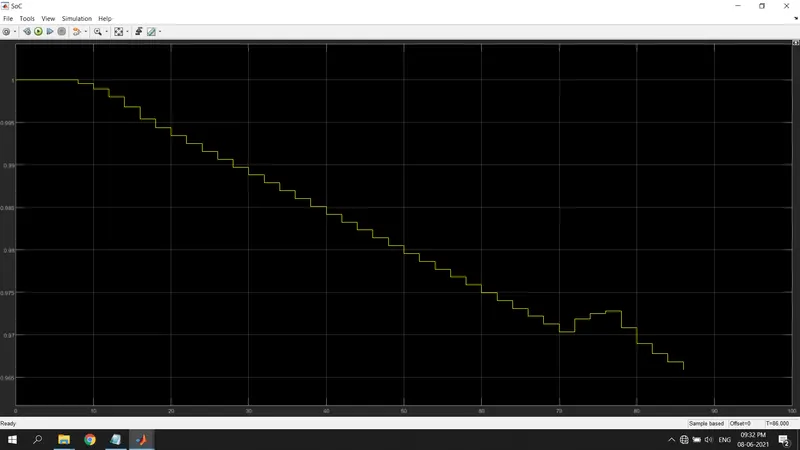
SoC is the percentage or level of battery presents after certain travel or consumption of battery charge by the vehicle. In the designed vehicle battery charge or SOC is calculated by the giving it to the rate transition and then to gain where 1/(nominal battery capacity) then to a discrete-time integrator and it will get minus from the 1 as it is considered a 100% of battery and it is multiplied with 100 to get percentage of battery.
The majority of blocks are simscape blocks where physical to simulink converter is used to convert the physical signal from simscape block to simulink signal.
controlled pwm voltage source
This block creates a Pulse-Width Modulated (PWM) voltage across the PWM and REF ports. The output voltage is zero when the pulse is low, and is equal to the Output voltage amplitude parameter when high. Duty cycle is set by the input value. Right-click the block and select Simscape->Block choices to switch between electrical +ref/-ref ports and PS input u to specify the input value.
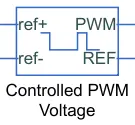
At time zero, the pulse is initialized as high unless the duty cycle is set to zero or the Pulse delay time is greater than zero.
The Simulation mode can be set to PWM or Averaged. In PWM mode, the output is a PWM signal. In Averaged mode, the output is constant with value equal to the averaged PWM signal.
Select Simulation mode as Averaged.
H-Bridge:
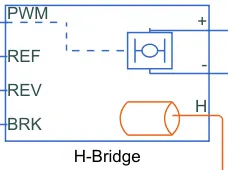
This block represents an H-bridge motor drive. The block can be driven by the Controlled PWM Voltage block in PWM or Averaged mode. In PWM mode, the motor is powered if the PWM port voltage is above the Enable threshold voltage. In Averaged mode, the PWM port voltage divided by the PWM signal amplitude parameter defines the ratio of the on-time to the PWM period. Using this ratio and assumptions about the load, the block applies an average voltage to the load that achieves the correct average load current. The Simulation mode parameter value must be the same for the Controlled PWM Voltage and H-Bridge blocks.
If exposing the power supply connections, the block only supports PWM mode
Temperature Sensor:
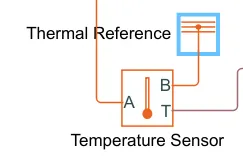
This block measures temperature in a thermal network. There is no heat flow through the sensor. The physical signal port T reports the temperature difference across the sensor. The measurement is positive when the temperature at port A is greater than the temperature at port B.
Solver Configuration:
used for simulation.
References:
Electrical Reference: Used to ground the all the electrical connections.
Mechanical Rotational Reference: Used to ground all the mechanical rotational parts.
Thermal Reference: Used to ground the thermal sensor.
Vehicle Body & Transmission:
Motor will produce the rotational output which will give to the vehicle body and transmission system. The rotational output is taken by the gear system here to maintain the constant speed throughout the transmission without any loss in speed from the motor to tires. Below is a diagram that is how it is how it inside the vehicle body and transmission system and in the main design, it is referred just only as a transmission system.
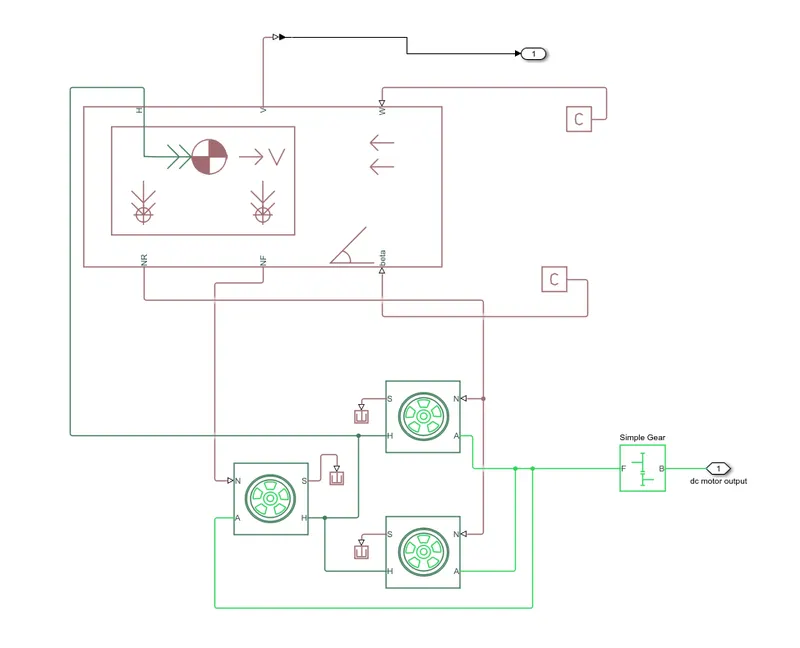
Vehicle Body:
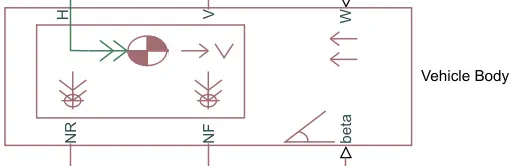
parameter:
mass: 700 kg
no of wheel per axle: 2
frontal area :1048m^2
drag coefficient :0.5
air density : 1.18kg/m^3
Wheels:
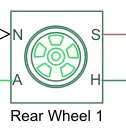
A is the mechanical rotational conserving port for the wheel axle
H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire
N is a physical signal input port that applies the normal force acting on the tire
S is a physical signal output port that reports the tire slip.
Parameters of Wheels:
| Wheel Radius | 0.306m |
| Vertical load | 3000n |
| Peak longitudinal force at rated load | 3500n |
| Slip | 10 |
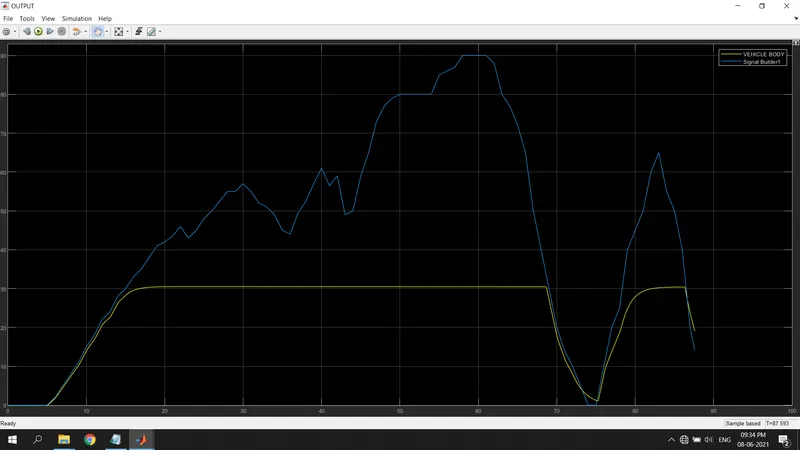
matlab simulation result for ftp75:
input duty cycle:for (ftp75)
state of charge :
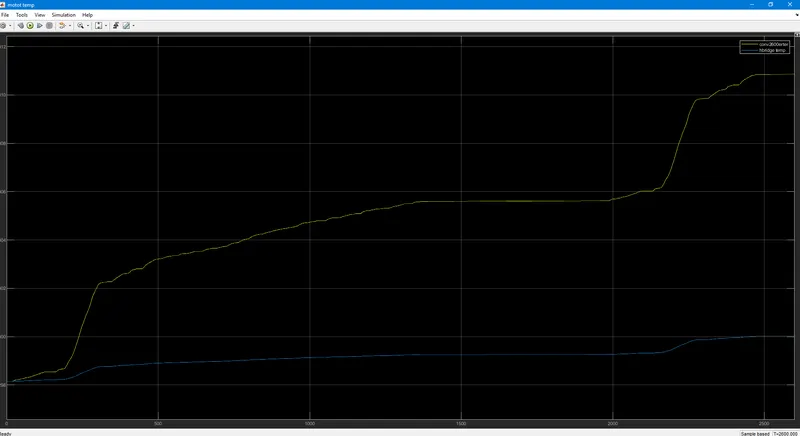
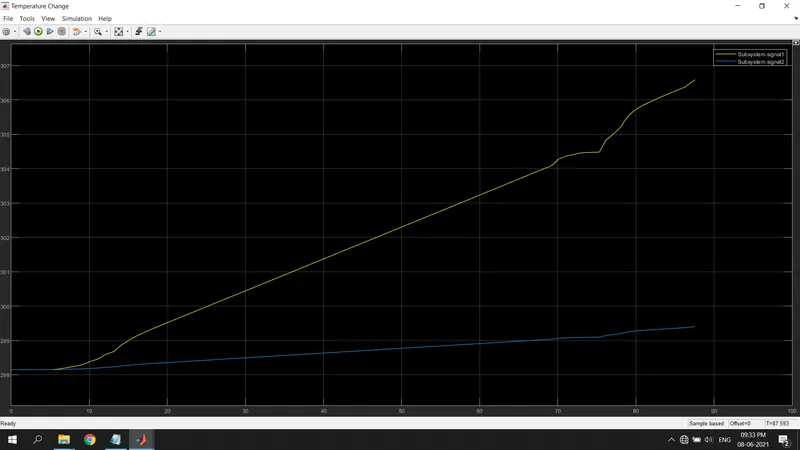
motor and h bridge temperature:
velocity:
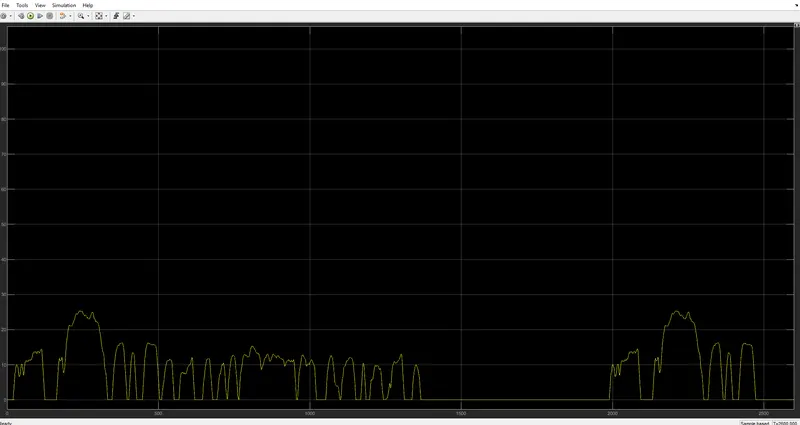
matlab simulation result for custom duty cycle:
acceleration command:
input duty cycle & velocity:
temperature (motor,h-bridge):
state of charge:
Conclusion:
- Here I have compromised with the temperature of Motor and controller to achieve vehicle speed is near to reference speeds. Since I haven’t used any cooling system in the model. In the real time application, the motor temperature is less than 1000C.
- In the real time application, the motor, battery & controller temperature is controlled by air cooling. Hence, the temperature of this components is not increased to this extent.
- Hence, Created a MATLAB model of an Electric Rickshaw (three wheel passenger vehicle) by using Li-ion battery, PM Brushed DC Motor.
- Detremined the variations of Temperature of Motor and controller, SoC% and Energy consumed by the by vehicle for all the three Reference Drive cycles (i.e.; FTP75, Manually prepared).