Final Project: Design of an Electric Vehicle
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
AIM: To Create a MATLAB model of electric car which uses a battery and a DC motor.
Electric car
An electric car is a vehicle which used to run through the battery. It uses the motor to run which uses only electrical energy which stored in the battery. It is the replacement of the IC Engine which run through petrol or diesel. As the same as ICE, it charges its batteries through charging stations with electrical energy instead of fuels by using charging ports chargers. It has low maintenance and eco friendly and also having long life. The efficiency of the electrical cars is little bit higher than the normal ICE type vehicles. The batteries are manufactured with the combination of some chemical as positive and negative by the separator which called electrodes, due to this its protection and safety must be taken as high priority otherwise it leads dangerous effects and explodes as well. They use an electric motor for propulsion. The most common types of motors used are permanent Magnet Synchronous Moto (PMSM) and three phase induction motor. It charges by using both AC and DC type charge technologies.
The main parts of the electric car are,
Battery with BMS controller
Converter and inverter
Motor or generator
Charger
Storage device
model for electric vehicle
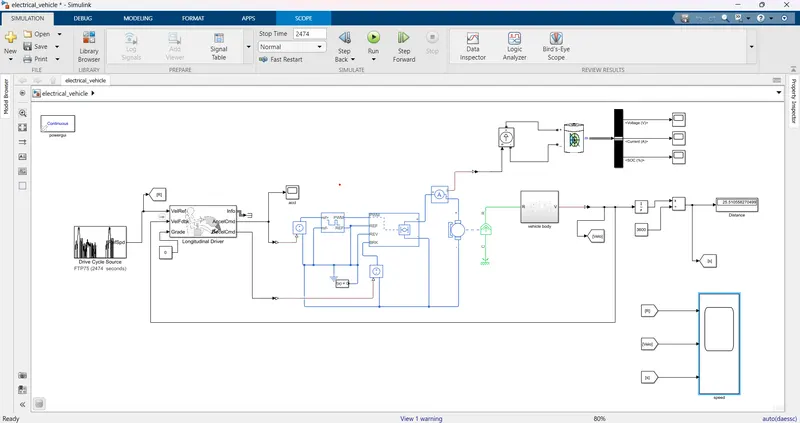
Now let us look at each of the blocks used to create this MATLAB model.
The main blocks or subsystems of the model are
drive cycle source
A driving cycle is a series of data points representing the speed of a vehicle versus time.
Driving cycles are produced by different countries and organizations to assess the performance of vehicles in various ways, as for instance fuel consumption, electric vehicle autonomy and polluting emissions.
Fuel consumption and emission tests are performed on chassis dynamometers. Tailpipe emissions are collected and measured to indicate the performance of the vehicle.
Another use for driving cycles is in vehicle simulations. More specifically, they are used in propulsion system simulations to predict performance of internal combustion engines, transmissions, electric drive systems, batteries, fuel cell systems, and similar components.
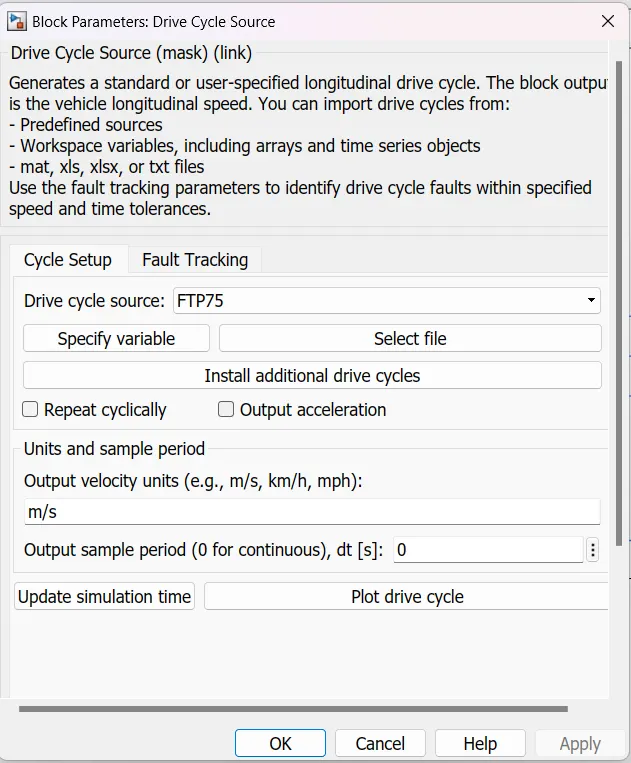
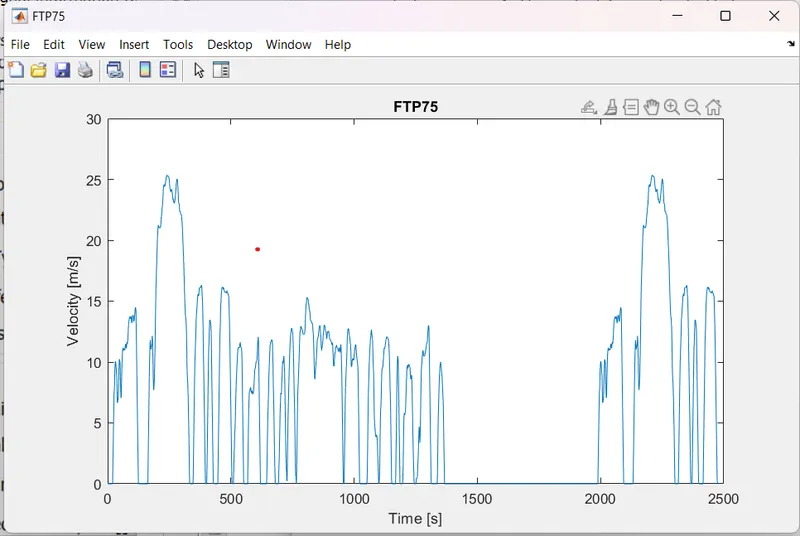
The EPA Federal Test Procedure, commonly known as FTP-75 for the city driving cycle
longitudinal drive
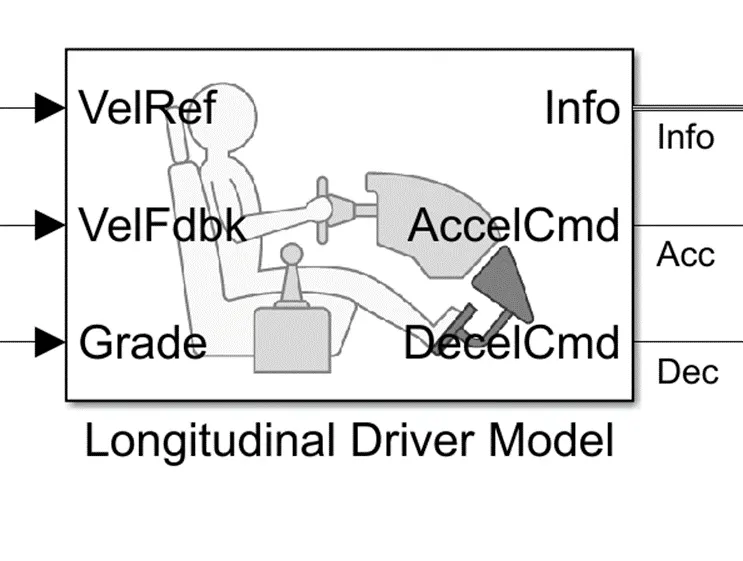
It like a driver which is used to take the charge of driving its acceleration breaking commands as per the given conditions which is called as a reference. It also called as an auto control which it takes the feedback from the vehicle and run as per the given values and changes its commands based on the feedback with the reference values respectively.
This block is used to create a longitudinal speed-tracking controller and it is based on reference and feedback velocities. We can use this block to model the dynamic response of a driver to generate the commands necessary to track a longitudinal drive cycle.
Here in this block the
VEL Ref is used to take the reference values for the driver to drive the vehicle.
Vel Fdbk is used to take the feedback from the output of the given data from the vehicle speed which is called as a velocity.
Accel Cmd is an output signal that gives as an input to the power control unit-controlled voltage source 1 which is connected to the PWM for the purpose of acceleration when the output is reduced to lower than the given reference value.
Decel Cmd is also an output signal that gives as an input to the power control unit-controlled voltage source 2 which is connected to the BRK for the purpose of breaking when the output is becoming higher than the given reference value.
The info is for the signal information to get the physical values and the grade is to measure the road angle respectively.
Controlled pwm voltage
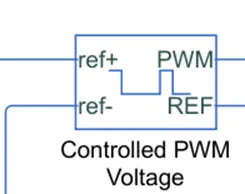
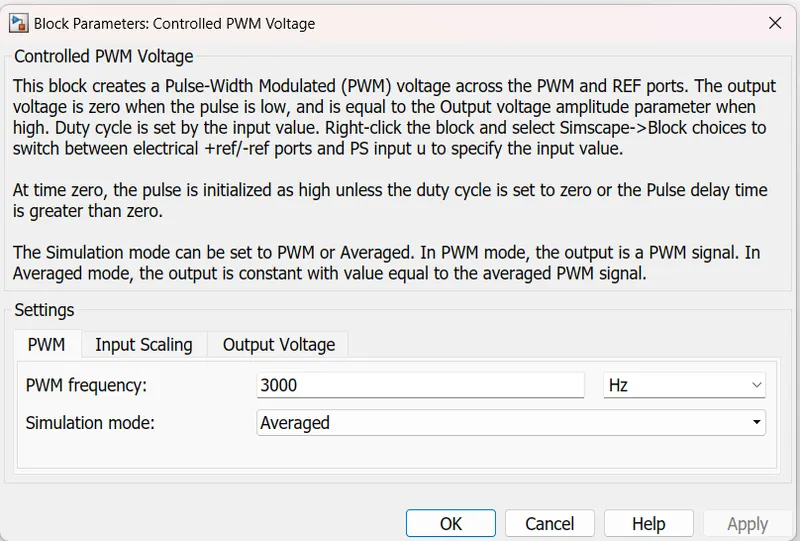
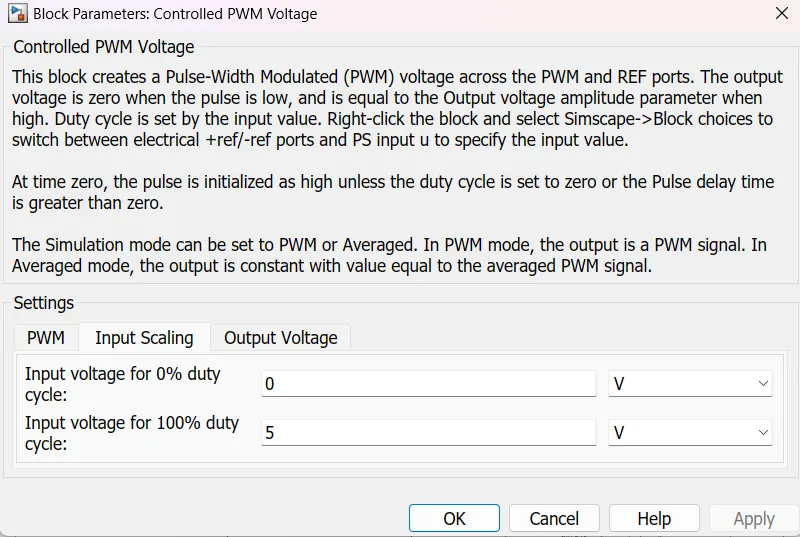
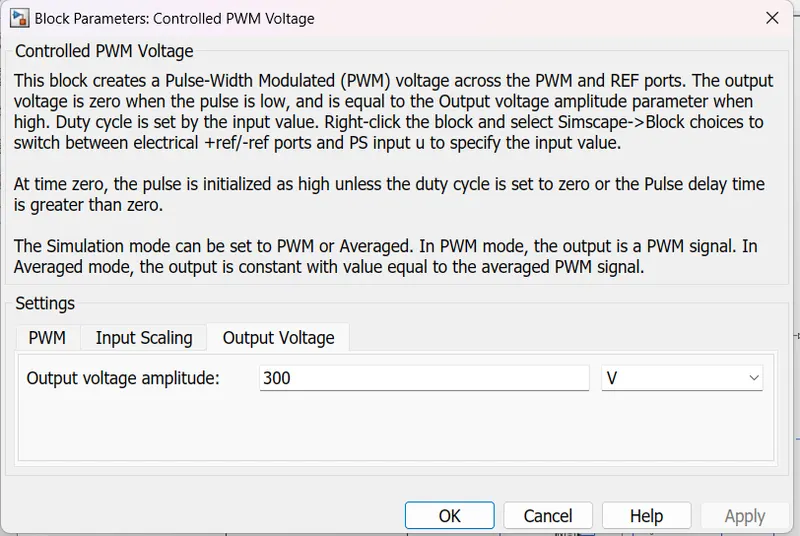
It is used to give the Pulse Width Modulation signals to the H bridge circuit at PWM terminal. The +ve reference terminal of the block is connecter to the controlled voltage source and -ve is connected to the electrical reference, the PWM is connected to the H bridge PWM as said above and REF is connected to the REF and REV terminals of the H bridge. Actual the main aim of the controlled PWM voltage is to give the controlled voltage in the form of a pulses in the DC voltage.
H-bridge
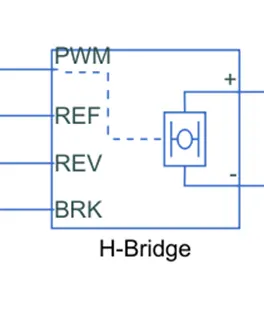
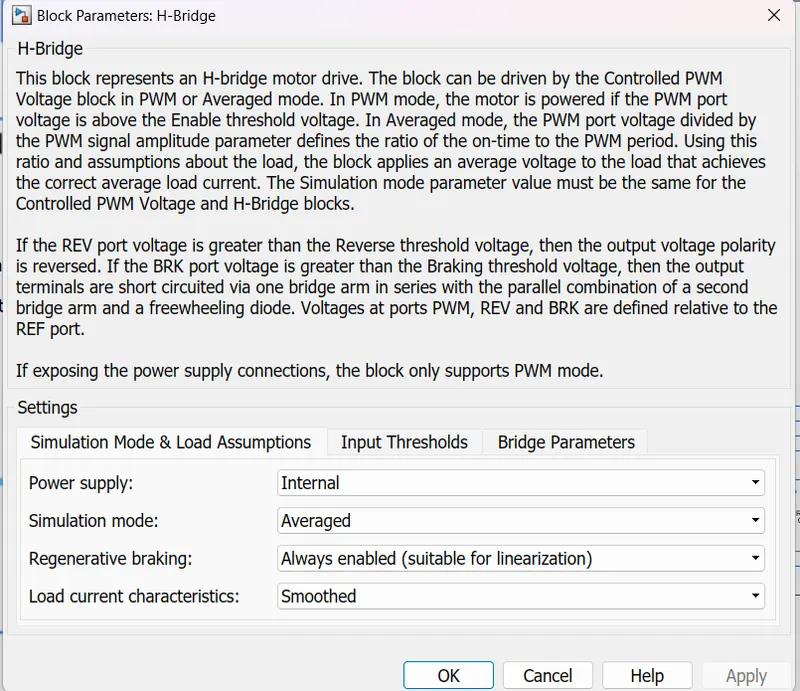
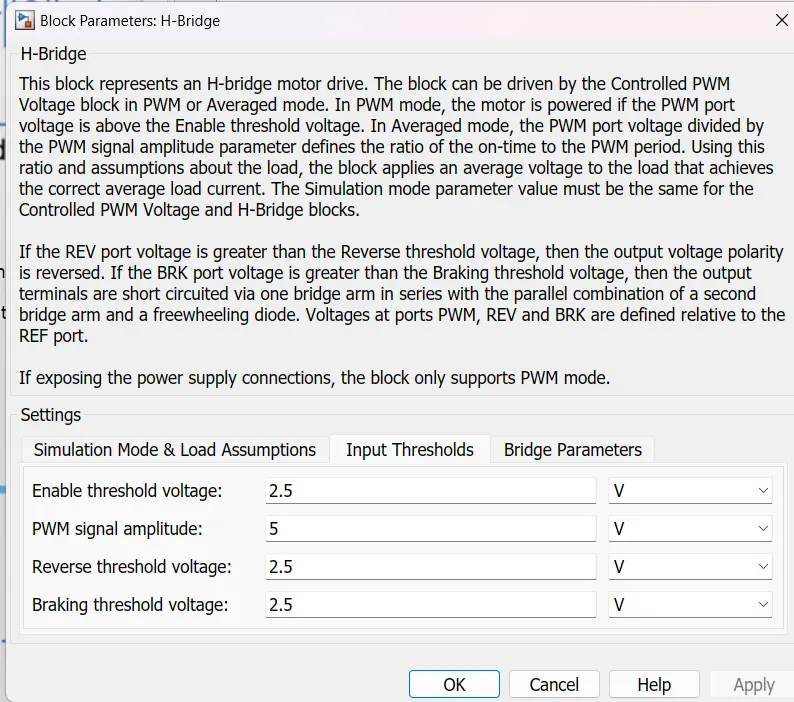
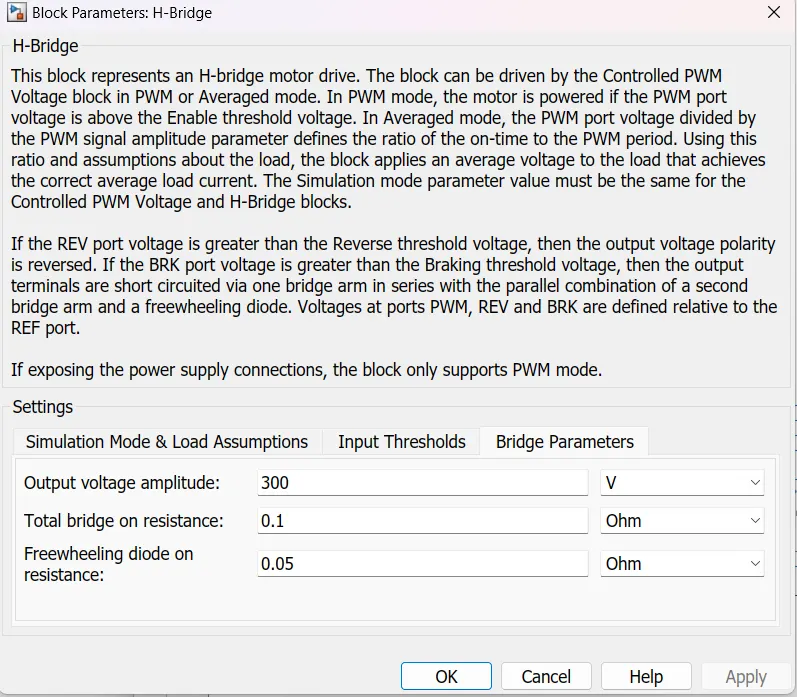
This block is used to change the polarity of the voltage applied across the DC motors so as to run the motor in forward and reverse direction as per the input command.
As the name indicates that the H symbol in the block is connected to the DC motor and the PWM, REF, REV, BRK are used to control the block DC motor.
dc motor
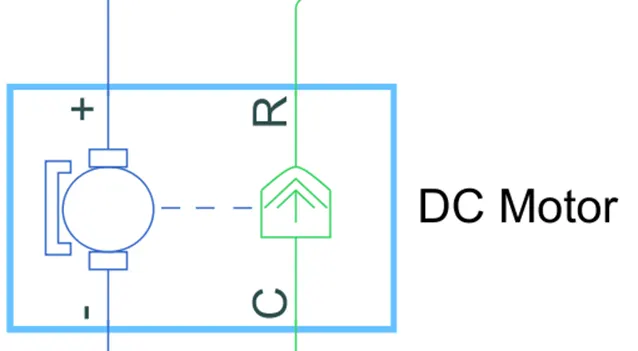
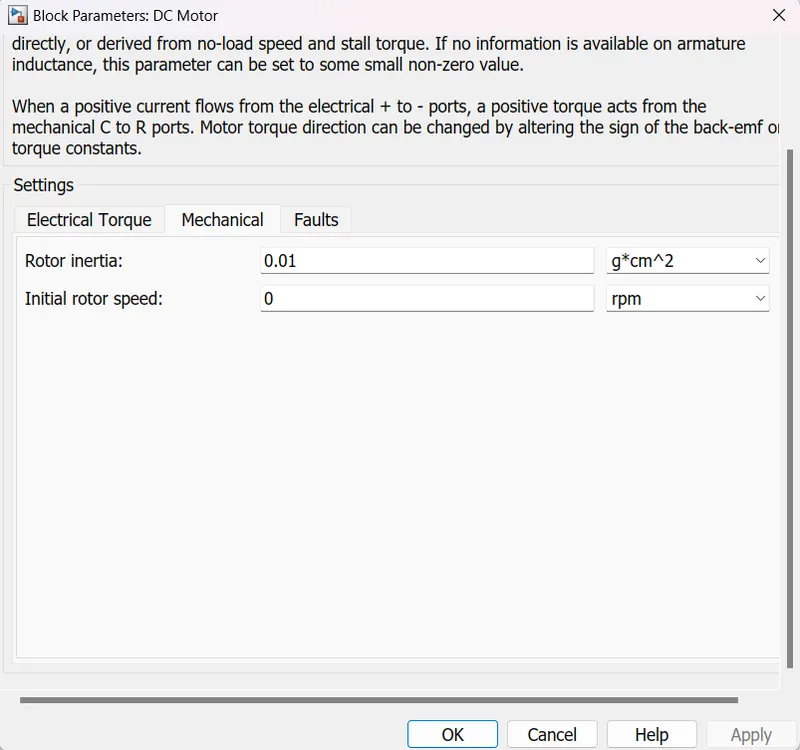
It is used to convert the electrical energy to mechanical energy. In this electric vehicle model, we have used type is permanent magnet DC motor. This motor can also act as a generator in the case of regenerative braking.
In this block the motors the electrical side is represents with the blue colour and the mechanical side is represents with the green as well with the combination of shaft which is in the dotted line. here the motors +ve and -ve terminals are connected to the H-Bridge +ve and -ve terminals respectively with the electrical reference in -ve side. And the mechanical side Rand C terminal are connected to the vehicle body simple gear terminal and to the mechanical rotational reference respectively.
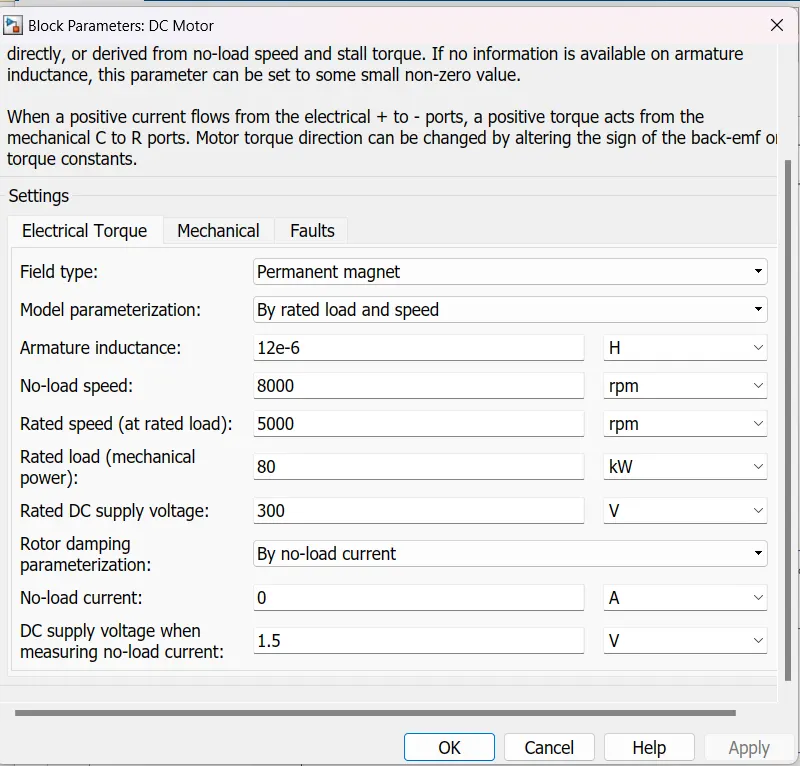
Here we used the voltage that is DC voltage value is 300 V with the power of 50 Kw. The rated and no-load speed of the motor are given as 5000 and 8000 Rpm respectively by keeping all other parameters are same. The mechanical characteristics also be kept as same without any change.
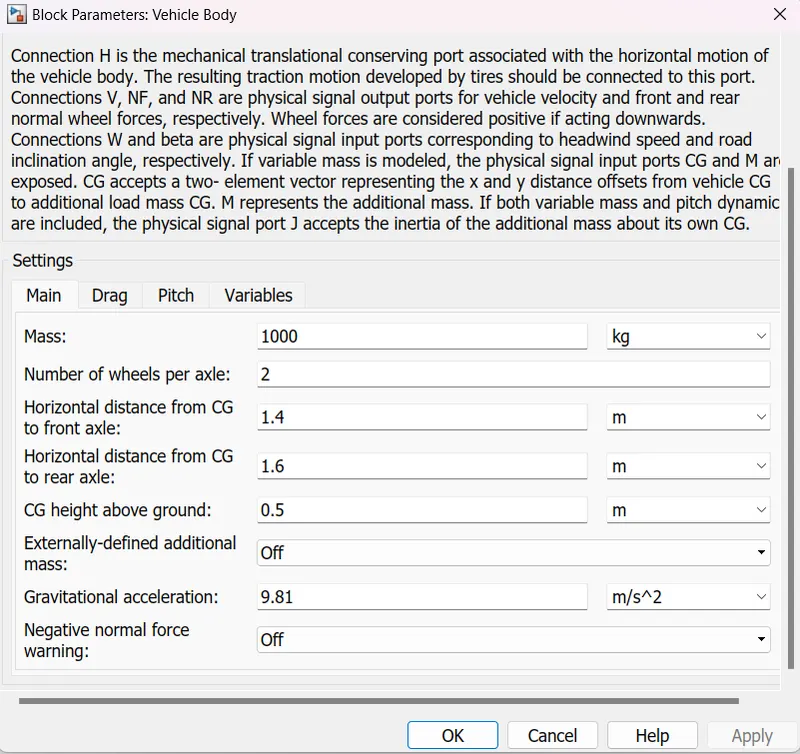
vehicle body
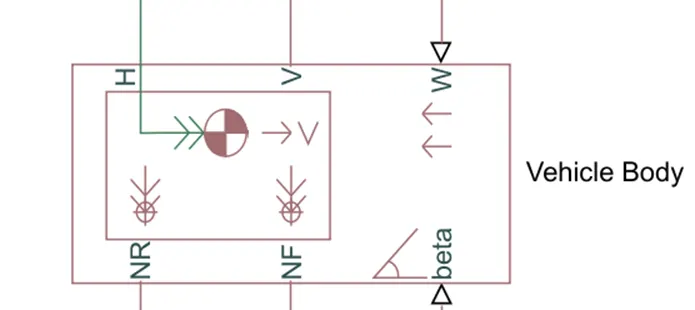
The vehicle body is used to represent the vehicle in practical way it has the same inputs as a real-world vehicle requires like drag values, pitch, variables, wind velocity and road angles etc.
The connection ports that is Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively, In this ports Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively.
This block has an option to include an externally-defined mass and an externally-defined inertia. The mass, inertia, and centre of gravity of the vehicle body can vary over the course of simulation in response to system changes.
As it says above that the connection of the vehicle body ports which are inputs that is H is connected to the tire blocks H terminal. NR and NF to the rear wheel N and front wheel N terminals. W and beta are the optional here we connected both to the physical signal (PS) constant with the value of 0. V is the output port which gives the velocity value that is it gives the speed that a vehicle is be gone.
tire(magic formula)
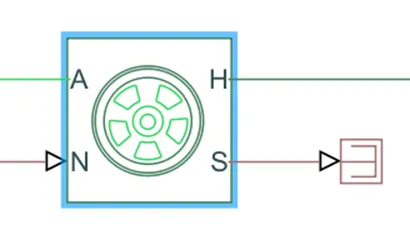
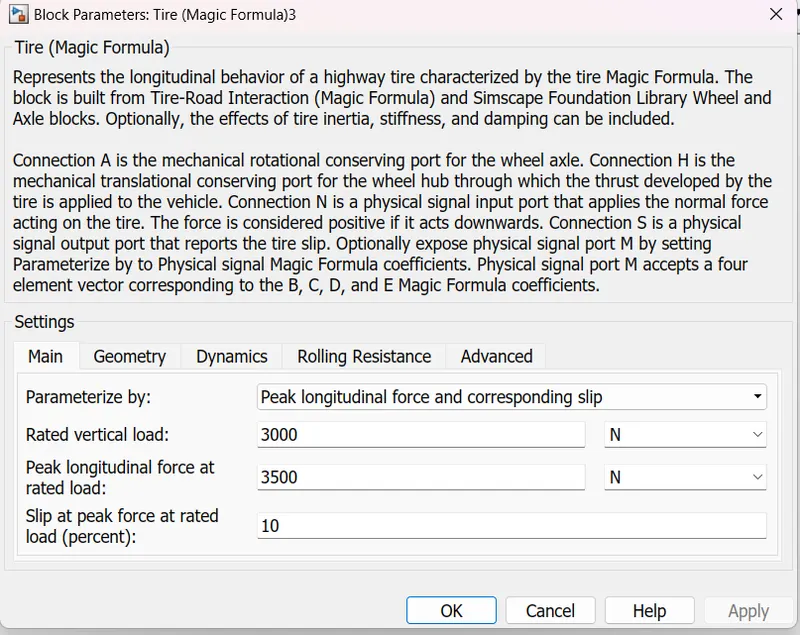
As we seen above that the tires are used in the vehicle body which is having the 2 tires each per axle which moves along with the given throttle value as left and right front and rear blocks. It is the mathematical model of the design or block of the tire which have the same parameters and effects which are designed In the model as real. The effects for the real one is applied to the tire as same.
Here the names A indicates the mechanical rotational conserving port for the wheel axle. Connection H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle. Connection N is a physical signal input port that applies the normal force acting on the tire. Connection S is a physical signal output port that reports the tire slip. We not consider the slip in this subsystem so we connected the S terminal to the terminate physical signal to not to generate the warnings to the not connected ports.
simple gear
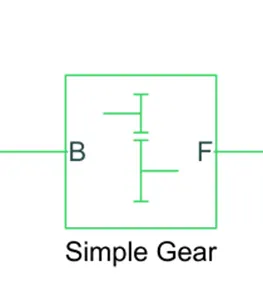
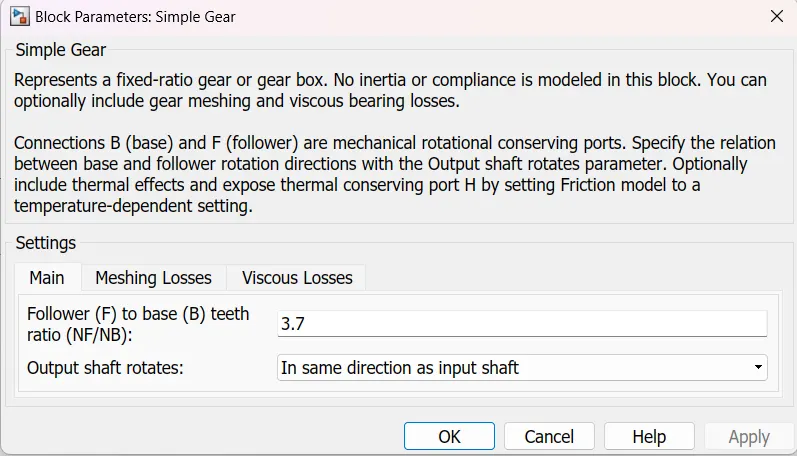
t is the representation for the gear box in the vehicle, it seems similar as a real gear box we can include meshing and bearing losses if we need.
It is located between the connection of the motor terminal R and A is the mechanical rotational conserving port by the gear terminals B and F respectively.
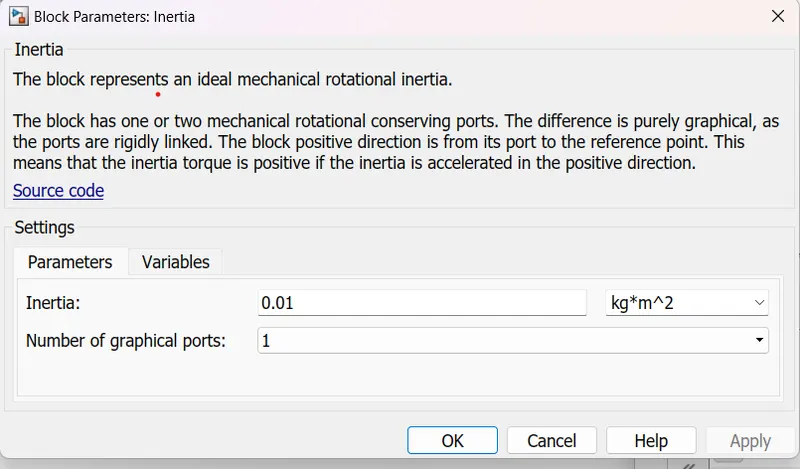
ineria
It is used to represent the ideal mechanical rotational inertia which is the reference port to give the positive inertia torque with the terminal used to connect to the reference one.
battery
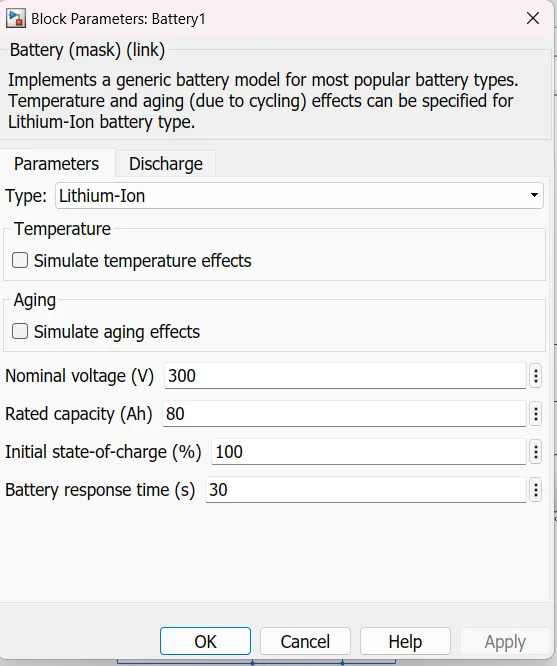
This battery block represents a simple battery model. The block models the battery as a series internal resistance and a current voltage source.
We can say that the battery is the one of the main important part or the block in the vehicle and model as well. By connecting this terminasl to the controlled voltage source it supplies controlled signals to discharge and also charging in the regenerative type as well. The output signals of the battery are taken are SOC, current, and voltages.
controlled voltage source
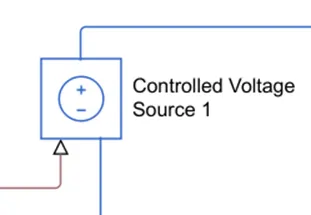
It is used to control the voltage which is connected to the positive reference of the controlled PWM voltage in the form of a signal by the longitudinal driver model acceleration command. Another controlled voltage source 2 is used to connect to the H bridge BRK terminal the negative sides of both the sources are connected to the electrical reference as shown above.
controlled current source
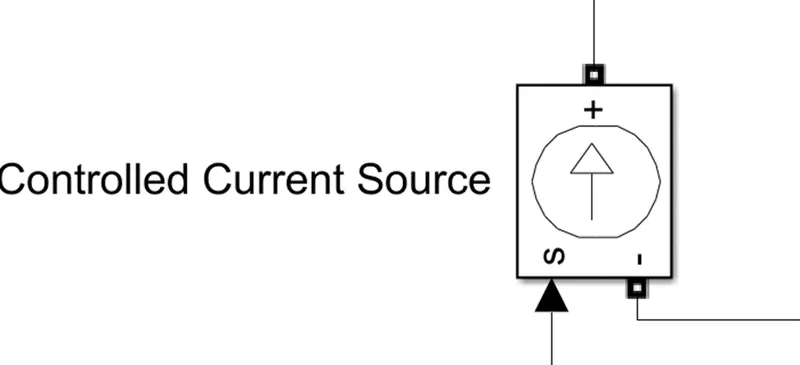
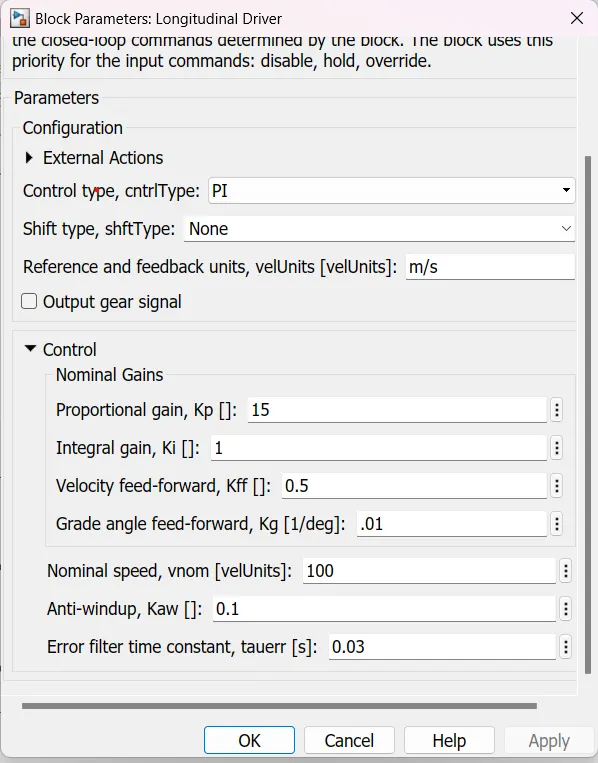
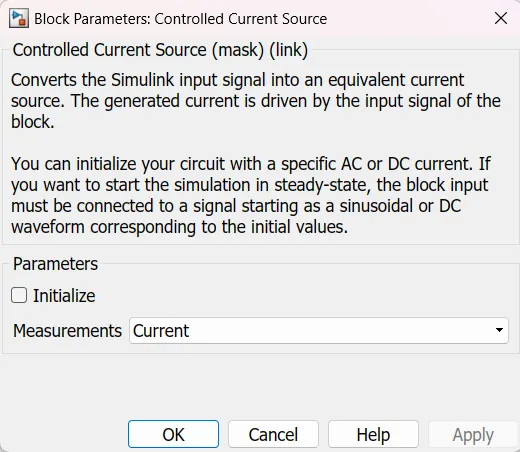
There is need to use the parameters of the controlled current source, so the parameters block of the controlled current source is like,
current sensor
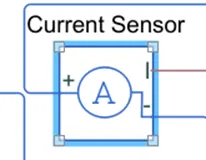
This is used to measure the current flowing through the H-bridge. The +ve and -ve terminals of the current sensor are connected to the DC motor and H-Bridge block respectively and the signal is connected to the controlled current source in the battery subsystem as a physical input signal from the H-Bridge circuit.
constant

scope
It is used to display the signals generated during simulation.
display
It is used to display the value that connected to this block in the form of physical form.
Unit conversion:
goto and from
bus selector
The bus selector is used to block the output signals which are given as an input to that bus selector block. This is used to select by the designer to which have to generate which not that can be identified by the parameter block of the bus selector which is looks like.
solver configuration
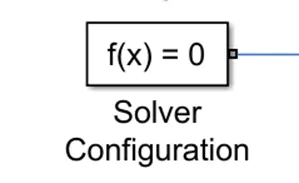
It is placed in the power control unit for the mathematical values in the model solver settings at the simulation time
electrical reference
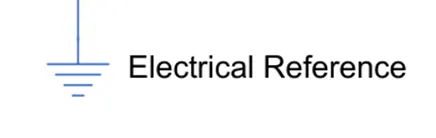
It is used to connect all the terminal of the negative signals and the reference values as the ground.
mechanical rotational reference
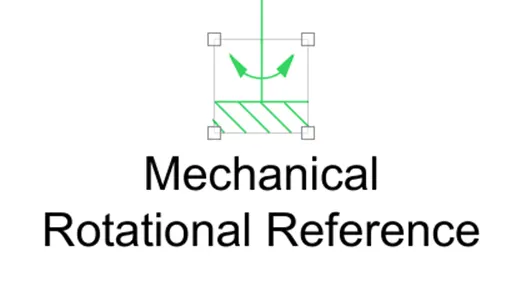
It is representing as a mechanical ground reference point that is as a frame part which is used to connect rotational parts to the ground.
ps constant
ps terminators
powergui
it is used with simulation of power systems and power electronics.
It is used for the analysis and measurement of parameters like voltage, current, active power, reactive power like that.
It gives the steady state values of the system.
if we run the simulition we get
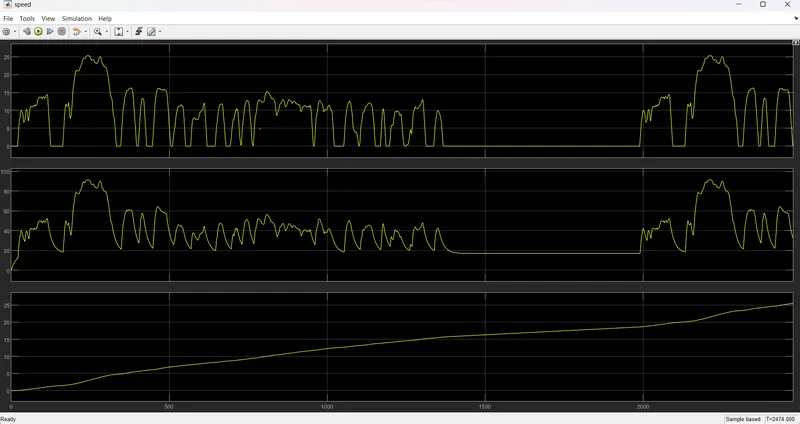
voltage
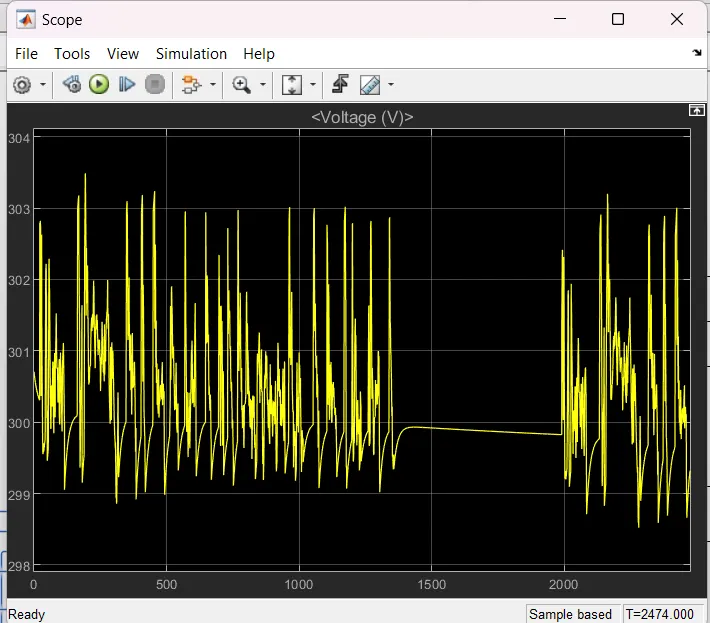
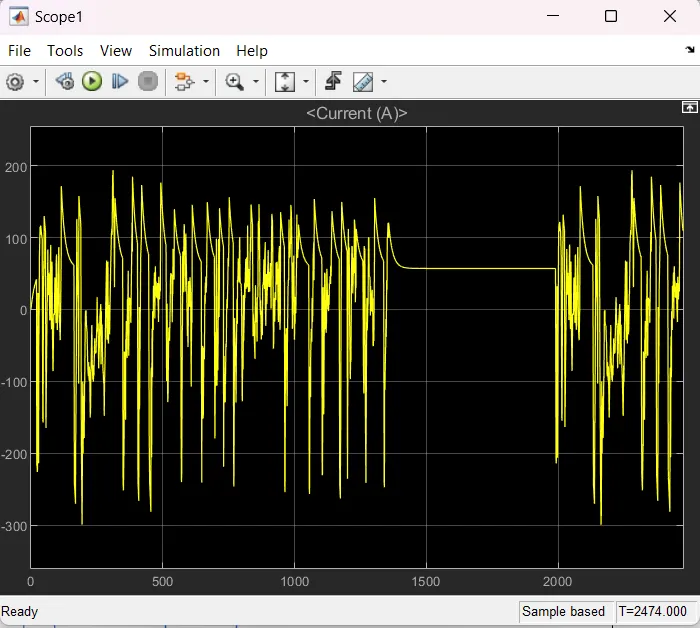
current
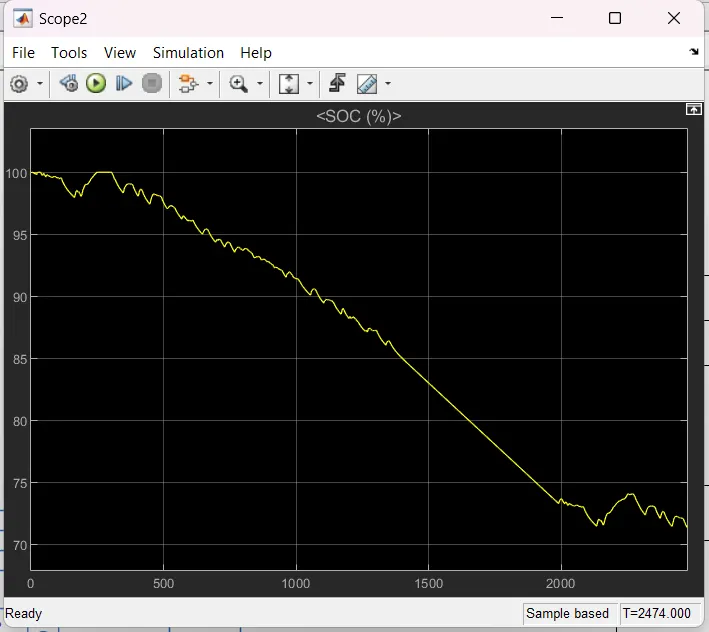
battery soc
acceleration
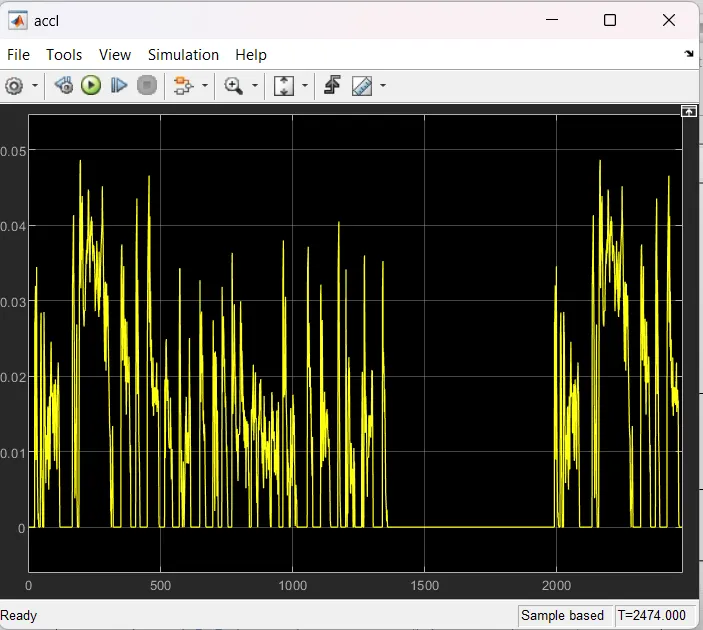
By this model that we created in the MATLAB with the drive cycle FTP75 we travelled the distance of about 25.5Km with the battery capacity of about 80 Ah, and the battery remains is 30.37%. we can also observe that by changing the values of the battery model, and vehicle body values like weight etc we will get different out put values of the battery and distance travelled. It is used in real time with some changes of space and weight with the accurate values.