Final Project: Design of an Electric Vehicle
EV Live Batch 21.
1 Aim: Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objectives:
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
Ans:
MATLAB Model Of Electric Car With DC Motor And Battery:
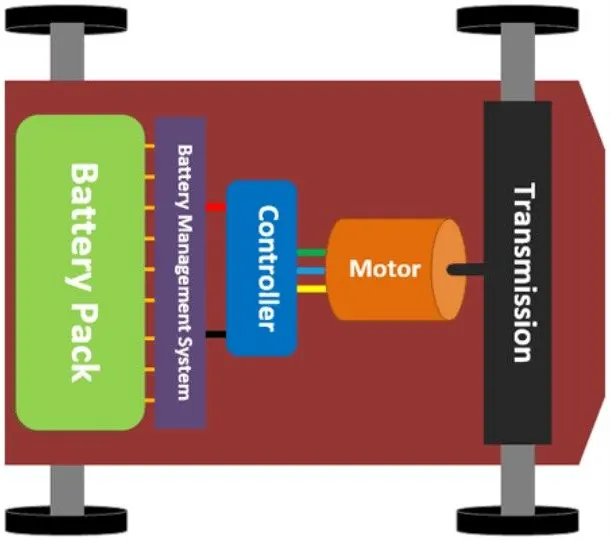
=> Block Diagram Of Electric Vehicle.
=> Vehicle Body Consists of Wheels and Gears.
=> DC Motor is used for vehicle Propulsion.
=> Let us Consider a Simple Battery.
=> Used 4 Quadrant switches as Power converter.
=> Control unit consits of PWM modulation of DC voltage and Lonitudinal Driver.
1.SIMULINK Model Of Electric Vehicle:
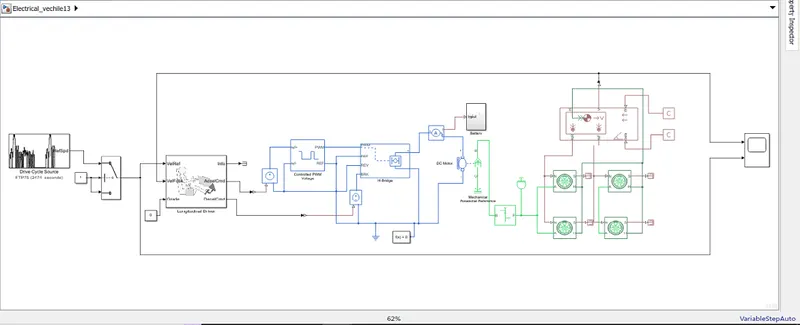
PowerTrain Blocks used in Simulink:
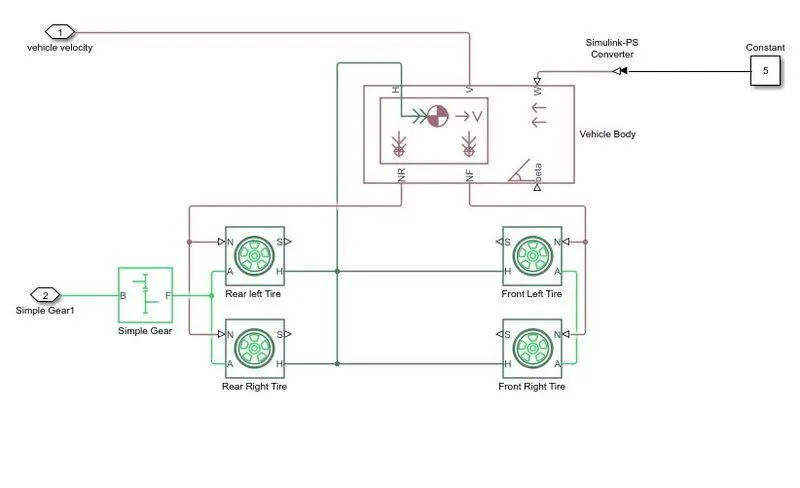 => Vehicle Body:Complete vehicle body is considered as Subsystem as shown above.
=> Wheels: This Block represents the physical Wheel properites of a vehicle Specified by tire manufacturer.
=> Four Wheel:(2 for rear axle and 2 for front axle) Blocks are used and Each one has same specifications.
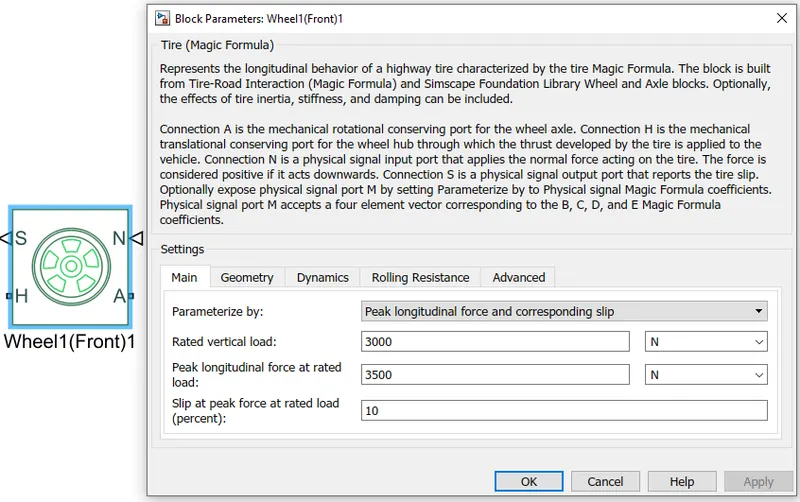
=> Wheel Blocks are considered by default without any changes in all Parameters.
=> If wheel parameters are specified then that will certainly effects the vehicle performance.
Ports:
N-Normal Force: This Input Port is used for Force to be applied on Wheel.
=> Front Wheels N-Port is connected to NF port of vehicle Body.
=> Rear Wheels N-Port is connected to NR port of vehicle Body.
S-Slip:Physical signal output port associated with the relative slip between the tire and road.
A-AXLE: This Mechanical Translational Port gives Mechanical link between two wheels.
=> Both Rear and Front Wheels are connected through A-Port.
H-HUB: Mechanical translational port associated with the wheel hub that transmits the thrust generated by the tire to the vehicle body( maintain same speed in all wheels).
=> All H-Hub ports of Wheels connected to H-port of Vehicle Body.
2.Vehicle Body: This Block gives the Vehicle Body Parameters to be set measured by Physical Vehicle.
In simulation all Parameters are considered as default to reduce simulation time.
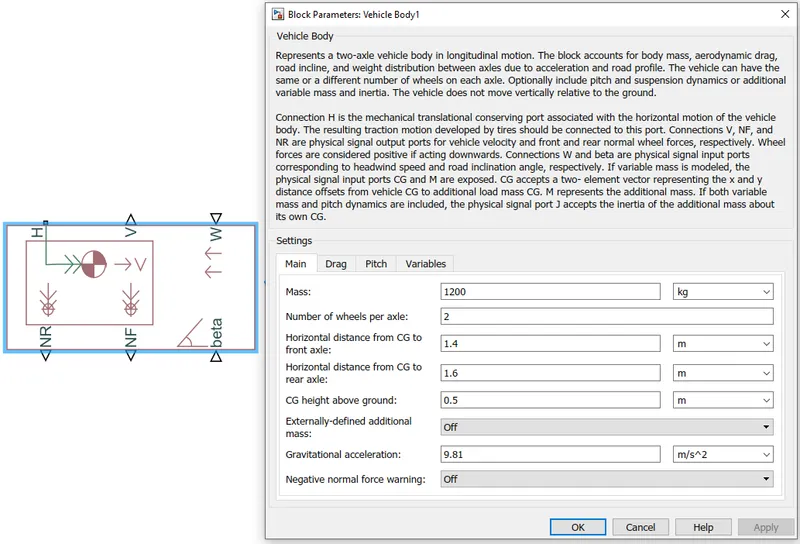
=> H,NR and NF ports are connected to Wheels Ports of vehicle.
=> Beta port gives the vehicle body Inclination to the ground in Radians.
=> W-Port Gives the wind velocity applied on front of the Vehicle body(Headwind Speed in m/s).
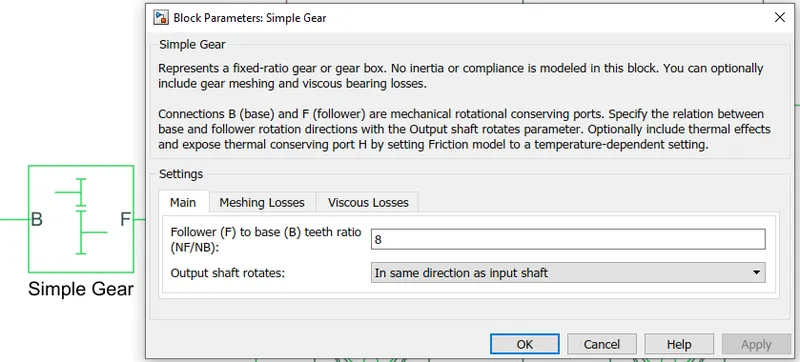
3.Simple GEAR: Represents a fixed-ratio gear from Base(B) to Follower(F).
=> Gear Ratio is specified by manufacturer as of now it is considered as 8.
4.DC Motor:
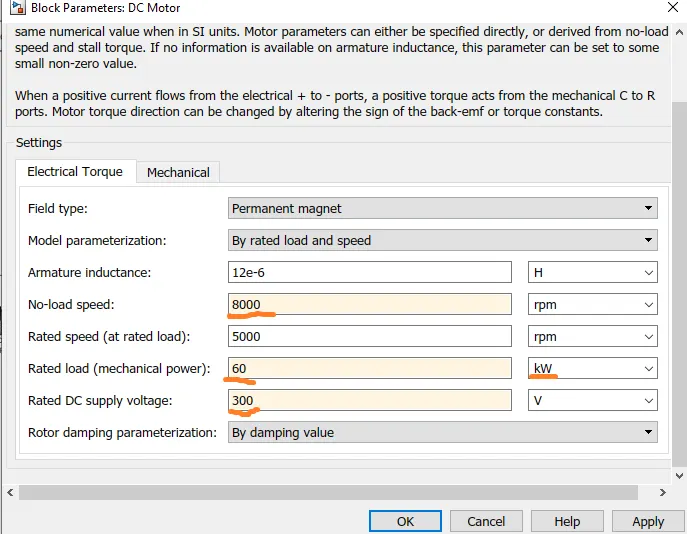
=> This Block represents the electrical and torque characteristics of DC Motor.
Motor Parameters are set as:
No load speed of vehicle=8000 RPM
Rated Load Speed vehicle=5000 RPM
Rated Voltage =300 V
Rated Load of vehicle =60 KW
=> Remaining all other Parameters( Resistance,Inductance,EMF....) are set as Default.
=> Blue Part represents electrical Connection to Battery.
=> Green part Represents Mechanical Part to be connected to shaft of Gear.
=> R-Port is connected to B-Base port of Gear.
=> C-Common port is connected to mechanical rotational reference frame.
5.References:
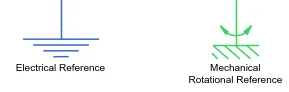
Electrical Reference : Gives the Nuetral Point to the electrical Circuit.
Mechanical Rotational Reference: This Block is considered as a rigid base (ground/frame) point of mechancial body.
Current Sensor: Sense the current taken by DC Motor and gives the feedback to Battery.

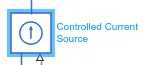
Controlled current Source : Maintain required amount of current to flow from the battery which is sensed from current sensor.
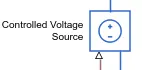
Controlled Voltage Source: Maintain Required amount of voltage to be maintain across DC motor which takes voltage level signal from driver.
6.H-Bridge:
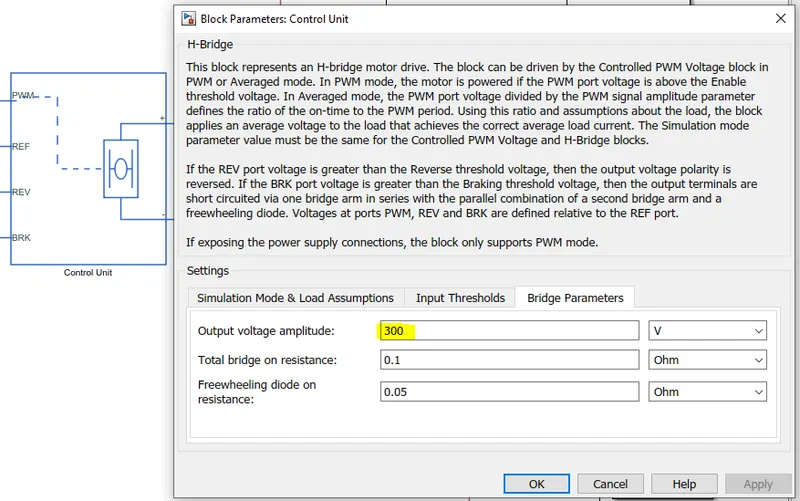
The H-Bridge block output is a controlled voltage that depends on the input signal at the PWM port.
PWM: If the input signal has a value greater than the Enable threshold voltage parameter value, the H- Bridge block output is on and has a value equal to the value of the Output voltage amplitude parameter.
If it has a value less than the Enable threshold voltage parameter value, the block maintains the load circuit using Freewheeling diode.
=> REV and BRK mode are grounded in simulation.
=> Output voltage: set to 300v (consider as Motor rated voltage).
=> Simulation mode is averaged to reduce the simulation time.
=> REV: voltage that controls when to reverse the polarity of the H-Bridge block output.
=> BRK: voltage that controls when to short circuit the H-Bridge block output.
=> Power supply: Power supply can run in two model Internal and External Mode.
7.External Mode:
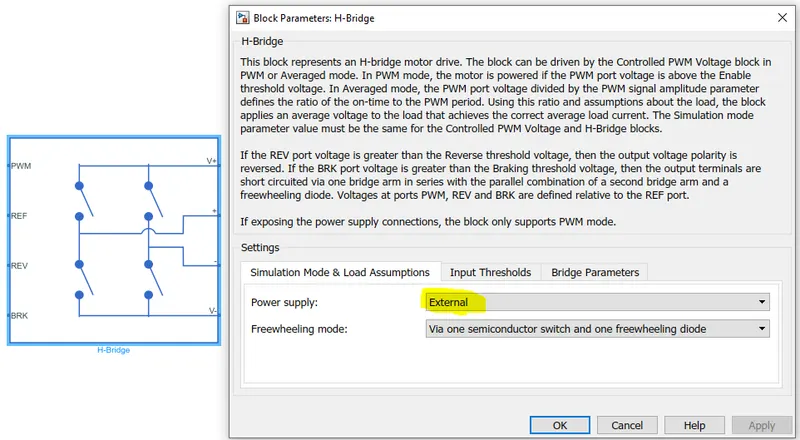
=> Gate Pulse is given by external DC source to Semi conductor switches.
=> If power supply is internal then Gate pulse is obtain internally(Based on Inductance value of motor) such a way that motor runs continously.
8.Controlled PWM voltage:
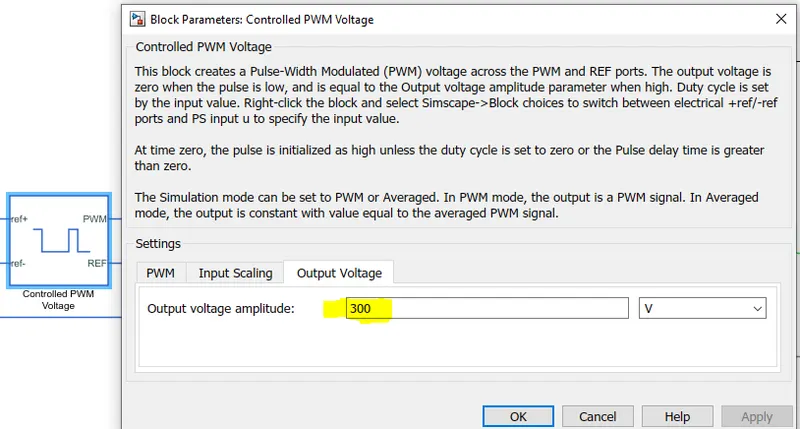
=> The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source.
Simulation Mode is AVERAGED to reduce simulation time.
Output voltage: set to 300v (consider as Motor rated voltage).
9. Lonitudinal Driver:
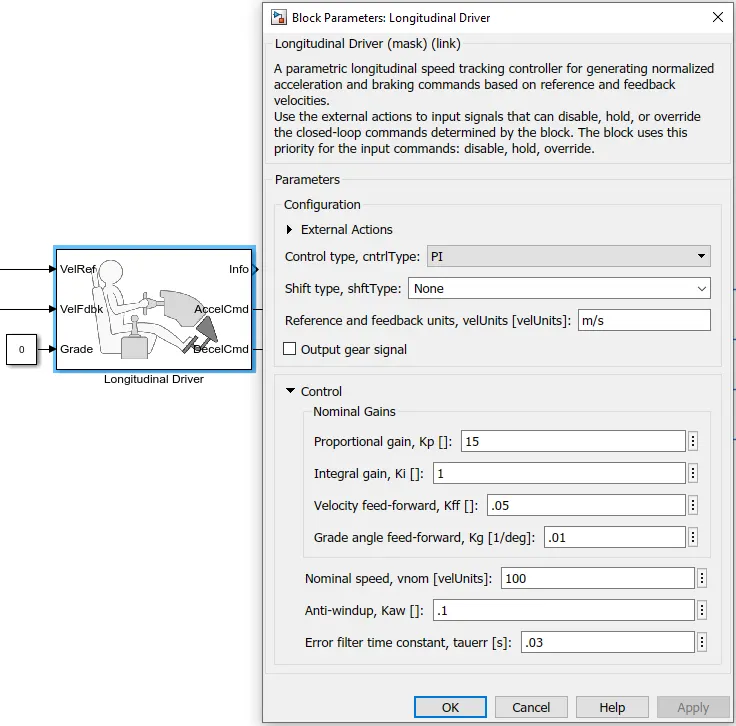
=> (Acts as Driver of vehicle)The block generates normalized acceleration and braking commands that can vary from 0 through 1.
It is Speed Tracking Block which uses a PI controller to reduce the error between Reference velocity and output velocity and gives Accleration and brake commands to Motor through H-bridge.
All Parameters are set as default.
Grade is set as zero so, there is no gradeability in Vehicle.
10.Drive Cycle:
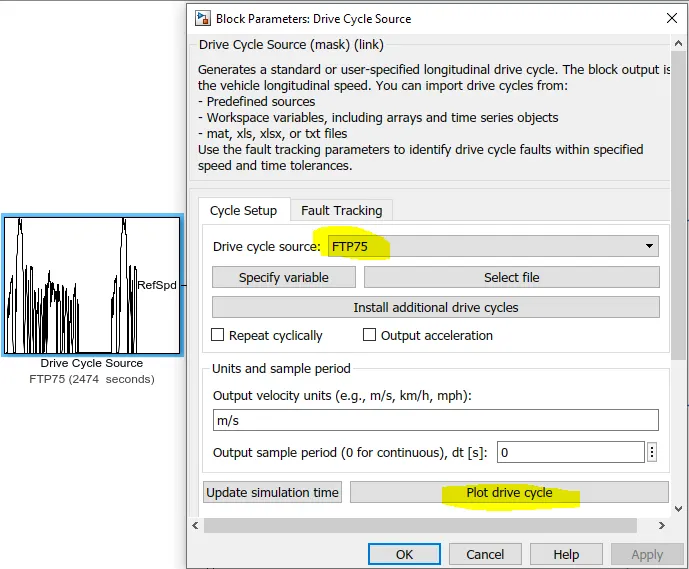
=> The Drive Cycle Source block generates a standard or user-specified longitudinal drive cycle.The block output is the specified vehicle longitudinal speed.
11.FTP75:
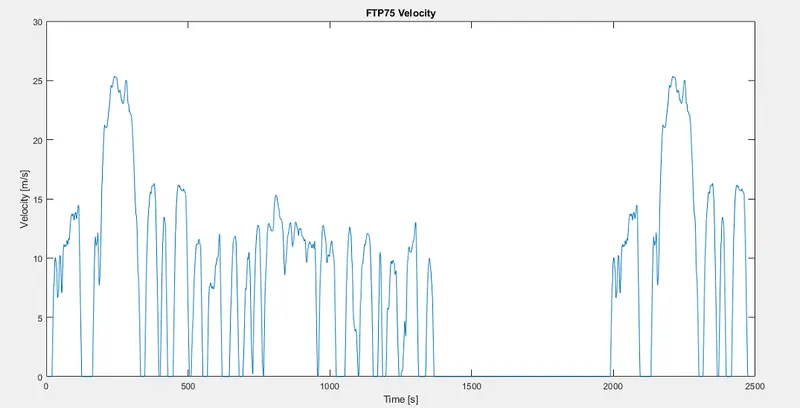
=> FTP75 used to generate velocity across vehicle and evaluate the vehicle performance.
=> Run Time:2474sec.
12.Battery:
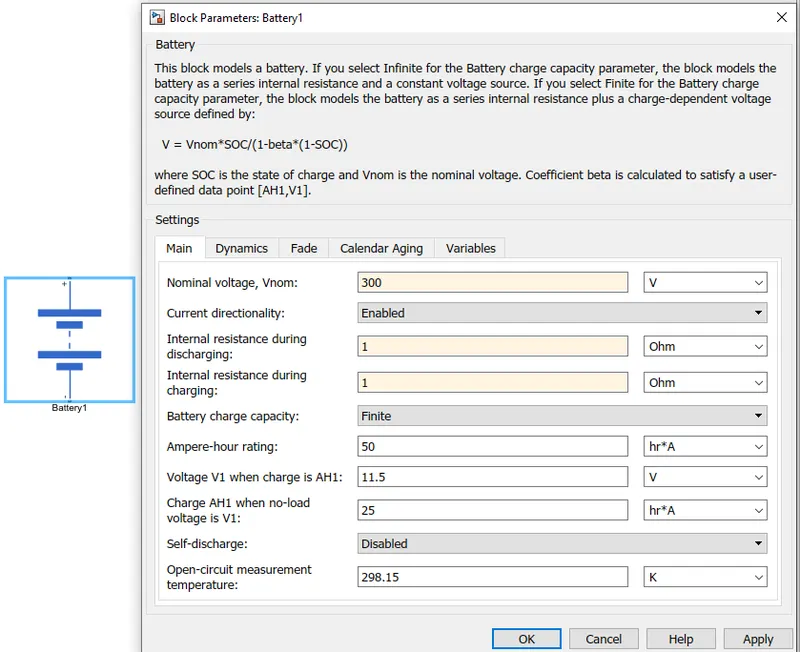
=> This block represents the Physical model of battery.
=> Battery voltage=Motor rated voltage =300v.
=> Amphere-Hr rating =50AH.
13.Calculation Of State of charge (SOC):
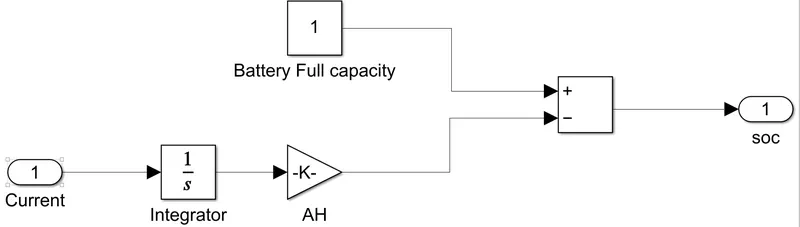
=> To calculate the SOC from current (I) utlisied by motor is defined as
`SOC(t)=(1/C)int_0^tI(t)dt`
where C= Battery capacitance(AH)
I= current
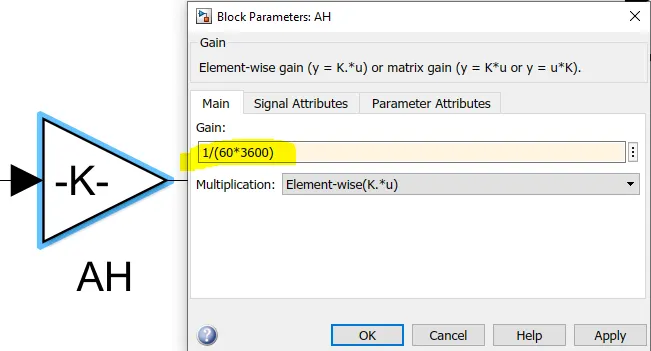
Simulink model of SOC: Current is Integrated and Divide with battery Ampere hour rating (Gain Block)in seconds then subtracted the obtain result from battery full capacity.
Result(1):
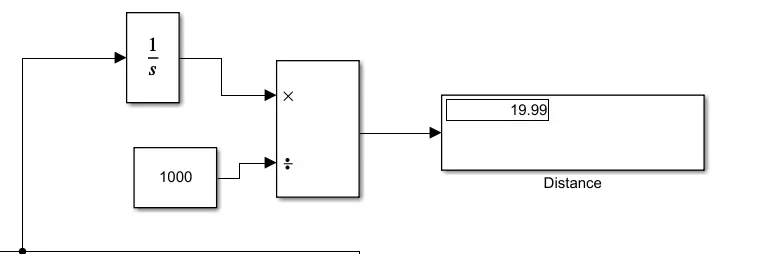
=> In this case the vehicle covers a distance of 19.99 km after 2474 sec with a max speed of 26 m/s.
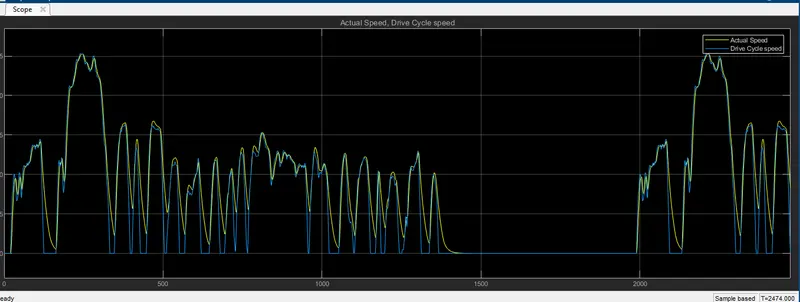
=> When the Motor Rated Load mechanical power is 450 kWatt & rated DC supply voltage is 300 Volt.
=> from the above scope, we can see that the Blue line indicates the FTP75 Drive cycle & the Yellow line indicates the actual Drive cycle covered by the vehicle.
=> The maximum speed achived by the FTP75 drive cycle is slightly more than 26 m/s or 93.6 km/hr but the actually the vehicle can move with a maximum speed of approximately 26 m/s or 93.6 km/hr.
=> So from the above plot, we can understand that the actual drive cycle follows the path of load Drive cycle such as FTP35 but keeping this motor rating we can't match the maximum speed achived by FTP35 drive cycle.
=> In order to increase the maximum speed of the vehicle & to match with the loaded drive cycle we have to increase the Motor rating.
Result(2):
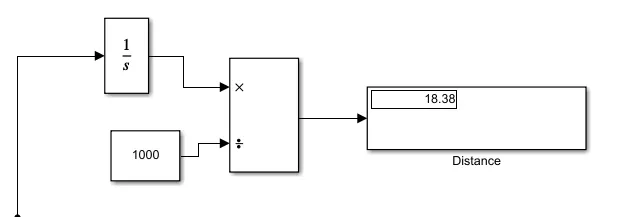
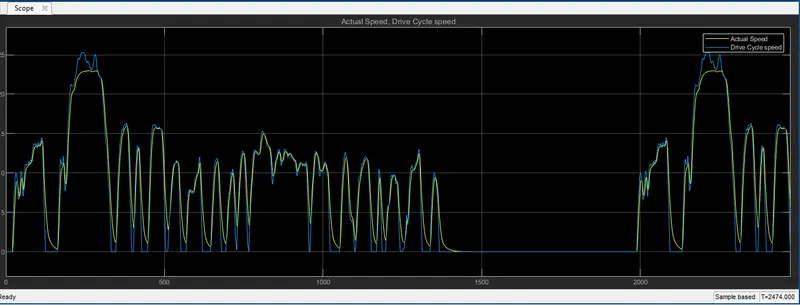
=> If we increase the Mechanical power at rated load into 500 kWatt & the rated DC supply voltage into
600 Volt then we can see that the maximum speed achieved by the vehicle is approximately 26 m/s.
=> still this motor rating is not enough for achieving the maximum speed.
=> Here the vehicle covers a distance of 18.38 km with a max speed of 26 m/s or 93.6 km/hr.
=> so we have to again increase the Mechanical power at rated load.
Result(3):
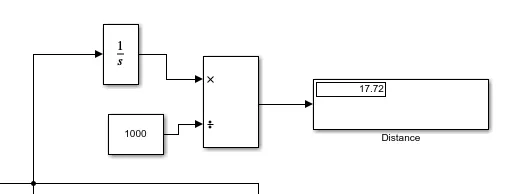
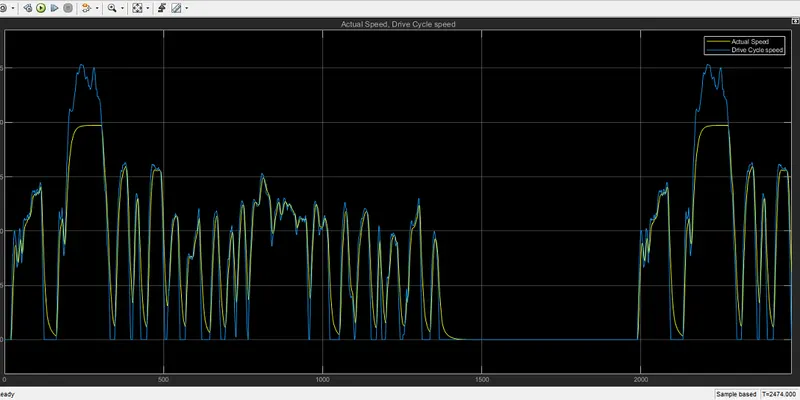
=> Here we have taken the Mechanical power at rated load as 400 kWatt & the Rated DC supply voltage as 700 Volt.
=> from the above plot, we can see that the maximum speed achieved by the vehicle is approximately 19 m/s.
=> we can observe that actual drive cycle fore FTP75 drive cycle. Here the vehicle covers a distance of 17.72 km with max. speed of 19 m/s or 68.4 km/h.
Result(4):
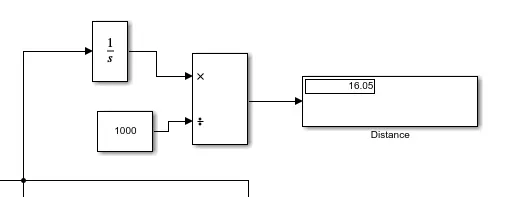
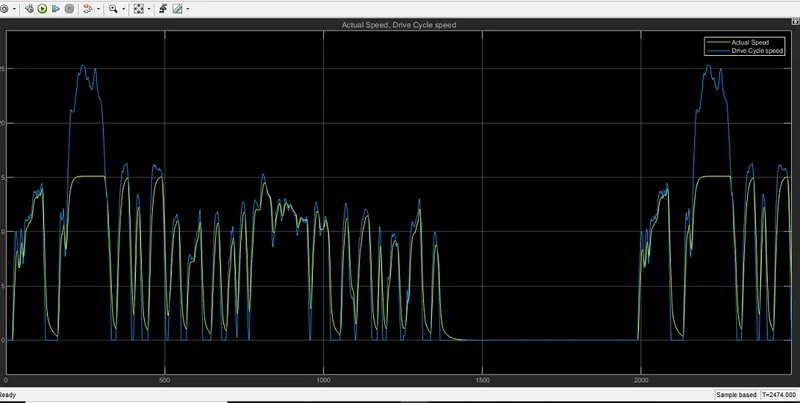
=> Here we have chosen the Mechanical power at rated load is 600 kWatt & Rated DC supply voltage is 1000 Volt.
=> Here we can observe that actual drive cycle less with the FTP75 drive cycle.
=> The maximum speed achieved by the vehicle is 15 m/s.
=> Here the vehicle covers a distance of 16.05 km with a max speed of 15 m/s or 54 km/hr.
=> But still we can observe that there is so much gap between the actual speed & FTP drive cycle speed.