Final Project: Design of an Electric Vehicle
Aim:Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objectives:
To make a most simple and low run time vehicle model using individual components model
To check out performance parameters:
Speed,
SOC,
Current etc.
Introduction:
The electric vehicle's energy conversion efficiency is more than the energy conversion efficiency of a conventional vehicle. The battery is going to be an efficient source of power. The model simulation will provide batterie's behavior, and we can also observe how breaking will charge the battery. Making a Simulink model has a lot of advantages. Before going for a real hardware model, we can observe and validate system key parameters inside a simulation to know how the system will function? Below simulation model will give you an idea about how electric vehicle components are arrenged and how we can achieve optimal performance?
Block Diagram of the Electric vehicle System:
In this challenge, I am going to create a MAtLAB model of Electric vehicle or car. An electric car known as EV electric vehicle, is powered fully by an electric motor and battery. Electric vehicle uses energy stored in main battery, which are recharged by household electricity or charging station. EV's depends on which called as electric propulsion. A vehicle is basically Electromechanical system with a large number of subsystem. The close integration of all the sub-system is essential for deriving the most out of it and making it more efficient.
From the diagram there are five main blocks,
- Vehicle Body
- DC Motor
- DC Motor Driver
- Battery
- Controller
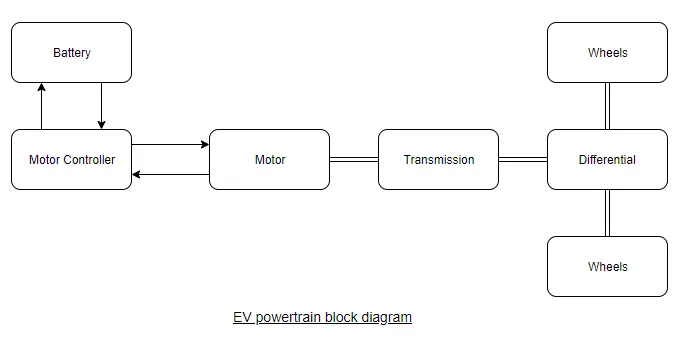
Wheels connect to the Motor is connected to axel of the vehicle system and the vehicle body.
before Battery is connected to directly to the motor will required motor controller. So this motor controller is nothing but to change the speed of the vehicle. If you dirctly connected to battery to the motor. The motor will run to the rated speed and there want be any control over the vehicle.
So We want to control to happen and that is possible power converter.
So this power converter is nothing but H-bridge with Regenerative braking feture so will connect the battery.
Battery will gives supply power converter. Power converter will actually changed the voltage applied to the motor. that will actual change speed of the vehicle
So this is the basic arrengement of the Electric vehicle.
Now we want to actually simulate the situation and we want to run this model for the given input
We need to have throttle and break pedal in our hand that is nothing but drive cycle input
So if you decide that what speed we want to run your vehicle
You have to give drive cycle input that is nothing but speed at what speed we want to run your vehicle
This is drive cycle input and Driver controller which ill actually tracK of the actual speed of the vehicle and which will match with given input.
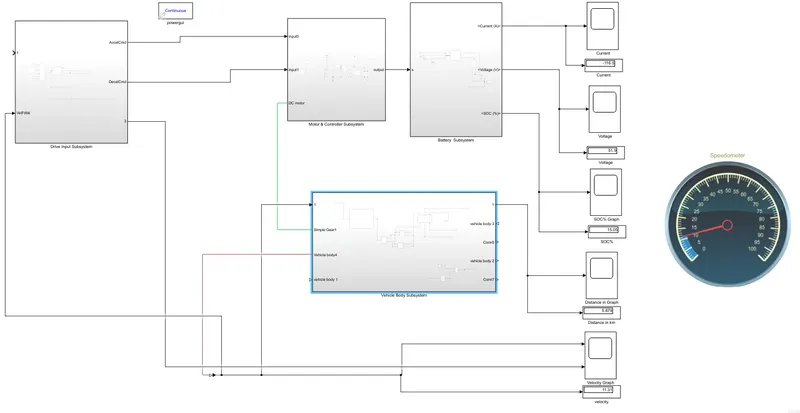
Above is the image of the electric vehicle system this is the sinulink block diagram, which contains block from the library browser.
Model Parameters:
Simulink Model:
When working with a bigger models, it is good idea to create a subsystem. In order to group of component into a single block. You can easily create a subsystem. I have divided the simulation system into a Four subsystem.
- First subsystem contains the vehicle body.
- Second Subsystem contains the motor and controller circuit.
- Third Subsystem contains the Battery pack.
- Fourth Subsystem contain the Drive input.
We see one by one,
1. Vehicle Body Subsystem:
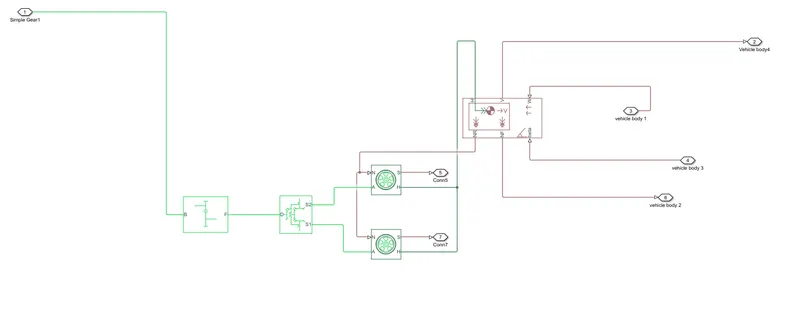
Below we can see the model of vehicle body. The Ev model is the combination of both Electrical and Mechanical parts. The mechanical parts in the system include tires, vehicle body, transmission(simple) gears, differential, and the motor. The tires and the vehicle body are formed into a subsystem to separatre the mechanical component from that of electrical components. We can change the block parameters as per our requirements.
The image of the subsystem is attached below.
Subsystem blocks are explained below:
1. Vehicle Body:
These is the block of vehicle body which represents a dual axel vehicle or a 4 wheeer. There are 6 ports.
The following image shows the Vehicle body block from Powertrain block set.
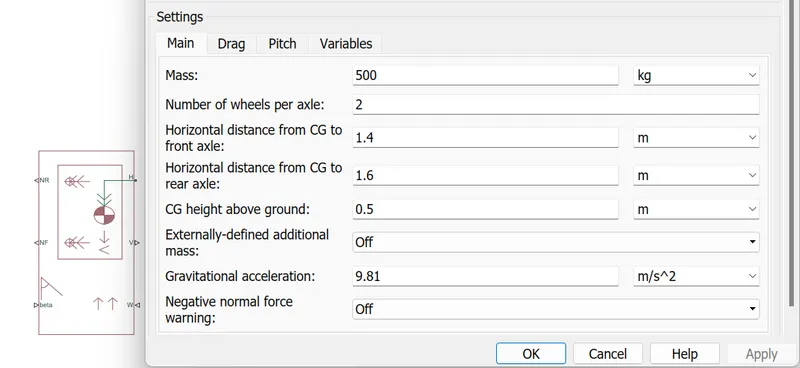
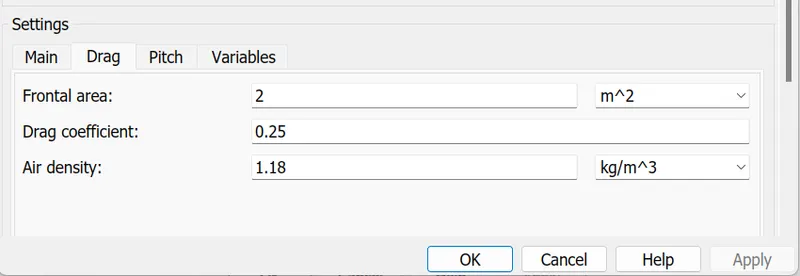
The Ports W and beta are physical signal input ports which are for wind speed and inclination of road respectively.
Connections to V, NF, and NR are physical signal output ports for the velocity of the vehicle.
Front axel and Rear axel it is a normal forces and the H is for Horizontal motion and the tie is connected to this port.
2. Tire (Magic Formula)
We have selected the tire(Magic Formula).
The following image shows the Tire block from Powertrain block set.
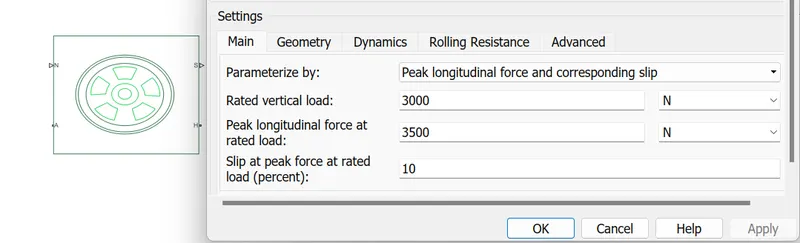
There are two connection ports.
connection N - is a physical signal input portthat applies the normal force acting on tire.
connection S - is a physical signal output port that reports the tire slip.
There are two conserving ports:
Connection A - Represent axel on which the tire are mounted.
Connection H - Represent wheel hub which transmits thrust generated by the wheel to the body of the vehicle.
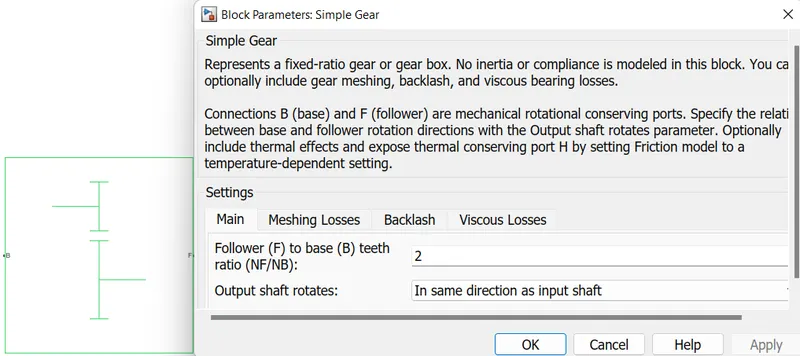
3. Simple Gear:
This block is used for giving a fixed gear ratio. This is a mechanical component and can be avoided, but it ives users the ability to adjust vehicle speed with respect to the rpm of the motor.
The following image shows the Simple gear Powertrain block set.
4. Differential Block:
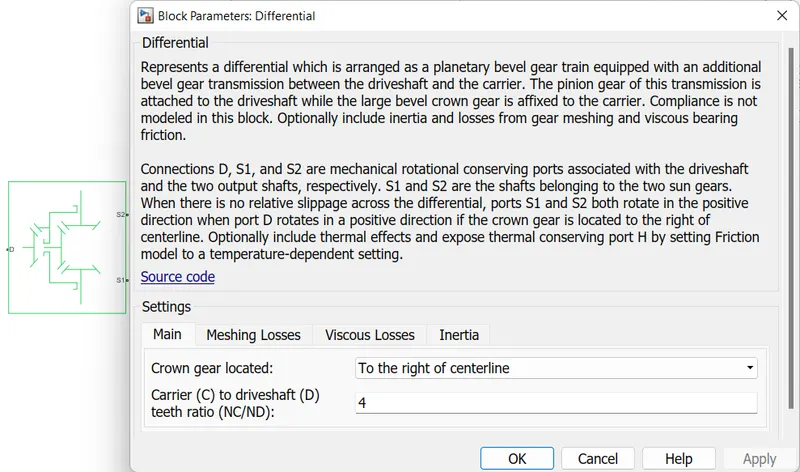
The differential block is represent the Gear mechanism that allows driven shafts to spins at different speed.
The following image shows the Differential block from Powertrain block set.
2. Motor Circuit and Controller Subsystem:
Component needed are a DC motor, H-Bridge and controlled PWM voltage, which produces Pulse width modulated signal to control voltage fed to H- Bridge as per requirements. Regenerative breaking approach is added.
The image shows of the Motor circuit and controlled subsystem.
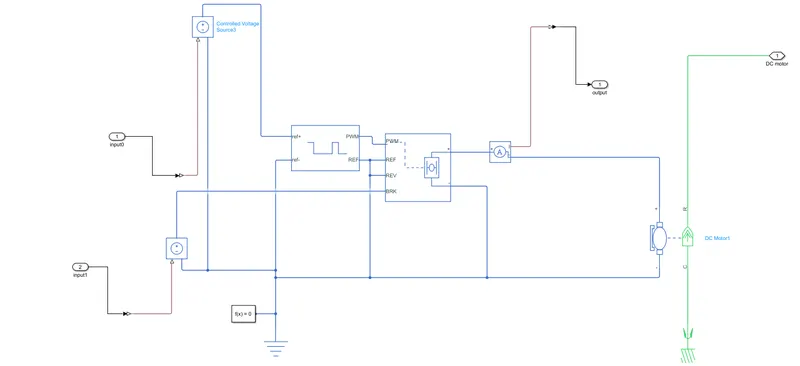
Subsystem Parameters are explained below.
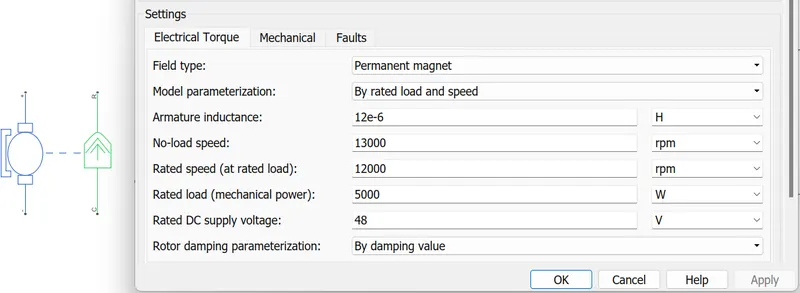
1. DC Motor
The Motor will take controller power from the battery and convert electrical energy to mechanical energy. Different types of motors can be used to drive the wheels. so we using the DC motor. The purpose of the dc motor in electric vehicle is to drive the tires/wheels.The one side of the DC motor block is connected to the vehicle body blocks, and the other side is connected to DC motor driver, which controls and rotates the motor.
The following image shows the DC motor block from Powertrain block set.
2. H-Bridge Motor Driver
The H - Bridge block is used to drive a motor. The H bridge two output ports
Positive Port
Negative Port
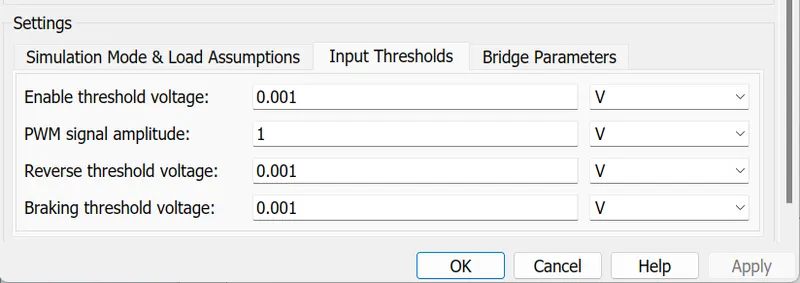
This port is directly connected to the motor that has to be controller. There is also a REV port.When the reverse threshold voltage is lower than the REV port voltage,the polariy of the motor is reversed, and if the BRK port voltage is greater than the value of breaking threshold voltage, it indicates that the vehicle is in braking condition.
The following image shows the H-Bridge Motor Driver block from Powertrain block set.
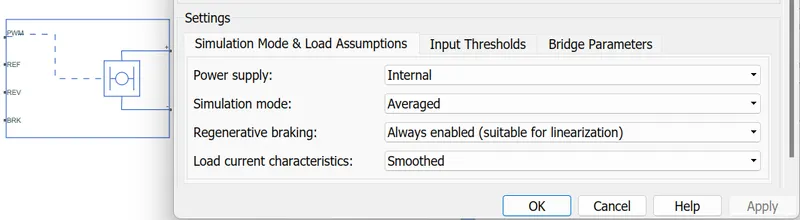
I Have changed the Input Thresholds as per our requirements
3. Controlled PWM Voltage Source
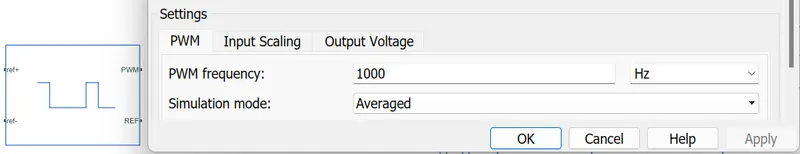
The PWM signal is used or controlling the speed of the traction motor. This block is used for providing a controlled PWM voltage output.
The Duty cycle is given by,
100*(Vref-Vmin/Vmax-Vmin)
Where,
Vref - is the reference voltage across the ref+ and ref- ports.
Vmin - denotes the minimum reference voltage.
Vmax - denotes the minimum reference voltage.
The following image shows the Controlled PWM Voltage Source block from Powertrain blockset.
4. Current Sensor
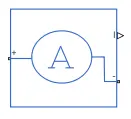
This block is used to measure the flow current through of circuit.
5. Controlled voltage Source
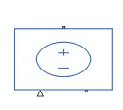
The controlled voltage source block is used to give a constant voltage output. It has two electrical conserving ports and a physical signal port. The output from the controlled voltage source is fed to the controlled PWM voltage source.
3. Battery Pack Subsystem:
The following image shows the Battery Pack Subsystem.
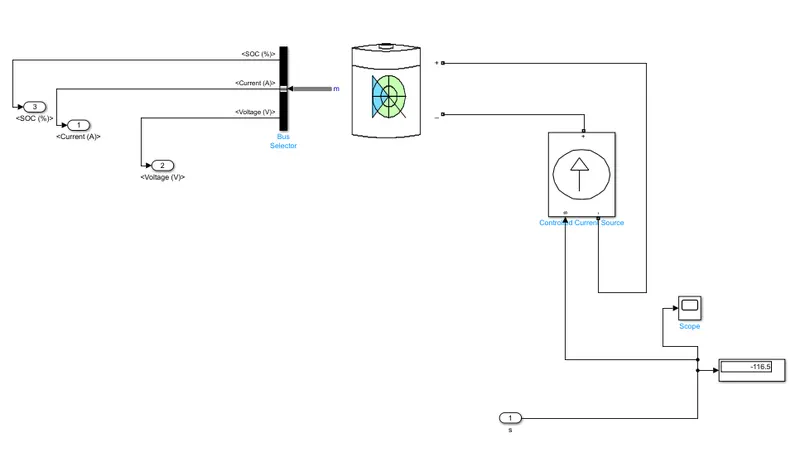
Subsystem Parameters are explained below.
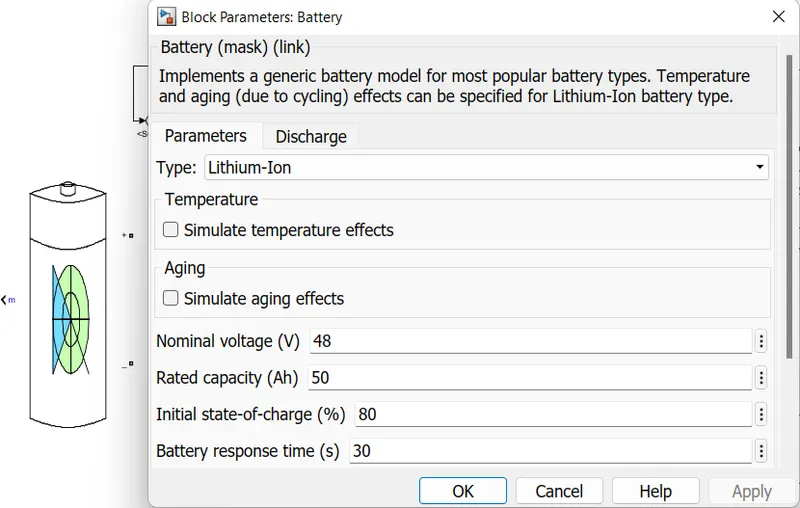
1. Li-ion Battery:
The Battery block implements a generic dynamic model that represent most popular types of rechargeable batteries.
The following image shows the Li-ion Battery block from powertrain blockset.
2. Current Controlled Source:
The Controlled Current Source block converts th Simulink input signal into an equvivalent current source The generated current is driven by the input signal of the block.
The following image shows the Current Controlled Source block from Powertrain blockset.
4. Drive Input Subsystem:
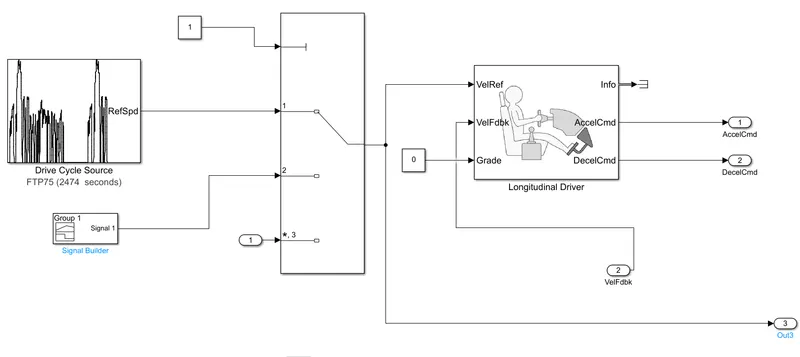
Subsystem Parameters are explained below.
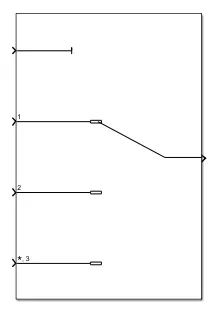
1. Multiport Switch
A multi input port is used in order to provide more number of inputs as per the requirment.
2. Longitudinal Driver Block
The longitudinal Driver Block acts as an actual driver who interprets the vehicle speed command from the reference signal. This block use the external action to input signals that can disable, hold or override the close loop commands determined by the block.
The following image shows the Longitudinal driver block from Powertrain blockset.
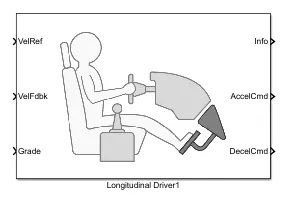
The block is capable of taking feedback velocity of the ehicle and changing the speed by giving output signal, it can decide when the vehicle needs to be accelerated and when the break need to be applied.
3. Drive Cycle Source
The Drive cycle source block is used to provide the refernence Speed of the simulation.
The following image shows the Drive Cycle Source block from Powertrain blockset.
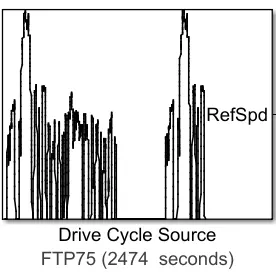
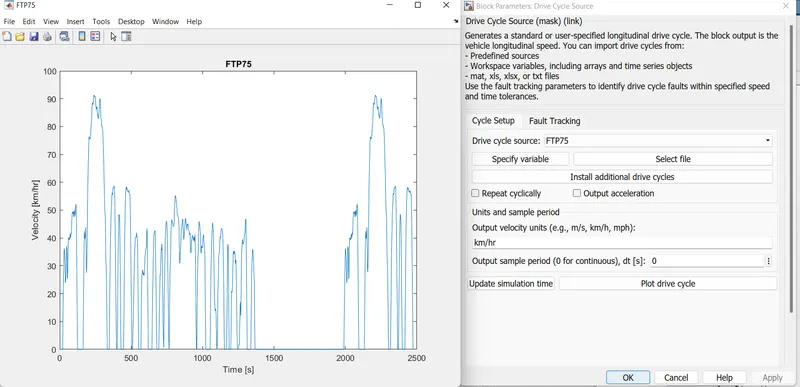
There are many Drive cycle sources as well as we can generate our own signal by using signal builder. So I used the FTP75 Drive Cycle Source block to create the Drive input.
4. Testing and simulation
After designing the circuit, all thet is left is testing the circuit. We usually need to put scope at any point in the circuit to measure the desired parameters. The scope module looks like the one shown below.
The scope can have multiple inputs, and the real time output is displayed when the simulation
Overall Model of Electric Vehicle:
Result:
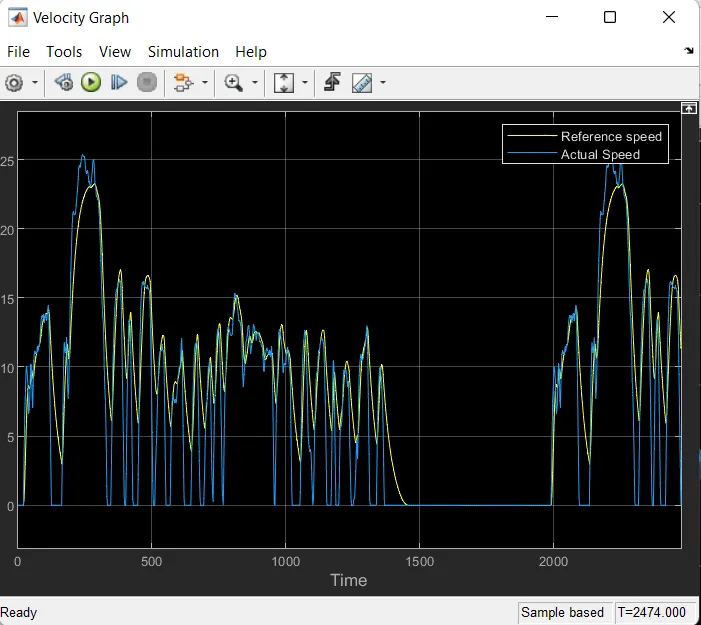
First, with the aid of the Drive Cycle source FTP75. Each drive cycle has its own time duration.So the Drive Cycle source FTP75 has time duration is 2474 seconds.
Below the image shows the how the velocity of the vehicle actual speed is following the reference speed of the input drive cycle.
SOC (%) Curve
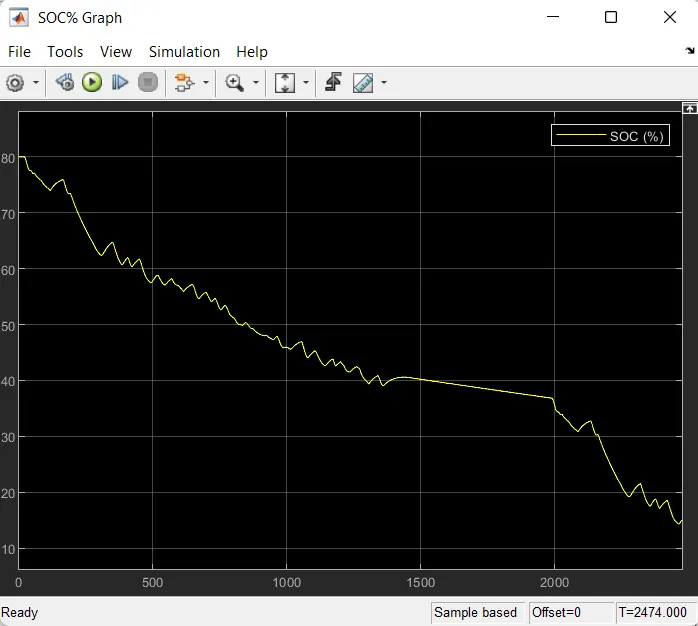
The graph of the SOC percentage.
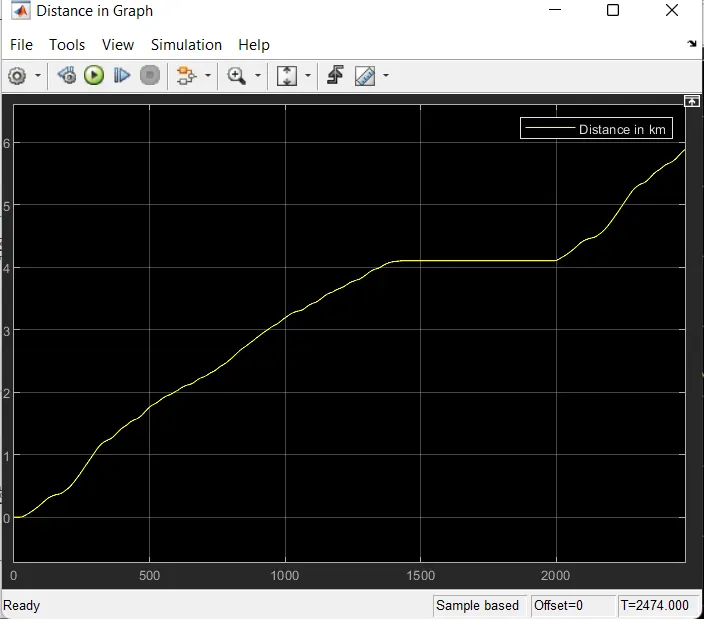
The SOC of vehicle after running for 2474 seconds the battery has changed intermittently from 80% to 15.5% so approximetly 16%. During this vehicle has travelled for 5.8 Km. Trend is decreasing but during some time it is increasing. The SOC increases beacause Regenerative breaking.
Distance travelled ( km )
It is the total distance travelled by the vehicle 5.8 Km.
Current Curve:
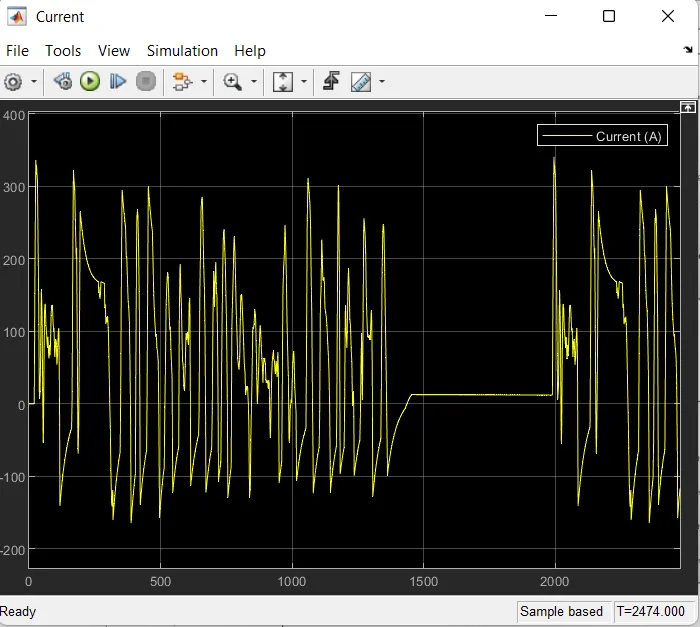
The Current graph, we can see that the maximum current value during normal driving is 340A. and during the breaking te current is having a maximum value of 116.5A but in the opposite direction. The nature of the current drawn by the DC motor accordance with Driving cycle is shown below.
Conclusion:
The Matlab model of an Electric Vehicle or car has been successfully made by choosing Suitable blocks from powertrain block set. We understand how to make the model of Electric vehicle by using powertrain blockset.
So we conclude that the Vehicle speed and reference drive cycle were plotted. The SOC State was observed for the entire duration. as well as we observed the total distance travelled by the vehicle 5.8 Km.