Side Pole Crash Simulation on Vehicle Structure
OBJECTIVE
- To check the unit system and either follow [Mg mm s] or [Kg mm ms].
- To create the appropriate interface, friction 0.2, and recommended parameters.
- To make sure there is no penetration and intersection.
- To create a rigid wall with friction 0.1.
- To compare the model weight with the reference model and use added masses to reach target weight 700 kg while getting CG about the required range.
- To provide an initial velocity of 35 mph.
- To use the model checker to ensure good quality
- To assign min. time-step: 0.5 to 0.1 microseconds.
- To simulate for 80 ms.
- Output Requests
- Sectional force in the cross member.
- The intrusion at B pillar, hinge pillar, and fuel tank region, and to provide recommendation on what can help to reduce fuel tank intrusion.
- Peak velocity of an inner node of the door.
PRE-PROCESSING
The first objective of the challenge was to check the unit system. Fig. 1 shows the cad model of the bumper. From fig. 1, and fig. 2, it is certain that the [Kg mm ms] unit system has been followed.
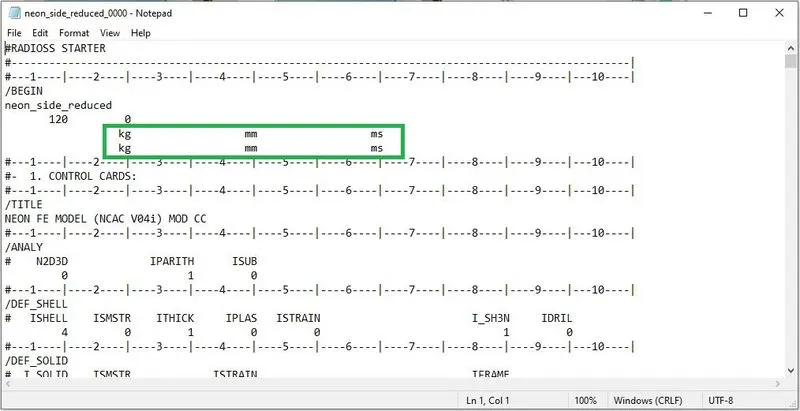
Figure 1: The unit system mentioned in the starter file is [Kg mm ms].
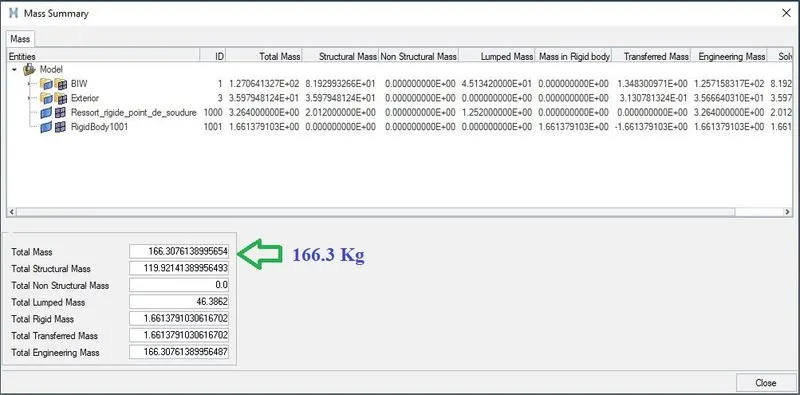
Figure 2: Mass summary of vehicle, mentioning it as16.3 kg.
In material property, the E value is equal to 210. That must be in GPa or kN/mm2. The density value is equal to 7.89e-06, which must be in kN/mm3.
The total mass of a vehicle is generally measured in tonnes. However, because of the software limitation of 100k nodes, the vehicle body size is reduced to 88734 nodes. And therefore, the total mass of the vehicle body is reduced to 166.3 Kg, which further has to increase to 700 Kg.
The second objective of the project was to create the type 7 interface. The type 7 interface is the general node-to-surface contact for any application. It is much recommended for self-impacting simulation.
Now to create this type 7 interface, firstly, all the existing interfaces were deleted, and type 7 was newly created by right-clicking in the solver deck, and selecting Create → INTER → TYPE7, as shown in fig 3. In the TYPE7 card, all the nodes and all the elements were selected as a slave and the master respectively. The Istf is kept equal to 4, which computes for minimum initial contact stiffness between slave and master. The Igap was kept equal to 3 which maintains the variable gap taking into account the size of the mesh to avoid any initial penetration.
Idel was kept equal to 2 which deletes the segment of the master side when any linked element is deleted. The minimum stiffness was kept to 1 kN/mm. Friction value, and min. the gap was kept equal to 0.2 and 0.5 respectively. Inacti was kept equal to 6 to avoid any initial penetration. Now, Inacti is the flag that allows to relax from initial penetration. In type 7 of an interface type, when a gap is defined around the master surface and slave nodes, if the nodes of the slave are inside the gap region of the master and/or vice-versa, it is called initial penetration. This initial penetration develops an error in the results; thus, it is always good to not have any initial penetration or intersections. Keeping Inacti = 6, it de-penetrates the model by moving the node slightly, and the gap is going to be varied with time. Iform was kept to 2 to allow stiffness formulation.
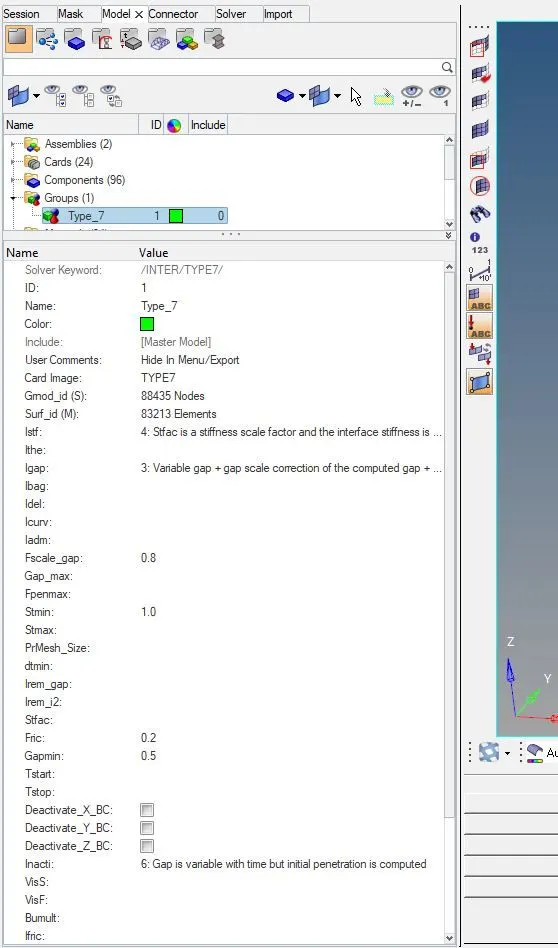
Figure 3: Type 7 interface card.
While defining the type 7 interface card, the preventive measure has been taken to avoid any initial penetration or intersection, if any exist. Yet it is better to check manually if any penetration exists in the model. To check that, there is a tool in Tools → Penetration Check. The complete component was selected to check for any penetration in the whole model. When the tool checked the model, it found no penetration in the model, which was a good sign.
Now, for a side-crash to occur in the simulation, a pole was required. In the solver deck, right-clicking the mouse and selecting the Create → RWALL → CYL, a cylindrical rigid wall card gets created, as shown in fig. 4.
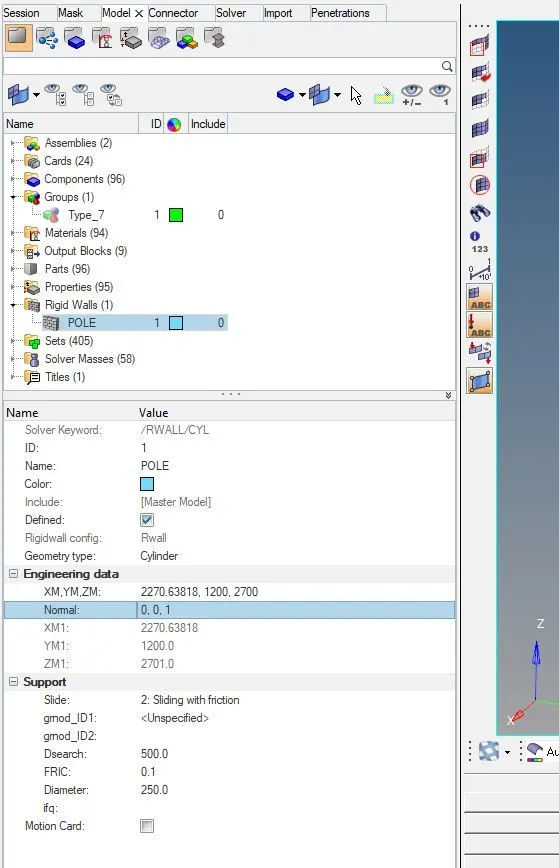
Figure 4: Cylindrical rigid wall card.
The XM, YM, ZM is the co-ordinate of the base node, which was selected from the outer-most area of the B-pillar. The direction of the normal vector was given perpendicular to the roof. The Support → Slide was kept to the ‘Slide with friction’, and the FRIC value was given as 0.1. The Dsearch, which is a search distance, is given as 500. Fig. 5 shows the view of the rigid wall.
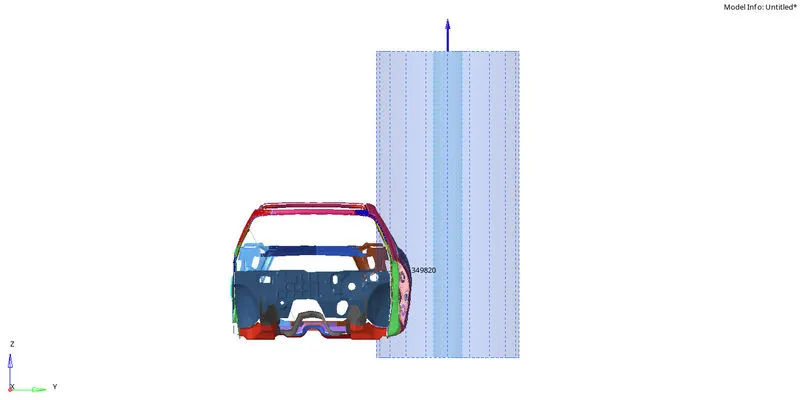
Figure 5(a): Side-view of model showing the position of the pole.
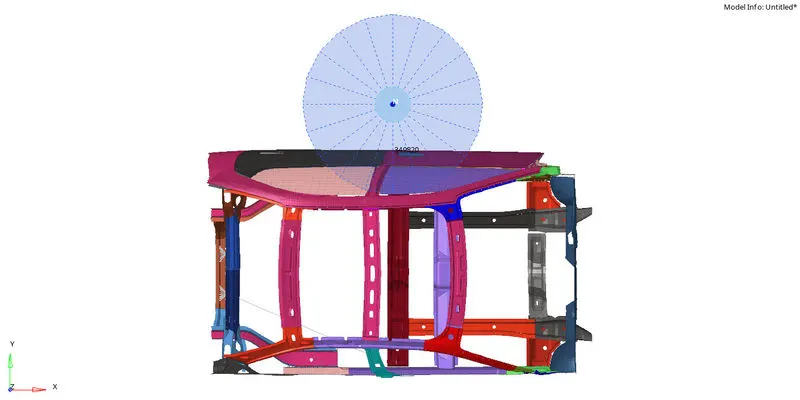
Figure 5(b): Top-view of model showing the position of the pole.
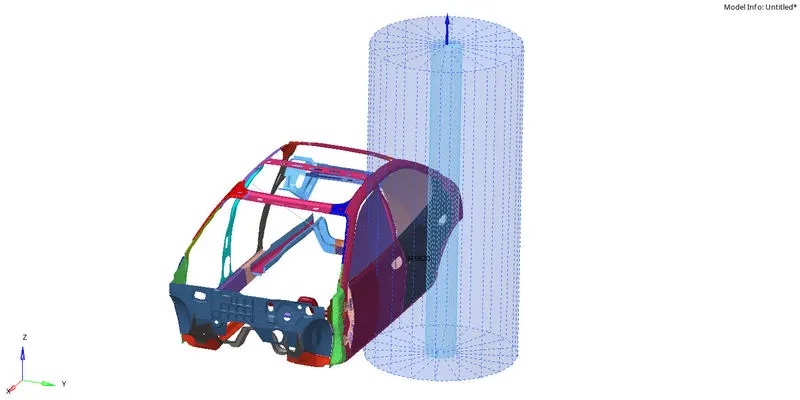
Figure 5(c): Isometric view of model showing the position of the pole.
It was required to keep the overall mass of the vehicle to 700 kg, however, using Tools → Mass Details → Mass, Cog, and Inertia, it was found that the existing mass of the vehicle was only 166 kg. Also, the COG must be in line with the cross beam of the driver seat, which is not there as required. In the solver tab, right-clicking and selecting Create → ADMAS, a mass can be added to the set of nodes. Selecting this tool, a mass was adjusted in the rear as well as front, on a trial-and-error basis, to bring the cog on the cross beam of the driver seat, and to increase the overall mass of the vehicle to 700 kg.
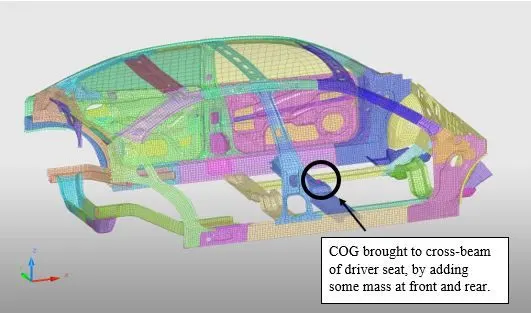
Figure 6: Using ADMAS some mass was added in front and rear to do the mass-balancing and bring the COG point to in-line with the cross beam of the driver seat.
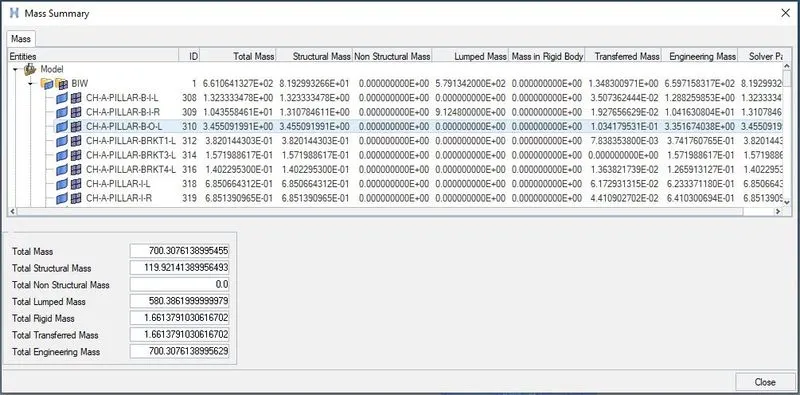
Figure 7: Total mass of the vehicle is increased from 188 kg to 700 kg.
When the model is ready for the simulation environment, boundary conditions are required for the simulation to occur. In this crash project, the initial velocity is one of the boundary conditions. The initial velocity of 35 mph to be applied to the vehicle. Because, the working unit is [Kg mm ms], the initial velocity is 15.6464 mm/ms. Fig. 8 shows the INIVEL card with all values mentioned. To apply the initial velocity, right-clicked in the solver tab, and selected Create → BOUNDARY CONDITIONS → INIVEL. In that INIVEL card, all the components of the vehicle were selected for assigning the initial velocity, and the velocity of 15.6464 was applied in the y-direction, i.e., in the direction of the pole.
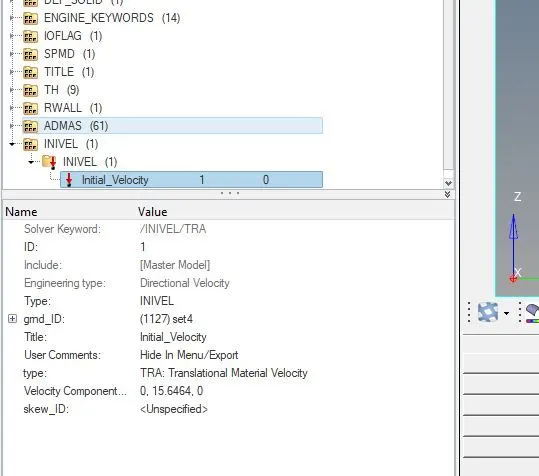
Figure 8: INIVEL card to assign initial velocity.
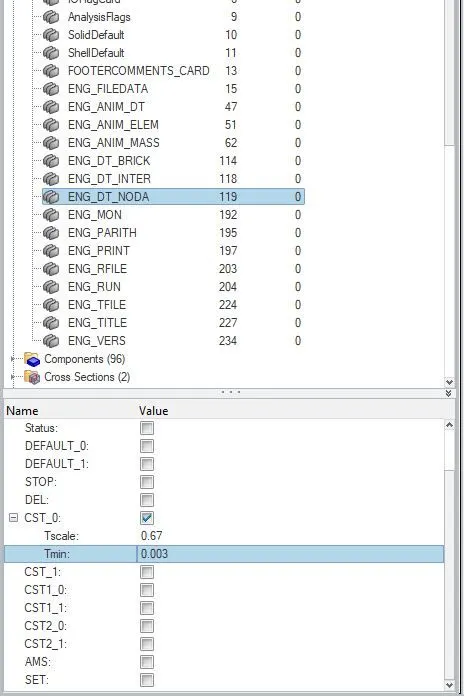
Now, the time-step was required to be 0.5 to 0.1 microseconds. Thus, in the Cards of Model tab, ENG_DT_NODA is opened. In that card, CST0 formulation is selected to maintain constant time-step. The minimum time-step, Tmin of 0.3 microseconds, or 0.003 ms, Tscale of 0.67 is applied, as shown in fig. 10.
|
Figure 9: ENG_DT_NODA card with 0.3 microseconds of time-step applied. |
The engine run-time was required to be 80 ms. Thus, in the Cards of Model tab, the ENG_RUN card was opened. In that, the Tstop value changed to 80 ms, as shown in fig. 10.
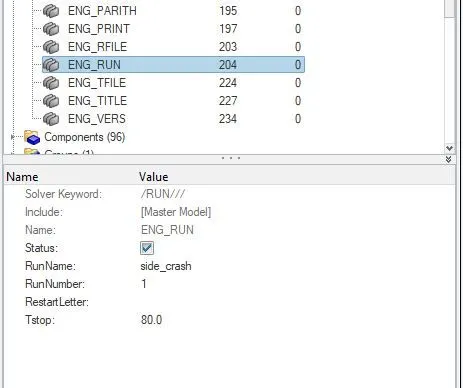
Figure 10: ENG_RUN card with Tstop value of 80 ms.
For getting the desired results like sectional force in cross-members, a moving frame is required. To create the moving frame, right-clicked in solver tab, and Create → FRAME → MOV was selected. It was a moving frame card, using which a moving frame was created corresponding to the global coordinate., as can be seen in fig. 11.
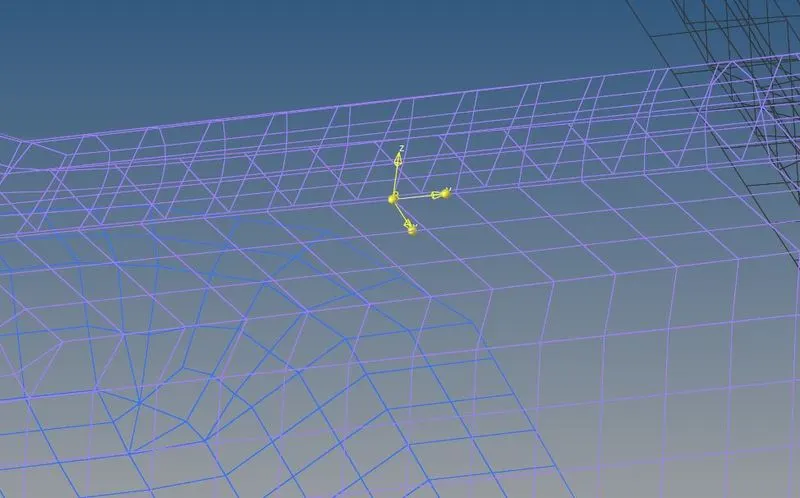
Figure 11: Moving frame on cross-beam.
After introducing the moving frame, further a cross-section is also required around that frame. Thus, right-click in the solver tab, and Create → SECT → SECT was selected. In that card, Frame_ID was the moving frame that was created, grshel_id was the set of elements defining the cross-section. After assigning all the parameters, it appears as shown in fig. 12. Fig. 12 showing the sections created on two cross-beams.
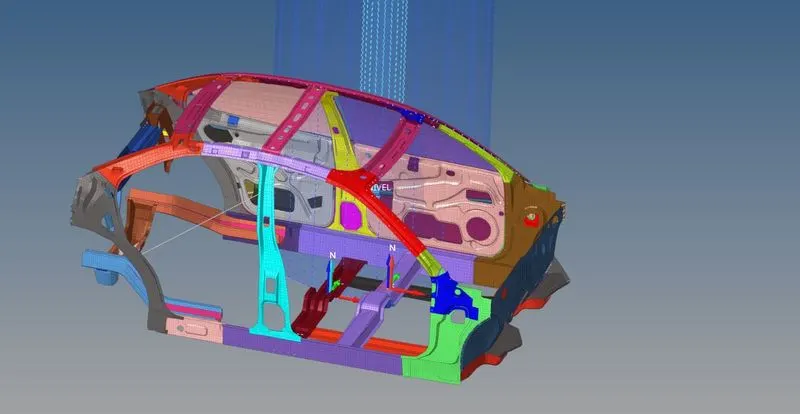
Figure 12: Moving frame and section applied on cross-beams.
After creating these moving frames and sections, their results have to be requested. Thus, right-click in the Model tab, and Create → Output Block was selected. It requests the time history file. In this card, ENTITY ID is selected as the Crosssections that were created earlier, and in that, the cross-sections were selected for time history. Fig. 14 shows the output block card.
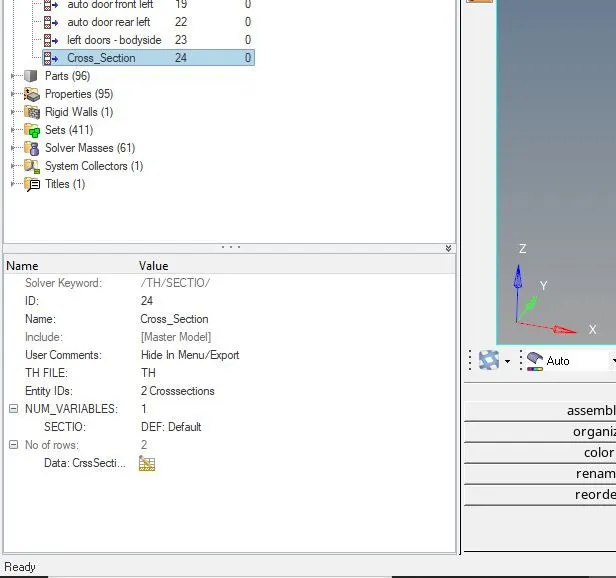
Figure 13: Output block card for getting the time history of the cross-section.
The structure had to check for intrusion on the end of the B-pillar, hinge pillar, and fuel tank region. To do that, a skew was created in line with those nodes by right-clicking in the solver tab and selecting Create → SKEW → MOV. Once created, then, an output block was created in which ENTITY ID is selected as the node on which intrusion has to be analyzed, and Iskew is selected as the corresponding skew in-line with that node.
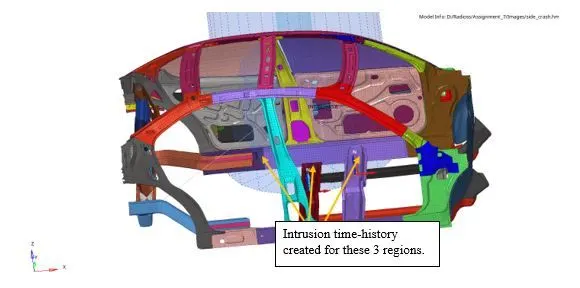
Figure 14: Intrusion created for the ends of B-pillar, hinge pillar, and fuel tank region.
|
Intrusion time-history created for these 3 regions. |
It was also required to check for the peak velocity on the inner node of the door. The procedure for creating the card to check the peak velocity is as same as the procedure of creating the card to check intrusion. A skew was created in line with the node on the inner side of the door.
SOLVER
When the model is ready with all the properties and boundary conditions defined, it is ready for the simulation to run. The model was saved and using Analysis → Radioss, a simulation was run. Four cores of the system were used by giving command -nt 4.
POST-PROCESSING
Output File Check
The run took 6856.2 seconds i.e., 1 hour 54 minutes 16 seconds, to simulate the model, as can be seen in fig. 15.
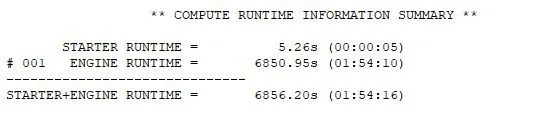
Figure 15: Run has taken 6856.2 seconds to simulate the model.
When the output file was checked for the errors, it was found that there was no mass error occurred during simulation. Also, the energy error of -1.6 % is acceptable. Thus, the simulation that occurred is acceptable.
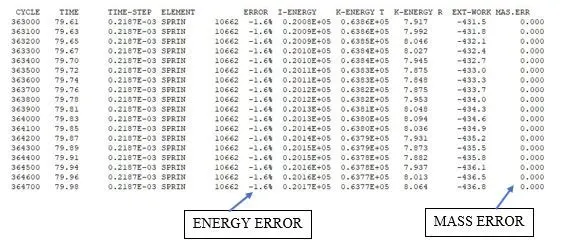
Figure 16: Increased energy error and mass error.
Contour Plot
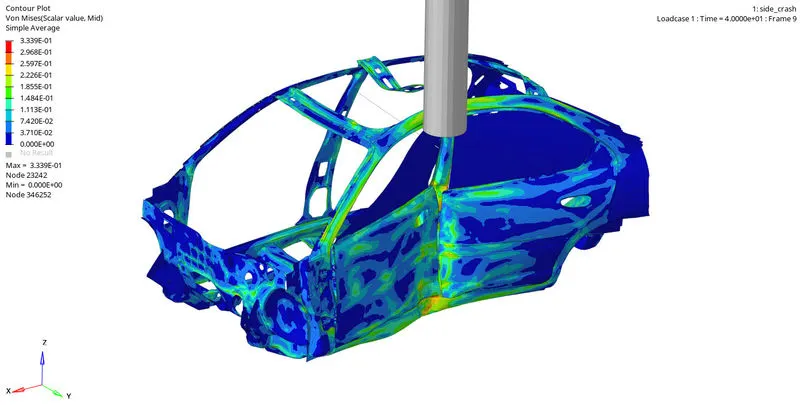
Note: The simulation appears like the pole hit the vehicle's roof. It happened due to a graphical issue. The pole is infinite, thus the graphical issue doesn't matter.
Fig. 17 shows the Von-Mises stresses developed in the vehicle structure during side crash, with the maximum value of stress is equal to 351.7 MPa. From the simulation, it is found that during side-crash, the cross-beam of the driver seat gets highly affected.
|
Figure 17: Von Mises stresses developed in the vehicle structure during a side crash. |
In fig. 18, it can be seen that the mode of deformation of cross-beam is not the acceptable one. The C-shape in the cross-beam is making the cross-beam weaker and thus needs some re-development.
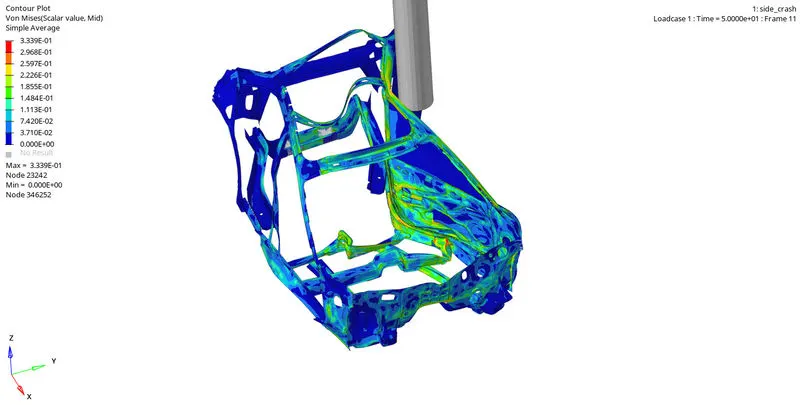
Fig. 18: Figure showing the distorted cross-beams after side-crash.
Fig. 19 shows the plastic strain developed in the vehicle structure with the maximum value of 0.67. It shows that no significant plastic strain has developed in the large area of the structure which is a good sign.
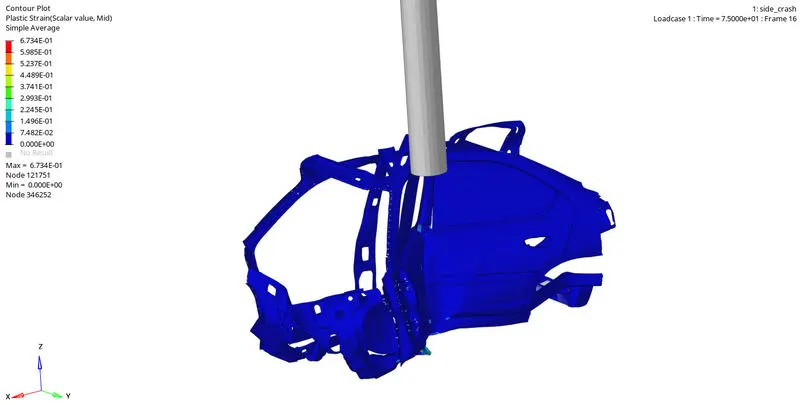
Figure 19: Plastic strain developed in-vehicle structure during a side crash.
Graphs
Fig. 20 showing the plot of a global variable. It shows that till 13 or 14 ms, the crash has not occurred, and thus the values of kinetic energy (KE), internal energy (IE), and total energy (TE) were constant. Once the crash occurred, the vehicle's kinetic energy started transferring to internal energy arising due to the deformation of the elements. The normal value for contact energy is 0 to 0.5% of total energy, and the normal value for hourglass energy is 10 to 15% of total energy. The plot shows that both the contact energy and hourglass energy are within the acceptable zone. The QEPH elements (improved integrated elements) have helped to reduce the hourglass effect.
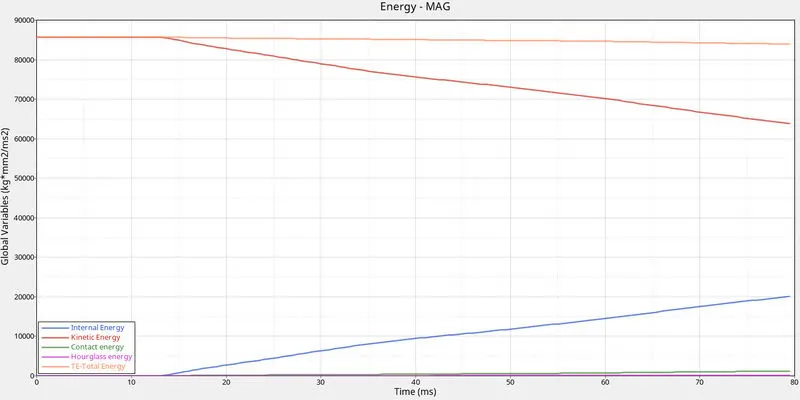
Figure 20: Plot of global variables.
The nature of force distribution in cross-members is shown below figure. Fig. 21 shows that once the crash started tremendous deformation has occurred, which kept rising. The red line is the cross member of the driver seat. The deformation in that cross-member is almost equal to the other cross-member. It suggests that the mode of deformation is not safe for the driver.
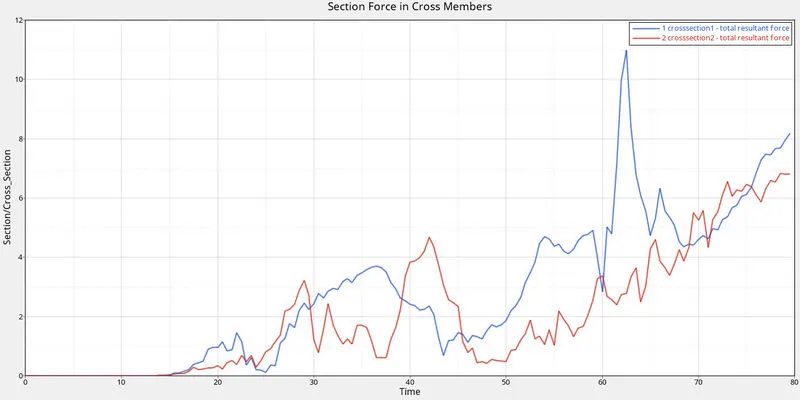
Figure 21: Plot of total resultant force in cross-members.
The figure below shows the intrusions in the hinge, B-Pillar, and fuel tank region.
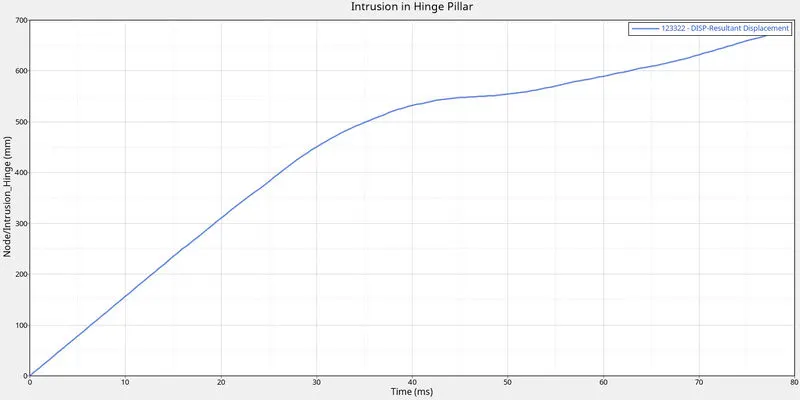
Figure 22: Plot of intrusion at the end of hinge pillar.
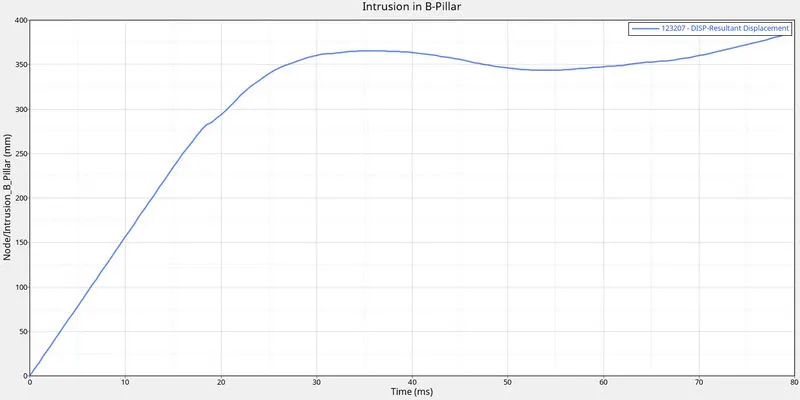
Figure 23: Plot of intrusion at the end of B-pillar.
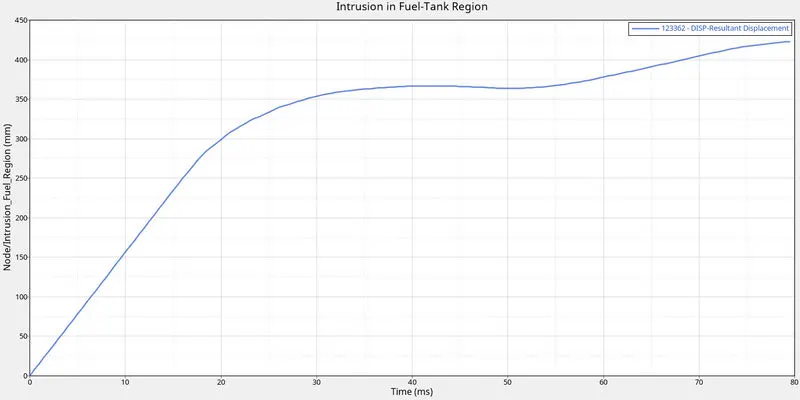
Figure 24: Plot of intrusion in the fuel tank region.
There was an intrusion of 700 mm, 400 mm, and 425 mm respectively. It is a very huge amount of deformation to be noted. For making the occupant safe, an energy absorber has to be put in the door-side. The 425 mm of deformation in the rocker near the fuel tank region is a critical condition. Such heavy deformation in the fuel tank region could worsen the condition of the crash.
As can be seen in fig. 12 and fig. 14, no cross-member is there in the fuel tank region. This unavailability of cross-members enhances the possibility of severe deformation occurring. To avoid such heavy deformation, especially in the fuel tank region, cross-member with stiffer material has to use.
Fig. 25 shows that the maximum velocity of 16 mm/ms has occurred on the inner side of the door. It occurred when the impact started.
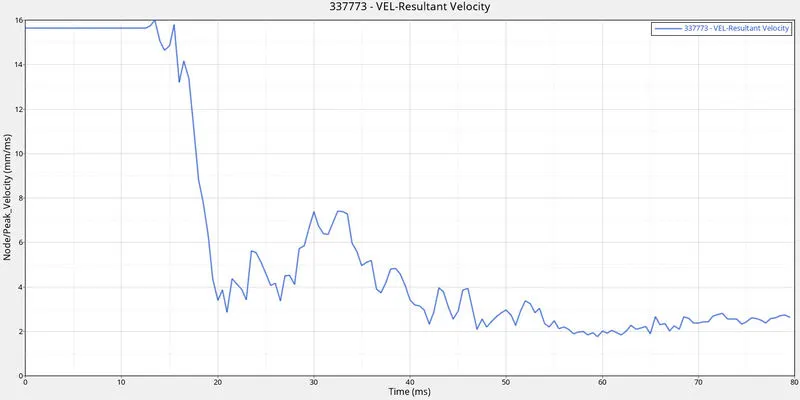
Figure 25: Velocity vs. time plot during simulation.
CONCLUSION
The side-crash simulation on vehicle structure showed very undesirable results, which could severely harm the occupants. There was a limitation of software on the nodes of the model. Thus, the model of the vehicle structure is not the full-fledged one. And therefore, many of the members of the structure are missing in it. Thus, the result cannot give the perfect idea of the safety of the occupant. However, it indicated the importance of cross-members in the vehicle structure. It needs more attention while designing and developing it.