Side Crash Analysis on a Dodge Neon BIW model using Hypermesh and RADIOSS.
Project-2 Report.
- Aim: To perform the deck set up and run the Side Crash simulation on the given Dodge Neon BIW model.
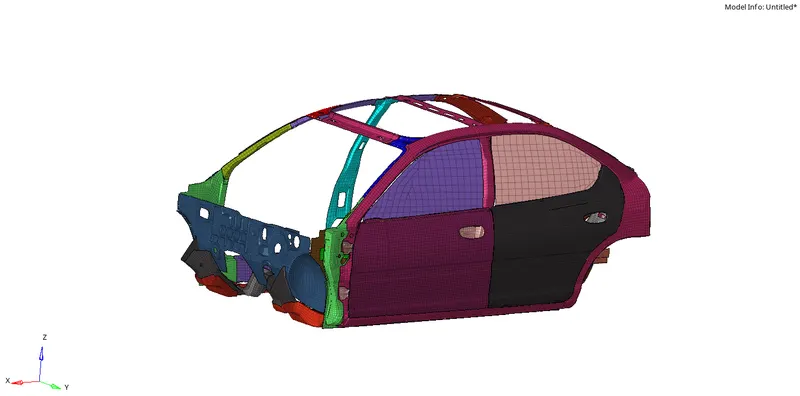
Initial model. - Objective: 1. To Check for Penetration and Intersections.
2. To create Appropriate Contact Interface wherever needed.
3. To create a Rigid Wall for the simulation.
4. To increase the weight of given model to about 700kg.
5. To give an Initial Velocity of 35mph to the model.
6. To create Sections and measure Sectional Forces across them.
7. To measure Peak Velocity on a Inner node on the Door. - Procedure:
1. The very first step in the solver deck setup of this model is to check the units in which the Geometry has been modelled. To do this, we need to use the Begin card in the Model tab as shown. Here we can view the basic units of Mass, Length and time that were used in the model.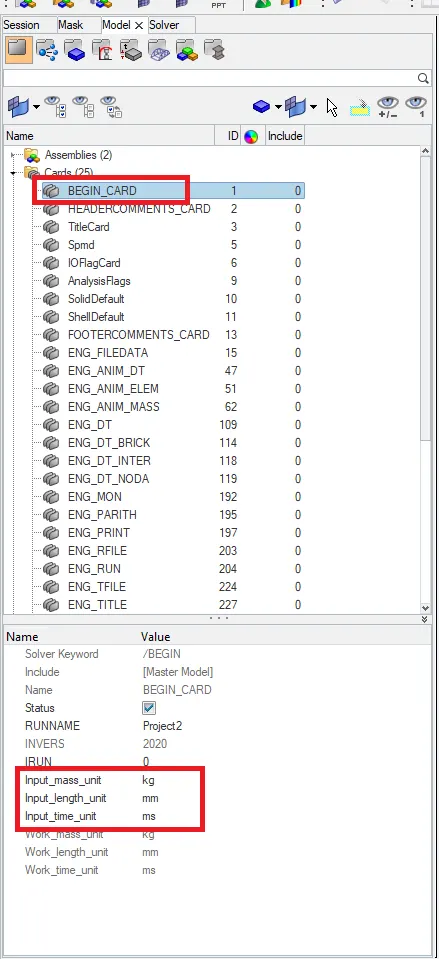
Begin Card.
We can see that the units of Mass, Length and Time are Kg,mm and ms respectively.
2. After the units were confirmed, we then proceed to check for penetration and intersections in the model. To do this, we simply need to use Hypercrash and use the Penetration checker in the model. We can use this option in the Quality Tab and use the option of Check All Solver Contact Surfaces.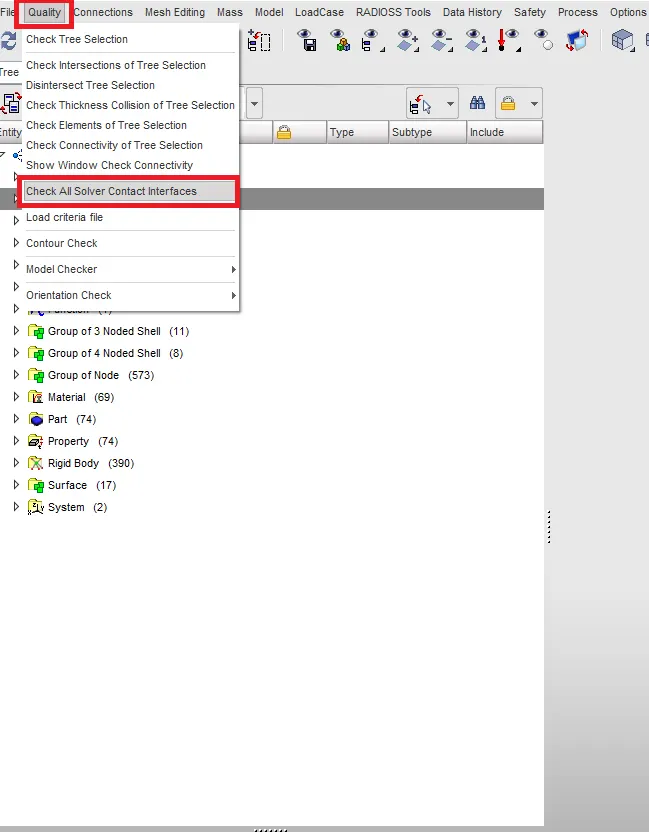
Quality -> Check All Solver Contact Interfaces.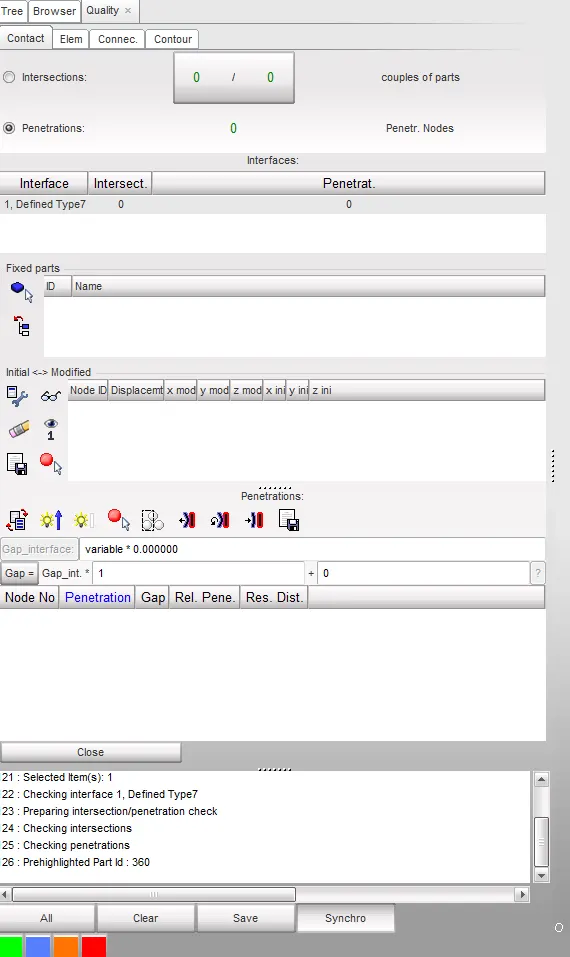
Total Intersections and penetrations.
We can clearly see that there are no penetrations and intersections in the model.
3. After this, we then go onto create a Self impact contact interface. And for this we simply right click in the tree and use the Create New option and use the Contact interface option in it as shown.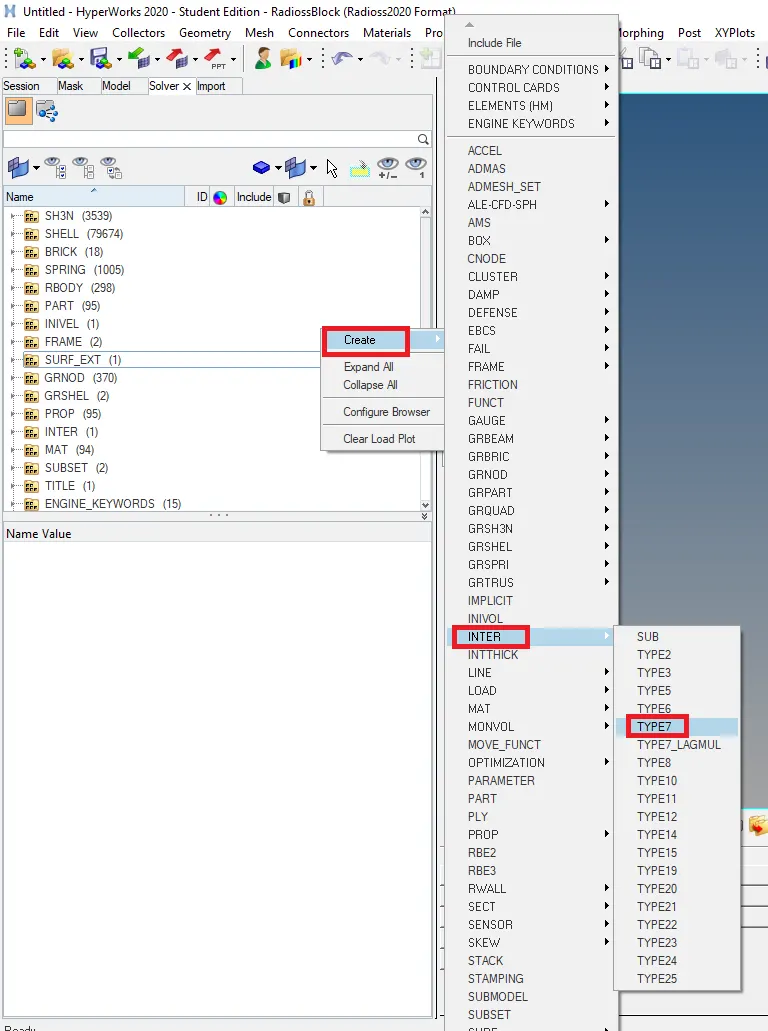
Create -> Type7 contact.
Like this, we can create a Type 7 contact. Now in this contact we need to define the basic properties such as Igap, Istiff, Inacti etc. We simply change their value to the recommended value.
Here are the recommended values for a Type7 Contact:
1. Istf = 4 (Stiffness based on the Softer segment.)
2. Igap = 2 (Variable Gap taken into account.)
3. Idel = 2 (Remove Slave nodes from contact because of element deletion.)
4. Inacti = 6 (Reduce gap by 30% more than the defined gap.)
5. Iform = 2 (Frictional forces are calculated according to the Stiffness parameters.)
6. Stmin = 1000N/mm (Minimum stiffness to avoid a too soft contact.)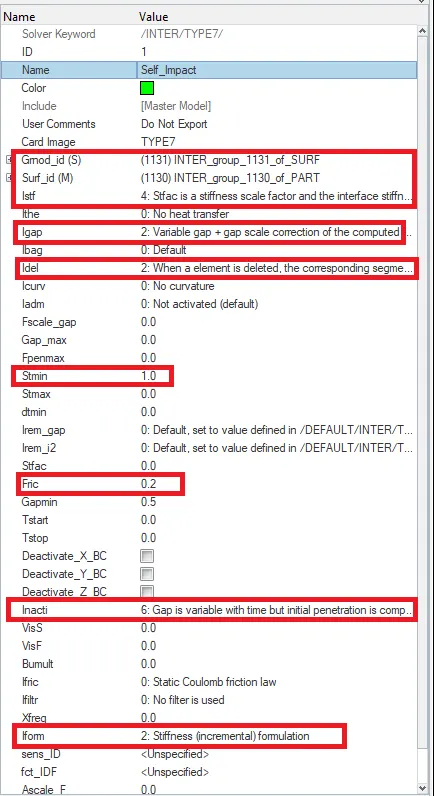
Recommended Properties.
Then after this step, we simply need to give in the Slave nodes and the master segment. Since we are defining a Self Impact in the model, the Slave and Master segments for this contact will be the entire given model. So, we then select the slave and master in the graphics area.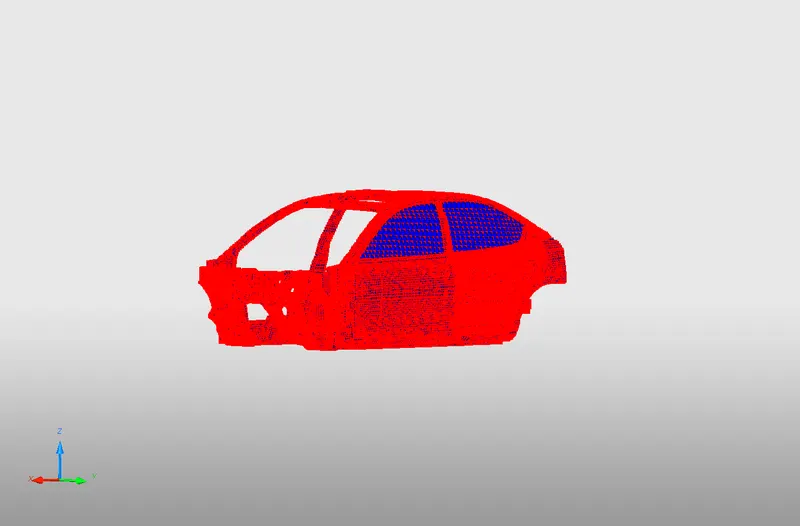
Self Impact Contact Defined.
4. After this step, we need to check all the rigid body connections in the model. To see if we have appropriate connections defined throughout the model, we need to do it by visual inspection. So, for this, we simply move around the model and check if two surfaces are connected appropriately. Any two surfaces that have a gap between them must be connected using either Rigid Body connections or even springs in some cases.
In case we get two surfaces, where the contact is not appropriately defined, we then need to add a Rigid body Element or maybe a Spring Element.
5. After checking for all the Rigid Bodies in the model, we then proceed to create the Rigid Wall for the Simulation. To do this, we simple use the Create new option that appears when we right click in the Tree. We need to create a Cylindrical Rigid Wall for this simulation.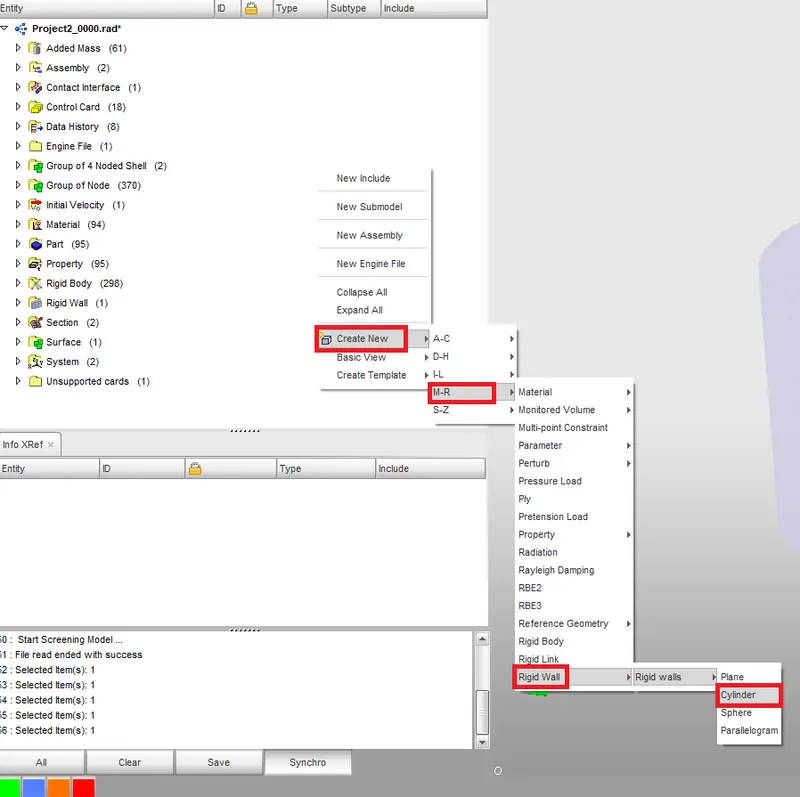
Create -> Rigid Wall.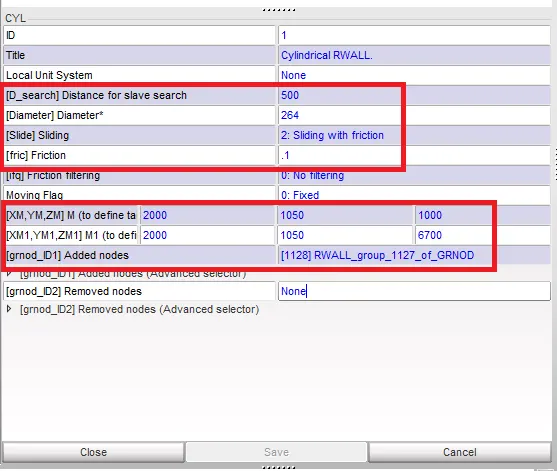
Rigid Wall Properties.
We use the value of 0.1 for friction as requested for this case. The Dsearch distance we can use can be around the range of 500-1000mm.Since this Rigid Wall is in the shape of a Cylinder, we need to give the Diameter of the All the Nodes within this distance will be considered as salve nodes for the contact between the model and the Rigid Wall. We can add seperate set of nodes to this Rigid wall that the system should consider for Slave nodes in the option of [grnod_ID1] as shown. We can use this option and add all the nodes in the model to the Slave nodes.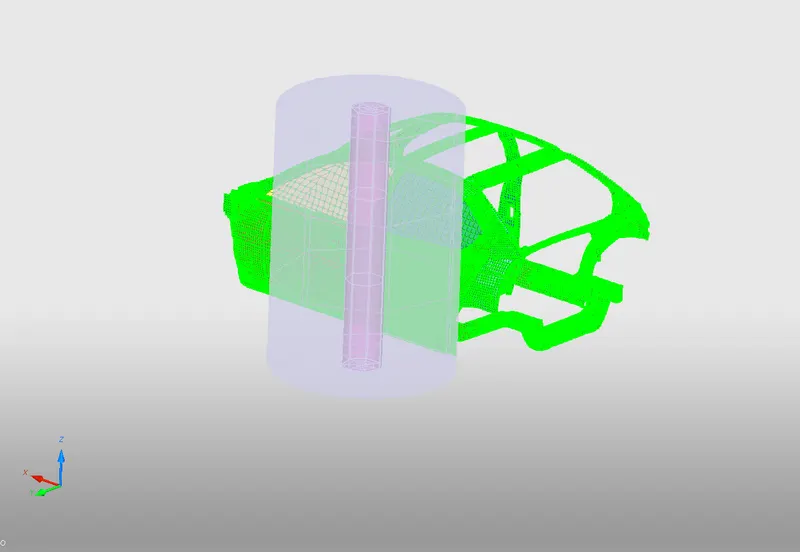
Rigid Wall Defined.
6. After defining the Rigid Wall, the next step is to Balance the mass in the model. The current weight of the model is shown to be around 188kg. But since we need to simulate and replicate the whole weight of the vehicle body, we must increase the weight of the given body to approximately 700kg. To do this, we can simply add mass at various points in the model.
The mass to be added is 700-188 kgs = 512kgs. So, we must add this mass to the various nodes in the model. But, while adding mass to the model, we must also change the location of the COG to the desired range (In general, the COG of the body is under the driver). To add mass in the model, we must use the option of Added mass in the Loadcase tab.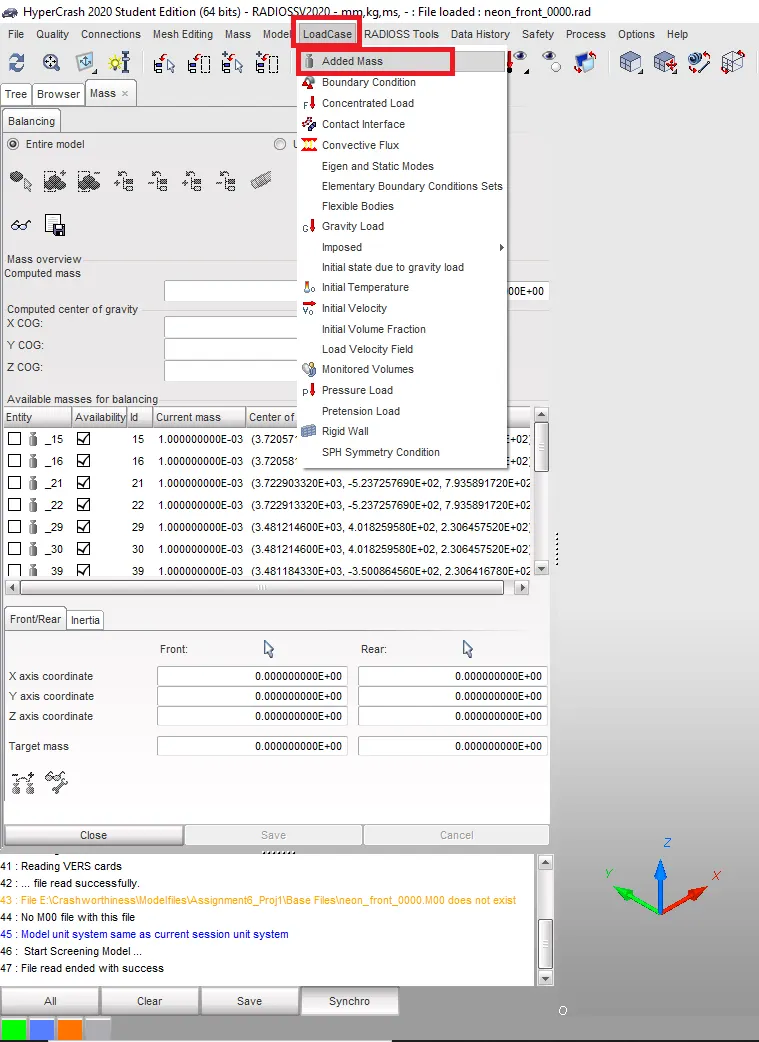
Loadcase -> Added Mass.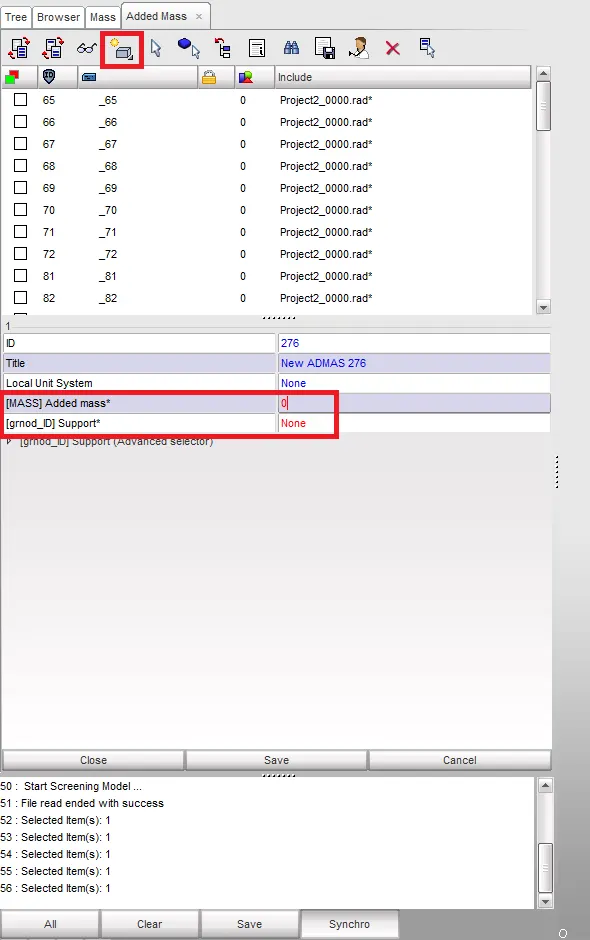
Added Mass command.
Before we can add mass on the model, we need to be careful with the units of the mass. When we began the set up of the model, we set the units of mass as kg. We can add mass on the nodes by creating a new object (from the icon shown in the picture above). Then we must add the amount of mass that we need to add, say for example, If we wanted to add the mass of the seat onto the given model. We will then add another 40kgs on the location of the seat. We need to add select that set of nodes in [grnod_ID] and then add this mass. Just like this, we need to add masses into the model and reach the desired mass of 700kgs for the model. We can confirm the total mass of the model using the Mass -> Balancing command.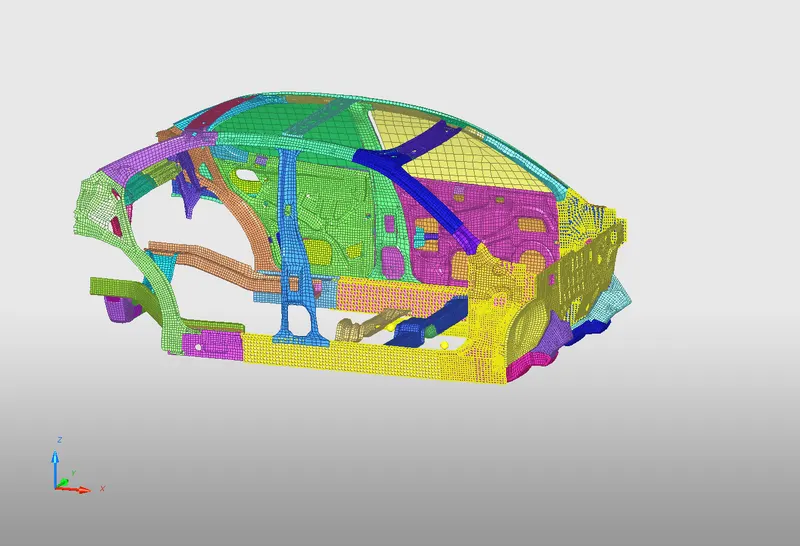
Mass added on the Highlighted nodes.
We can review the CG of the model using the "Show CG point" command.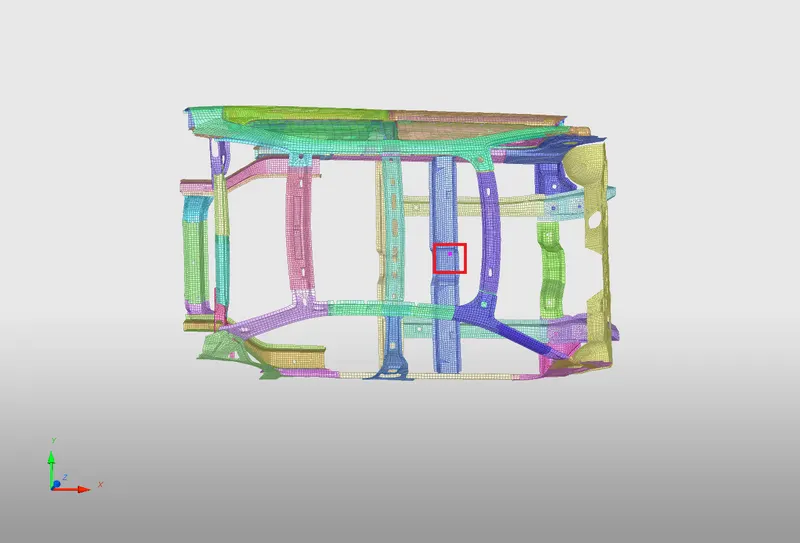
Final COG of the body.
7. After the target mass of the model is reached, then we need to give an Initial Velocity to the vehcile. In our case, we give the initial velocity of 35mph which when converted to mm/ms is around 15.65mm/ms. To give an Initial Velocity to the model, we need to use Initial Velocity tab under the Loadcase tab as shown below.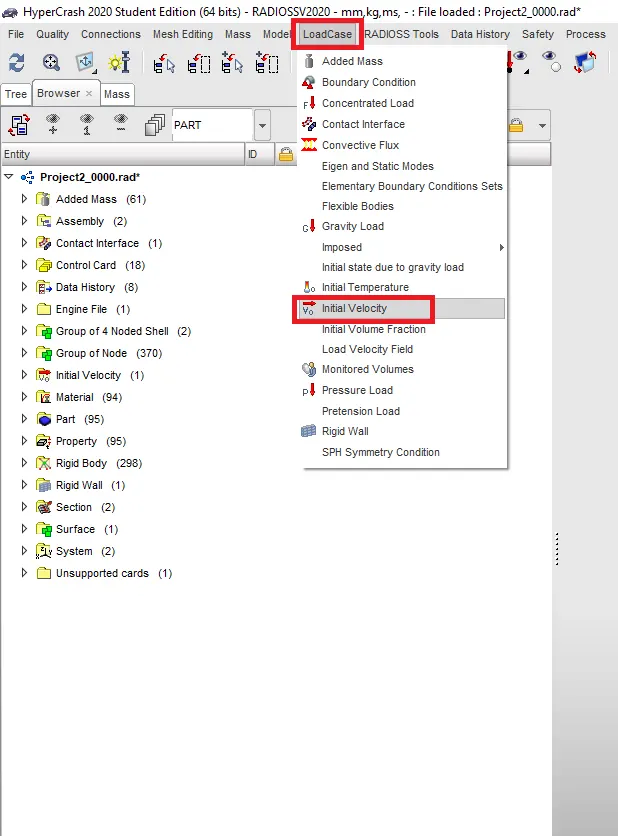
Loadcase -> Initial Velocity.
After we need to select the Direction and the Nodes on which the Initial Velocity is needed to be applied. For our setup we give the magnitude as 15.65 mm/ms and as for the nodes, we need to select the entire body of the vehicle.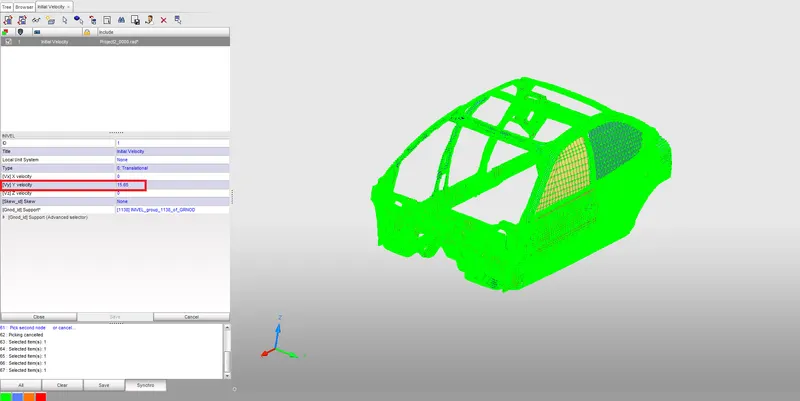
Initial Velocity applied with properties.
8. The next step is to give the Timestep for the simulation. There are various cards that we need to add and give different values for them. For example: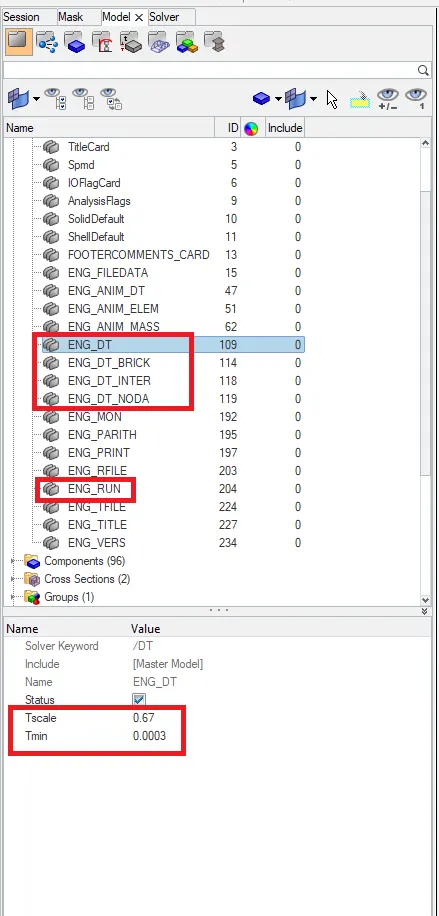
ENG_DT values are shown in the snapshot above.
ENG_RUN has a value of 80.0ms.
ENG-DT-BRICK- Tscale:0.9, Tmin: 0.0001ms
ENG_DT_INTER- Tscale: 0.67, Tmin: 0.0005ms
ENG_DT_NODA- Tscale:0.67, Tmin:0.0001ms
All these values will affect the simulation time and the results we get.
9. The next step is to create sections on the model to study the Sectional Forces on that particular component. So, to define a section, we need to define a Skew first. To define a skew, we simply need to right click in the tree and select the option of Skew. We must select three nodes that will then go on to define the three axes of the Skew system that we are creating.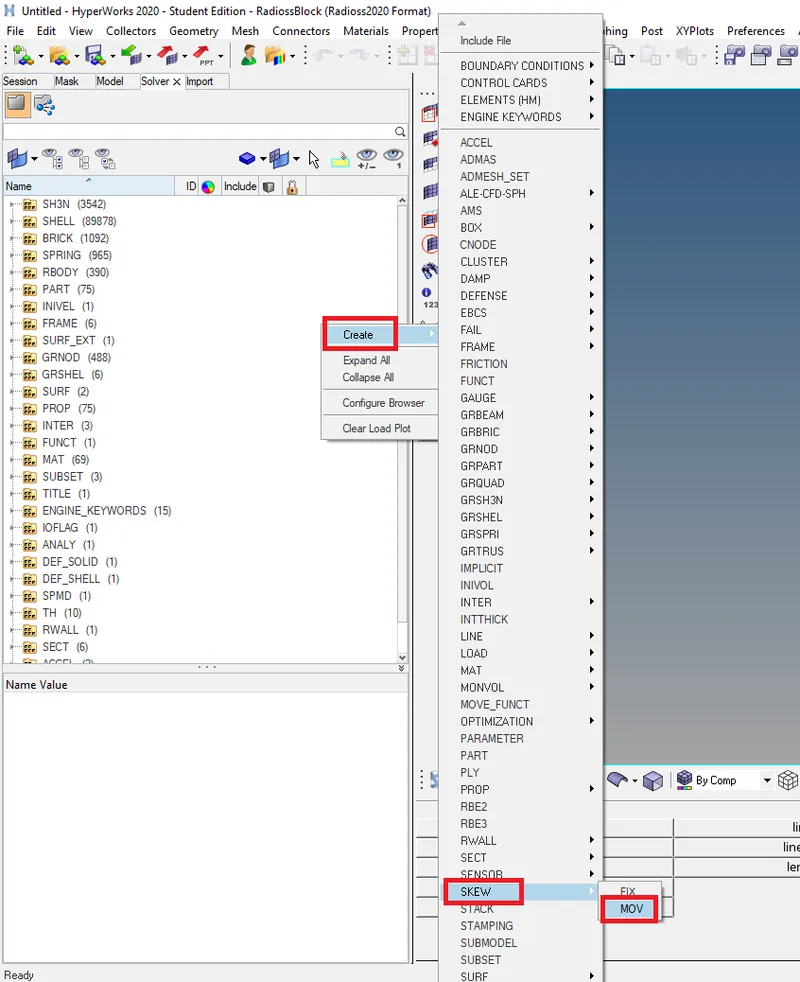
Create -> Moving Skew.
We then need to select the three nodes on which we need the Skew system. In our case setup, we need to define around 2 sections. We need to make sure that the normals of all the sections defined need to be in one particular direction. All the normals can be facing either the wall or even away from the wall.We need to make sure that they are in a single direction.
After we define a Skew, we then need to give the input of all the elements for the definition of the sections. We need to define a section and give in the three Nodes and also the elements on which we need to make the section on.
We can create a Section just in the same way as we created a skew system. We need to right click in the Tree and select Sections as the following: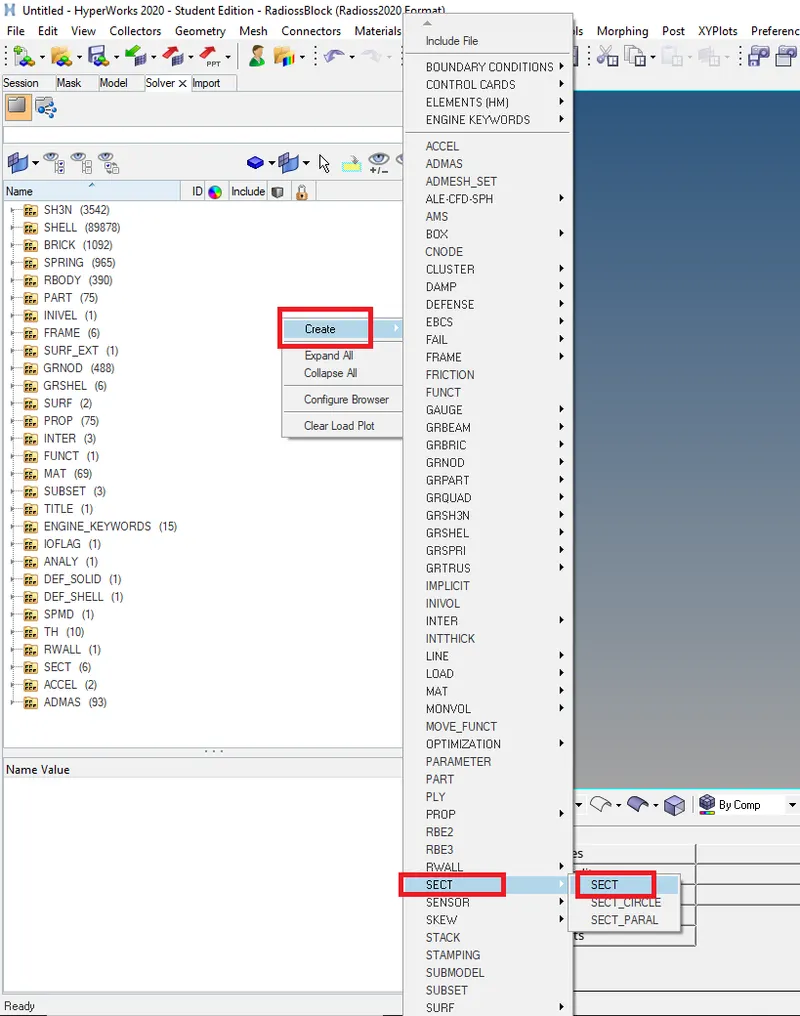
Create -> Sections.
After we define a Section, we then need to give the input of all the elements for the definition of the sections. We need to define a section and give in the three Nodes and also the elements on which we need to make the section on.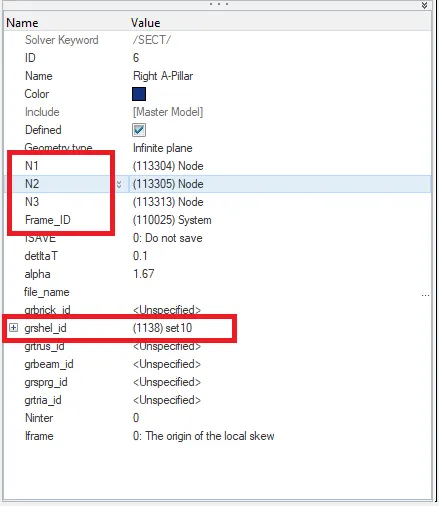
Sections Properties.
In the grshel_id we need to select the elements on which the section is to be defined. We must also specify the Frame ID for the section. Similarly we can define all the Sections in the model.
We make sections in the model so that we can study the peak forces at those particular sections. All the Sections were defined as the following: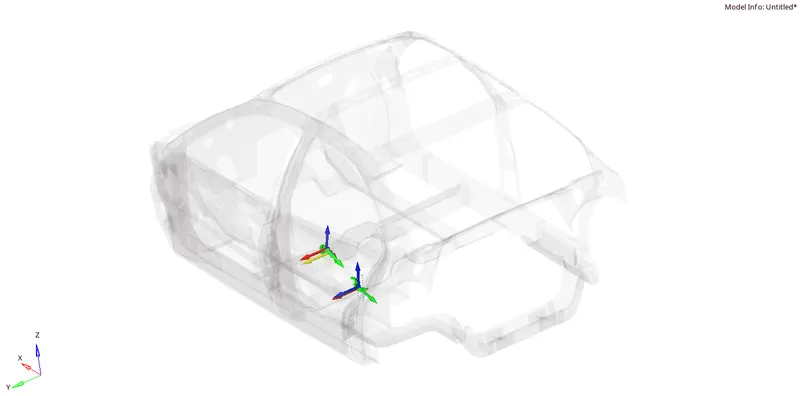
All the defined Sections.
We can clearly see that the Normals for all the Sections defined have a similar direction.
10. The next step is to measure the intrusions at B pillar, hinge pillar and the fuel tank region. To measure the intrusions, we simply need to mark these nodes and request a Time History of these nodes. In the Time History File, we will request certain data such as the displacement and the Velocity of the node. We can mark these nodes by creating a temporary node at the required points in the model. So, for me to measure intrusions at the given points, I have put nodes at the points shown below: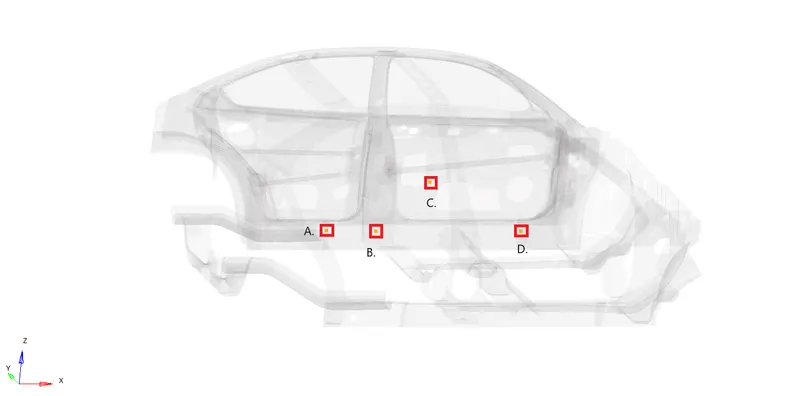
Nodes marked for intrusion on the model.
A: Fuel Tank Node.
B: B-pillar Node.
C: Node at the Door for Peak Velocity.
D: Hinge Pillar Node.
11. The final step before we run this simulationis to create a Time History(TH) for all the nodes and the sections we have plotted. To create a TH, we simply have to right click on the tree and use the create option. Under this option, we have a TH command. In this command, we can select the type of Time history we request the solver to calculate. We can request for Nodal calculations, Contact Interface calculations etc.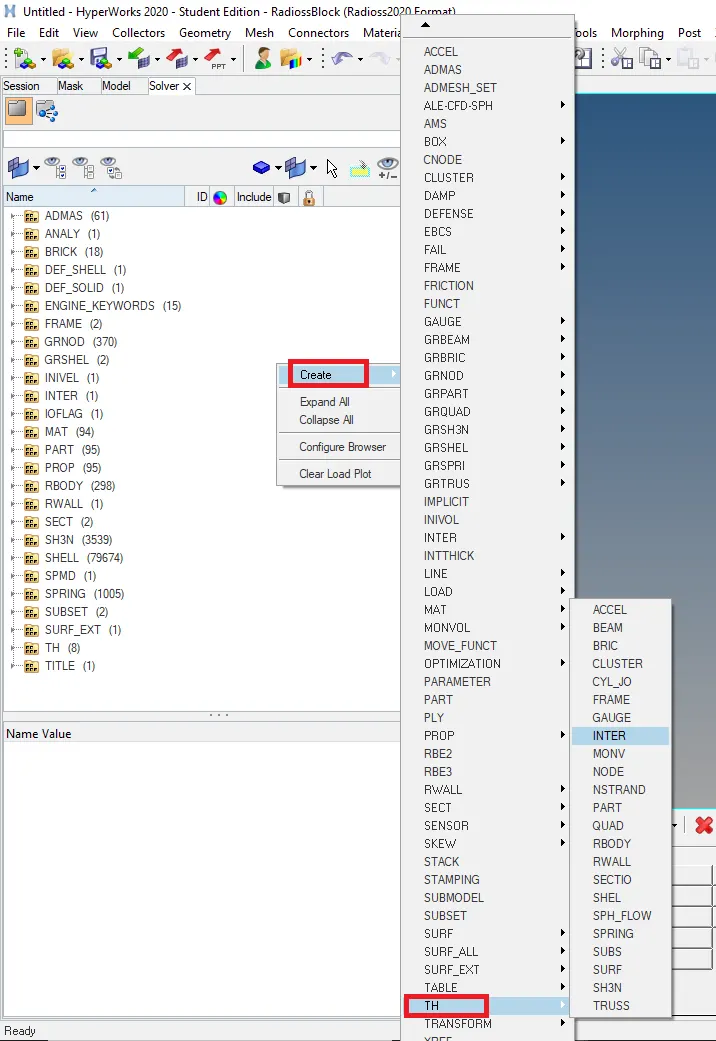
Create -> TH
In our case, we only the Time history for the nodes and the Sections that we have defined. So we simply create two seperate Time history request from the Solver. The final TH request made will look something like the following: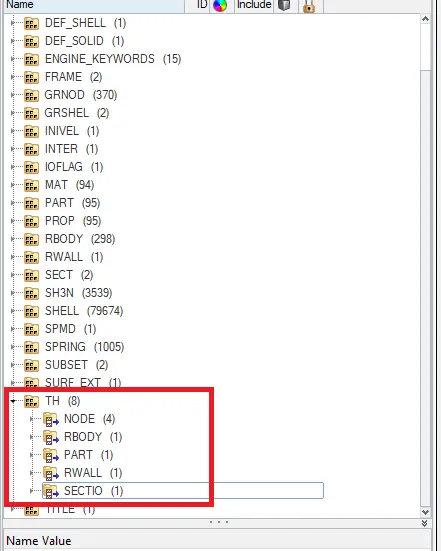
TH created.
12. After the Deck Setup is done, the last step includes checking the model in the Model checker. To check the model, we can use the Model checker in either Hypermesh or Hypercrash. In Hypermesh, the Model checker can be accessed under the Tools tab.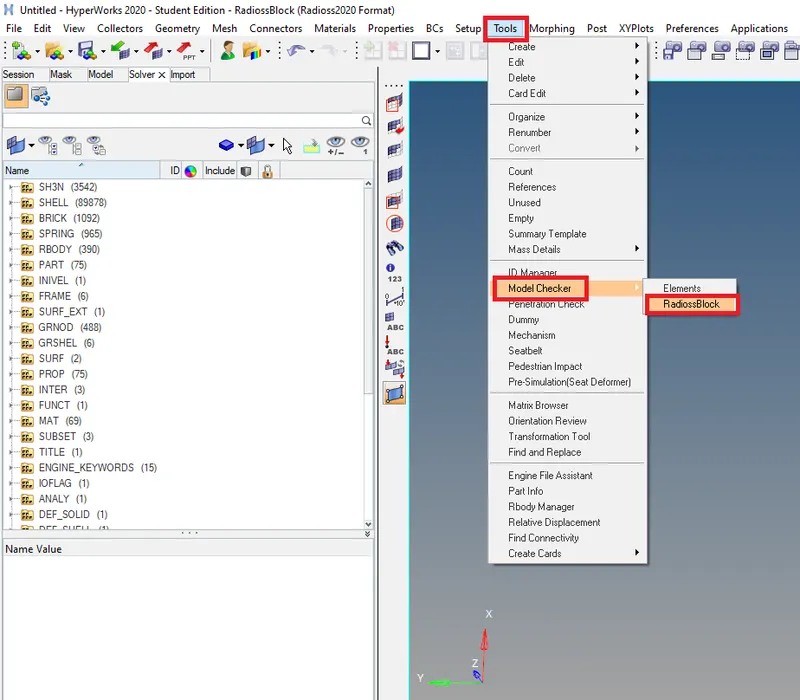
Tools -> ModelChecker.
This model checker will show all the warnings and errors in the model. All the errors must be resolved and the warnings if not critical, can be left in the simulation, else, they too must be resolved. Like this the model can be checked and be resolved for any errors in the model.
After the model checker is run, we then go on to run the simulation. To run this simulation we have to use the Radioss command in the Analysis tab.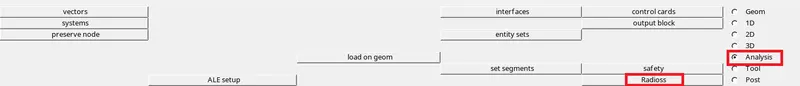
Analysis -> RADIOSS.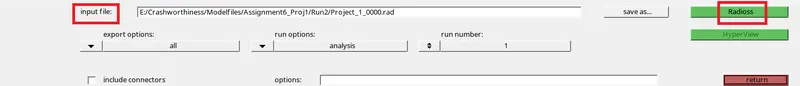
RADIOSS Command.
The input file is the file location in the system where we want to save all the simulation files, such as the .h3d file and the T01 files for example.
After the simulation is run, we can confirm that the simulation has run properly when we see a NORMAL TERMINATION at the end of the simulation as follows: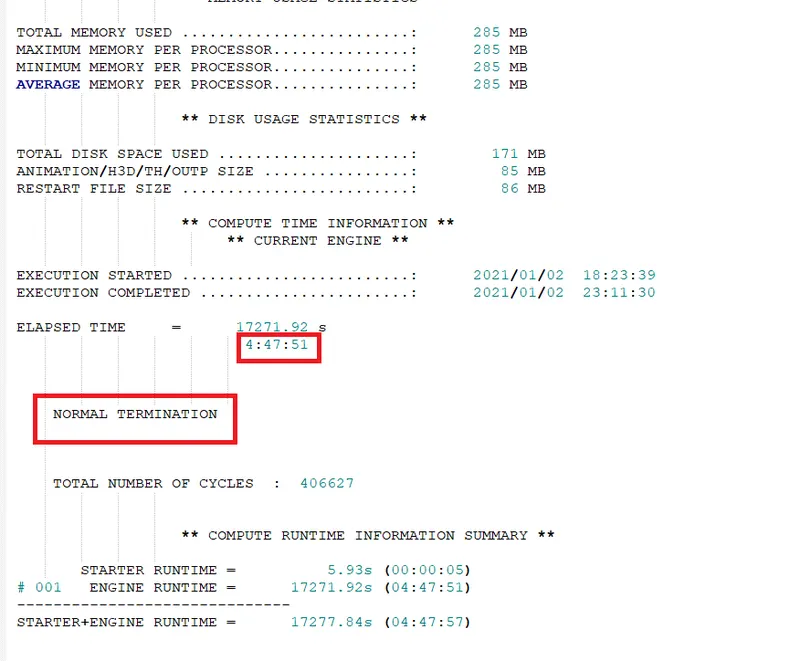
Normal Termination and Elapsed time can be seen after the simulation is completed.
In our case, our elapsed time after the simulation was ran is about four hours and fourty seven minutes.
We can then later view the simulation in Hyper-view or by simply clicking on Results.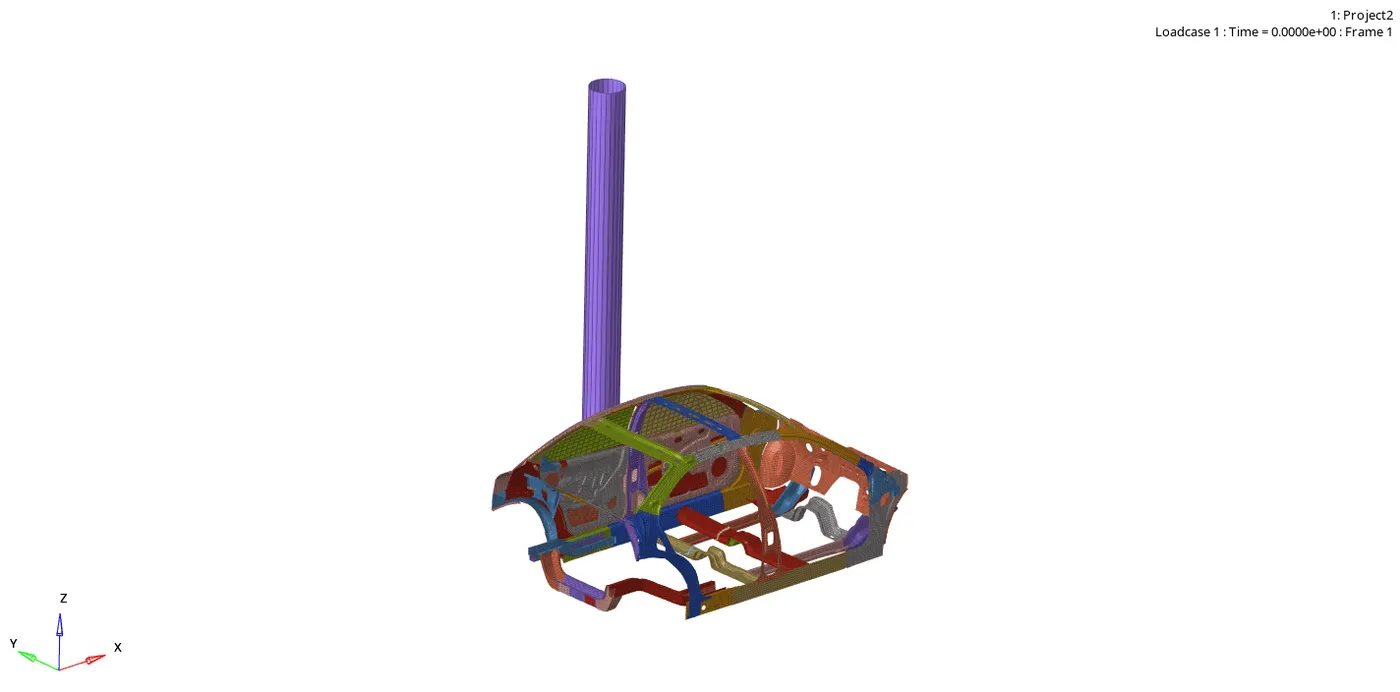
Animation of the simulation.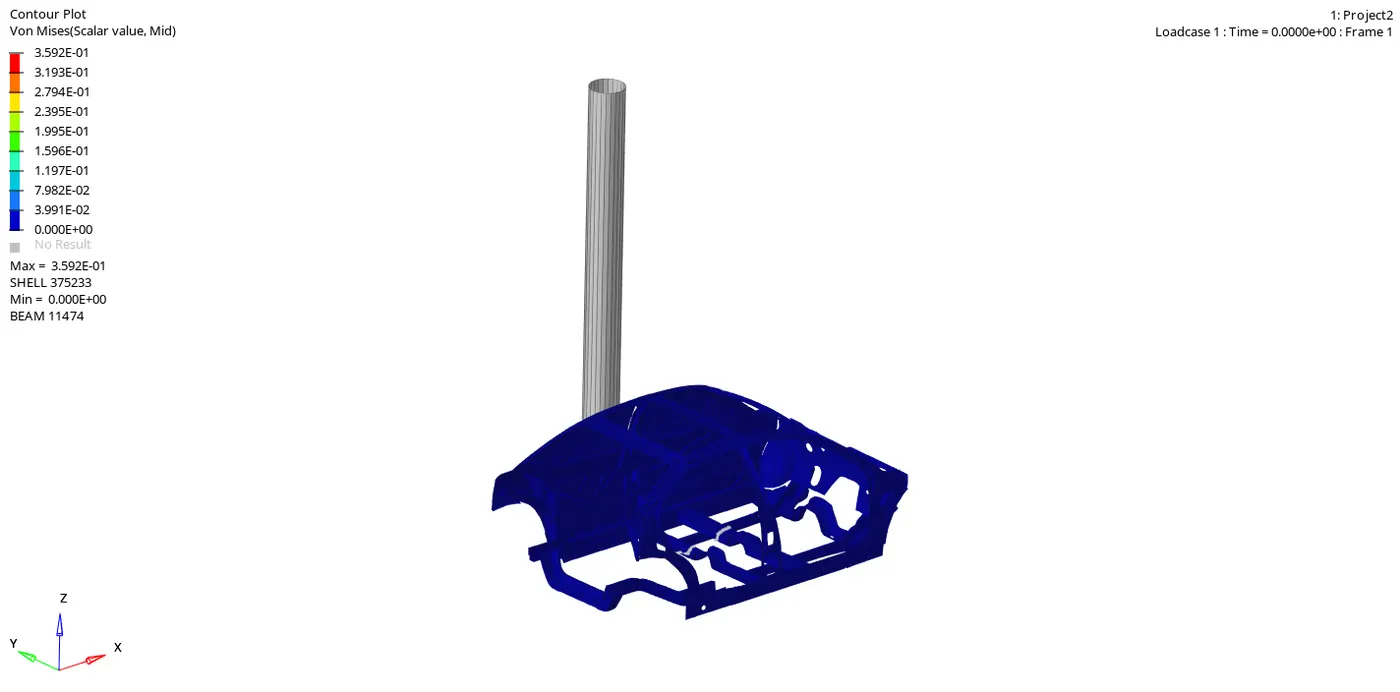
Von-misses Plot.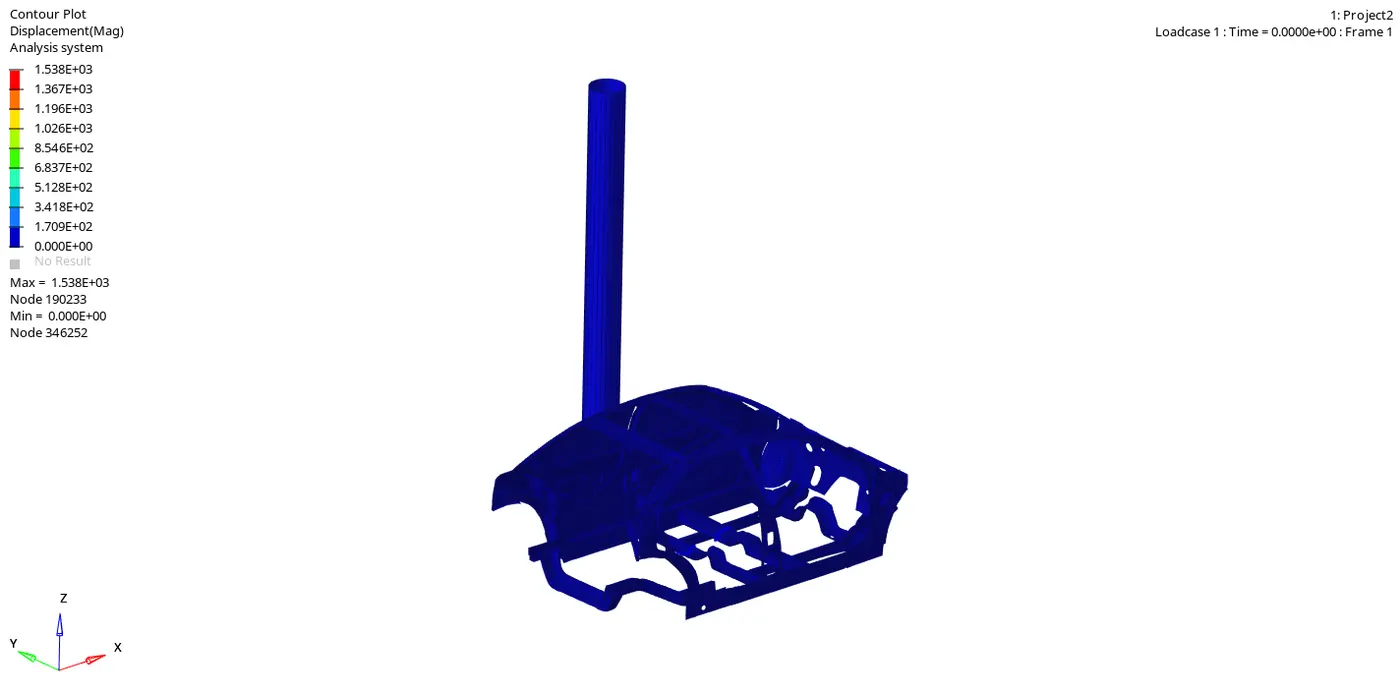
Displacement Plot.
13. The very last step is to study the Simulation results by plotting all the necessary graphs and extracting data from them. To plot graph, we need to use the Hypergraph tab. To access the Hypergrraph tab, we simply need to change as the following: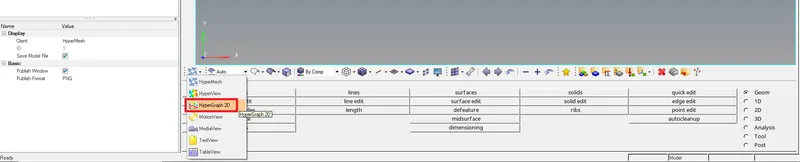
Hypergraph 2D
In this tab we need to open the Time history file. It is the T01 File that will be available in the Folder where we saved all the files. We can import this file by clicking on the icon shown below:
HyperGraph Command.
We can set the variables between which we need the graph to be plotted as well.
A. Sectional Forces: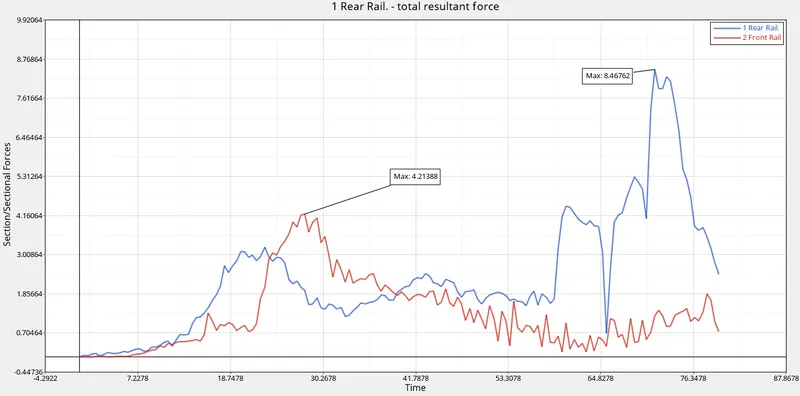
Sectional Forces
From the plot we can see that the Sectional Forces on the Rear Rail has touched a maximum value of 8.5KN whereas in the Front Rail, it has peaked at 4.2KN. The way that theses rails experience forces and collapse are different. This can be confirmed from both, the Graph and the Simulation. We can see that the Rear Rail experiences the forces much earlier and it tends to fail before the other rail. This can be seen both in the graph as the curve for the rear rail starts climbing before the other curve.
B. Intrusions on the desired locations.
1. B-pillar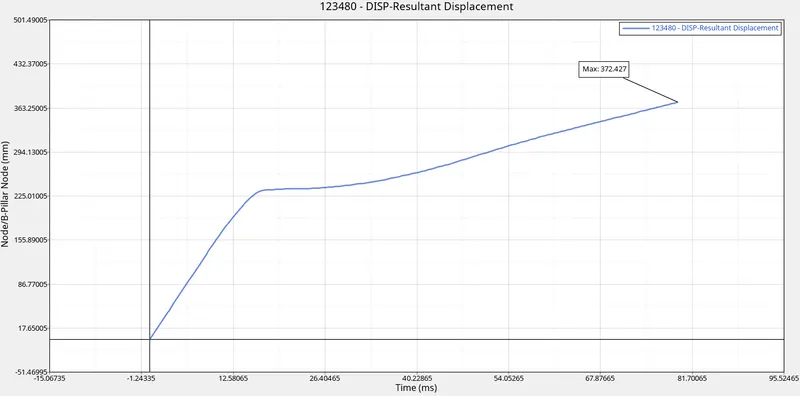
B-Pillar Intrusion.
The maximum Node displacement is approximately 372.5mm
2. Hinge-Pillar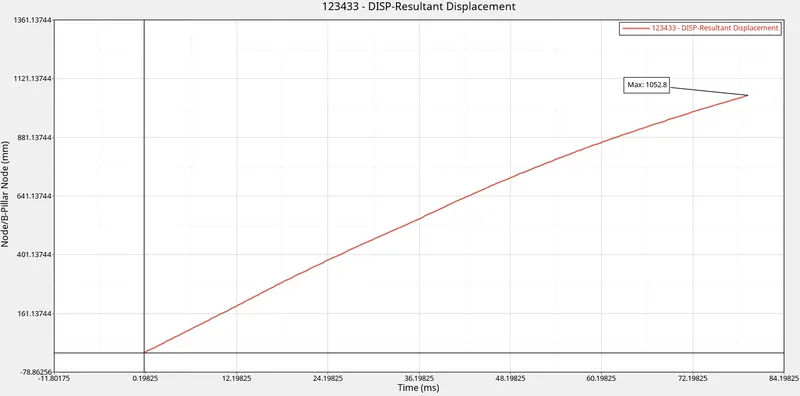
Hinge Pillar Intrusion.
The peak displacement of the node is around 1053.0mm.
3. Fuel Tank.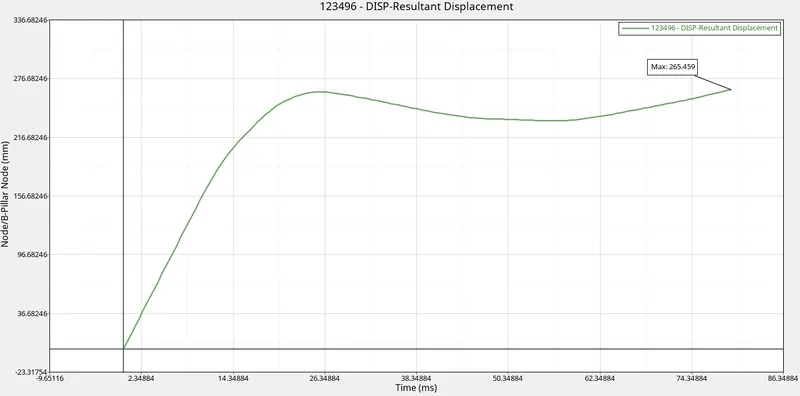
Fuel Tank Intrusion.
The maximum Node displacement is approximately 265.5mm
All the intrusions at these locations are very high. Since we do not have a full scale model due the limit on the number of nodes in the model. Becasue of this, we are getting a higher magnitude of intrusions as the model is much less stiffer. Many components such as the seat or even the engine is missing from our model. These components add weight and stiffness to the model. But, to this model, we can add a cross member across these nodes. Adding a cross member, we increase the stiffness and reduce the intrusions.
C. Peak Velocity of the inner node on the door.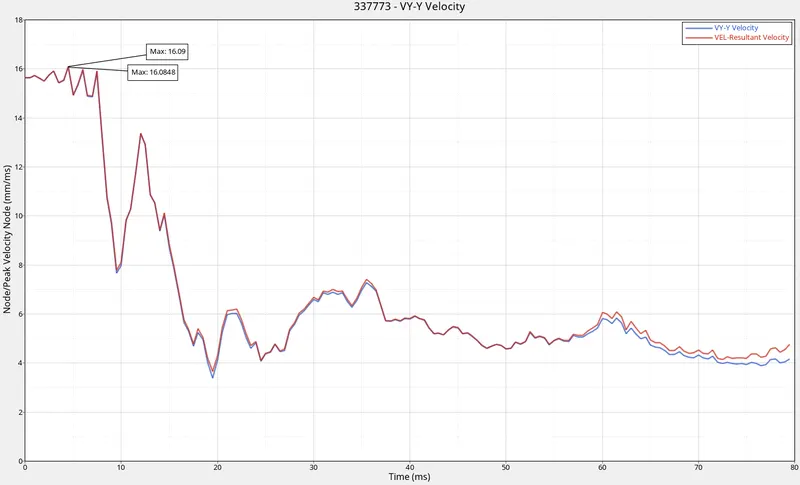
From the plot given above, we can see that the Resultant Velocity and the Velocity ini the Y direction in the simulation have very similar plots. Both these plots have a paek velocity of 16.09 mm/ms.
D. Energies in the Simulation.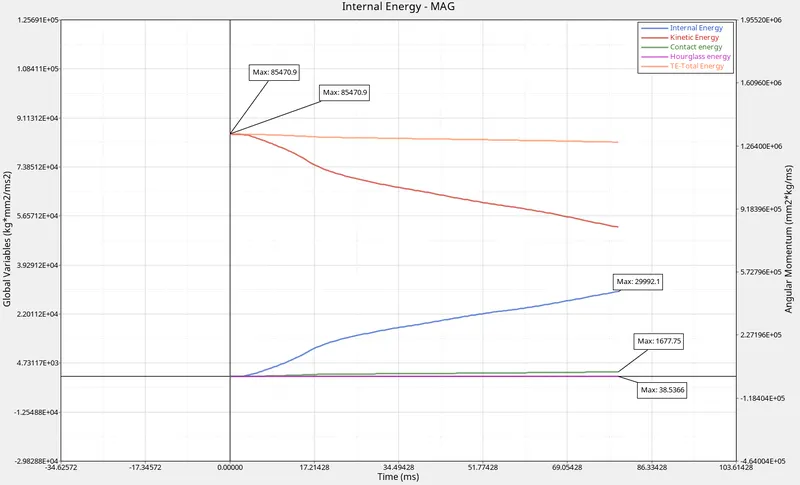
Energy Plot.
Ideally: `("Hourglass Energy"+ "Contact Energy") / ("Total Energy") <= 15%`
In our case:
38.53 + 1677.75 / 85470.9 = 2%
This is well below the limit, hence this condition is satisfied.
From the Above plot, we can see that the Total Energy is decreasing by a little margin and that the contact energy is also minimal. We can observe that the Total Energy has peaked out at 85,740.9J and the Hourglass Energy has a peak of 38.5J. We can clearly see that the Kinetic Energy is being converted into Internal energy. Ideally all of KE should be converted into IE and the Total Energy must remain constant, but in our case since we have Hourglass Energy error, our Total Energy is decreasing. We can rectify this hourglass energy by further reducing the Timestep of the simulation and giving the Ideal Properties wherever we can.
Our Requirement from an Ideal Simulation is that we have minimal Contact energy and maximum Energy absroption/Deformation in the elements. We can check the Energy error in the Engine output file, which has maxed out at -2.1% which is also within the appropriate limits for it to be. Our Mass error is also 0.0% which means that the solver did not need to add mass onto the nodes to reduce the timestep to further avoid the Hourglass Error.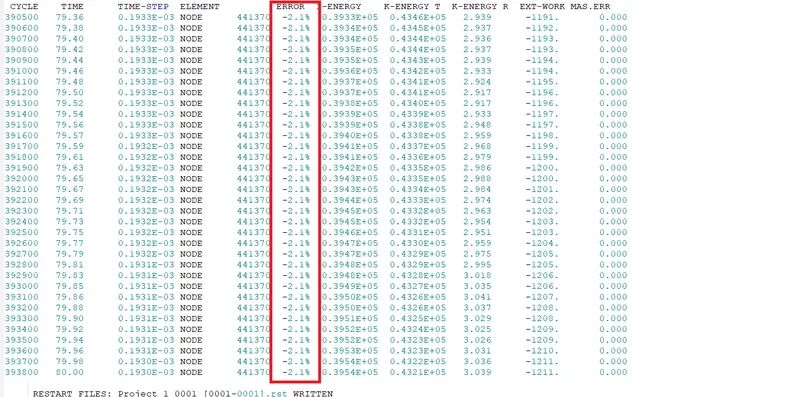
Engine File Output.
E. Rigid Wall Forces.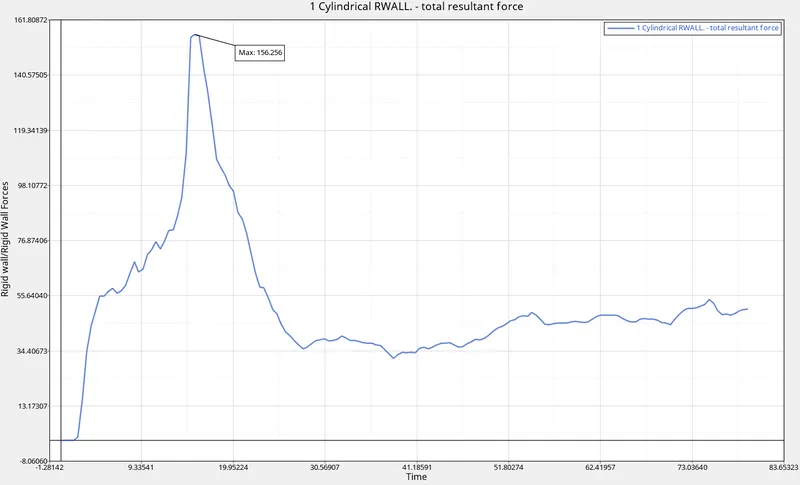
Rigid wall Forces.
The peak Force that was recorded on the Cylindrical Rigid Wall was approximately 156.3KN - Conclusion: In conclusion, I would like to state that this project helped me get a proper understanding on the procedure of doing a Side Crash of a vehicle and how to extract different data from the simulation.