Frontal Crash of a NEON Dodge Model in FMVSS Regulation
OBJECTIVE
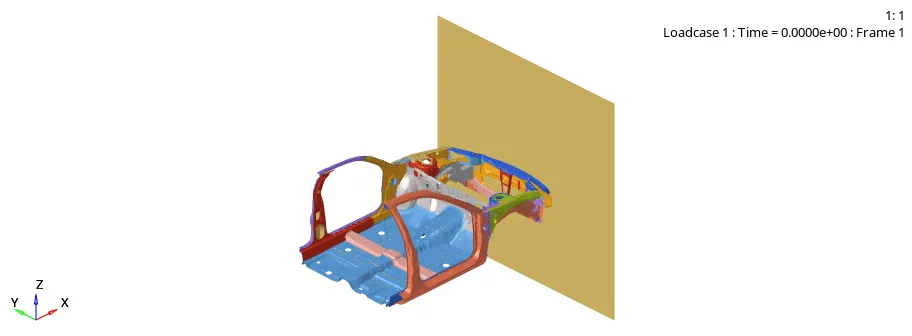
Performing Frontal crash analysis of a car
PROCEDURE
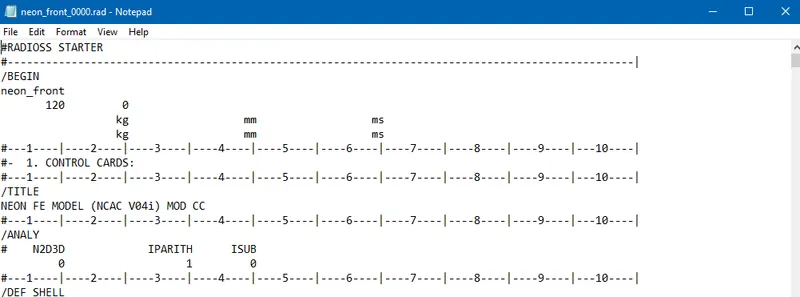
1. The unit system in place is [Kg mm ms]. Open the 0000.rad file in notepad and one can observe the unit system in the starter file.
2. Open the file in the hypercrash and import the neon_front_0000.rad file. Keep the preferred unit option as [KN Kg mm ms] in line with industry standards as well as the .rad file. Run the model checker to see for the errors and warnings throughout the file. We can solve them one by one.
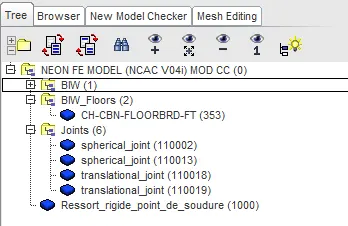
3. We will check the node equivalence to make sure that no two nodes or more nodes exist within the specified search tolerance[1mm]. In the entity tree, create new assemblies and sort the parts as per need.
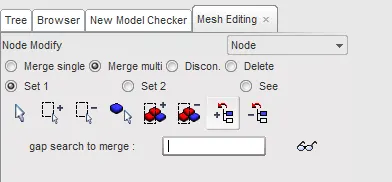
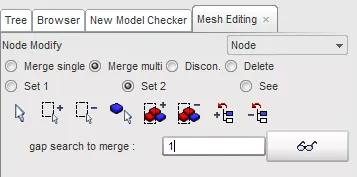
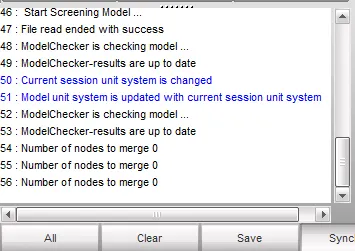
4. Then under the mesh editing tab, select node and then modify. Check the option Merge multi and Set 1. Add the selected parts. Now select set 2 and give the tolerance value to 1mm. Again select the part and hit the search icon. You will see the message of nodes
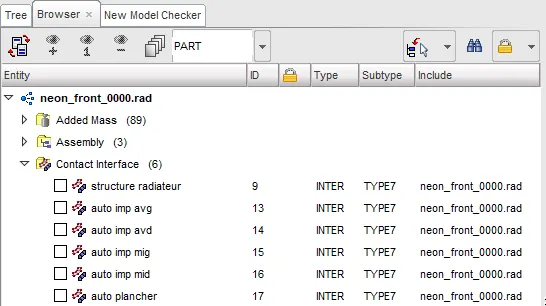
5.TYPE 7 contact interface can be observed as the selected option for all under the contact interfaces tab on the entity tree.
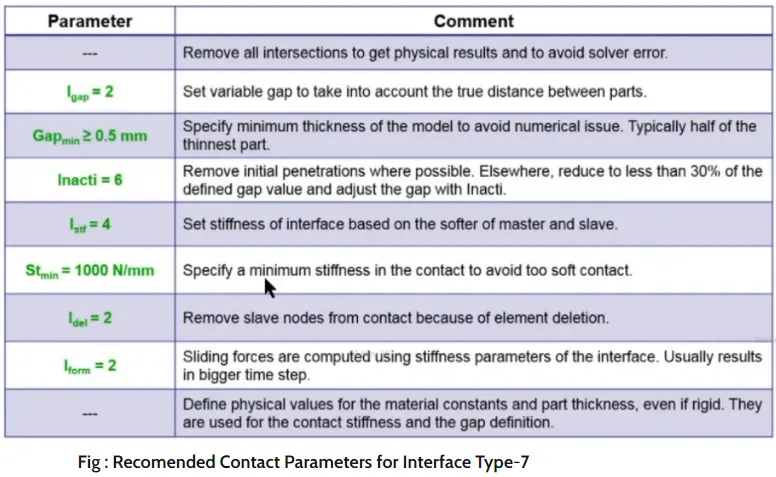
6. We would like to keep the recommended parameters as shown below. Select the parameters and then right-click to edit the same.
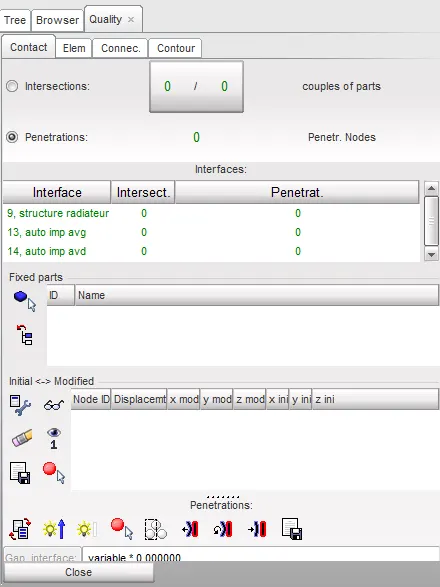
7. Make sure of no penetrations and intersections. Penetration is defined as the overlap of the material thickness of the shell elements, while Intersection is defined as elements that actually pass completely through one another. All models and especially impact models should be checked for penetrations and intersections and de-penetrated to ensure the integrity of the model. Penetrations adversely affect results and should be removed.
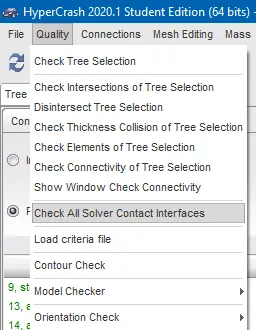
8. Click on the All solver contact Interface option under the quality tab. We can notice there is no intersection and penetration present in the model.
9. Now we will look at the material property and make some necessary changes if required as per recommendation. The material cards are LAW 2(PLAS_JOHNSON) or Johnson Cook which is an elastoplastic material. This workload involves nonlinear analysis which requires the value of true stress and true strain. In this law, the material behaves as linear elastic when the equivalent stress is lower than the yield stress. For higher stress values the material behavior is plastic.
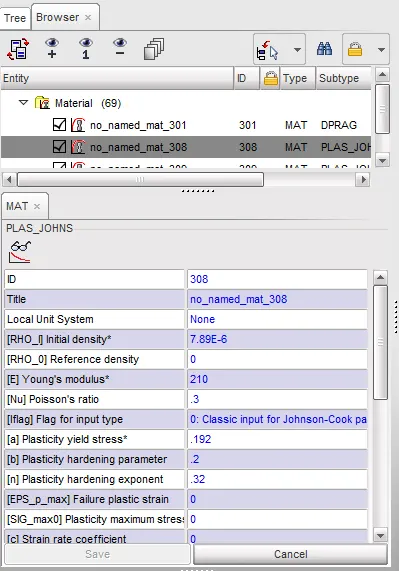
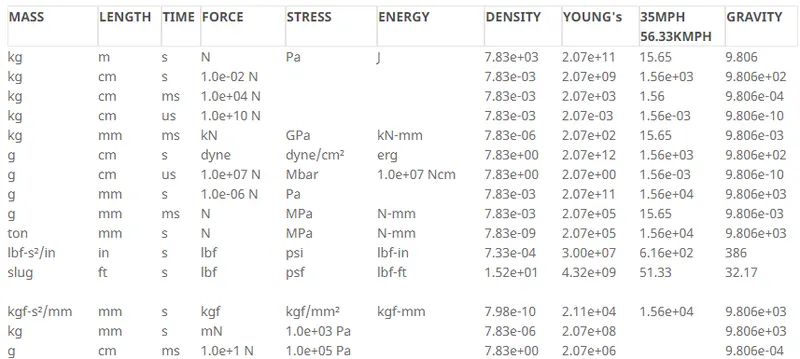
10. We will use the consistent units to check out the material property. The unit system in place is [KN mm ms Kg] and the value of density, youngs modulus are in accordance with that of steel.
11. We will take a look at the shell element formulation property to ensure it is in line with the recommendation. Make some necessary changes as required.
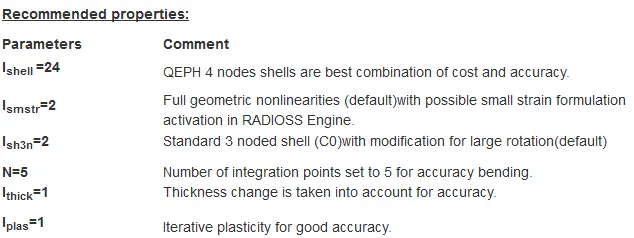
12. With a one-point integration formulation, if the non-constant part follows exactly the state of the constant part for the case of elastoplastic calculation, the plasticity will be under-estimated due to the fact that the constant equivalent stress is often the smallest one in the element and element will be stiffer. Therefore, QEPH, defining a yield criterion for the non-constant part seems to be a good idea to overcome this drawback. QEPH shells are more accurate for elastic or elasto-plastic loads, whatever the loading type - quasi-static or dynamic. QEPH shells will give better results if the mesh is fine enough. It is not recommended for the coarse mesh.
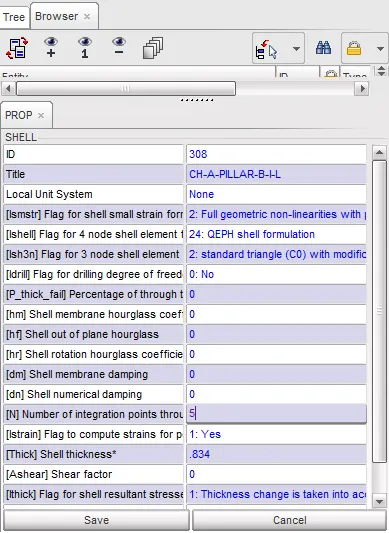
13. In the case of elastic behavior, one gets the exact solution from three integration points – that is to say that the bending moments are exactly integrated through the thickness of the shell – and it is not necessary to use more integration points. In the case of plastic behavior, the bending moments are not integrated exactly. Using more integration points, the solution becomes more accurate; so it is recommended to use five integration points and N=0 means the global integration method is applied(Each element is integrated based upon its property). The default value is 0 which means the global integration model which only compatible with Material Laws 1, 2, 22, 36, 43, and 60. Failure models are not available with global integration for shells.
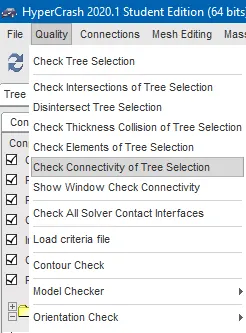
14. Check the connectivity of tree selection in order to ascertain any issues with the connections. We can see two free spherical joints that will be deleted.
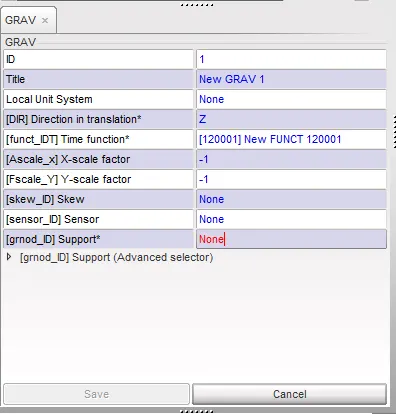
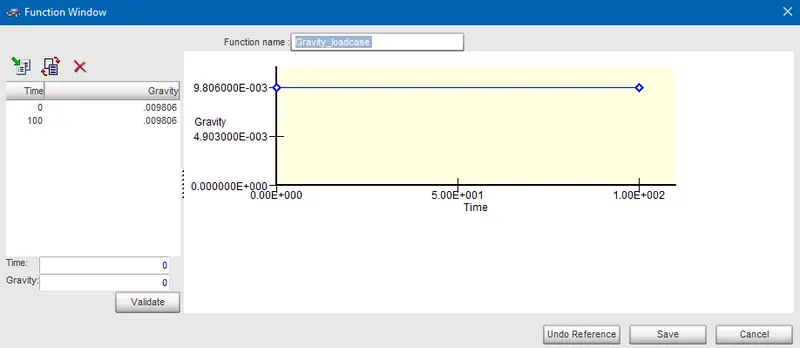
15. Define gravity load which can be found under load cases. Define the time function like 0 to 100 ms with the gravity of 9.806e-03. Keep the Skew_ID as none to use the global co-ordinate system.
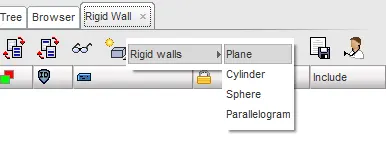
16. We will now create the rigid wall upon which the front impact will take place. It will feature a recommended friction value of 0.1. Choose the Rigid wall option under the load case tab. Mainly to constrain the movement of a moving body after impact, We will be using a planar wall.
17. A rigid wall is a nodal constraint applied to a set of slave nodes in order to avoid the node penetration to the wall. If contact is detected, then the slave node acceleration and velocity are modified.
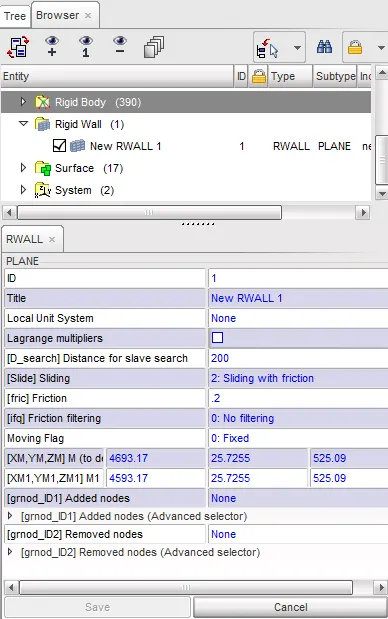
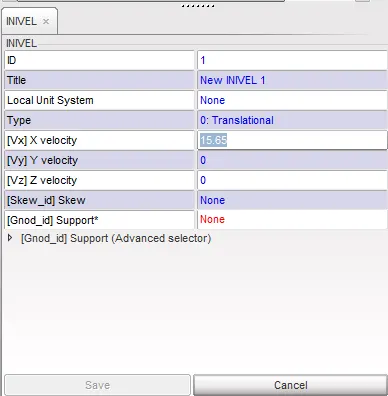
18. Under Loadcase tab, go to the Initial velocity option. Click on create a new option. Keep the type as translational and X Velocity as 15.65. Velocity value is aligned with the consistent units [Kg mm ms]. We are keeping the initial velocity as 35 MPH.
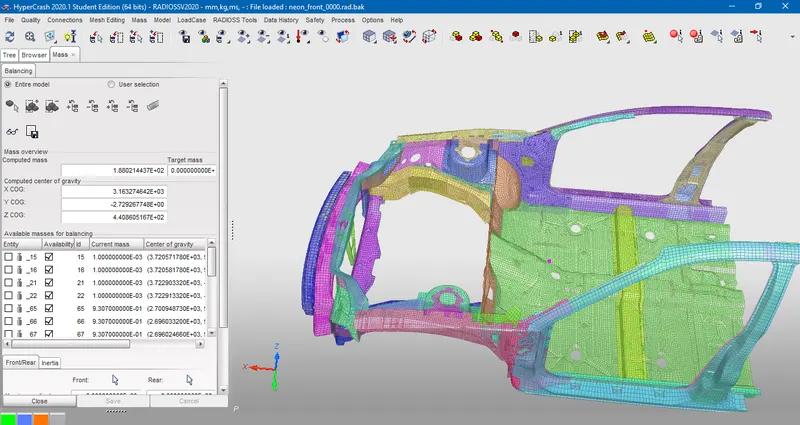
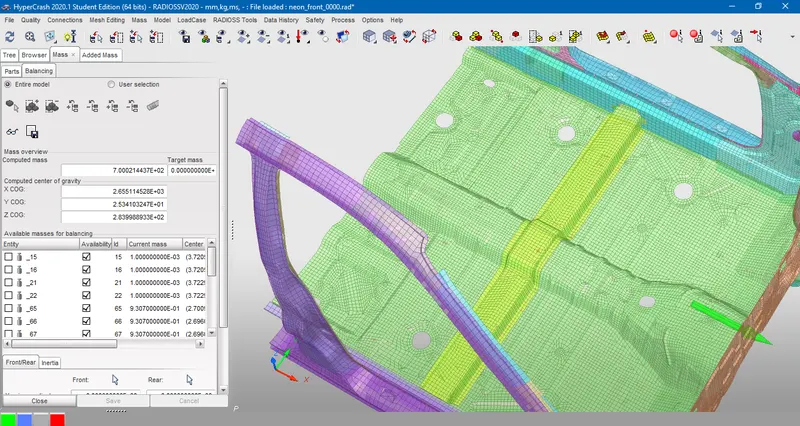
19. Unde Mass tab you will find the balancing option where you go observe the CG of the part with a mass of 188 kgs. We will need to increase it to 700 Kg and bring the CG position right below the front seating while maintaining the same CG coordinates value on the Y and Z axis.
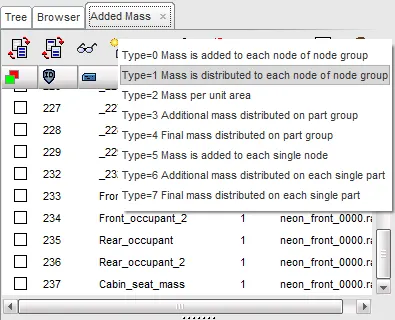
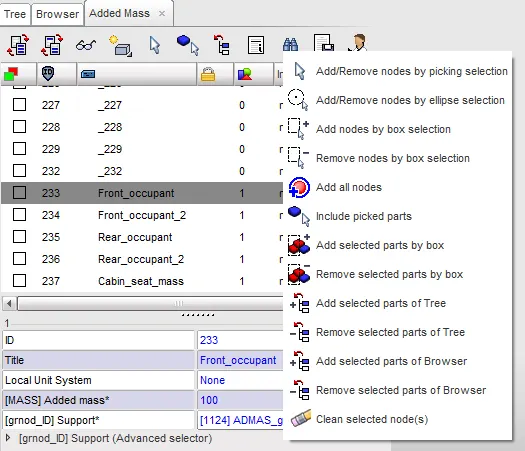
20. Click on Added mass option present under Loadcases tab and select the option to create a new mass. Pick Type 1 as it leads to mass distribution to each node of the node group. For support select the required node using various options available.
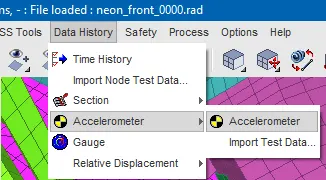
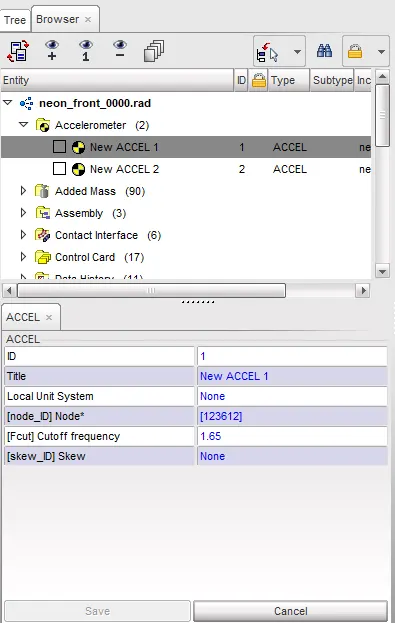
21. Now we will make necessary arrangements to meet our output request. We will place the accelerometer at the base of the B pillar rocker on both sides. We will find the accelerometer option under the Data history tab. Select the appropriate Node_ID for the same.
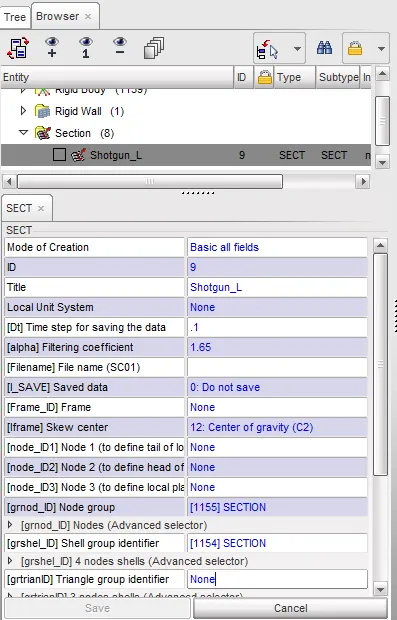
22. We will find the section option under the Data history tab. Select the component and then the 3 nodes to define the local coordinates for the section. You can edit the required elements as well to have a clean cross-section.
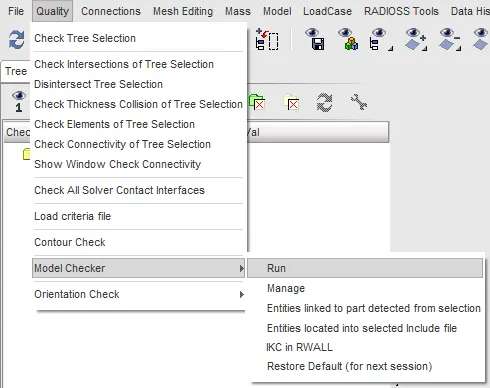
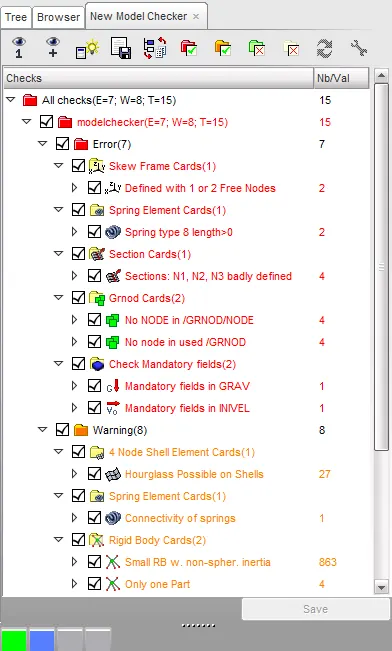
23. Conduct a model check to make sure that errors and warnings before exporting the rad for radioss solver. Go to Model checker under the Quality tab and then click run.

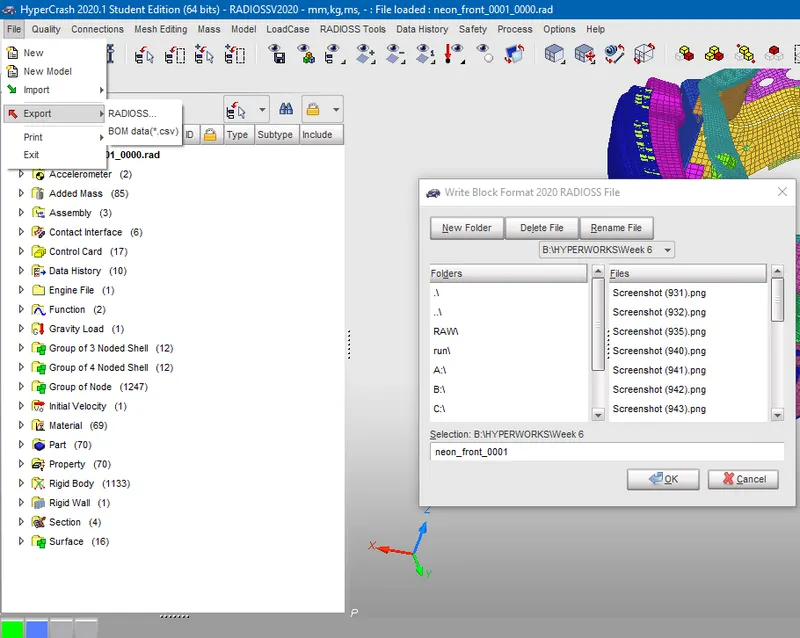
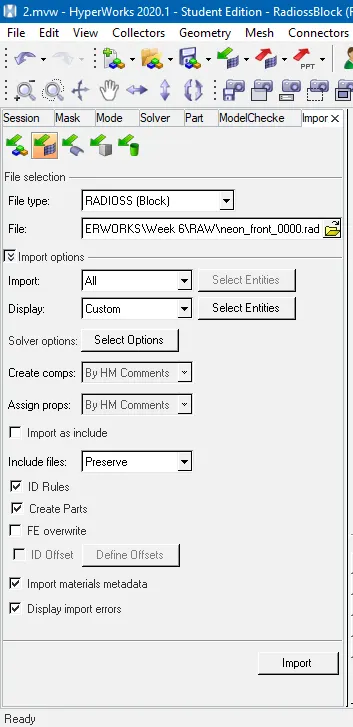
24. Export the file radioss file and import the .rad file under the solver deck.
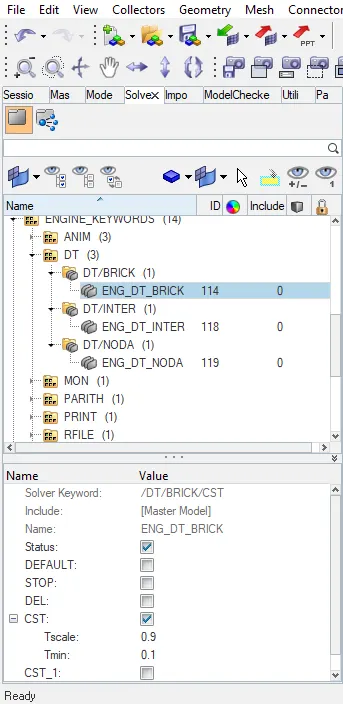
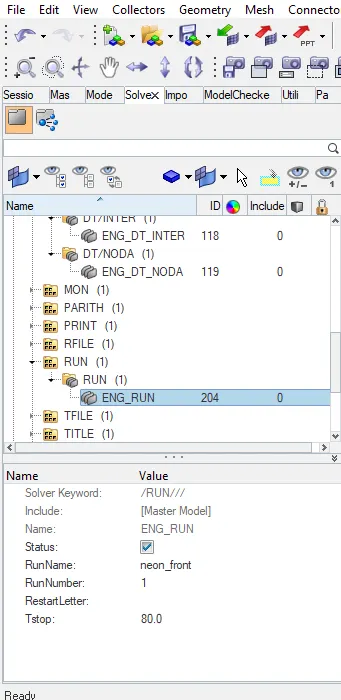
25. We will set the time step between 0.1 to 0.5ms and run time to 80ms. Edit the DT files under the Engine Keywords and the run file to set the time step to 0.5 as the minimum time step and 80 ms as the run time.
26. Study of intrusions in the car cabin near the dashboard will be done through skews. 2 nodes are created and fixed skews are assigned to it.
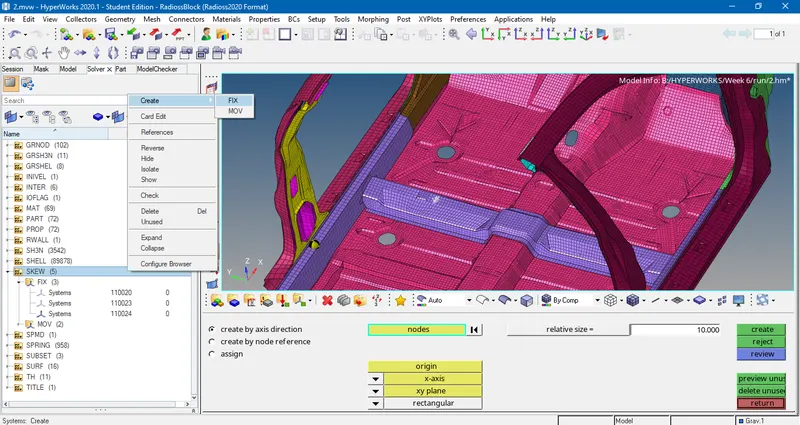
27. Create the /TH/NODE card and select the required nodes and then the fixed skew near the B-cabin pillar base support. There the travel of the node is computed from the global coordinates and it is presented In the local coordinates. The overall travel of the node is obtained.
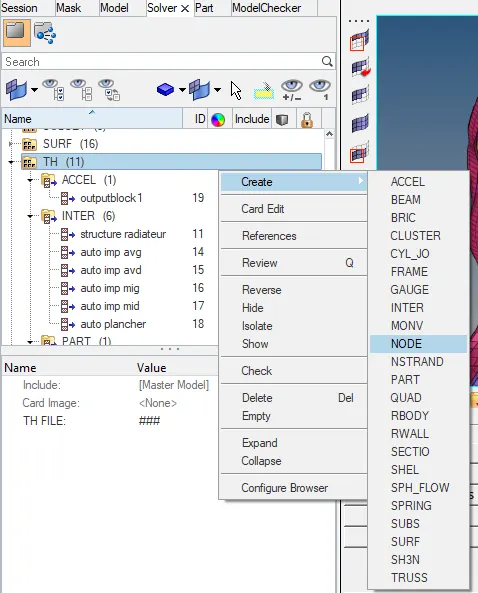
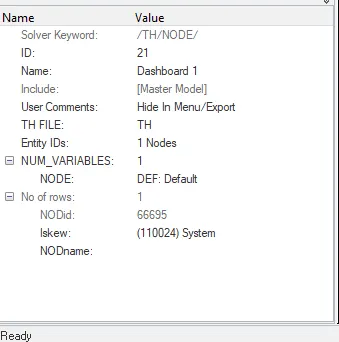
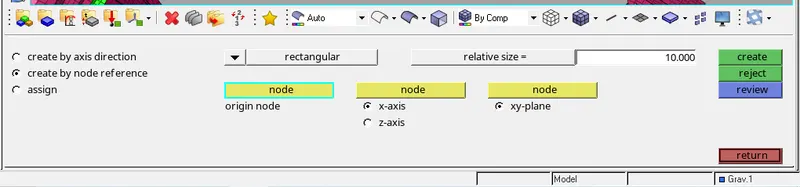
28. Let's create a moving frame for the section. To create a moving frame, Under the Solver deck, right-click to Create and then choose Frame with Mov option. Select the origin node, X-axis direction, and XY plane. This can be created based on the global coordinate system if possible based on the geometry orientation wrt global coordinate system.
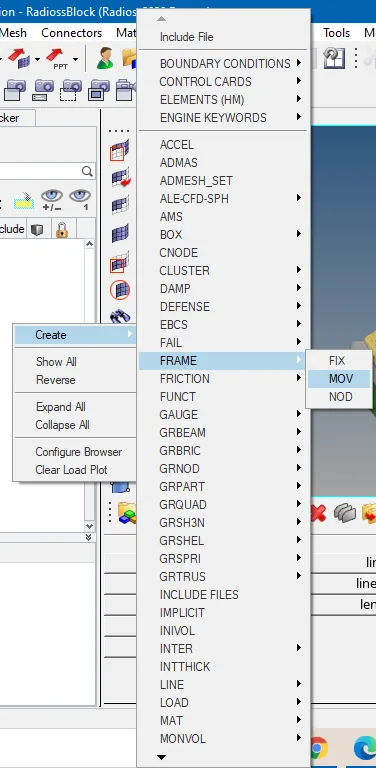
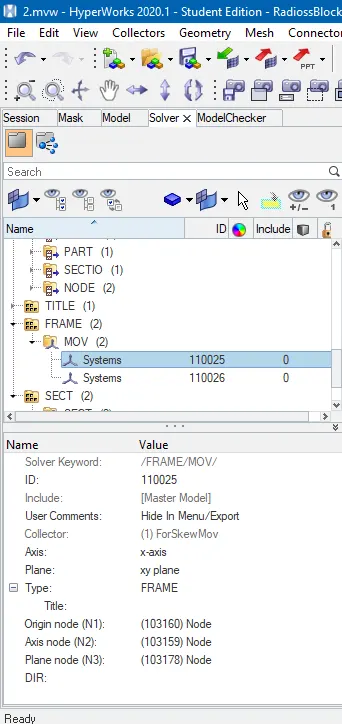
29. Inorder to get the cross-sectional forces at Shotgun, A-pillar, Hinge pillar, and rails from bumper we create a section for each of them on side of the neon body.
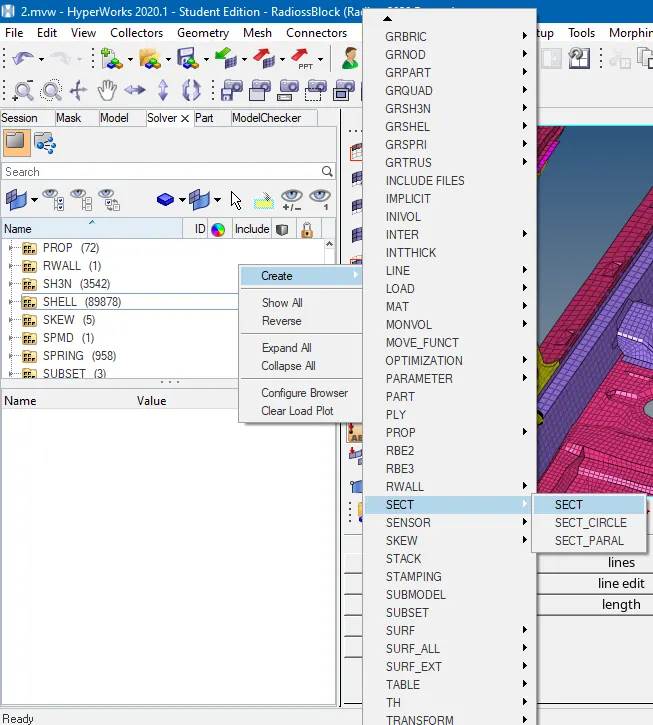
30. In the Solver browser, right-click and select the Sect Option. First, select the frame that is already created and assign it to the section. Select the required shell elements using the grshel_id option. Then Right-click to create in the new dialog box for required elements selection by clicking on the entity id as elements.
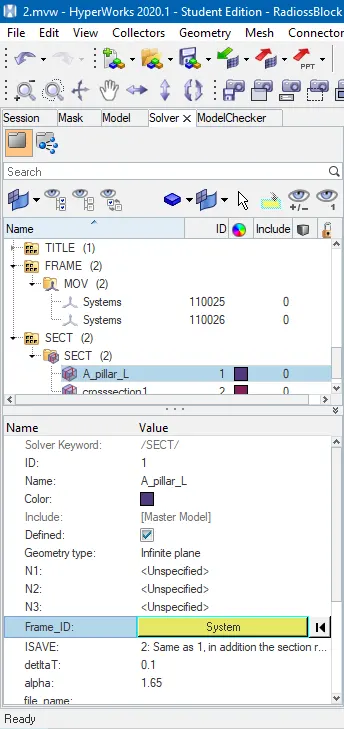
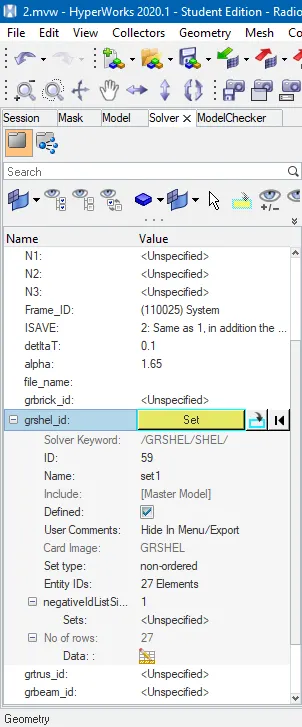
31. Enter the values for Isave as 2, deltaT as 0.1, and alpha with a default value of 1.65.
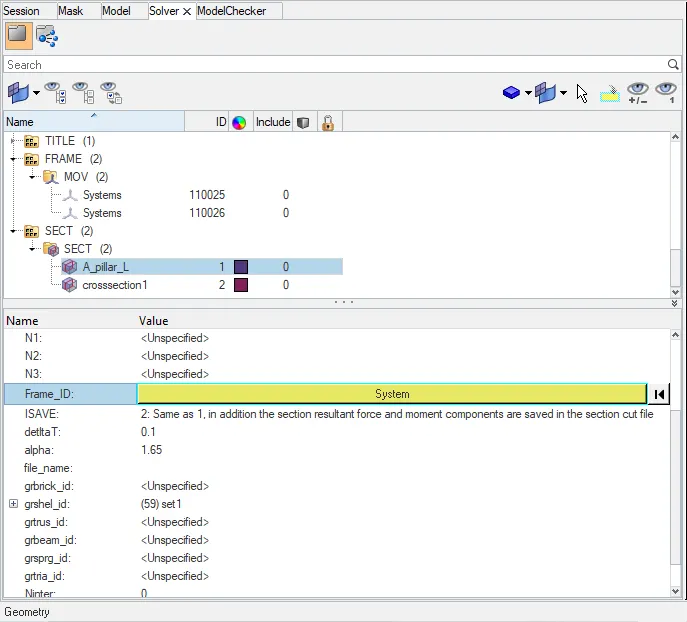
32. Check the intersection and penetration and connectivity of the model to root out any discrepancies. Finally, Run the Radioss model checker to see for any error. There should be no error and one can ignore the warnings. We should check for results to see if warnings are having any significant impact on the simulation.
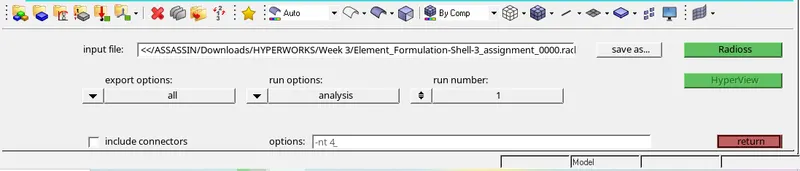
33. Go to the Analysis tab and run the radioss simulation. Select option for Export Option, Analysis for run options, and run number Should be 1.
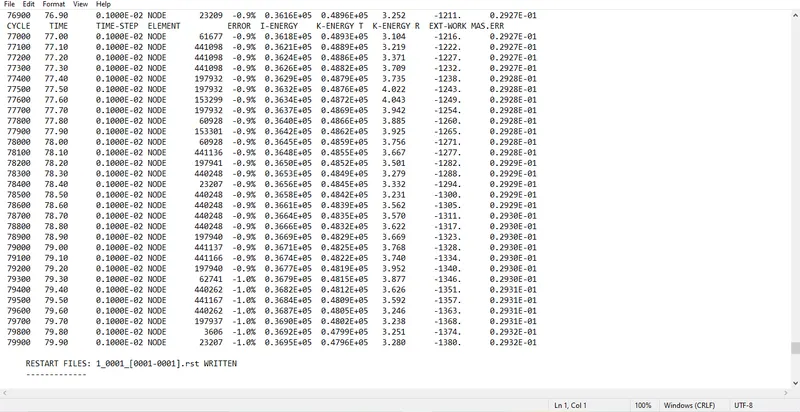
34. At the end of the simulation, do the energy error and mass error checks and determine whether the results would be acceptable. Since the Energy error% is around -0.9% and the Mass error at 0.029 we will go ahead and check the results.
35. Open Hyperview and import the .h3d file to see the results such as Specific energy, plastic strain, and Von mises energy. Select the Contours under the plots which can be found in the result tab. Now select and result in type and its magnitude. For some results select the components and select simple in the case of the averaging method.
36. Open 2D Hyperview and plot 2D graphs. First, we will look for dashboard intrusion after the crash. We have two node points which we will look into for results.
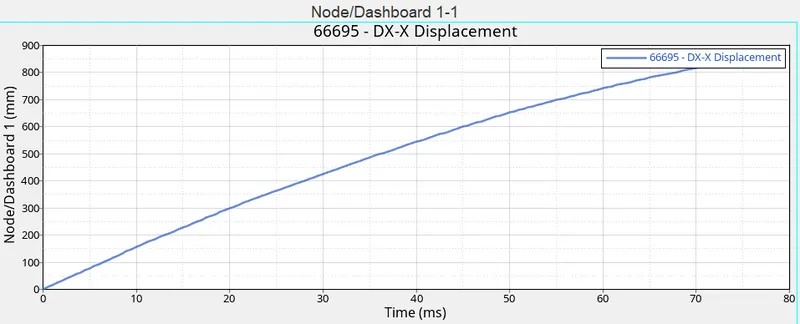
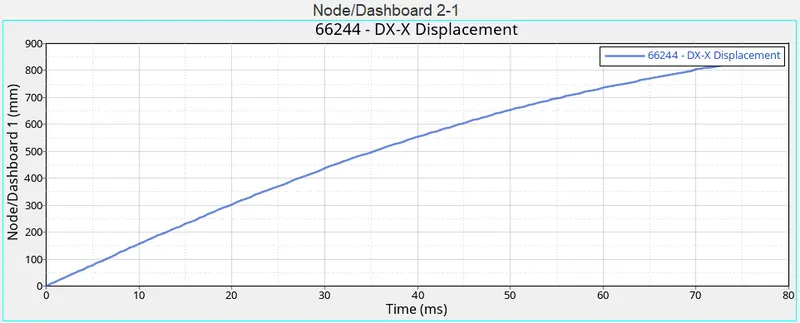
37. Now we look for the results from the accelerometer for the Acceleration curve received on the accelerometer at the base of the B pillar (on the B pillar rocker).
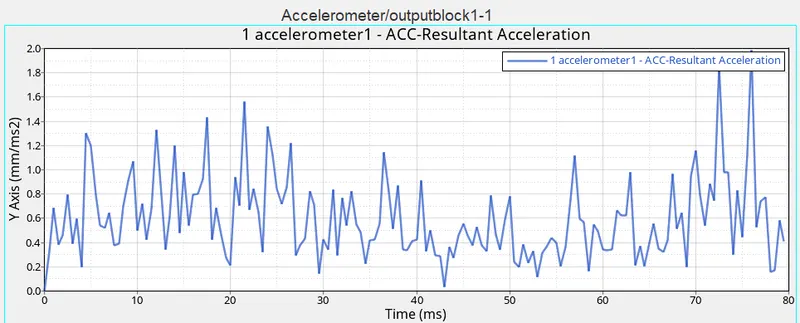
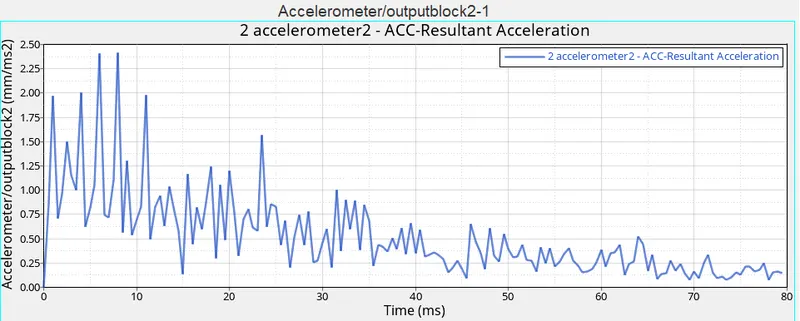
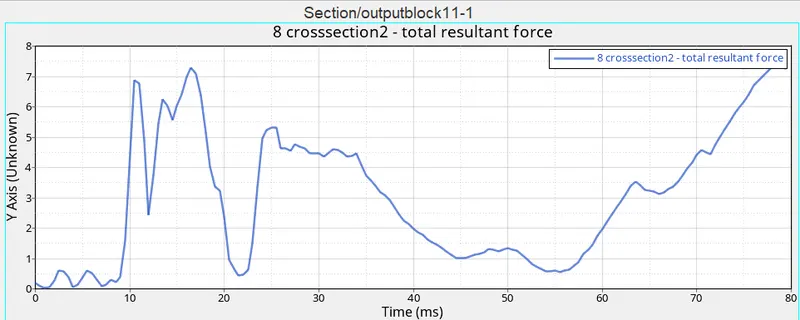
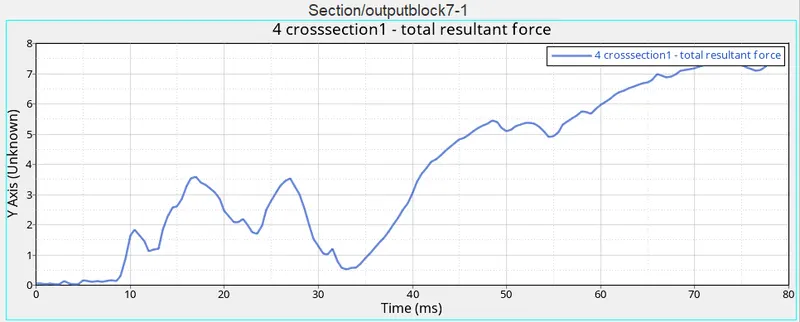
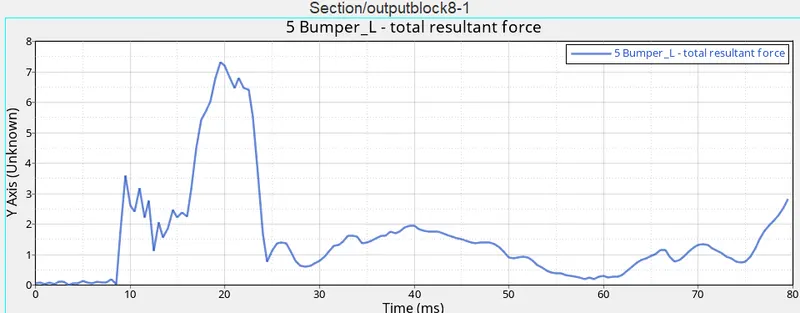
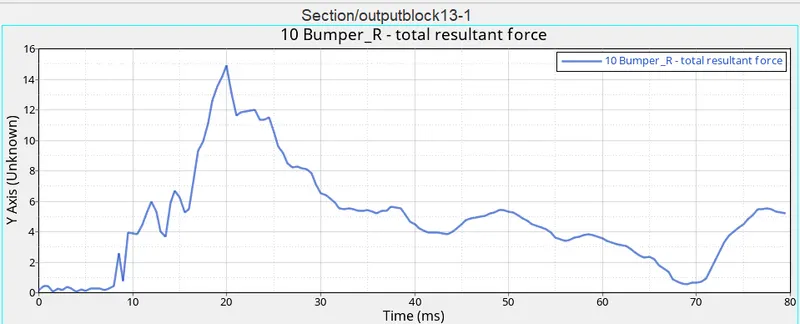
38. Now we will look for the forces on our sections created in the model
- Sectional force in the rails at the location of the indicated node.
- The axial force received on the rails from the bumper.
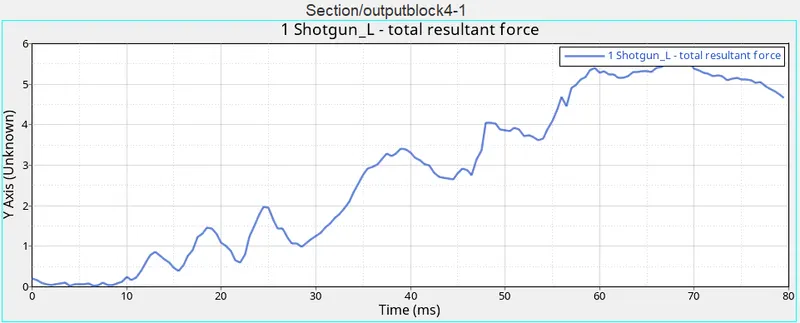
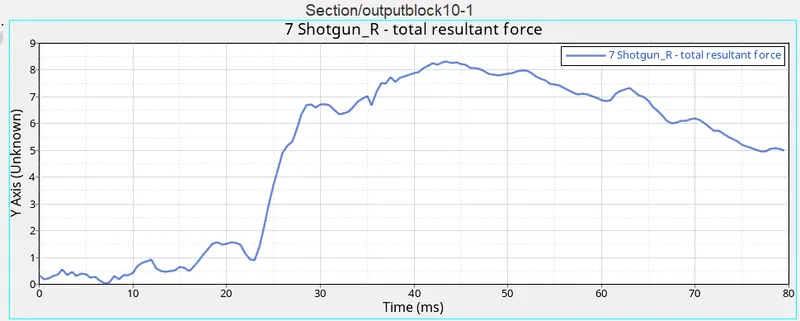
- Shotgun cross-sectional forces.
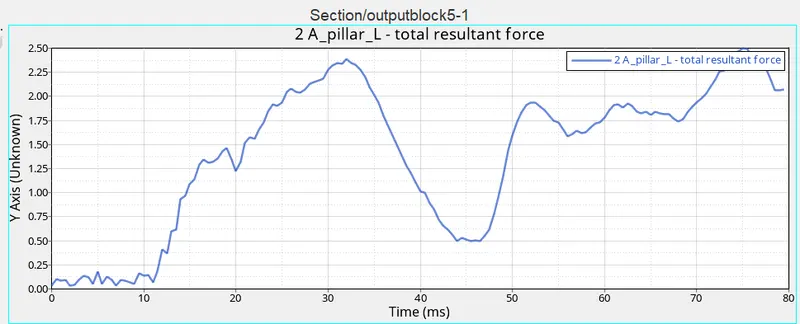
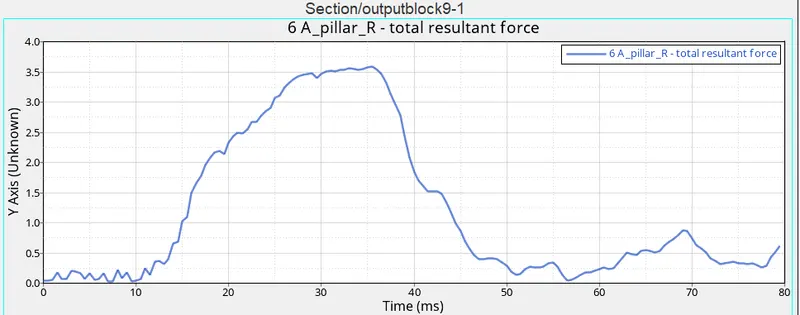
- A pillar cross-section forces.
- Hinge Pillar cross-section forces.
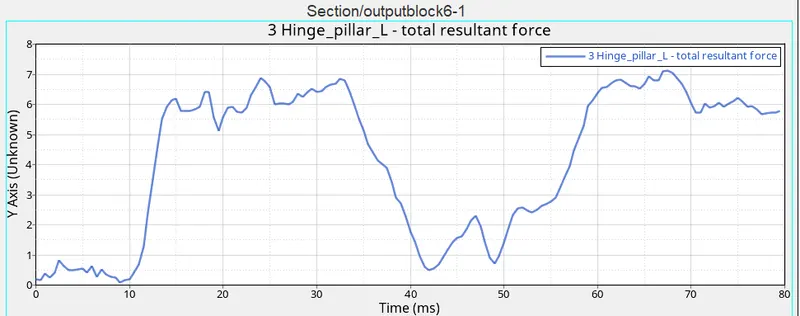
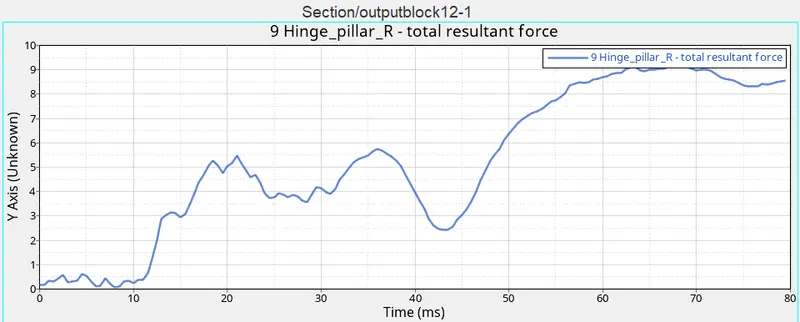
RESULT
We notice that the dashboard has an intrusion of over 870.97 mm with respect to the B-pillar mid support.
We saw a normal termination with no of the cycle of 80001 and elapsed time of 5462.79 s. We saw that the Energy error % is around -0.9% and the Mass error at 0.029 and found them to be satisfactory.
The frontal car analysis was performed with the frontal section of the BIW. Due to the limitation of the Radioss solver to import the full BIW model with 300k element, we had to reduce the size to a bare minimum to continue the analysis. The mass of the BIW was initially was just 188kgs which was increased to 700 kgs to intimate the whole car model with proper mass and CG.
| Result Type | Left side | Right side |
| Sectional force in the rails (Kgmm/ms2) | 7.54 | 7.30 |
| On rails from bumper (Kgmm/ms2) | 7.30 | 14.91 |
| Shotgun cross-sectional forces (Kgmm/ms2) | 5.54 | 8.30 |
| A pillar cross-section (Kgmm/ms2) | 2.49 | 3.58 |
| Hinge Pillar cross-section forces (Kgmm/ms2) | 7.13 | 9.20 |
| Acceleration curve (mm/ms2) | 2.41 | 1.98 |
Internal energy and Kinetic energy is the total sum of Energies. When Internal increases with the crash taking place and getting converted into kinetic energy it lead to the stable total energy. The Kinetic energy is highest before the crash takes place as the vehicle is moving at a certain speed. Just as the crash takes place kinetic energy starts
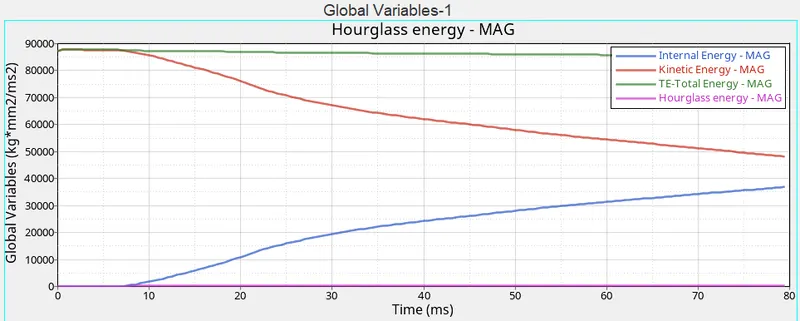
From the above, we can see the hourglass to be almost zero.
CONCLUSION
We have added mass on the nodes to get a value of CG to mimic the full model and the simulation will not be 100% the same as that of the real model. We cannot set up the miss parts properly and will present some errors for sure.
We can see that the resultant force value for the sections on both sides of the body has different values prompting us to conclude that the stiffness of the body is not symmetrical. Also if see the sectional force on rails, the right side seems to have absorbed more impact force than the left side of the body even though the overall peak value is almost the same for both sides.
The acceleration value on the B pillar rocker has a larger value for the right side of the body which means that the left side of the BIW is crushed before the right side.
As far as the error is concerned we did not encounter any during the simulation but had some warning regarding the DRUCKER-PRAGER MATERIAL LAW and Rigid Body connection to the accelerometer. They did not have any significant effect on our simulation. So we will ignore them for this analysis.
Finally, as far as the frontal crash simulation is concerned it is important for the BIW to absorb the energy and come to rest to prevent any major intrusion in the B cabin(Passenger seating zone). It is important for the safety of the occupants and that's why we measured the intrusion in the cabin space.