Simulation of Frontal crash test for Neon car in Radioss.
PROJECT 1
Crash worthiness is one of the core topics in the passive safety of vehicles and plays an important role in the condition that the impact cannot be avoided. Generally, the analysis of crashworthiness is based on the related crash responses, i.e. the displacement, velocity and acceleration, of critical parts of a vehicle in full car crash tests. However, these tests are required appropriate facilities, one or more cars with measuring devices, experienced staff and a long time to prepare. It means they are complicated, expensive, long-lasting and therefore not easy to realize. This is especially true in the early stage of vehicle design. Therefore, vehicle designers and researchers made a lot of effort to build numerical models to describe the crash processes. Up to now, various technologies are used to model the vehicle crash. Typical crash models may be classified into three broad categories
1) Detailed nonlinear finite element models.
2) Multi body models and multi body based lumped parameter models.
3) Functional approximation or response surface models.
In the proceeding of the study, a piece wise linear model is proposed to represent the vehicle-rigid wall frontal crash. Compared to existing models, this model is developed based on the analysis of crash responses and therefore can reflect the performance of vehicle structures in crashes.the vehicle structure would transmit the impact load in a proper way, i.e. load-carrying path. In addition, there are some weak components arranged as crumple zone. During the crash, the crumple zone will deform and absorb energy and ensure the rest parts of the vehicle are safe. In the local design, the material and shape of beams, shells and connectors are also considered to achieve better energy-absorbing performance.
Crash is the explicit analysis. Explicit dynamics analysis is used to determine the dynamic response of a structure due to stress wave propagation, impact or rapidly changing time- dependent loads. Momentum exchange between moving bodies and inertial effects are usually important aspects of the type of analysis being conducted. This type of analysis can also be used to model mechanical phenomena that are highly nonlinear. Nonlinearities may stem from the materials, (hyperelasticity, plastic flows, failure), from contact (high speed collisions and impact) and from the geometric deformation (buckling and collapse). Events with time scales of less than 1 second (usually of order milliseconds) are efficiently simulated with this type of analysis. Based on all these conditions the user will select an explicit solver to solve the analysis. Typical examples of explicit analysis are crash analysis, drop test, bird strike, fan blade out…etc. Obtaining an answer from an explicit simulation can be simple — it can be more challenging to get the correct answer. The predictions of a simulation are usually very difficult to confirm using traditional techniques, making it crucial that the analysis is carried out carefully and thoroughly. Nonlinear analysis requires a lot of experience and a careful understanding of what you want to achieve, as well as a careful understanding of the software's analytical capabilities. When choosing a method for a dynamic problem, considerations must be made regarding the length of time the response can take place compared to the explicit method's stability limit.
Various Crash Test
A crash test is a form of destructive testing usually performed in order to ensure safe design standards in crashworthiness and crash compatibility for various types of vehicle like small, medium and heavy duty and its related systems and components for the sake of getting the performance of the vehicle under the different conditions of crash at different angles with taking certain object like rigid wall, cables specially three-strand cable, concrete barriers, guardrail systems etc. It will be performed either by numerical simulations or experimentally. Figure below depicts different types of crash test generally used.
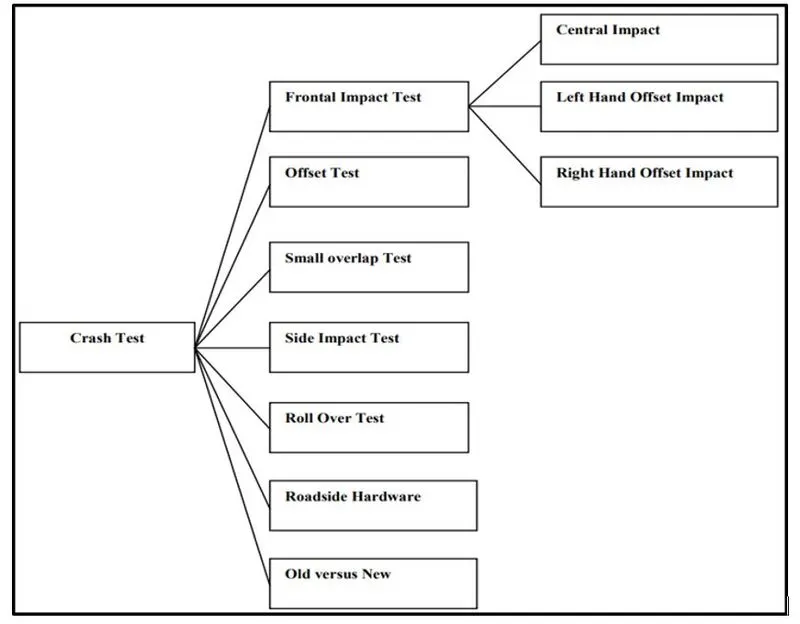
• Frontal Impact test- In this test a fully front structure of the vehicle collides with another object like another vehicle, rigid wall etc. at a given speed.
• Offset Test- In this test only a part of front portion of the vehicle strikes on some barrier usually a vehicle at a given speed.
• Small Overlap Test- In this only a small portions of the vehicle strikes an object like tree, pole or if a car were to clip another. This situation loads a maximum value of force into the vehicle structure at a particular given speed. This test usually comprises of 15% to 20% of the front structure.
• Side Impact Test- In this test sometimes the vehicle is in static condition or in dynamic and another vehicle or an object collide at the side surface having some speed.
• Roll-Over Test- In this test a vehicle is in rollover condition having certain angle by which they tests ability (specifically the pillars holding the roof) to support itself in a dynamic impact. It is also done for the static crash testing condition.
• Roadside Hardware- These are performed to ensure that the crash barriers and crash cushions will protect vehicle occupants from roadside hazards.
• Old Versus New- In this an impact is done between old car against a new car and the big car against a small car; it is performed to show the advancements in crashworthiness.
Crash tests are conducted under rigorous scintific and safety standards. Each crash test is very expensive so the maximum amount of data must be extracted from each test. Usually, this requires the use of high-speed data-acquisition, at least one traixial accelerometer and a crash test dummy, but often includes more.Crash test is much important which helps in minimizing the losses such as deaths,injuries and prioperty damages from the vehicle crashes on the roads.
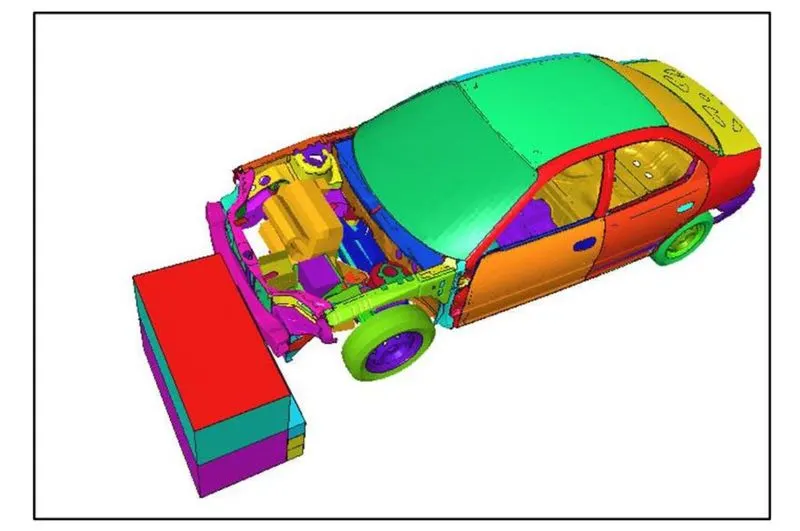
In this Project we have performing the Frontal crash of the vehicle.Frontal impacts are the impacts undertaken against the solid barrier with precise speed.Test reequire3s only front portion of the vehicle to impact the barrier.
In the New Car Assessment Program (NCAP), passenger vehicles are crashed at 35 mph into a rigid barrier that covers the full width of the vehicle. The Institute runs offset frontal tests instead of full- width frontal tests. In an offset crash only one side of a vehicle's front end, not the full width, hits the barrier.
During a car crash, energy is transferred from the vehicle to whatever it hits, be it another vehicle or a stationary object. This transfer of energy, depending on variables that alter states of motion, can cause injuries and damage cars and property. The object that was struck will either absorb the energy thrust upon it or possibly transfer that energy back to the vehicle that struck it. Focusing on the distinction between force and energy can help explain the physics involved.
Software used for Crash Analysis:
• LS-DYNA
• PAMCRASH
• RADIOSS
• MSC.DYTRAN
• MADYMO
• ABAQUS
• ANSYS
Implicit and Explicit Philosophy
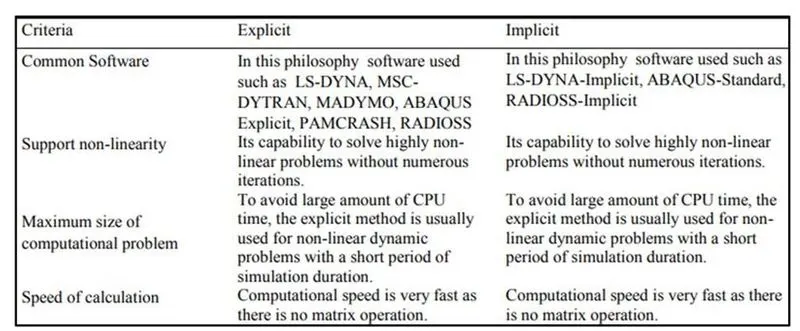
Most software’s would normally solve the dynamic equilibrium equation in an implicit approach however the foremost widespread approach that ought to be used for highly non-linear issues is to use explicit(specific) time integration scheme like a central difference scheme. There are several benefits of such a procedure and therefore the most significant is that it results in an algorithmic programmed which may be simplified programmed, does not need any matrix operation procedure and more is very appropriate for a quick parallel computing methodology.In the the below Table shows the common difference between the implicit and explicit philosophy.
Procedure:
1) Import the given Model into Hypermesh Workbench.
• Go to Import Command which is in Tool Bar.
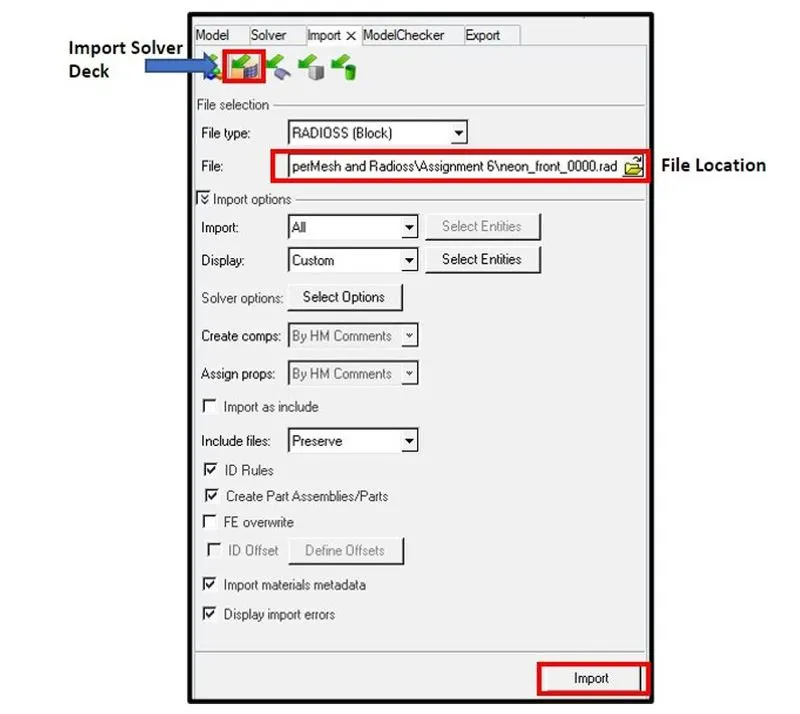
Model will be displayed in the hypermesh Graphics area ashown below:
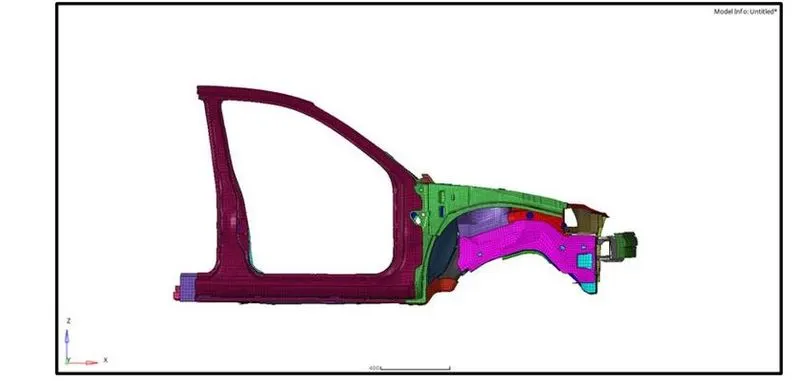
Case Setup and Execution:
1) Check unit system and either follow[Mg mm s] or [Kg mm ms].
• Open the Starter file Neon_Front_0000.rad in the Note pad and Check the Unit System followed.
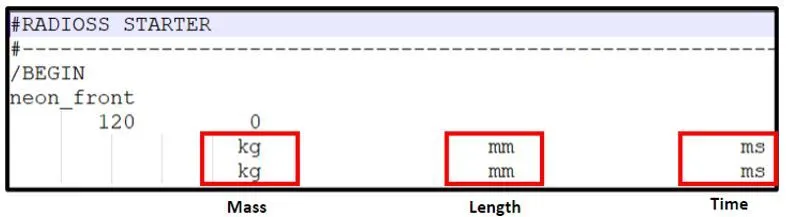
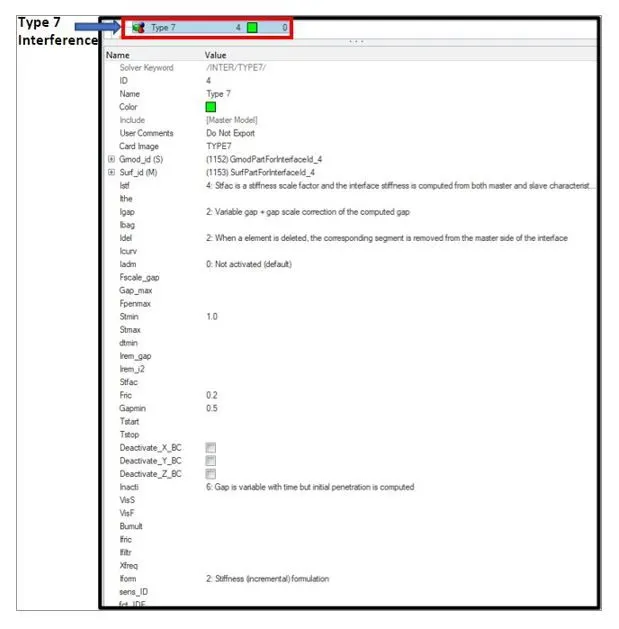
2) Create appropriate interface ,friction 0.2 and recommended
In this case,Type 7 Contact Interface is defined.Interface TYPE7 is a multi-usage impact interface, modeling contact between a master surface and a group of slave nodes. It is also possible to consider heat transfer and heat friction.
All limitations that were encountered with interfaces TYPE3, TYPE4 and TYPE5 are solved with this interface:
- A node can at the same time be a slave and a master
- Each slave node can impact each master segment; except if it is connected to this
- A node can impact on more than one
- A node can impact on the two sides, on the edges and on the corners of each
- It is a fast search algorithm without The main limitations of this interface are:
- Time step is reduced in case of high impact speed or contacts with small
- It does not work properly if used with a rigid body at high impact speed or rigid body with small
Defined Properties are shown below:
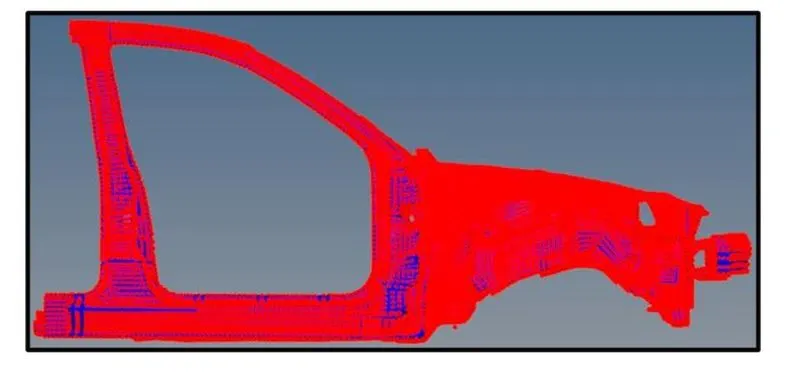 '
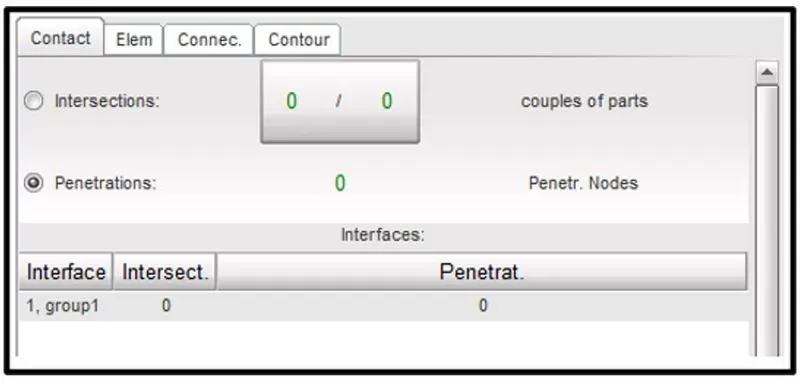
3) Make Sure No Intersection and Penetration in the Model
Before Going to run the Simulation always we should make sure that there is No intersection or penetration in the model.If there is any penetration then we can remove it by using the tools
provided in the Hypermesh or hypercrash.Since in this Model we dont have any Intersection and penetration we take takethe model to the further process.
4) Create rigid wall with friction 0.1.
There are four types of rigid walls available in Radioss:
1. Infinite Plane
2. Infinite Cylinder with Diameter D
3. Sphere with Diameter D
4. Parallelogram
Each wall can be fixed or moving.
A kinematic condition is applied on each impacted slave node. Therefore, a slave node cannot have another kinematic condition; unless these conditions are applied in orthogonal directions.
In this we have used the infinite plane rigid walls.
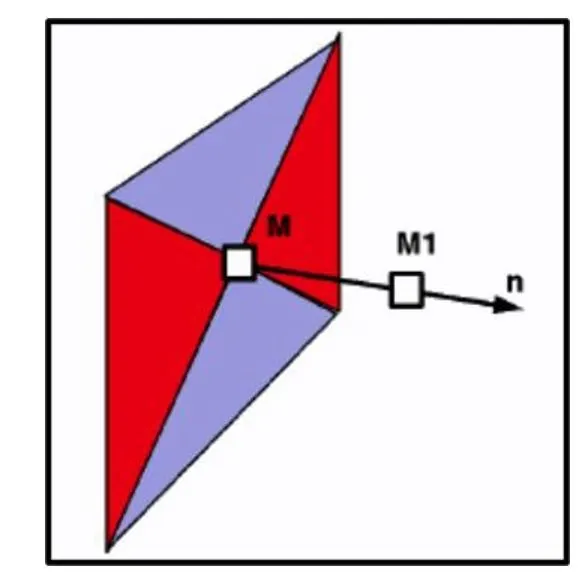
A Rigid wall is a pure kinematic option on all impacted slave nodes. It is defined using two points, M and M1. These define the normal, as shown in figure below:
Now let us create the Rigid wall for the given Model
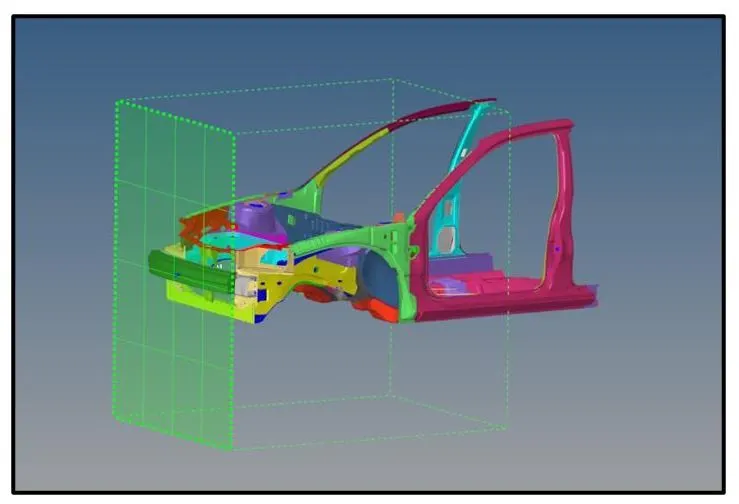
In this model we are creating the rigid wall with friction of 0.1 and Search Distance of 2000.
• Go to Solver Browser>Right Click>Create>RWALL
• Select the Type of rigid Wall.In this we have taken.
• Enter the Coordinate of Nodes(M) where rigid wall to be created.
• Define the Node group defining slave nodes to be added to the rigid wall(grnd_ID1).
• Define the distance for slave search(D_search).
• Define the friction coefficiant as 0.1(Input data)
• The Rigid wall will be created as shown in picture below:
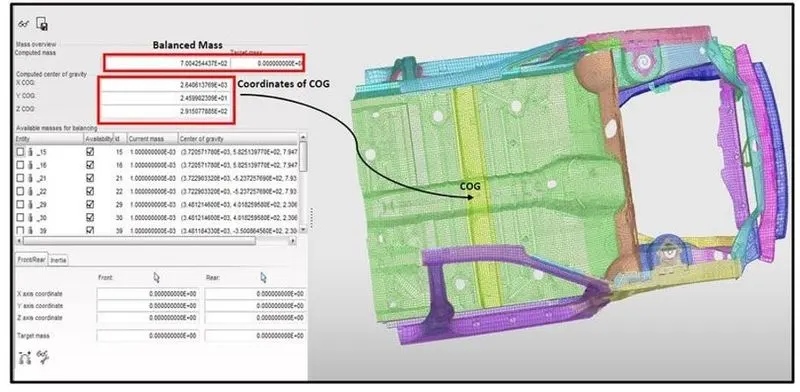
5) Compare the model weight with the full scale 300k nodes model and use added masses to reach target weight 700kg while getting CG about the required range.
To find the Initial COG of the Component,
• Import the model into hypercrash.
• Go to Mass>Balancing
• Total Weight of the given model is aaprx 188kg and the COG is situated at the place near to the Gear Lever as shown in the figure below:
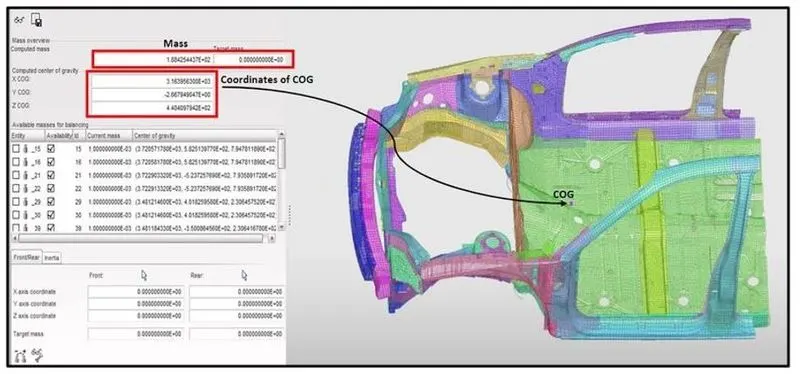
As per Full Scale Model the total weight of the component is 700kg and COG is near to the Cross Beam.In order to place the COG near to the Cross Beam ,we need to add the Mass and Balance the Component.
• Go to Load case>Added Mass.
• Add Mass to the Suitable Component on the Floor Panel.For Eg:Give the Weight of 130kg near to the Driver Seat(Weight of the Seat is 50kg and average weight of the Passenger is 80kg)
• Hence the Balanced Component with weight of 700kgs is shown below:
6) Initial velocity 35 mph.
Initial Velocity is the velocity at time interval t = 0 and it is represented by u. It is the velocity at which the motion starts.
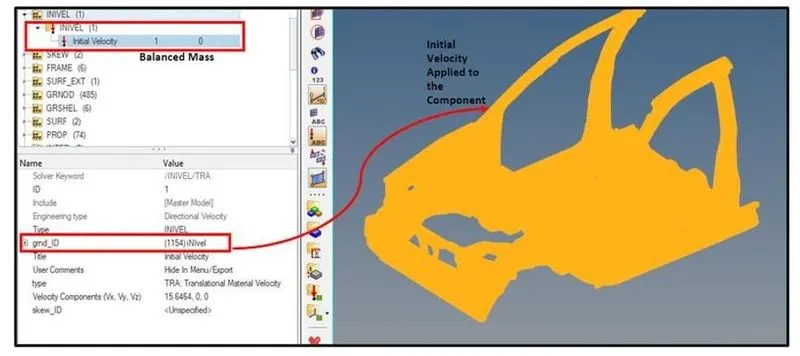
So in order to perform the crash test we need to input the Initial Velocity for the car which in 35mph
equivalant to 15.64mm/ms in the direction where the vehicle is going to hit the Rigid wall.
• Initial velocity can be added both in Hypermesh and Hyper crash
• in hypermesh,Go to Solver Browser>Right Click>Create>INIVEL.
• In this we can initialize both translational and rotational velocities on a group of nodes in a given coordinate system.
• Define the Node group on which specified initial velocities are applied(grnd_ID1).
• Define the Type of Velocity (Translational /Rotational).
• Since we need to apply the velocity in translational X Direction,define the velocity (15.646mm/ms) in `V underset x`.
• Thus the Initial Velocity is applied as shown in the Figure
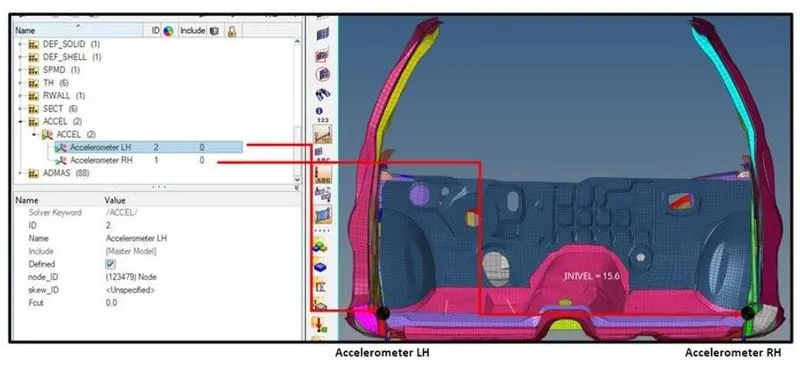
7) Fixing Accelerometer at the B Piller on Both Sides.
An accelerometer is an electromechanical device used to measure acceleration forces. Such forces may be static, like the continuous force of gravity or, as is the case with many mobile devices, dynamic to sense movement or vibrations. Acceleration is the measurement of the change in velocity, or speed divided by time.
Here in order to check the accelertaion of the nodes at the B piller,we are providing the Accelerometer.
• Go to Solver Browser>Right Click>Create>ACCEL.
• Select the Node where we need to put an Accelerometer.
• Define the Skew Id if Needed.
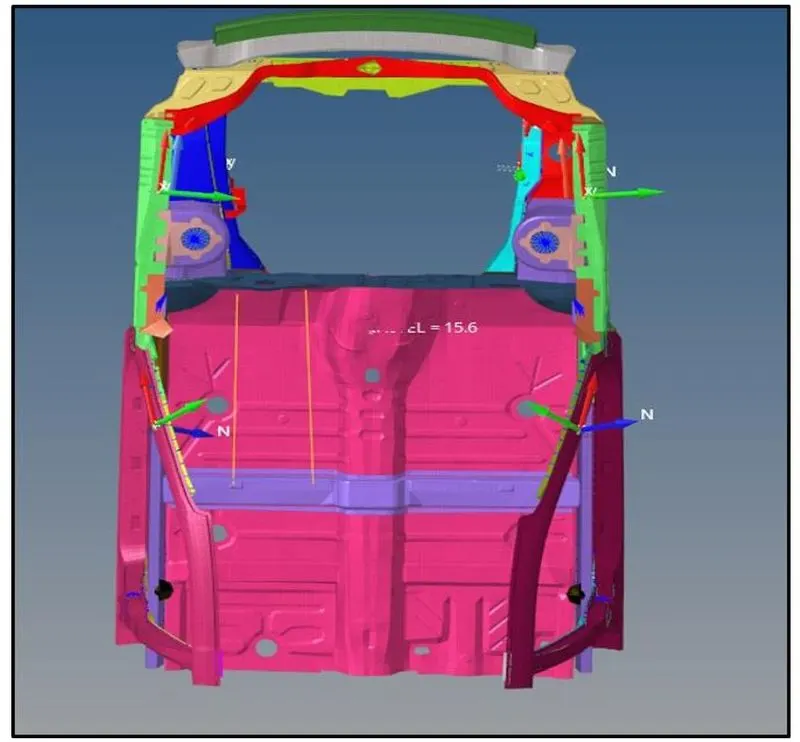
• Accelerometer has been placed as hown in the figure:
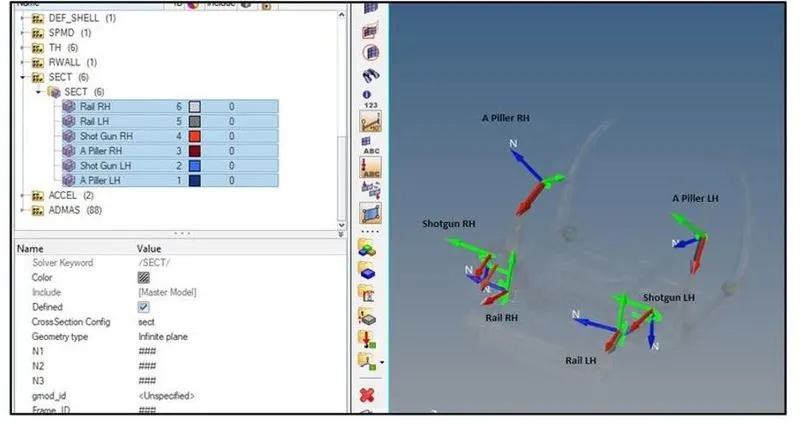
8) Creation of Sections at A Piller,B Piller ,Shot Gun,rails and the Bumper in order to Study the sectional forces.
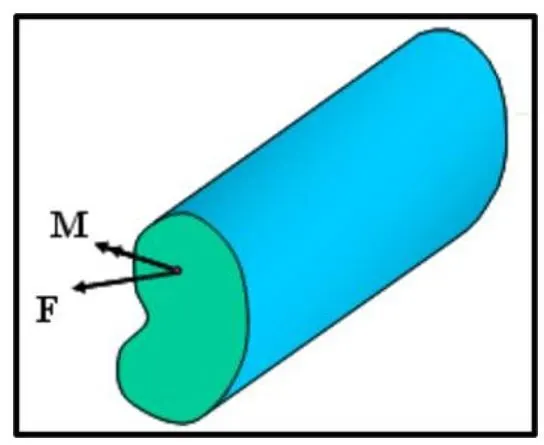
A section is a cut in the structure, where forces, moments or energy will be computed and stored in output files (using /TH/SECTIO).
Generally, to define the section, the following points are required:
• A cutting plane.
• A reference point to compute forces.
• A direction of the section.
• To Create the Sections at perticular area,create the FRAME over there. Frames are used to define local directions.These directions can be used to apply:
• Boundary conditions
• Concentrated load
• Fixed velocity
It is a mobile or fixed reference. The quantities are computed with respect to the origin of the frame which may be in motion or not depending on the kind of reference frame. For a moving reference frame, the position and the orientation of the reference vary in time during the motion. The origin of the frame defined by a node position is tied to the node.Frame is used to measure the relative Motions.
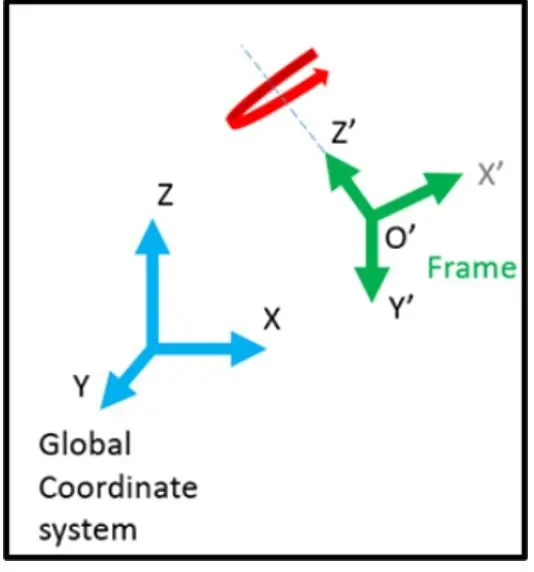
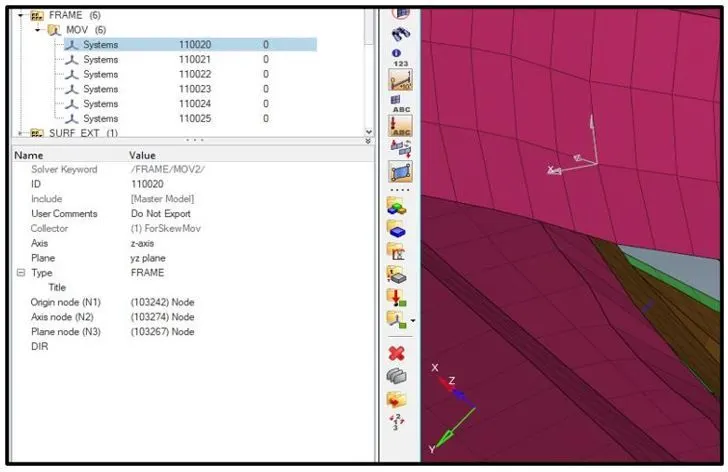
• To Create the Frame,Go to Solver Browser>Right Click>Create>FRAME.
• Define the Nodes as the Axis of the Frame
• Thus the frame is Created as shown below:
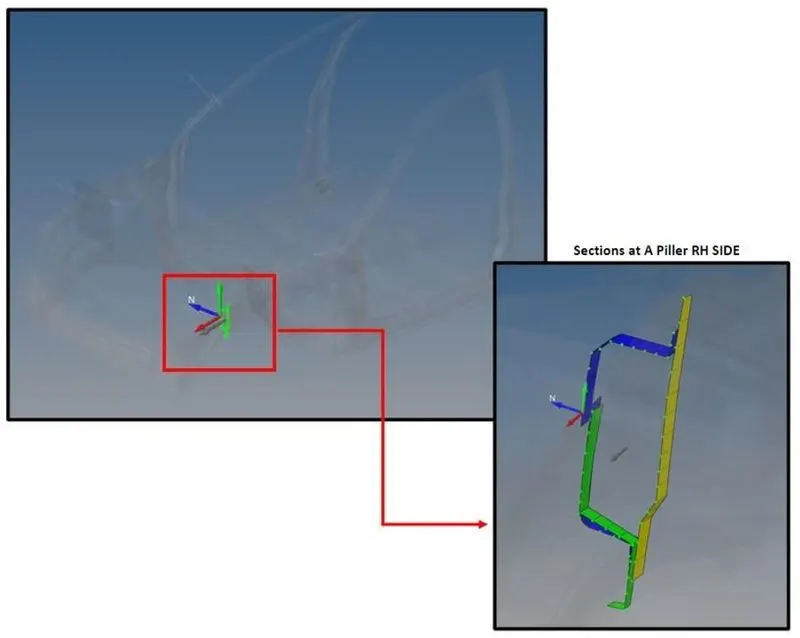
Once the frame is created ,We need to create the Section at the Areas.
• To Create the Frame,Go to Solver Browser>Right Click>Create>SECTIO.
• Define the Nodes with reference to the Axis of the Frame.
• Define Delta T and Alpha Value as 0.1 and 1.67 respectively.
• Define the cutting plane by a group of elements and its orientation by a group of nodes(grshell_ID)
• Thus the Selection has been Created at A Piller LH Side as shown below:
Similarlly the Sections is created at B Piller,Shotgun and the Rails as shown below:
9) Intrusions on the dash wall 66695,66244.
In order to Check the Intrusion at the given Nodes,We have create the Spring at the place and applied Spring Properties and requested output in the TH File.
• To Create the Spring,Go to 1D>Springs>Select the Nodes where the spring is to be created.
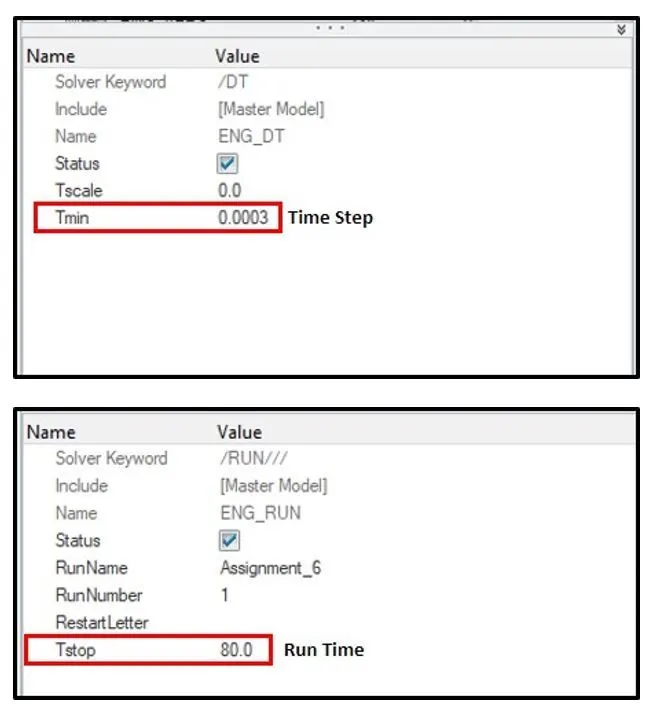
10) Check Model cards and change Time-step 0.5 to 0.1 microseconds and Run time 80ms
11) Creation of Output request
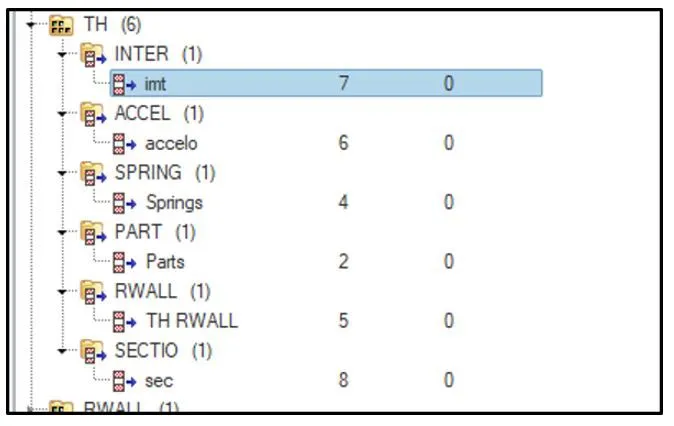
Once al the Deck setup is done ,we need to create the output request in TH.
• To Ask for output request,Go to Solver Browser>TH>Select the output we need.
• Select the Entity for wich the utput is required.
• Thus the time history file has been setup as shown in the figure below:
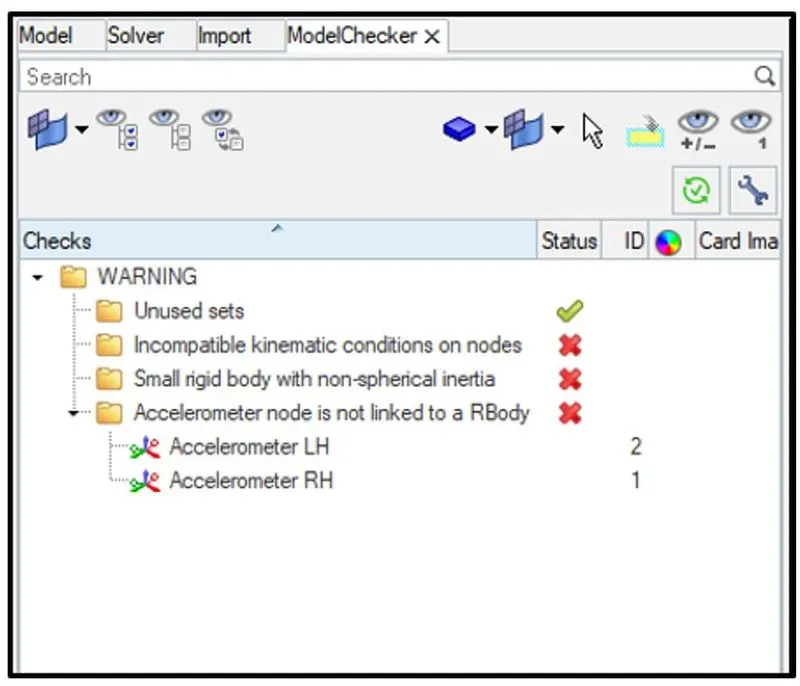
12) Use model checker to ensure good quality.
In order to run the simulation smoothly we need to check the model if there is any errors.On Checking the Model Checker we will come to know if any errors is there in the Model and we have to debug the issue.
13) Run the Simulation,To Run the Simulation,
• Go to Analysis>Select the Location to where the animated file to save
• Hit on Radioss.
Results and Comparison:
1) Energy Error and Mass Error
• Open the 0001.Out File in Notepad.
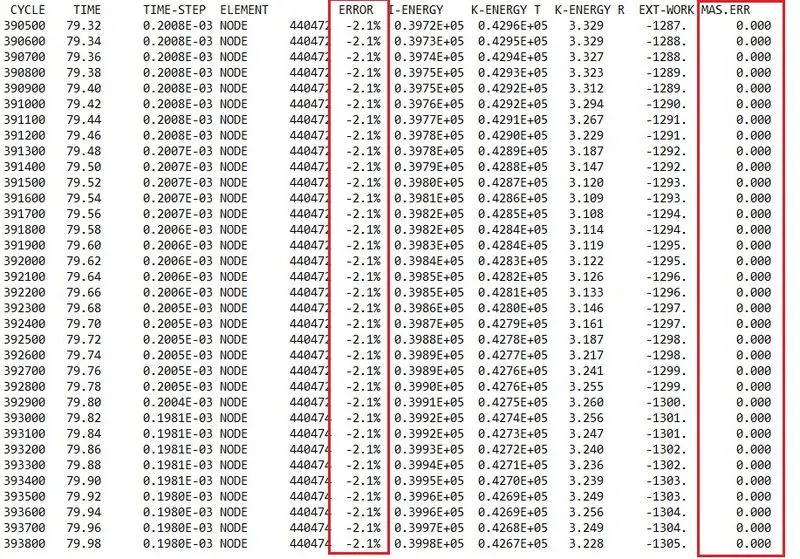
From the Above Image we can see that the maximum Energy error is -2.1% and Mass Error is Zero which is Accepted and the total number of cycles is 393800.
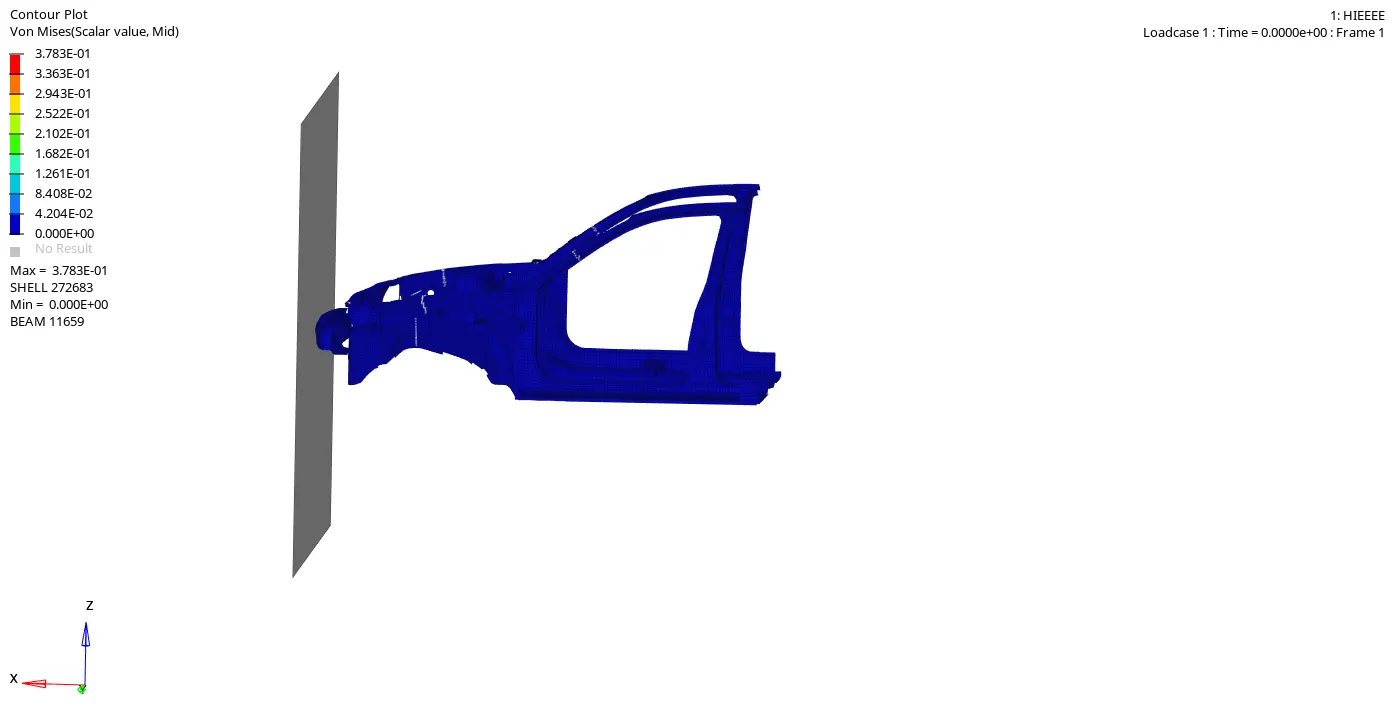
2) Von Mises Stress
Maximum Von Mises Stress occured is 0.37Gpa at Node 191116.From the below Animation we can see that once the car hits the Rigid wall,the maximum stress is flowing from the bumper region to the A Piller and also towards the floor panel.
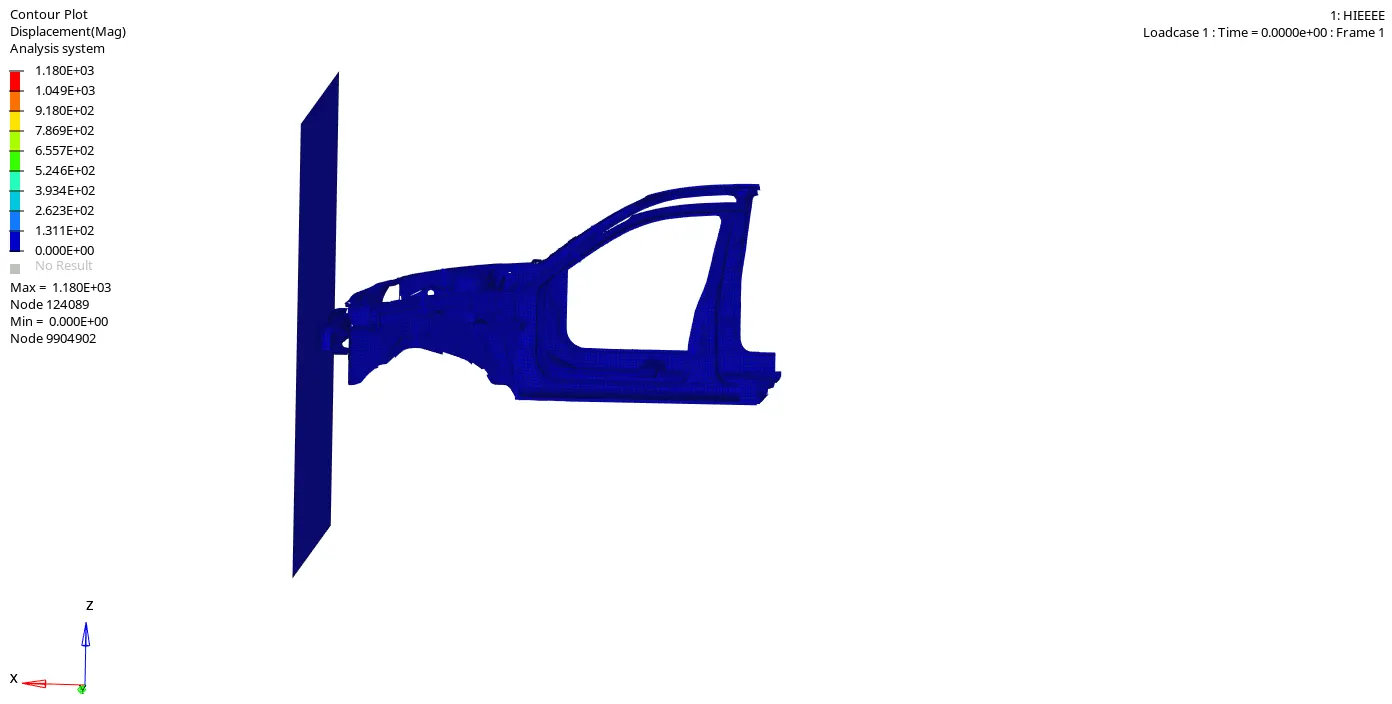
3) Displacement
the Maximum displacement occured is 1180mm at node 79695
4) Energy Plots
• Internal Energy and Kinetic Energy
Internal energy is nothing but the Heat of the System.When the Kinetic Energy is Decreases,the Energy absorbed by the system increases i.e we all know that Energy neither be created nor be destroyed.Once the Vehicle is moving with certain velocity(Say 15.646mmm/ms for the Model),initial kinetic Energy will be High(Refer Above Graph).Once the car is hit to the rigid wall,the vehicle starts deforming results in absorbing the Surrounding Energy and Stored in it.Thus the internal Energy starts increasing.At the Maximum deformation,the Velocity will become Zero and thus the kinetics Energy will also be droping down to zero resulting there is no energy to absorb in the system.Thus the Internal Energy Remains Constant thereafter.
Once after the simulation,The maximun kinitic Energy is found at 85467.8kN/mm at t=0 and the maximun internal Energy is at 41076.5kN/mm at t=79.5ms.
• Contact Energy and Hourglass Energy
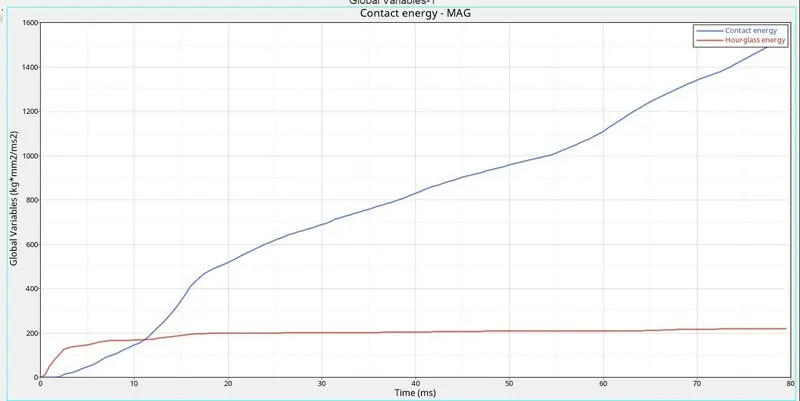
From the above graph we can see that the Hourglass energy is almost negligible since we have used Improved integrated element formulation(QEPH).From the Graph the hourglass energy is at 0 and constant throughout the simulation.
Contact Energy is nothing but the opposite energy generated from the System to Avoild the Penetration.To avoid the penetration we have determine the `Gap underset min` value to 0.5.When the car is moving with velocity of 35mph and hits the rigid wall,it starts deformation at the bumper section and hence the penetration of the elements occurs and thus the opposite reaction force also exerted in order to avoid the penetration.Hence the contact energy increasing gradually from zero.The maximum Contact energy found is 1530.1kN/mm at t=79.5ms.
5) Sectional Force
• Sectional Force at A Piller LH and RH
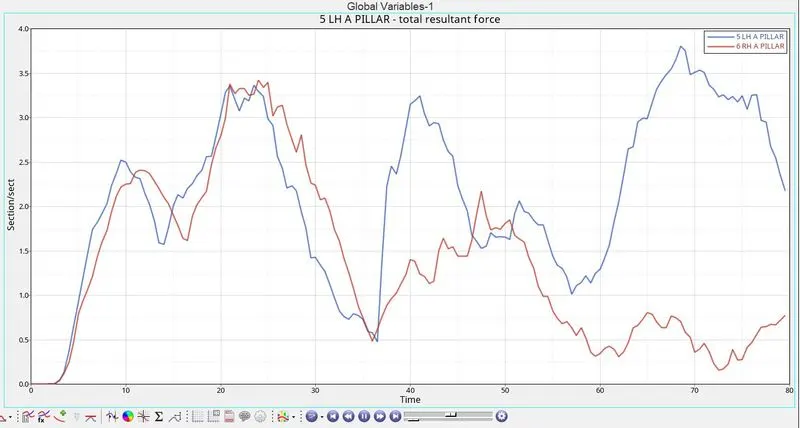
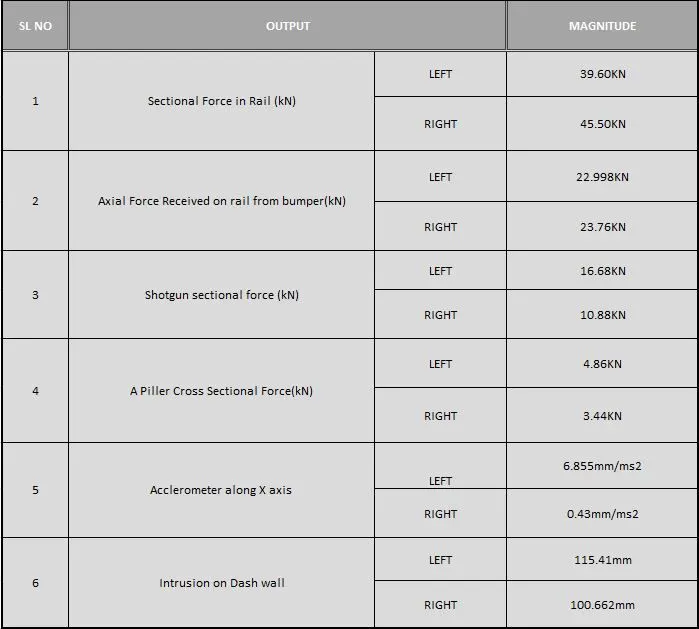
The maximum cross sectional force at Left A Piller is 4.86kN/mm at t= 65ms whwere as maximum cross sectional force at Right A Piller is 3.44kN/mm at t=24.1ms.The Force occured at the A Piller are the force transmited from the Shotgun section.The force propogation is not same at both the Lh and Rh and hence the amount of deformation at both the A Pillersections are differnt.Once the car bumper hits the rigid wall the compressive force is transmited from bumper to the A piller through raila and shotguns.So Obiviously the Sectional force at A pillers are very less compared to the Section which is ar front of the A Piller as seen from the animation.Once the maximum compressive force reached,it start bending of the shotgun results in the shotgun coming in contact with Rigid wall and rigid wall in turn exert the force on the shotgun.thsi force is again propogates to the A Piller hence sectional force is increasing again.
• Sectional Force at Rail
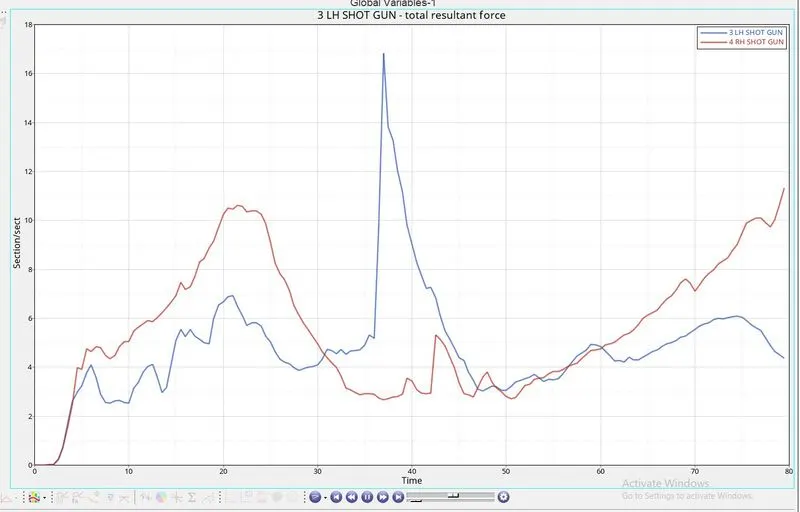
The maximum cross sectional force at Left Shotgun is 16.68kN/mm at t=39.7ms where as maximum cross sectional force at Right Shotgun is 10.88kN/mm at t=80ms.The Force occured at the shortgun are the force transmited from the rail section.The force propogation is not same at both the rails and hence the amount of deformation at both the shotgun sections are differnt.Once the Compressive force reaches its maximum value it starts to deform rapidly.Therefore the Compressive force is decreasing as refered from the graph.As the crash contintinues,the shotgun will come into contact with Rigidwall as found in Animation,the rigid wall also exert the force directly on to the shorguns and hence there is a increase in the Sectional force as seen in graph.
• Intrusions on the dash wall 66695,66244.
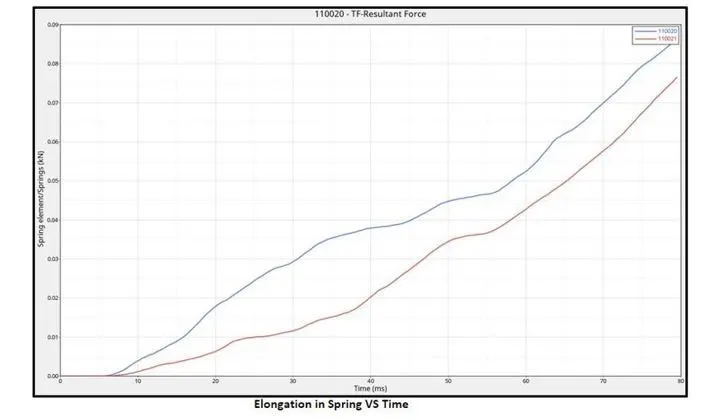
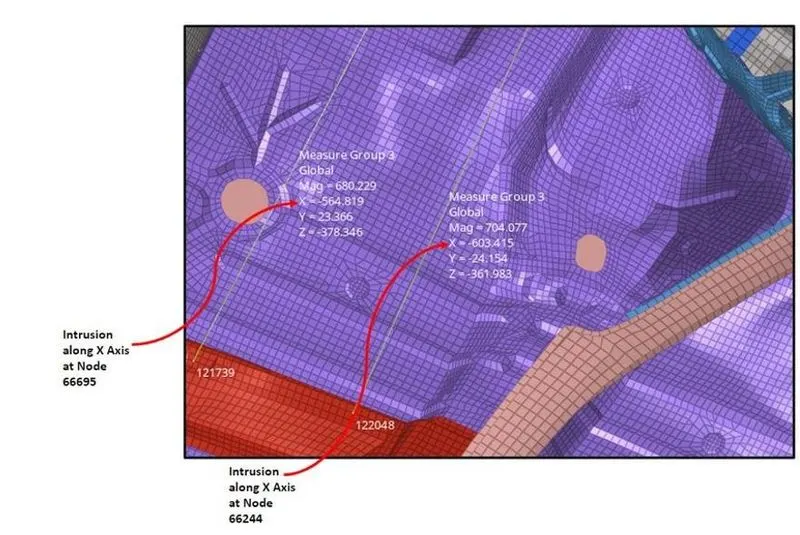
To check the Intrusion at dash wall at the perticulaer given node,we have created the spring over the place.Intrusion at this perticuler node is calculated in order to check weather the crash will result in the safty of the driver due to the deformation occured at the front portion of the vehicle.From the above graph we can see that rhe maximum intrusion occured in the spring(Node 66695,121739) during crash is 115.41mm and maximum intrusion occured in the spring(Node 66695,121739) during crash is 100.662 mm.Practically this eleomgation refered to which extent the foot pedal or the passenger legs will move once the crash is happening .From the animation we can notice that there is not much deformation occured at this location and the elongation is also low.Hence we can coclude that there is a less injuries will happen to the Passenger/driver.
6) Acceleration curve received on the accelerometer at base of B pillar
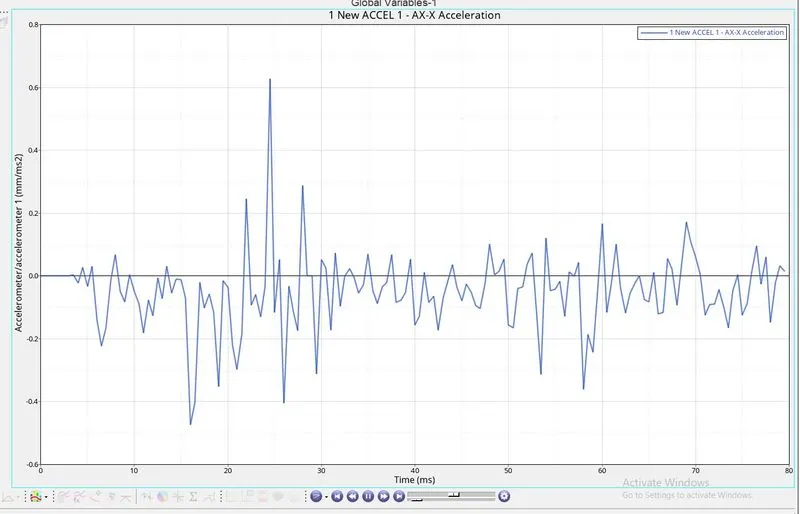
Acceleration RH VS Time
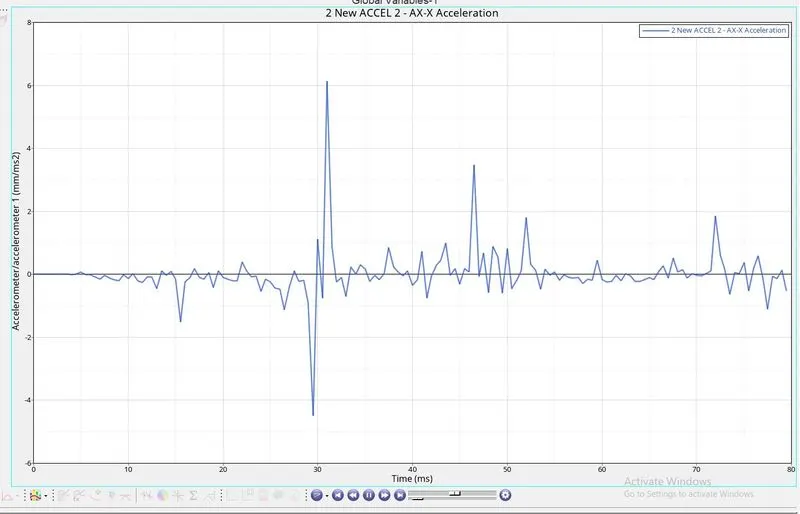
Acceleration LH VS Time
As we all know that an Acceleration is the rate of change of velocity.To measure the acceration ,we have placed the accelerometer near to the Rocker at both the sides. From the above graph we can see that initially the acceleration is constant before vehicle hittng the rigid wall.Once the Car hits the rigid wall with the initial velocity,the front structure crushers tranforming the vehicles kinitic energy into strain energy within the vehicle's deforming front structure,thereby bringing the vehicles to rest.The acceleration of the vehicle during the crash is not constant across the structure.The front of the vehicle slows down immediately as it hits the rigid wall, while the rest of the structure decelerates at a slower rate as seeing in graph.As seen from graph there is sudden increase in the
accleration,this might be because of some vibration occur during the crash with respect to the point where the acclerometer is placed.
The max Acclerations at X direction recored in Lh Accelerometer is 6.855 `frac{mm}{ms^2}` at
t=29ms and Max Deceleartion occured is 5.584 `frac{mm}{ms^2}` at t=28ms.
The max Acclerations at X direction recorded in Rh Accelerometer is 0.43`frac{mm}{ms^2}` at
t=29ms and Max Deceleartion occured is 0.537 `frac{mm}{ms^2}` at t=33ms.
Also Notice that Acclerometer has recorded the Accleration in Y and Z Direction also.Hence the max Resultant Accleration recored in Lh Accelerometer is 8.17 `frac{mm}{ms^2}` at t=29ms and max Resultant Accleration recored in Rh Accelerometer is 1.6 `frac{mm}{ms^2}` at t=66ms(Refered from Total resultant Accleation Vs Time Plot)
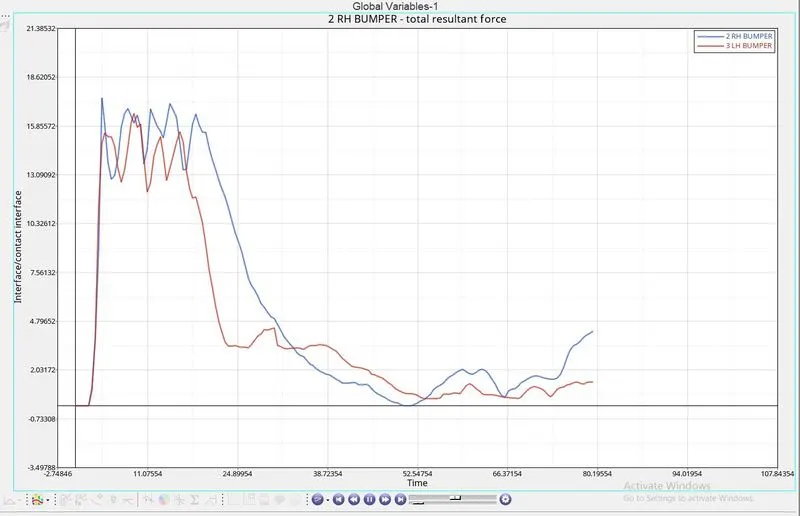
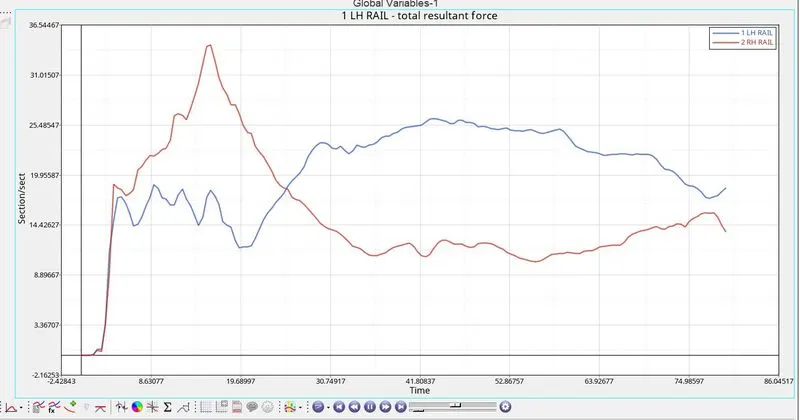
From the graph we can see that initially there is no axial force is transmited from bumper to the Rail.Once the Vehicle hits the rigid wall,first the Bumber will start deforming transmiting the starin energy to the rail sections.From the graph we found that the Maximum axial force received from bumper to the LH rail is 17.22kN nd Maximum axail force received from bumper to the RH rail is 17.98 kN.
Consclusion:
In the present work, Finite element modelling practices used for crash analysis are studied and after effects of the different parameters on the vehicle have been reviewed.The aim of this work is to study the effects of such crash
parameters on the dynamic response of automobile component through finite element approach path.These analyses mainly focus on software selected, crash type, vehicle/components considered for crashing, material used, type of element used, boundary conditions adopted tool used for post processing the results etc.
Thus the Given Neon Dodge Car has been Analised under the given Condition,Applied boundry Condition, and Studied the behaviour of Propogation of forces from one component to another and also studied the acceleration involved in the crash test along the direction of moving vehicle.The total deformation of the car structure is analyzed. From this model we can conclude that the Contact interface and penetration plays a vital role in the crash test.Even a single mistake results in the variation in time step and also high contact energy.Also the center of gravity (COG) of the car is important to determine the dynamic performance as all the forces and moments are acting at the COG. The stability of the vehicle depends on the road conditions and driving maneuvers.Hence the Mass Balancing also plays a improtant role in the crash test.
In the future scope, different car body structures can be modelled and different car body materials can be taken by assigning different velocities for crash analysis.