Frontal crash- BIW of NEON
AIM:-
To setup & run the simulation of Frontal crash- BIW of NEON and observe the errors and energy changes.
SOFTWARE:-
HYPERWORKS
OBJECTIVES:-
Objectives to check in this model:-
- 1.Check unit system and either follow[Mg mm s] or [Kg mm ms].
- 2.Create appropriate interface ,friction 0.2 and recommended parameters.
- 3.Make sure of no penetrations and intersections.
- 4.Correct rigid bodies if any issues.
- 5.Create rigid walls with friction 0.1.
- 6.Compare the model weight with the full scale 300k nodes model and use added masses to reach target weight 700kg while getting CG about the required range.
- 7.Initial velocity 35 mph.
- 8.Use model checker to ensure good quality.
- 9.Time-step :0.5 to 0.1 microseconds.
- 10.Run 80 ms.
Output requests:-
- 1.Sectional force in the rails at location of indicated node 174247.
- 2.Axial force received on the rails from the bumper.
- 3.Shotgun cross sectional forces.
- 4.A pillar cross section.
- 5.Acceleration curve received on the accelerometer at base of B pillar (on B pillar rocker).
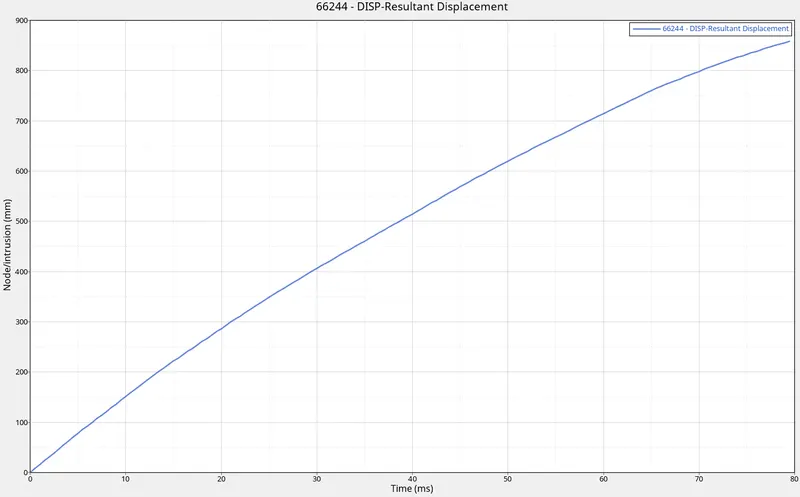
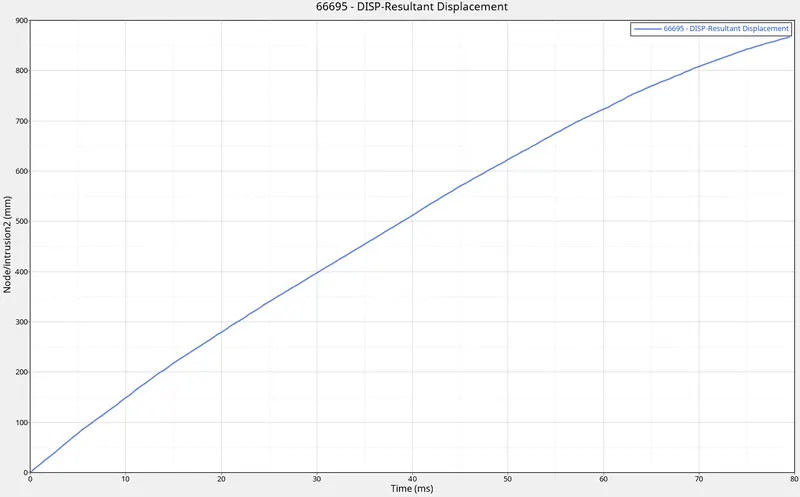
- 6.Intrusions on the dash wall 66695,66244
PROCEDURE:-
Firstly, select the user profile to RADIOSS.
After changing the user profile, import the solverdeck file.
Goto > menu bar > file > import > solver deck.
Now check the unit system.
Goto >Tab bar > Cards > Begin card.
In this simulation we are using the [Kg mm ms] unit system.
After checking the unit system, create an interface.
Goto > Tab bar > Groups > right click on it and create.
In this model, we are creating Type 7 Interface.
The recommended parameters are:-
Istf : 4 - It is the gap for stiffness definition, it is the interface stiffness which is the minimum of the master and slave stiffness.
Igap : 2 - It is the gap option flag. Igap = 2 is Variable gap + gap scale correction of the computed gap.
Idel : 2 - It is the node and segment deletion flag. When a 4-node shell, a 3-node shell or a solid element is deleted, the corresponding segment is removed from the master side of the interface. It is also removed in case of explicit deletion using Radioss Engine keyword /DEL in the Engine file.
Additionally, non-connected nodes are removed from the slave side of the interface.
Stmin : 1 - It is the minimum stiffness value which can be used only if Istf value is not equal to 1.
Irem_gap : 1 - The option Irem_gap is used to deactivate slave nodes which are close to elements. But in this case since we put the value as 1 that means there is no deactivation of slave nodes.
Stfac : 2 - Stiffness scale factor applied to the master side of the interface (if Istf is not equal to 1).
Fric : 0.2 - Coulomb friction
inacti : 6 - Deactivation flag of stiffness in case of initial penetrations. But in this case, the value is set to 6 that means the gap is variable with time but initial penetration is computed.
Gapmin : 0.5 - Minimum gap for impact activation.
Iform : 2 - Stiffness (incremental) formulation.
After creating the new interface card delete all the existing interface cards.
Now create a rigid wall with friction 0.1.
Goto > Tab bar > right click > create > rigid wall.
After a rigid wall is created, assign the base node on the center of the bumper and normal x=-1 as the car is moving towards the rigid wall.
Slide : 2 - sliding with friction
Dsearch : 1000 - Distance for slave search / Search distance.
After assigning the values of the rigid wall, create a balancing Mass and COG to the car.
To add the mass on the car body.
Goto > Tab bar > right click on the tab area > Create > Solver Mass.
After solver mass is created, select the nodes on the cross sections and add constant mass on it.
Similarly create another solver, select the nodes on the other cross section and add constant mass on it.
After the mass is created, Check the mass value matching as per required.
Goto > menu bar > Tools > Mass details > Mass, Cog and Inertia.
COG check it point, It should be on the center of the cross section.
After the mass and COG is applied. Create initial velocity.
Goto > Tab bar > right click on the solver browser > create > BOUNDARY CONDITIONS > INIVEL.
Select gmd_id, select nodes of whole components, Enter the value 15.65 in X-direction as the car collides towards the rigid wall.
After initial velocity, check for penetrations and intersection.
Goto > menu bar > Tools > Penetration check.
Select the interface type 7 which we created, run to check. There are no penetrations and intersections found.
After checking penetrations and intersections, check for errors.
Goto > menu bar > Tools > Model Checker > RadiossBlock.
Select the error right click on it and run.
If there are any errors it will show on the issue count.
After the Model check is done, apply the time-step value tfreq=0.5.
Goto > Tab bar > cards > ENG_ANIM_DT.
After editing the time step, apply run time value Tstop=80.
Goto > Tab bar > cards > ENG_RUN.
Output Request:-
To create a cross section on the body of the car
Goto > Tab bar > solver browser > right click and create > Frame > MOV.
Select the three nodes and create a movable frame.After the frame is created assign it with a local skew to select the local direction.
After assigning skew enter the Iframe=12 and grshell_id to select 2 rows of elements.
Similarly, create a cross section for shotgun, bumper and rails.
To create an Accelerometer on the rocker box below B pillar.
Goto > Tab bar > solver browser > right click and create > Accelerometer.
Select the node_id and enter Fcut=1.65.
To create an intrusion on node id 66695, 66244 as per given.
Goto > Tool > numbers.
Select nodes to search by id. After the numbers are displayed on the graphical screen.
Goto > Tab bar > solver browser > right click and create > SKEW > MOV.
Select three nodes i.e. origin node, Axis node and plane node to create a movable skew for intrusion.
Create card’s in the output block for cross sections, accelerometer and intrusions.
For cross sections.
For Accelerometers.
For intrusion 1.
For intrusion 2.
To call all the output requests we have created in the model.
After all the inputs and values are assigned, run the model checker to check the error.
Errors which have been found after running the model checker need to be cleared. There are two methods to clear the errors.
- To export the radioss file and open in hypercrash and then delete the error that is not assigned. Then export it back to hypermesh.
Note: After the file is imported to hypermesh delete the unsupportable card.
- In hypermesh after running the model checker, Apply auto correction.
After clearing all the errors and checking the values. Run the radioss, including connectors and option value as -nt 4.
After the simulation is runned it creates .h3d,.T01,.out, starter file and engine file.
To view animate file. Open hyperview, load the .h3d file and apply.
To plot graphs. Open hypergraph, load the .T01 file and apply load conditions.
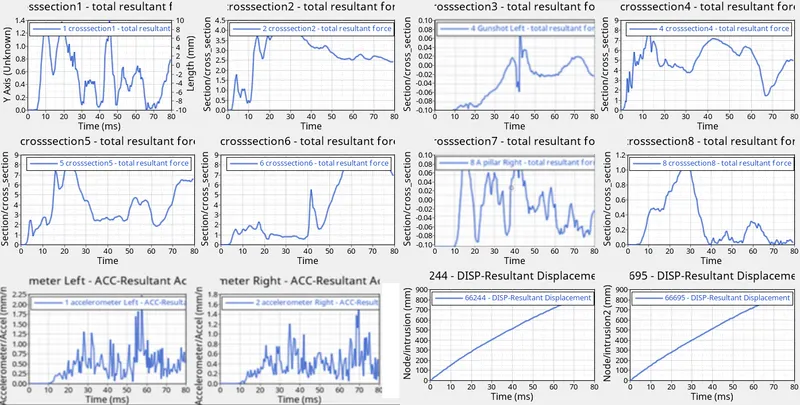
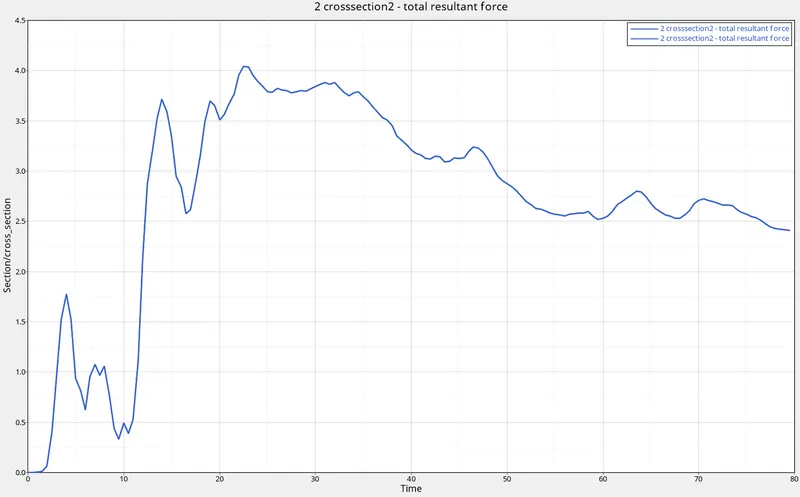
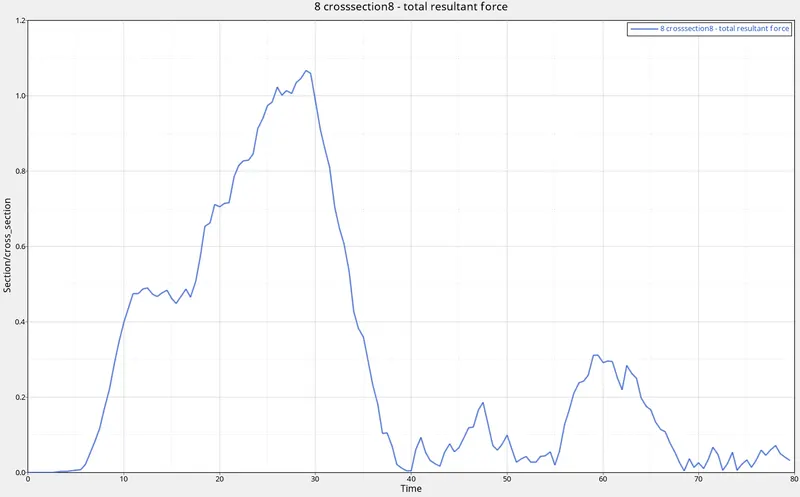
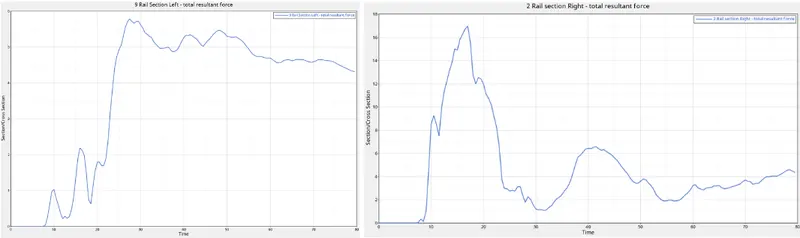
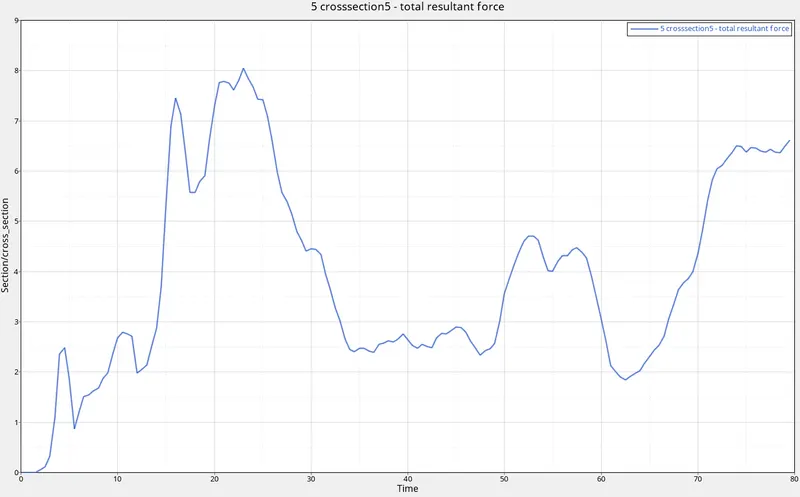
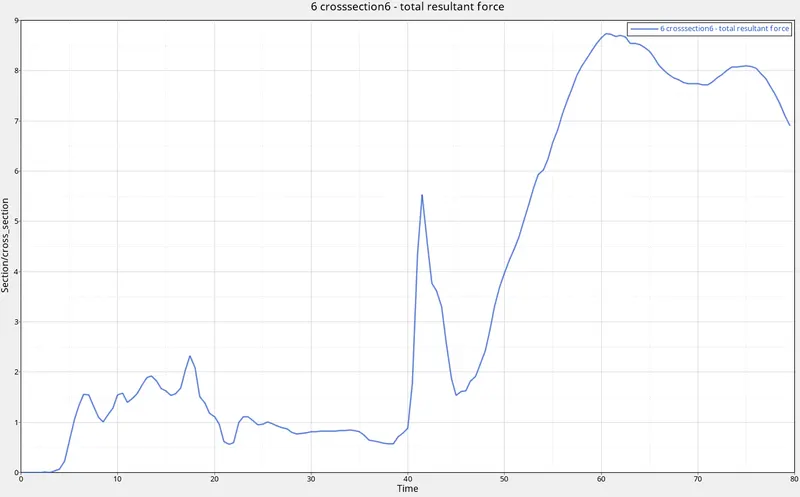
All the cross section, acceleration and intrusions are plotted below.
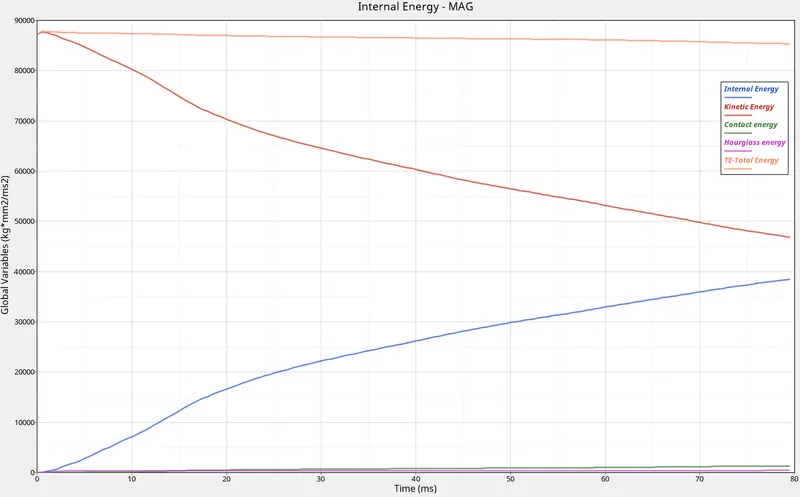
All the energies are plotted below.
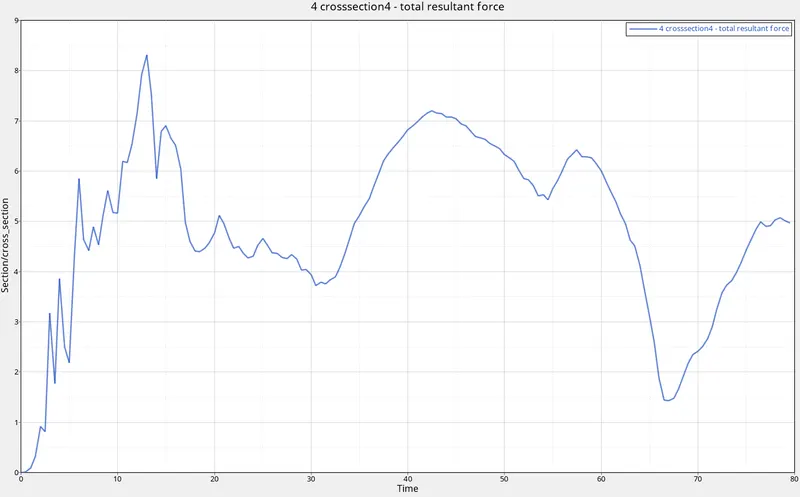
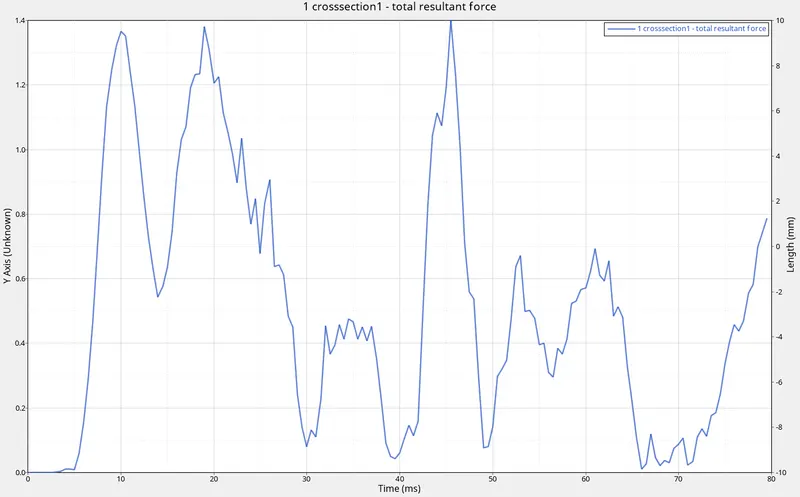
CROSS-SECTIONS:
A - PILLAR:
SHOTGUN:
RAIL:
BUMPER:
ACCELEROMETER:
INTRUSIONS:
OBSERVATION:-
As we seen that the impact in the frontal region deformed the whole body. When the car hitted with the rigid body the forces transfered from frontal region to the B pillar region which compressed the lower surface towards each other. As the cross section distributed the force evenly less deformation is taking place.
As from the graph hourglass energy and contact energy is near a value of zero. As there is no penetrations and intersection of elements.
As we have used penetration check and the elements are fully integrated with perfect parameter.
As there is decrease in kinetic energy and increase in internal energy the total force is linear. Since total energy = kinetic energy+internal energy.
In accelerometer graph, the acceleration oscillate sharply during the crash period as it was maintained constant.
RESULT:-
The given below is the final result from .out file.
| CYCLE | TIME | TIME-STEP | ELEMENT | ERROR | I-ENERGY | K-ENERGY | T K-ENERGY | R EXT-WORK |
MAS.ERR |
| 80000 | 80.00 | 0.1000E-02 | NODE 72586 | -1.0% | 0.3860E+05 | 0.4672E+05 | 3.083 | -924.6 | 0.2961E-01 |
Idiom used:-
Type 7 interface:
Type 7 interface is a node to surface type of contact. It is a general purpose contact and is used to simulate all conditions. It provides a cylindrical gap area around the edges which makes it more accurate. The main advantage of interface type 7 is that the stiffness is not constant and increases with the penetration preventing the node from going through the shell mid-surface.
RIGID WALL:
Rigid walls allow for an easy way to define an interface between a rigid surface and nodes of a deformable body. A rigid wall is defined by a surface type and a group of slave nodes. It is a concrete wall which will be fixed in one place. It is plotted in this case to perform a crash analysis on the body. It can sustain enough load to perform a crash analysis.
Center of gravity (COG):
Center of gravity simply called as COG is a point from which the weight of a body or system may be considered to act. It is very important that the COG should be at the center of the body during crash analysis so that the animation of the crash looks like a real time scenario.
Initial velocity:
Initial velocity is the velocity of the object before the effect of acceleration which causes the change. It is the velocity of the body at which motion starts where time interval = 0
Penetration and Intersection:
A penetration in the model is a condition where a node gets pierced in the element and causes it to fail during the simulation. While intersection in a model is a condition when an element is cutting another element which again causes the elements to fail during the simulation process.
CROSS-SECTIONS:
A section is a set of nodes and a set of elements. More the sections in the body, better the force distribution and less the pointed load. Less the pointed load we have, less the load will be in a particular region which results in less injuries to the occupant.
Accelerometer:
An accelerometer is an instrument or device which is used for measuring the acceleration of a moving body.
Intrusion:
Intrusion results when the energy of the crash exceeds the strength of the vehicle frame, resulting in a violation of the occupant compartment. Injury may then occur either from direct contact with the vehicle structure, or passenger movement as a result of the acceleration imparted to the occupant from the vehicle.