Assignment 5-RADIOSS Interfaces & Study of Effect of Notches Challenge
1. Objective:
- To generate the mesh for the given bumper component with the mesh size of 6 mm.
- To change the parameters for the given crash tube model as various cases.
- To plot the graphs with RWALL forces, contact forces, internal energy (Post-processing) & compare the results.
2. Software used: Altair Hyperworks Desktop 2020
3. User profile:
- Optistruct(For meshing challenge(bumper)).
- Radioss( For the crash tube model).
4. Pre-requisites:
Difference between Hypermesh & Hypercrash:
Hypercrash is a specialized pre-processor for radioss(Only for crash analysis). But whereas, Hypermesh is a generalized pre-processor for so many
solvers. It is designed to give the load cases for the solvers such as optistruct, Abaqus, LS DYNA, Ansys & Radioss.
Note:
- The widely used unit system in industries to develop a deck in the hypercrash is: KN, mm, ms, Kg.
- When a file is exported from the radioss( Hypercrash), It will create another new 0000.rad file. And it will store the previous 0000.rad file as a backup file(as 0000.rad.bak). And also it will create a M00 file(Which stores the data of tree & weld data).
- If that M00 file is deleted, In hypercrash we don't get the connection in our list of tree. But, they will be represented as a type 2 contact interfaces.
- In hyper crash, the engine cards are represented as control cards. And the data history file is seen in T01 file.
Interfaces (or) contact modeling:
The interfaces are defined as a model how the parts interact, when they come into contact with each other. While discussing the interfaces, there
are four types of interfaces widely used. They are:
- Interface penalty method
- Type 7, Variable stiffness, Node to surface contact
- Type 11, Variable stiffness, edge to edge contact
- Type 24, Linear stiffness, node to surface & surface to surface contact
Other type is Type 19, which is the combination of both type 7 & type 11.
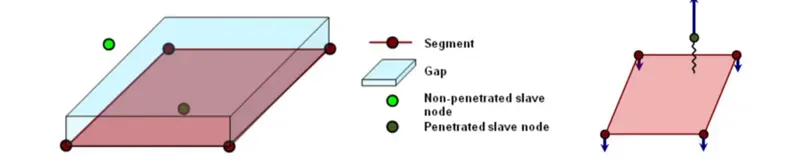
Penalty method:
This method treats the behavior between the slave nodes & master segments(surfaces) as springs that generate the resistive forces as a function
of penetration, as shown in below figure.
Time step is inversly proportional to the stiffness.
There are two types of time steps. They are:
- Nodal time step
- Kinematic time step
But the simulation is governed by the "Kinematic time step".
Type 7:
- This contact is used for node to surface contact.
- It can simulate all types of impact between a set of nodes and a master surface.
- It is non-oriented & slave nodes can belong to the master surface. Hence, the auto-impact is possible(can also be a self contact).
- In this method, the penalty method with variable stiffness can alos be used.
- Resistive forces are applied to keep the slave nodes out of the contact gap.
- Stiffness is non-linear.
- Contact gap can be constant or variable.
Contact gap: It's a gap between the slave nodes & master segment, which indicates when a slave enters in to that gap, which makes the resistive
force come in to picture.
The resistive force vs penetration curve whivh is non-linear for the type 7 contact appears as shown in the below figure.
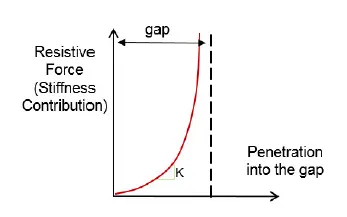
To have a stability, maintain the penetration lower level, which makes the stiffness less.
Important parameters in Type 7:
There are 7 parameters, which are important to be assigned at the time of creating the type 7 contact. They are:
Igap: Which determines the size of the gap is calculated.
Gapmin: To indicate the minimum gap for the activation of interface.
Inacti: Action to take, if initial penetration exists.
Istf: Affects how the stiffness of the stiffness is calculated.
Iform:To indicate the formulation of friction.
Stmin: To indicate, how much minimum stiffness to be used in the interface
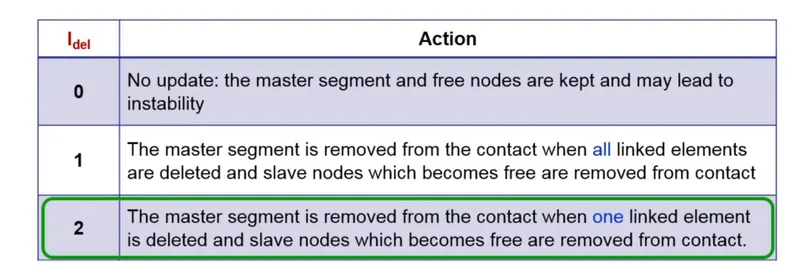
Idel: To indicate, what to do with the slave nodes & master segments if elements failed/deleted that they are attached to.
Igap:
|
Igap |
Gap type |
Description |
|
0 |
Constant gap |
The gap is defined by the Gapmin & is constant for all the contact. (Default) |
|
1 |
Variable gap |
Gap varies according to the characteristics of the impacted master surface & impacting slave node. |
|
3 |
Variable gap |
Variable gap with gap scale factor & mesh-size correction. |
It depends on the Gapmin value (Recommended value for Gapmin is 0.5 mm).
Recommended value: 2 (or) 3
Reason: Majorly, used is 3. Because, gap scale factor & mesh size correction is taken in to account. Beacuse of adding gap scale factor, it puts a
scale factor to the founded gap. In so many cases, there will be so many components with each other(i.e., By default the components will rest on
each other). And if we don't want any reaction force to activate there. The Fscale gsp is going to relax the interface contacts by a bit. Which allows
the slave node to reach up to the gap 0.8. Which reduces some calculations for solver.
Mesh-size correction: If the mesh size is big, then the nodes will be far away from each other. It is very likely, instead of nodes coming in to
contact with the master segment, the edge of the slave node or element comes in to contact with the master. Because, the contact is not well
defined. If the mise size correction factor, it can be overcomed.
Limitation of Type 7: It will consider only the nodes as a slave nodes.
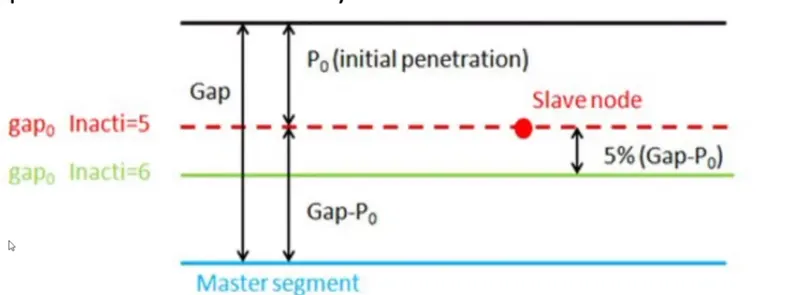
Inacti:
Before discussing about Inacti, the initial penetration should be understood.
Initial penetration: Some nodes even pass behind or past to the master segment or element as shown in the below figure, which causes locking in
simulations, leading to the computational failure.
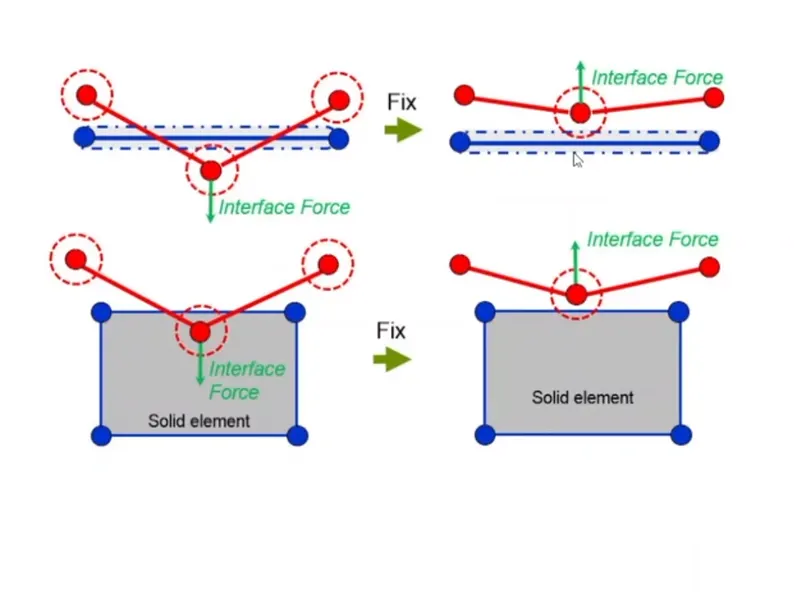
This can be overcomed by using a fix algorithm. After using it would be like, which puts a load on simulation, which leads to the pushing force
going on this node, which results to the energy error in the simulation. There are so many values, and the recommended is 6, as shown in the
below figure.
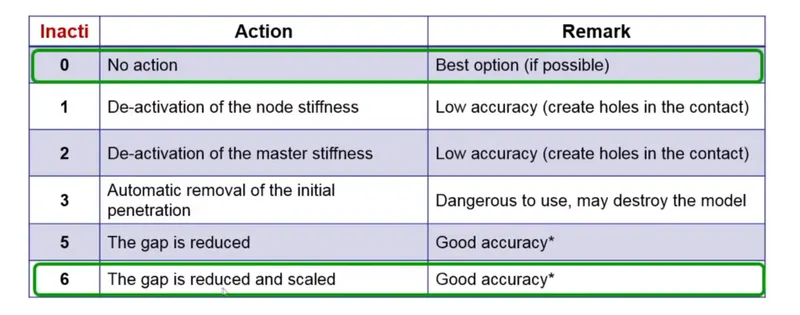
Reason: In case of going for value 5, it will scale down even further to as compared to case 5; the gap is reduced to P0 as shown in below figure.
Becauseof that, In the case of vibrations at the slave side, the contact will get activated & deactivated. Which creates the problem. But where as in
case of 6, it will scale scale down even further too, in such a way likeless than (Gap-p0). Which in dicates the less gap when compared to (Gap-p0)
of inacti 5. This leads a slave node to vibrate. Because of sound wave propogation through it, which reduces the contact calculations & increases
the stabiltity of simulation.
Istf:
The recommendes value is 4. The reason is: Because of mimimum stiffness, the resistive forces that are being applied on the slave node will be
kept to minimum.
k = Max[stmin, min(stmax, Ko)]
where, Ko = min(Km, Ks); Km---> Stiffness of master segment, Ks---> Stiffness of slave nodes.
Example: If a soft component is coming in contact with a hard component, The soft component is going to absorb more resistive force & So that
the stiffness of soft component should be considered. Beccause, the component is soft, it's stiffness is less. The final value for contact stiffness,
can be bounded by lower(Stmin) & Upper limits (Stmax).
Iform:
Iform means "sliding force computation". The recommended value is Iform: 2.
Reason: Because the, sliding forces are computed using the stiffness parameters of the parameters. But whereas in Iform: 1, the sliding forces are
computed using the viscous paramenters.
Idel:
The parameter"Idel" indicates the update for deleted elements due to failure. The recommneded value is 2. The reason is shown in the below
figure.
Finally the recommended values for the parameters are:-
Igap = 2 (or) 3
Gapmin `ge` 0.5 mm
Stmin = 1000 N/m (or) 1 KN/mm
Istf = 4
Inacti = 6
I del = 2
Iform = 2
Advantages & Disadvantages of Type 7 contact:-
Advantages:
- Physically correct representation
- High accuracy for describing the self contact & buckling.
- Best used with shells to shells (or) solids to shells.
Disadvantages:
- Requires more stringent modeling practices.
- Does not tolerate intersections(Slave node passing master segment).
- Time step may reduce due to increasing interface stiffness.
- With respect to the methodology, It will not see the contact due to edges crossing each other at angles.
Type 11 contact:
- It is also known edge to ege contact. In the case of edge crossing, type 11 interface can be added to capture the physics correctly.
- It is defined by identifying the master & slave lines in terms of edges.
- It works similar to type 7 contact interms of penalty formulation, gap definition, search method.
- Slaves will recieve stresses & forces. And the object which is to be analyzed is the "Slave".
- Coarser the mesh, stiffer the structure. Hence the master is typically meshed coarser. So that the slave doesn't penetrate in to the master. That's why the less deformable (or) highly stiffer structure is taken as master & less stiffer as slave.
Note: Type 19 contact is the combination of both type 7 & type 11 contacts.
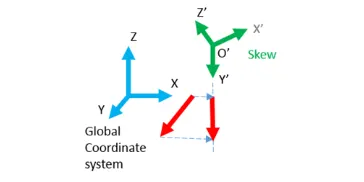
Skew:
- Skew is one type of reference coordinate system which helps in defining local quantities with respect to the global coordinate system.
-
Here the origin of the skew remains in a fixed position even if it is a fixed skew or moving skew.
-
In a moving skew, the orientation of the node of interest is recomputed everytime, with that of the origin coordinates of the skew.
Application:- The example is the study of intrusions in the car through skews. 2 nodes are created and fixed skews are assigned to it. There the
travel of the node is computed from the global coordinates and it is presented In the local coordinates. The overall travel of the node is obtained.
The skew is represented as shown in the below figure.
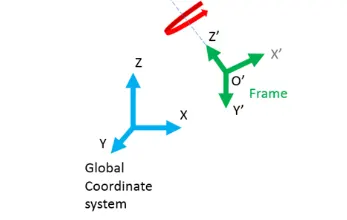
Frame:
-
A frame is a type of reference coordinate system where the quantities defined follow its own origin.
-
Here, unlike the moving skew, the moving frame is attached with the node which is selected as origin.
-
It helps in Calculating the motion of the body relative to the frame defined.
-
Frames are used only in notable options like imposed velocity, imposed displacement, TH/node etc. The frame is shown in the below figure.
Tied contact/INTER/Type 2:-
Definition:- It is defined as an interface that kinematically connects a set of slave nodes to a master surface. It can be used to connect coarse &
fine meshes, Model spot welds, rivets etc.
- Slave literally follows whatever the master is importing over the slave.
- Slave nodes can not have any motion by themselves. And if we put any constraints on the slave node except Type 2; it shows a pop-up like incompatible kinematic conditions.
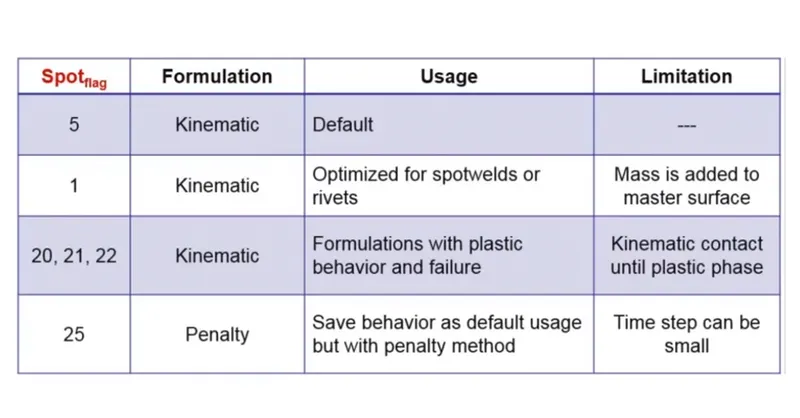
- It allows to use penalty method, which removes the potential incompatible kinematic conditions with the spot flag= 25. But in so many cases, Spot flag 25 is not recommended. Because, it will remove the errors automatiaclly, which may leads to arise new problems. The different formulation for spot flag is shown in the beow figure.
5. Procedure:
Model 1: Meshing the given model(Bumper):-
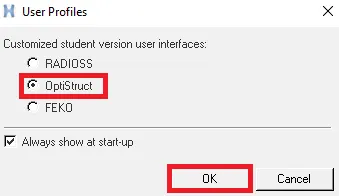
Initally, the user profile should be selected. As this model is to be only meshed. And hence no analysis is required, optistruct is selected is as an
user profile,as shown in fig.
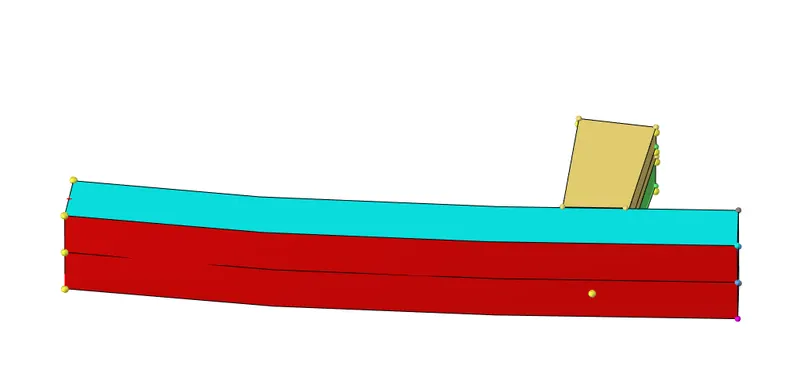
Then the model should be imported in the hyperworks software. After importing the geometry, the given geometry appears in the graphical display
as shown in fig.
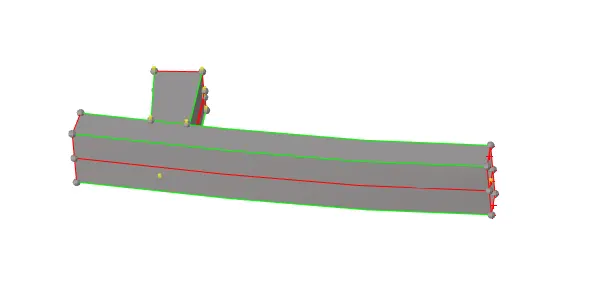
The next step is to view the component by topo. After switching it to topo, the geometry in the graphical display as shown in fig.
Geometry clean up:-
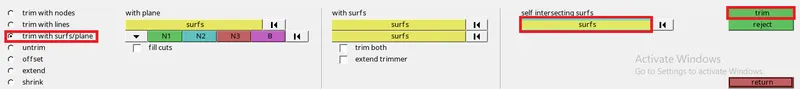
The next step is to clean up the geometry. In the given bumper model, there are some surfaces which are intersecting with each other. So, this
can be overcomed by using the surface edit panel, trim with surfaces option as shown in fig.
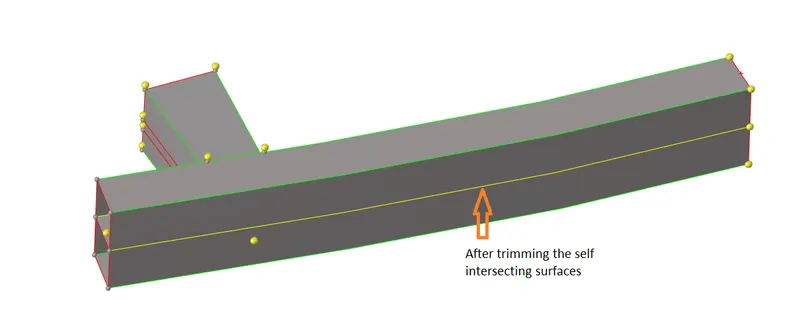
After trimming those self intersecting surfaces, the splitted surfaces will appear with yellow line(Indicating the juntion for three surfaces) as
shownin fig.
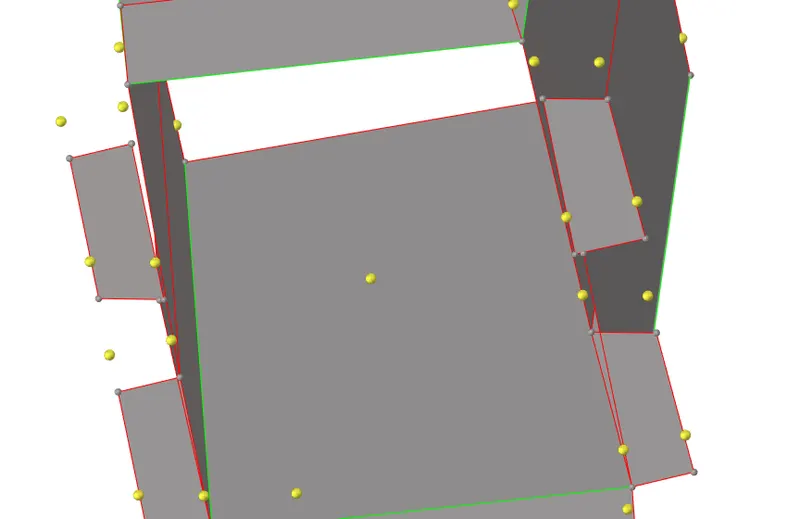
There are some surfaces which are to be connected as shown in fig , by extending them.
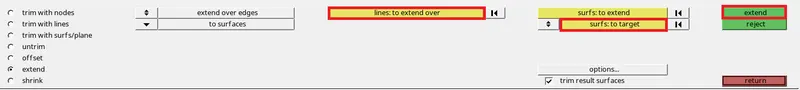
The extend option can be seen in surface edit panel, as shown in fig. In thet the line to extend over and surfaces to target should be selected.
After extending both the surfaces, the surfaces seems to be like self intersecting, as shown in fig.
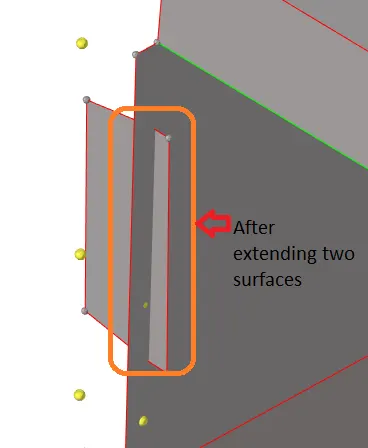
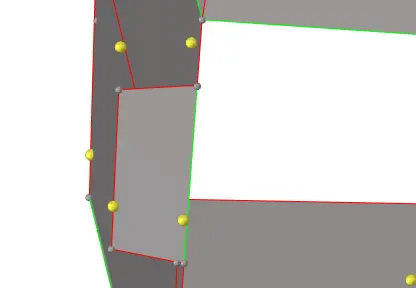
The next step is trim with the self intersecting surfaces. Then the extra surfaces are to be deleted. After deleting this extended surfaces, it appears
as shown in fig.
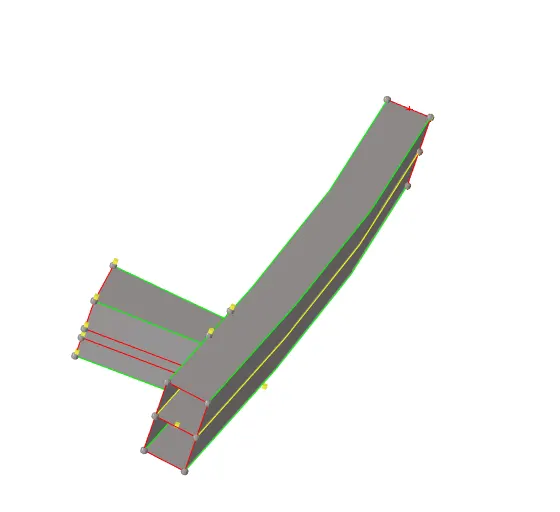
After geometry clean up, the given bumper model appears as shown in fig.
Meshing:-
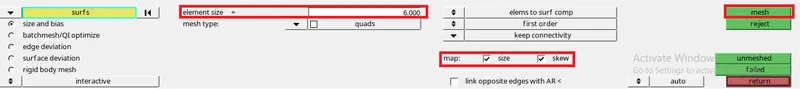
Before meshing, the parameters as shown in fig in the automesh panel should be selected. Anfd then by selecting the surfaces the by clicking
on mesh, mesh will be generated.
After meshing, one surface. the mesh appears as shown in fig.
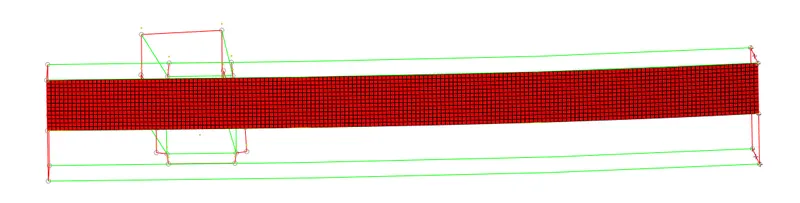
After meshing entire component, it appears as shown in fig.
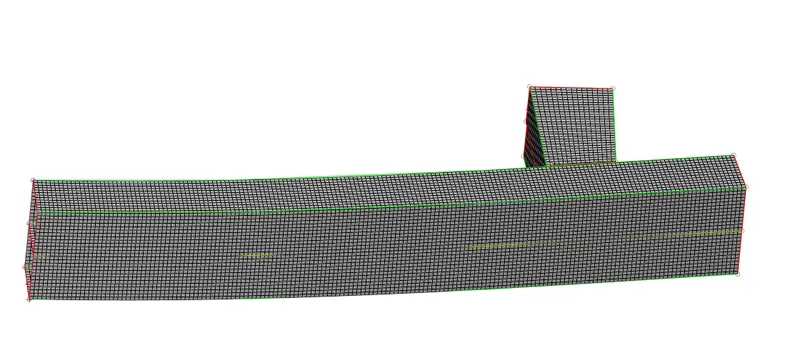
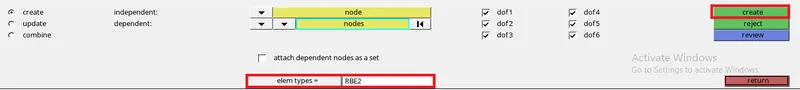
Then the given model(bumper) is connected with the help of rigid (RBE2) elements. Giving the connections depends on user. The process of
selecting the rigid elements are: 1D panel---> Rigids---> selecting the nodes by switching to calculatie nodes. Selecting the nodes to form rbe2
elements is done as shown in fig.
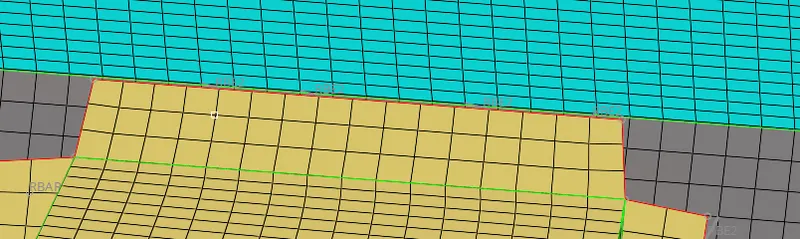
After giving the connections between the sub-components, it appears as shown in fig.
Model 2:(Performing various cases on the given tube model):-
Case 1:(Running the model as it is by defining the TH for interfaces):-
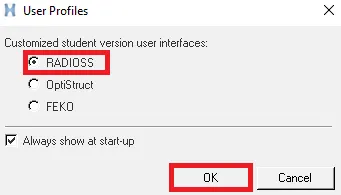
The next model is to analyzed. So, the user profile choosed is "Radioss" as shown in fig.
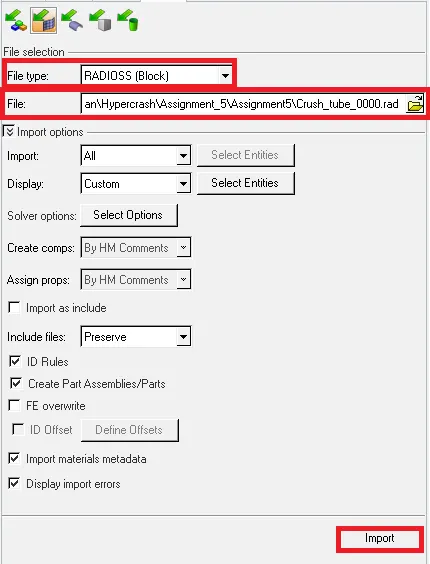
Then the starter rad(0000.rad) file should be imported, from the import solver deck option in the menu bar, as shown in fig.
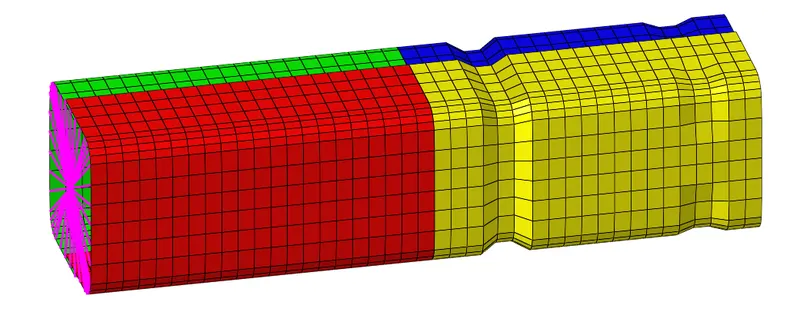
After importing the file, the given model in the graphical display appears as shown in fig.
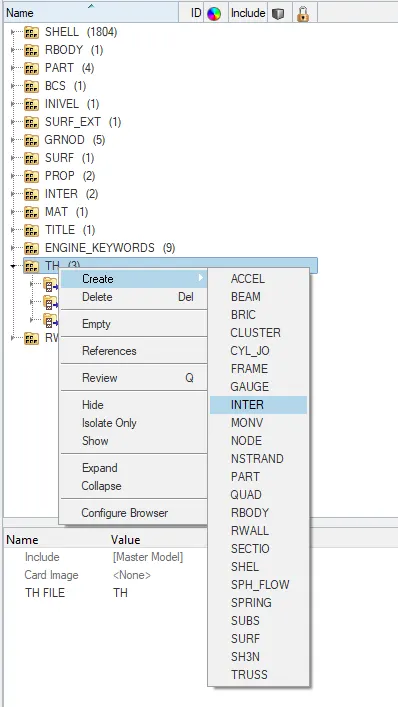
As mentioned in the question , the output should be requested for interfaces or contact forces. So, the interfaces should be added in the TH. So,
the TH is created for the interfaces as shown in fig.
After assigninig the TH for interface, it appears as shown in fig.
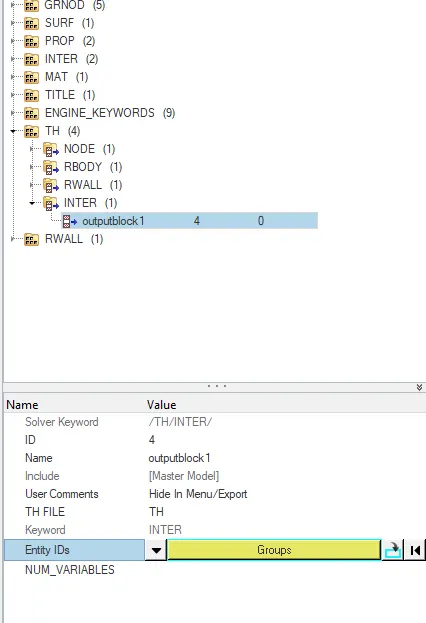
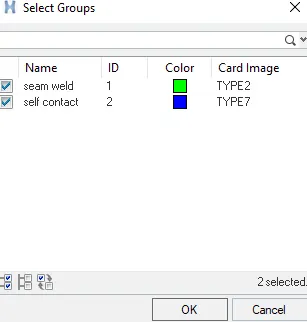
Then the already created interfaces(represented in the form of groups) are assigned to the created TH, as shown in fig.
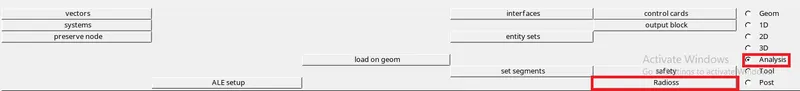
Then the simulation is to be runned. The process of running the simulation is: Analysis panel---> Radioss. As shown in fig.
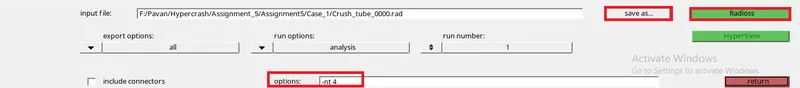
Then the file should be saved in any location, Where all the animation files, time history files will be stored. And the "-nt 4" option is used to
assign the task for the 4 cores in the cpu as shownin fig. WHich will speed up the simulation.
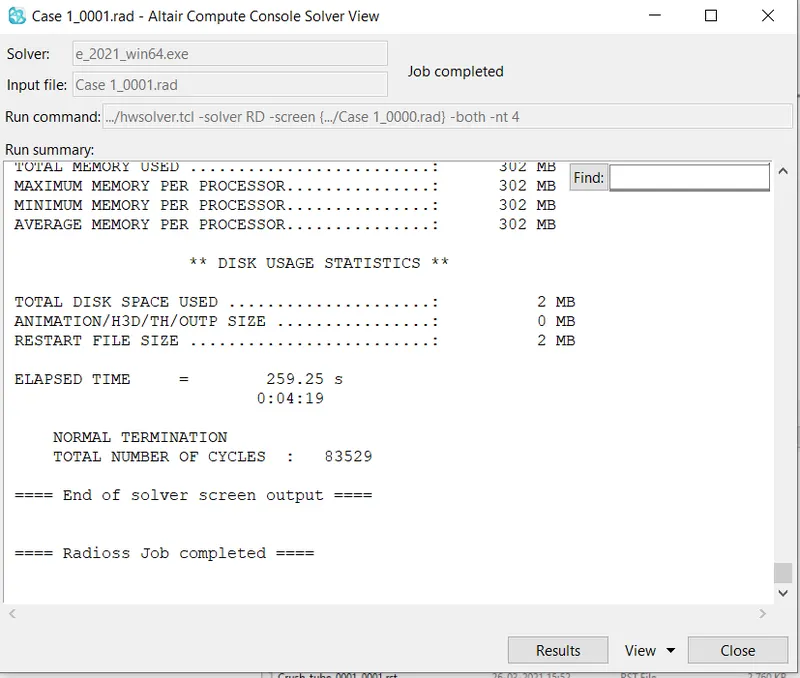
Then by clicking on "Radioss", the simulation wil be runned. After some time, if the simulation is done properly and completed, it shows a pop-up
as seen in fig. Which indicates that, job is completed.
The created animation files in the specified location appears.
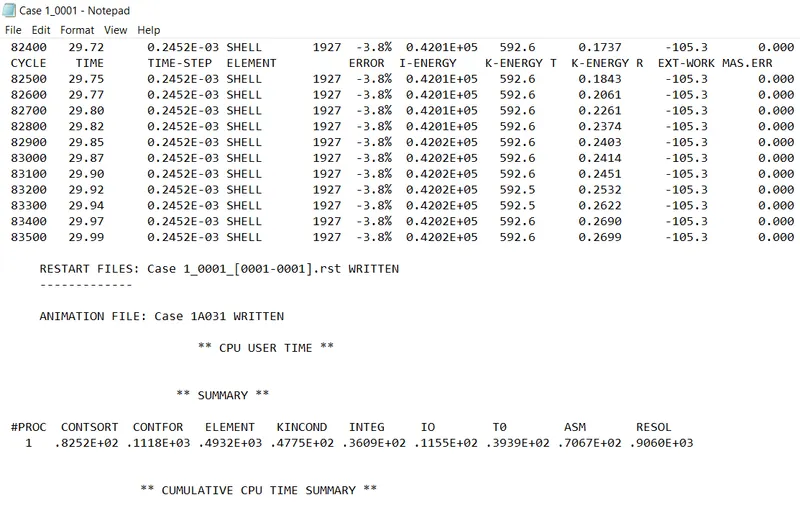
Then the 0001.out file is opened, to view the obatined results in the form of values. The obtained results for the last cycle is shown in fig 5.26.
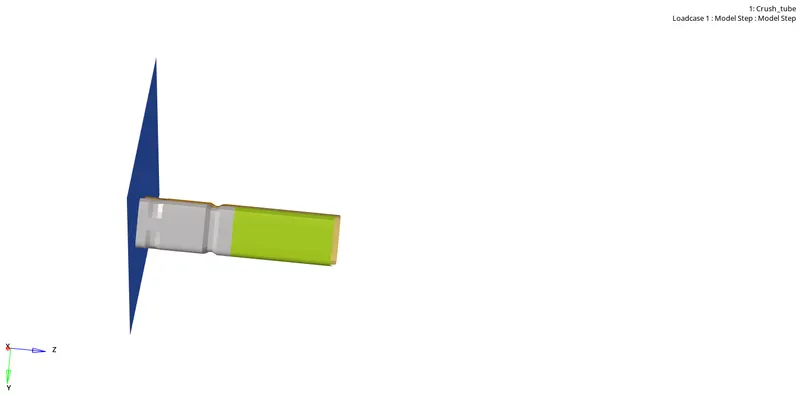
Then the next step is to simulate the model with respect to the obtained files. For doing that, the h3d file(combination of all animation files) is
imported in the another window. After importing the h3d file, the given crash tube model with the rigid wall appears in the graphical display as
shown in fig.
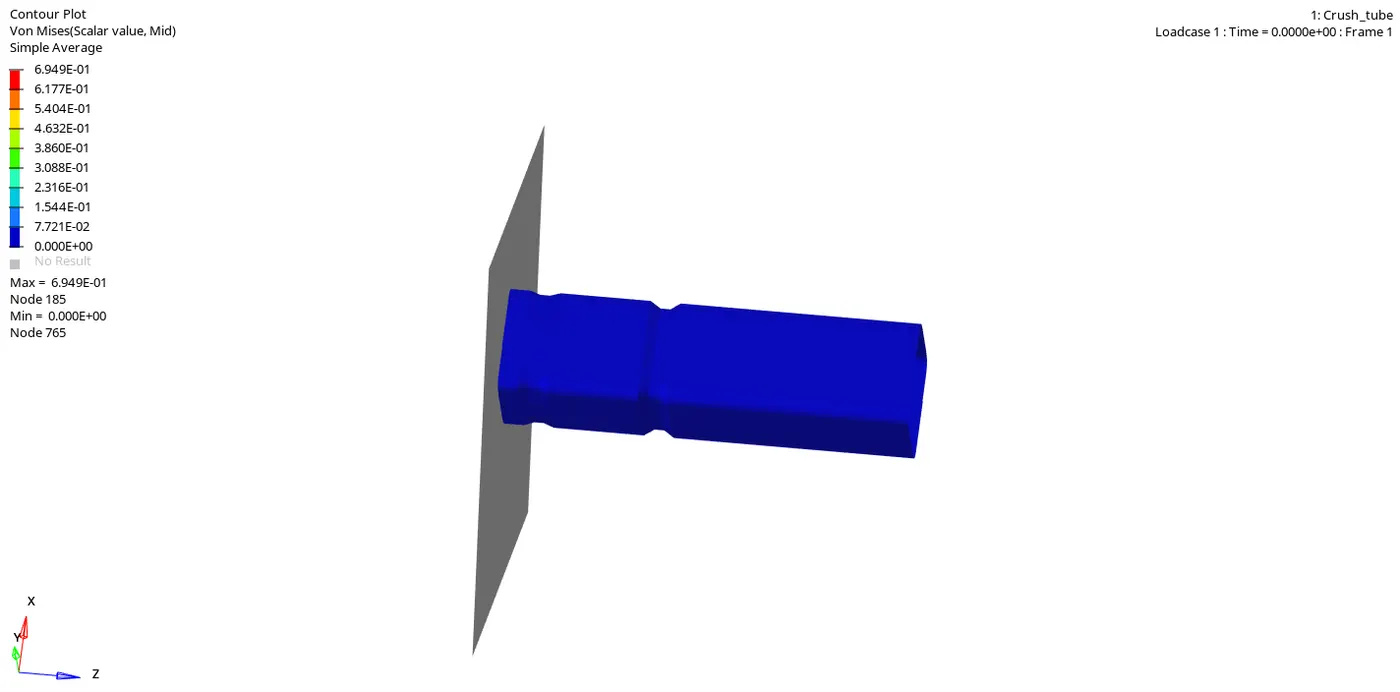
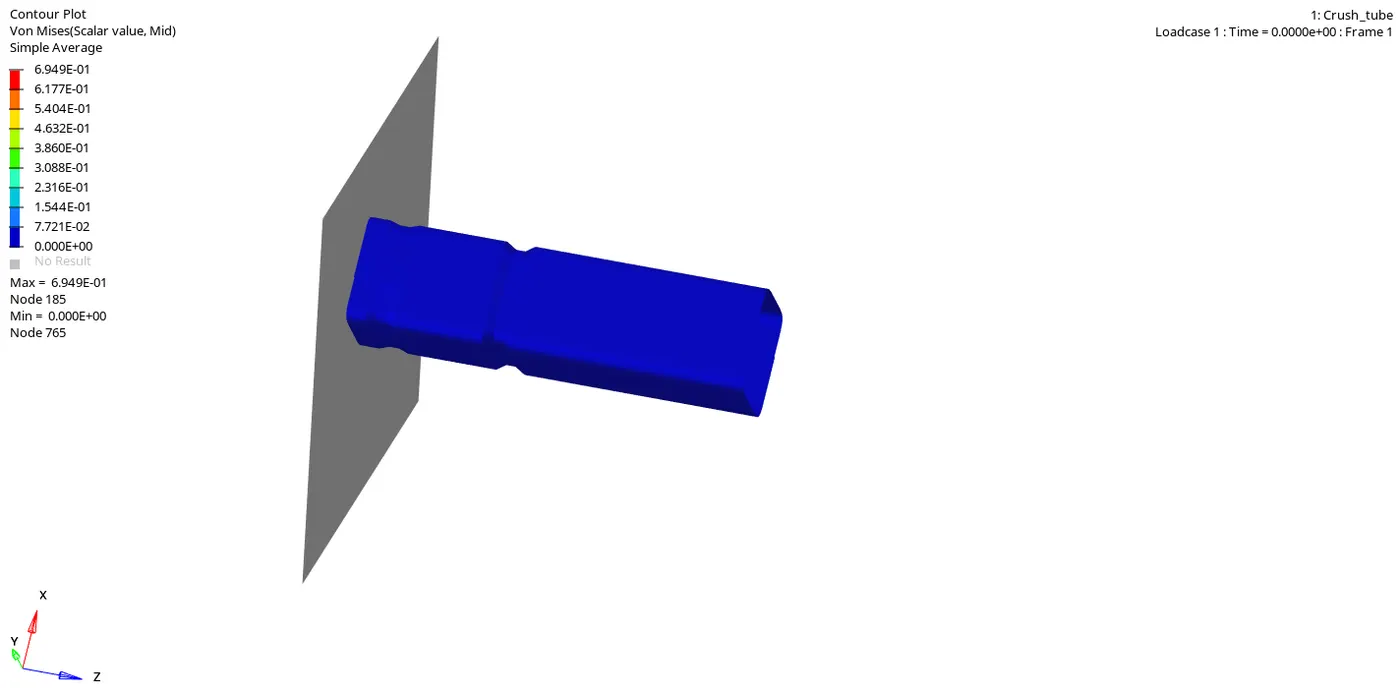
Then the contour panel is opened and the parameters such as result type, selecting the components & averaging method are selected. Then it is
applied. The obtained simmulation in terms of von-mises, appears as shown in the below animation.
Post-processing:
The next step is to do the post-processing(i.e., obtaining the graphs with the help of obtained results). For doing that, the T01 file should be
imported in the other window. After importing the parameters should be selected to obtain the graphs. Initially, the rigid wall force graph is
obtained. So, the parameters should be selected as shown in fig.
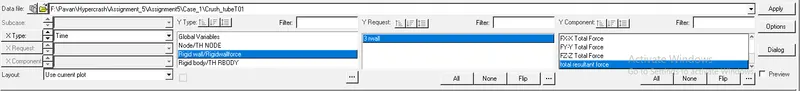
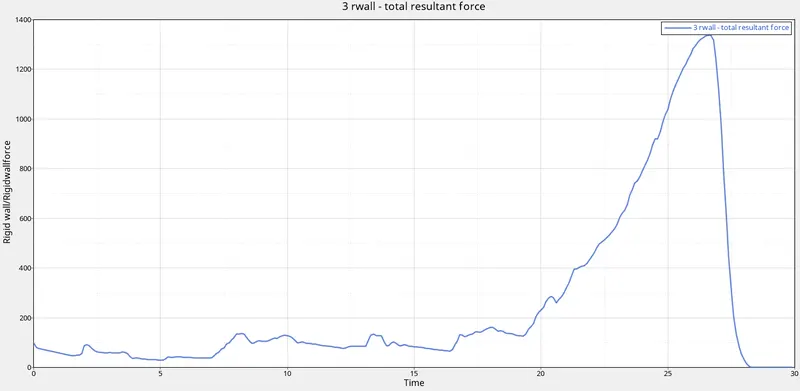
The obtained rigid wall force graph appears as shown in fig. It goes on increasing. Because, the forces with in the elements starts increasing at the
beginning, when the velocity is given. And when the entire tube collides with the rigid wall, the rigid wall forces reaches to the peak value. Due to
this the contact energy increases, which results the increase in rigid wall forces.
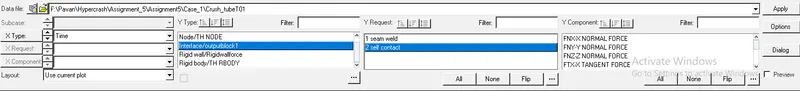
The next graph to be obtained is, contact forces graph. Some parameters should be selected as shown in fig.To obtain the graph.
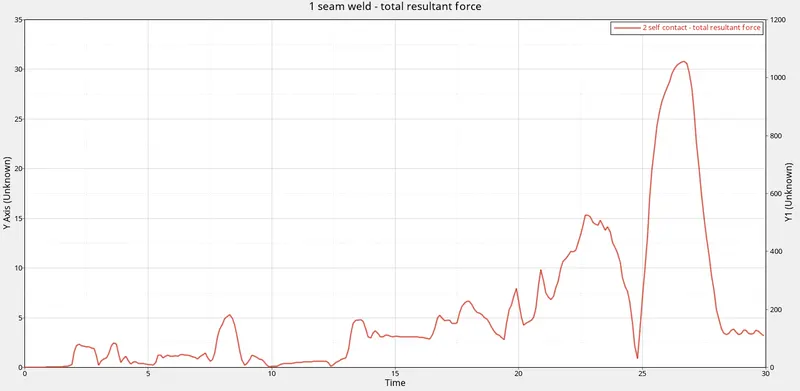
The obtained contact force graph appears as shown in fig. Initially, there will be no contact forces at the beginning. So, the curve starts from
origin. And there will be some fluctuations in the curve at the middle. Due to fluctuation of contacts with in the elements. And then it reaches to
the peak value as shown in fig, when the entire model undergoes collision, there will be more contact with in the elements & even with rigid
wall.
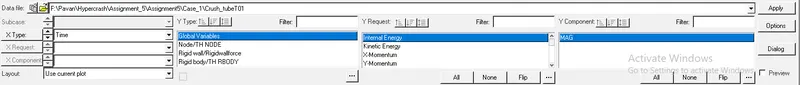
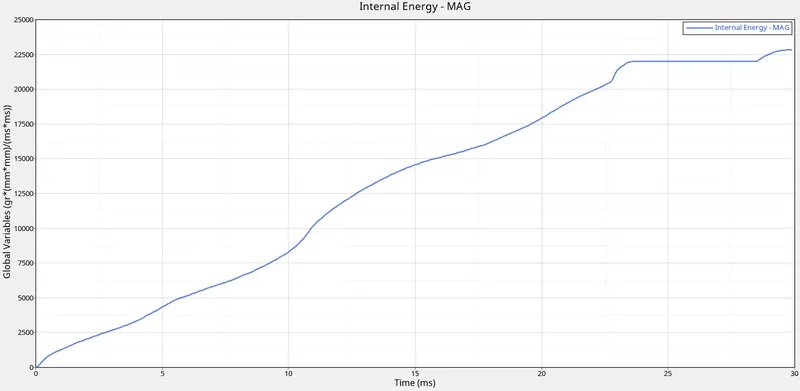
Then the final graph to be obtained is internal energy graph. The parameters to be selected inorder to obtain the graph are as shown in fig.
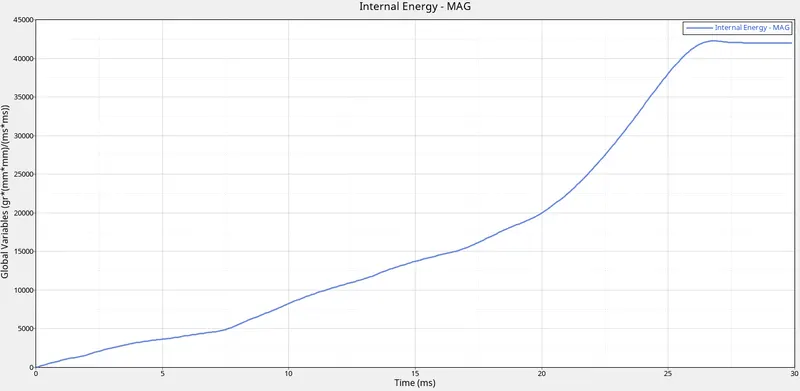
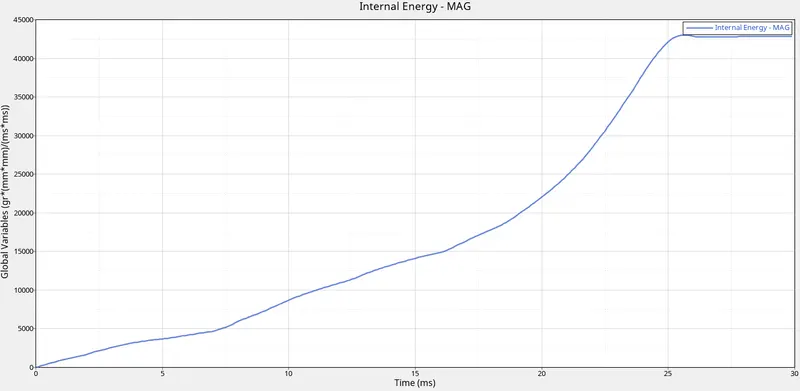
The obtained internal energy graph appears as shown in fig. The internal energy increases to the peak value at the end of the collision. And
becomes constant.
Case 2:(Changing the inacti value to 6):-
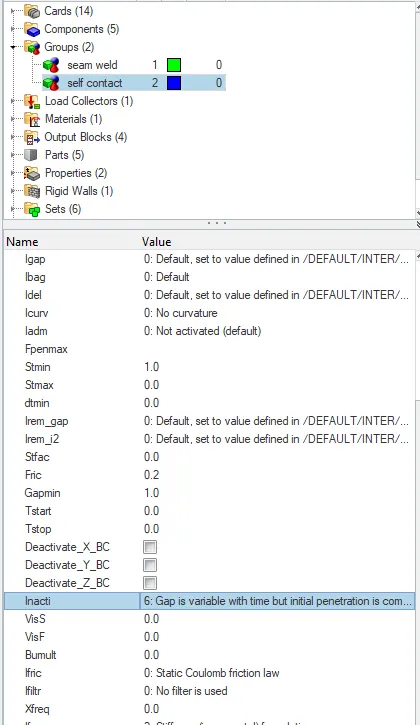
In this case, In the interfaces card the inacti value is changed to 6, as shown in fig 5.34. Then, the simulation is runned. With this, the gap will be
scaled further in between the slave & master.
Then the obtained simulation from h3d file in terms of von-mises stress appears as shown in the below animation.
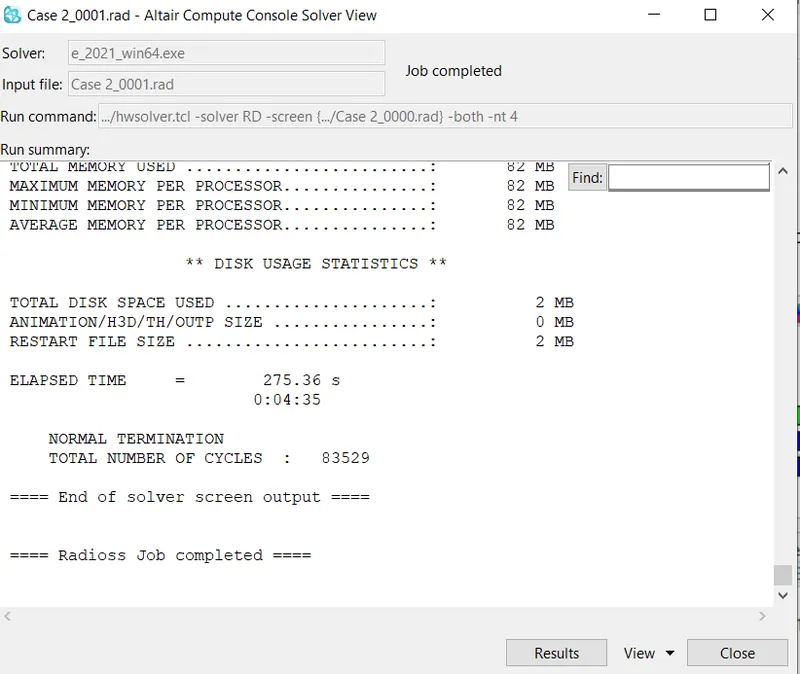
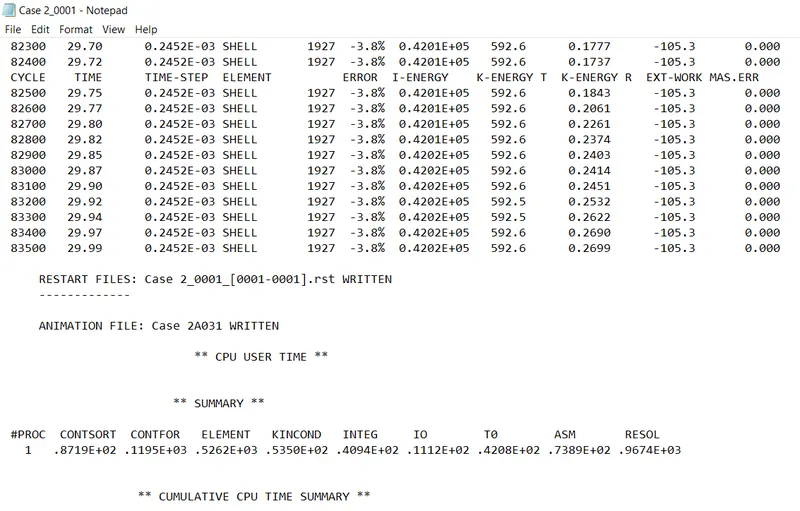
After running the simulation, the obtained 0001.out file is opened. To view the obatined results in the form of values. The obtained results for the
last cycle is shown in fig.
Post-processing:
Then the To1 file is opened in another window. Inorder to view the results in terms of graphs. The obtained rigid wall force graph appears as
shown in fig. It goes on increasing. Because, the forces with in the elements starts increasing at the beginning, when the velocity is given.
And when the entire tube collides with the rigid wall, the rigid wall forces reaches to the peak value. Due to this the contact energy increases,
which results the increase in rigid wall forces. It will be some what similar to case 1.
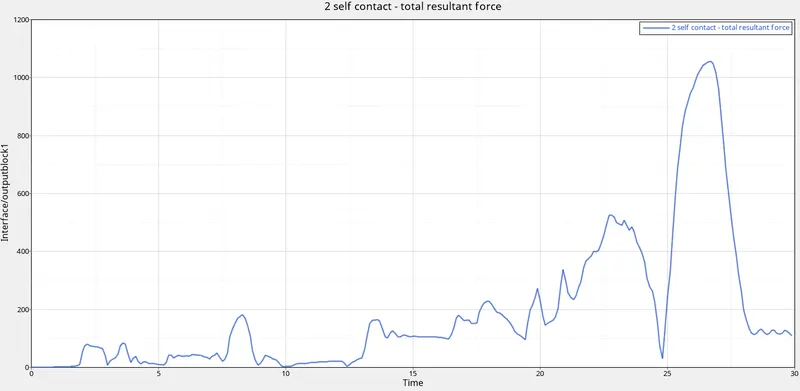
Then the graph to be obtained is, contact forces. The obtained contact force graph appears as shown in fig. Initially, there will be no contact forces
at the beginning. So, the curve starts from origin. And there will be some fluctuations in the curve at the middle. Due to fluctuation of contacts
with in the elements. And then it reaches to the peak value as shown in fig, when the entire model undergoes collision, there will be more contact
with in the elements & even with rigid wall. It will aslo be some what similar as in case 1. Becuase, there are no initial penetrations.
Then the internal graph is obtained. The obtained internal energy graph appears as shown in fig. The internal energy increases to the peak
value at the end of the collision. And becomes constant. As there is no change in the above graphs, there is change in internal energy graph also.
Case 3:(Creating the type 11 contact):-
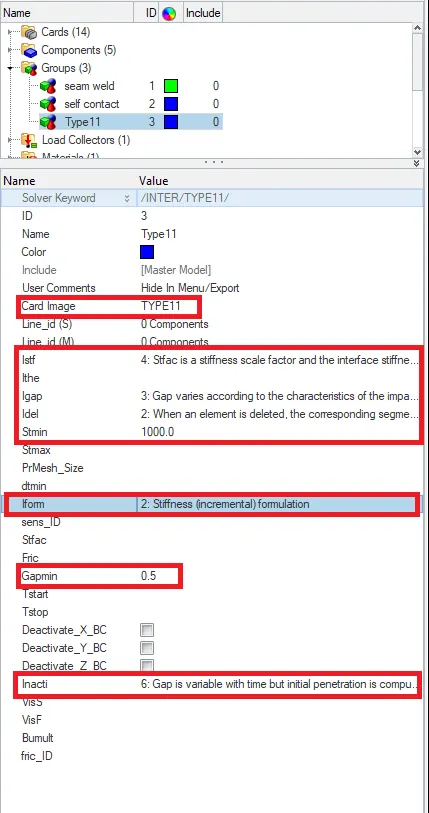
In this case, the new contact named "Type 11". In this contact, some parameters are to be entered, as shown in fig. In order to get, the better
results.
While defining the slaves & master, ensure that all elements should be as a slave & as well as master, as shown in fig.
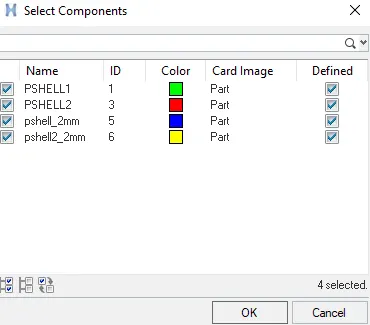
fig 5.40
After creating the contact, then for obtaining the output a TH is requested for that contact. While defining the TH for that contact, the interfaces should be entered, as shownin fig 5.41.
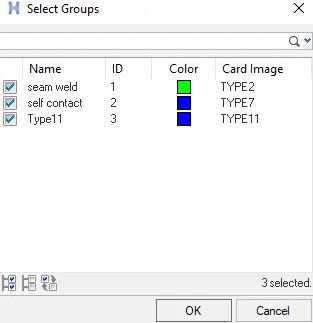
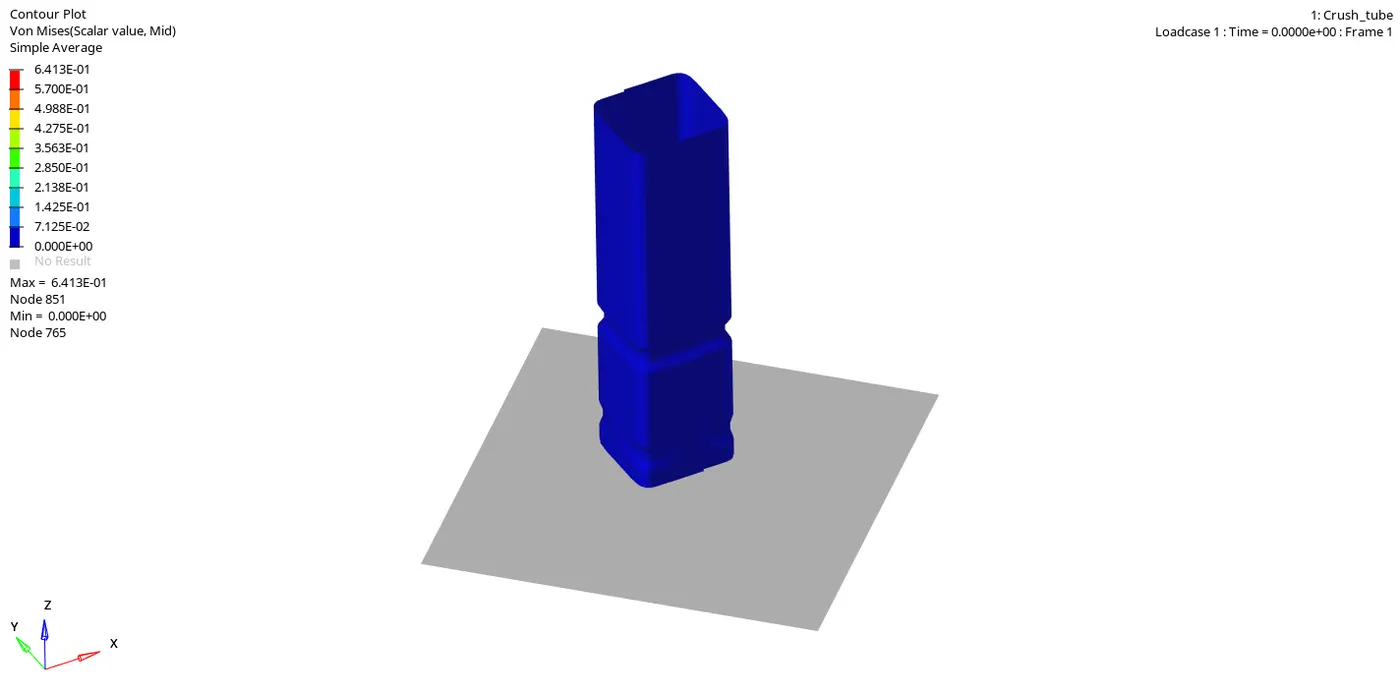
The next step is to run the simulation. After running the simulation, the obtained simulation from h3d file in terms of von-mises stress appears as
shown in the below animation.
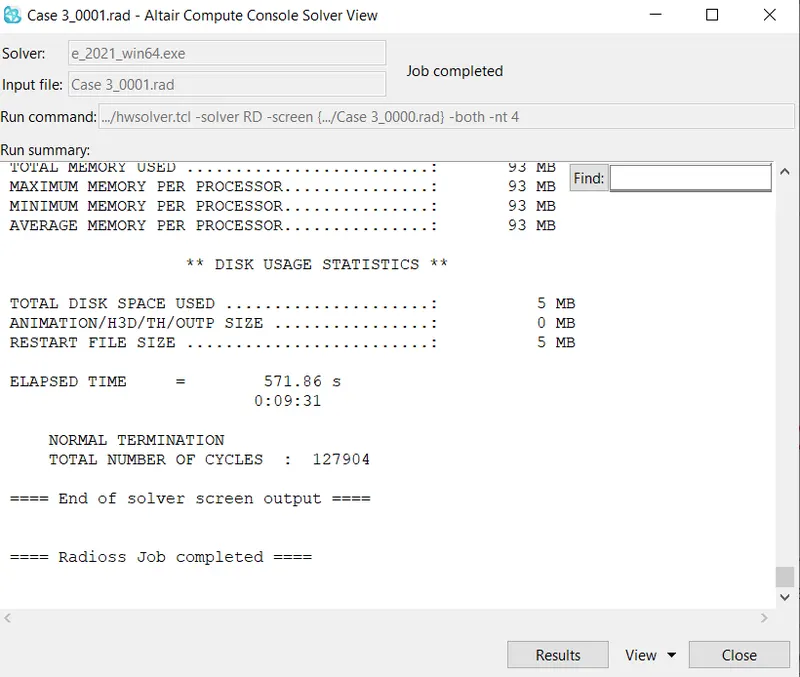
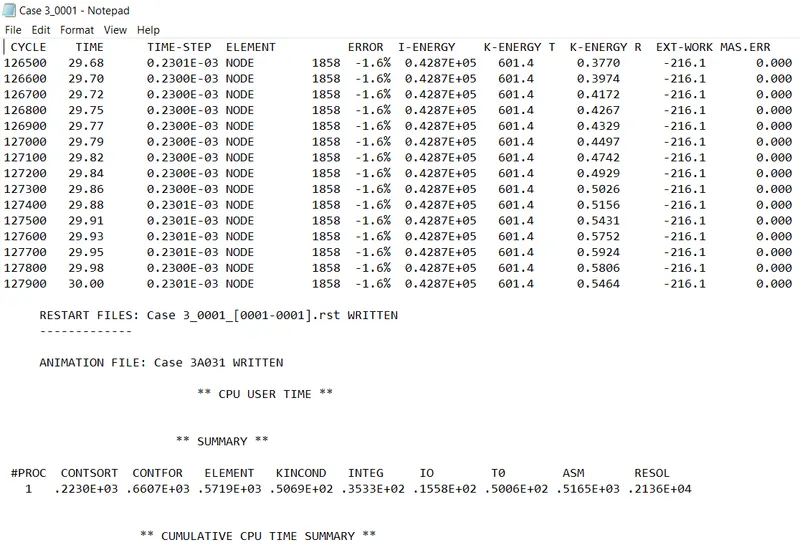
After running the simulation, the obtained 0001.out file is opened. To view the obatined results in the form of values. The obtained results for the
last cycle is shown in fig.
Post-processing:
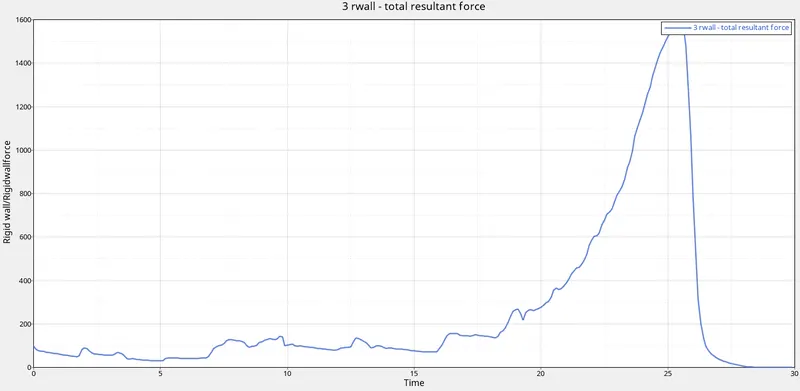
Then the post-processing is done. The obtained rigid wall force appears as shown in fig. Frome that graph, The thing noticed is the rigid wall force
value is increased (With in the range 1400-1600), when compared to the previous cases. The reason is, Type 11 contact is also defined along with
the pre-defined type 7 contact. So, the contact forces with respect to the edge to edge contacts are also seen.
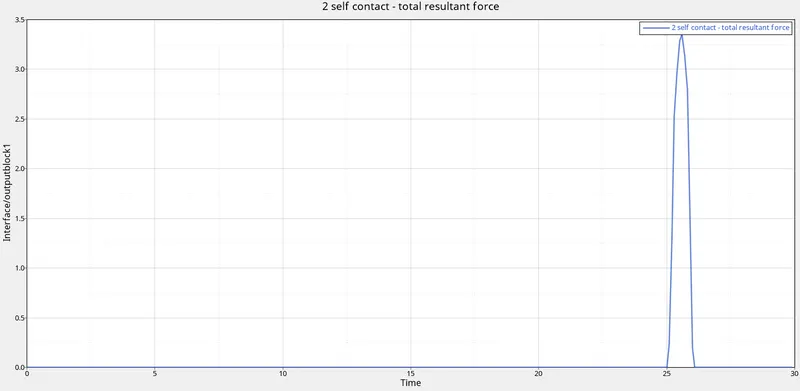
The next graph obtained is, contact forces with respect to type 7 contact. The obtained contact forces graph for type 7 contact is shown in fig. The
contact forces will be constant and reaches to the peak value, when all of a sudden the nodes comes in contact with the master elements with in
the tube model. And the graph falls back, when the model attains reaction against the rigid wall.
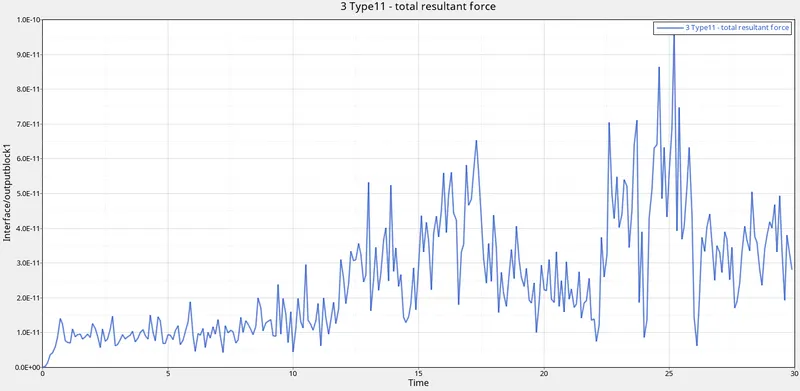
Then a graph is obtained for the type 11 contact. The obtained graph for type 11 contact is shown in fig. As this graph depicts about the edge to
edge contact. There will be the fluctuations, as the edges of the elements comes in to contact gradually. ANd reahes to a peak value, after the
entire collision. And decreases thereby due to the little expansion of the model after hitting the rigid wall.
Then a graph is obtained for the internal energy, which appears as shown in fig. There will be no change in the kinetic energy.
Case 4:(Running the given model by removing the notches & boundary condition on the rigid body node):-
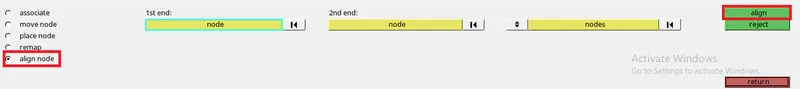
In this case, the notches are removed & the pre-defined boundary conditions are also removed. For removing the notches, the option used is
"Align node" as shown in fig. The key-board shortcut for that is "Shift+F8".
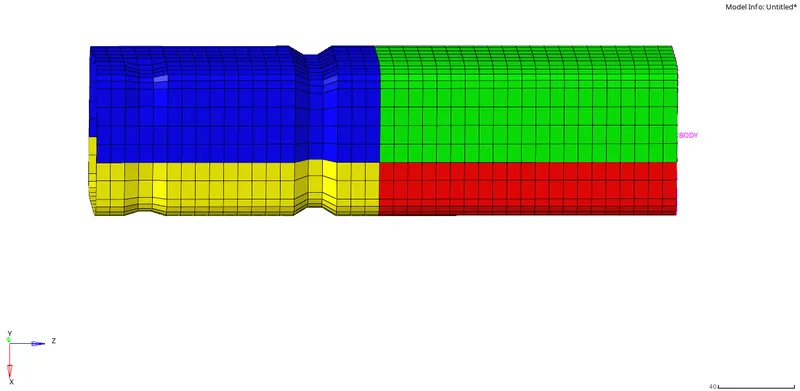
Before removing the notches, the given tube model seems to be as shown in fig.
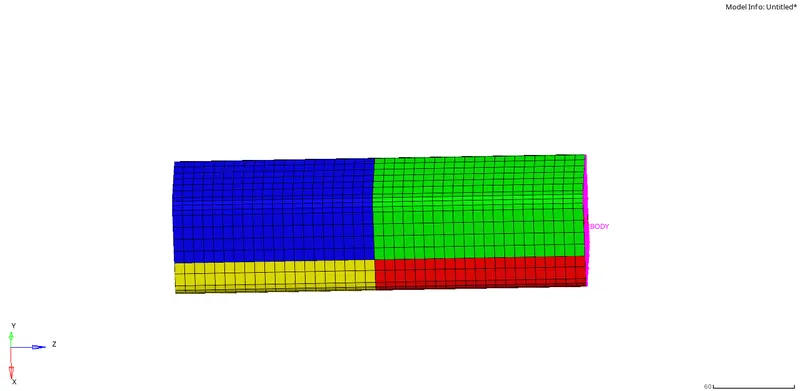
After removing the notches, the model appears as shown in fig below.
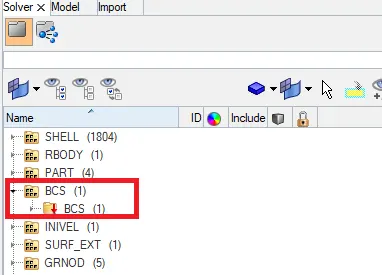
The next step is to remove the boundary condition on rigid body node. Which is present in the tab bar in the solver browser, as shown in fig.
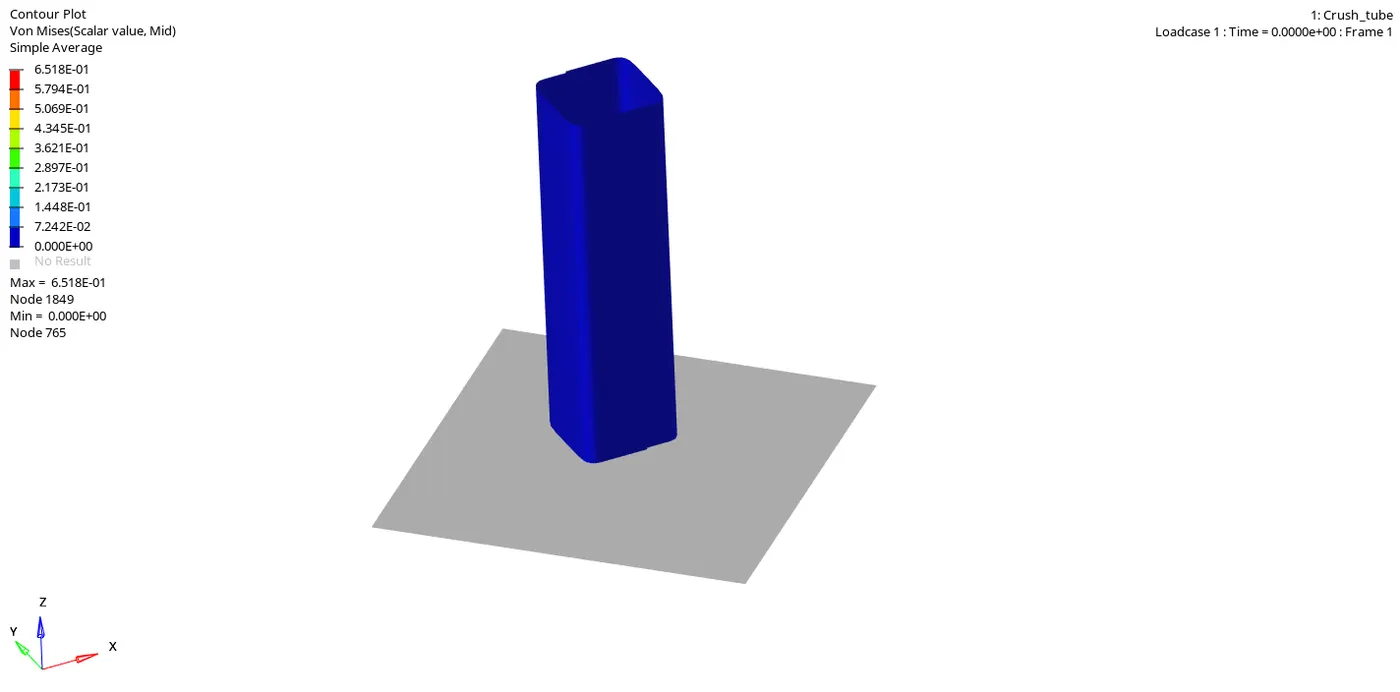
Then the simulation is runned. After running the simulation, the obtained h3d file is imported in other window. To view the simulation. The
obtained simulation appears as shown in the below animation.
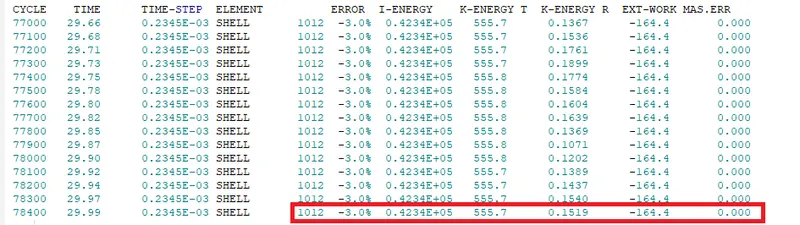
Then the obtained 0001.out file is opened. To view the obatined results in the form of values. The obtained results for the last cycle is shown in fig.
Post-processing:
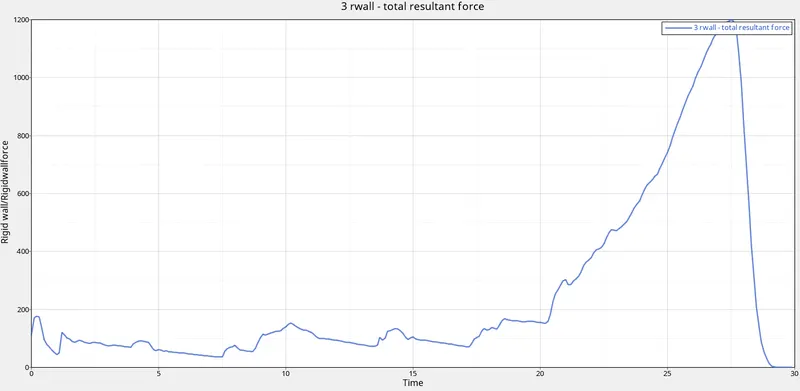
The next step is to go for post processing. The obtained rigid wall graph appears as shown in fig. In this case the rigid wall force is reduced when
compared to the previous cases. The maximum values lies in the range of 1000-1200 N. This is due to the removal of notches. As the notches are
removed, there will be a change in element shape at the notches, which results in the reduction of rigid wall forces.
Then the obtained contact force graph appears as shown in fig. There is a reduce in the contact forces. Because, the notches & boundary
conditions are removed. So, the energy will be observed by the elements will be faster when compared to the previous cases with the notches.
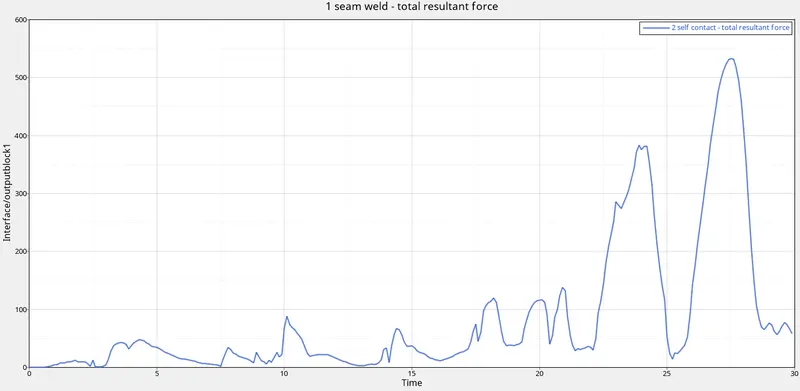
The obtained internal energy graph appears as shown in fig. There will be no change in the internal energy, when compared to the other cases.
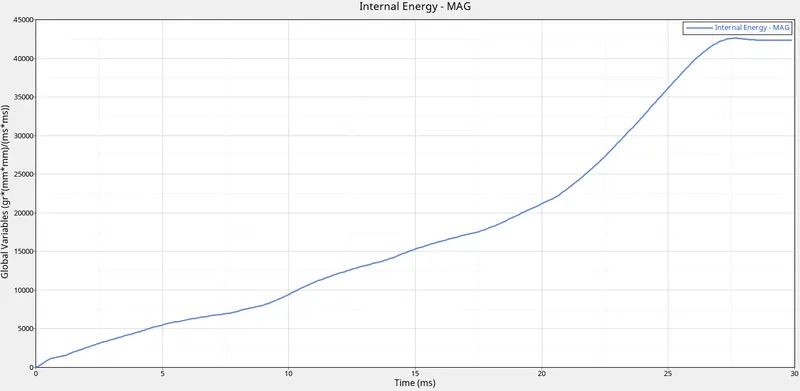
Case 5:(Running the simulation by creating the notche at the middle):-
In this case, a notch is created at the middle of the tube. This is done by using "Translate" option, as shown in fig. The magnitude is selected as
2.5 mm to translate. Because, it is calculated by using the pythagorous theorem in the model for the previous case. And the model with case 4 is
choosed to open here. Because, it doesn't have notches.
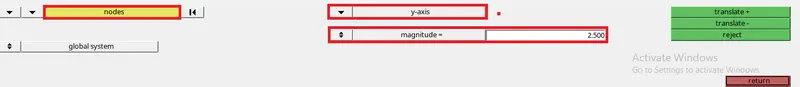
After translation of nodes at the middle, the tube model appears as hown in fig.
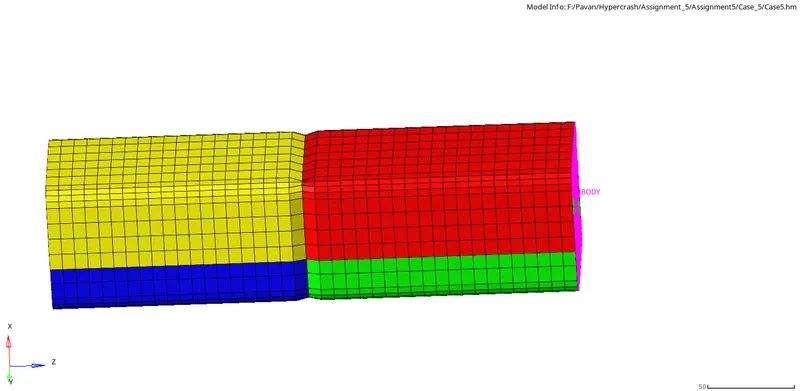
Then the simulation is runned. After running the simulation, the obtained h3d file is imported in other window. To view the simulation. The
obtained simulation appears as shown in the below animation.
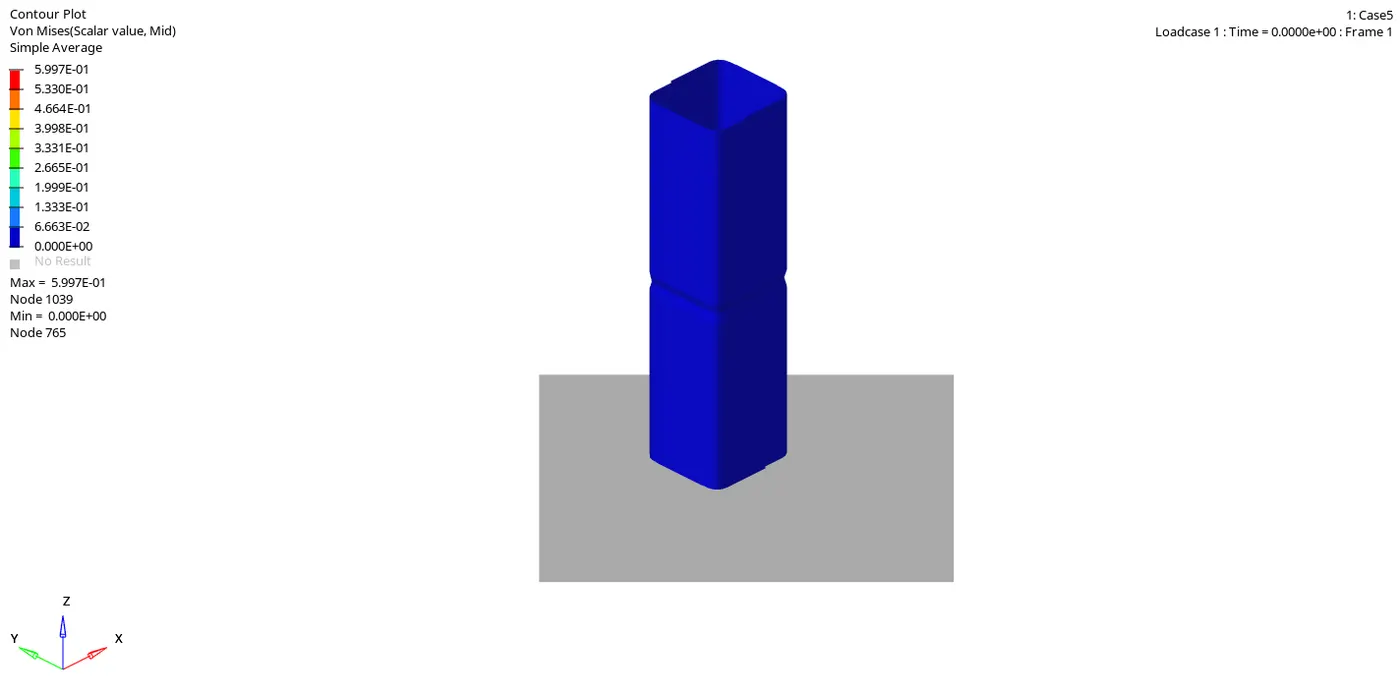
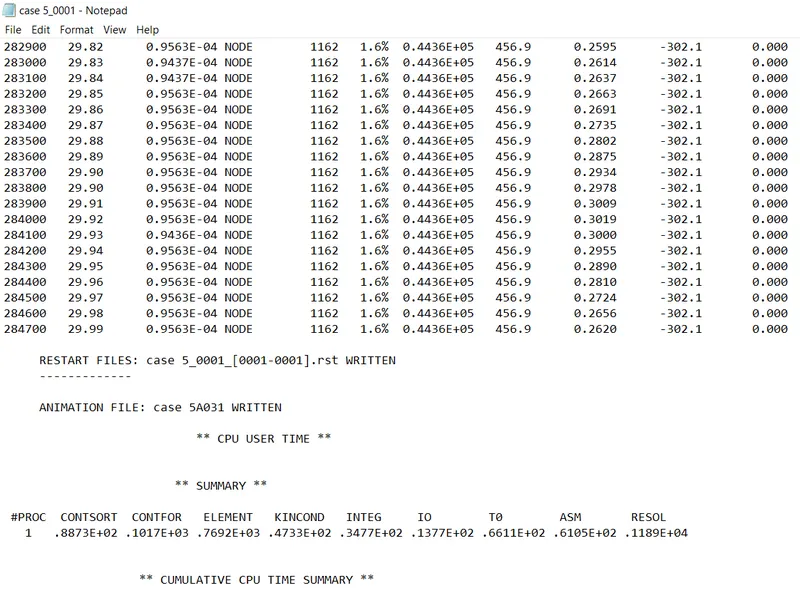
Then the obtained 0001.out file is opened. To view the obatined results in the form of values. The obtained results for the last cycle is shown in fig.
Post-processing:
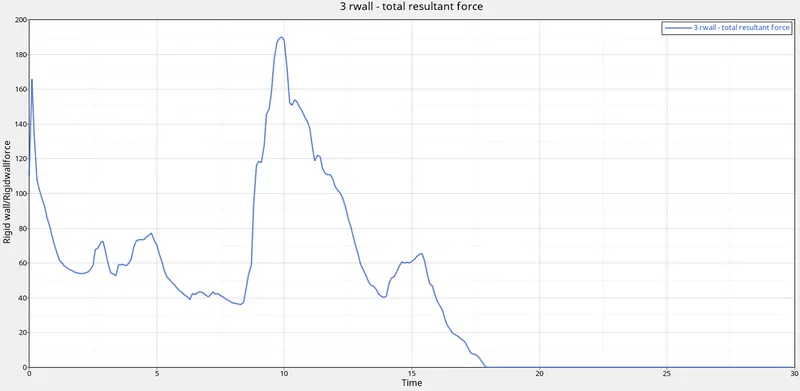
The next step is to go for post processing. The obtained rigid wall graph appears as shown in fig. Here the rigid wall force will reaches to peak
value at the beginning. Because, there will be more contact force at the beginning. Because, the notch is at the center. There will be a collision till
the notch first. And the model moves back and the elements after the notch will be collided with the rigid wall. So, there will be a rise in the graph
again.
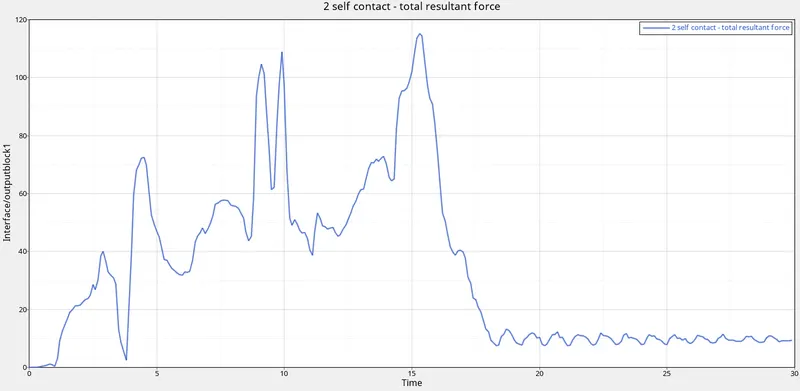
Then the obtained contact force graph appears as shown in fig.The interface force is less when compared to the other cases. Because, the entire
model collides with the rigid wall two times(i.e., For first time the elements before the notch & The second one is for the elements after the notch).
So, there will be fluctuations in the curve.
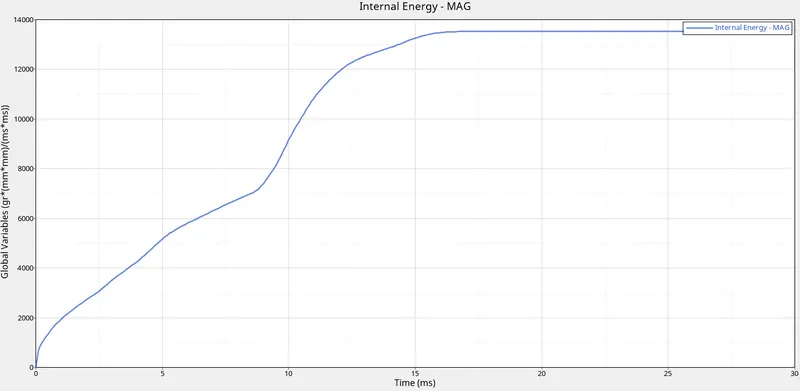
The obtained graph for internal energy appears as shown in fig. There will be a change in the internal energy. Because, As there is a notch only at
the middle. The elements will be impacted without any deviation, as of in the previous cases in which the notch is present at the beginning. There
will be a drop in the internal energy at the middle as shown in fig. Due to the model moves back after hitting the rigid wall. And there will be a rise
again. Because, the model again hits with the elements after notch.
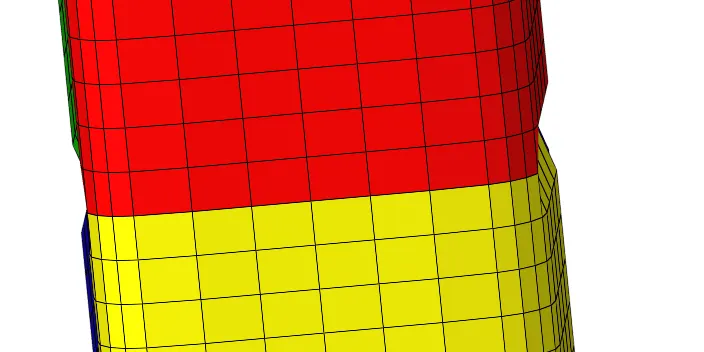
Case 6:(Running the simulation by Creating a new notch with nodes only from opposing 2 faces):-
In this case, the new notch is created at the middle again. But only at the two opposite faces, as shown in fig. Again the model stored in case 4 is
opened.
Then the simulation is runned. After running the simulation, the obtained h3d file is imported in other window. To view the simulation. The
obtained simulation appears as shown in the below animation.
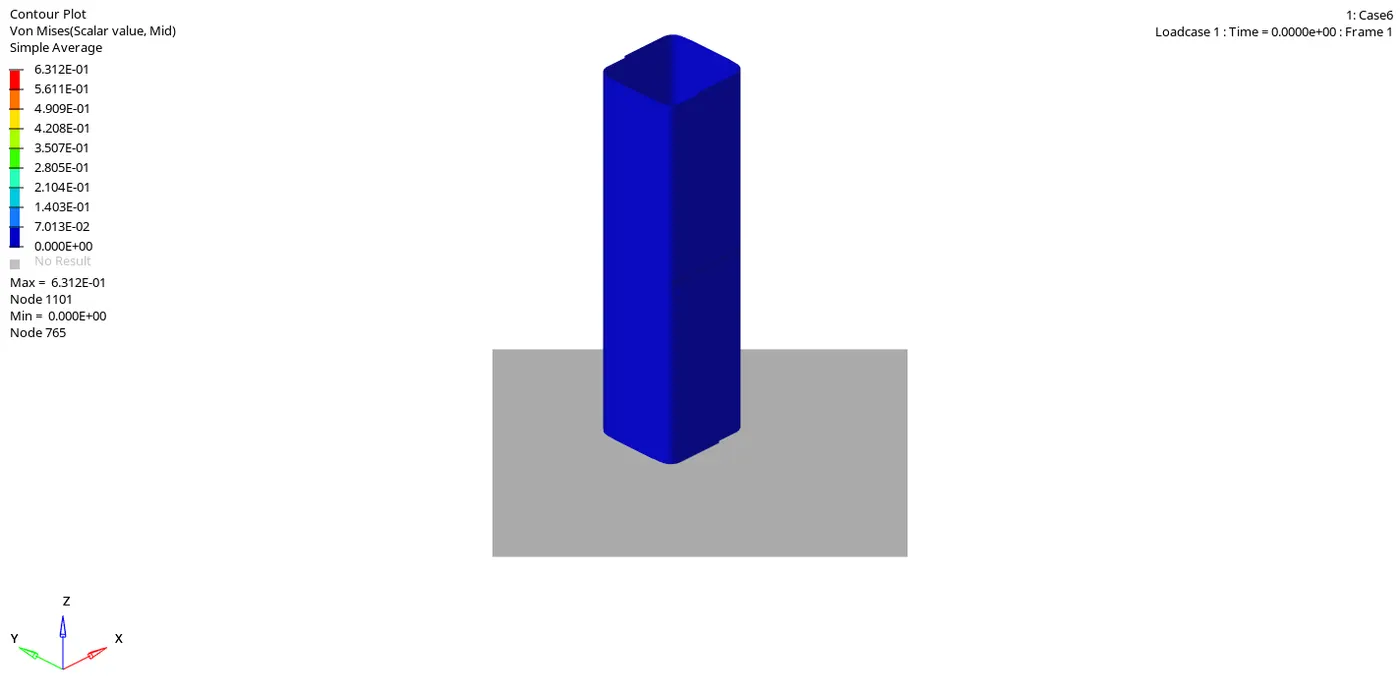
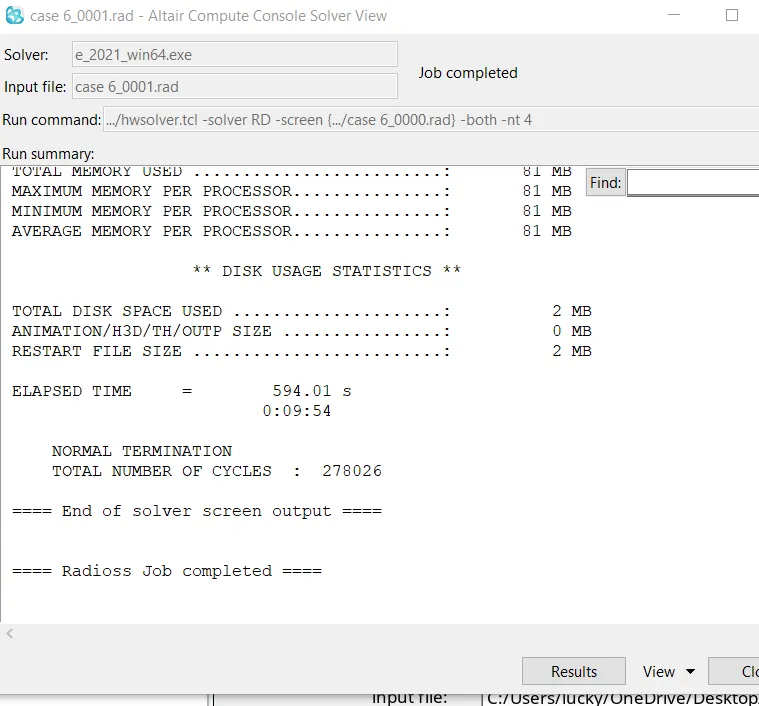
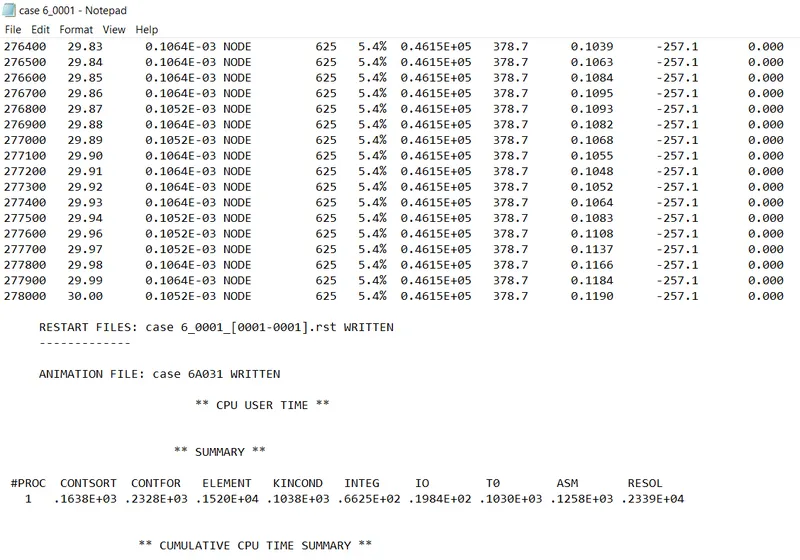
Then the obtained 0001.out file is opened. To view the obatined results in the form of values. The obtained results for the last cycle is shown in fig.
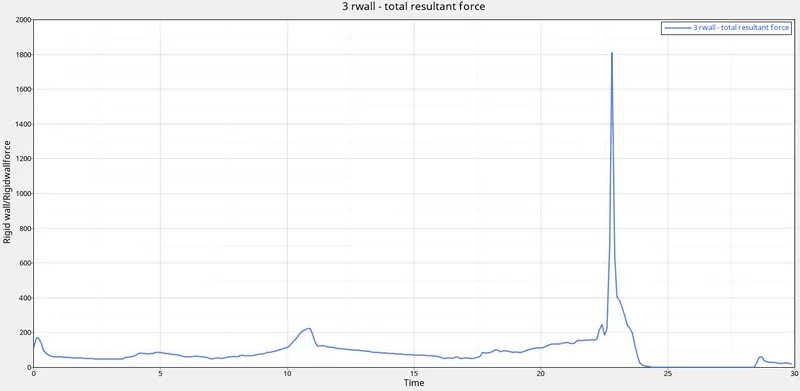
The obtained rigid wall force graph appears as shown in fig.There will be a rise in rigid wall force when the entire collision takes place. The area
with the notch will be experiencing more stress.
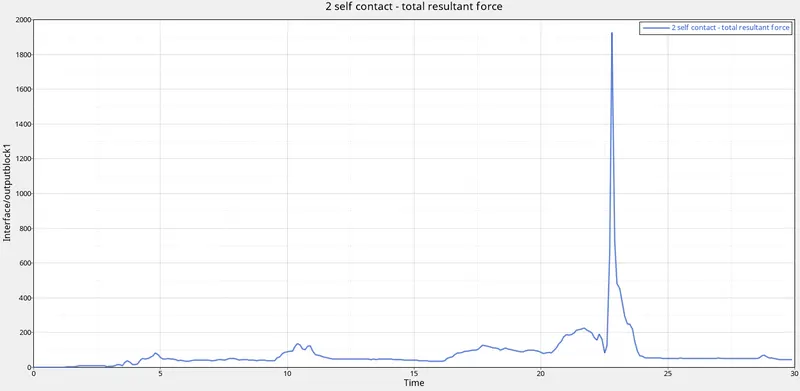
The obtained interface force is seen in fig below. The contact interface rises at the end of the collision.
The obtained internal energy graph for this case, appears as shown in fig below. There is a change in internal energy due to the notch. Because,
the notch area will experience high stress & deflect stress.
Comparison of above cases:-
| Basis for comparison | Case 1 | Case 2 | Case 3 | Case 4 | Case 5 | Case 6 |
| Enenrgy error(%) | -3.8% | -3.8% | -1.6% | -3.0% | 1.6% | 5.4% |
| Mass error(%) | 0 | 0 | 0 | 0 | 0 | 0 |
| Max Von-mises stress | 6.949E-01 | 6.949E-01 | 6.413E-01 | 6.518E-01 | 5.997E-01 | 6.312E-01 |
| Internal energy(KJ) | 0.4202E+05 | 0.4202E+05 | 0.4285E+05 | 0.4234E+05 | 0.4436E+05 | 0.4615E+05 |
| Kinetic energy(KJ) | 592.6 | 592.6 | 601.4 | 555.7 | 456.9 | 378.7 |
| External work | -105.2 | -105.3 | -216.1 | -164.4 | -302.1 | -257.1 |
| Notches | Notches will be there. | Notches will be there | Notches will be there | No notches | A notch at the middle of the model | Notches at the opposing faces in the middle. |
6. Coclusion:
- Generated the mesh for the given bumper component with the mesh size of 6 mm.
- Changed the parameters for the given crash tube model as various cases.
- Finally, plotted the graphs with RWALL forces, contact forces, internal energy (Post-processing) & compared the results.
7. Learning outcomes:-
By doing this challenge, the following apects can be learned:
- Observing the variation in results with respect to the change in notches.
- Observing the behavior of crash by various cases.