Assignment 4-RADIOSS Material Laws Challenge
Aim-
- To run the simulation for plate and rigid ball by using johnson cook material and eleasto plastic material and also to apply brittle failure according to condition given in the challenge.
Objective-
- To run the simulation as it is in first case.
- To make changes with shell parameter,material card and failure parameter for all 7 case.
- To analyse the energy error, mass error,total number of cycle and simulation time also.
- To plot graphs for all 7 cases and compare them.
Type of material in Refrence of Material Card-
- Law1-Elastic
- Law2-Johnson-Cook
- Law27-Elastic-Plastic Brittle
- Law36- Elastic-Plastic Tabulated
- Law42- Odgen(HyperElastic)
- Law70-Foam
Type Of material according to their property-
- Isotropic Elasticity
- Isotropic Elasto-plastic
- Composites and Anisotropic
- Viscous
- Hydrodynamic
- Explosive
Law1-Isotropic Elasticity
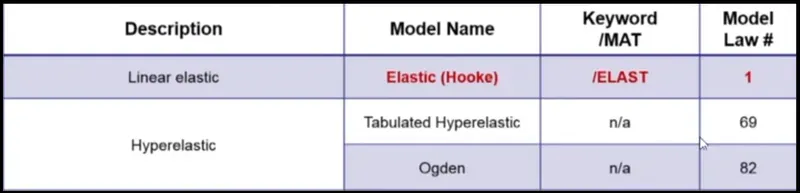
- Keyword in radioss like /MAT/Elast defines an isotropic, linear elastic material using hooks law. This law represents linear relationship between stress and strain. it use in truss, beam(type 3 only) shell and solid elemnts.
- This law usefull for material attached to rigid body.
- This law used for completely elastic material.Here material stiffness can be defined by two values, yound modulus and poission ratios
- Formula using for young modulus calculation is shown below.

Isotropic Elasto-plastic
- This law represents an isotropic elasto plastic material using the johnson-cook material model.
- This model express material stress is function of strain,strain rate and temperature.
- A built-in failure criterion based on maximum plastic strain is available.
Law36-Elastic Plastic piecewise material
- This law model as isotropic Elasto plastic material.
- It used in user defined functions for the work hardening portion of the stress strain curve ( For ex. Plastic strain vs stress).
- It use for brick and shell elements.
- Elastic portion of the material stress strain curve defined by young modulus and poission ratio and density.
- Material plasticity curve can be given for up and arbitrary number of strain rates.
- Linear interpolation of stress strain curve. 1.For a given strain rate 2.For a given plastic strain.
- In order to avoid poor curve interpolation during the strain calculation a dummy curve defined for a high strain rate value can be added in the model, Typically the highest strain rate curve is repeated.
- The curves has to be defined such as they don't intersect themselevs in the strain range being used otherwise the calculation may fail.
There some case points for failure of elemets.
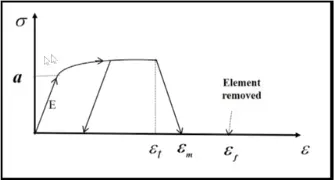
- `εp_max` is the maximum plastic strain for element deletion for any loading (tensile, compression or shear)
- `epsilon_t` is begining of tensile damage.From this point the stress value defined in the curve is reduced by the factor where `epsilon_1` is the largest principle strain. That is,
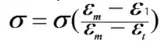
- `epsilon_m` is end pf tensile damage the stress value is null but elements is not deleted at that point.
- `epsilon_f` is the tensile failure strain value for element deletion.
Law27- Elasto plastic material for brittle failure.
- This Law combines Elasto-plastic johnson-cook material model with with an orthotropic brittle failure model.
- Material damage is accounted for prior to failure.Here failure and damage occur only in tension.
- This Law is only applicable for shell elements.
- Yield surface defination is same as Johnson-cook Law2.
- Dmagae and rapture will define with four parameters for each principle direction.
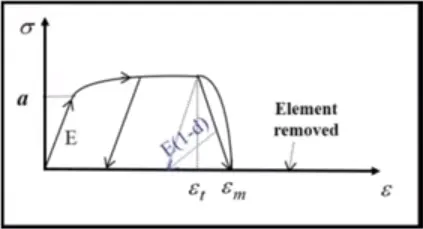
- `epsilon_t`= strain at begining of tensile failure
- `epsilon_m`=maximum tensile strain at which the stress, in the element is set to a value dependent on dmax1.
- dmax =maximum damage factor.
- `epsilon_f`=maximum tensile strain for element deletion.
Viscous material-
There are two types of viscous material we study-
1. Law42-Hyper Elastic(MAT/ODGEN or MAT/LAW42)-Odgen,Moony Rilvin
- This is of visco Hyperelestic behaviour (non-linear elastic).
- This law is generally used to model incompressible rubbers,polymers,foams and elastomers.
- This law can be used for shell and solid elements both.
- But mainly used for polymers and elastomers.
2.Law70-Tabulated Foam(MAT/FOAM_TAB or MAT/LAW70)
- Visco Elastic Behavior.
- Stress strain relationship defined by function according to strain rate.
- Unloading behaviour defined by,
a. Curves b.Hysteresis parameters
Procedure-
Stage-1: Import-
[Note-Import this model using Radioss profile]
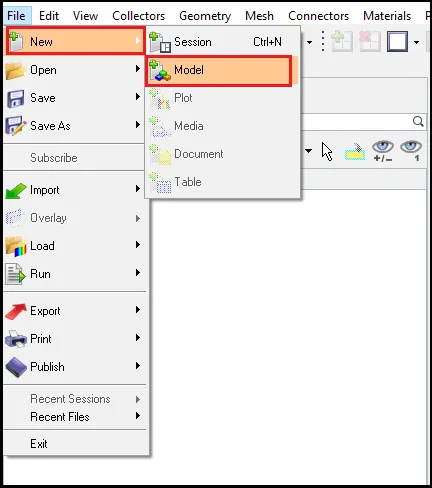
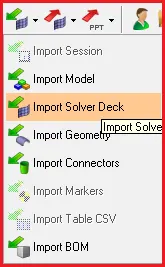
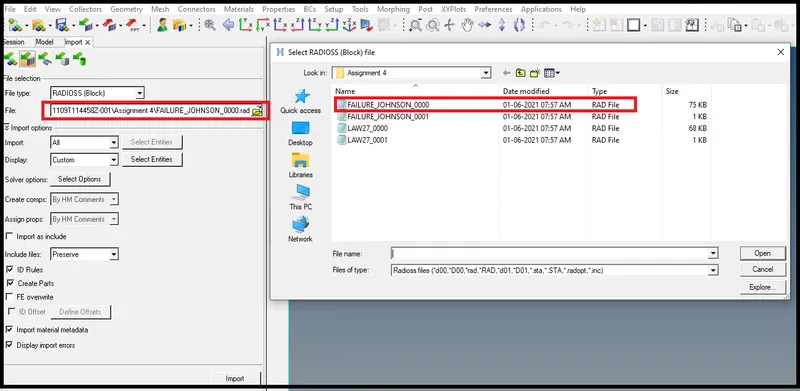
- Now after selecting the file, click on open and then import.
- Then we can see file imported on GUI.
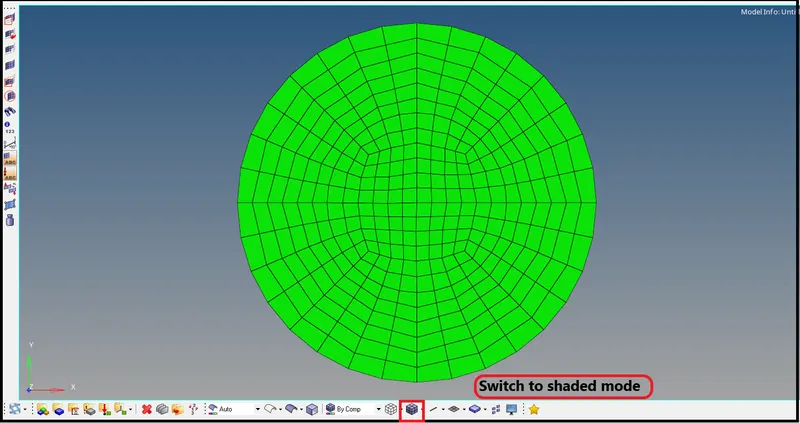
- After importing the model switch it to shaded mode.
Case-1
- In case-1 run the simulation as it is, given with material and elemental property.
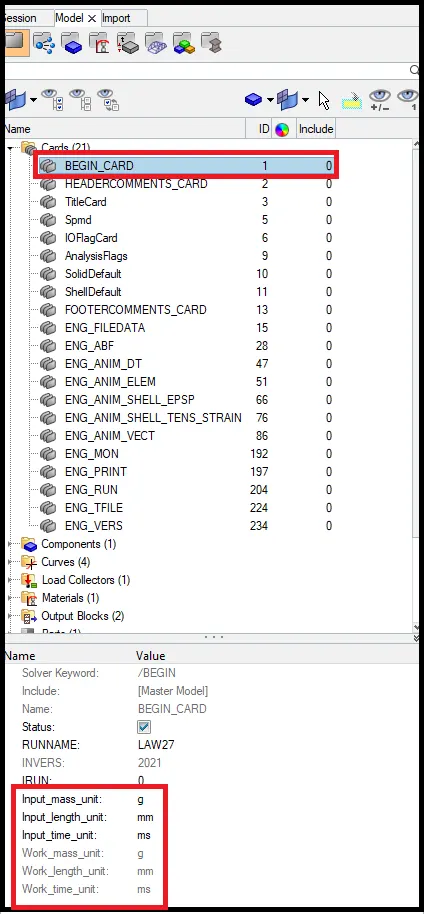
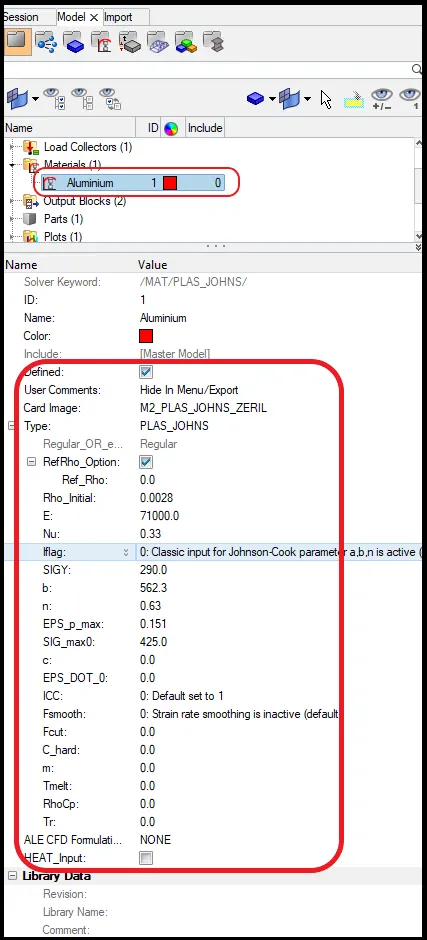
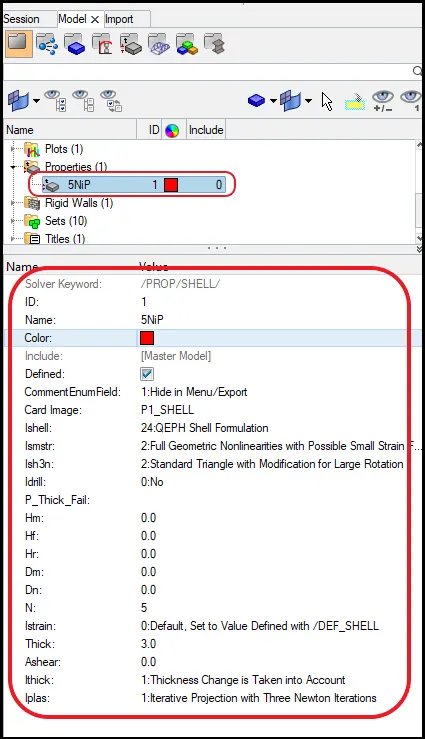
- For that we need to check some parameter like what are the units, material and properties is given.
Check for unit-
Go to Model browser > Begin card
Material check-
Go to Model browser > Material >
Property check-
Go to Model browser > Property >
- Now after checking all the criteria Run the simulation as is it
- To run the simulation go to Analysis > Radioss.
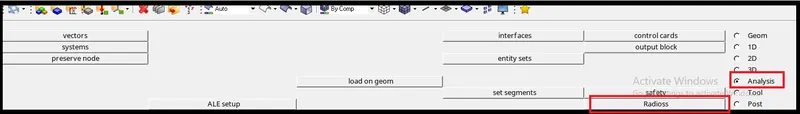
- After clicking Radioss click on input file and save it in new folder as Case-1.
- Check the include connectors and option as -nt 4.
- N indicated the how many cores will involve to run the simulation.
- It will make simulation faster.
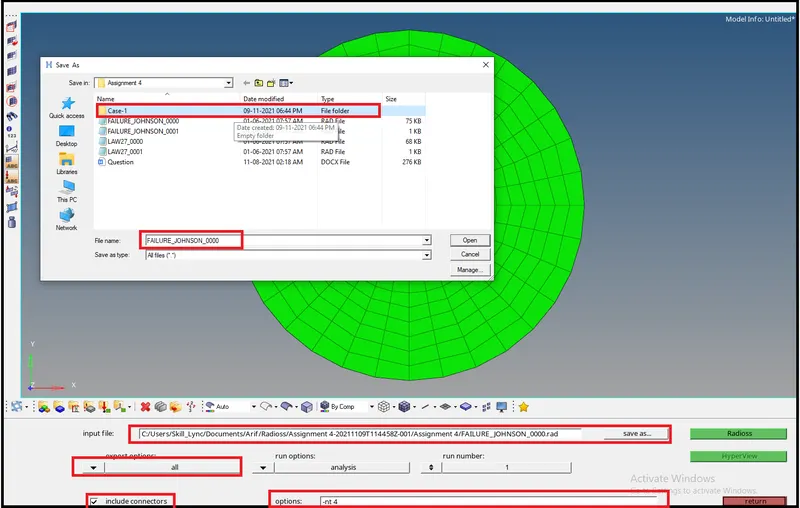
- After that click on Radioss it will start the simulation.
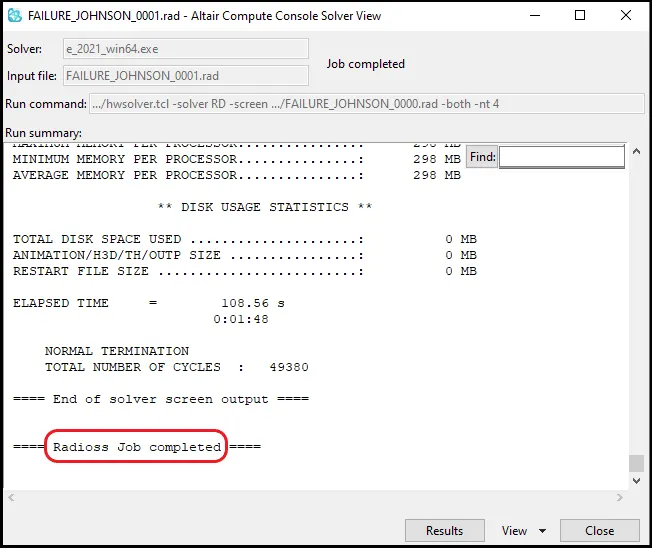
- And wait untill the new window popup and show as Radioss job completed.
- Now open the Engine file (0001.rad) file to varify the Tfreq and Tstop values.
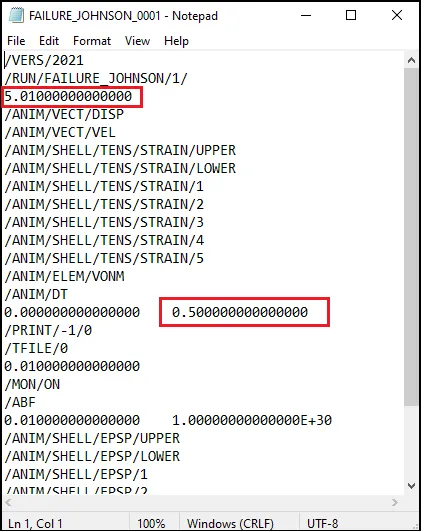
Fig- (0001.rad File)
- Now after running the simulation we got animation file also.
- In which all the details are stored that how simulation is ran like time steps, Energies losses during simulation, No of cycles etc.
- So now open 0001.out file and check all the details.
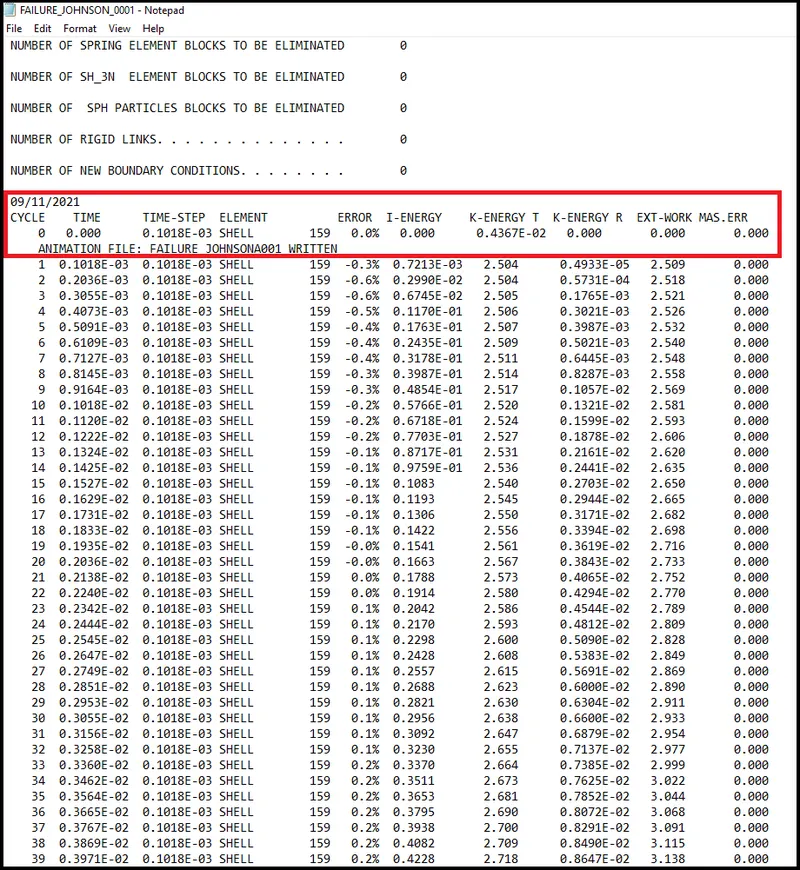
- Here we can see all variable in the out file about energy and mass loss also.
- So for checking the maximum loss check the last cycle details.
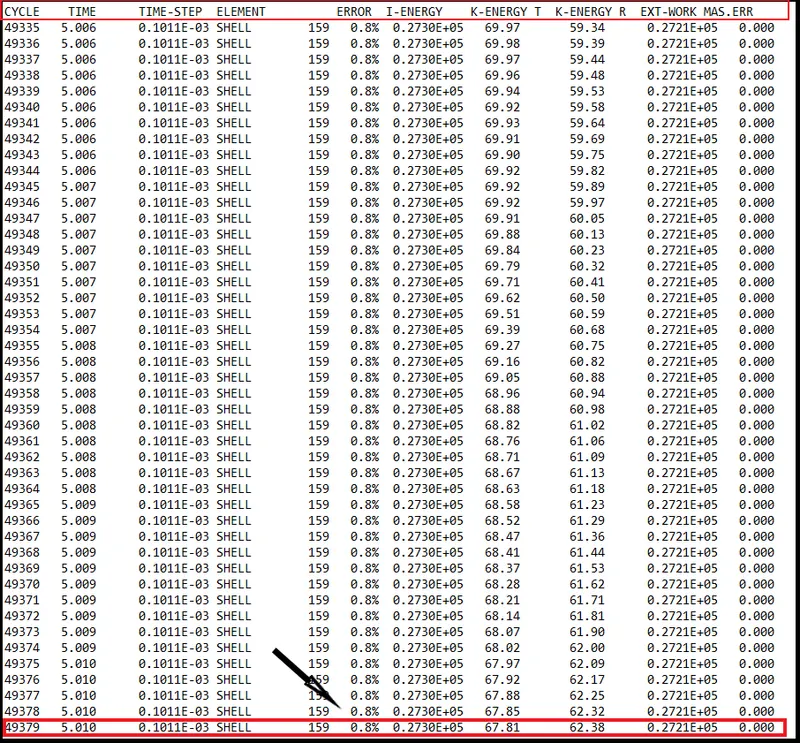
- Here in in last cycle of the simulation we have maximum energy losses where,
Energy error is 0.8 % Acceptable (Range is -15% to +5%)
Mass Error 0 Acceptable (Range is 0 to 2%)
So the resultent energies are,
- Internal Energy 0.2730E+5
- Kinetic Energy 67.81
- External work 0.2721E+5
- No of cycles 49379
Post processing-
- Review the simulation using Hyperview.
- Plot the graphs using Hypergraph-2D
1.Review the simulation using Hyperview.
Split the screen in two part-
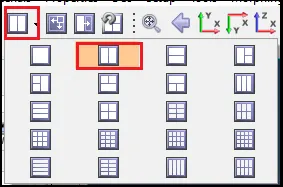
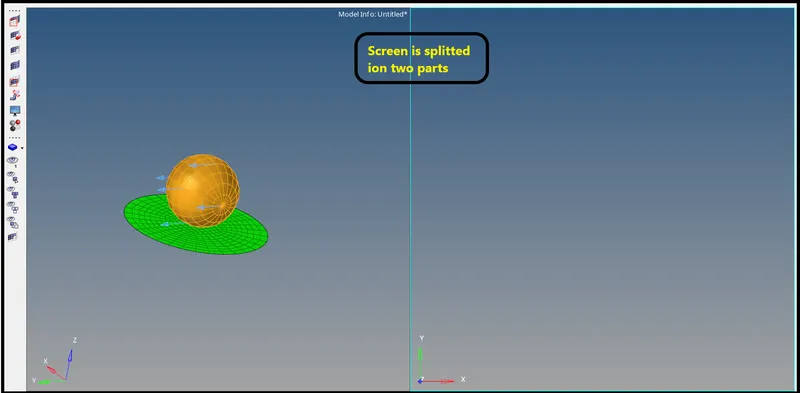
- Now after splitting the sreen open hyperview after switching into in 2nd screen.
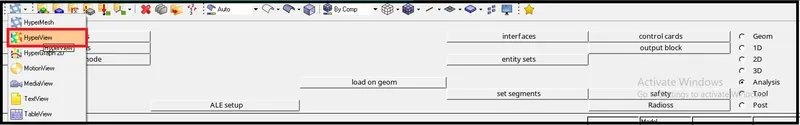
- In hypergraph window import the h3d file for simulation run.
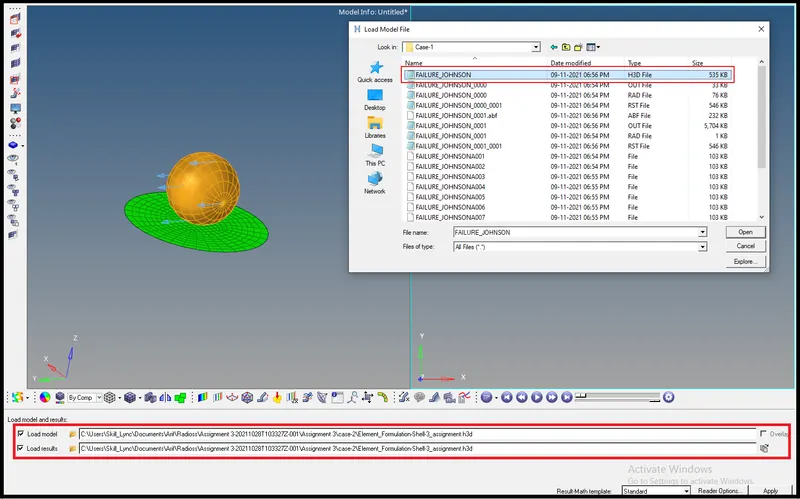
- Now after loading the file in hyperview it will the model as shown below.
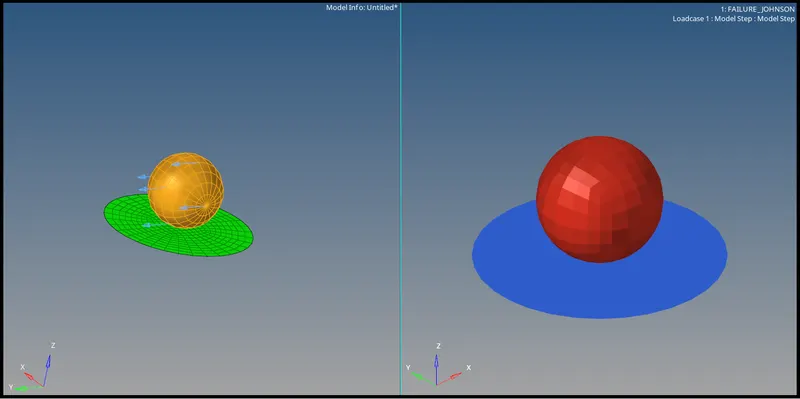
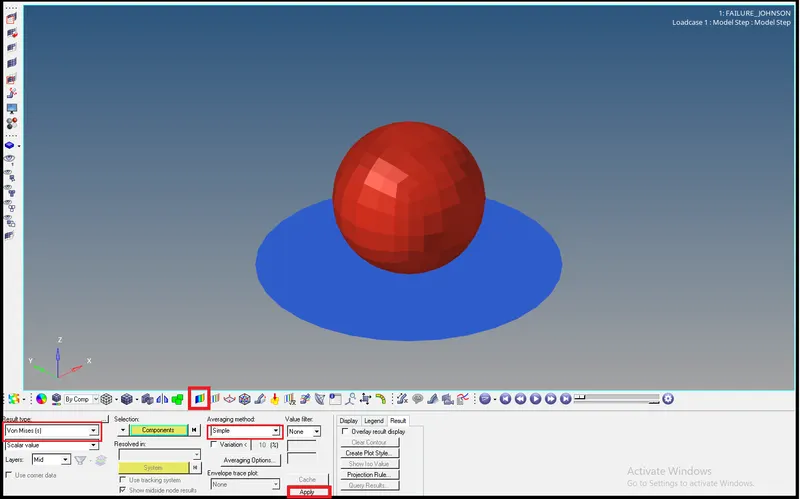
- Now after importing the h3d file on hyperview GUI go for contour activation.
- In contour it will show the simulation graphically and contour lies of load and other properties variation.
- To activate contour go to Tool bar > contour as shown below.
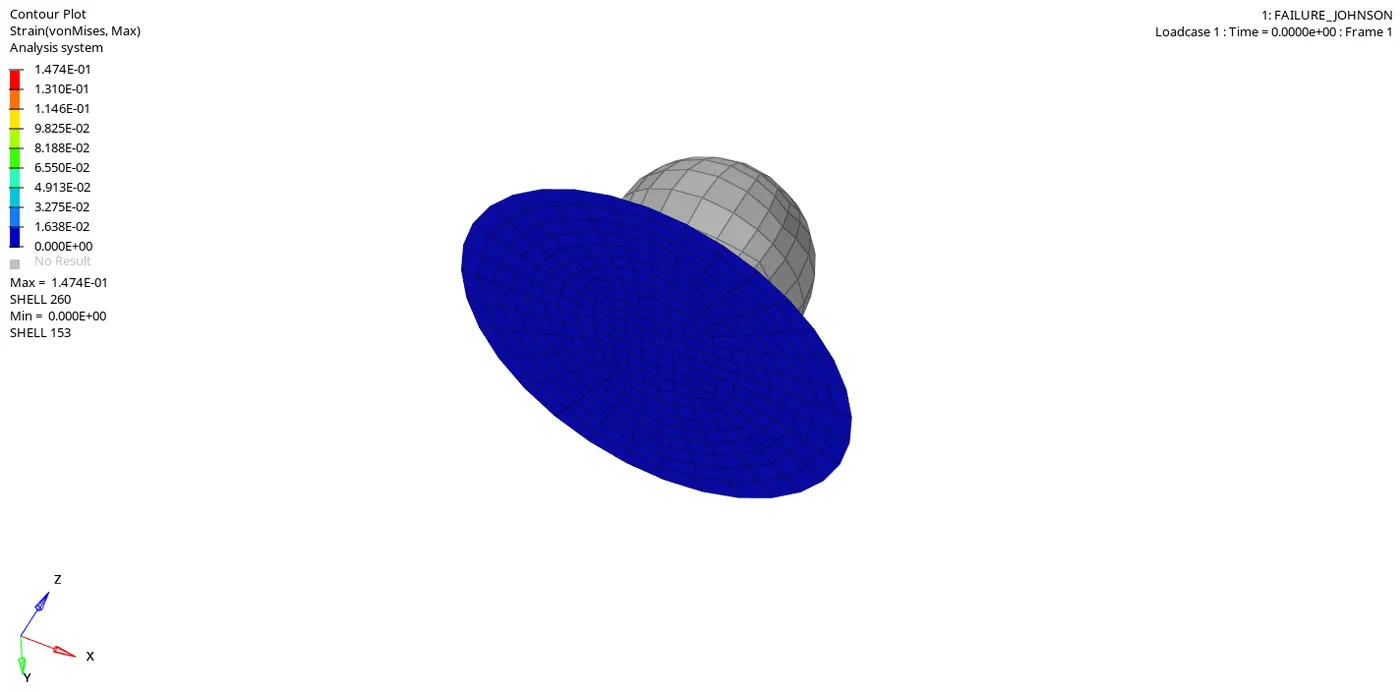
- After applying contour, Run the simulation and we will get this,
2. Plot the graphs using Hypergraph-2D
- Now split the window in 3Part and open hypergraph-2D in new window.
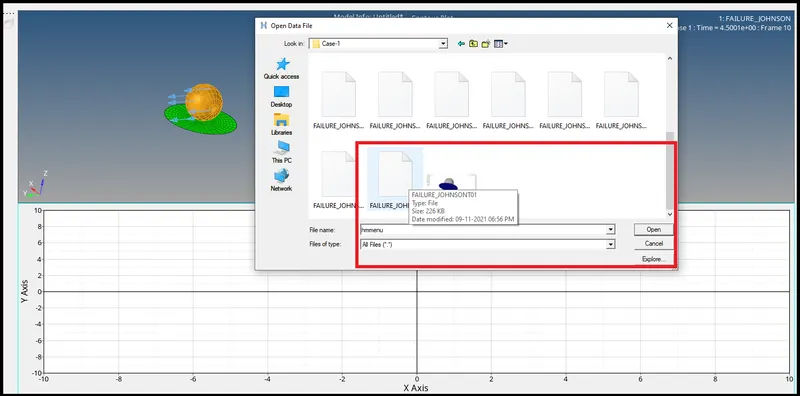
- After opening the hypergraph windoe import the T01 file in Hypergraph.
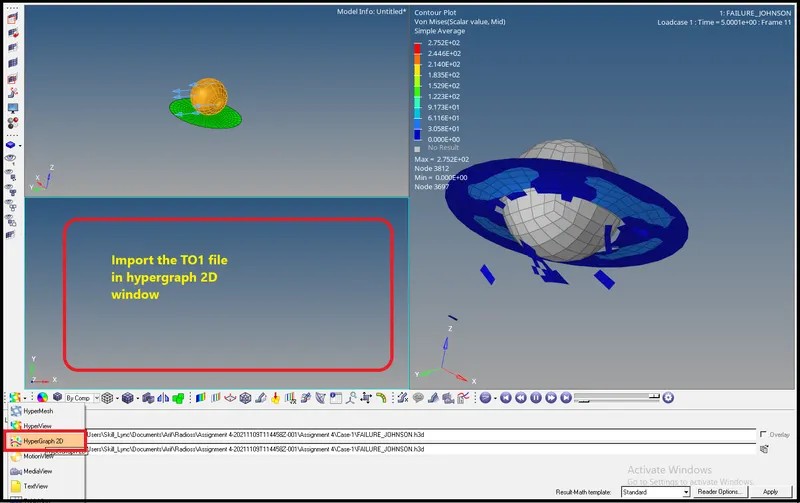
- hypergraph 2D is very much usefull data nalysis and plotting graph tool with interfaces and many popular file formats.
- To switch go to client selector > select hypergraph 2Das shown above.
Import the T01 File-
Start plotting graphs-
- First will plot the rigid wall force graph.
Rigid Wall Force-
Graph-
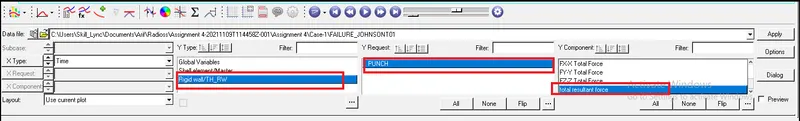
- Here in Rigid Force graph we have lot of parameter which we can defined but here in this case we dont know about the exact direction of force applied.
- So for that we will go for resultent force and will draw graph for resultent Rigid wall force graph.
- Select the option as shown below.
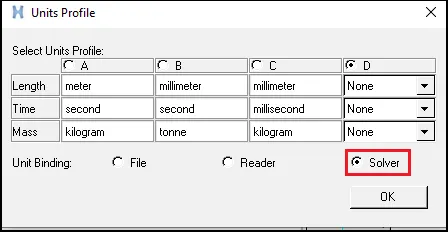
- When we click on apply the Unit profile window will pop-up and we will sleect the solver unit system.
- So it will plot graph according to the units present in solver.
click on ok and get graph,
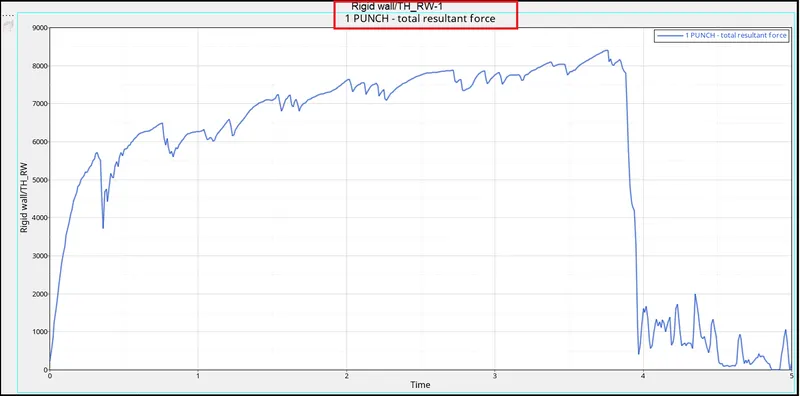
- At t=0 Rigid wall force is zero because at that time there was no contact between ball and plate.hence elements are not exerting any force to rigid ball.
- The moment the ball hits the plate rigid force start increasing and it will show some zig-zag behaviour and thats due to noise and vibration induced due to sudden impact.
- At the ultimate stress point elements starts breaking and ball starts loosing contact to the elements thats why we can see the sudden drop in the graph.
- Since some elements was still in contact with plate after rapture due to that we can see further zig-zag graph at lower force.
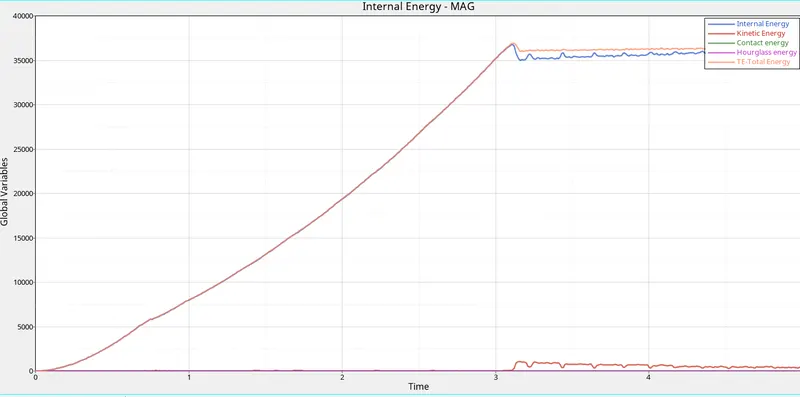
Combined Energy Graph-
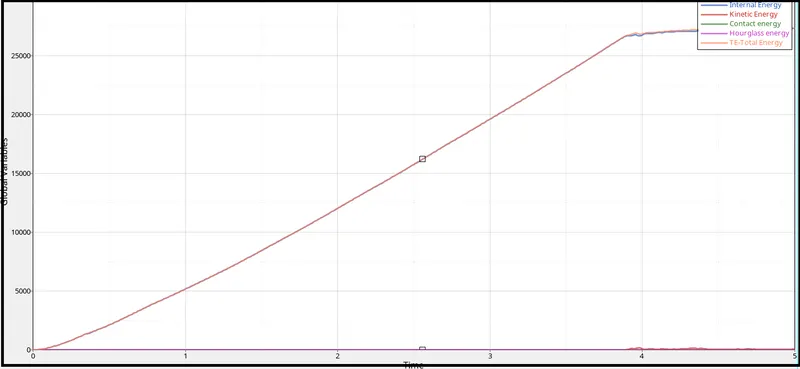
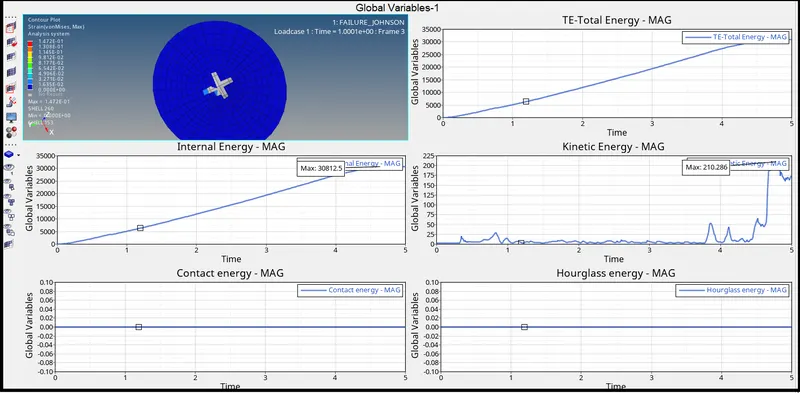
- This graph is complete representation of all energies curve during simulation.
- Now we will plot graph and analyzeindivisually.
Internal Energy-
Graph-
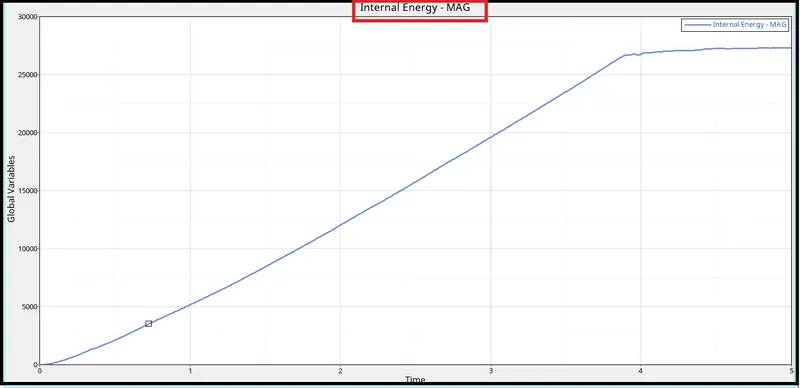
- Initially ball was not into contact with circular plate so at t=0 internal energy was zero.
- And the time when ball hits the plate there is stress generation and due to this stress, strain will happen.
- That strain starts the deformation in the plate and due to this internal energy start increasing.
- It will increse till ultimate strength after that point elements starts breaking and due to this element break, strain increment stopped that is why graph is flat after rapture point.
Kinetic Enrgy-
Graph-
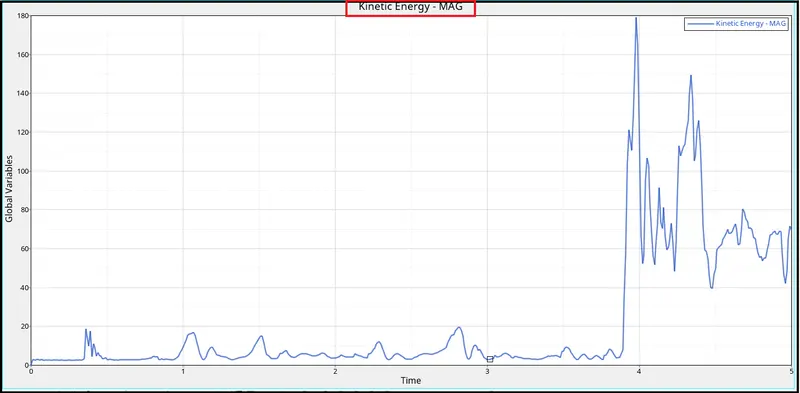
- At t=0 velocity of elements are zero because at that time there was no contact between ball and plate.
- But when ball hits the plate then elements start moving due to deformation till plastic fracture.
- But after fracture since elements are starts breaking then there is sudden rise in velocity of elements we can see in simulation hyperview animation.
- So due to this there is sudden gain in kinetic energy in elements due to rapture.
Hourglass energy-
Graph-
- Since we have used improved under integerated elements which is Ishell 24 (QEPH).
- So due to that there is no hourglass is noted.
Contact Energy-
Graph-
- Here in this case there is no contacts between deformable elements in plates.
- So we can see there is constant line in contact energy graph.
Case-2 - Use same FAILURE JHONSON 000.rad with change in Failure criteria. (lfail_sh=1, Dadv=1, lxfem=1 )
- Here in 2nd case material Law will be same ( LAW2) but the failure criteria will be change.
a.lfail_sh = 1 (Default, shell is deleted or cracked)
b.Dadv = 1 (It will initiate the crack when it will reaches ultimate stress)
c.lxfem = 1 (It will delete the cracked element.)
- Give all the value in input failure card.
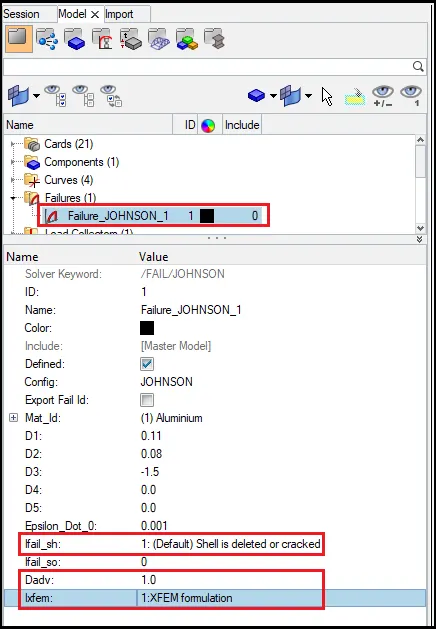
- Now run the simulation as with edited failure card.
- After running the simulation we will see new h3d and animation will be generated.
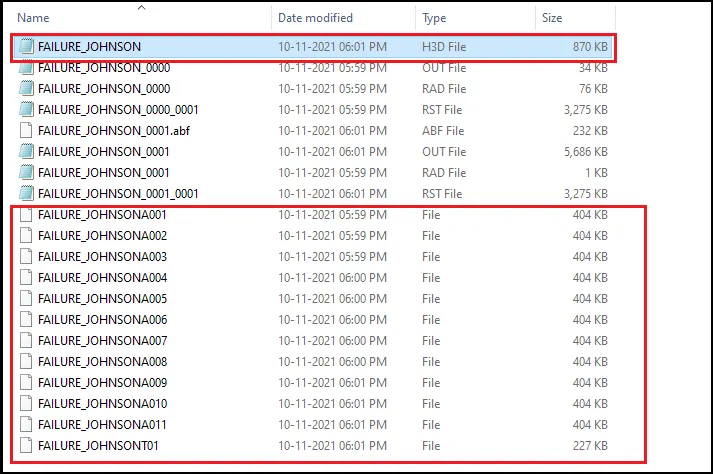
- Now open 0001.out file and check all the details.
- Here we can see all variable in the out file about energy and mass loss also.
- So for checking the maximum loss check the last cycle details.
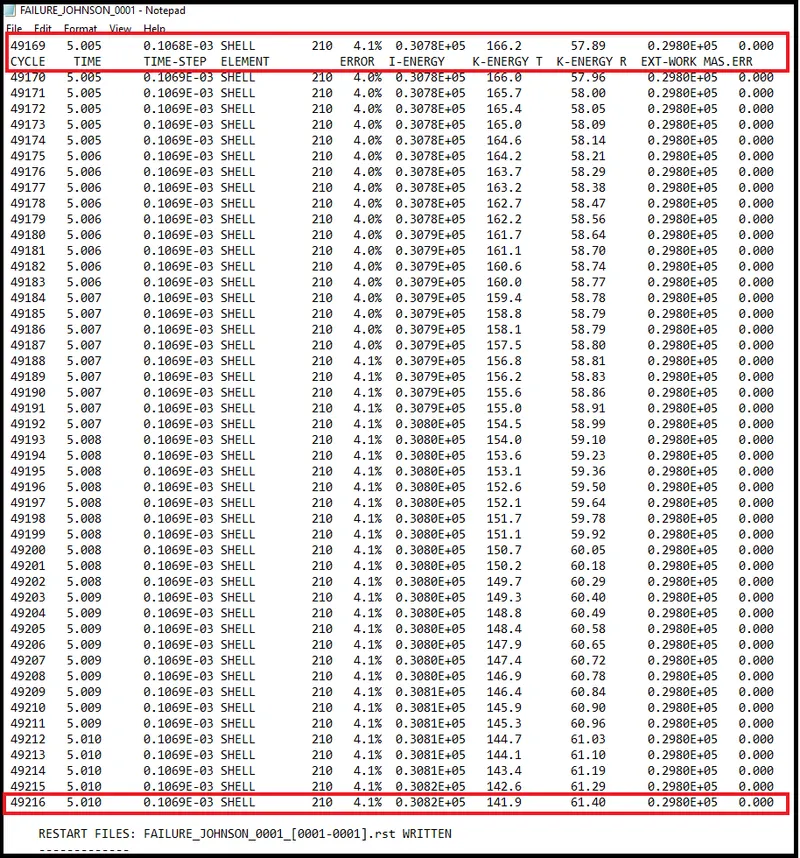
- Here in in last cycle of the simulation we have maximum energy losses where,
Energy error = 4.1 % Acceptable (Range is -15% to +5%)
Mass Error = 0 Acceptable (Range is 0 to 2%)
So the resultent energies are,
- Internal Energy 0.3082E+5
- Kinetic Energy 141.9
- External work 0.2980E+5
- No of cycles 49216
Post processing-
- Review the simulation using Hyperview.
- Plot the graphs using Hypergraph-2D
1.Review the simulation using Hyperview.
- Now open the hyperview in 2nd window and upload h3d File there to see the simulation in hyperview.
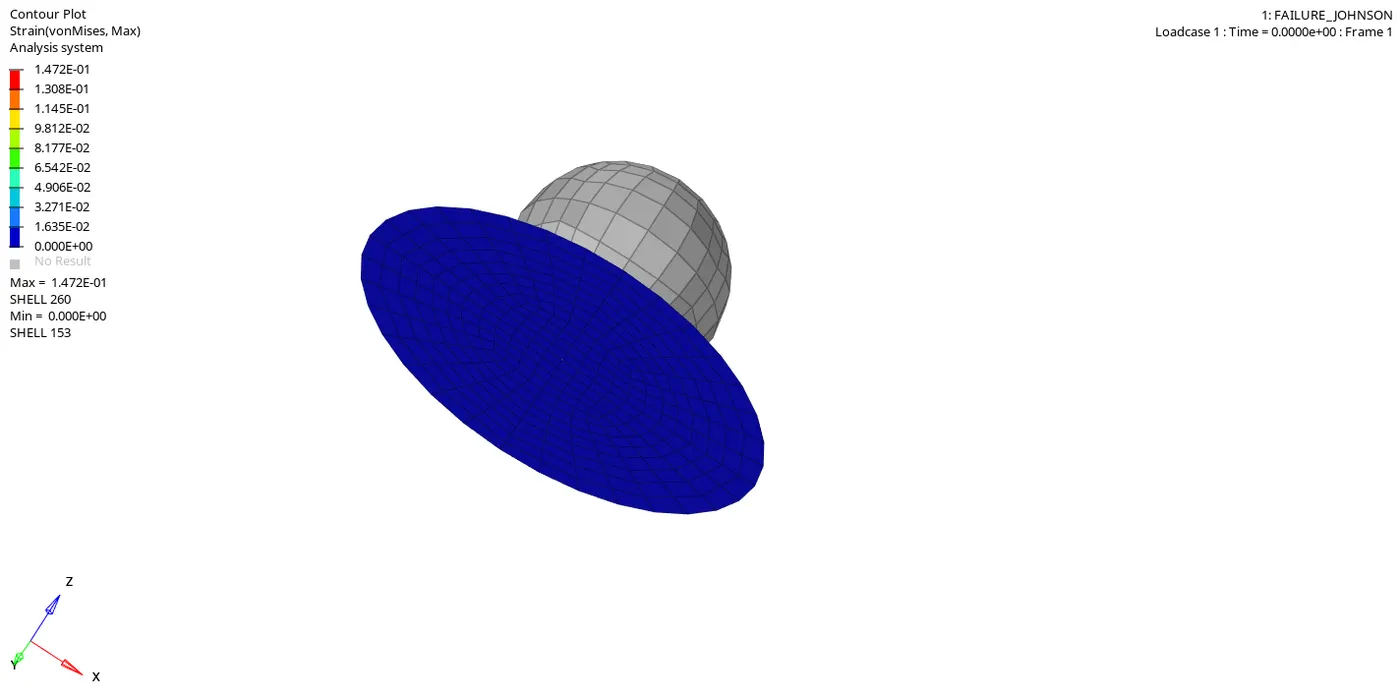
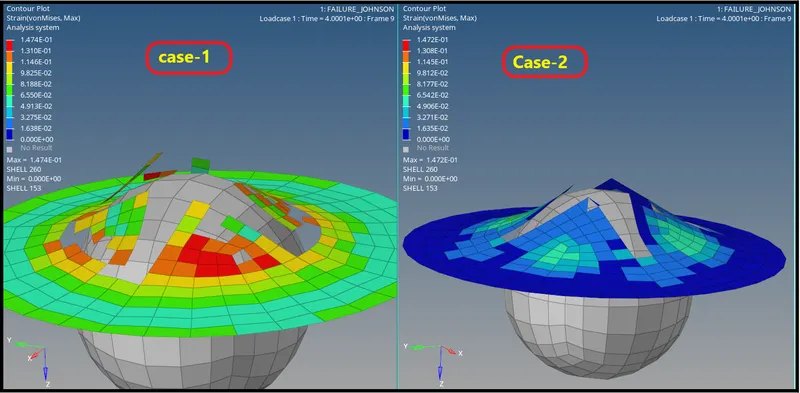
- In this this the maximum Eps_max value recorded is 1.472e-01 which is Eps_max=.1472.
- But we have given Eps_max value= 0.151 in material card so it should fail on 0.151 value.
- The moment when rigid ball hits the plate the elements reaches its Eps_max value= 0.151 and get break and deleted.
- Since elements are deleted so the Eps_max value of 0.151 of deleted elements is not going to display by solver.
- it will display Eps_max value for only those elements which are present.In which many of reaches maximum value as 0.1472 and many elements ar reaches at different value as shown on above animation.
2. Plot the graphs using Hypergraph-2D
- Now split the window in 3Part and open hypergraph-2D in new window.
- After opening the hypergraph windoe import the T01 file in Hypergraph.
Rigid wall force Graph-
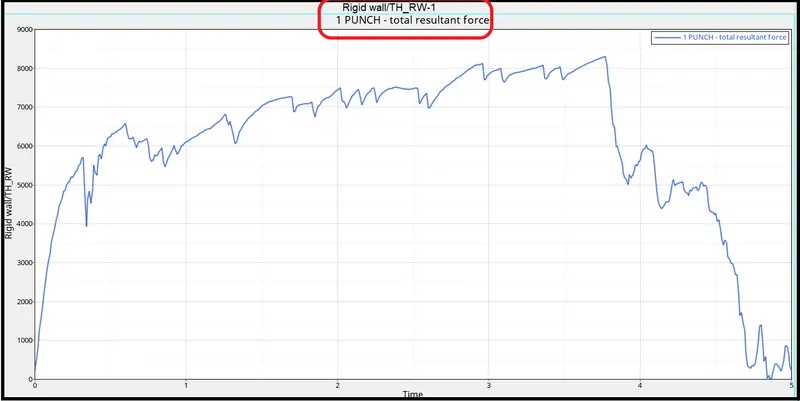
- At t=0 Rigid wall force is zero because at that time there was no contact between ball and plate.
- The moment the ball hits the plate rigid force start increasing and it will show some zig-zag behaviour and thats due to noise and vibration induced due to sudden impact.
- At the ultimate stress point elements starts breaking and ball starts loosing contact to the elements thats why we can see the sudden drop in the graph.
- But in this case we can see less drop in Rigid force graph after breaking compared to case-1.Because in case-2 more elemnts in contact with ball during simulation as we can see in image below.
- Since some elements was still in contact with plate after rapture due to that we can see further zig-zag graph with lower force.
Internal Energy-
Graph-
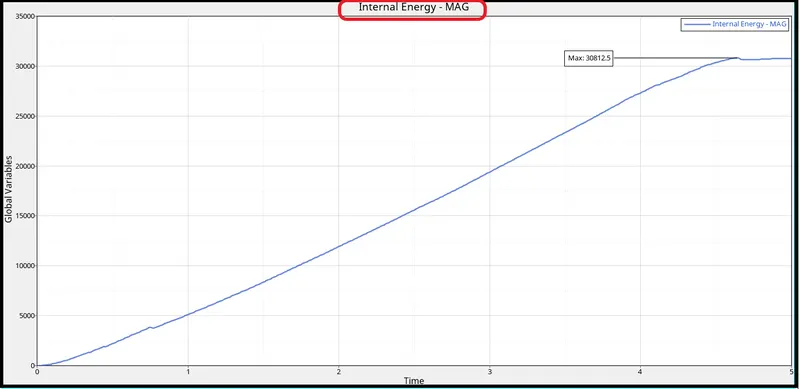
- It will increse till ultimate strength because deformation is taking place and due to deformation strain energygenerated and that energy is storing in the form of internal energy.
- After that point elements starts breaking and due to this element break, strain increment stopped that is why graph is flat after rapture point.
Kinetic Enrgy-
Graph-
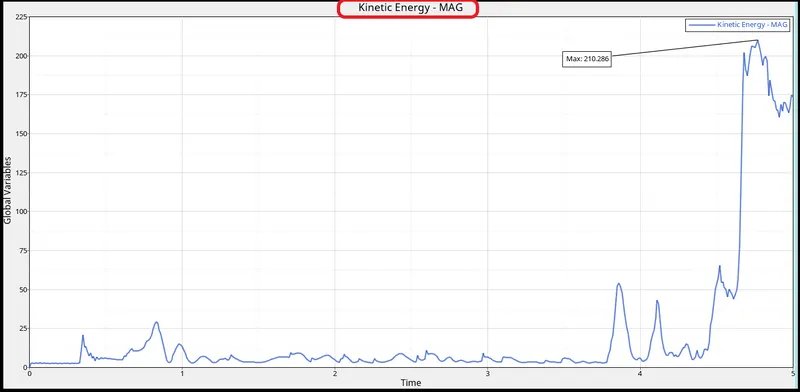
- At t=0 velocity of elements are zero because at that time there was no contact between ball and plate.
- But when ball hits the plate then elements start moving due to deformation till plastic fracture and due to deformation strain energy is storing so thats why kinetic energy not increasing that much.
- But after fracture since elements are starts breaking and moving at faster rate then there is sudden rise in velocity of elements we can see in simulation hyperview animation.
- Ad then its decreasing slightly because of losing contact.
Hourglass energy-
Graph-
- Since we have used improved under integerated elements which is Ishell 24 (QEPH).
- So due to that there is no hourglass is noted.
Contact Energy-
Graph-
- Here in this case there is no contacts between deformable elements in plates.
- So we can see there is constant line in contact energy graph.
Total Energy-
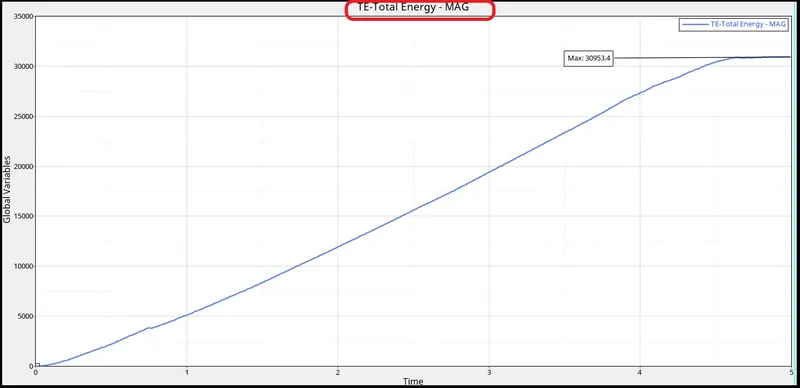
- Total energy is sum of all type of energy present here,Kinetic+Internal+contact+hourglass.
- So it will increase as all energies combinedly increase.
Combine Graph of all energies-
Case-3- Delete the failure card (fail/JHONSON)
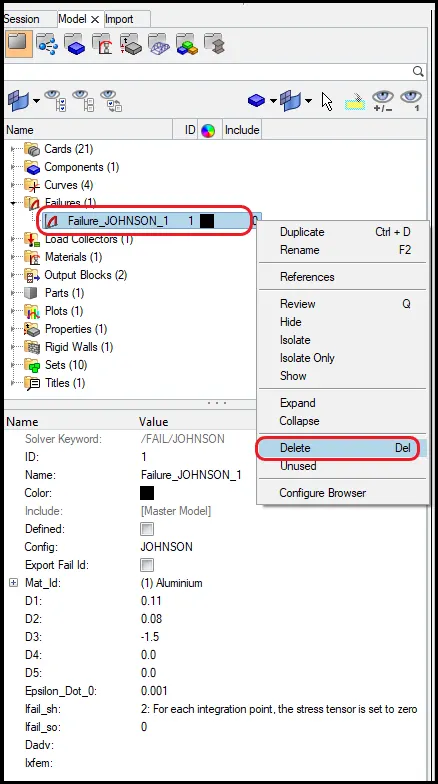
- Now run the simulation and save the radioss file as different case as case-3.
- After running the simulation we will get animation file, h3d file and also T01 file.
Check for file after simulation,
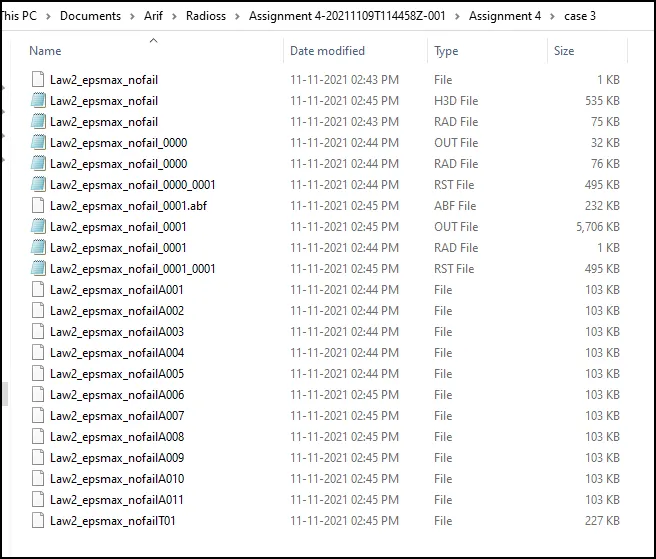
- Now we can see all files have been created.
- Now open 0001.out file and check all the details.
- Here we can see all variable in the out file about energy and mass loss also.
- So for checking the maximum loss check the last cycle details.
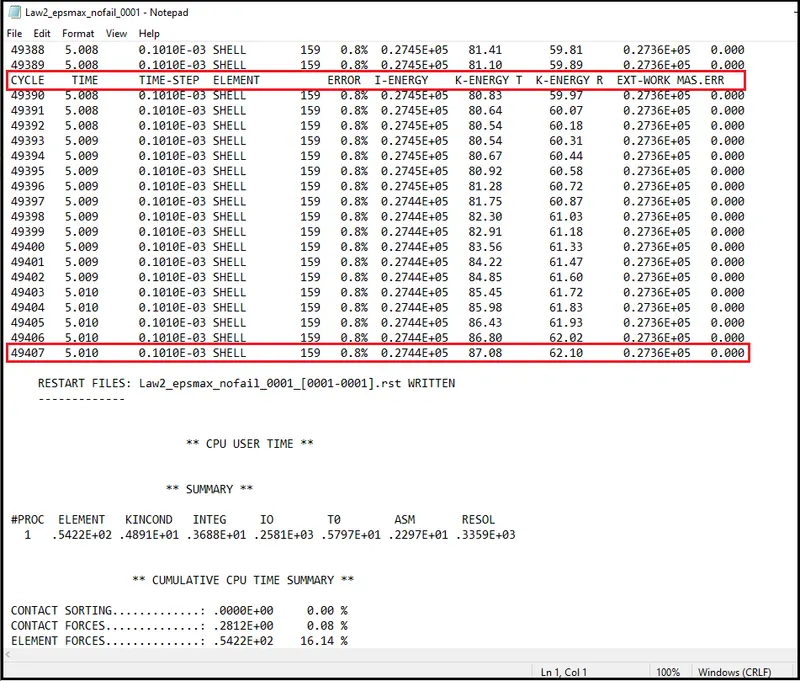
- Here in in last cycle of the simulation we have maximum energy losses where,
Energy error = 0.8 % Acceptable (Range is -15% to +5%)
Mass Error = 0 Acceptable (Range is 0 to 2%)
So the resultent energies are,
- Internal Energy 0.2744E+5
- Kinetic Energy 87.08
- External work 0.2736E+5
- No of cycles 49407
Post processing-
- Review the simulation using Hyperview.
- Plot the graphs using Hypergraph-2D
1.Review the simulation using Hyperview.
- Now open the hyperview in 2nd window and upload h3d File there to see the simulation in hyperview.
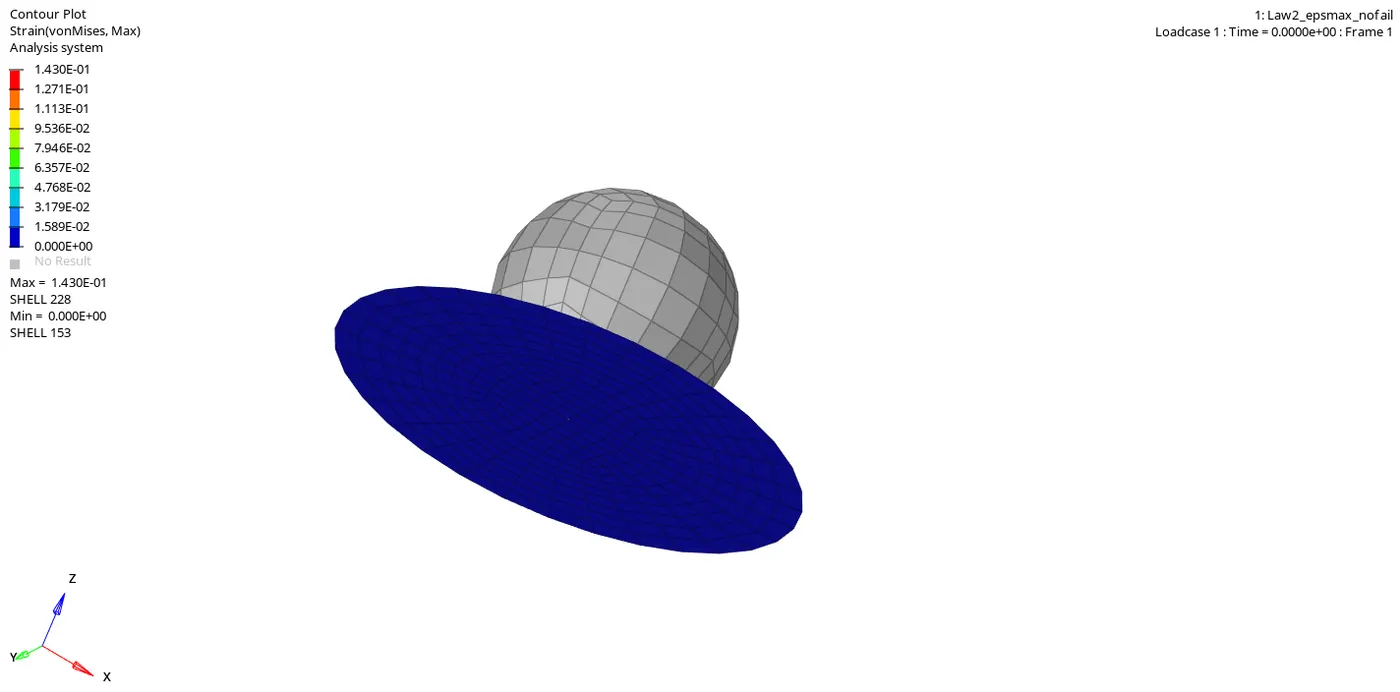
- In this this the maximum Eps_max value recorded is 1.430e-01 which is Eps_max=.1430.
- Few elements was already failed and deleted by reaching Eps_max value =0.151
2. Plot the graphs using Hypergraph-2D
- Now split the window in 3Part and open hypergraph-2D in new window.
- After opening the hypergraph windoe import the T01 file in Hypergraph.
Rigid wall force Graph-
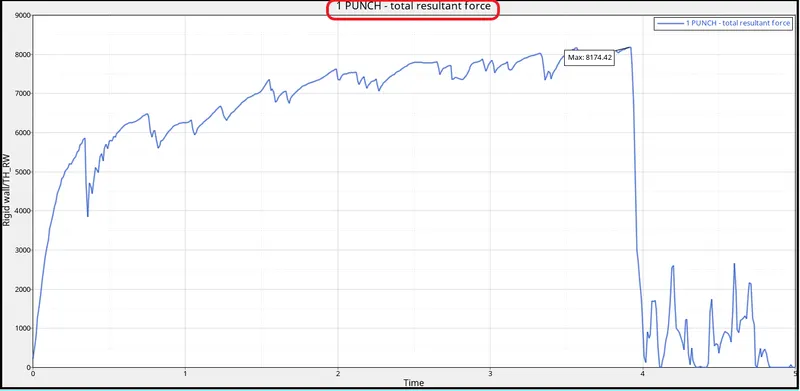
- Here rigid wall force graph variation is looks similar to cae-1 necause the element failure and breaking is simmilar to case-1.
- Most of the elements are break loose from plate thats why after ultimate point graph fall suddenly, after that also some remaing elemnts extered some force on ball that's why graph is continued in that way as shown above.
Internal Energy-
Graph-
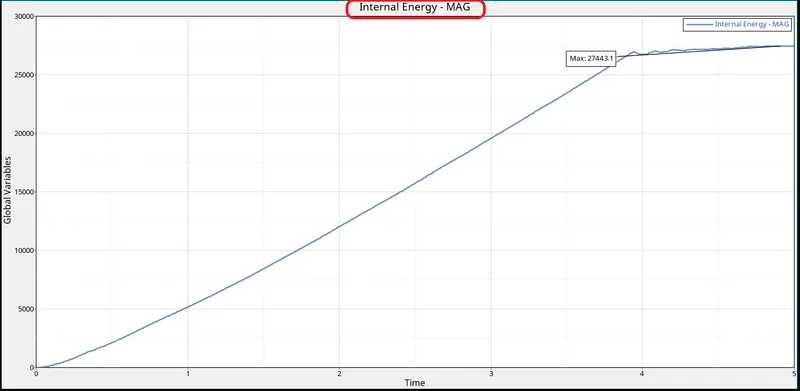
- It increasing till ultimate strength point because till that point deformation taking place.
- And due to deformation internal energy is recording.
- But after breaking point element looses the contact so that no deformation is happening that;s why graph is being constant after that point.
Kinetic Enrgy-
Graph-
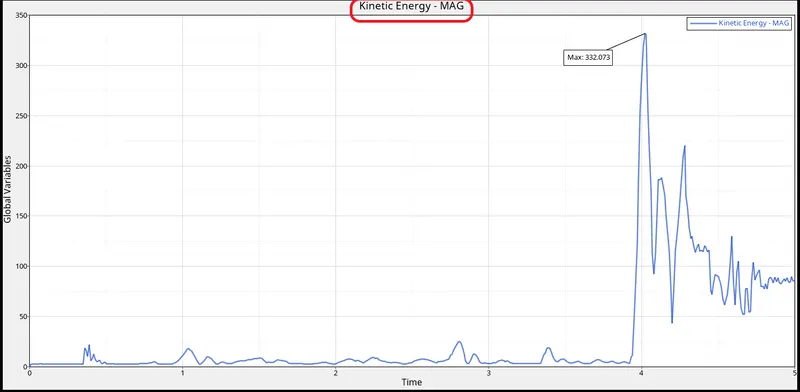
- Here in this case very less amount of kinetic energy is being noticed, because while ball is colliding to plate most of the energy is converted into strain energy.
- But after ultimate strain point due to elemental break suden increase in kinetic energy graph is noted.
Hourglass energy-
Graph-
- Since we have used improved under integerated elements which is Ishell 24 (QEPH).
- So due to that there is no hourglass is noted.
Contact Energy-
Graph-
- Here in this case there is no contacts between deformable elements in plates.
- So we can see there is constant line in contact energy graph.
Total Energy-
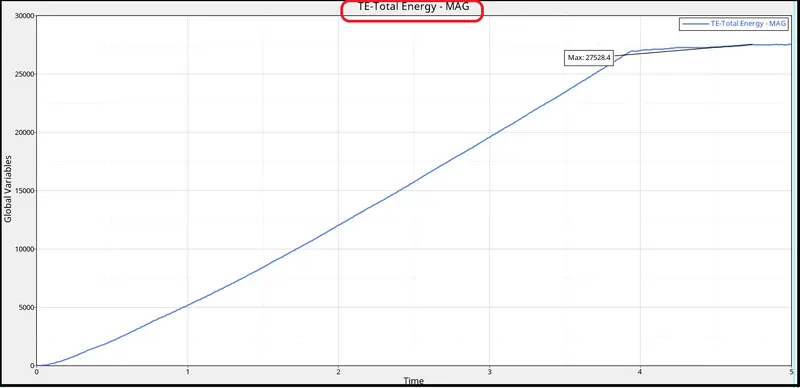
- Total energy is sum of all type of energy present here,Kinetic+Internal+contact+hourglass.
- So it will increase as all energies combinedly increase.
Combine Graph of all energies-
Case-4- Delete the Epx_p_max value from material card.
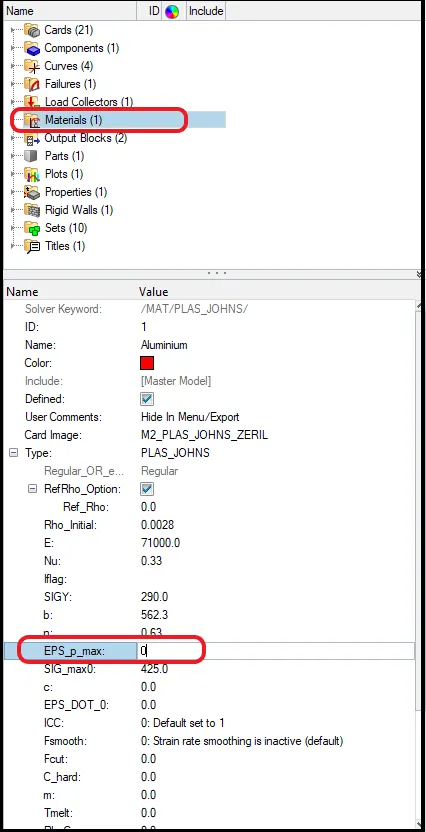
- Now run the simulation and save the radioss file as different case as case-4.
- After running the simulation we will get animation file, h3d file and also T01 file.
Check for file after simulation,
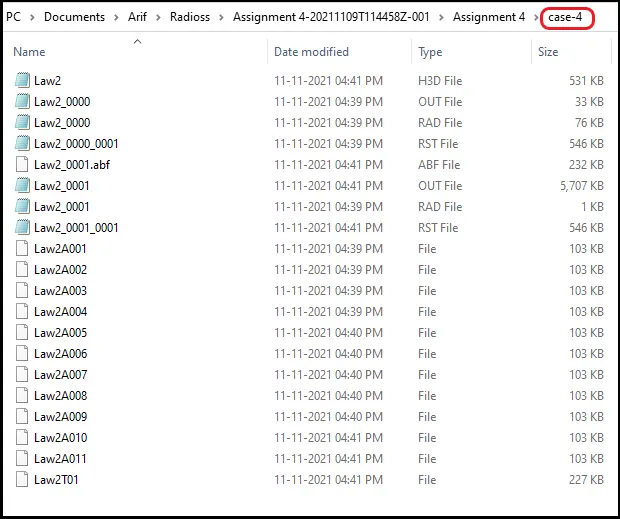
- Now we can see all files have been created.
- Now open 0001.out file and check all the details.
- Here we can see all variable in the out file about energy and mass loss also.
- So for checking the maximum loss check the last cycle details.
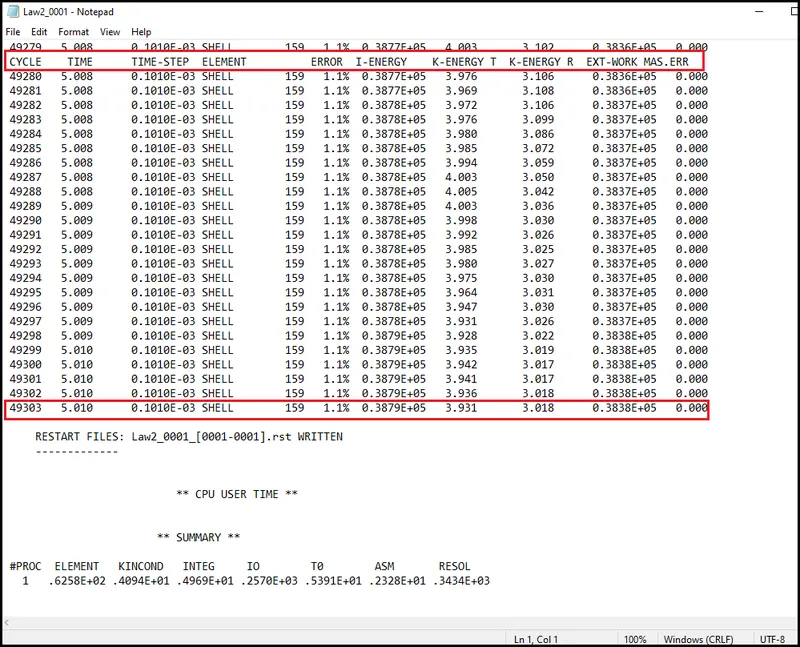
- Here in in last cycle of the simulation we have maximum energy losses where,
Energy error = 1.1 % Acceptable (Range is -15% to +5%)
Mass Error = 0 Acceptable (Range is 0 to 2%)
So the resultent energies are,
- Internal Energy 0.3879E+5
- Kinetic Energy 3.931
- External work 0.3838E+5
- No of cycles 49303
Post processing-
- Review the simulation using Hyperview.
- Plot the graphs using Hypergraph-2D
1.Review the simulation using Hyperview.
- Now open the hyperview in 2nd window and upload h3d File there to see the simulation in hyperview.
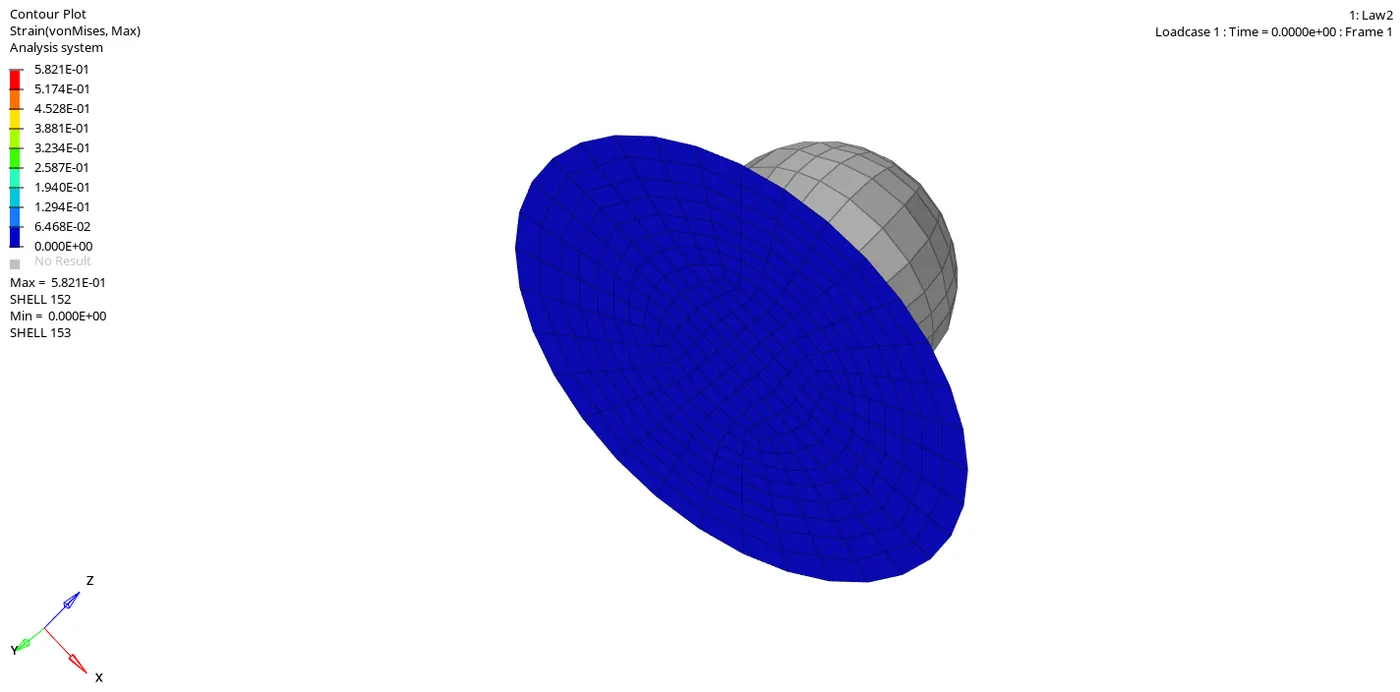
- In this this the maximum Eps_max value recorded is 0.5821 which is original Eps_max for Aluminium.
- Since we have not given any specific value for Eps_max so it will fail on original maximum strain value of aluminuim metal.
2. Plot the graphs using Hypergraph-2D
- Now split the window in 3Part and open hypergraph-2D in new window.
- After opening the hypergraph windoe import the T01 file in Hypergraph.
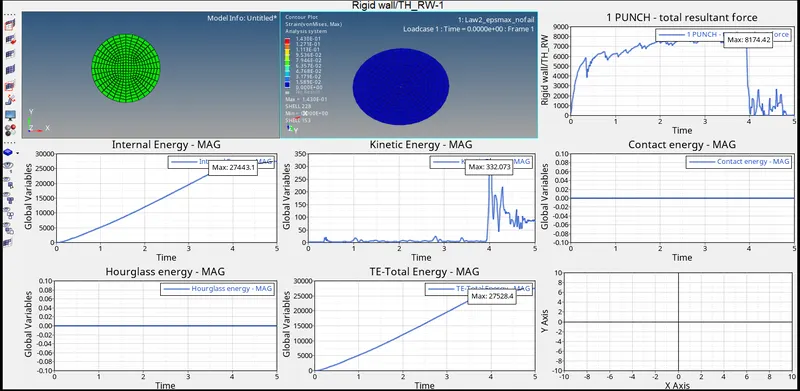
Rigid wall force Graph-
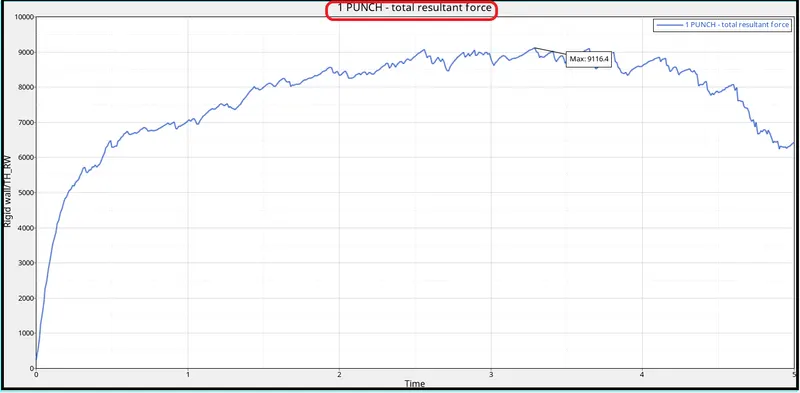
- Here in this case there is not such kind of sudden drop in graph, because here no defined value for maximum strain by user.
- So it will continued increasing till originial maximum strain value with some zig-zag pattern due to noise.
- And after reaching orginial max strain value it will break and then elements starts deleteing and lossing contact with rigid ball, that's why graph is decreaing slightly after some time.
Internal Energy-
Graph-
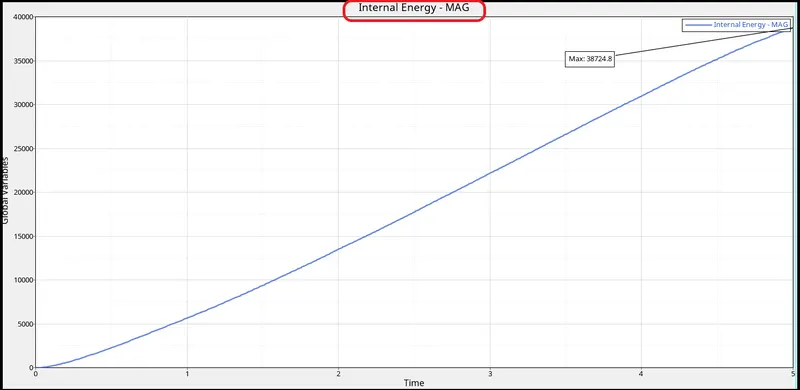
- Internal energy keep on increasing since there is not specific value for maximum strain given by user.
- The graph is not constant after some time like previous cases is just because the elements in previous case are break and fall apart, and after falling apart solver record no strain energy(because it will not deform after falling aprt) thats why graph were constant.
- But in this case no elements are falling apart, yes some elements are breaking deleted so for that solver will not record their internal energy value.
Kinetic Enrgy-
Graph-
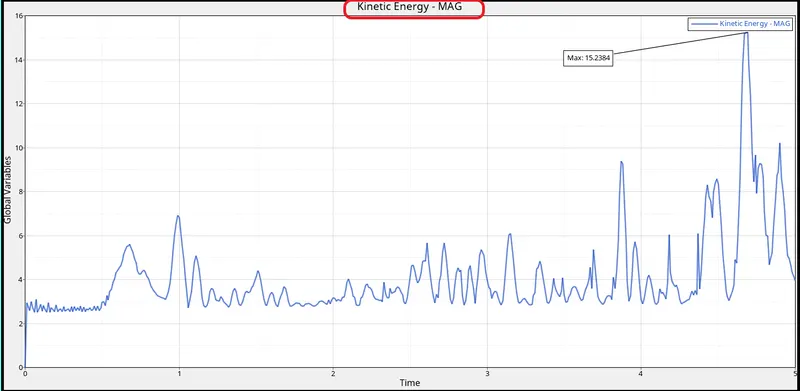
- Here initially there will be some kinetic energy present because elements are deforming at low speed,cause we have not given specific Eps_max value. so it will take time to deform and to reach its original Eps_max value.
- Along with time when its start deforming properly elements are also start moving little faster so their is gain in kinetic energy.
- And it will follow the same zig-zag pattern till ultimate strength of Aluminum or can say original Eps_max of Aluminim.
Hourglass energy-
Graph-
- Since we have used improved under integerated elements which is Ishell 24 (QEPH).
- So due to that there is no hourglass is noted.
Contact Energy-
Graph-
- Here in this case there is no contacts between deformable elements in plates.
- So we can see there is constant line in contact energy graph.
Total Energy-
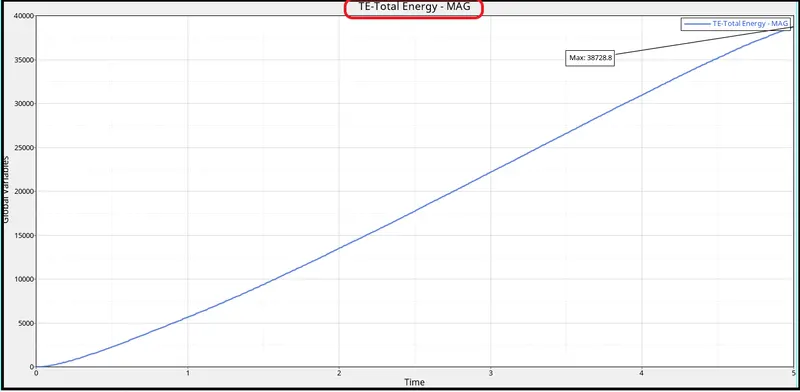
- Total energy is sum of all type of energy present here,Kinetic+Internal+contact+hourglass.
- It will follow the same pattern like internal energy.
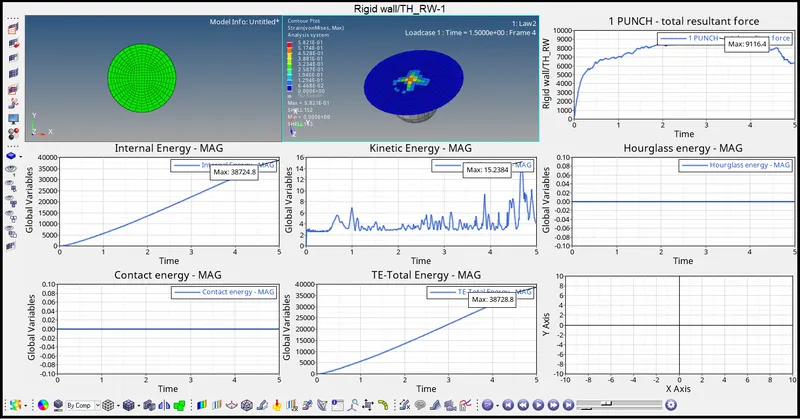
Combine Graph of all energies-
Case-5- Change the material card to Law1 with same E and rho value.
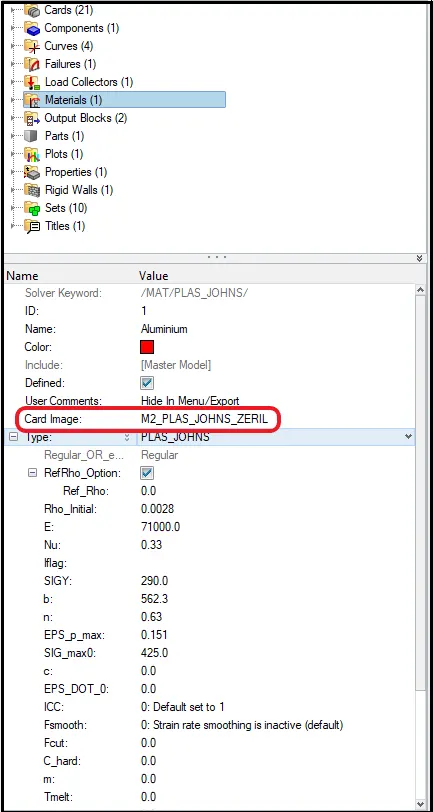
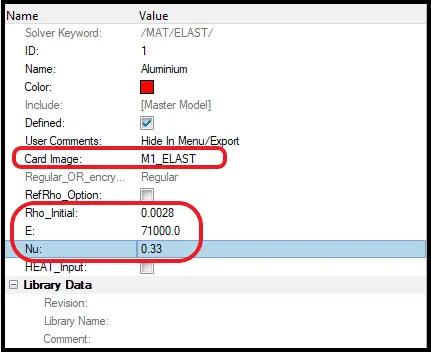
- Now run the simulation and save the radioss file as different case as case-5.
- After running the simulation we will get animation file, h3d file and also T01 file.
Check for file after simulation,
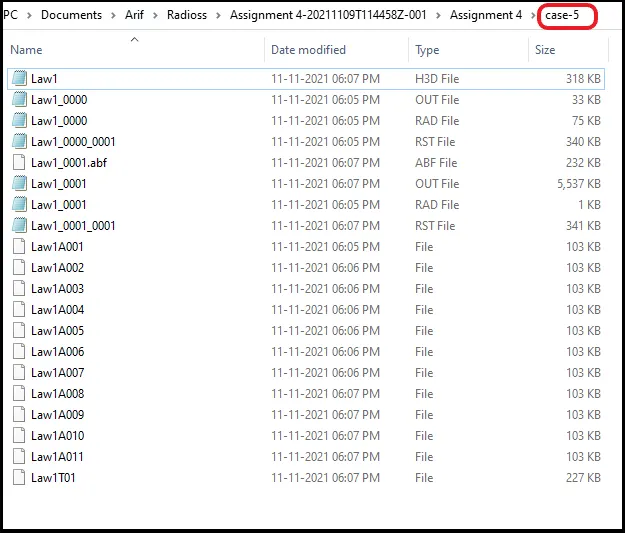
- Now we can see all files have been created.
- Now open 0001.out file and check all the details.
- Here we can see all variable in the out file about energy and mass loss also.
- So for checking the maximum loss check the last cycle details.
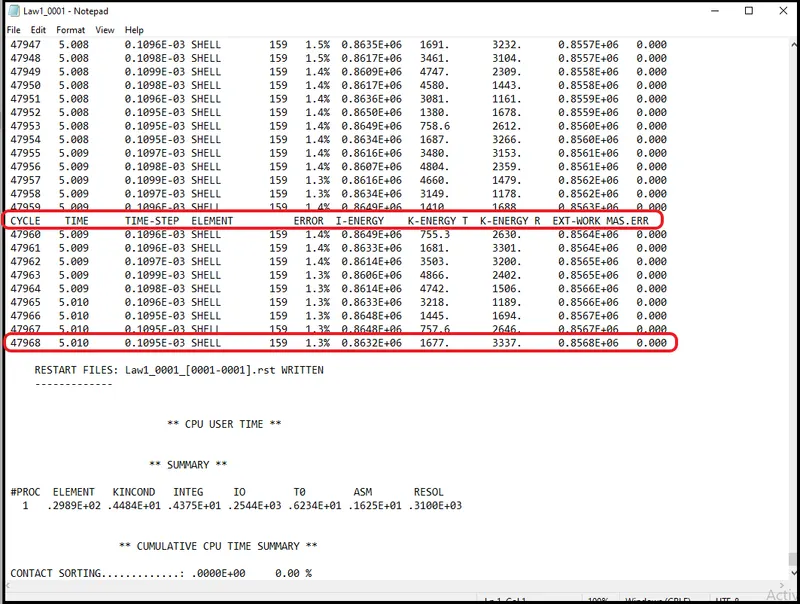
- Here in in last cycle of the simulation we have maximum energy losses where,
Energy error = 1.3 % Acceptable (Range is -15% to +5%)
Mass Error = 0 Acceptable (Range is 0 to 2%)
So the resultent energies are,
- Internal Energy 0.8632E+06
- Kinetic Energy 1677
- External work 0.8568E+06
- No of cycles 47968
Post processing-
- Review the simulation using Hyperview.
- Plot the graphs using Hypergraph-2D
1.Review the simulation using Hyperview.
- Now open the hyperview in 2nd window and upload h3d File there to see the simulation in hyperview.
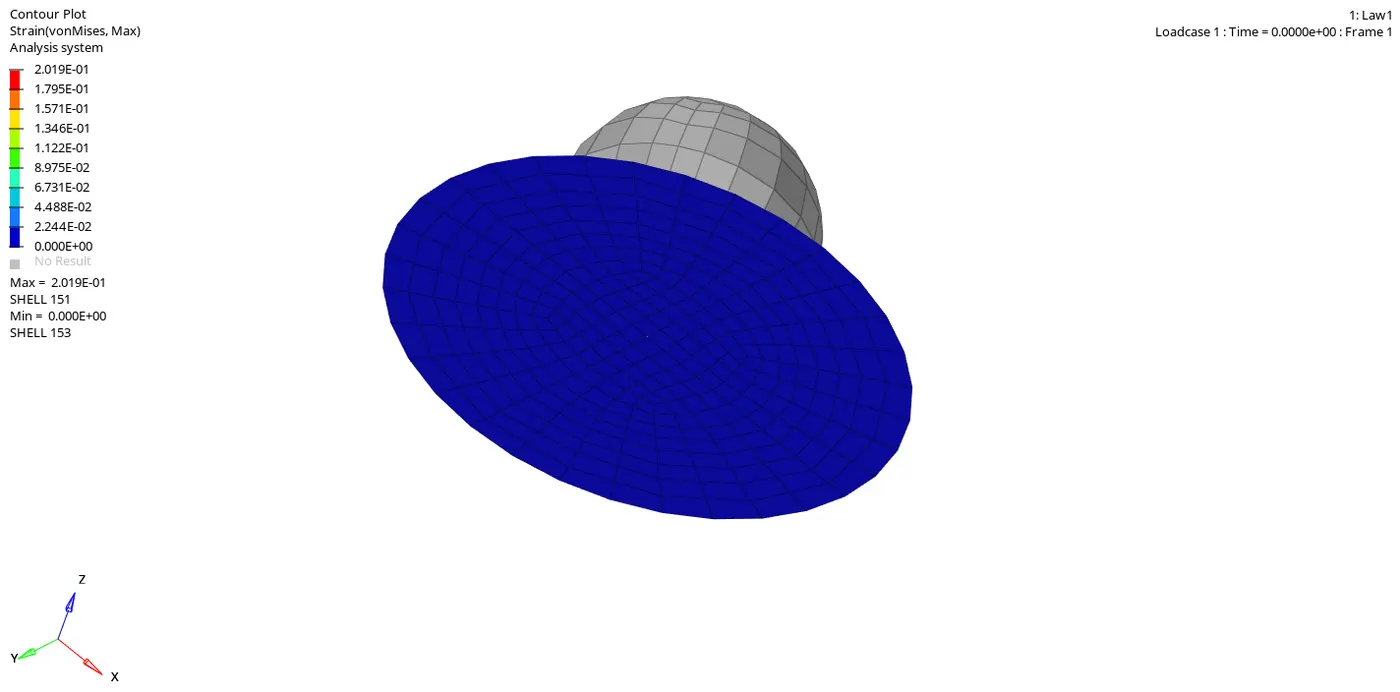
- Here in this case we had used Elastic Material with defined material property.
- So as animation we can see it will get elongated but elements will not delete because we have uses eleastic material.
- It reaches its Eps_max value 0.2019 noted.
2. Plot the graphs using Hypergraph-2D
- Now split the window in 3Part and open hypergraph-2D in new window.
- After opening the hypergraph windoe import the T01 file in Hypergraph.
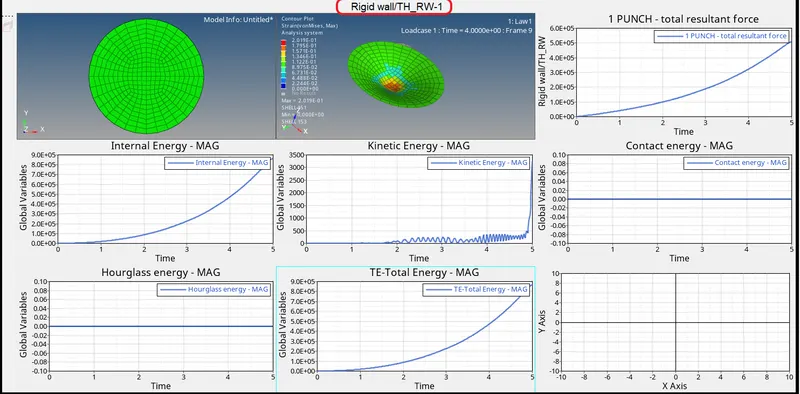
Rigid wall force Graph-
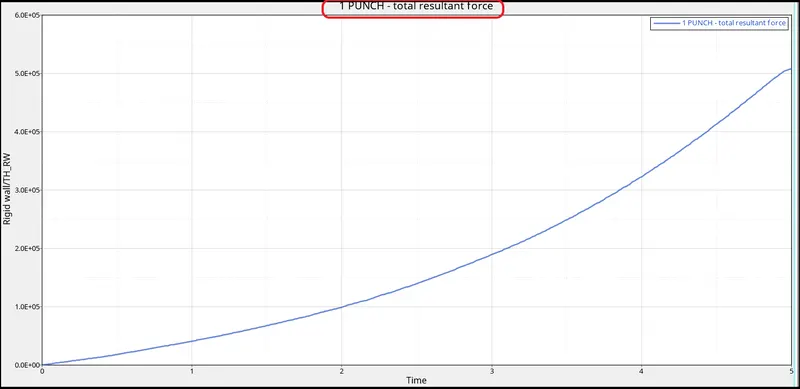
- In this case when ball hits the elastic plate there is gradual deformation take place but elements will not delete since it is eleastic material we had assigned.
- Since ball is collided to elastic plate so due to this a force is exerted by elements to the ball and that force will increase gradually
- Because element is not deleting and it will be always in contact so,as deformation is taking place in that way rigid wall force will also increase.
Internal Energy-
Graph-
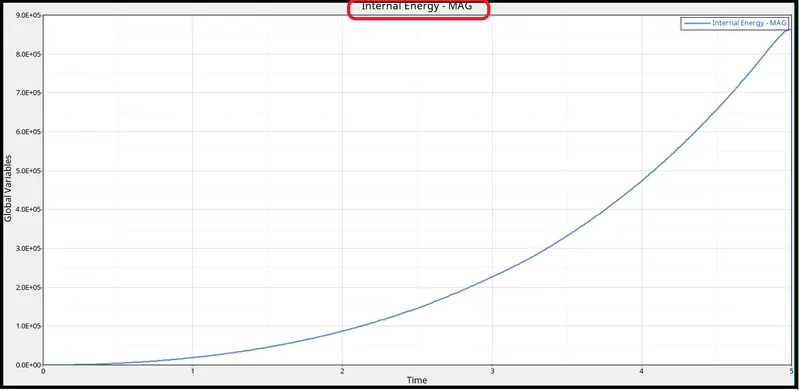
- In this case due to gradual deformation strain energy will also increase in same way.
- And that energy is internal energy stored in plate.
- Here elements are not breaking so it will keep increasing.
Kinetic Enrgy-
Graph-
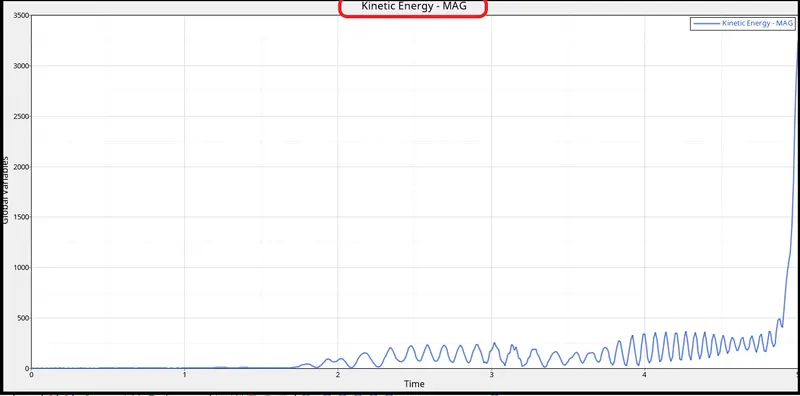
- Initially in this case kinetic energy of elements are less due to small deformation.
- But with respect to time deformation is taking place so that there is slight increament in kinetic energy we can see from graph.
- And it will end at higher value since deformation is keep increasing.
Hourglass energy-
Graph-
- Since we have used improved under integerated elements which is Ishell 24 (QEPH).
- So due to that there is no hourglass is noted.
Contact Energy-
Graph-
- Here in this case there is no contacts between deformable elements in plates.
- So we can see there is constant line in contact energy graph.
Total Energy-
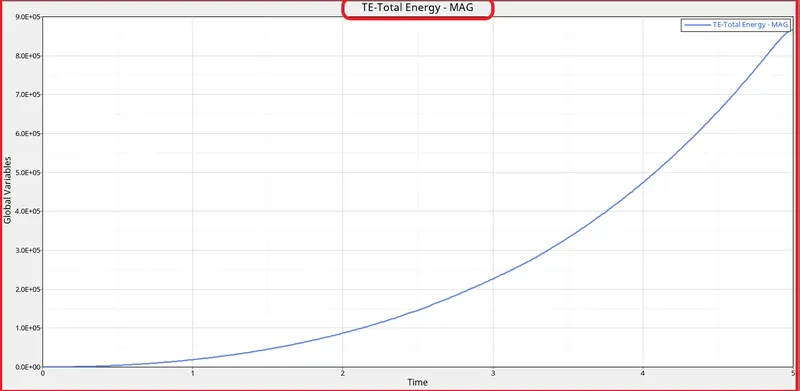
- Total energy is sum of all type of energy present here,Kinetic+Internal+contact+hourglass.
- It will follow the same pattern like internal energy.
Combine Graph of all energies-
Case-6- Change the material card to Law27
- Import Law27 0000.rad file and set the element formulation shell card as shown below.
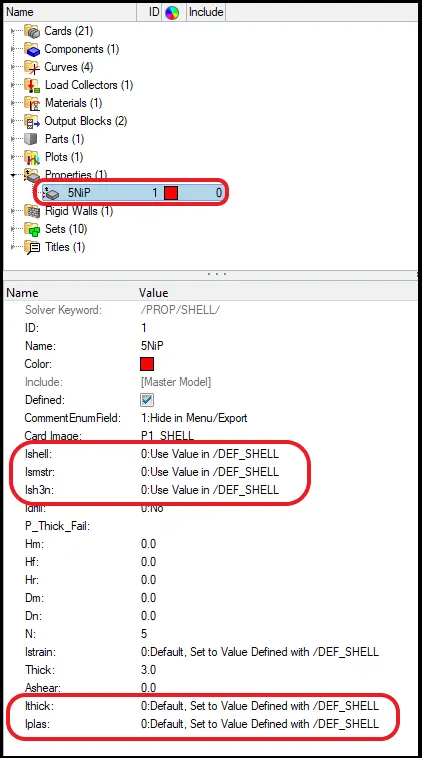
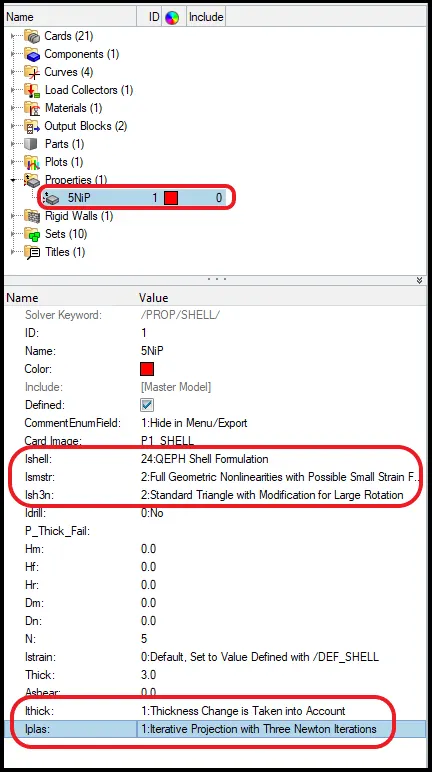
- Now run the simulation and save the radioss file as different case as case-6.
- After running the simulation we will get animation file, h3d file and also T01 file.
Check for file after simulation,
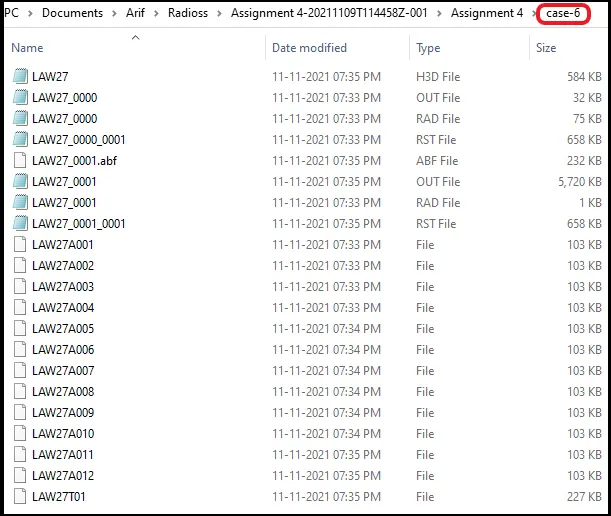
- Now we can see all files have been created.
- Now open 0001.out file and check all the details.
- Here we can see all variable in the out file about energy and mass loss also.
- So for checking the maximum loss check the last cycle details.
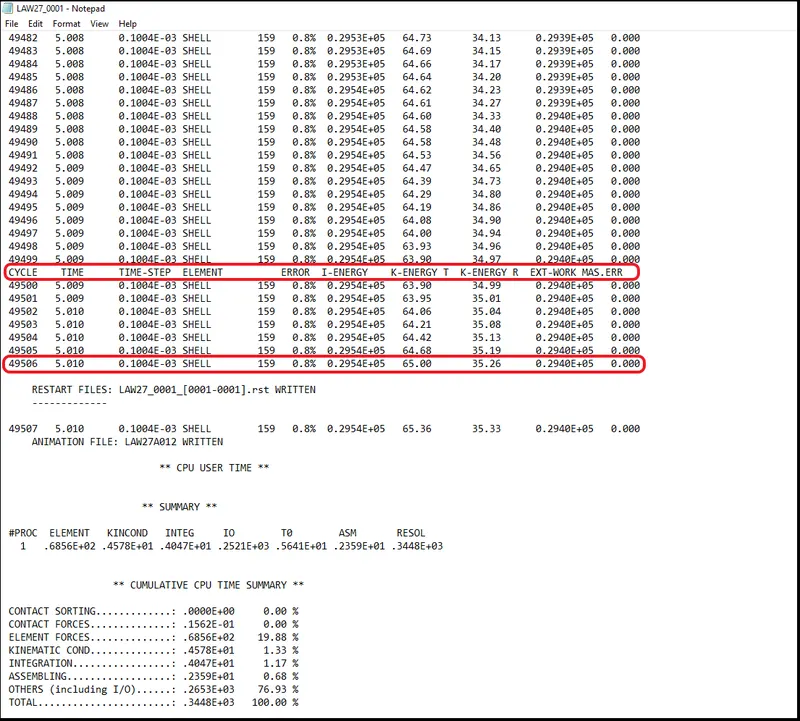
- Here in in last cycle of the simulation we have maximum energy losses where,
Energy error = 0.8 % Acceptable (Range is -15% to +5%)
Mass Error = 0 Acceptable (Range is 0 to 2%)
So the resultent energies are,
- Internal Energy 0.2954E+05
- Kinetic Energy 65
- External work 0.2940E+05
- No of cycles 49506
Post processing-
- Review the simulation using Hyperview.
- Plot the graphs using Hypergraph-2D
1.Review the simulation using Hyperview.
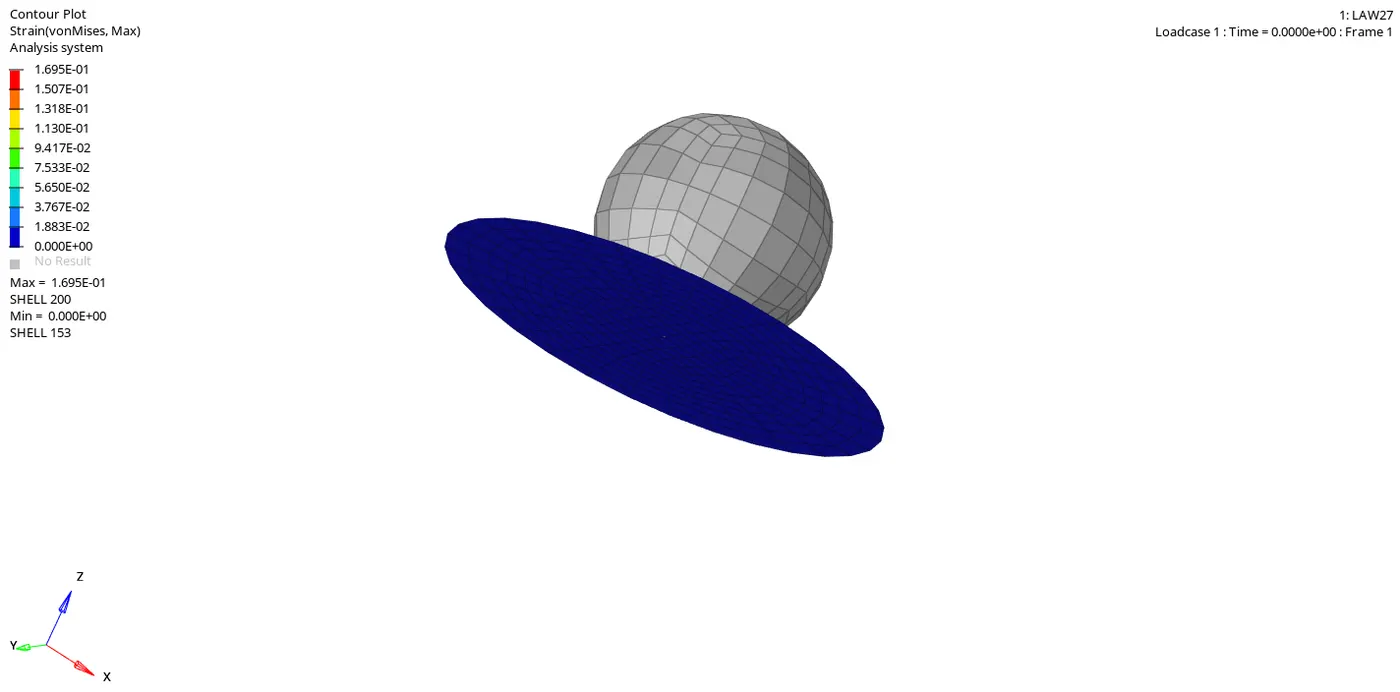
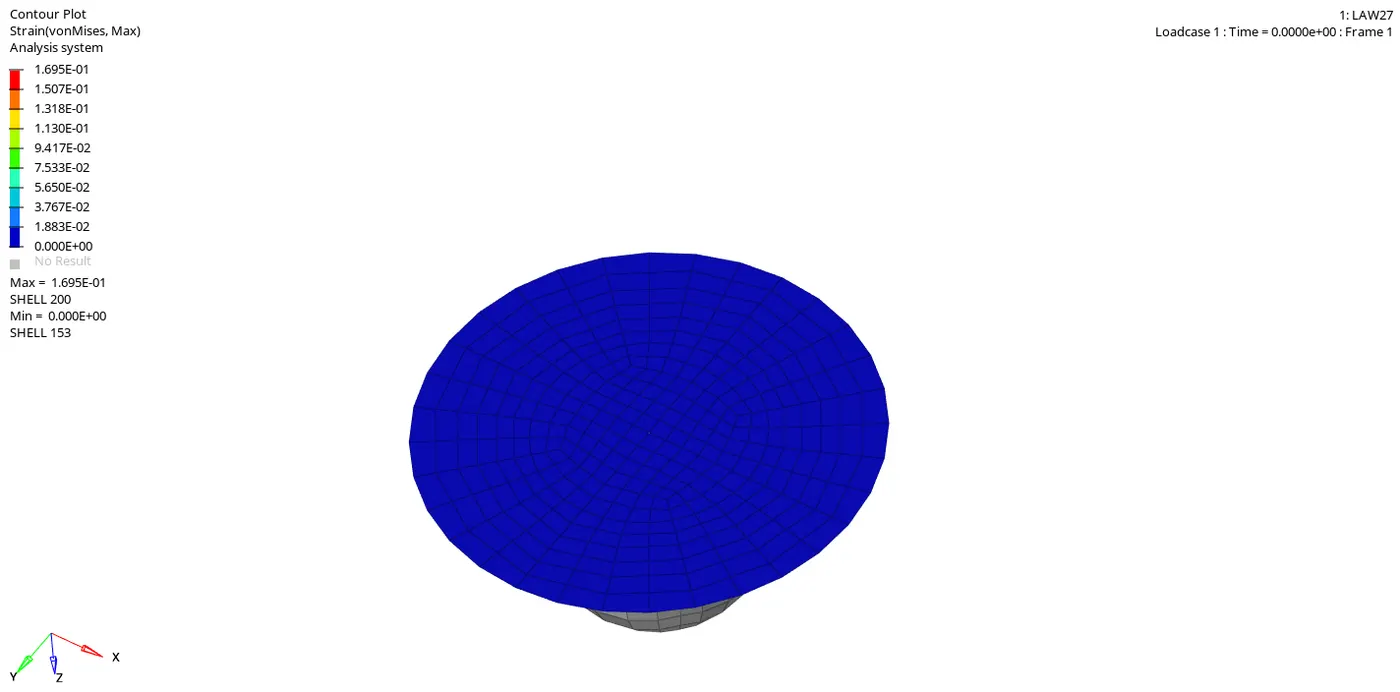
- Now open the hyperview in 2nd window and upload h3d File there to see the simulation in hyperview.
2. Plot the graphs using Hypergraph-2D
- Now split the window in 3Part and open hypergraph-2D in new window.
- After opening the hypergraph windoe import the T01 file in Hypergraph.
Rigid wall force Graph-
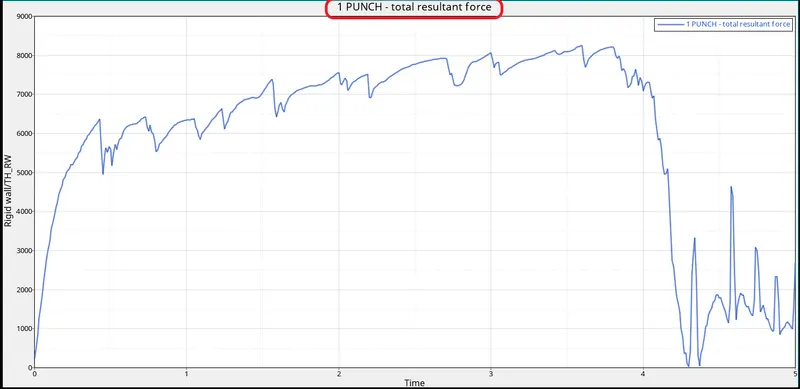
- In this also like perious cases elements will break after some time and can see a sudden drop in graph.
- After maximum strain point some material still in contact of ball so regid wall force act from those material as shown in graph.
Internal Energy-
Graph-
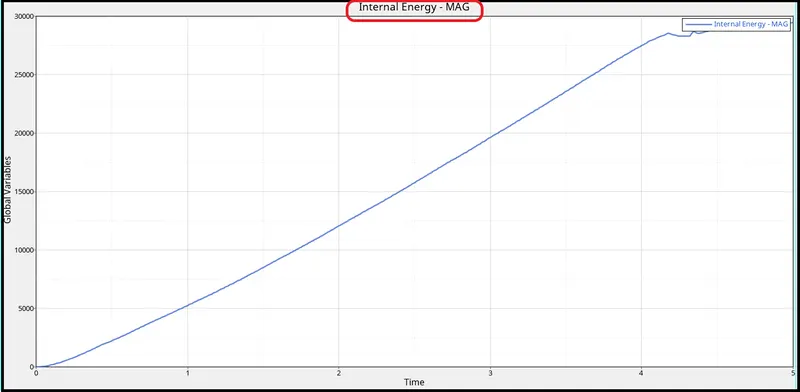
- Internal energy increase linearly and after maximum strain point it will get disturb due to material failure as shown above.
Kinetic Enrgy-
Graph-
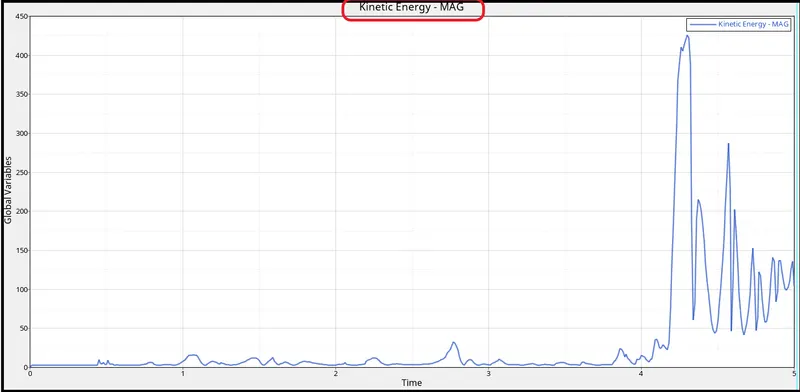
- Kinetic energy is slightly low initially and affter maximum strain point because till that point most of the energy getting absorbed as internal energy.
- After that elements are breaking and start moving away then that energy cinverted inti kinetic energy.
Hourglass energy-
Graph-
- Since we have used improved under integerated elements which is Ishell 24 (QEPH).
- So due to that there is no hourglass is noted.
Contact Energy-
Graph-
- Here in this case there is no contacts between deformable elements in plates.
- So we can see there is constant line in contact energy graph.
Total Energy-
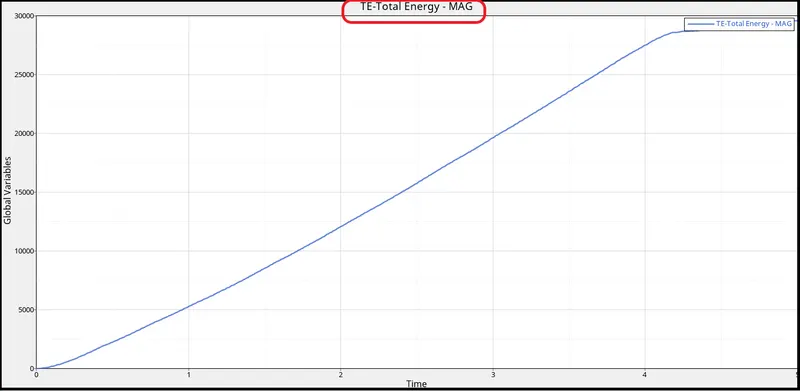
- Total energy is sum of all type of energy present here,Kinetic+Internal+contact+hourglass.
- It will follow the same pattern like internal energy.
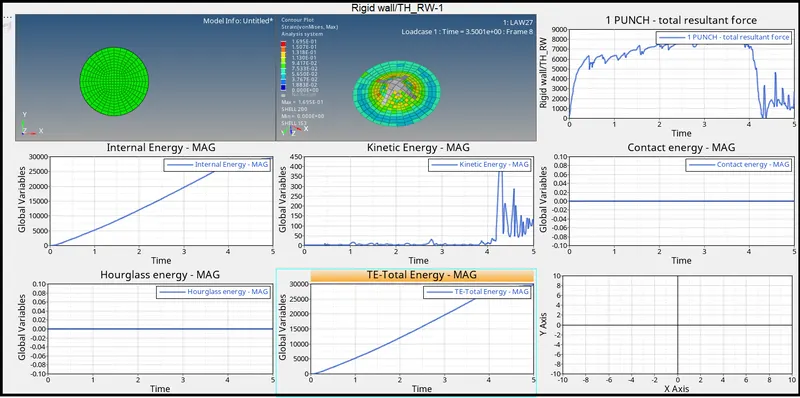
Combine Graph of all energies-
Case-7- Change the material card as Law36
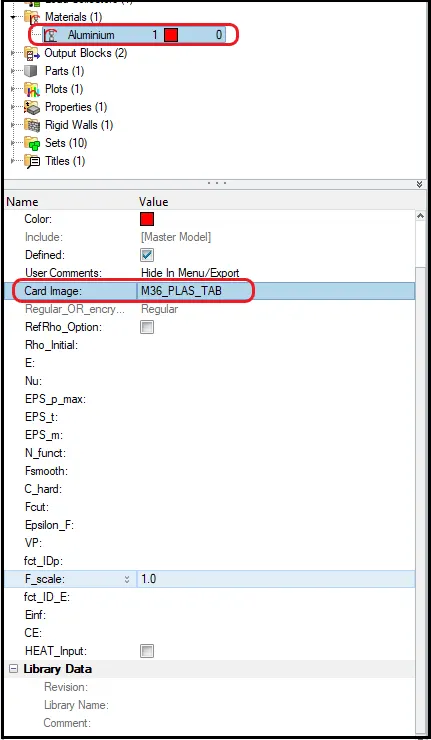
- After changing mat. card shell parameter wil also tunred to default.
- Now assign required shell parameter.
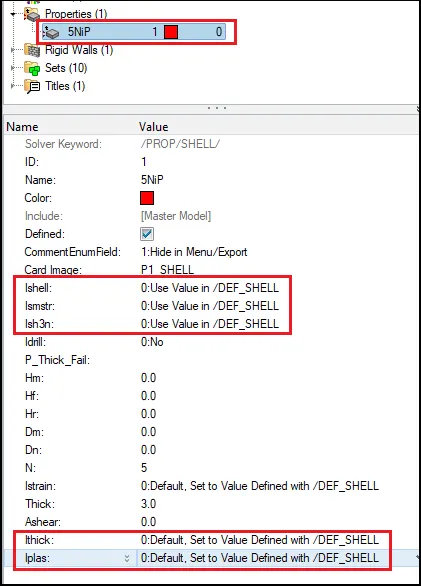
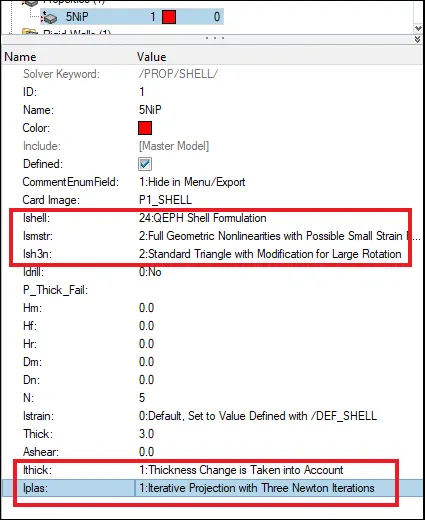
- Now set all the material property values according to mat card we have.
The mat. card given,
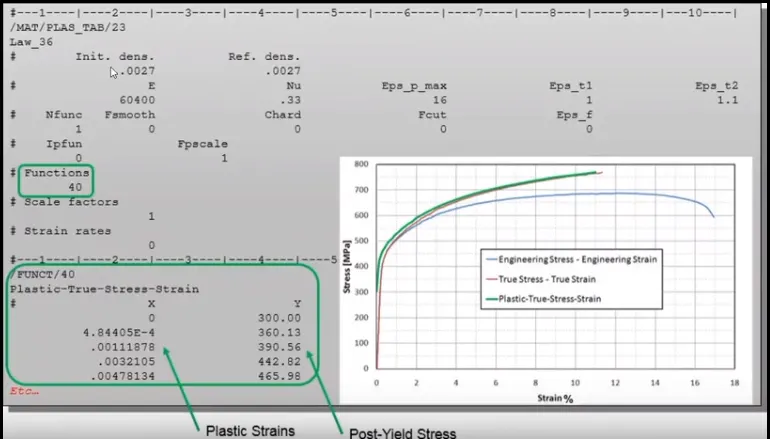
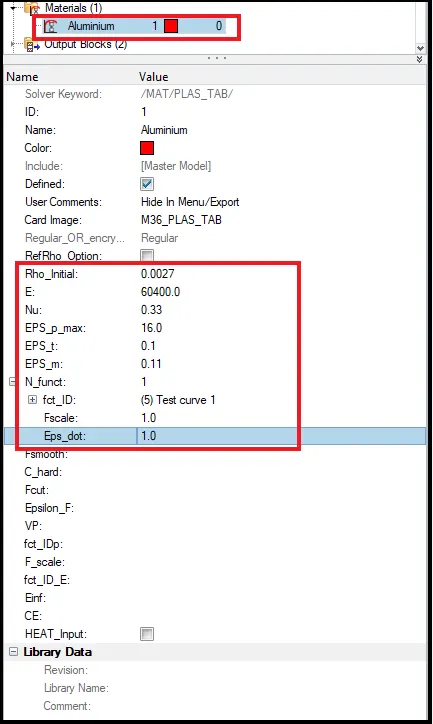
- After assigning the value for material property in mat. card.
- Now gor for create and plot a curve for stress strain for thus material.
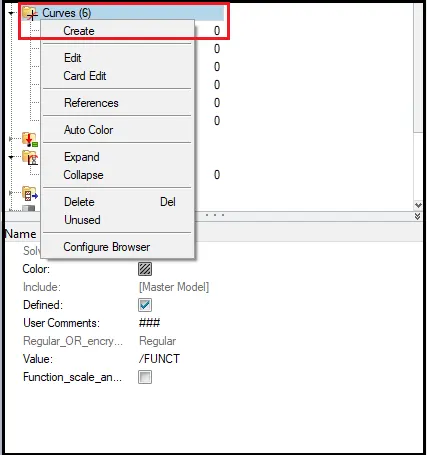
To create go to curve browser, right click and select curve and name a new curve as Test curve1.
- Since this material behaviour is dominating in strain region mainly so we will draw curve for that post yield region.
- We will put values manually for stress and strain according to that curve will start forming as shown below.
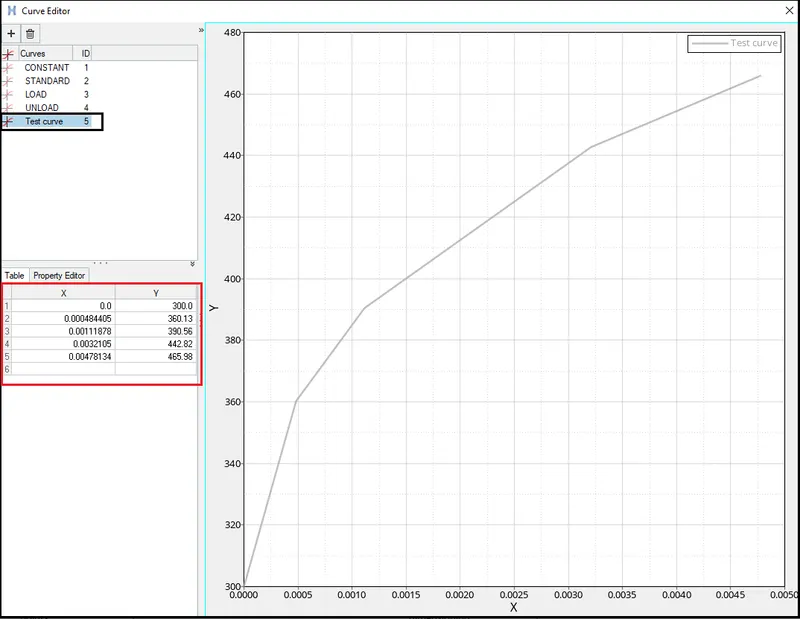
[Note- This curve defining in the plastic region only.]
- Now run the simulation after this and check for results.
- After running the simulation we will get animation file, h3d file and also T01 file.
Check for file after simulation,
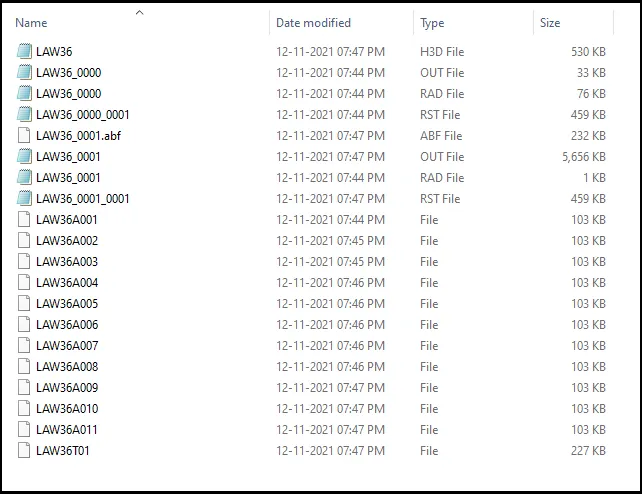
- Now we can see all files have been created.
- Now open 0001.out file and check all the details.
- Here we can see all variable in the out file about energy and mass loss also.
- So for checking the maximum loss check the last cycle details.
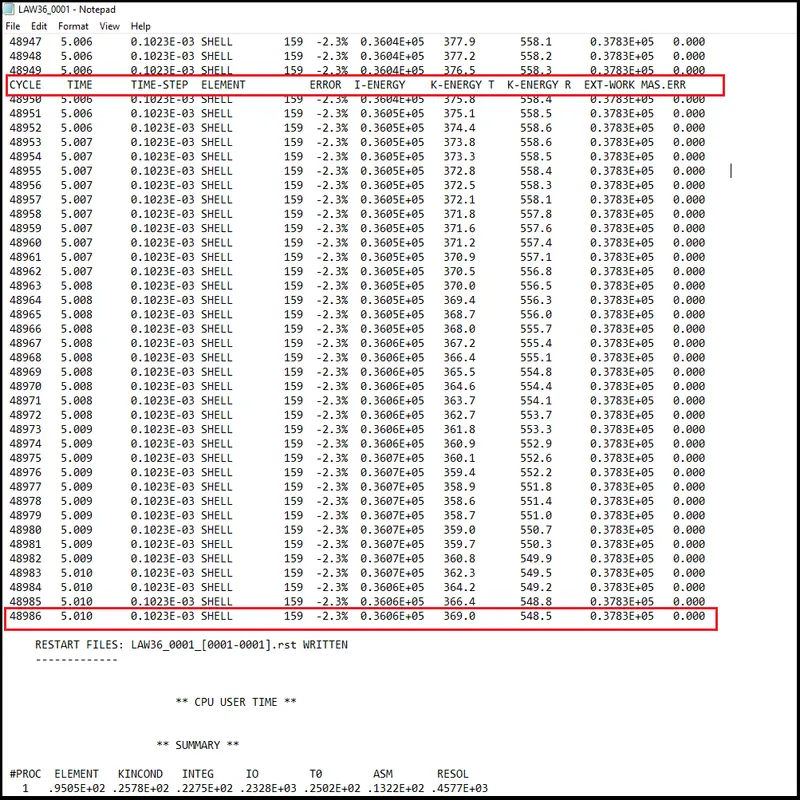
- Here in in last cycle of the simulation we have maximum energy losses where,
Energy error = -2.3 % Acceptable (Range is -15% to +5%)
Mass Error = 0 Acceptable (Range is 0 to 2%)
So the resultent energies are,
- Internal Energy 0.3606E+05
- Kinetic Energy 548.5
- External work 0.3783E+05
- No of cycles 48986
Post processing-
- Review the simulation using Hyperview.
- Plot the graphs using Hypergraph-2D
1.Review the simulation using Hyperview.
- Now open the hyperview in 2nd window and upload h3d File there to see the simulation in hyperview.
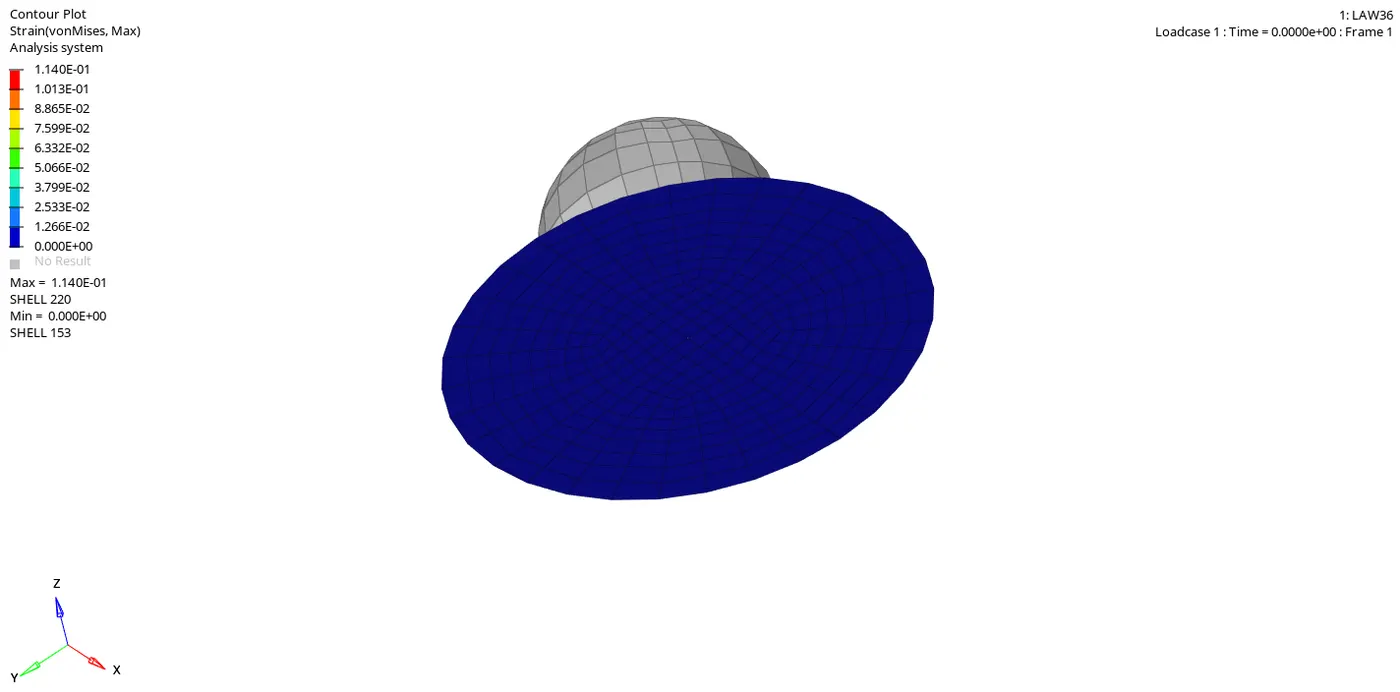
- Elemts will start deleteing when its reaches its maximum plastic strain value.
- Here maximum strain value shown of which material which is breaking,and present in above animation.
2. Plot the graphs using Hypergraph-2D
- Now split the window in 3Part and open hypergraph-2D in new window.
- After opening the hypergraph windoe import the T01 file in Hypergraph.
Rigid wall force Graph-
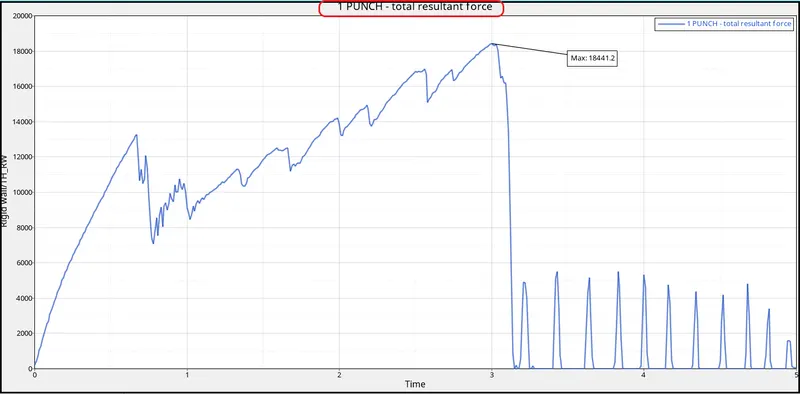
- Rigid wall force increase till point of maximum strain value cause till that point elements are in contact with rigid ball.
- After loosing contact rigid wall force drop down drastically cause most of the elements are break and moved away.
Internal Energy-
Graph-
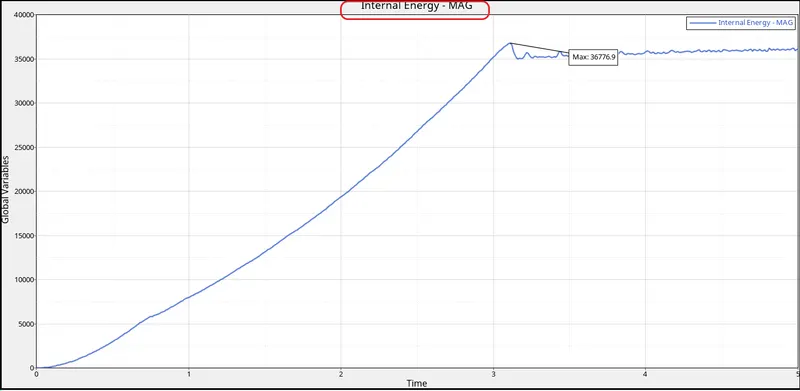
- Till plastic failure internal energy keep increasing as it store strain energy due to deformation of elements.
Kinetic Enrgy-
Graph-
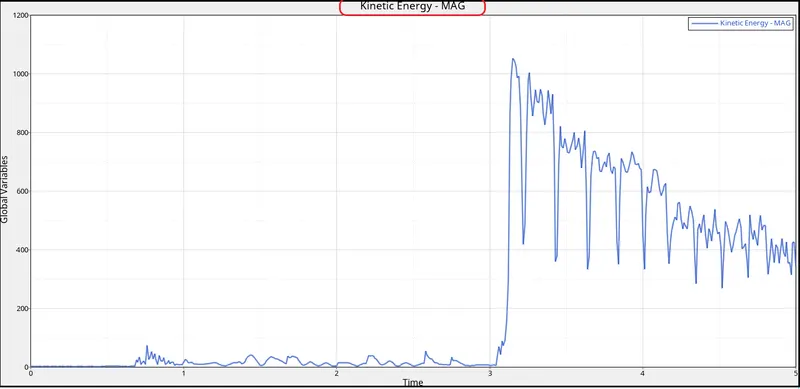
- Simmilarly in this case also most of the energy storing as internal energy till plastic failure.
- After that elements break and start moving away since elements already have internal energy and when it loos the contact and start moving away all internal energy start converting into kinetic energy.
Hourglass energy-
Graph-
- Since we have used improved under integerated elements which is Ishell 24 (QEPH).
- So due to that there is no hourglass is noted.
Contact Energy-
Graph-
- Here in this case there is no contacts between deformable elements in plates.
- So we can see there is constant line in contact energy graph.
Total Energy-
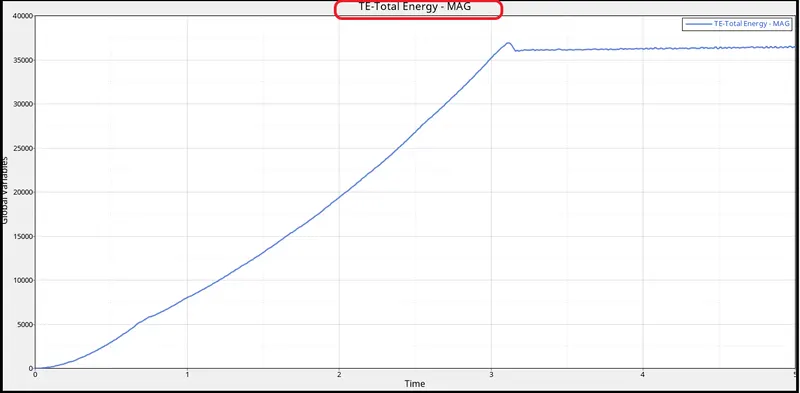
- Total energy is sum of all type of energy present here,Kinetic+Internal+contact+hourglass.
- It will follow the same pattern like internal energy.
Combine Graph of all energies-
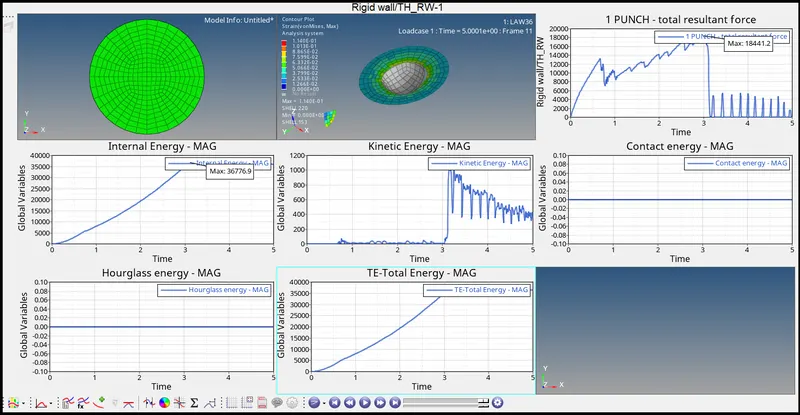
Comparision of all 7 cases-
Case-1
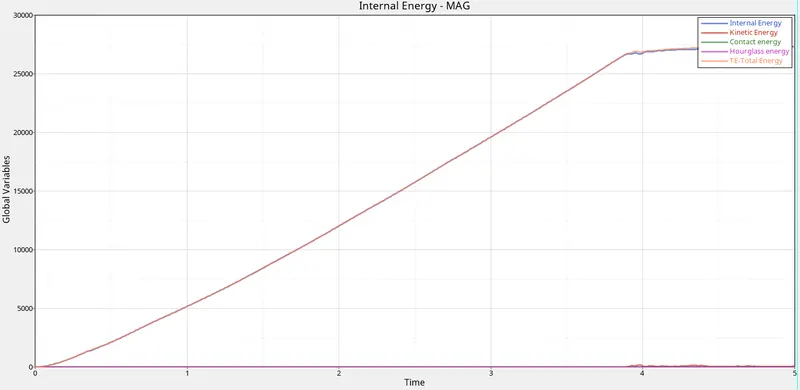
Case-2
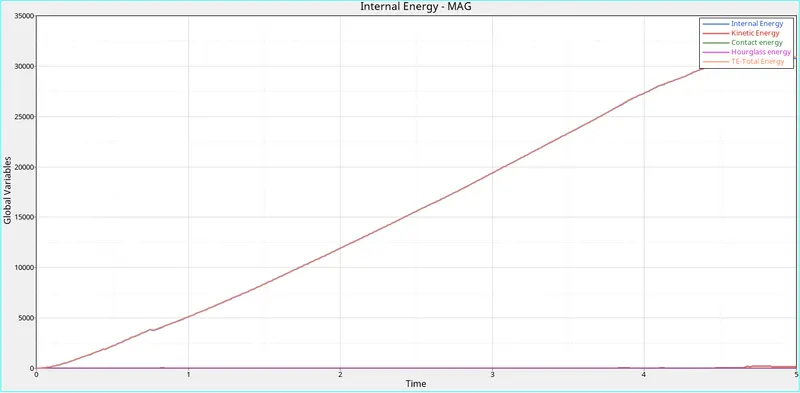
Case-3
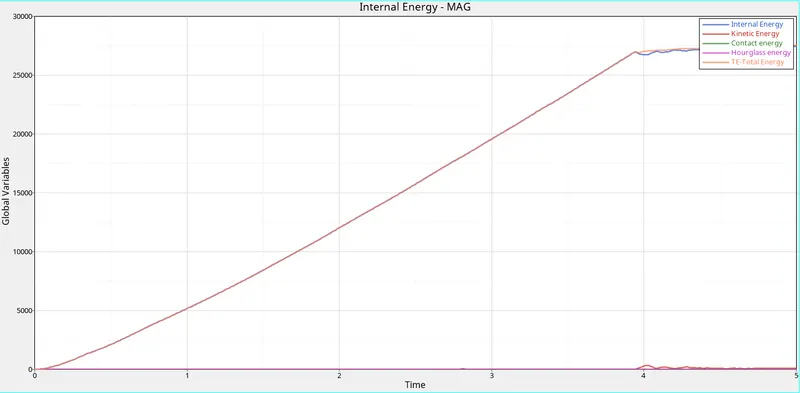
Case-4
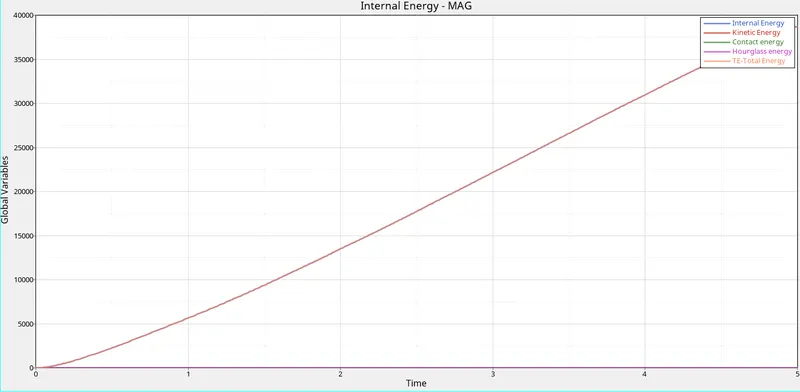
Case-5
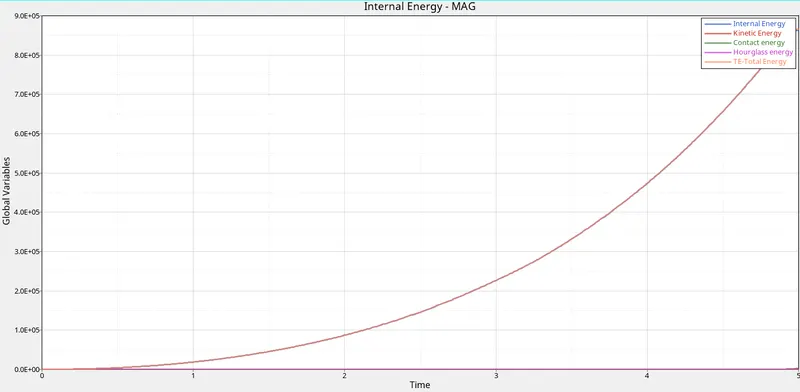
Case-6
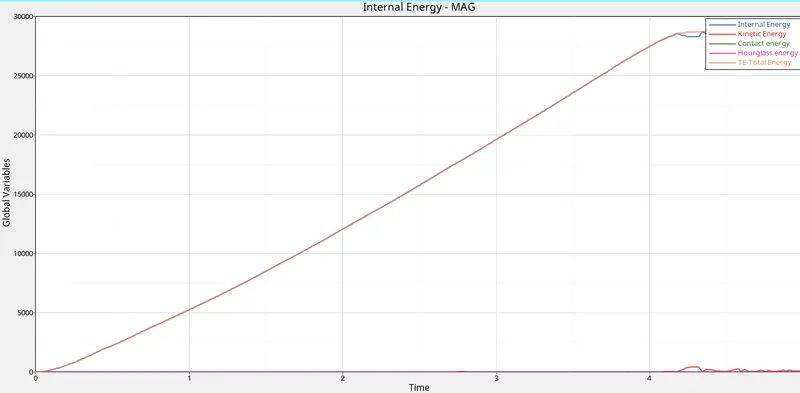
Case-7
| Cases | Energy error | Internal Energy | Kinetic Energy | External work | Mass Error | Elapsed time | Total no. of cycle | Material used | Chnged in material parameter | Element failure behavior |
| Case-1 | 0.8 % | 0.2730e+05 | 67.81 | 0.2721E+05 | 0.000 | 108.56 s | 49379 | Johnson cook [LAW2] | No change,Deafault shell parameters used and run. | Elements deleted |
| Case-2 | 4.1% | 0.3082E+05 | 141.9 | 0.2980E+05 | 0.000 | 111.06 s | 49216 | Johnson cook [LAW2] | change the value for lfail_sh,Dadv,Ixfem in failure card | Elements will crack and deleted |
| Case-3 | 0.8% | 0.2744E+05 | 87.08 | 0.2736E+05 | 0.000 | 108.32 s | 49407 | Johnson cook [LAW2] | Delete the failure card from the model browser. | Elements deleted |
| Case-4 | 1.1% | 0.3879E+05 | 3.931 | 0.3838E+05 | 0.000 | 109.95 s | 49303 | Johnson cook [LAW2] | Chnged the maximum plastic strain value (Eps_max=0) | Elements deformed then cracked but not deleted. |
| Case-5 | 1.3% | 0.8632E+06 | 1677. | 0.8568E+06 | 0.000 | 101.12 s | 47968 | Elastic material [Law1] | Change the material card to law1 and run with default parameter. | Elements deformed but not deleted. |
| Case-6 | 0.8% | 0.2954E+05 | 65.00 | 0.2940E+05 | 0.000 | 110.68 s | 49506 | Elasto plastic Brittle material [Law27] | Assign law27 and change the shell parameter.Also assign rapture parameter for elements. | Elements break and Deleted. |
| Case-7 | -2.3% | 0.3606E+05 | 369.0 | 0.3783E+05 | 0.000 | 104.24 s | 48986 | Elastic plastic Tabulated [Law36] | Created stress-strain using plastic strain and yield stress value.And also change shell parameters. | Elements break and deleted. |
Result-
- Assigned all type of quality failure and shell parameter for all cases.
- Runned all the seven cases mode successfully and all created file saved.
- Visualised all the model in hyperview.
- Plotted all the graphs in hypergraph-2D.
- Compared all the seven cases with thier results.
Learning Output and conclusion-
- In this challenge i learned,
- All type of material acrd and theri property.
- How to assign failure criteria for material.
- How deformation and rapture take place with different kind of paranmeter.
- Damage and rapture parameters for materials.
- How to draw stress strain curve in plastic region using plastic strain value and yield stress value, and due to this, Law36 makes very feasible and accurate methode for better output.