Week 9 - FVM Literature Review
FINITE VOLUME METHOD.
The finite volume method (FVM) is a method for representing and evaluating partial differential equations in the form of algebraic equations. In the finite volume method, volume integrals in a partial differential equation that contain a divergence term are converted to surface integrals, using the divergence theorem. These terms are then evaluated as fluxes at the surfaces of each finite volume. Because the flux entering a given volume is identical to that leaving the adjacent volume, these methods are conservative. Another advantage of the finite volume method is that it is easily formulated to allow for unstructured meshes. The method is used in many computational fluid dynamics packages. "Finite volume" refers to the small volume surrounding each node point on a mesh.
MAJOR DIFFERENCE BETWEEN FDM AND FVM.
A finite difference method (FDM) discretization is based upon the differential form of the PDE to be solved. Each derivative is replaced with an approximate difference formula (that can generally be derived from a Taylor series expansion). The computational domain is usually divided into hexahedral cells (the grid), and the solution will be obtained at each nodal point. The FDM is easiest to understand when the physical grid is Cartesian, but through the use of curvilinear transforms the method can be extended to domains that are not easily represented by brick-shaped elements. The discretization results in a system of the equation of the variable at nodal points, and once a solution is found, then we have a discrete representation of the solution.
A finite volume method (FVM) discretization is based upon an integral form of the PDE to be solved (e.g. conservation of mass, momentum, or energy). The PDE is written in a form which can be solved for a given finite volume (or cell). The computational domain is discretized into finite volumes and then for every volume, the governing equations are solved. The resulting system of equations usually involves fluxes of the conserved variable, and thus the calculation of fluxes is very important in FVM. The basic advantage of this method over FDM is it does not require the use of structured grids, and the effort to convert the given mesh into structured numerical grid internally is completely avoided. As with FDM, the resulting approximate solution is discrete, but the variables are typically placed at cell centres rather than at nodal points. This is not always true, as there are also face-centred finite volume methods. In any case, the values of field variables at non-storage locations (e.g. vertices) are obtained using interpolation.
INTERPOLATION SCHEMES.
The approximation of surface and volume integrals may require values of the variable at locations other than the computational nodes of the CV. Values at these locations are obtained using interpolation formulae.
UPWIND INTERPOLATION SCHEME.
The upwind interpolation (UDS) for approximating the value of a variable at the east face of a control volume is given by
`f_e={((f_P),if,(v*n),>,0),((f_E),if,(v*n),<,0):}`
This interpolation scheme is equivalent to using a backward or forward finite difference approximation (depending on the flow direction). It is first-order accurate, and is numerically diffusive with a coefficient of numerical diffusion `I_e^(Num)=((rho*u)_e*Deltax)/2`
LINEAR INTERPOLATION SCHEME.
We can approximate the value of the variable at CV face centre by linear interpolation of the values at two nearest computational nodes. Thus, at location ‘e’ on a Cartesian grid, the variable value is approximated by
`f_e=f_E*lambda_e+f_p(1-lambda_e),` `lambda_e=(x_e-x_P)/(x_E-x_p)`
The linear interpolation is equivalent to the use of the central difference formula of the first-order derivative, and hence, this scheme is also termed as the central difference scheme (CDS). This scheme is second-order accurate and may produce oscillatory solutions.
QUADRATIC UPWIND INTERPOLATION(QUICK).
A quadratic upwind interpolation (QUICK) scheme can be derived using polynomial fitting. The QUICK interpolation on a uniform Cartesian grid is given by
`phi_e=(6)/8*phi_U+(3)/8*phi_D-(1)/8*phi_(UU)`
where D, U and UU denote the downstream, the first upstream and the second upstream node respectively (E, P, and W or P, E and EE depending on the flow direction). The QUICK scheme is third-order accurate, but prone to oscillations.
FLUX LIMITERS.
Flux limiters are used in the high-resolution scheme – numerical schemes used to solve problems in science and engineering, particularly fluid dynamics, described by partial differential equations(PDE's). They are used in high-resolution schemes, such as the MUSCL scheme, to avoid the spurious oscillations (wiggles) that would otherwise occur with high order spatial discretization schemes due to shocks, discontinuities or sharp changes in the solution domain. Use of flux limiters, together with an appropriate high-resolution scheme, make the solutions total variation diminishing (TVD).
Note that flux limiters are also referred to as slope limiters because they both have the same mathematical form, and both have the effect of limiting the solution gradient near shocks or discontinuities. In general, the term flux limiter is used when the limiter acts on system fluxes, and slope limiter is used when the limiter acts on system states (like pressure, velocity etc.).
The main idea behind the construction of flux limiter schemes is to limit the spatial derivatives to realistic values – for scientific and engineering problems this usually means physically realisable and meaningful values. They are used in high-resolution scheme for solving problems described by PDEs and only come into operation when sharp wave fronts are present. For smoothly changing waves, the flux limiters do not operate, and the spatial derivatives can be represented by higher-order approximations without introducing spurious oscillations. Consider the 1D semi-descrete scheme below,
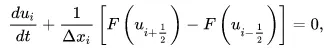
where
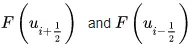
represent edge fluxes for the ith cell. If these edge fluxes can be represented by low and high-resolution schemes, then a flux limiter can switch between these schemes depending upon the gradients close to the particular cell, as follows,
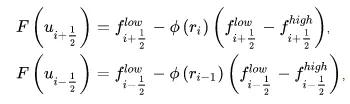
where
`f^(low)="low resolution flux"`
`f^(high)="high resolution flux"`
`phi(r)="flux limiter function"`
and 'r' represents the ratio of successive gradients on the solution mesh, i.e.,
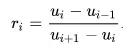
The limiter function is constrained to be greater than or equal to zero, i.e., `phi(r)ge0`. Therefore, when the limiter is equal to zero (sharp gradient, opposite slopes or zero gradients), the flux is represented by a low-resolution scheme. Similarly, when the limiter is equal to 1 (smooth solution), it is represented by a high-resolution scheme. The various limiters have differing switching characteristics and are selected according to the particular problem and solution scheme. No particular limiter has been found to work well for all problems, and a particular choice is usually made on a trial and error basis