Week 8 Worm Gear Challenge
Objective:
The aim of this challenge is to simulate the working of a worm-gear mechanism and find out the stress, total deformation and the equivalent strain for the model.
Case setup and execution:
First the transient structural module was opened. The geometry was imported.
The geometry was edited in Spaceclaim to cut the gear in half. To od this, the face on the side of the gear was selected and a sufficiently big rectangle was sketched. Then the pull option was used to cut the gear in half.
Then the model was opened in Ansys Mechanical. First the respective parts were renamed as worm and gear.
Then the existing contact was modified to the include more teeth of the gear in the contact. It was made frictionless. Rest of the parameters of the contact were kept unchanged.
By right-clicking on Connections - Insert - Joint path, a revolute body-to-ground joint for both worm and the gear each was defined.
It was made sure that the axes of all these joints are aligned as per the motion described in the definition of these joints.
Then the mesh was provided with the default size. The adaptive sizing was turned on.
In the analysis settings 15 steps were chosen. The solver and weak springs were program controlled. The Large deflection was turned on. In output controls, all the parameters were changed to Yes. For all the steps minimum timestep of 0.2 sec and maximum timstep of 0.5 sec was used. For first timestep initial timestep was 0.2 sec and for rest of the steps, carry over time step was used.
The revolute joint on the worm was given the joint-load for rotation in 15 steps of 50 degrees each.
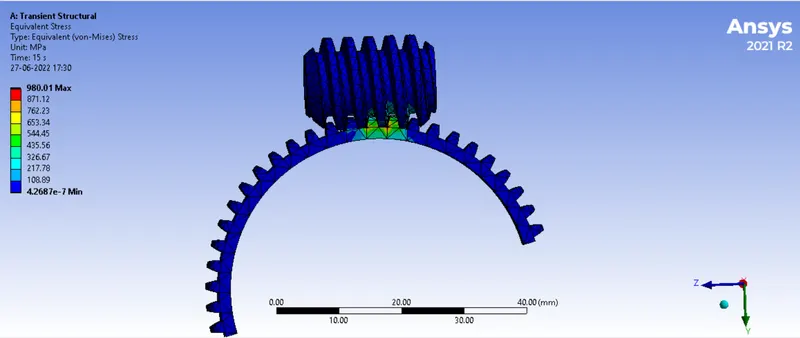
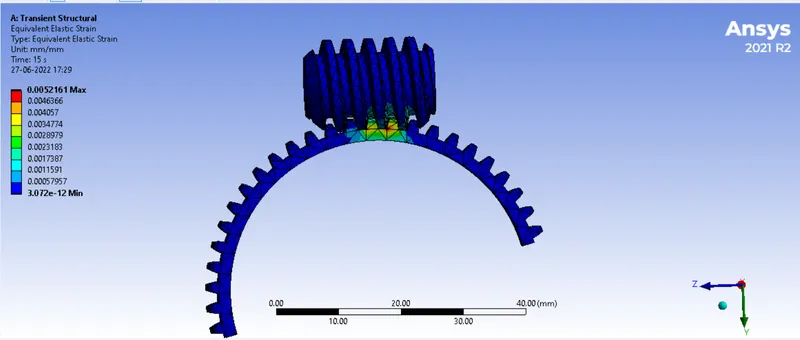
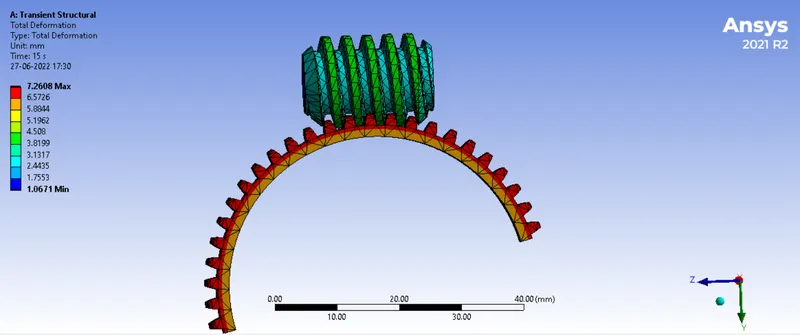
The output was requested for the total deformation, equivalent stress and equivalent strain.
The model was run. It ran smoothly with normal termination.
Results:
Animation
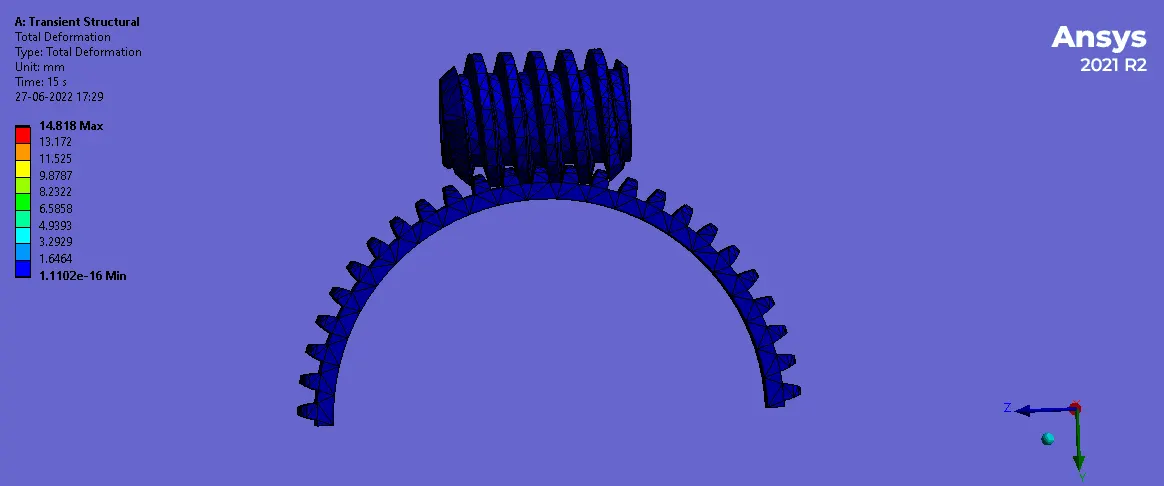
Equivalent stress
Equivalent elastic strain
Total deformation
Conclusion:
Thus, the model ram smoothly and it provided the results as : Total deformation = 7.2608 mm, Equivalent stress = 980.01 MPa and equivalent strain = 0.0052161. The simulation files are attached in the zip format.