Week 8:- 3D Finishing - Challenges 1
Challenge-8 week-8 3D Finishing Challenge-1
Q1. What do you understand by 3D finish process?
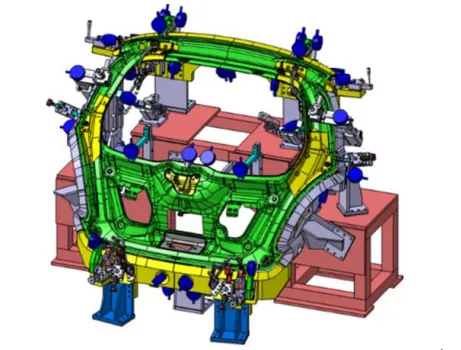
The 3D finish is the process by which a design is completely finished and ready for final simulation and 2D detailing, as shown in the figure below. While finishing
the design, the nominality of each unit and hole is checked to ensure that all units can be easily assembled. The concentricity and size of the holes should be checked to ensure that the various parts can be easily assembled. Fasteners are implemented based on hole size, and standard color codes based on customer requirements for differentiate type of hole/part. Standard hole colors are violet for a simple hole, yellow for a threaded hole, cream for a machined area, and blue for a dowel pin hole. After completing all of the preceding steps, the model is sent for simulation and 2D detailing.
Q2. What are the points need to be taken care of while finishing the design?
• Proper renaming of parts/ assemblies: Proper renaming of parts & assemblies should be done while finishing the design hence we can identify each and every part easily with unique identification.
• Nominality : All unit dimensions should be maintained nominal to facilitate easy assembly of the unit from a fixed edge.
• Hole concentricity & hole sizes: All parts are to be checked for hole concentricity and to be confirmed for easy assembly while finishing the parts.
• Machining area: The machining area in every part should be defined and the machining area should be highlighted by using standard color code.
• Gaps checking: Proper gap should be maintained between units to avoid the clash between the different units.
• Fasteners implementation: Fasteners should be implemented in all unit as per the requirement and load on the part.
Q3. What are rough locators & what is their use?
A rough locator is a part that instructs the operator on where to place the car panel on the pins. A rough locator can be either a standard or a custom part. Rough
locators are used in the automation process to help locate workpieces. The desired location where you want the workpiece to be when it is being worked on by a person, team, or robot is referred to as "locating."
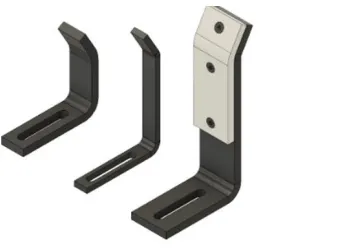
Uses of rough locators:
• Rough locators aid in the location of workpieces during the automation process. Locating refers to the desired location of the workpiece when it is being worked on by a person, team, or robot.
• The uniformity and quality of the finished product are directly affected by the precision of the locating components. This is why these elements are critical to your setup.
• It can also be referred to as a fool proofing method. Because the rough locator prevents the part from being loaded in the improper place. Because the rough locators are set based on the angle of the relevant panel, the part can only be loaded in the specified direction and orientation.
Q4. What are the points you need to consider while designing a rough locator?
• Rough locator should be placed at the edges of the car panel, which it has to guide.
• Rough locator has to be placed in the same angle of the car part edge with a minimum distance of 2-5 mm from the edge of the car part.
• Rough locator should guide the panel in pin arresting direction.
• Rough locator should guide the panel before 10-15mm to the start of the pin engagement.
• Rough locator should be designed with two slots to mount the easy adjustments.
• The slots should be in the direction of car part guiding.
Q5. What is the gun study process?
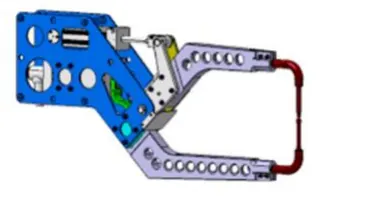
Welding is a procedure that is commonly employed in the vehicle sector, and the requirements for the welding process are a continual development effort in any industry. Car Body-in-White (BIW) is a complicated/complex construction that is assembled through welding. The first step before beginning the design of a welding fixture is to determine the placement of the spot welds. The location and orientation of the fixture's other important units, such as clamps and locators, are determined by the weld spot distribution. The below figure depicts the weld gun used for spot welding, as well as the weld matrix and weld position where the welding will take place. There will be two kinds of weld spots: geo weld points and respot weld points. The geo weld spots are welded in the first stretch, and the respot welded points are welded in the second stretch. Gun study entails studying the weld gun, which is a portable equipment for semiautomatic welding of parts/components that will be utilised for the operation depending on the size of the part, thickness of the part, and so on. If the weld gun fall to the fixture unit then redesigning of that unit or the repositioning of that unit is done and again confirmed whether the gun is falling or not.
Q6. What are the points need to consider during the gun study?
Weld gun study is very important process and presented below:
The total time required to complete all of the weld spots is determined by the number of weld spots on the panel and the time required to spot each weld. The weld spot's axis along the welding direction must be normal to the weld surface. If we have one or more device models and want to programme them, we can mimic the behaviour of each model in the work cell over time. Sequences are used to code instructions for each device.
The motion, manipulation, and operation of the devices are defined by the sequence. Cycle time for each device associated with sequences can be calculated based on the distance of each tag point from the home location, motion type, speed, and acceleration. The robot cycle time is properly computed in this manner. After all of the devices have been sequenced, a simulation is conducted with " collision check " enabled to ensure that the welding procedure is collision free.
Q7. What is pneumatic routing?
Pneumatic systems should be leak-free and efficient. Sometimes they aren't because of incorrect tube line routing caused by either a lack of understanding or cutting cuts on planning time, or both. Planning tube line routing takes time, but it can pay off handsomely, especially in complicated systems. Routing should be developed as the next step in system design after sizing the tube line and selecting the necessary fittings. Routing should be designed with clamping in mind. Appropriate design logically leads to proper clamming. Several lines can frequently be clamped together. Consider troubleshooting and maintenance: focus on logical design and avoid crossed lines. Design the tube line routing to minimize the possibility of users standing or climbing on plumbing.
Q8. What is the solenoid valve?
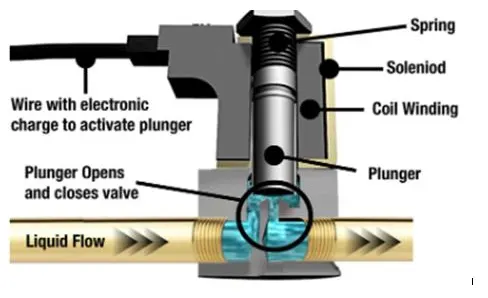
The function of a solenoid valve is to open or close an aperture in a valve body, allowing or preventing flow through the valve. By activating the coil, a plunger opens or closes the aperture by raising or lowering it within a sleeve tube. Solenoid valves are made up of a coil, plunger, and sleeve assembly, as shown in the figure below. An electromechanical valve is a solenoid valve. The characteristics of the electric current they employ, the strength or magnetic field they generate, the mechanism they use to regulate the fluid, and the type and properties of fluid they control all differ amongst solenoid valves. Linear action, plunger-type actuators, pivoted-armature actuators, and rocker actuators are all examples of mechanisms. On a manifold, multiple solenoid valves can be grouped together. Solenoid valves are the most commonly used control elements in fluidics; their functions include shutting off, releasing, dosing, distributing, and mixing fluids. Solenoids provide fast and safe switching, high reliability, long service life, medium compatibility of the materials used, minimal control power, and a compact design.
Q9. What is the valve bank?
A valve bank is a collection of solenoid valves. The valve bank will have a common inlet port, a single servo line to each pneumatic valve, and separate vent channels for each solenoid. A valve bank is a collection of separate valves used to operate independent consumers. Compact control blocks can be assembled using these parts. The valve is activated by selectively energizing the matching solenoid, allowing servo air to enter the valve's servo port. To return the valve to its fail-safe position, the solenoid is de-energized by venting the valve's servo port to ambient. The design architecture enables the simple selection of two to six solenoid valves.
Q10.What is sensor & brief about its application in automobile?
A sensor is a device that detects or measures a physical property and records, indicates, or responds to it in some other way. The signal from the sensors is sent
to the PLC, which then executes the following operation. Because the sensor is an extremely sensitive and easily damaged component, a sensor cover is supplied for
its protection.
Sensors play a critical part in the industrial automation segment, allowing products to be intelligent and highly automated. These enable one to detect, evaluate, measure, and process numerous changes that occur in manufacturing sites, such as changes in position, length, height, appearance, and displacement. These sensors
also play a key role in anticipating and averting numerous future events, meeting the needs of a wide range of sensing applications.
Q11.What are the types of the sensors?
The following is a list of different types of sensors that are commonly used in various applications:
Temperature sensor Proximity sensor
Accelerometer IR sensor (Infrared sensor)
Pressure sensor Light sensor
Colour sensor Humidity sensor
Tilt sensor Flow and level sensor
Q12.What are the fundamental points that need to be consider while designing or selection of sensors?
The fundamental points to be considered while designing of sensor are:
- Sensors should provide safety to the operator.
- The sensor unit is a unit that uses electrical sensors to sense the automobile panel.The signal from the sensors will be transmitted to the PLC, and this signal will be used to run the following step. Sensors are used to determine whether or not a panel or component is present. It should aid in avoiding human error.
- Ideally, the number of sensors should be equal. In comparison to the number of panels in an assembly, for example, if 14 panels are in an assembly, at least 14 sensors should be employed.
- Sensors should be constructed in such a way that they may be changed in three directions.
*********************************************************************EOP**************************************************************