Week 7 State of charge estimation
Week 7 Challenge
Aim
1. Simulate the 3 test cases from the harness dashboard and write a detailed report on the results
2. What is coulomb counting? Refer to the above model and explain how BMS implements coulomb counting for SOC estimation.
============================================================================
1. Simulate the 3 test cases from the harness dashboard and write a detailed report on the results.
Battery Management System
Battery management system (BMS) is technology dedicated to the oversight of a battery pack, which is an assembly of battery cells, electrically organized in a row x column matrix configuration to enable the delivery of a targeted range of voltage and current for a duration of time against expected load scenarios.
The oversight that a BMS provides usually includes:
- Monitoring the battery
- Providing battery protection
- Estimating the battery’s operational state
- Continually optimizing battery performance
- Reporting operational status to external devices
Here, the term “battery” implies the entire pack; however, the monitoring and control functions are specifically applied to individual cells, or groups of cells called modules in the overall battery pack assembly. Lithium-ion rechargeable cells have the highest energy density and are the standard choice for battery packs for many consumer products, from laptops to electric vehicles. While they perform superbly, they can be rather unforgiving if operated outside a generally tight safe operating area (SOA), with outcomes ranging from compromising the battery performance to outright dangerous consequences. The BMS certainly has a challenging job description, and its overall complexity and oversight outreach may span many disciplines such as electrical, digital, control, thermal, and hydraulic.
How do battery management systems work?
Battery management systems do not have a fixed or unique set of criteria that must be adopted. The technology design scope and implemented features generally correlate with:
- The costs, complexity, and size of the battery pack
- Application of the battery and any safety, lifespan, and warranty concerns
- Certification requirements from various government regulations where costs and penalties are paramount if inadequate functional safety measures are in place
There are many BMS design features, with battery pack protection management and capacity management being two essential features. We’ll discuss how these two features work here. Battery pack protection management has two key areas: electrical protection, which implies not allowing the battery to be damaged via usage outside its SOA, and thermal protection, which involves passive and/or active temperature control to maintain or bring the pack into its SOA.
Electrical Management Protection: Current
Monitoring battery pack current and cell or module voltages is the road to electrical protection. The electrical SOA of any battery cell is bound by current and voltage. Figure 1 illustrates a typical lithium-ion cell SOA, and a well-designed BMS will protect the pack by preventing operation outside the manufacturer’s cell ratings. In many cases, further derating may be applied to reside within the SOA safe zone to promote further battery lifespan.
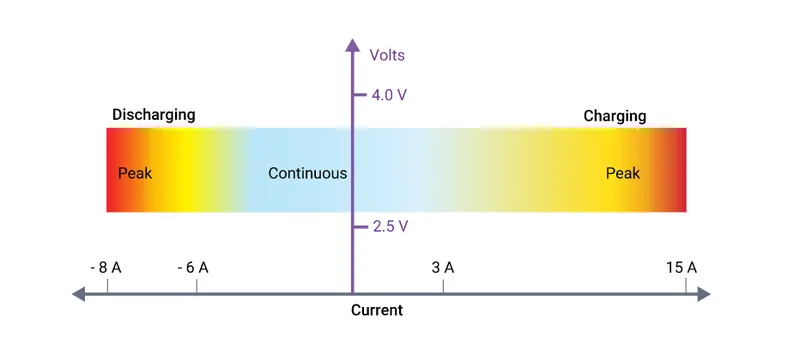
Lithium-ion cells have different current limits for charging than for discharging, and both modes can handle higher peak currents, albeit for short periods. Battery cell manufacturers usually specify maximum continuous charging and discharging current limits and peak charging and discharging current limits. A BMS providing current protection will certainly apply a maximum continuous current. However, this may be preceded to account for a sudden change of load conditions; for example, an electric vehicle’s abrupt acceleration. A BMS may incorporate peak current monitoring by integrating the current and after delta time, deciding to either reduce the available current or interrupt the pack current altogether. This allows the BMS to possess nearly instantaneous sensitivity to extreme current peaks, such as a short-circuit condition that has not caught the attention of any resident fuses, but also be forgiving to high peak demands, as long as they are not excessive for too long.
Electrical Management Protection: Voltage
Figure 2 shows that a lithium-ion cell must operate within a certain voltage range. These SOA boundaries will ultimately be determined by the intrinsic chemistry of the selected lithium-ion cell and the temperature of the cells at any given time. Moreover, since any battery pack experiences a significant amount of current cycling, discharging due to load demands and charging from a variety of energy sources, these SOA voltage limits are usually further constrained to optimize battery lifespan. The BMS must know what these limits are and will command decisions based on the proximity to these thresholds. For example, when approaching the high voltage limit, a BMS may request a gradual reduction of the charging current or may request the charging current be terminated altogether if the limit is reached. However, this limit is usually accompanied by additional intrinsic voltage hysteresis considerations to prevent control chatter about the shutdown threshold. On the other hand, when approaching the low voltage limit, a BMS will request that key active offending loads reduce their current demands. In the case of an electric vehicle, this may be carried out by reducing the allowed torque available to the traction motor. Of course, the BMS must prioritise safety considerations for the driver while protecting the battery pack to prevent permanent damage.
Thermal Management Protection: Temperature
At face value, lithium-ion cells may have a wide temperature operating range, but overall battery capacity diminishes at low temperatures because chemical reaction rates slow down remarkably. Concerning capability at low temperatures, they do perform much better than lead-acid or NiMh batteries; however, temperature management is prudently essential since charging below 0 °C (32 °F) is physically problematic. The phenomenon of plating of metallic lithium can occur on the anode during sub-freezing charging. This is permanent damage and not only results in a reduced capacity, but cells are more vulnerable to failure if subjected to vibration or other stressful conditions. A BMS can control the temperature of the battery pack through heating and cooling.
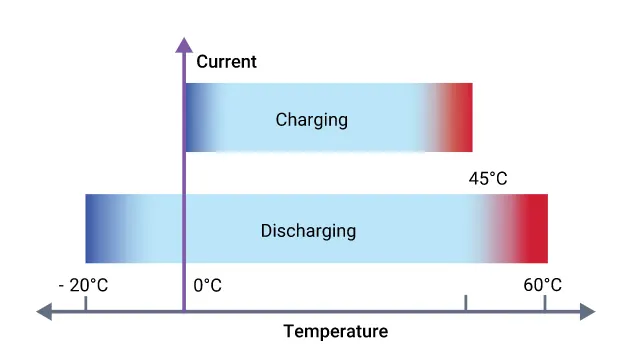
Realized thermal management is entirely dependent upon the size and cost of the battery pack and performance objectives, design criteria of the BMS, and product unit, which may include consideration of targeted geographic region (e.g. Alaska versus Hawaii). Regardless of the heater type, it is generally more effective to draw energy from an external AC power source, or an alternative resident battery purposed to operate the heater when needed. However, if the electric heater has a modest current draw, energy from the primary battery pack can be siphoned to heat itself. If a thermal-hydraulic system is implemented, then an electric heater is used to heat the coolant which is pumped and distributed throughout the pack assembly.
BMS design engineers undoubtedly have tricks of their design trade to trickle heat energy into the pack. For example, various power electronics inside the BMS dedicated to capacity management can be turned on. While not as efficient as direct heating, it can be leveraged regardless. Cooling is particularly vital to minimize the performance loss of a lithium-ion battery pack. For example, perhaps a given battery operates optimally at 20°C; if the pack temperature increases to 30°C, its performance efficiency could be reduced by as much as 20%. If the pack is continuously charged and recharged at 45°C (113°F), the performance loss can rise to a hefty 50%. Battery life can also suffer from premature ageing and degradation if continually exposed to excessive heat generation, particularly during fast charging and discharging cycles. Cooling is usually achieved by two methods, passive or active, and both techniques may be employed. Passive cooling relies on the movement of airflow to cool the battery. In the case of an electric vehicle, this implies that it is simply moving down the road. However, it may be more sophisticated than it appears, as airspeed sensors could be integrated to strategically auto-adjust deflective air dams to maximize airflow. Implementation of an active temperature-controlled fan can help at low speeds or when the vehicle has stopped, but all this can do is merely equalize the pack with the surrounding ambient temperature. In the event of a scorching hot day, this could increase the initial pack temperature. Thermal hydraulic active cooling can be designed as a complementary system and typically utilizes ethylene-glycol coolant with a specified mixture ratio, circulated via an electric motor-driven pump through pipes/hoses, distribution manifolds, a cross-flow heat exchanger (radiator), and cooling plate resident against the battery pack assembly. A BMS monitors the temperatures across the pack and opens and closes various valves to maintain the temperature of the overall battery within a narrow temperature range to ensure optimal battery performance.
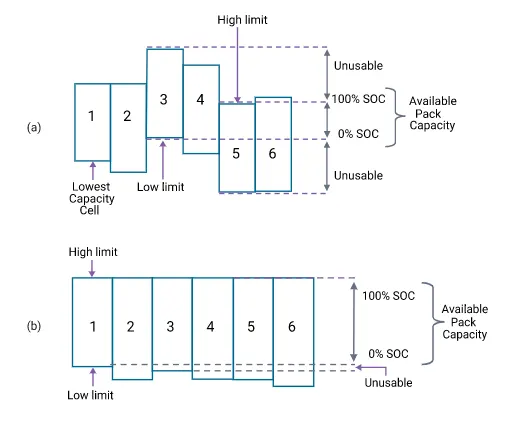
The balancing process endpoints, before and after, are shown in Figure 5. In summary, a BMS balances a battery stack by allowing a cell or module in a stack to see a different charging current than the pack current in one of the following ways:
- Removal of charge from the most charged cells, which gives headroom for additional charging current to prevent overcharging, and allows the less charged cells to receive more charging current
- Redirection of some or nearly all of the charging current around the most charged cells, thereby allowing the less charged cells to receive charging current for a longer length of time.
Capacity Management
Maximizing a battery pack capacity is arguably one of the most vital battery performance features that a BMS provides. If this maintenance is not performed, a battery pack may eventually render itself useless. The root of the issue is that a battery pack “stack” (series array of cells) is not perfectly equal and intrinsically has slightly different leakage or self-discharge rates. Leakage is not a manufacturer defect but a battery chemistry characteristic, though it may be statistically impacted by minute manufacturing process variations. Initially, a battery pack may have well-matched cells, but over time, the cell-to-cell similarity further degrades, not just due to self-discharge, but also impacted by charge/discharge cycling, elevated temperature, and general calendar ageing. With that understood, recall earlier the discussion that lithium-ion cells perform superbly, but can be rather unforgiving if operated outside a tight SOA. We learned previously about required electrical protection because lithium-ion cells do not deal well with over-charging. Once fully charged, they cannot accept any more current, and any additional energy pushed into it gets transmuted in heat, with voltage potentially rising quickly, possibly to dangerous levels. It is not a healthy situation for the cell and can cause permanent damage and unsafe operating conditions if it continues.
The BMS is what steps in and saves the day, or the battery pack in this case. To show how this works, a key definition needs to be explained. The state-of-charge (SOC) of a cell or module at a given time is proportional to the charge available relative to the total charge when fully charged. Thus, a battery that resides at 50% SOC implies it is 50% charged, which is akin to a fuel gauge figure of merit. BMS capacity management is all about balancing the variation of the SOC across each stack in the pack assembly. Since the SOC is not a directly measurable quantity, it can be estimated by various techniques, and the balancing scheme itself generally falls into two main categories, passive and active. There are many variations of themes, and each type has pros and cons. It’s up to the BMS design engineer to decide which is optimal for the given battery pack and its application. Passive balancing is the easiest to implement, as well as to explain the general balancing concept. The passive method allows every cell in the stack to have the same charged capacity as the weakest cell. Using a relatively low current, it shuttles a small amount of energy from high SOC cells during the charging cycle so that all cells charge to their maximum SOC. Figure 4 illustrates how this is accomplished by the BMS. It monitors each cell and leverages a transistor switch and an appropriately sized discharge resistor in parallel with each cell. When the BMS senses a given cell is approaching its charge limit, it will steer excess current around it to the next cell below in a top-down fashion.
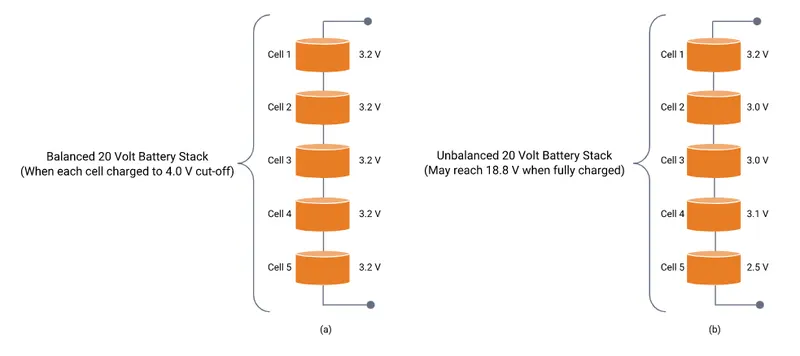
The battery pack series cell array is what determines the overall pack voltage, and the mismatch between adjacent cells creates a dilemma when attempting to charge up any stack. Figure 3 shows why this is so. If one has a perfectly balanced set of cells, all is fine as each will charge up in an equal fashion, and the charging current can be cut off when the upper 4.0 voltage cut-off threshold is reached. However, in the unbalanced scenario, the top cell will reach its charge limit early, and the charging current needs to be terminated for the leg before other underlying cells have been charged to full capacity.
Types of battery management systems
Battery management systems range from simple to complex and can embrace a wide range of different technologies to achieve their prime directive to “take care of the battery.” However, these systems can be categorized based on their topology, which relates to how they are installed and operate upon the cells or modules across the battery pack.
Centralized BMS Architecture
Has one central BMS in the battery pack assembly. All the battery packages are connected to the central BMS directly. The structure of a centralized BMS is shown in Figure 6. The centralized BMS has some advantages. It is more compact, and it tends to be the most economical since there is only one BMS. However, there are disadvantages to a centralized BMS. Since all the batteries are connected to the BMS directly, the BMS needs a lot of ports to connect with all the battery packages. This translates to lots of wires, cabling, connectors, etc. in large battery packs, which complicates both troubleshooting and maintenance.
Modular BMS Topology
Similar to a centralized implementation, the BMS is divided into several duplicated modules, each with a dedicated bundle of wires and connections to an adjacent assigned portion of a battery stack. See Figure 7. In some cases, these BMS submodules may reside under a primary BMS module oversight whose function is to monitor the status of the submodules and communicate with peripheral equipment. Thanks to the duplicated modularity, troubleshooting and maintenance are easier, and extension to larger battery packs is straightforward. The downside is overall costs are slightly higher, and there may be duplicated unused functionality depending on the application.
Primary/Subordinate BMS
Conceptually similar to the modular topology, however, in this case, the slaves are more restricted to just relaying measurement information, and the master is dedicated to computation and control, as well as external communication. So, like the modular types, the costs may be lower since the functionality of the slaves tends to be simpler, with likely less overhead and fewer unused features.
Distributed BMS Architecture
Considerably different from the other topologies, where the electronic hardware and software are encapsulated in modules that interface to the cells via bundles of attached wiring. A distributed BMS incorporates all the electronic hardware on a control board placed directly on the cell or module that is being monitored. This alleviates the bulk of the cabling to a few sensor wires and communication wires between adjacent BMS modules. Consequently, each BMS is more self-contained and handles computations and communications as required. However, despite this apparent simplicity, this integrated form does make troubleshooting and maintenance potentially problematic, as it resides deep inside a shield module assembly. Costs also tend to be higher as there are more BMSs in the overall battery pack structure.
The importance of battery management systems
Functional safety is of the highest importance in a BMS. It is critical during charging and discharging operations, to prevent the voltage, current, and temperature of any cell or module under supervisory control from exceeding defined SOA limits. If limits are exceeded for a length of time, not only is a potentially expensive battery pack compromised, but dangerous thermal runaway conditions could ensue. Moreover, lower voltage threshold limits are also rigorously monitored for the protection of the lithium-ion cells and functional safety. If the Li-ion battery stays in this low-voltage state, copper dendrites could eventually grow on the anode, which can result in elevated self-discharge rates and raise possible safety concerns. The high energy density of lithium-ion powered systems comes at a price that leaves little room for battery management error. Thanks to BMSs, and lithium-ion improvements, this is one of the most successful and safe battery chemistries available today.
The performance of the battery pack is the next highest important feature of a BMS, and this involves electrical and thermal management. To electrically optimize the overall battery capacity, all the cells in the pack are required to be balanced, which implies that the SOC of adjacent cells throughout the assembly are approximately equivalent. This is exceptionally important because not only can optimal battery capacity be realized, but it helps prevent general degradation and reduces potential hotspots from overcharging weak cells. Lithium-ion batteries should avoid discharge below low voltage limits, as this can result in memory effects and significant capacity loss. Electrochemical processes are highly susceptible to temperature, and batteries are no exception. When environmental temperature drops, capacity and available battery energy roll off significantly. Consequently, a BMS may engage an external in-line heater that resides on, say, the liquid cooling system of an electric vehicle battery pack, or turn on resident heater plates that are installed underneath modules of a pack incorporated within a helicopter or other aircraft. Additionally, since charging frigid lithium-ion cells is detrimental to battery life performance, it is important to first elevate the battery temperature sufficiently. Most lithium-ion cells cannot be fast-charged when they are less than 5°C and should not be charged at all when they are below 0°C. For optimum performance during typical operational usage, BMS thermal management often ensures that a battery operates within a narrow Goldilocks region of operation (e.g. 30 – 35°C). This safeguards performance, promotes longer life, and fosters a healthy, reliable battery pack.
The benefits of battery management systems
- Functional Safety. Hands down, for large-format lithium-ion battery packs, this is particularly prudent and essential. But even smaller formats used in, say, laptops, have been known to catch fire and cause enormous damage. The personal safety of users of products that incorporate lithium-ion powered systems leaves little room for battery management error.
- Life Span and Reliability. Battery pack protection management, electrical and thermal, ensures that all the cells are used within declared SOA requirements. This delicate oversight ensures the cells are taken care of against aggressive usage and fast charging and discharging cycling, and inevitably results in a stable system that will potentially provide many years of reliable service.
- Performance and Range. BMS battery pack capacity management, where cell-to-cell balancing is employed to equalize the SOC of adjacent cells across the pack assembly, allows optimum battery capacity to be realized. Without this BMS feature to account for variations in self-discharge, charge/discharge cycling, temperature effects, and general ageing, a battery pack could eventually render itself useless.
- Diagnostics, Data Collection, and External Communication. Oversight tasks include continuous monitoring of all battery cells, where data logging can be used by itself for diagnostics, but is often purposed to the task for computation to estimate the SOC of all cells in the assembly. This information is leveraged for balancing algorithms but collectively can be relayed to external devices and displays to indicate the resident energy available, estimate expected range or range/lifetime based on current usage, and provide the state of health of the battery pack.
- Cost and Warranty Reduction. The introduction of a BMS into a BESS adds costs and battery packs are expensive and potentially hazardous. The more complicated the system, the higher the safety requirements, resulting in the need for more BMS oversight presence. But the protection and preventive maintenance of a BMS regarding functional safety, lifespan and reliability, performance and range, diagnostics, etc. guarantees that it will drive down overall costs, including those related to the warranty.
Learn how to accurately simulate the dynamic behaviour of a single battery cell using Simulink and scale your models all the way to perform system-level simulation of the entire battery pack. Use this dynamic model of the battery pack to design and test algorithms for Battery Management System before generating production-quality C/C++ code and targeting embedded processors.
This example Simulink Project includes:
- Battery Cell Characterization.
- Detailed Battery Pack Plant Model.
- Designing BMS Algorithms.
- Code Generation.
- Verification & Validation (Requirements + Test Cases).
- Hardware-In-Loop Testing of BMS.
The BMS model consists of a BMS ECU (electrical control unit) and a plant. The control unit with its various monitoring and control algorithms is connected to a block with the representation of the battery pack and associated circuitry and peripherals. This model contains two versions of the battery pack: a small one with just 6 cell series, and a larger 16-module pack, each module containing a 6-cell series string. The architecture is 6s-1p and 96s-1p packs, respectively.
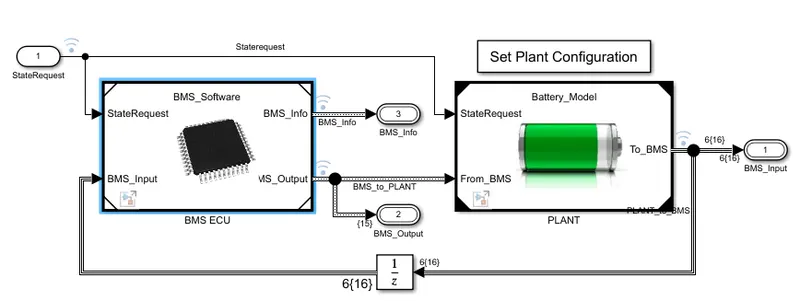
The BMS ECU and its subsystem consist of the state machine.
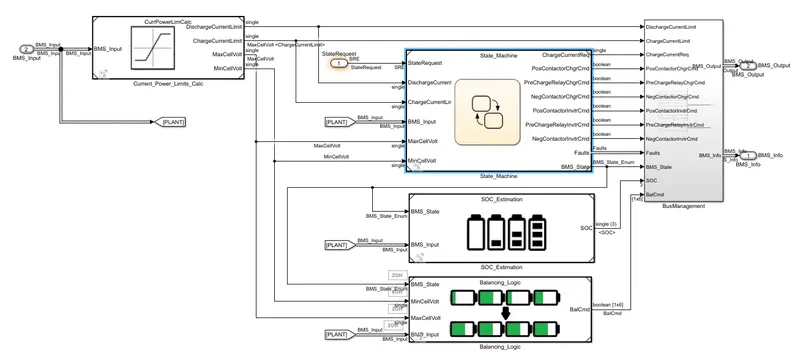
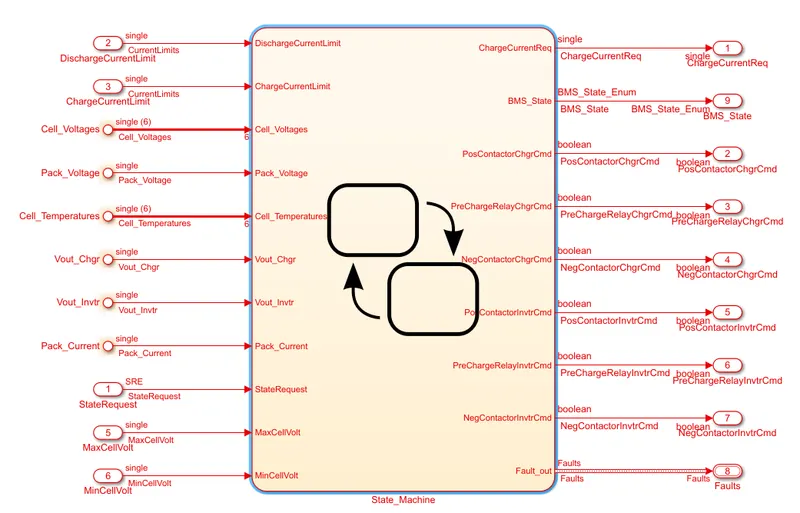
State Machine defines the main operating state of the BMS. The state machine has four parallel states (parallel meaning that they can be active at the same time):
a.) The first one defines the variable BMS_State which indicates standby, driving, charging, and fault. Charging comprises constant current and constant voltage stages.
b.) The second state switches the fault state ON in case a current, voltage, or temperature value reaches an unsafe level.
c.) The third and fourth states define the contactor ON and OFF switching sequence for the charger and inverter. This is needed to avoid an excessively large current inrush at the beginning of the charging stage.
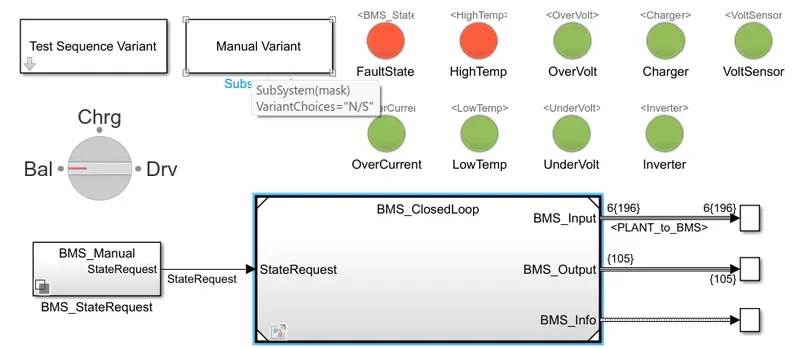
After opening the BMS system we have to go for the harness dashboard. The harness dashboard is shown below. It consists of the test sequence variant subsystem which holds three different test cases. This dashboard also helps in determining the fault states and other parameters as shown in the diagram below. The green colour indicates that the system is working without any errors while the red signal will indicate that there is a fault in the system.
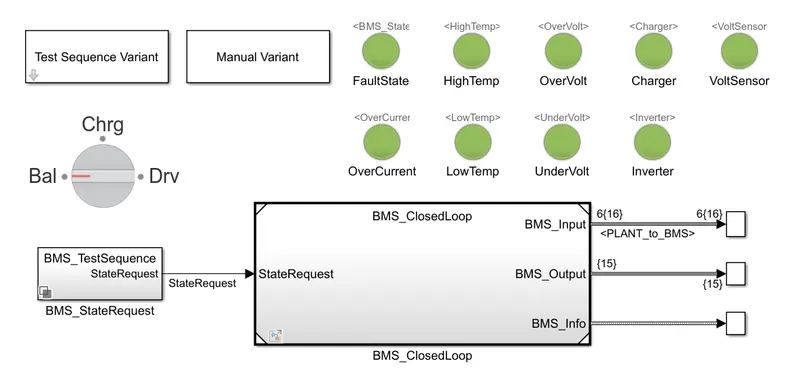
To check the faults in the system we have to go back to the harness dashboard. Here, in the first compilation, test case 1 is selected.
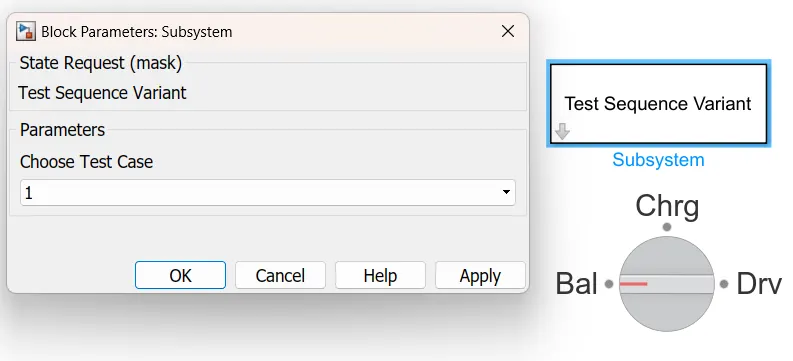
After applying the selected test case1, we have to run the simulation. The dashboard shows there are no errors or faults.
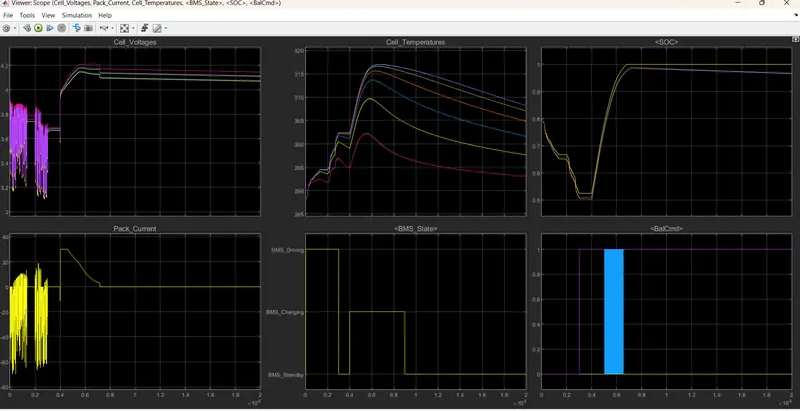
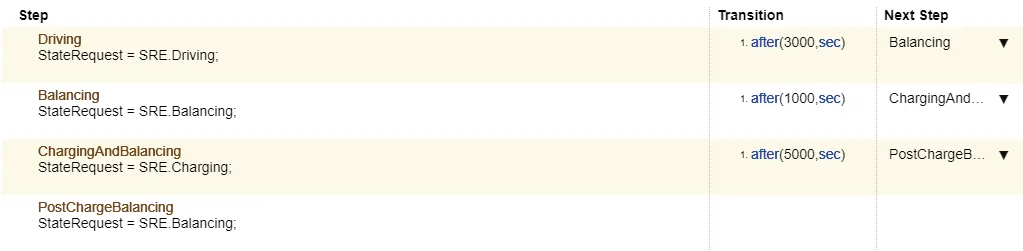
There are three stages of driving condition, namely Driving, Charging and Standby.
When the simulation begins, initially the vehicle is in a driving state and the SOC will decrease for this time period. After a time period of 3000 seconds the next step is balancing mode and the vehicle is in standby condition. After, another 1000 seconds, the vehicle is in the charging phase and the battery's SOC increases almost to 100%. The next phase is the post-charging phase in which the vehicle again goes into standby mode.
Fault in MATLAB BMS_Closeloop Model
The Model represents a rough idea of how the BMS reacts and gives the user an idea of any fault occurring in the Battery Pack, if any. The model here allows the user to know the error by glowing the RED Light on the dashboard.
The various defects that can occur are
- Fault State
- over current
- High temperature
- low temperature
- over voltage
- under voltage
- charger
- inverter
- Volt Sensor
- In the 1st test sequence case the is no fault in the system model. All GREEN lights on the dashboard.
- The input cycle can be seen in the 5th graph in which the vehicle initially undergoes driving, then charging till SOC= 90% and then later in the standby state.
- During Charging The Battery pack voltage is increased up to 4V.
- The cell temperature increases during the driving and charging cycle.
- The SOC drops to less than 50% after the driving cycle and then later put into charging until SOC Reaches 90%.
- The Current supplied to the EV during the driving phase can be seen in the current graph.
Test Sequence2
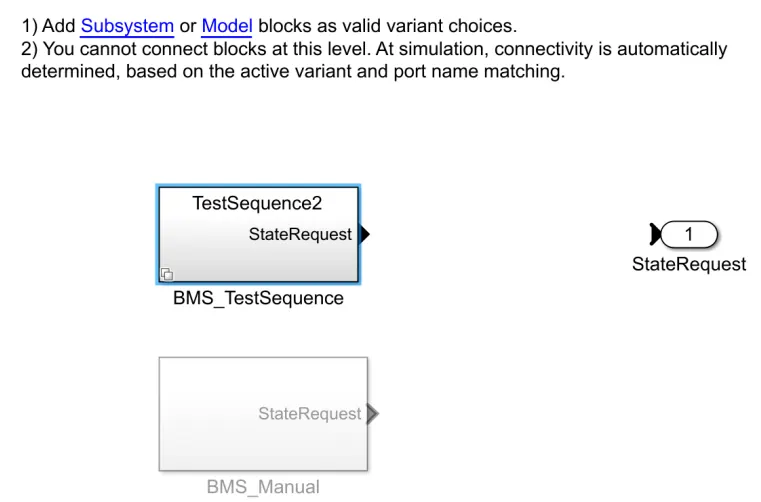
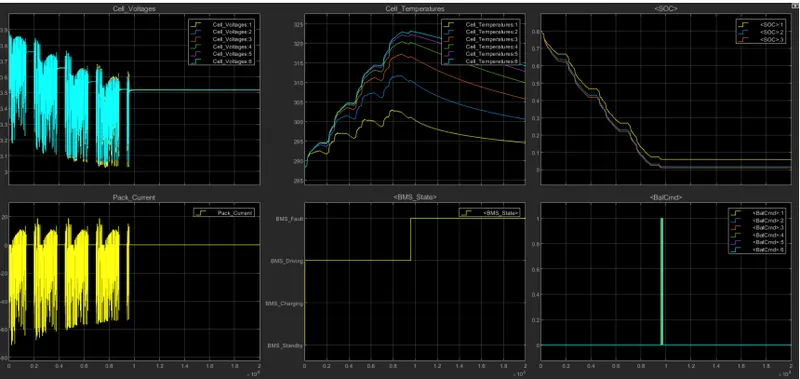
Now, we will go for the second test case. For this we have to go to test case variant subsystem and select test case 2 from there and click on "Ok". Then we have to run the system for the given simulation time. The result shows that there is a fault condition in the vehicle. The dashboard on the model depicts the same with a red colour indication.
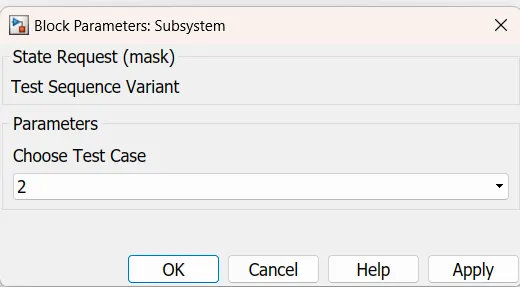
This test case has two Phases for the battery pack, i.e., Driving and Charging phases.
The Result shows that there is a fault condition in the vehicle. The dashboard on the model depicts the same with a red colour indication.
After 10,000 sec when the driving cycle is over, during the charging and balancing phase the fault condition occurs.
- During the initial phase i.e. the driving mode, the voltage at the start of driving was around 4V, after which the voltage steadily drops and reaches around 3.5 V at 10,000 sec. At the same time, the BMS_ Stage is changed to a fault condition. The SOC has also dropped down to 0% after the driving mode.
- The fault that occurred in the system is due to HIGH TEMPERATURE. The dashboard on the model depicts the same with a red colour indication.
This fault might have occurred due to improper use of the battery pack to drive the EV or due to over usage of the battery pack for 10,000 sec which is more than 2.5 hr of continuous use.
Test Sequence 3
The last test is for the third test sequence. For this, we have to go to test case variant susbystem and select test case 3 from there and click on "Ok".
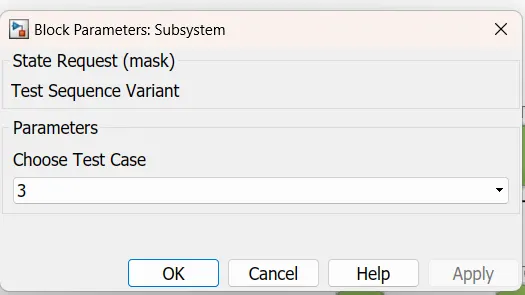
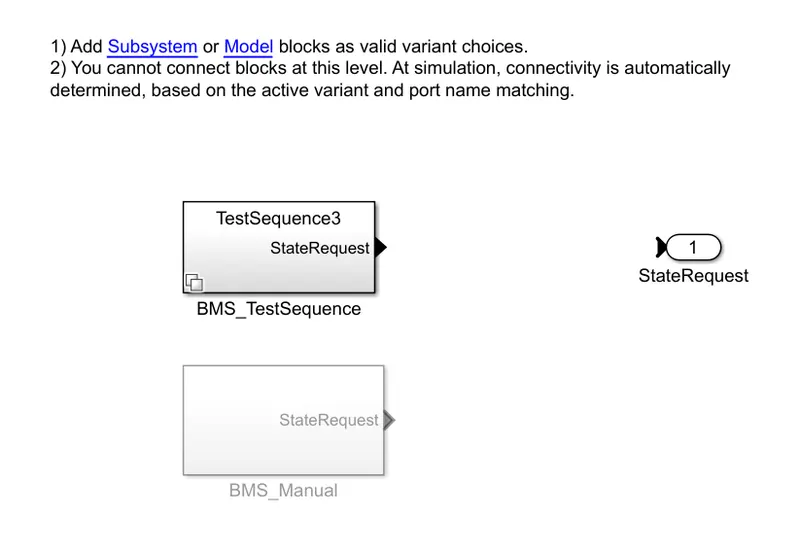
After applying the selected test case, we have to run the simulation. The dashboard shows there are no errors and faults.
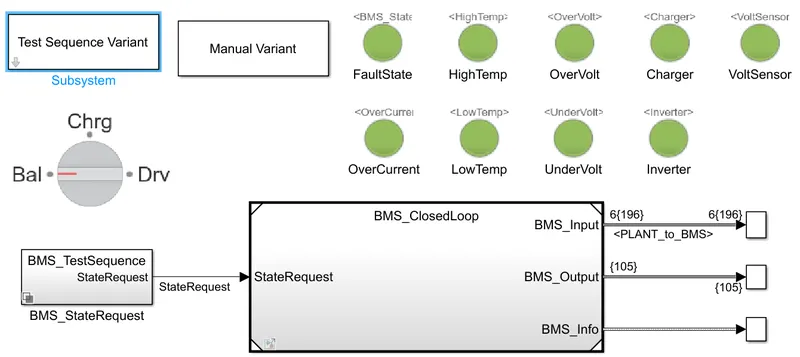
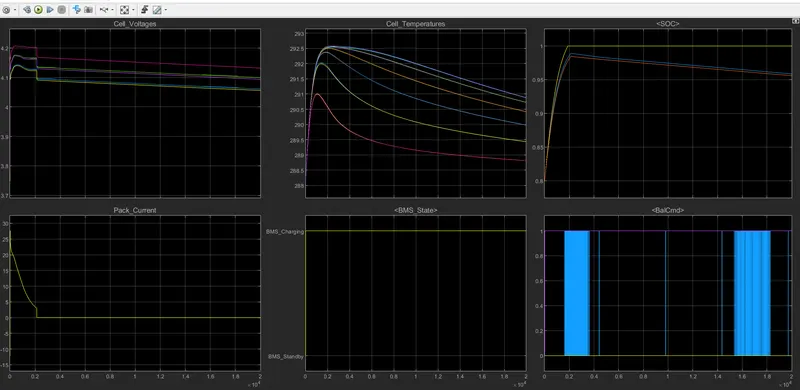
There is only a single phase here for the third test case, i.e. the charging phase.
The scope shows the results for the third test case. Here the SOC increases from 80 to 100% and then remains in standby mode.
==========================================================================
2.SOC Estimation by Coulomb Counting
SoC Estimation by Coulomb Counting is based on the measurement of the current and integration of that current over time.
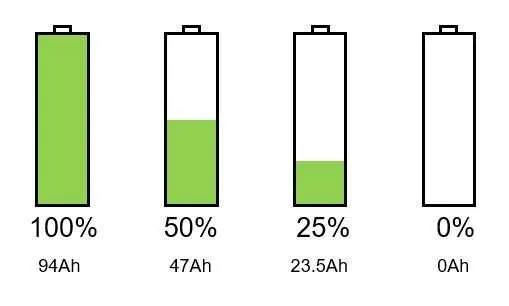
The State of Charge (SoC) of a battery cell is required to maintain it’s safe operation and lifetime during charge, discharge and storage. However, SoC cannot be measured directly and is estimated from other measurements and known parameters. This leads to errors in the estimated SoC and that means it is not possible to fully exploit the full capability of the cell.
Coulomb counting gives a relative change in SoC and not an absolute SoC. If you measure the current over a given time step you have a measure of the number of Ah that have left or been received by the battery.
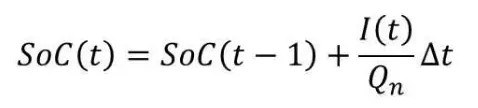
where:
- SoC(t) = estimated State of Charge at time, t
- SoC(t-1) = previous State of Charge at time t-1
- I(t) = charging or discharging current at time, t
- Qn = battery cell capacity
- Δt = time step between t-1 and t
If you want to know the absolute SoC you need to know the starting SoC of the cell, SoC(t-1) as given in the equation. One option is to fully charge the cell to a known voltage. Charging to maximum cell voltage and SoC can be used as a reset and known point.
There are a number of sources of error with the coulomb counting method:
- Starting SoC accuracy
- Current measurement accuracy
- Current integration error
- Uncertainty in battery capacity
- Timing error
In order to define the accuracy you need it is important that you firstly look at what the SoC is used for.
- capacity of the cell that is remaining (fuel gauge on your phone or electric vehicle)
- an input to estimate the available charge and discharge power capability of the battery
- used in the calculation of State of Health
The accuracy required for these values will determine the accuracy that is required for the inputs to the SoC algorithm. This will impact the selection of:
- components for cell voltage measurement
- voltage sense wires, connectors and connection locations
- current sensor or sensors
- voltage and current measurement channel accuracy
- timing circuit
Simulink model for SOC Estimation if Difined Below.
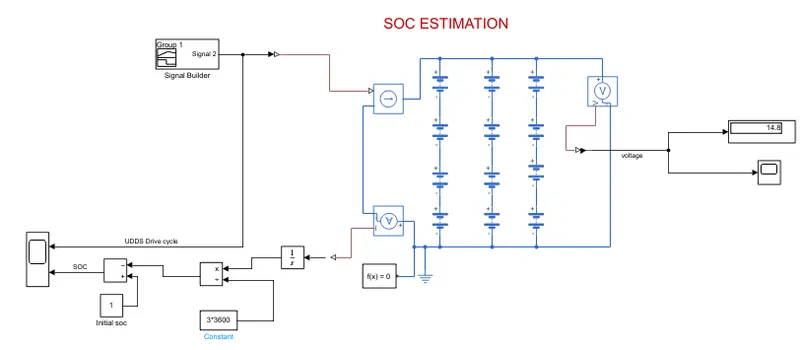
Simulink model for estimation of SOC is mension above.
Explanation
- We are taken here 4S3P(12 cells connected in parellel and series) model for ous experiment.
- Battery parameters set as per the datasheet.
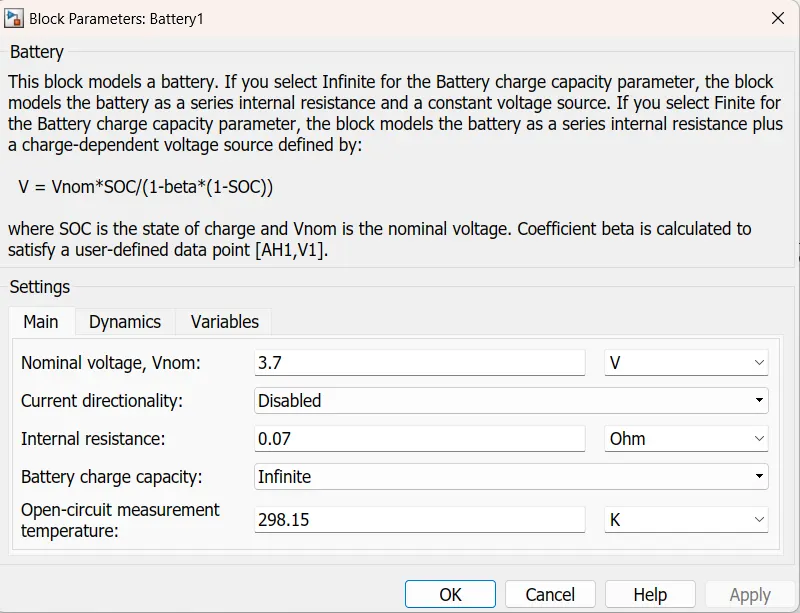
- In columb counting method of finding SOC we are going to intigrate the instanteneous current.
- Above we mension the equation for SOC Estimation.
-
Controlled current source The block represents an ideal current source that is powerful enough to maintain the specified current through it regardless of the voltage across it.
- Input for controlled current source is given from signal builder block.
- Signal builder block create signal from UDDS Drive cycle.
- Voltage sensor block used to sence voltage of pack and the display it in display block.
- Current sensor block sence the current of batttery pack.
- Instanteneous current is integrated and devide with pack SOC.
- Resultant is substracted from initial SOC.
Results
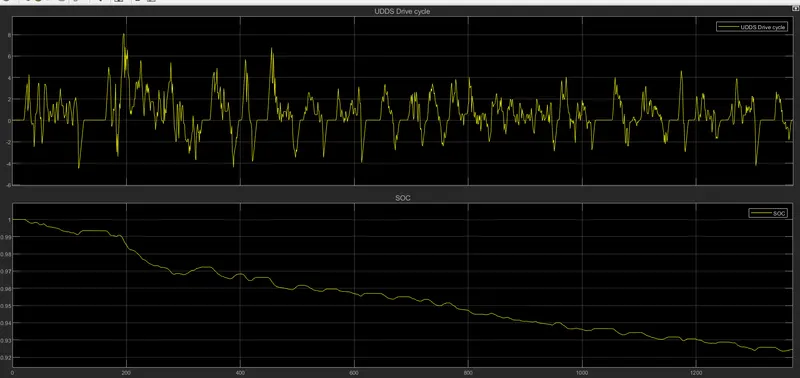
- Drive Cycle is shown in the above graph.
- SOC of battery back is decreases from 100% to 92.35% in 1370 sec.
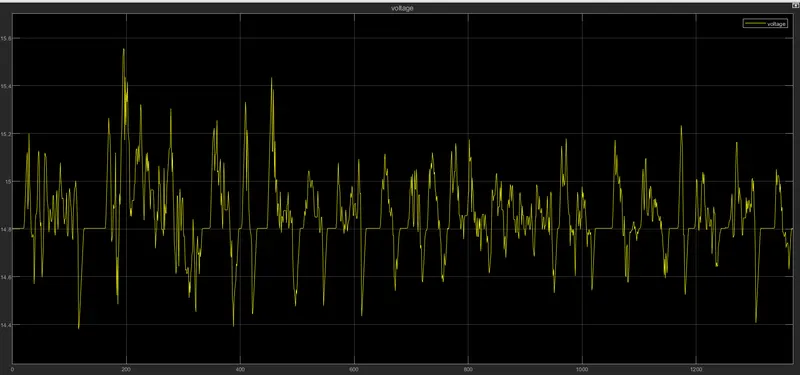
- Pack voltage is max 15.56 volt and minimum is 14.38 volt as per drive cycle current.
- Average PAck current of 4 series connection is 14.8 volt is shown in display block.
Conclusion
- In State request 1 There are three stages of driving condition, namely,Driving,Charging,Standby.
- Second test case has two Phases for the battery pack, i.e., Driving and Charging phases.
- Third test case has only one e, i.e. the charging phase.
- SOC estimation model run for UDDS drive cycle and we got the result of decreasing SOC from 100% to 92.35% after 1370 sec.