Week-7 Challenge: DC Motor Control
1. A. An H-bridge is a simple circuit that controls a DC motor to go backward or forward.
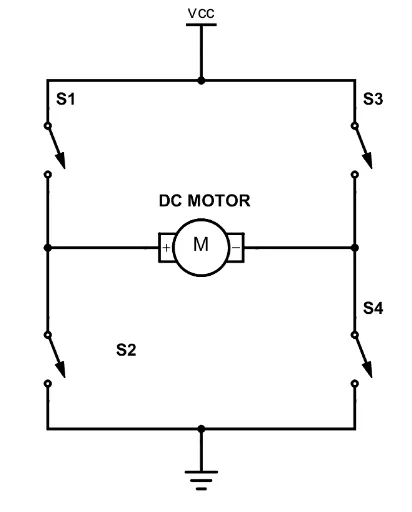
A DC motor spins either backward or forward, depending on how it is connected to the plus and the minus.
If you close switch 1 and 4, you have plus connected to the left side of the motor and minus to the other side. And the motor will start spinning in one direction.
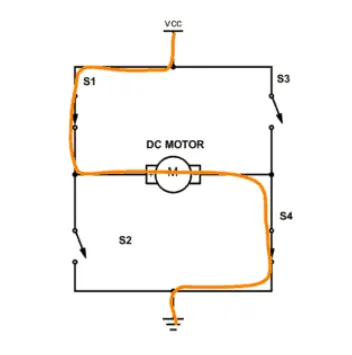
If you instead close switch 2 and 3, you have plus connected to the right side and minus to the left side. And the motor spins in the opposite direction.
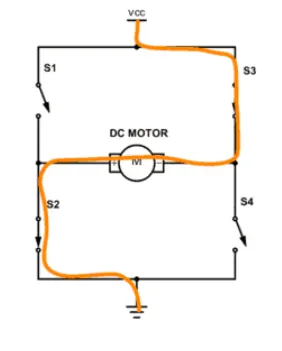
The circuit replaces the switches with NPN type transistors. Diodes are given for the current to free wheel as the DC motor is a RLE load where the current cannot change direction instantaneously.We all know that transistor works as switch. For NPN transistor if we give enough +Ve input to base it will turn ON and if we give 0 input it will be turned OFF. So in this circuit if Q1 and Q4 are turned ON simultaneously the motor will rotate forward and if Q2 and Q3 are turned ON then motor will rotate in reverse direction.
In order to vary the speed of the DC motor, We have to change the voltage applied to the DC motor. This could be achieved with the help of Pulse width modulation.
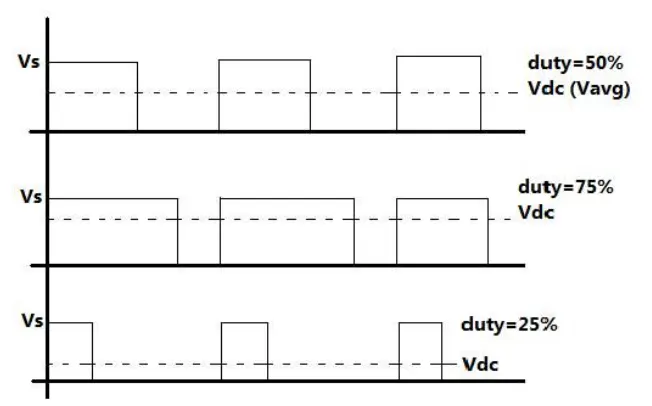
The voltage depends on the duty cycle, if duty is 50% the average output voltage Vdc is exactly the half of Vs. If duty is increased to 75%, Vdc also increases to 3/4th of Vs and if duty is decreased to 25%, Vdc reduces to 1/4th of Vs. Thus as pulse width varies the average output voltage varies. So we have to apply PWM to DC motor to vary its speed.
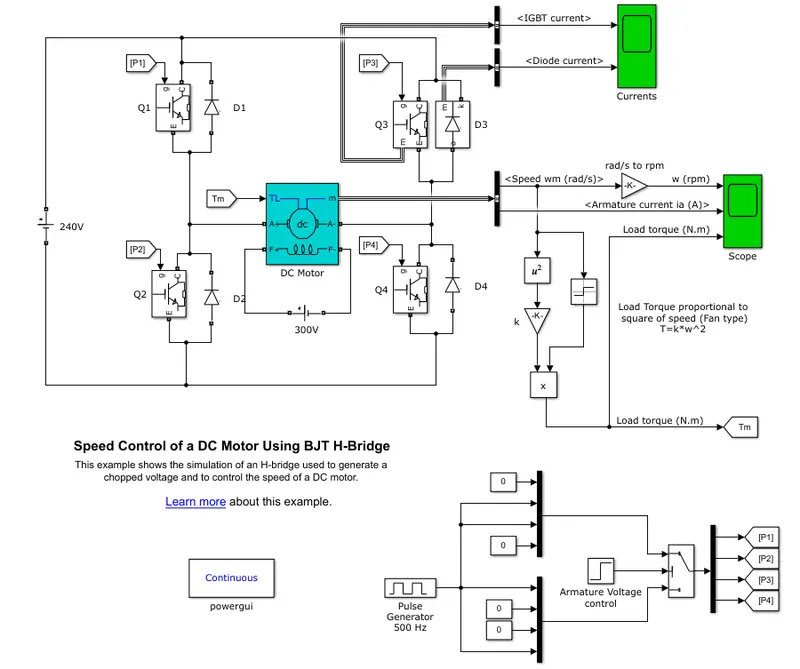
In the simulink model, we use Bipolar junction transistor for the switching application. The gate of the BJT is controlled by the pulse generator block within the simulink model, where the duty cycle and the applied voltage can be varied.
Load torque is proportional to the square of the speed and is generated by multiplying the constant with speed.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
1.B. Comment on the armature current shoot-up from the scope results.
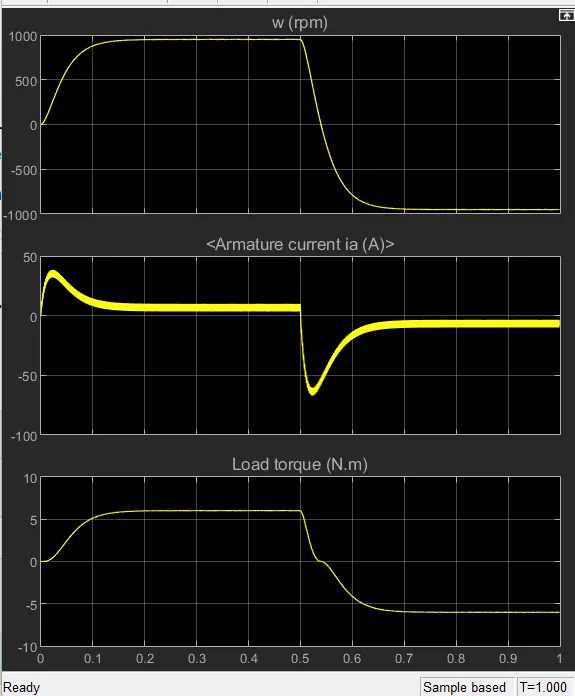
With default parameters, keeping the duty cycle as 75%, when the duty cycle is high and Vdc also increases to 3/4th of Vs which results in sudden spike in armature current.
Changing the duty cycle to 50%, the average output voltage Vdc is exactly the half of Vs and the spike in armature current is reduced.
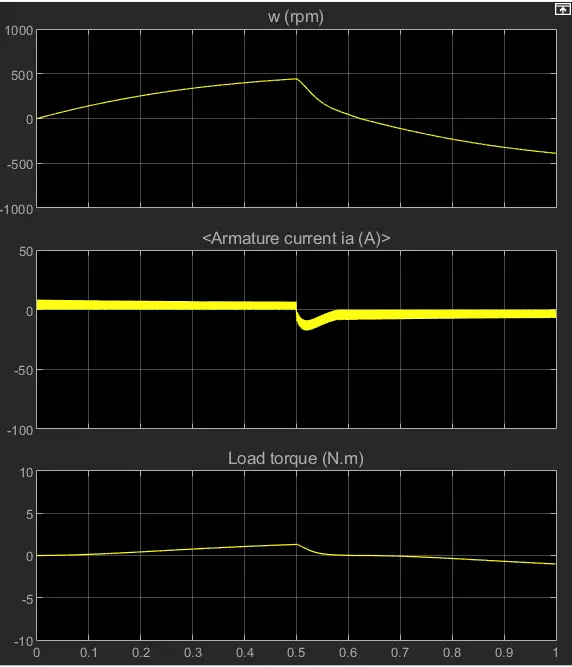
We can conclude, the spike in armature current can be reduced by decreasing the duty cycle.
1.C.Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
| H bridge | Four Quadrant chopper DC drive |
| Only Two quadrants of operation are possible. They are Forward motoring and reverse motoring | It can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration) |
| Higher armature current ripple. | Lower armature current ripple due to high switching frequency of DC-DC coverters |
| Less complex | More complex |
| Simulation is continuous and simulation time is more | Discrete and Simulation time is less |
| Widely Used in Robotics | Widely used in Automobile |
2. Two Quandrant Chopper Operation
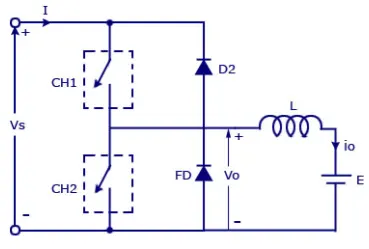
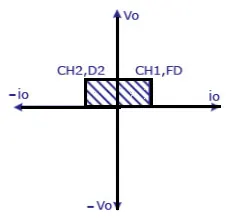
The above model is the model of Type Chopper(Type A Two Quadrant Chopper). In this type of Chopper, the average voltage will be always positive but the average load current might be positive or negative. The two Switches CH1 and CH2 should not be turned on simultaneously as the combined action may cause a short circuit in supply lines. For regenerative braking and motoring these type of chopper configuration is used.
We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper CH1 is on the current flows from source to load. The inductor stores energy. When Ch1 turn OFF the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs. The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source. The load current will be negative when the CH2 is on. The current completes its path through diode D2.
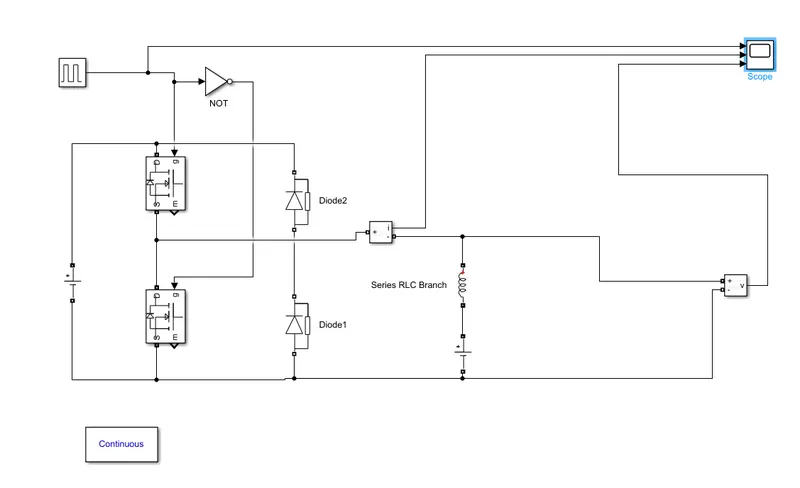
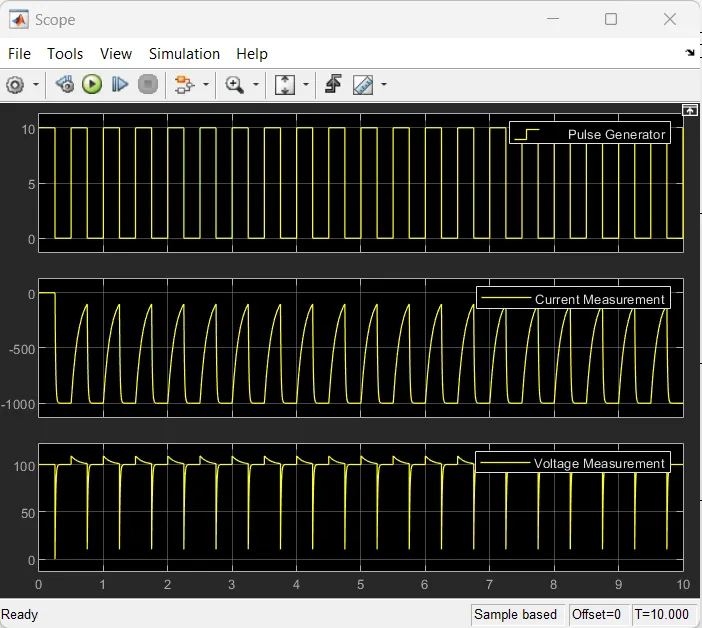
From the output, we can observe voltage is always positive, and current is negative.
3. Operation of BLDC Motor
A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and it accomplishes electronically controlled commutation system (commutation is the process of producing rotational torque in the motor by changing phase currents through it at appropriate times) instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors.
Construction of Brushless DC motor
In this motor, the permanent magnets attach to the rotor. The current-carrying conductors or armature windings are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy.
The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit. A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
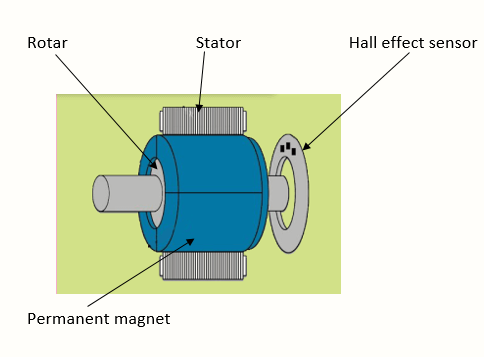
Brushless motor does not have any current carrying commutators. The field inside a brushless motor is switched through an amplifier which is triggered by the commutating device like an optical encoder.
The layout of a DC brushless motor can vary depending on whether it is in “Out runner” style or “Inrunner” style.
-
Outrunner – The field magnet is a drum rotor which rotates around the stator. This style is preferred for applications that require high torque and where high rpm isn’t a requirement.
-
In runner – The stator is a fixed drum in which the field magnet rotates. This motor is known for producing less torque than the out runner style, but is capable of spinning at very high rpm.
Working Principle of Brushless DC motor
BLDC motor works on the principle similar to that of a brushed DC motor. The Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current carrying conductor is stationary and the permanent magnet is moving.
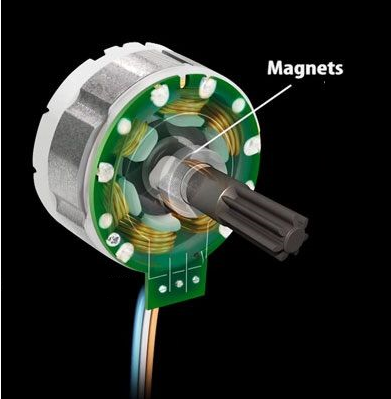
When the stator coils get a supply from source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles which causes the motor to rotate.